TRANSFER FUNCTION
Target:-
- Autonomous Driving System
- Derive transfer function of a mass, spring and damper
- derive a transfer function of an electrical system.
Objective:-
- How hybrid electric cars can be operated more efficiently by autonomous driving systems?
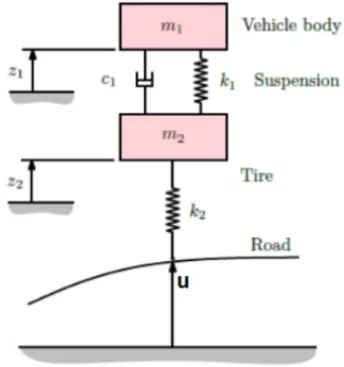
a.) Derive the transfer function of the suspension system shown
b.) Convert the transfer function to state-space format.
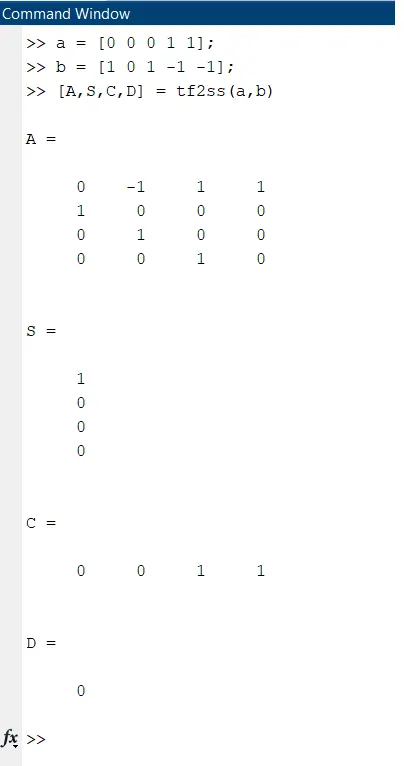
c.) Perform the same in MATLAB using suitable commands.
- Derive the transfer functions of RC(output across C) and CR (output across R) circuits. Are they equal?
Theory:-
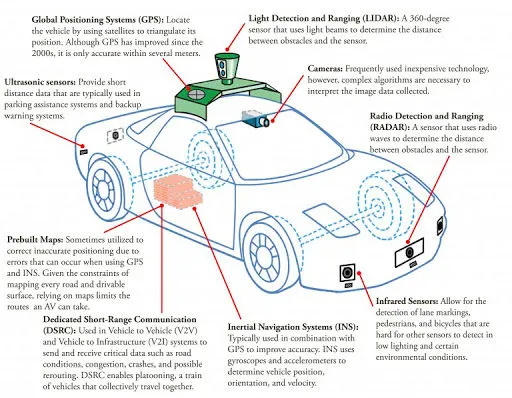
Autonomous Driving System hybrid vehicles are the future of the modern automobile industries and making them autonomous is taking this vehicle to a different level making them autonomous is really difficult task and is also an expensive method for making them autonomous we required a lot of devices and those are
- GPS
- LIDAR
- RADAR
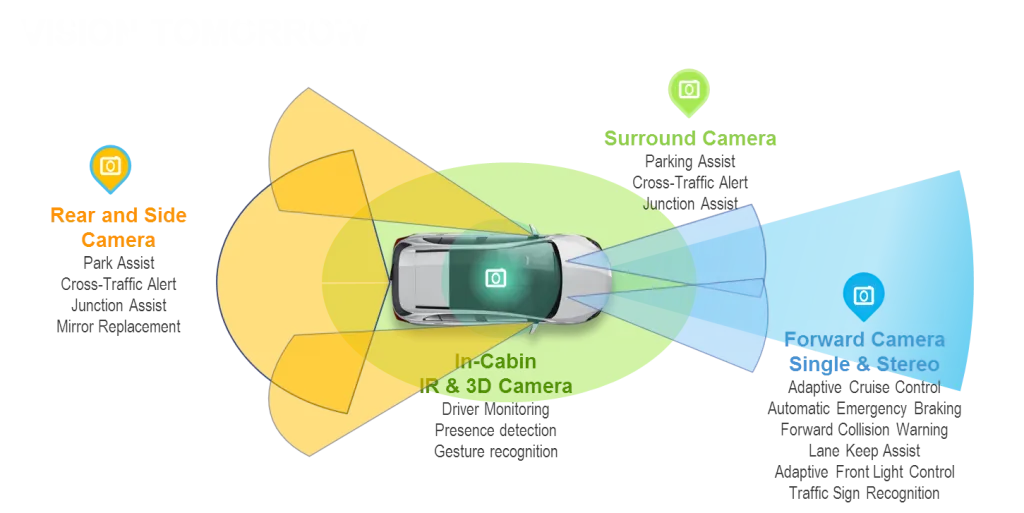
- Video Cameras
- Central Computers
Let us first discuss the first autonomous component GPS which stands for Global Positioning System. The GPS receiver calculates its own position and time based on data received from multiple GPS Satellite. Each satellite carries an accurate record of its position and time and transmits that data to the receiver. The GPS satellites carry very stable atomic clocks that are synchronized with other satellites and with ground clocks. Any drift from time maintained on the ground is corrected daily. In the same manner, the satellite locations are known with great precision. GPS receivers have clocks as well, but they are less stable and less precise.
Let us now discuss the LIDAR which stands for Light Detection And Ranging this device is bulky devices compare to the other autonomous devices. Hybrid Vehicles may use LiDAR for obstacle detection and avoidance to navigate safely through environments. Point cloud output from the lidar sensor provides the necessary data for robot software to determine where potential obstacles exist in the environment and where the robot is concerning those potential obstacles. Singapore's Singapore-MIT Alliance for Research and Technology (SMART) is actively developing technologies for autonomous lidar vehicles. Lidar simulation models are also provided in autonomous car simulators.
Now comes the RADAR in the autonomous Devices Which stands for Radio Detection And Ranging RADAR has been used in automotive for decades and can determine the velocity, range and angle of objects. It is computationally lighter than other sensor technologies and can work in almost all environmental conditions. Long-Range Radar (LRR) is the defacto sensor used in Adaptive Cruise Control (ACC) and highway Automatic Emergency Braking Systems (AEBS). Currently deployed systems have limitations and do not react correctly to certain conditions, such as a car cutting in front of your vehicle, detecting thin profile vehicles such as motorcycles being staggered in a lane and set distance based on the wrong vehicle due to the curvature of the road. To overcome the limitations. a radar sensor could be paired with a camera sensor in the vehicle to provide additional context to the detection and to avoid the error which is present in this autonomous device
Video Cameras are also part of the autonomous devices as modern vehicles use them for better sign identification this all camera is powerful and also know the traffic signals and if the person is moving in ar any vehicle is moving or not. The camera sensor technology and resolution play a very large role in the capabilities. Cameras, similar to the human eye, are susceptible to adverse weather conditions and variations in lighting. But cameras are the only sensor technology that can capture texture, colour and contrast information and the high level of detail captured by cameras allow them to be the leading technology for classification. These features, combined with the ever-increasing pixel resolution and the low-price point, make camera sensors indispensable and volume leader for ADAS and Autonomous systems.
The Central computers are the brain of the Autonomous System and these are the devices that control all devices and take control over the vehicle and records everything in the network of the vehicles. it takes the autopilot under the supervision of the driver. it takes care of all the ignition system in the vehicles and when autopilot is enabled your car to steer, accelerate and brake automatically within its lane. Current Autopilot features require active driver supervision and do not make the vehicle autonomous. Navigate on Autopilot suggests lane changes to optimize your route, and makes adjustments so you don’t get stuck behind slow cars
- From the above model the for two transfer function equation which is below-
- The transfer function
`M_1 ddotZ_1 = K_1(Z_2-Z_1) + C_1(dotZ_2 -dotZ_1)` --------------------------Equation 1 And `M_2ddotZ_2 = K_2(U-Z_2) -K_1(Z_2-Z_1) - C_1(dotZ_2 -dotZ_1)` --------------------------Equation 2 Considering all the initial condition being zero and then applying Laplce's transform to the above equations from Equation 1 `M_1 (d^2 Z_1(t))/dt = K_1(Z_2 -Z_1) + C_1[(d Z_2(t))/dt - (d Z_1(t))/dt]` Or, `M_1S^2Z_1(S) = K_1(Z_2- Z_1) + C_1 [SZ_2(S) - SZ_1(S)]` Or, `M_1S^2Z_1(S) = K_1(Z_2- Z_1) + S*C_1 [Z_2(S) - Z_1(S)]` Or, `Z_1(s) [M_1S^2 + C_1s + K_1] = Z_2(S)[Z_2(S)- Z_1(S)]` Or, `Z_2(s) = Z_1(S) (M_1S^2 +C_1S+ K_1)/(C_1S +K_1)` -----------------------Equation 3 From Equation 2 `M_2 (d^2 Z_2(t))/dt = K_2(U -Z_2) - K_1(Z_2-Z_1) + C_1[(d Z_2(t))/dt - (d Z_1(t))/dt]` Or, `M_2S^2Z_1(S) = K_2U(S) - K_2Z_2(S)- K_1(Z_2(S) - Z_1(S)) - C_1S(Z_2(S)-Z_1(S))` Or, `Z_2(S) (M_2S^2 + K_2 + K_1 +C_1S) = U(S)K_2 + Z_1(S)(K_1+C_1S)` Or, `Z_2(S) (M_2S^2 + K_2 + K_1 +C_1S) - Z_1(S)(K_1+C_1S) = U(S)K_2` ----------------------Equation 4 Let us only take the LHS of the Equaion 4 From Equation 4 `Z_2(S) (M_2S^2 + K_2 + K_1 +C_1S) - Z_1(S)(K_1+C_1S)` Puting 3 in 4 `[Z_1(S) (M_1S^2 +C_1S+ K_1)/(C_1S +K_1)](M_2S^2 + K_2 + K_1 +C_1S) - Z_1(S)(K_1+C_1S)` `Z_1(S) [(M_1M_2S^4 +M_1K_1S^2 +M_1K_2S^2 +M_1C_1S^3 +M_2C_1S^3+C_1K_2(S)C_1K_1(S)+C_1^2S^2 +M_2K_1S^2 + K_1K_2 +K_1C_1S - (K_!-C_1S)^2)/(K_1-C_1S)]` `(Z_1(S))/(U(S)) = (C_1S^2 + (K_1 +K_2C_1)S + K_1K_2)/(M_1M_2S^4 +(M_1+M_1C_1+M_2C_1)S^3+(M_1K_2+M_1K_1+C_1C_2+M_2K_1)S^2 +(K_1+C_1K_2)S+K_1K_2)` -
State-space format
Converting the above equation into the differential equation Neumerator ---> `C_1ddotY + (K_1+ K_2C_1)dotY +K_1K_2Y` Denomenetor ---> `M_1M_2ddot(ddotY) + (M_1+M_1C_1+M-2C_1)dot(ddotY) + (M_1K_2 +M_1K_1 +C_1C-2+M_2K_1)ddotY +(K_1+C_1K_2)dotY + K_1K_2Y` By Assuming `X_1 = Y` `X_2 = dotY = dotX_1` `X_3 = ddotY = dotX_2` `X_4 = dot(ddotY) = dotX_3` `X_5 = ddot(ddotY) = dotX_4` Or, `U = M_1M_2dotX_4 +(M_1+ M_1C-1 +M_2C_1)X_4 +(M_1K_2 +M_1K_1 +C_1C_2 +M_2K_1)X_3+(K_1 +C_1K_2)X_2 +K_1K_2X_1` Or, `M_1M_2dotX_4 = U - (M_1+M_1C_1 +M_2C_1)X_4 -(M_1K_2+M_1K_1+ C_1C_2+M_2K_1)X_3 -(K_1+C_1K_2)X_2- K_1K_2X_1` Or, `dotX_4 = 1/(M_1M_2)[ (-M_1+M_1C_1 +M_2C_1)X_4 -(M_1K_2+M_1K_1+ C_1C_2+M_2K_1)X_3 -(K_1+C_1K_2)X_2- K_1K_2X_1] + 1/(M_1M_2)*U` Now I have to do the state space representation for the above differential equation in the form of `dotq(t) = Aq(t) + BU(t)` Or, `[[dotX_4],[dotX_3],[dotX_2],[dotX_1]] = [[-(-M_1-M_2)/(M_1M_2)-(M_2K_1+M_1K_1 +M_1K_2)/(M_1M_2) (C_1K_2)/(M_1M_2) (K_1K_2)/(M-1M_2)], [1 0 0 0], [0 1 0 0], [0 0 1 0] ]* [[X_4],[X_3],[X_2],[X_1]] + [[1/(M_1M_2)],[0],[0],[0]]*U` Output :- `Z = [0 ,0 ,C_1K_1 ,K_1K_2] [[X_4],[X_3],[X_2],[X_1]]` - Solutions
- The transfer function
- The transfer function of the electrical RC circuit with the Two conditions is
- The transfer function of the RC circuit around C is below:-
By applying KVL i.e, kickoffs Voltage Law `V_i(t) = V_r +V_c` `V_i(t)= I(t) + V _o` Applying Laplash Transformation Equation Or, `V_i(S) = RCS V_o(s) + V_o(S)` Or, `V_i(S) = [RCS +1] V_o(S)` `:.` `(V_o(S))/(V_i(s)) = 1/(1+RCS)` 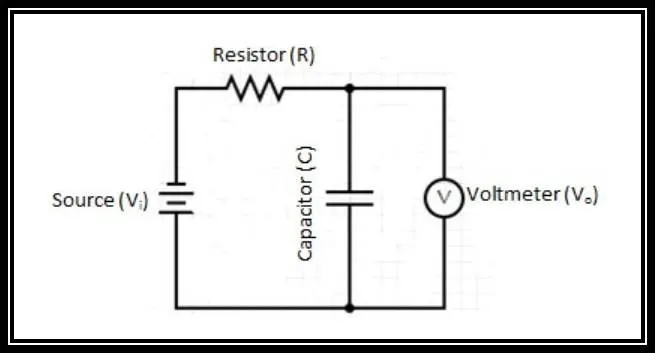
- The Transfer Function of the RC circuit around R is below:-
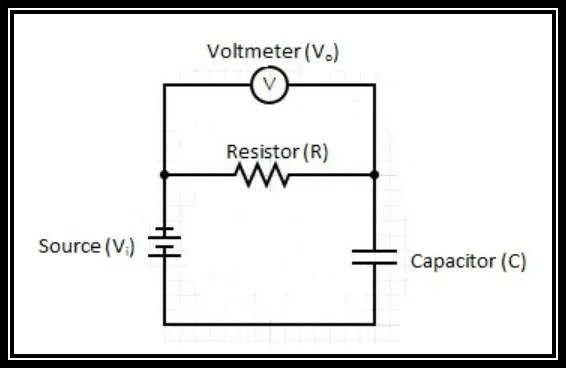
Let us assume that the current is flowing in the anti-clockwise direction
Applying the KVL i.e, Krichoffs Voltage Law
`V_i(t) = R_i(t) + 1/C i(t)dt` ---Eq 1 `V_o(t) = R_i(t)` ---Eq 2 Applying the Laplash Transformation Equation `V_i(s) = RI(s) + 1/(CS) I(S)` Or, `V_o(S) = RI(S)` Or, `I(S) = (V_o(S) )/ R` Or, `V_i(S) = V_o(S) + 1/(CS) * (V_o(S))/R` Or `V_i(S) = (RCS+1)/(RCS) V_o(S)` `(V_o(S))/(V_i(S)) = (RCS)/(RCS +1)`
- The transfer function of the RC circuit around C is below:-
Solution:-
- Theory.
- Theory.
- Theory.
- Theory.
- below is the process for the MATLAB operation:-
- expand the command prompt.
- type the required transfer function.
- change the transfer function to the state-space model by typing the command "tf2ss".
- press the enter.
- check for the error.
Observation:-
2.C)
 |
Conclusion:-
- We all know that there are few disadvantages of autonomous vehicles due to the bulkiness of the devices used in that but in the coming time we will overcome that much
- we got to find the method to convert the physical model of the spring, mass, damper and then converting into the transfer function, then converting into the state-space model.
- From above we have concluded that both the transfer functions are different in both the terms in accordance to the C and R.
Reference:-
https://skill-lync.com/knowledgebase/derivation-of-transfer-function-of-a-suspension-system-and-converting-into-a-state-space-format