DC-DC Converter
Target:-
- Explanation of certain terms.
- Use Tune compensator for DC Motor
- Explanation of S-plane
Objective:-
- .
- Explain the following terms and note down their mathematical formulae.
- Rise time
- Settling time
- Peak overshoot
- Steady-state error
- Tune a compensator for DC Motor Using Bode Diagram Graphical Tuning. The transfer function is given as-
`G = 1.5 / (s^2 + 14s + 40.02)`
Meet the following specifications - Rise time less than 0.5 seconds, Steady-state error of less than 5%, Overshoot of less than 10%, Gain margin greater than 20 dB, Phase margin greater than 40 degrees.
- Explain the following terms and note down their mathematical formulae.
- Can a system with a pole on the right half of the s-plane be stable? Justify your answer with an example.
- Use the following link of Synchronous Buck Converter to solve the following questions:
- https://www.mathworks.com/help/physmod/sps/ug/synchronous-buck-converter.html;jsessionid=d329b9b7f786706ee82e2b490282
- Simulate the default values and comment on the results concerning the stability of the system.
- Change the reference voltage and comment on whether it is tracking the reference voltage or not.
- Change the PI gain values and comment on the stability of the system w.r.t. new values.
- Change the switching frequency and comment on the stability of the system w.r.t. new values.
- https://www.mathworks.com/help/physmod/sps/ug/synchronous-buck-converter.html;jsessionid=d329b9b7f786706ee82e2b490282
Theory:-
- .
a. Rise Time (`t_r`):- Rise Time is defined as the time for the waveform to go from 0.1 to 0.9 of its final value. Rise time is found for the difference in time at c(t) = 0.9 and c(t) = 0.1 . `:.` `t_r = (pi - theta)/omega_d` b. Settling Time (`t_s`):- Settling Time is the time required for the response to reach the steady-state and stay within the specified tolerance bands around the final value. In general, the tolerance bands are 2% and 5%. the settling time is denoted as (`t_s`).
The settling time for the 5% tolerance band is:
`:.` `t_s = 3/(delta * omega_n) = 3 tau` The settling time for 2% tollerence band is:
`:.` `t_s = 4/(delta * omega_n) = 4 tau` c. Peak Overshoot(`M_p`):- Peak Time is the time required for the response to reach peak value for the first time. it is denoted by(`t_p`). At `t = t_p` the first derivative of the response is zero. `:.` `t_p = pi/ omega_d` Peak Overshoot (`M_p`) is defined as the deviation of the response at the peak time from the final value of the response. it is also called the maximum overshoot. We can write it as
`:.` `M_p = c(t_p) - c(oo)` d. Steady-State Error:- A Steady-State error is defined as the difference between the desired value and the actual value of a system when the response has reached the steady-state. We can calculate the steady-state error of the system using a final value theorem.
`:.` `e_(oo) = lim_(t->oo) e(t) = lim_(s->0) E(s) = lim s/(1+G(s)) R(s)` 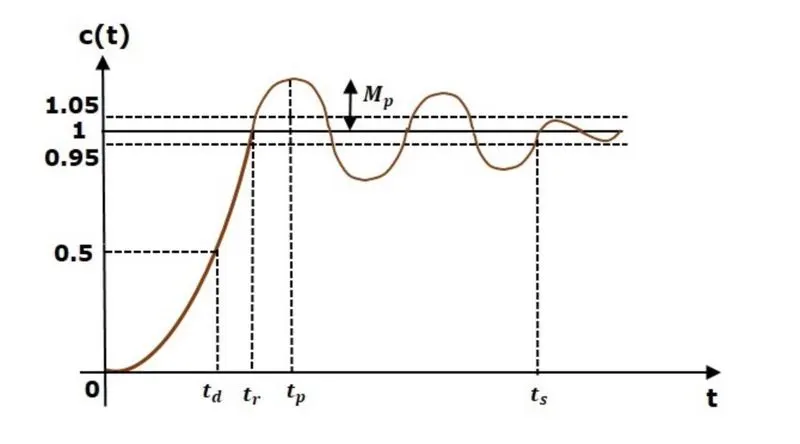
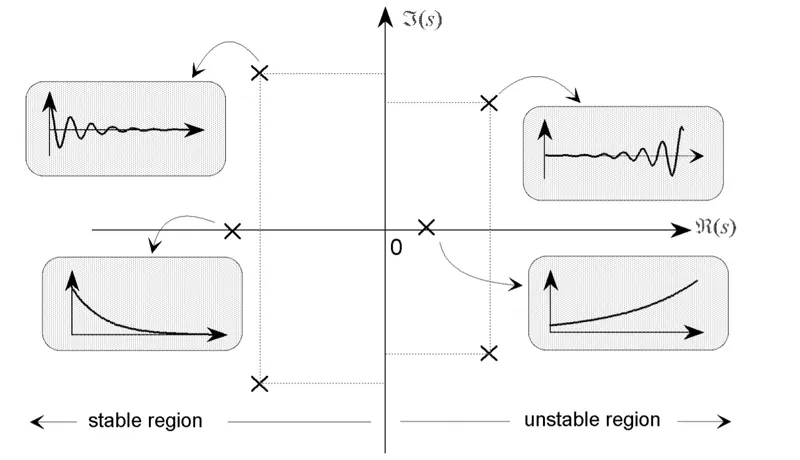
- No, if anyone pole is on the right side of the s-plane the system is not stable because,
The stability of a linear closed-loop system can be determined from the location of the closed-loop poles in the s plane. If any of these poles lie in the right-half s-plane, then with increasing time they give rise to the dominant mode, and the transient response increases monotonically or oscillates with increasing amplitude. This represents an unstable system. As soon as the power is turned on for such a system, the output may increase with time. If no saturation takes place in the system and no mechanical stop is provided, then the system may eventually be subjected to damage and fail, since the response of a real physical system cannot increase indefinitely. Therefore, closed-loop poles in the right-half s plane are not permissible in the usual linear control system. If all closed-loop poles lie to the left of the `jomega`axis, any transient response eventually reaches equilibrium. This represents a stable system.
Whether a linear system is stable or unstable is a property of the system itself and does not depend on the input or driving function of the system. The poles of the input, or driving function, do not affect the property of stability of the system, but they contribute only to steady-state response terms in the solution. Thus, the problem of absolute stability can be solved readily by choosing no closed-loop poles in the right-half s plane, including the jw axis. (Mathematically, closed-loop poles on the jw axis will yield oscillations, the amplitude of which is neither decaying nor growing with time. In practical cases, where noise is present, however, the amplitude of oscillations may increase at a rate determined by the noise power level. Therefore, a control system should not have closed-loop poles on the `jomega` axis.)
But all closed-loop poles lie in the left-half s plane does not guarantee satisfactory transient-response characteristics. If dominant complex-conjugate closed-loop poles lie close to the jw axis, the transient response may exhibit excessive oscillations or may be very slow. Therefore, to guarantee fast, yet well-damped, transient-response characteristics, it is necessary that the closed-loop poles of the system lie in a particular region in the complex plane.
`.^1`The stability of a linear system may be determined directly from its transfer function. An nth order linear system is asymptotically stable only if all of the components in the homogeneous response from a finite set of initial conditions decay to zero as time increases,
`lim_(i->oo) sum_(i=1)^n C_i e^(p_i t) = 0` where the pi is the system poles. In a stable system, all components of the homogeneous response must decay to zero as time increases. If any pole has a positive real part there is a component in the output that increases without bound, causing the system to be unstable`.^[1]`
`.^[2]` The total response of a system is the sum of the forced and natural responses:
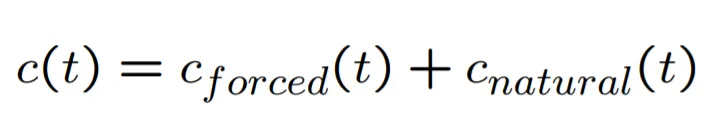
- A linear, time-invariant system is stable if the natural response approached zero as the time approaches infinity.
- A linear, time-invariant system is unstable is the natural response grows without bound as the time approaches infinity.
- A linear, time-invariant system is marginally stable if the natural response neither decays nor grow, but remains constant or oscillates as the time approaches infinity`.^[2]`
Solution:-
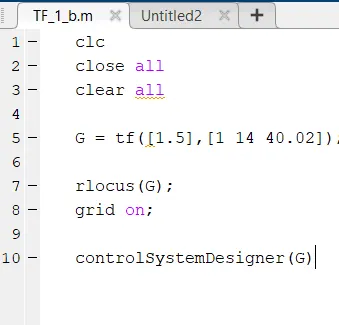
- b) the process for the tune the compensator for the DC motor are below:-
- open the MatLab then make a new script file.
- type all the basic command that is required,
- type the transfer function,
- make the grid on then,
- type rlocus for which we will get the rlocus and
- type the command"controlSystemDesigner" as it is written,
- this command will open the controller then we have to tune them into our specification,
- `T_r = 0.5 sec , M_p = 10% , GM <= 20dB and PM = 40 ^@`
-
Theory
- for solving the following questions on Synchronous Buck Converter are like this:-
- to run the synchronous Buck Converter on the default value
- Open the Matlab and click on the help section or open the Simulink then search for the Synchronous Buck Converter
- When found the model click no the first model
- Click on an open model, the model will be open in the Simulink
- Click on the run button keeping all the parameter in default value.
- observe them and conclude on the
- Now we have to change the reference voltage
- from the above no need to get a new file,
- at the bottom near the feedback controller side to it "r"
- change the reference voltage from 15 to somewhat around 20,
- make sure that that it should be below the main voltage.
- keeping all the parameters the same, run the simulation,
- then observe the scope output and determine the stability and is it keeping the trace of the reference voltage.
- changing the PI controller
- keep the first file as it is in the default value
- now open the feedback controller
- now inside the feedback controller, there are many blocks, one of them is the controller block.
- on opening, the controller here are 3 types controller and by default 1 is been selected
- go back and change the variant from the main menu select the second one for time being and observe and comment on the observation.
- now repeat all process but now with the third variant and now observe the output and comment on the output
- changing the switching frequencies
- from the above block no need to get a new file
- keep the reference voltage to 20 Volts as it is
- open the feedback controller
- change the saturation which is presently in 0.95 change it to 0.75 for high value
- change the saturation block with the lower from 0.01 to 0.05 for the low value.
- save all the changes and observe the output and comment on it.
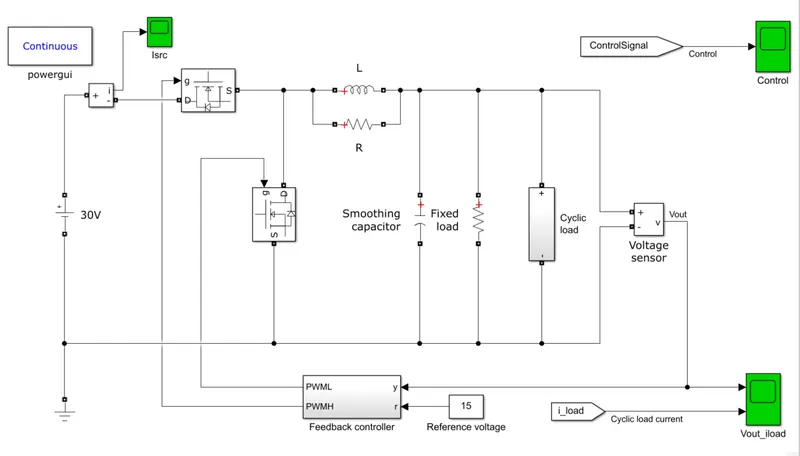
- to run the synchronous Buck Converter on the default value
Observation:-
- b)the following are the observation:
The Control system designer window displays the BODE plot editor and Root locus editor side by side along with Step response. One must tune the compensator to satisfy the condition of design requirements. On bode plot editor, the magnitude plot needs to be adjusted to around 4 rad/sec to get rise time and overshoot as per the condition. 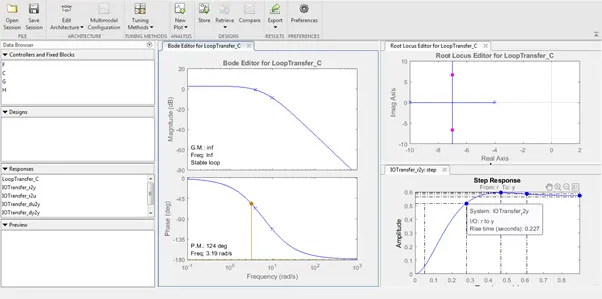
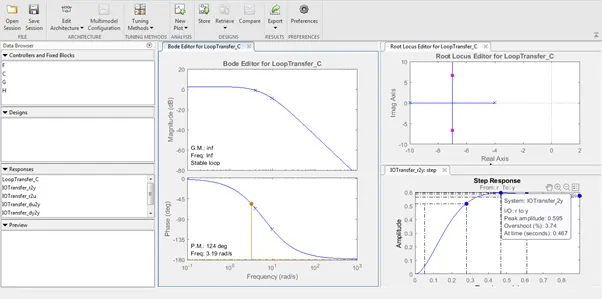
The Rise time and Overshoot have got satisfied now. To achieve 5% of steady-state error, the integrator must get added by right-clicking the Magnitude plot of Bode plot editor as shown below. 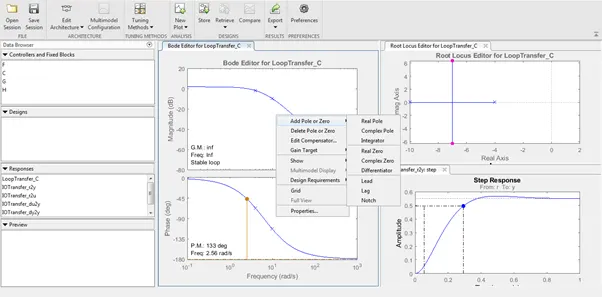
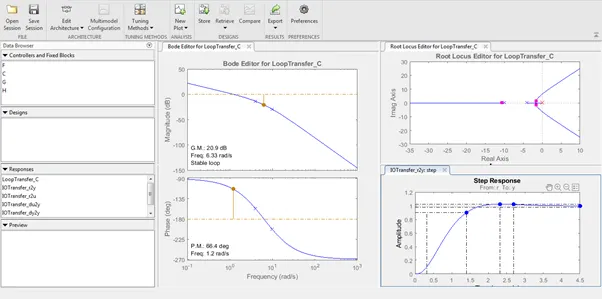
The gain of the compensator is increased directly by selecting the Edit compensator. We can calculate the gain value from `e_(ss) = lim_(s->0) s*E(s) = lim_(s->0) s* 1/(1+kG(s)) R(s)` The gain value can be increased to 100. The lead compensator can be added with a pole at -25 and zero at -5. The lead compensator will reshape the frequency-domain plot by providing a sufficient phase lead angle over some appropriate frequency range to offset the excessive phase lag associated with the plant. The transfer function of the lead compensator is
`D(s) = (taus+1)/(taualphas + 1); alpha<1;tau>0` This is the complete process and the value is below:: 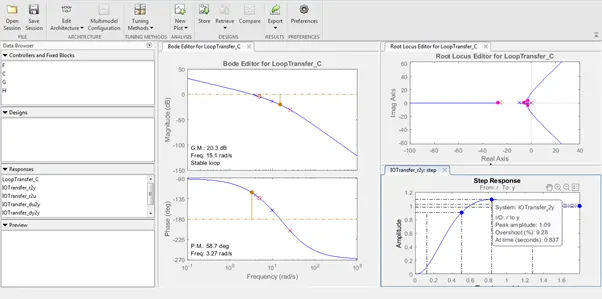
- The Observation is
we can find that the poles on the right side of the plane are unstable and they make the system unstable completely and when the poles are on the left side of the plane the system is stable - .
- the observation and the comment
as we can see that the `V_(out)` is as per the required voltage but it gets the maximum peak voltage around 16.5 Volts approx. 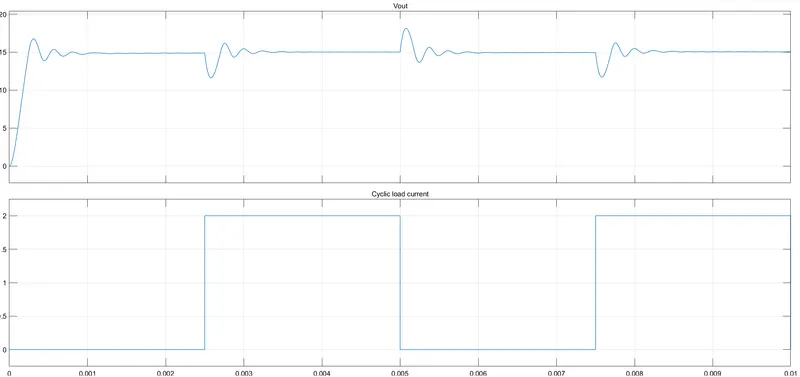
- the observation and the comment
as the increase in the reference voltage is been increased 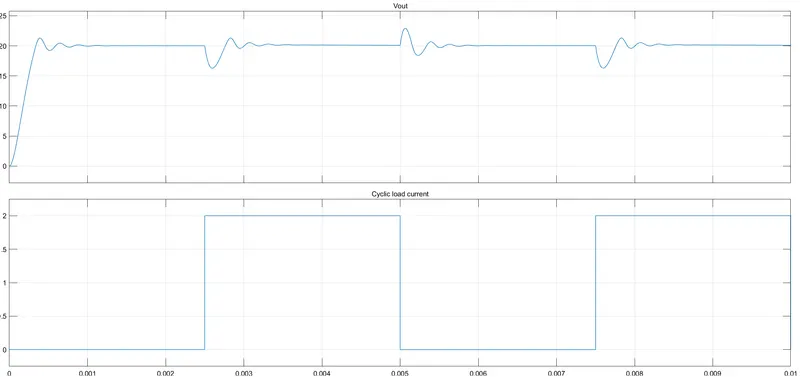
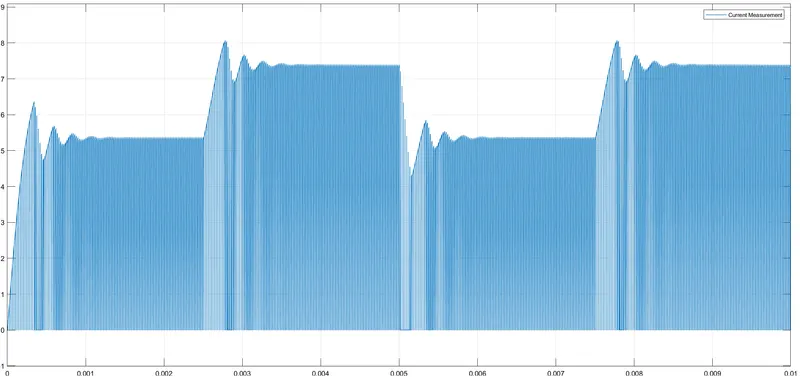
- this has 2 types of observation
- the observation and commenting
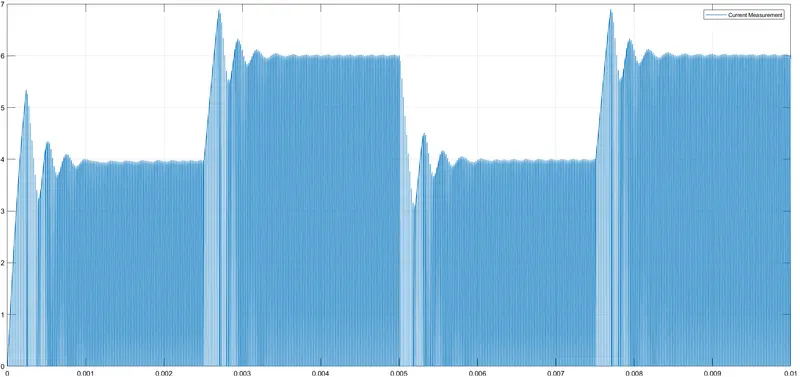
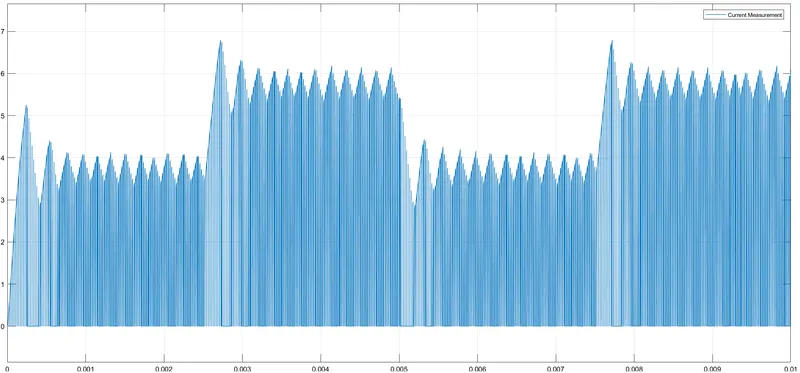
when we apply the 2nd variant PI controller which is a discrete time-invariant system we have observed that the system is marginally stable;e which is not been stoped oscillation and is normally isolation in between the 15.4 volts to 14.4 volts and coming to the switching current that is been more disturbed and the slop is triangular increasing and decreasing. 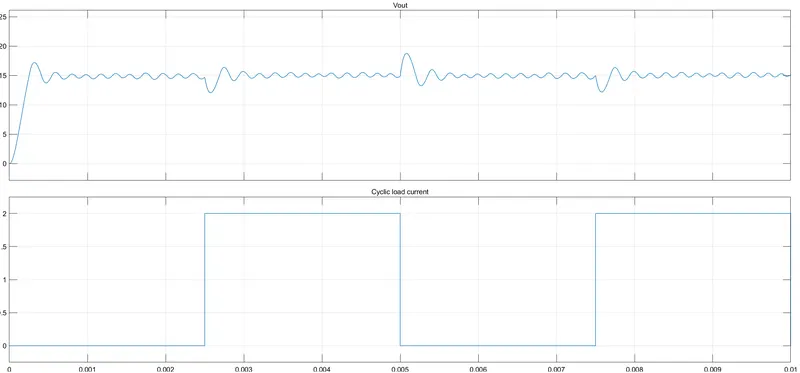
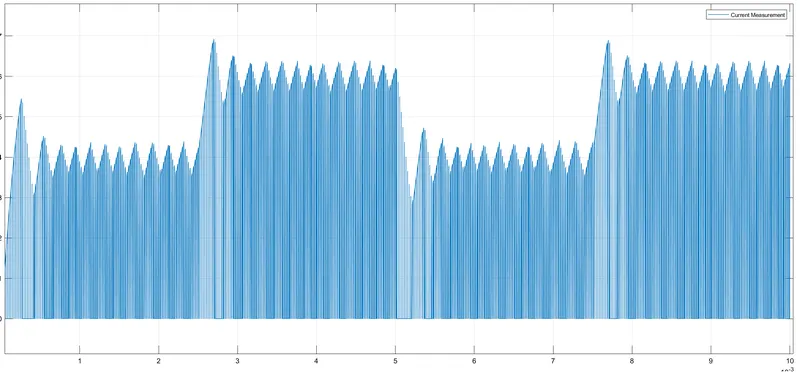
- the observation and commennting
when we apply the 3rd variant PI controller which is a Fixed type variant system we have observed that the system is also marginally stable and in better the oscillation is been increasing and decreasing as the switch is changing and the oscillation is also the same as the 15.4 volts to14.4 volts and coming to the switching it is more rapid 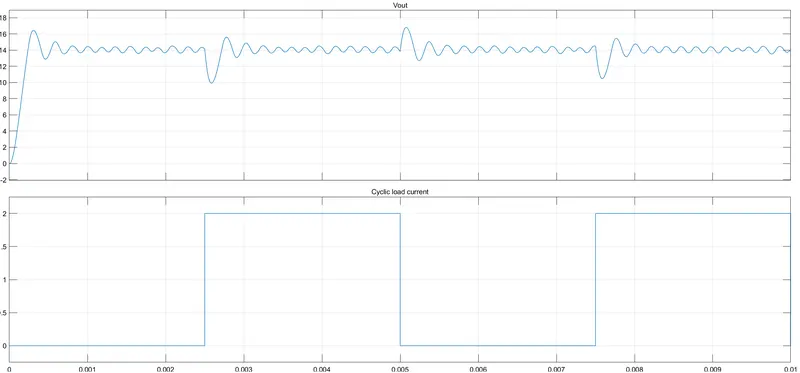
- the observation and commenting
- the observation and the comment
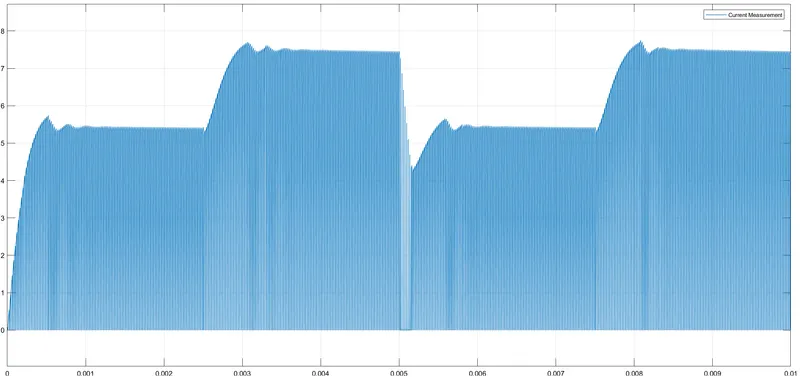
as we have changed the switching frequency the new results do not change only the first peak was been reduced which helps in reducing the settling time and the switching curve 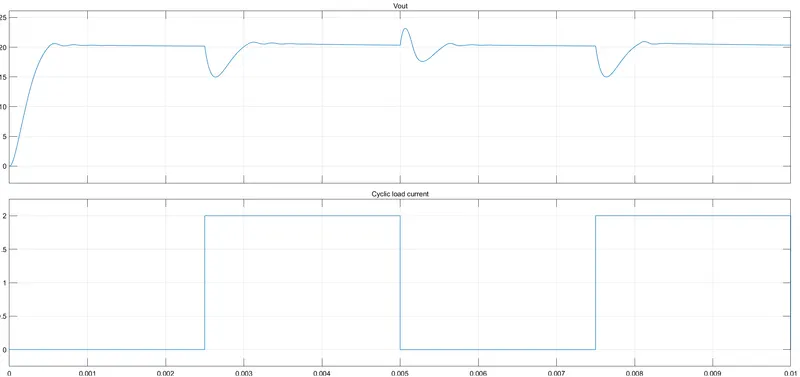
- the observation and the comment
Conclusion:-
- we conclude from the 1st are
- we got some knowledge about the following time-dependent terms like rising time,settling time,etc
- we have to tune the Transfer Function and by introducing an integrator to the circuit and adjusting the rise time and many functions to attend to the requirement.
- no, it is never been possible to make a system completely stable if any one pole of the system is on the right side of the plane.
- the stability information is below
- stable system the oscillation is been stopped and the required voltage is been achieved
- stable system the oscillation is been stopped and the required voltage is been achieved
- it has two parts
- Marginally stable as the oscillation is not been cleared and jumps within the 1V of error
- Marginally stable as the oscillation is not been cleared and jumps within the 1V of error and is more stable than the above discreet time-variant PI
- the system is stable, On changing the frequency I got to reduce the Peak Overshoot of the system and changing the linear switching to smooth switching.
Reference:-
- https://web.mit.edu/2.14/www/Handouts/PoleZero.pdf
- http://www.personal.reading.ac.uk/~sis01xh/teaching/CY2C2/splane1.pdf
- https://skill-lync.freshdesk.com/support/solutions/articles/43000585187-tune-compensator-using-control-system-designer-tool
- https://www.mathworks.com/help/physmod/sps/ug/synchronous-buck-converter.html;jsessionid=d329b9b7f786706ee82e2b490282