Final Project: Electric Rickshaw modelling
INTRODUCTION:
Let us first look at the layout and working of an electric rickshaw.
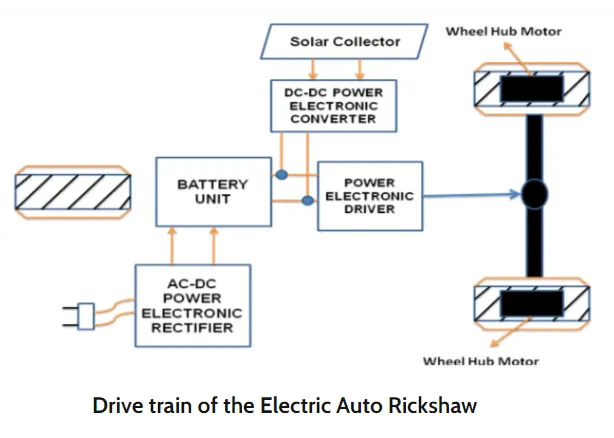
Electric rickshaws have the same principle as EV's. They also run on lithium-ion battery packs. The motors generally used here are DC motors. Mostly, electric rickshaws are rear wheel driven.
The drive train is seen above. The power for the battery pack goes via an AC charger circuit with a rectifier to convert them into DC power. After charging the battery pack, the signals are sent to the electronic control unit (power converters & motor controllers). The purpose of these ECU's is to control speed according to the driver input (accelerator & brake). These pulses are then sent to the DC motor which transfer power to the wheels.
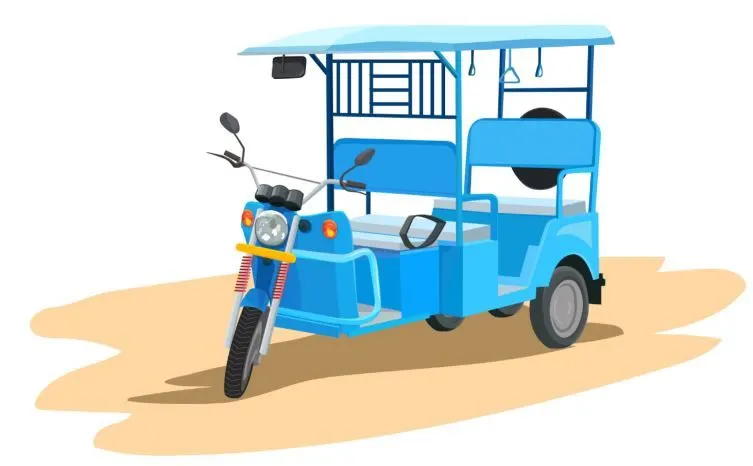
A picture of an electric rickshaw is seen below.
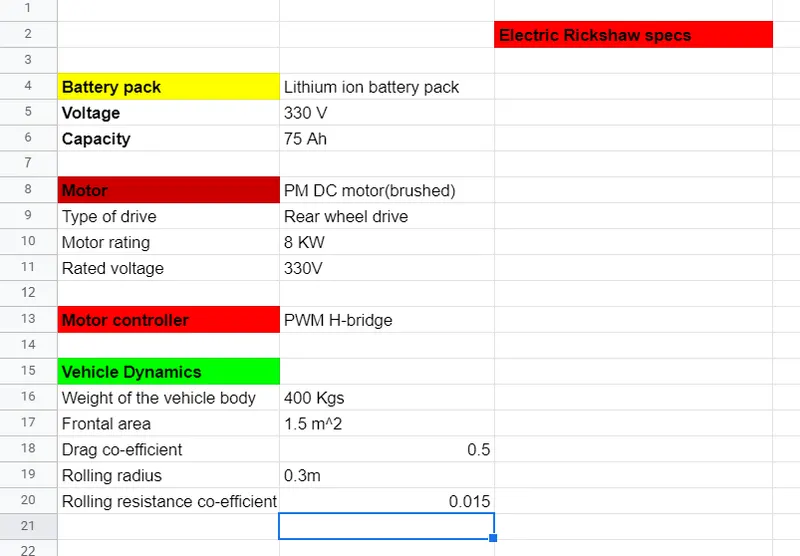
Now we will see the specifications of this electric rickshaw before proceeding to model them in MATLAB.
MATLAB model:
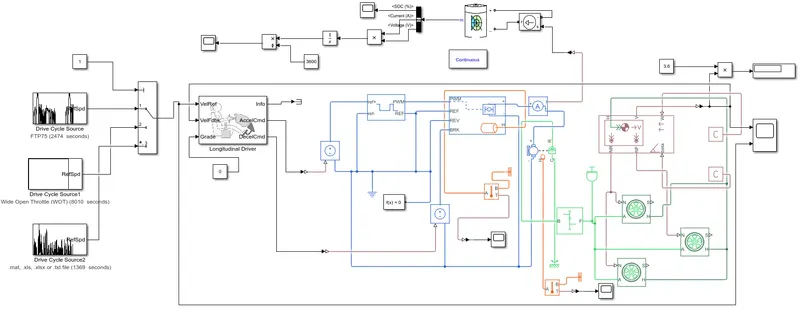
We are asked to model the electric rickshaw for three different reference drive cycles.
The three drive cycles include:
1). FTP 75 drive cycle
2). WOT (user-defined).
3). UDDS drive cycle.
The plot for the FTP drive cycle is shown below:
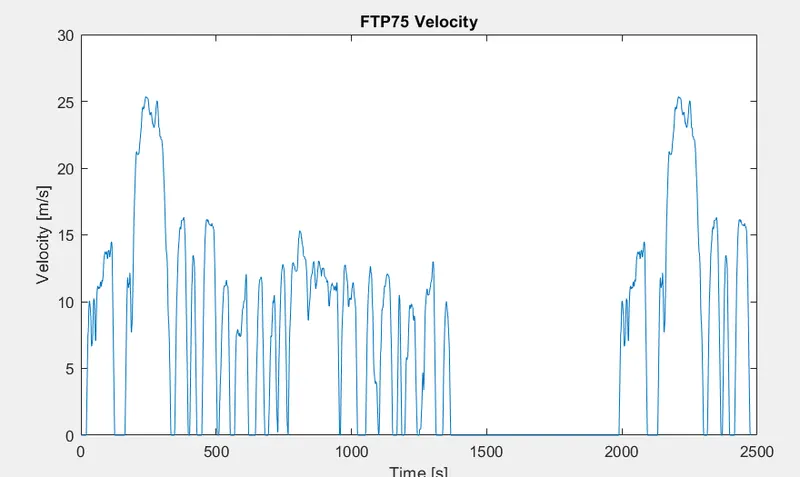
This drive cycle is for a time period of 2474 secs and the max velocity achieved in the drive cycle is 25m/s.
WOT (user-defined):
In the question, we are asked to create a drive cycle for 100km at a constant speed of 45kmph. We will input them into this drive cycle.
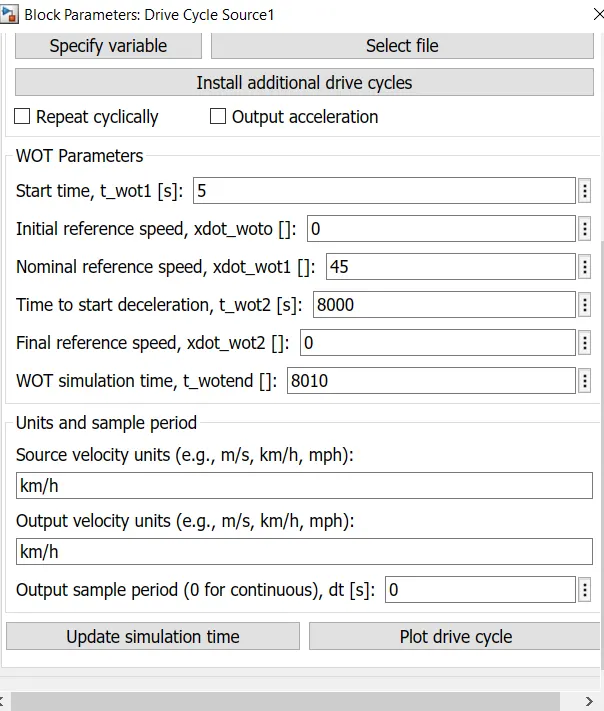
We will calculate the drive cycle time for this WOT.
Time = Distance/speed = 100/(45/3600). (Since we want our drive cycle time in seconds, convert kmph into kmps)
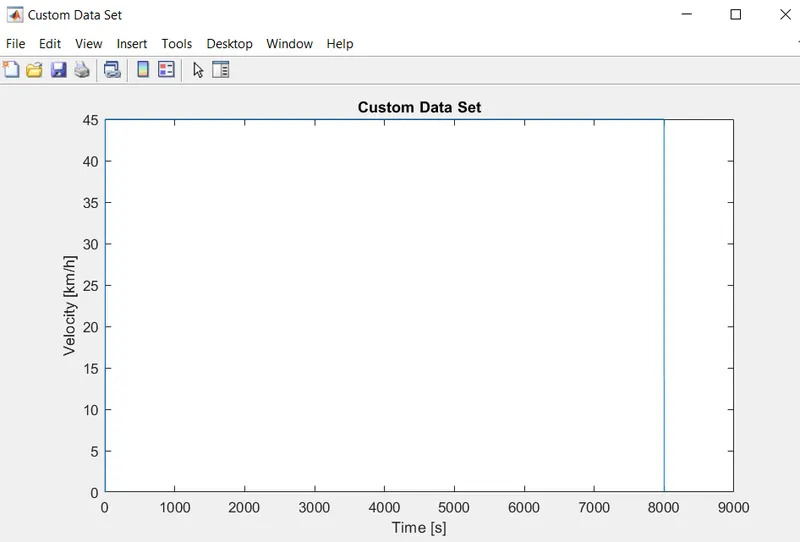
Time = 8000 seconds.
The drive cycle plot is shown below.
UDDS drive cycle:
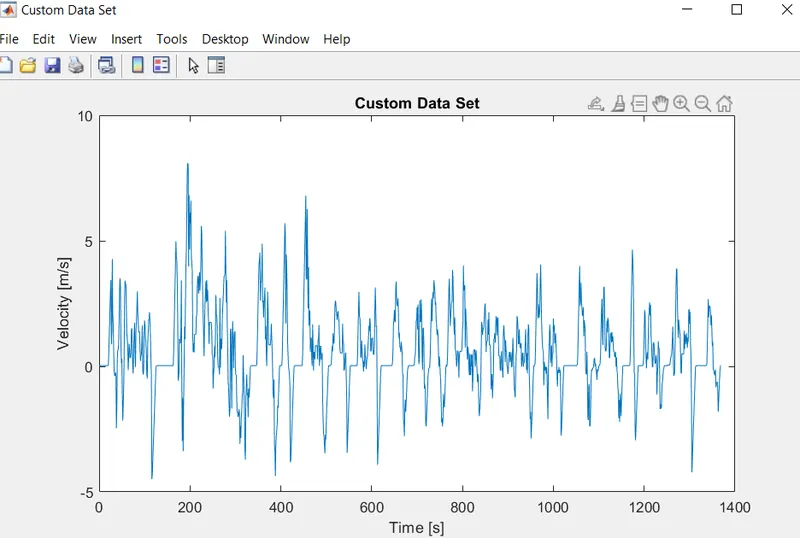
This drive cycle is called as the Urban Dynamometer Driving Schedule. We will see the plot for this drive cycle.
Now we have selected our drive cycles. We need a block to manage these three drive cycle references during simulation. This is where the multiport switch block comes into place.
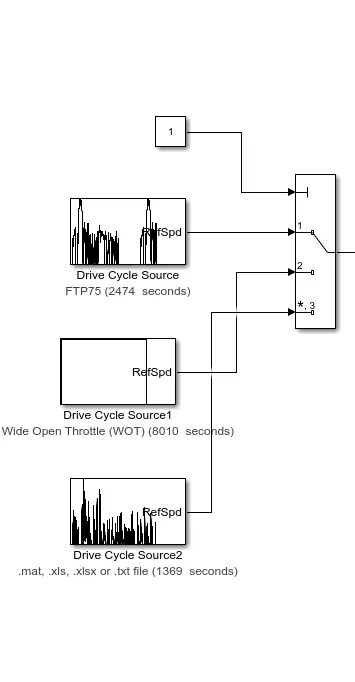
The multiport switch consists of a control port and 3 data ports as default. We can change the number of data ports for our convenience. Since there are 3 drive cycles, we are using three data ports.
The control port is connected to a constant block. This constant block chooses the drive cycle out of the three options during run time. The FTP-75 drive cycle is numbered as 1, WOT is numbered as 2 & the UDDS as 3.
LONGITUDINAL DRIVER:
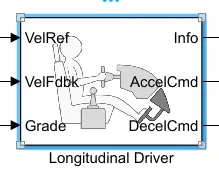
The longitudinal driver block creates a driver scenario for the system. THis block also consists of a PI controller, which is used to match the actual drive cycle of the system with the selected reference drive cycles. The parameters of the block are shown below.
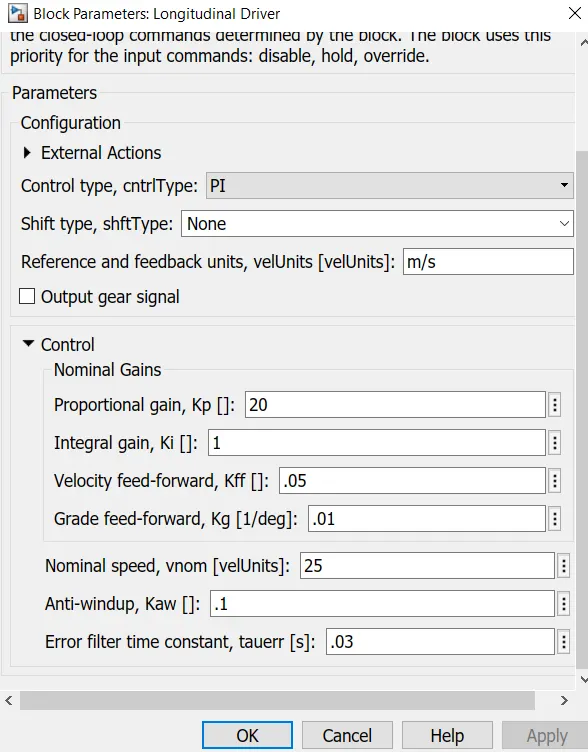
The propotional gain and integral gain are kept as default.
The multiport switch output is connected to the Vel.Ref port. The Vel.Fdbk is the actual drive cycle of the system, which comes out from the vehicle body dynamics. The grade angle is kept as 0.
The longitudinal driver block converts the reference drive cycle data as equivalent current & voltage signals, which are connected to the controlled voltage sources.
Now we will see the motor drive system of the model.
MOTOR DRIVE:
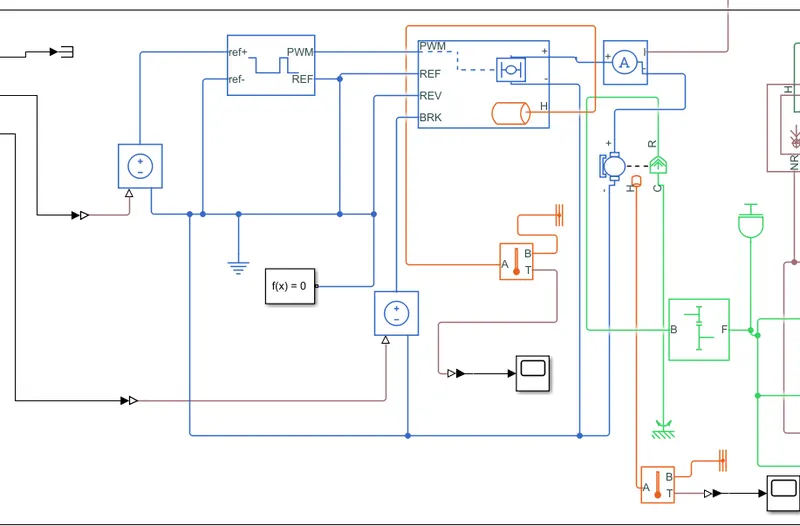
We have already decided that our motor controller would be the PWM H-bridge. This PWM H-bridge consists of 4 transistor switches with the motor at its center, making the circuit shaped as the alphabet H. These switches when open & closed, changes the direction of the current. The direction of current determines the direction in which the motor would rotate.
We have to convert our controlled voltages into controlled PWM voltages. This is done with the help of the controlled PWM voltage block, which changes the pulse width of the signals according to the controller requirement.
They are passed on to the controller. The controller parameters are shown below. The controlled PWM voltage block converts the voltage signals to the parameters shown below.
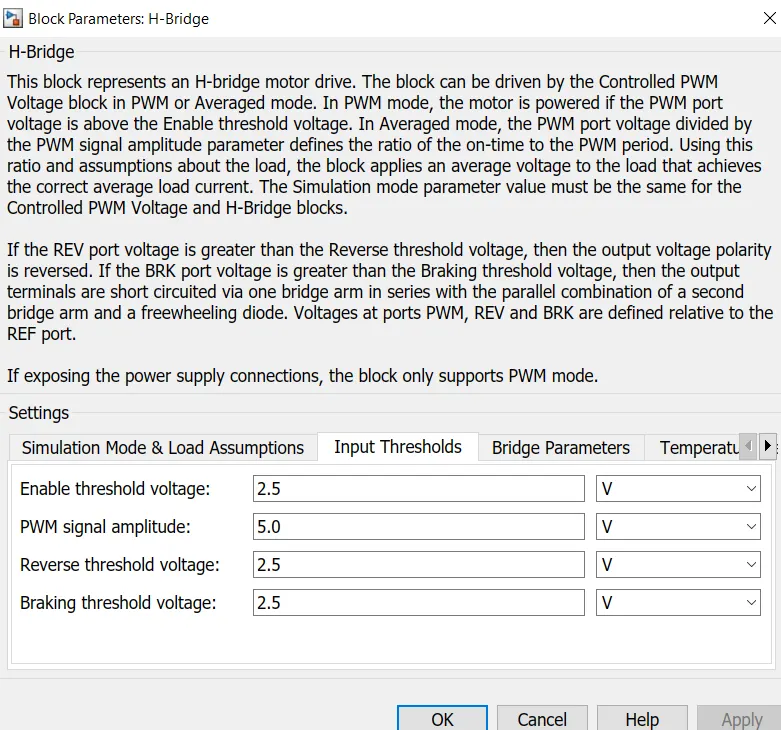
The enable threshold voltage, reverse threshold & braking threshold are kept at 2.5V. These parameters are the limit at which the motor starts to enable(switch on), stop and reverse the motor. If the voltage at REV, BRK & PWM are greater than the threshold voltage, the motor activates the braking, reverse conditions. The signal amplitude is kept high at 5V.
The output voltage of the H-bridge is kept at 330V, same as the operating voltage of the motor.
We add a thermal port to the H-bridge, because we are asked to monitor the thermal effects of the controller during simulation. This will give us an idea of what temperature the controller is during driving. Use the temperature sensor block, the thermal reference and the scope window to get the temperature plot.
Now the controller is connected to the DC motor. The parameters of the DC motor are seen below.
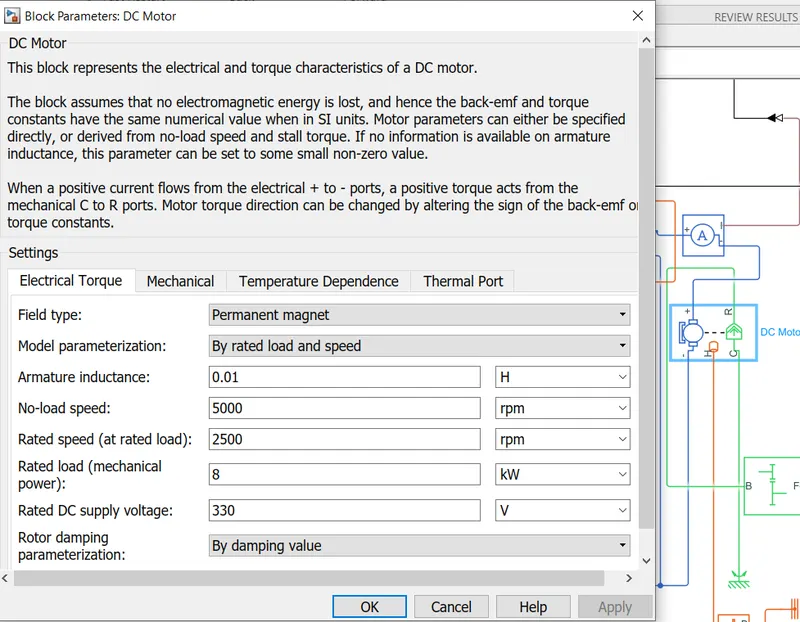
The motor parameters are entered as per the specifications given in the spreadsheet.
We also add a thermal port to the DC motor to track its temperature at various speeds. Use the temperature sensor block, the thermal reference and the scope window to get the temperature plot.
Now that the motor drive is finished, we will look at the vehicle body dynamics of the electric rickshaw.
VEHICLE BODY DYNAMICS:
We will look at the block diagram of the vehicle body.
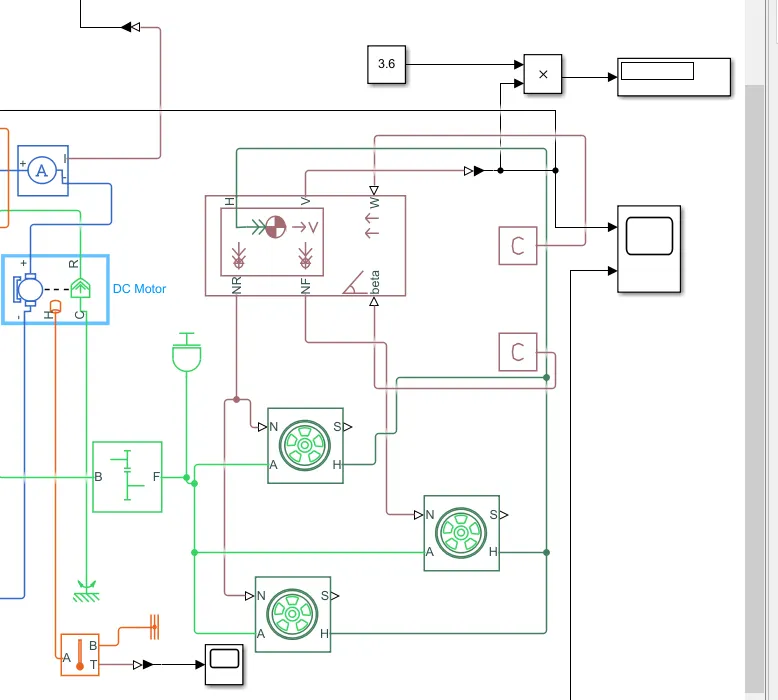
The DC motor is connected to the simple gear block, which is used to transfer the power to the wheels of the vehicle. The parameters of the simple gear block is shown below.
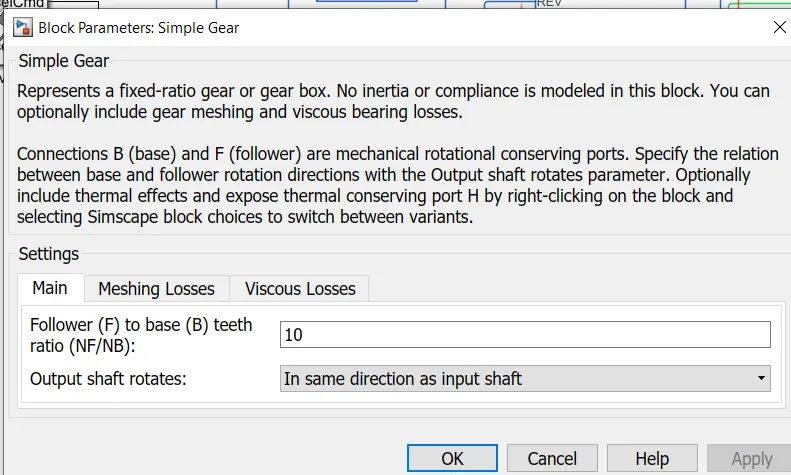
The output of the simple gear block is connected to the rear wheels. We use the Tire(magic formula) block to simulate the tyres of the vehicle. The block is shown below.
It's parameters are shown below.
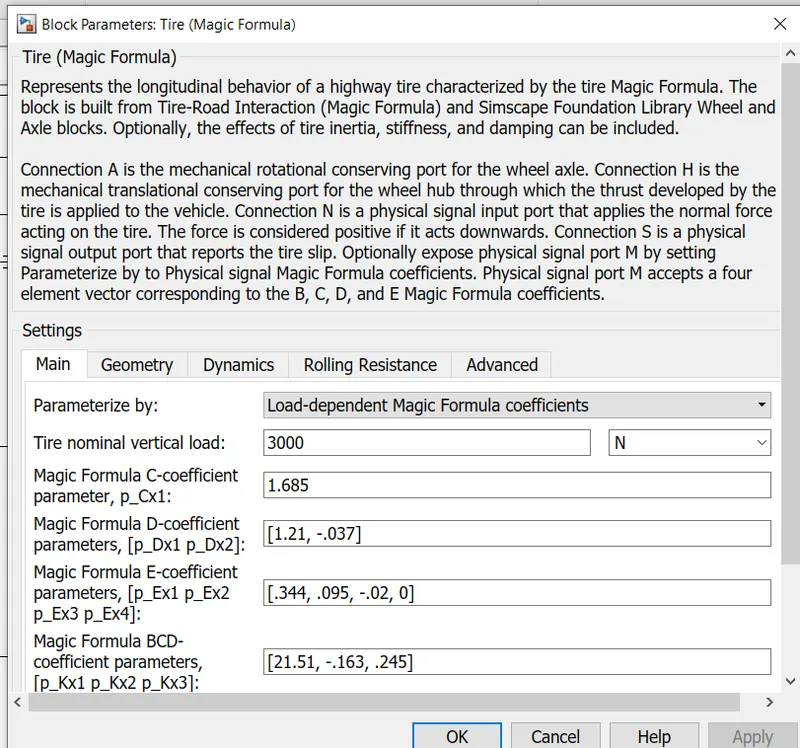
The rolling resistance is enabled and the parameters are shown below.
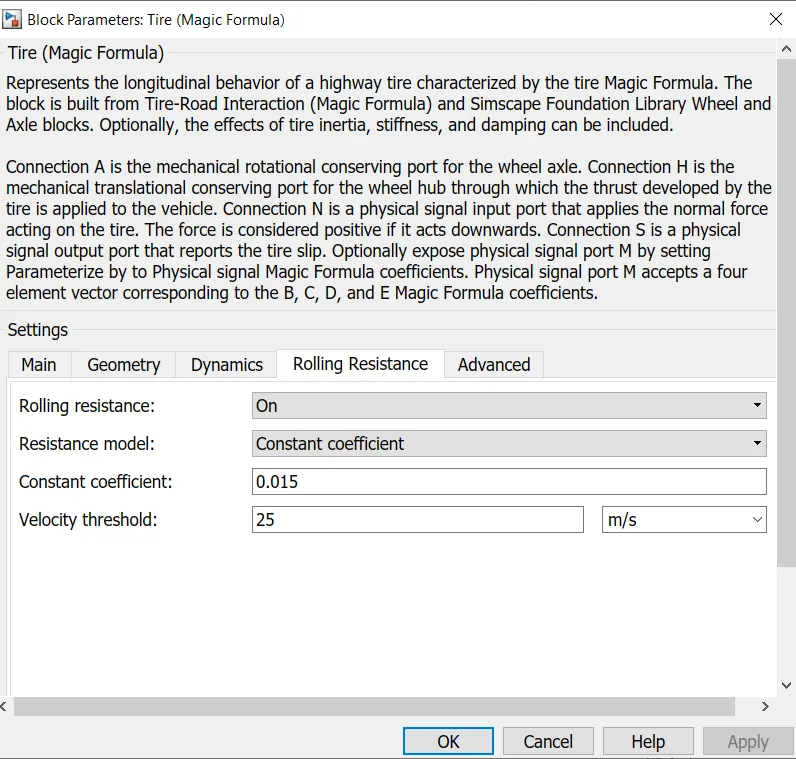
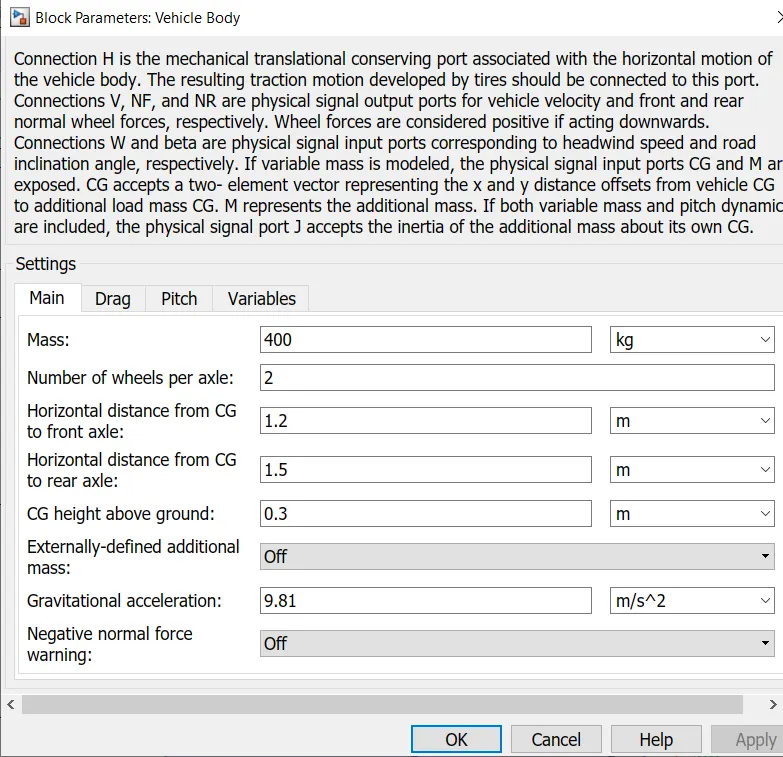
Now we will look into the vehicle body parameters. Use the vehicle body dynamics block to simulate a vehicle body based on the weight, centre of gravity, frontal area & drag co-efficient.
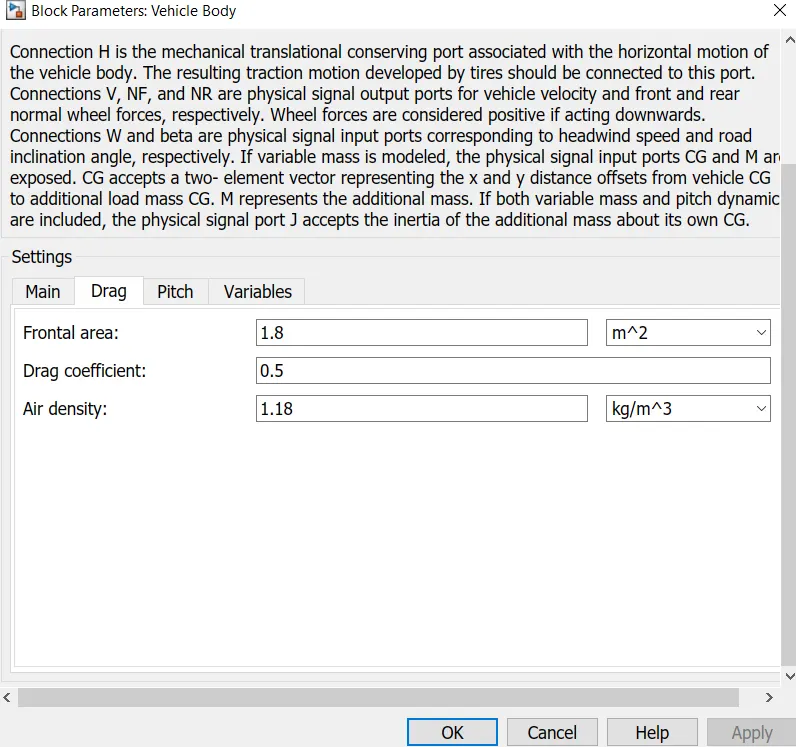
The frontal area & the drag co-efficient are also enabled.
Connect the tire blocks to the vehicle body as shown in the model screenshot.
We have not considered the grade angle & the wind velocity for the electric rickshaw. Hence the values are to be specified as zero. Use the PS constant block to specify the values to the vehicle body.
Create a display block to display the speed of the vehicle in Kmph. Since our drive cycle data are in m/s, multiply the output velocity by 3.6 to get the values in kmph.
The output velocity is fedback to the longitudinal driver block. The reference and the actual drive cycle data is attached to a scope window to compare the results.
Now we will see the battery system of the electric rickshaw.
BATTERY SYSTEM:
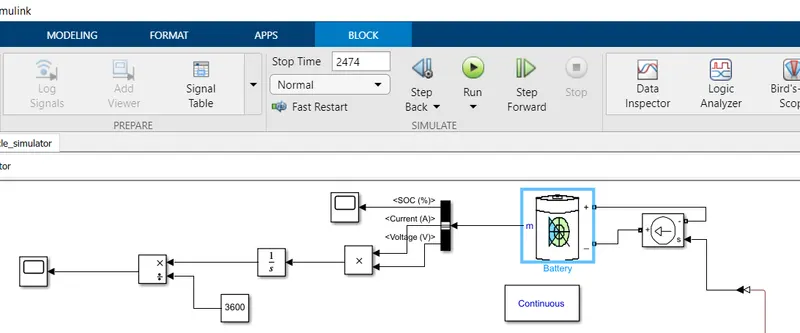
A current sensor is connected to the H-bridge controller & the signals are sent to a controlled current source.
Then the generic battery block is connected across it. The battery parameters are entered as per the pack specifications.
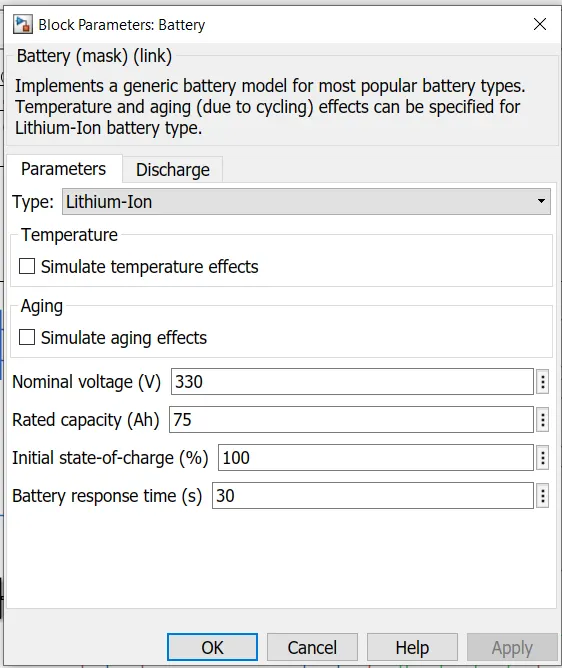
Use the bus selector block to extract the signals out of the generic battery block. There are three output signals that can be extracted out of the block:
1). SOC.
2). Battery current.
3). Battery voltage.
The SOC output is connected to a scope window. The current & voltage signals are used to calculate the energy consumption.
The formula for energy consumption is given by:
Energy = Work done/Time.
Generally the energy is expressed in Kw-h. The work done by the battery is the product of Voltage and current.
Time is denoted in seconds as 3600 seconds. (One hour)
The product block is used to multiply both current & voltage. They are passed into the integrator block to denote the work done for a total time period. Then the divide block is used to divide the work done by time in seconds.
The results are connected to the scope window to show the energy consumption of the battery for the run time.
We have completed the modeling. Now let us run the model for the results.
RESULTS:
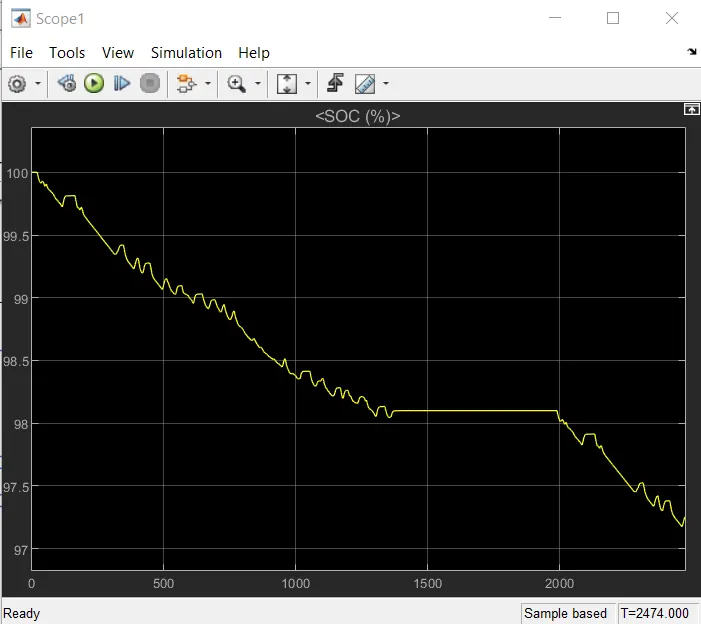
1. We will first test for the FTP drive cycle. Keep the run time as 2474 secs.
The velocity reference & the actual feedback plot is shown below.
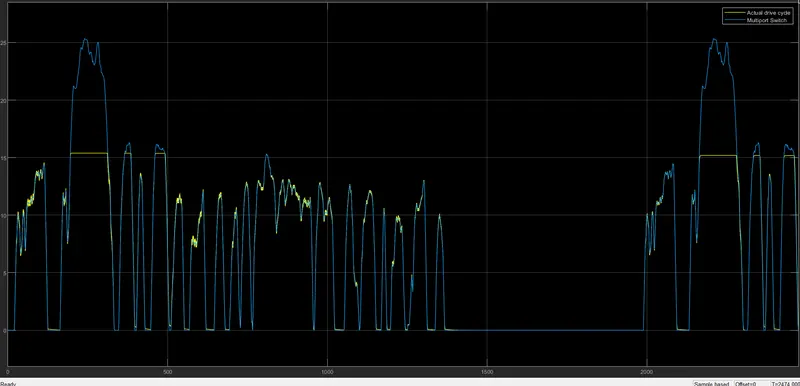
The actual velocity is almost matching with the reference cycle except for some small areas.
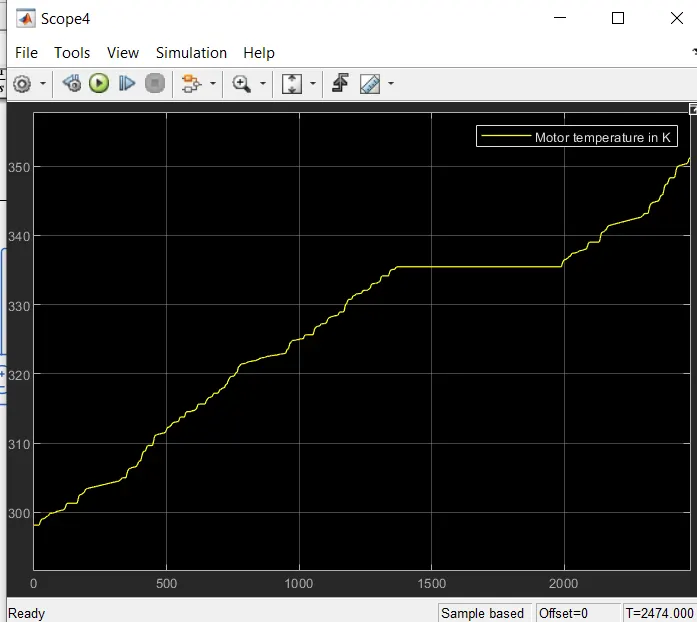
The motor temperature throughout the run time is shown below:
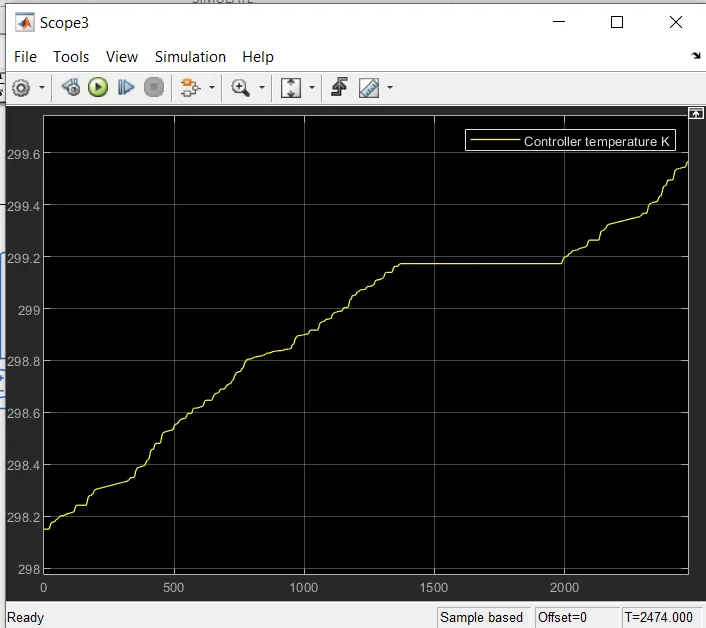
The controller temperature is also shown below:
The SOC for the simulation is also shown here:
2. Now we will test for the WOT (100km for a constant speed of 45kmph).
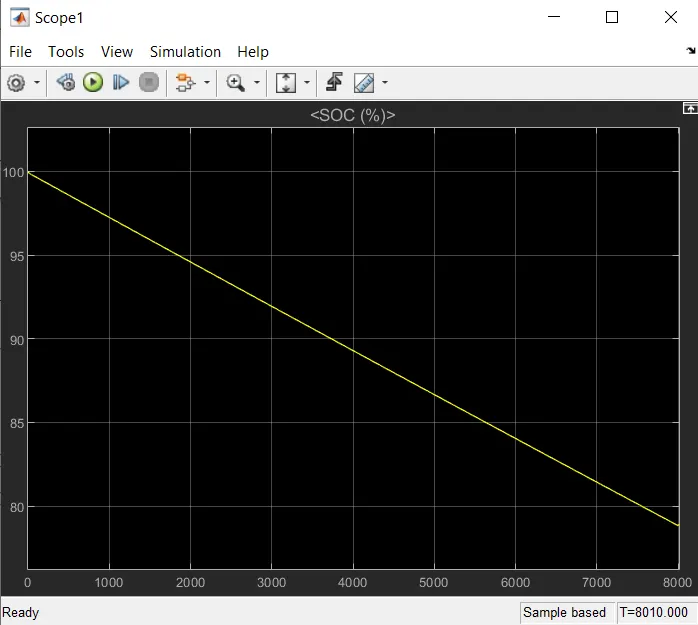
Keep the run time as 8010 secs.
The drive cycle of the WOT is shown below.
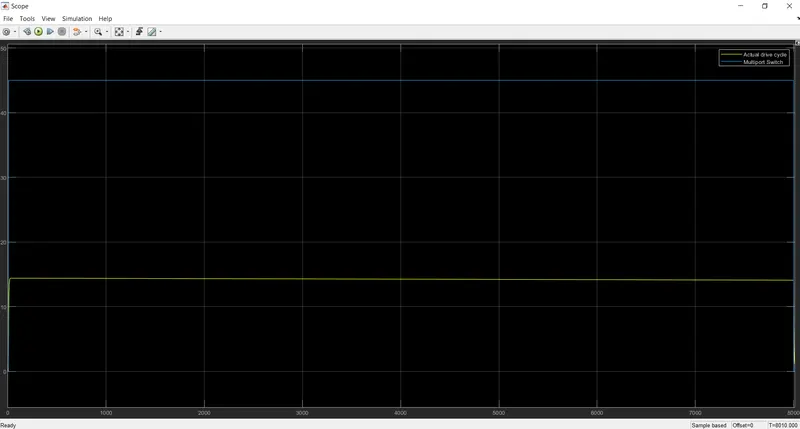
The actual drive cycle is lower than the reference drive cycle.
The SOC of the drive cycle is shown below:
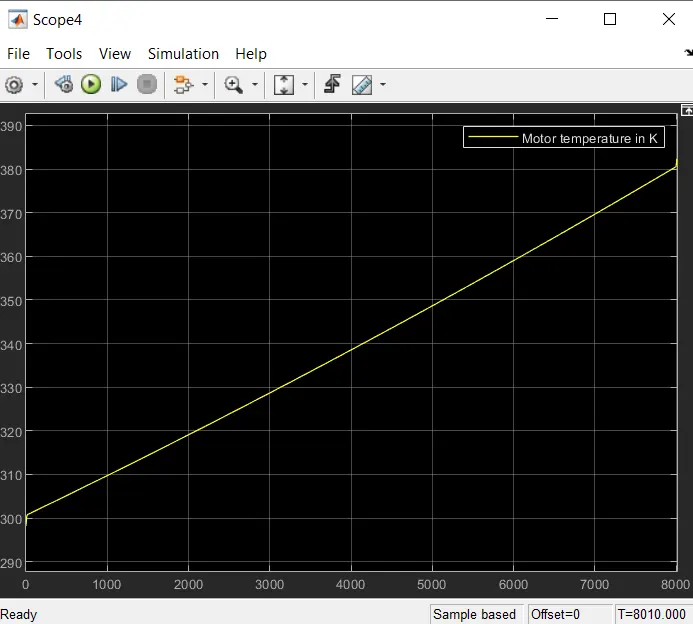
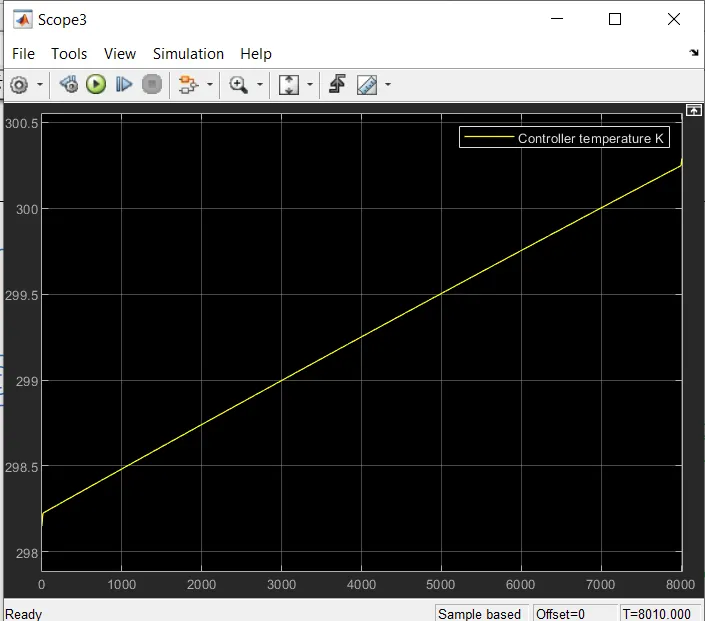
The motor and controller temperatures are shown below.
The total energy consumption for the drive cycle is shown below.
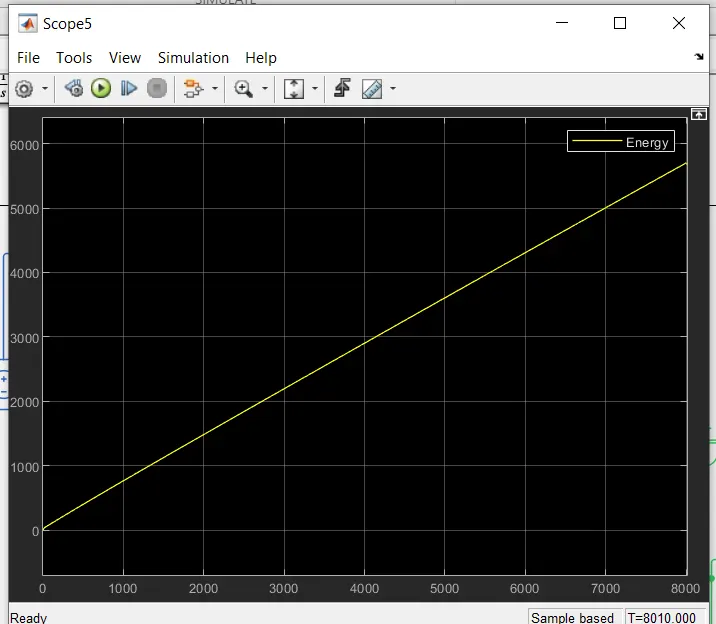
Note that the energy unit is in W-s. Converting into Kw-h would give us the real value of energy consumption.
CONCLUSION:
1. The electric rickshaw model has been simulated succesfully.
2. In this model, the temperature of motor & controllers keep increasing. This is because we have not applied any thermal management system to the model. Real life models will have motor and controller temperature of less than 90 degree celsius.
3. The variation in battery SOC, energy consumption, drive cycle of the model was found. Since we have enabled regenerative braking to the controller, we did not have much decrease in SOC.