BIW Side Crash Analysis of a Dodge Neon car under FMVSS using Hypermesh, Hypercrash & RADIOSS
AIM:
Side crash analysis, deck setup using hypermesh and hypercrash.
OBJECTIVE:
- To check the unit system and either follow [Mg mm s] or [Kg mm ms].
- To create the appropriate interface, friction 0.2 and recommended parameters.
- To make sure of no penetrations and intersections.
- To correct rigid bodies if any issues.
- To create a rigid wall with friction 0.1.
- To compare the model weight with the full-scale 300k nodes model and use added masses to reach target weight 700kg while getting CG about the required range.
- To create an initial velocity of 35 mph.
- To input Time-step:0.5 to 0.1 microseconds and Run 80 ms
ABSTRACT:
An automobile car body structure was designed and analysed which can be used for traveling of the passengers and goods. The car body structure is made of aluminium and the crash analysis is performed on the car body structure to know how the car body structure deforms in a crash accident. Crash analysis is performed on car body designs for ensuring the safety of passengers in accidents. A detailed car body deformation analysis has been performed in HYPERMESH RADIOSS profile and HYPERCRASH. A side crash of a car is performed. A Finite Element Model of a car structure was used in a crash simulation to assess the safety and to know the crashworthiness of the car.
A crash simulation is a virtual recreation of a destructive crash test of a vehicle using a computer simulation in order to examine the level of safety of the vehicle and its occupants. Data obtained from a crash simulation indicate the capability of the vehicle body to protect the vehicle occupants during a collision against injury. This simulation technology has greatly increased the protection, dependability, and producing potency in today’s vehicles. The advantage of the simulation is numerous and important. Computer-aided parametric design software will be used for modeling of the problem to define all the coordinate values and geometrical details, then this CAD data would be transferred to a FEM software for pre-processing, solution, and post-processing followed by generation and interpretation of results related to energies, acceleration, and displacements with different loads & boundary conditions possible in various accidental situations. The automotive industry has probably the widest application of crash simulation. Simulating the crashworthiness of the vehicle in terms of very simple models based on the spring-mass damper systems was the focus when the computers were very slow and the breakthrough occurred when LSTC was formed. Nowadays software such as LS-DYNA and others have very wide practical aspects by incorporating special seat belt elements and passenger dummies for simulating precisely the occupant safety under various crash situations. Several standards have been originated in various countries related to automobile crashing. Although developed mainly for automotive applications, crash simulation software’s have also found application in train, ship, and aircraft crashworthiness. The two main standards associated with FAA (Federal Aviation Administration) requirements are those of bird strike impact and engine blade containment. Other applications in the defense sector are simulating the explosive detonation process and design of weapons. Computational Biomechanics also is continuously evolving with the development of finite element models closely following the actual physics models.
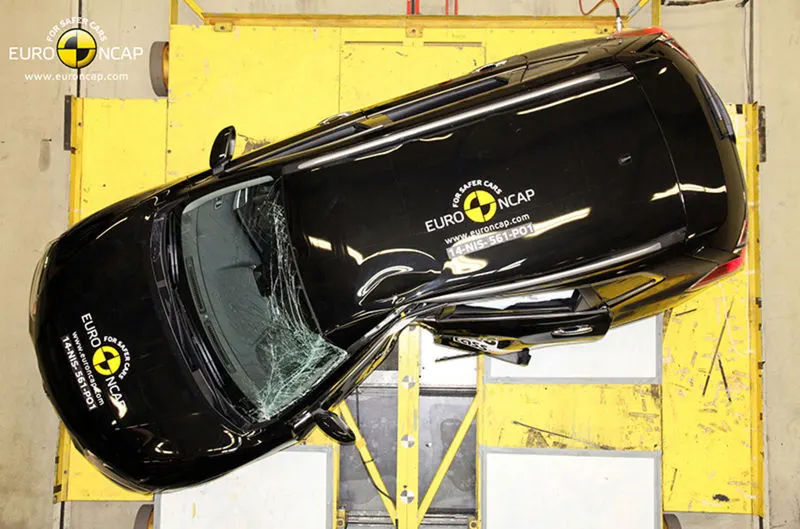
Side pole crash
Various Crash Test
A crash test is a form of destructive testing usually performed in order to ensure safe design standards in crashworthiness and crash compatibility for various types of vehicle like small, medium and heavy-duty and its related systems and components for the sake of getting the performance of the vehicle under the different conditions of the crash at different angles with taking certain object like a rigid wall, cables specially three-strand cable, concrete barriers, guardrail systems, etc. It will be performed either by numerical simulations or experimentally. The figure below depicts the different types of crash tests generally used.
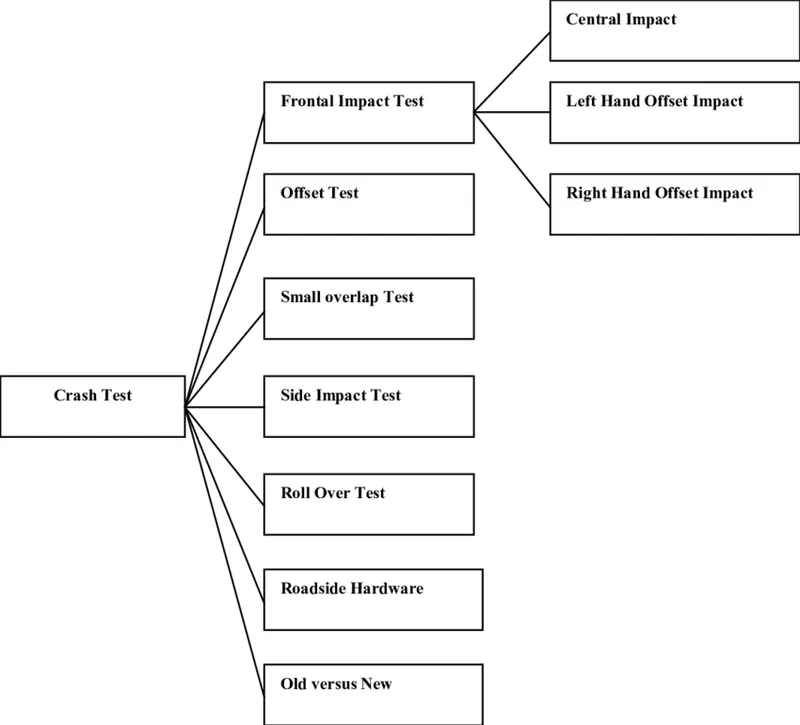
Different type of crash test's
- Frontal Impact test- In this test a fully front structure of the vehicle collides with another object like another vehicle, rigid wall, etc. at a given speed.
- Offset Test- In this test, only a part of the front portion of the vehicle strikes on some barrier usually a vehicle at a given speed.
- Small Overlap Test- In this only a small portion of the vehicle strikes an object like a tree, pole, or if a car were to clip another. This situation loads a maximum value of force into the vehicle structure at a particular given speed. This test usually comprises 15% to 20% of the front structure.
- Side Impact Test- In this test sometimes the vehicle is in static condition or in dynamic and another vehicle or an object collides at the side surface having some speed.
- Roll-Over Test- In this test a vehicle is in rollover condition having a certain angle by which they test (specifically the pillars holding the roof) to support itself in a dynamic impact. It is also done for the static crash testing condition.
- Roadside Hardware- These are performed to ensure that the crash barriers and crash cushions will protect vehicle occupants from roadside hazards.
- Old Versus New- In this, an impact is done between an old car against a new car and the big car against a small car it is performed to show the advancements in crashworthiness.
Crash tests are conducted under rigorous scientific and safety standards. Each crash test is very expensive so the maximum amount of data must be extracted from each test. Usually, this requires the use of high-speed data acquisition, at least one triaxial accelerometer, and a crash test dummy, but often includes more. A crash test is much important which helps in minimizing the losses such as deaths, injuries, and property damages from vehicle crash on the roads.
In this Project, we have to perform the Side crash of the vehicle. Side impacts are the impacts undertaken against the solid side pole barrier with precise speed. The test requires the side portion of the vehicle to impact the pole barrier.
In the New Car Assessment Program (NCAP), passenger vehicles are crashed at 35 mph into a rigid barrier that covers the full width of the vehicle. The Institute runs offset frontal tests instead of full-width frontal tests.
PROCEDURE:
- Check for UNIT SYSTEM
- Import model in HYPERCRASH
- Check for penetration and intersection
- Add masses to reach a target weight of 700kg
- Export changes file and import in HYPERMESH
- Create Self Interface contact
- Create a rigid wall
- Add velocity to the nodes
- Create cross-section's
- Create springs to check deflection
- Assign property to springs
- Create TH for section forces, intrusion springs, interface contacts
- Create cards
- Model checker
- Run the model
CHECK FOR UNIT SYSTEM:
In the data, we have two files
1. Neon_side_reduced_0000.rad ( Starter input file) :
The starter file stores information about:
- Nodes
- Load Conditions
- Velocity
- Boundary Conditions, etc.
- Basically, it is an ASCII (American Standard Code for Information Interchange) file that contains the model information.
- The starter file should always end with 0000.rad.
2. Neon_side_reduced_0001.rad ( Engine input file) :
The engine File stores information about:
- Simulation Runtime
- Simulation Speed control parameters, such as No. of Animation Files, No. of Time History File, Size of the history file and Animation frequency, etc.
- Basically, it is an ASCII (American Standard Code for Information Interchange) file that describes the run controls.
- We can also edit the Engine File directly through the Control Cards.
- The starter file should always end with 0001.rad.
To check unit
Go to Neon_side_reduced_0000.rad file >> Open >> check the unit system
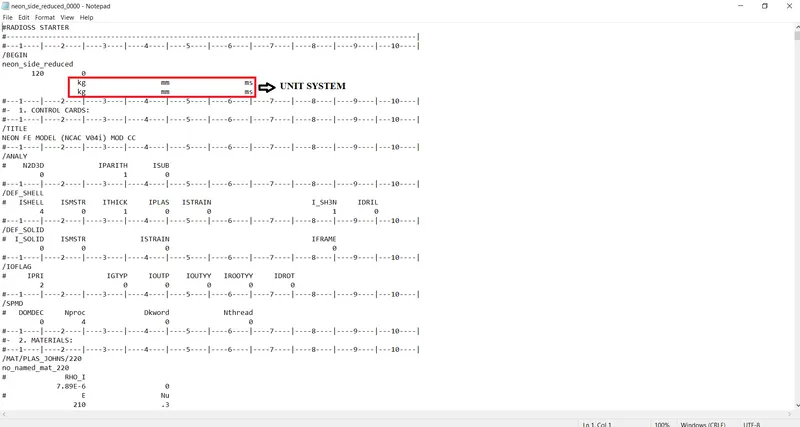
Unit System
IMPORT STARTER FILE IN HYPERCRASH:
Here some setup is done by Hypercrash and the remaining setups are done in Hypermesh.
To open hypercrash we have to first open hypermesh
Now go to Application >> Hypercrash>> Select the unit system >> open
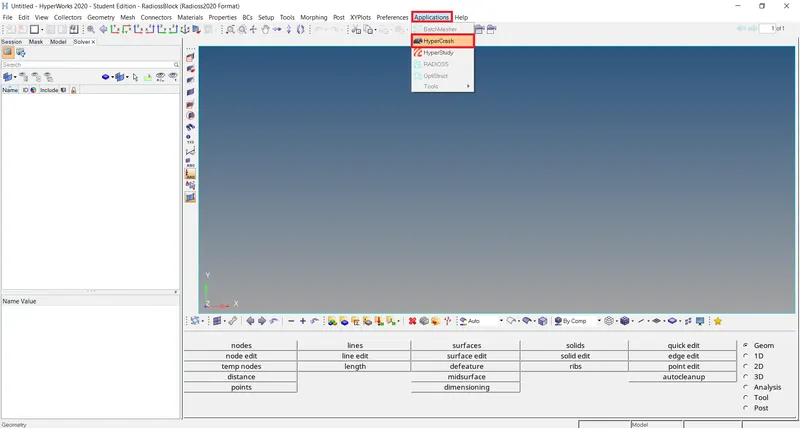
Opening hypercrash
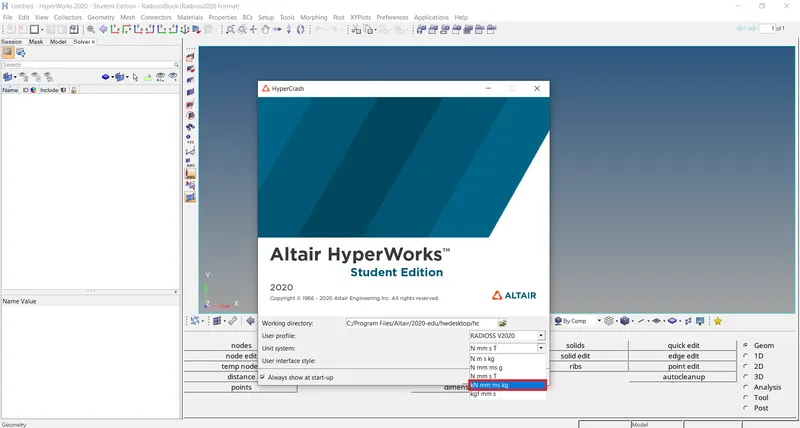
Selecting Proper UNIT SYSTEM
Select Neon starter file and drag it to hypercrash application to open the model
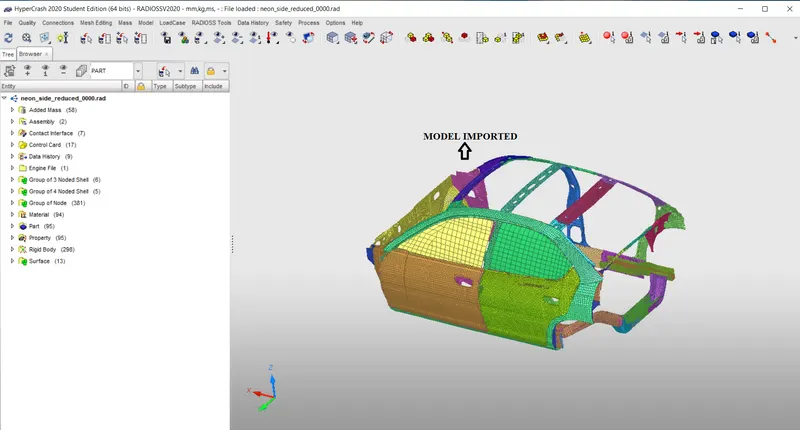
Model imported
CHECK FOR PENETRATION AND INTERSECTION:
Penetration is defined as the overlap of the material thickness of shell elements, while Intersection is defined as elements that actually pass completely through one another. All models and especially impact models should be checked for penetrations and intersections and De penetrated to ensure the integrity of the model. Penetrations adversely affect results and should be removed.
To check penetration and intersection
Got to Quality>> Check Intersection on tree >> Select parts > Click on check penetration
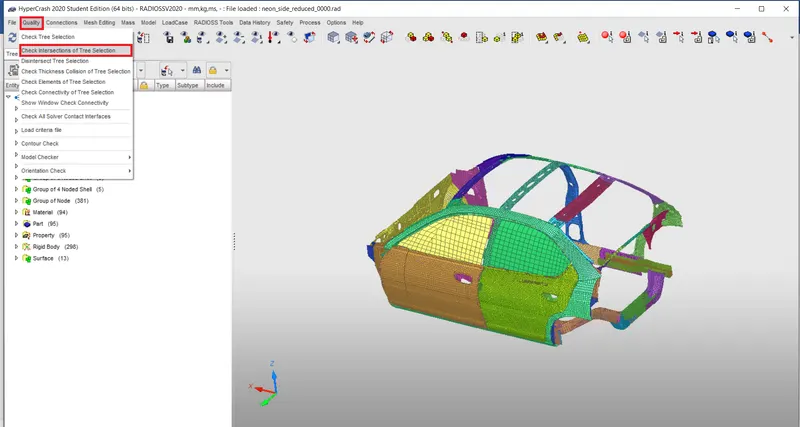
Checking for intersection and penetrations
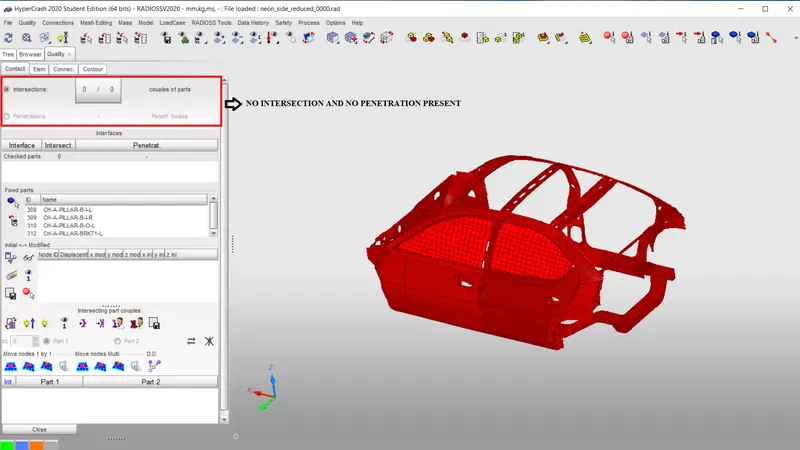
No intersection and penetrations present
We can clearly see from the above figure there are no penetrations and intersections are present in the model.
Compare the model weight with the full-scale 300k nodes model and use added masses to reach a target weight of 700kg while getting CG about the required range.
A vehicle’s center of gravity, or CG, is the theoretical point where the sum of all of the masses of each of its individual components effectively acts. In other words, from a physics perspective, a vehicle behaves as its entire weight resides at this one point. Carrying weight up high, such as a panoramic sunroof will raise a vehicle’s CG while placing heavy subsystems low in a vehicle, such as a battery pack, will work to lower it. Lower is better from a handling standpoint, as it reduces weight transfer during cornering and braking, and it also reduces the propensity to roll over.
ADD MASSES:
Mass balancing: In order to maintain the CG of a car we have to add mass for the given components, In the given model here are so many parts are missing because of the node limits in the student version
To check the CG
Go to menu >> Mass >> Balancing >> Show CG point
Before adding mass check the CG
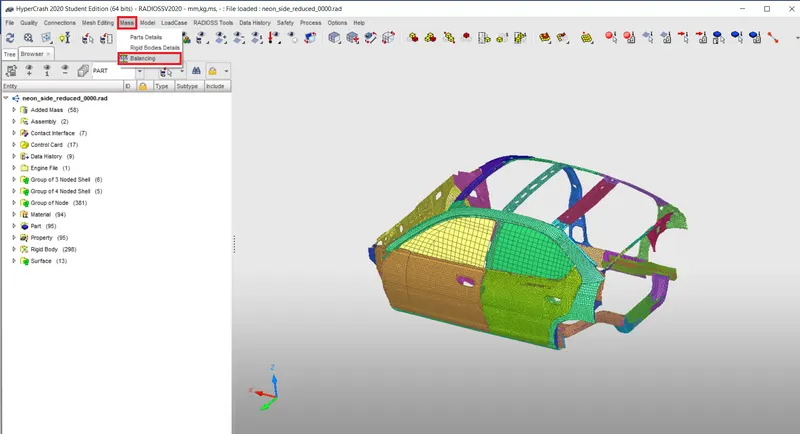
Check for CG
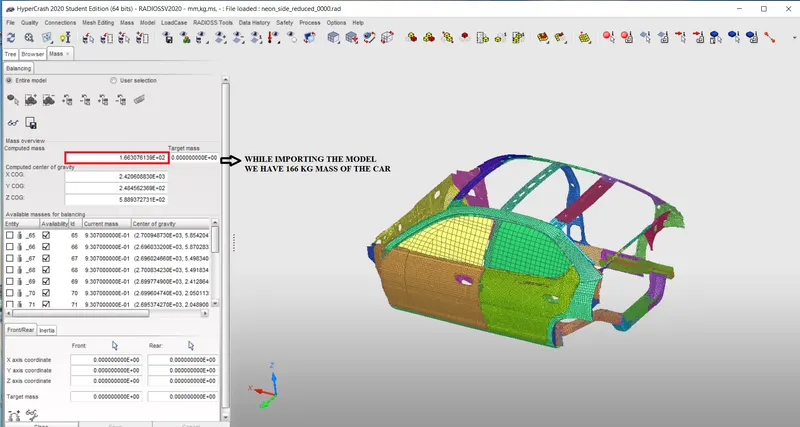
Total mass when we imported
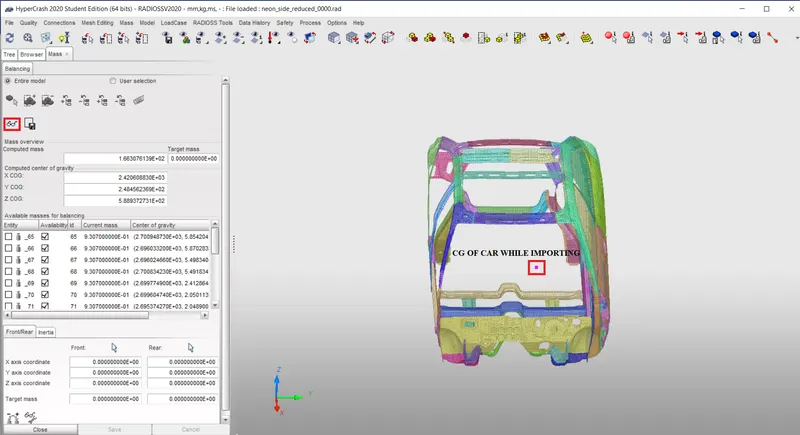
CG before adding mass
Current weight: 166 kg
Target weight: 700 Kg
- We have to add the mass in such a way that the Centre of gravity is exactly in the middle of the Cross Beam to simulate the real-time model.
- We are only worried about the position of the COG (X and Y axis) and not the height (Z-axis).
- We use Type 1 Mass, where mass is distributed on each node of the selected group.
Added Mass > Create New >> Type =1 >> Enter the Value (ex. 40kg) >>right click to pick nodes >> Select the group node by selecting in the graphics >> Select Add/Remove nodes by picking selection >> After selected hit YES >> Save
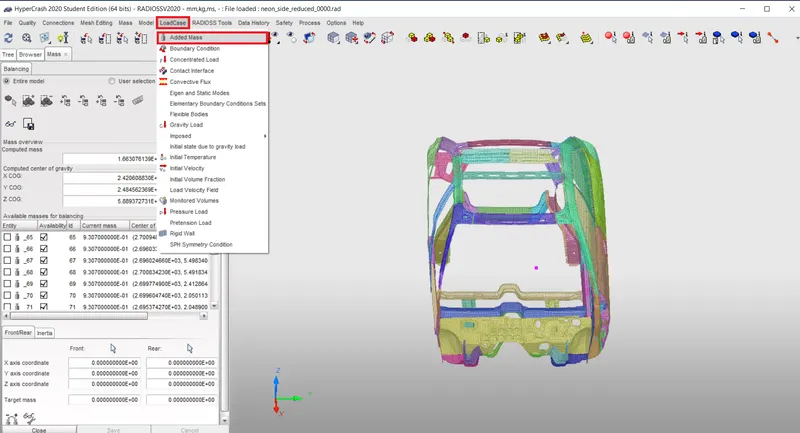
Adding mass
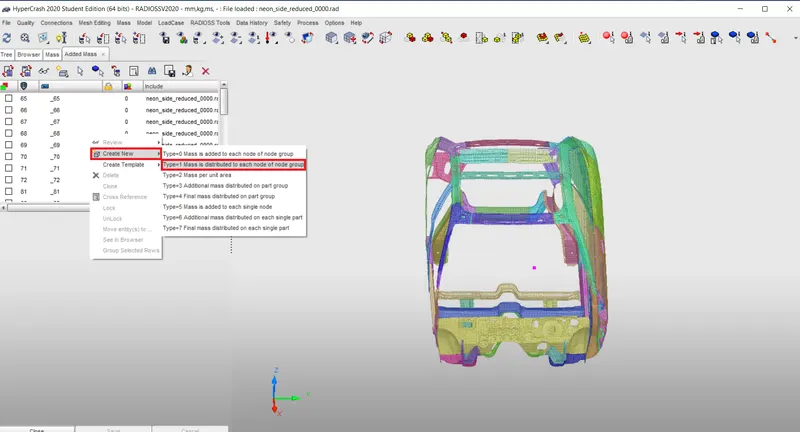
Selecting mass type as 1
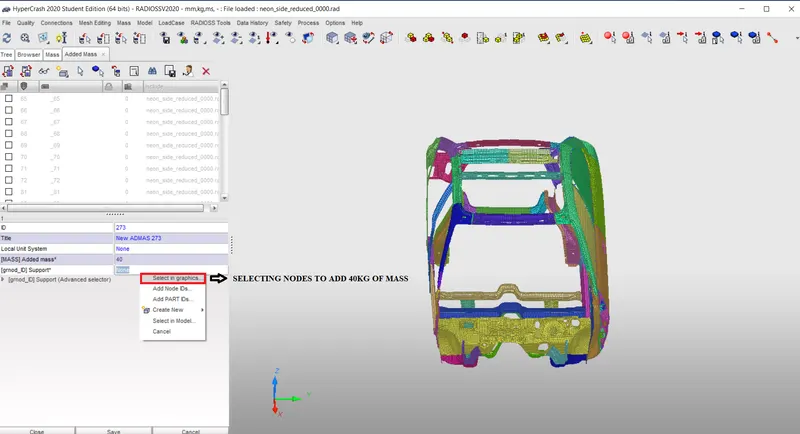
selecting nodes by graphics
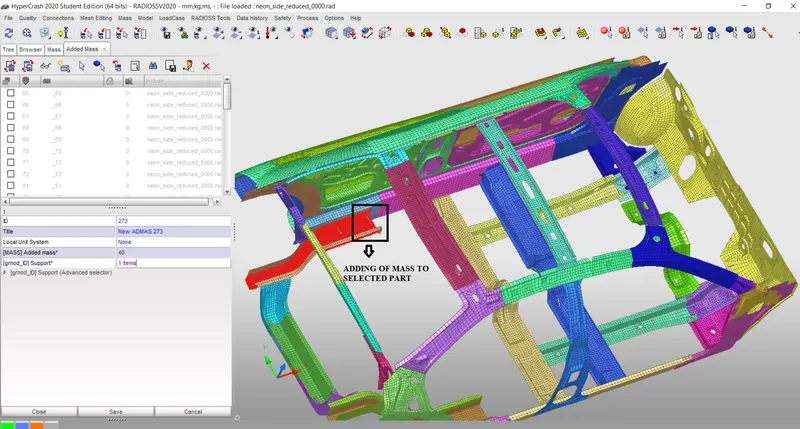
Mass added for the particular selected part
|
MASS in KG |
DESCRIPTION |
|
40 |
Left side part which supports the fuel tank |
|
40 |
Right side part which supports the fuel tank |
|
80 |
B-Pillar beam |
|
90 |
Seat cross reinforcement |
|
60 |
Driver and his seat |
|
60 |
Passenger and his seat |
|
50 |
Left side legs place |
|
50 |
Right side legs place |
|
63.69 |
Dashboard |
After balancing the mass, we achieve our target mass that is 700kg as shown in the figure below
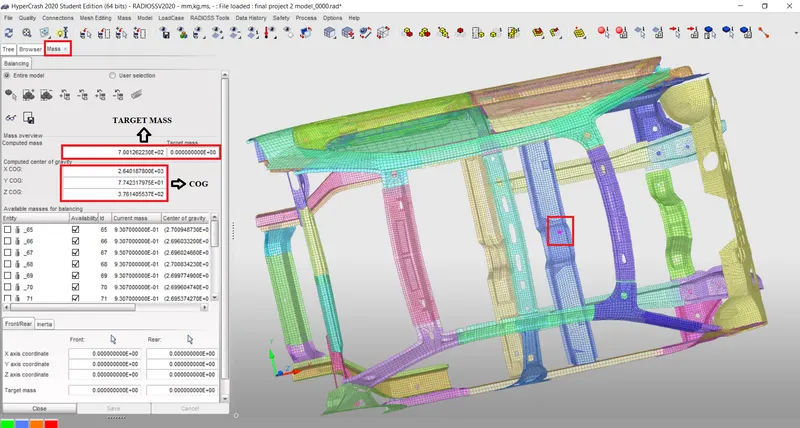
Target mass added
EXPORT HYPERCRASH FILE:
Export the changes made in hypercrash and import the same file in hypermesh to make other changes
For that
Go to File >> Export >> RADIOSS
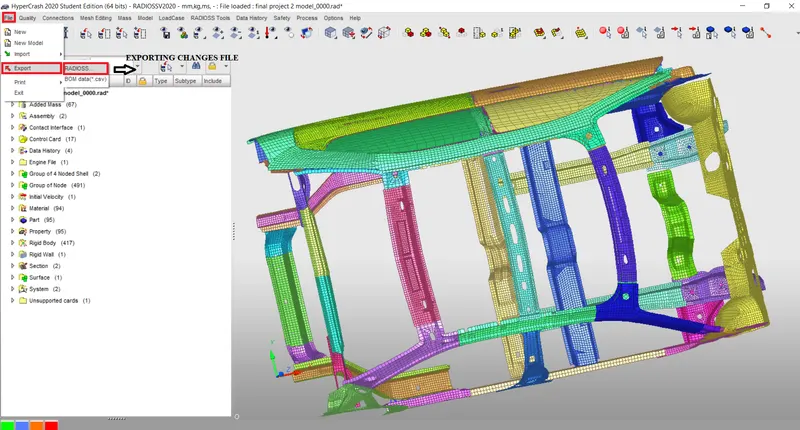
File exported
What are all the things to do and not to do in HYPERMESH and HYPERCRASH
|
SET UP'S |
HYPERMESH |
HYPERCRASH |
|
INTERFACE |
YES |
YES |
|
PENETRATION AND INTERSECTION |
YES |
YES |
|
RIGID WALL |
YES |
NO |
|
ADD MASS |
NO |
YES |
|
ADD VELOCITY |
YES |
YES |
|
ENGINE CARDS |
YES |
NO |
|
SECTIONAL FORCES |
YES |
NO |
|
SPRINGS |
YES |
NO |
|
MODEL CHECKER |
YES |
NO |
Now import the same file in hypermesh to do other changes
For that open hypermesh
Go to file >> Import solver deck >> Select Neon_side_reduced_0000.rad file >> Import
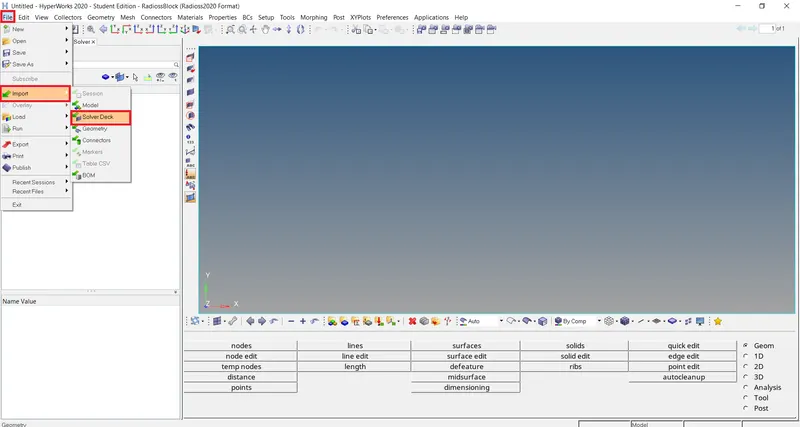
Importing starter file
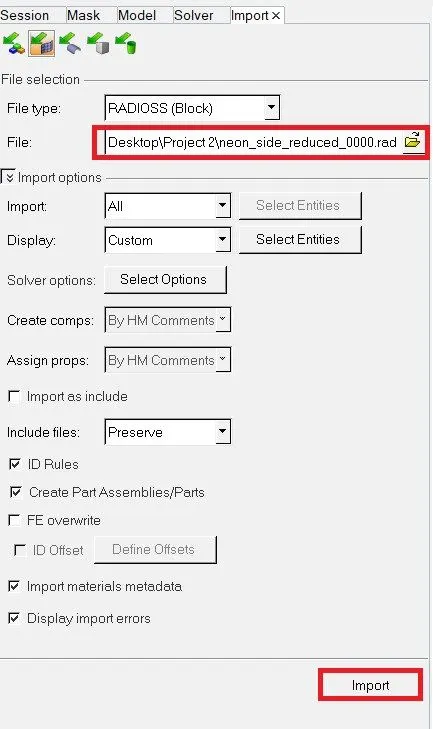
Selected starter file from the folder
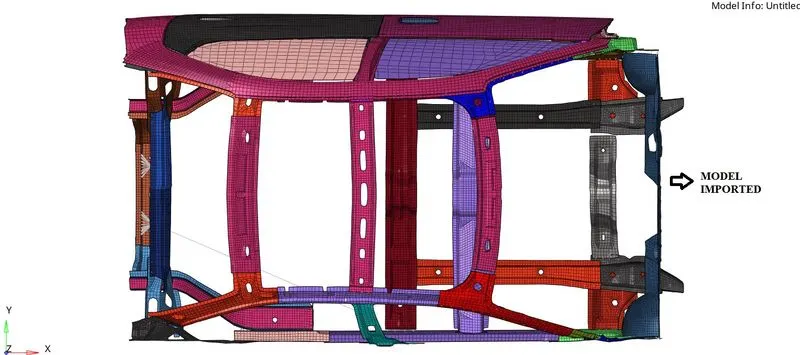
Model imported
CREATE SELF CONTACT:
In this case, the Type 7 Contact Interface is defined. Interface TYPE7 is a multi-usage impact interface, modeling contact between a master surface and a group of slave nodes. It is also possible to consider heat transfer and heat friction.
All limitations that were encountered with interfaces TYPE3, TYPE4, and TYPE5 are solved with this interface:
- A node can at the same time be a slave and a master node.
- Each slave node can impact each master segment; except if it is connected to this segment.
- A node can impact more than one segment.
- A node can impact on the two sides, on the edges, and on the corners of each segment.
- It is a fast search algorithm without limitations.
The main limitations of this interface are:
- Time step is reduced in case of high impact speed or contacts with a small gap.
- It does not work properly if used with a rigid body at high impact speed or a rigid body with a small gap.
It does not solve edge-to-edge contact (to solve this, /INTER/TYPE11 should be used along with TYPE7).
TYPE 7: NODE TO SURFACE
This interface simulates the most general type of contacts and impacts. TYPE7 interface has the following properties:
- Impacts occur between a master surface and a set of slave nodes, similar to the TYPE5 interface.
- A node can impact one or more master segments.
- A node can impact on either side of a master surface.
- Each slave node can impact each master segment except if it is connected to this segment.
- A node can belong to a master surface and a set of slave nodes.
- A node can impact the edge and corners of a master segment. None of the previous interfaces allows this.
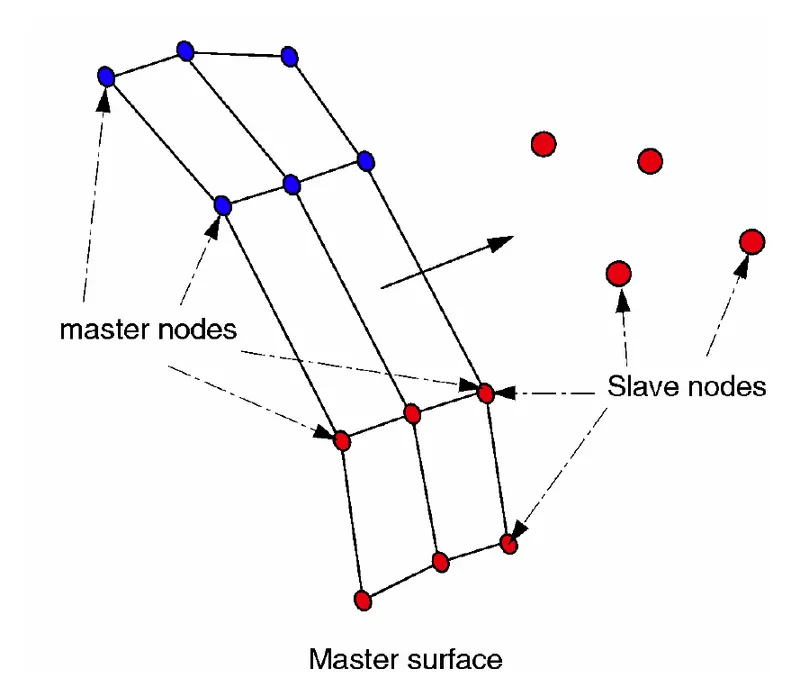
Type 7 contact
The recommended properties are as following:
1.Igap = 2 (Variable Gap took into account.)
2.Gapmin ≥ 0.5mm (minimum thickness to avoid the numerical issue.)
3.Inacti = 6 (remove initial penetrations wherever possible, else reduce to less than 30% of the defined gap)
4.Istf = 4 (Stiffness based on softer Segment)
5.Stmin = 1 kN/mm (Minimum stiffness in contact to avoid too soft contact.)
6.Idel = 2 (remove slave nodes from contact because of element deletion)
7.Iform = 2 (Frictional Forces are calculated on the basis of Stiffness parameter.)
Delete existing contacts and create new contacts with recommended properties
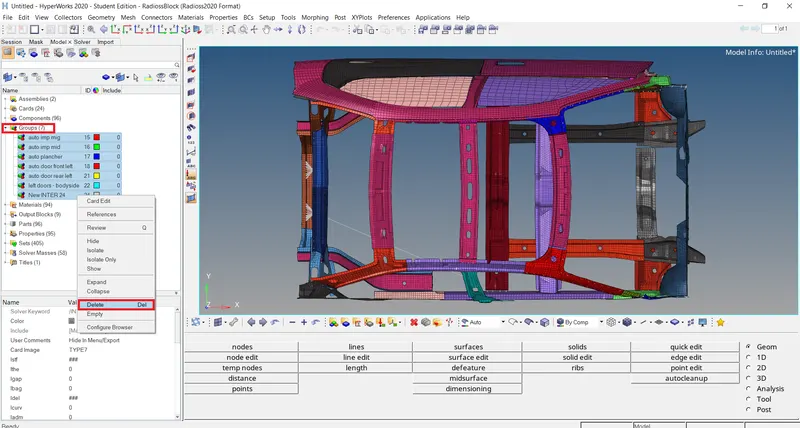
Deleting existing contacts
Now create a new contact
Goto model browser >> Right-click >> Create >> Contact >> Rename as Self contact >> Select slave node and master components >> Enter Type 7 recommended properties
We can select slave and master as a component and as well as node selection
For that, we just have to right-clicked where selecting nodes are components there is one option called create/Edit select and proceed with nodes or components
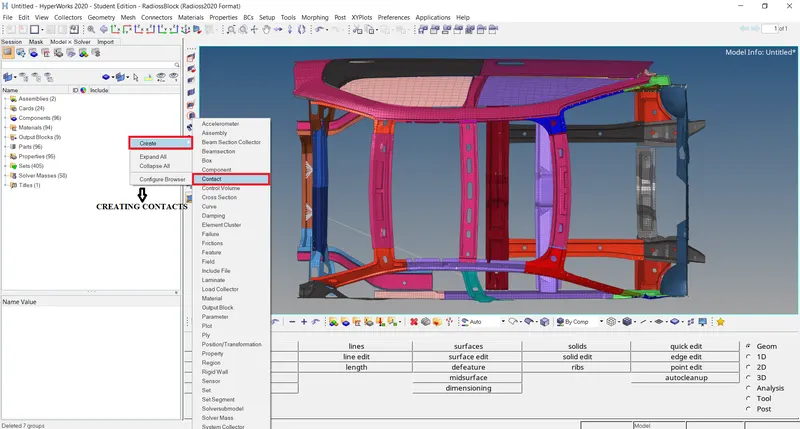
Creating new self-contact
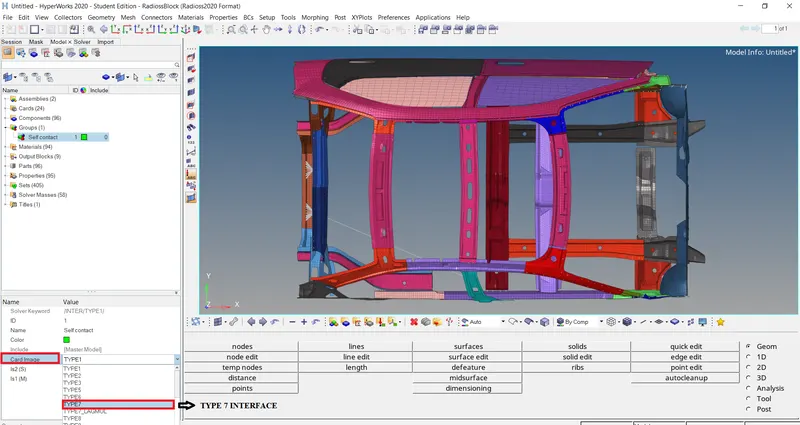
Selecting TYPE 7 contact
Then after this step, we simply need to give in the Slave nodes and the master segment. Since we are defining a Self-Impact in the model, the Slave and Master segments for this contact will be the entire given model. So, we then select the slave and master in the graphics area.
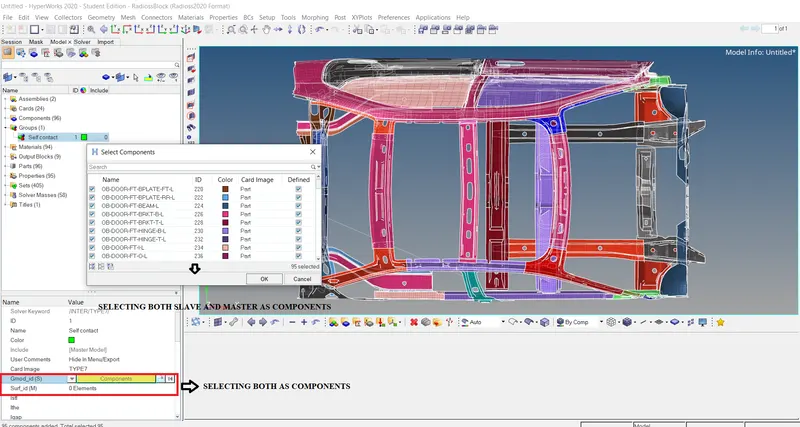
Selection of slave and master components for self-contact
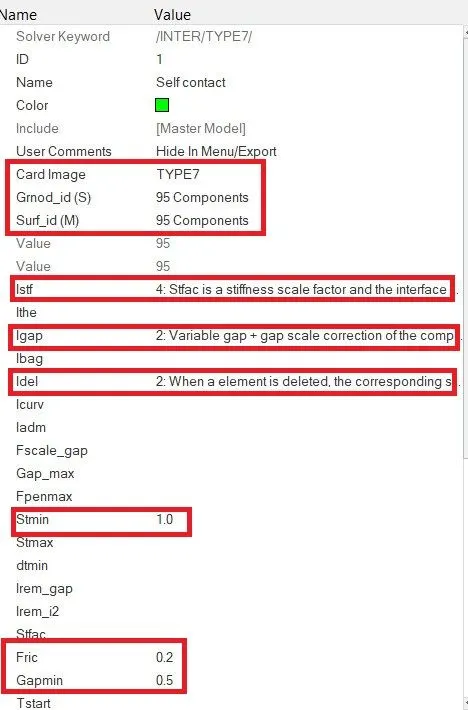
Recommended properties
check whether master and slave nodes selected proper
For that Simply right-click on self-contact >> Review
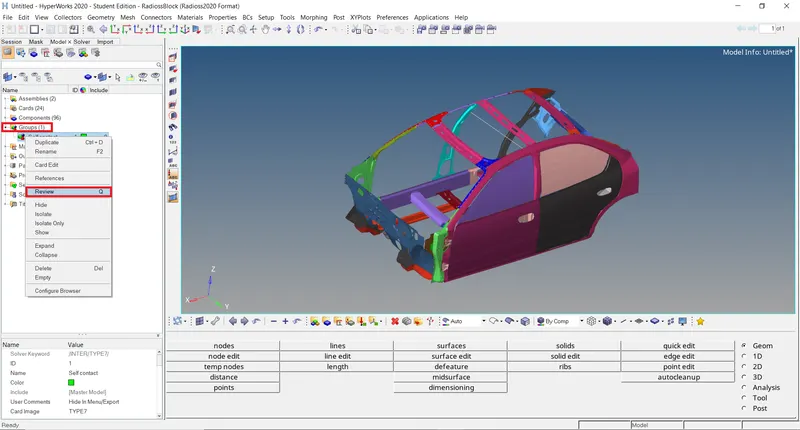
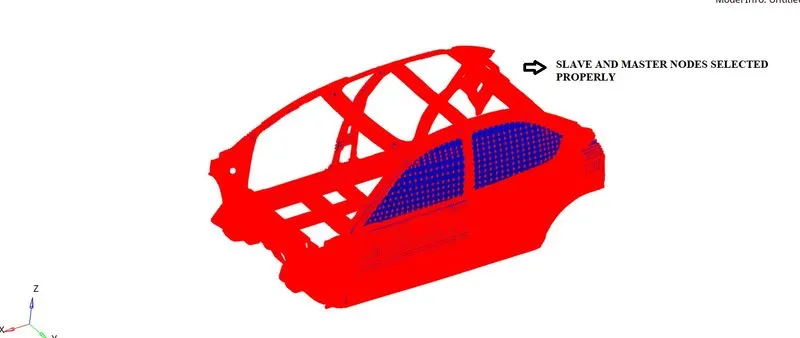
Slave and Master components Displayed
CREATE RWALL CYLINDER:
A rigid wall is a nodal constraint applied to a set of slave nodes in order to avoid the node penetration to the wall. If contact is detected, then the slave node acceleration and velocity are modified. Mainly to constrain the movement of a moving body after impact, we will be using a plane wall. An infinite plane wall is a plane that extends to infinity. It is defined with two points.
Rigid wall entities provide a method for treating a contact between a rigid surface and nodal points of a deformable body. In the Radioss user profiles, a rigid cylinder is created in the Model and Solver browsers.
To create an RWALL Cylinder
Go to Slover browser >> Create >> Rwall >> Cylinder
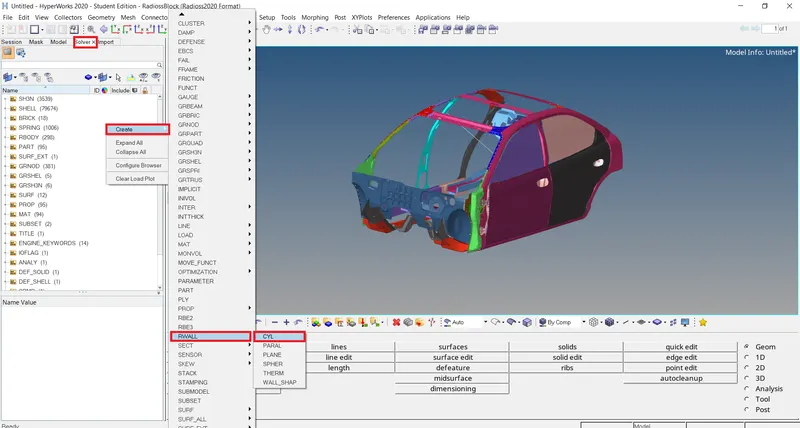
Creating an RWALL Cylinder
We need a reference node to create an RWALL Cylinder so, for that, we are creating a temp node in the mid of B-Pillar
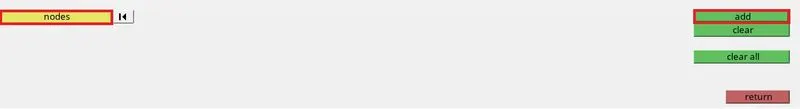
Temp node creating
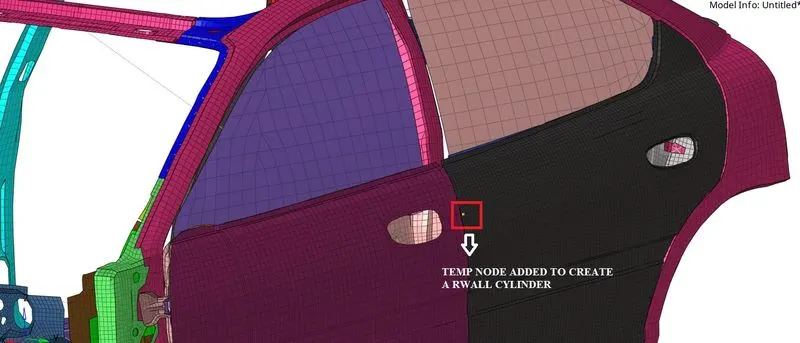
TEMP node created
Now translate this node to some distance with the reference of this translate node we have to create an R-wall Cylinder with respect to that CO-ORDINATES
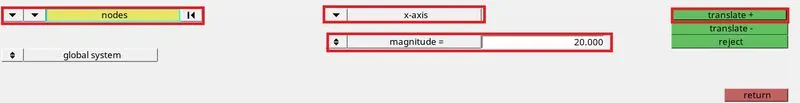
Translate node
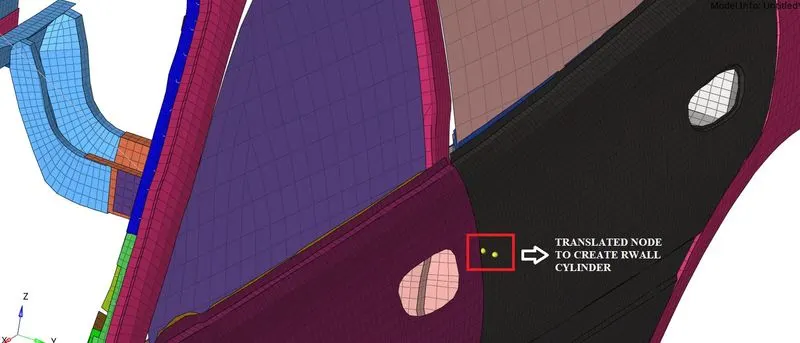
Node Translated
Now select the translated node and note down the X, Y, and Z coordinates
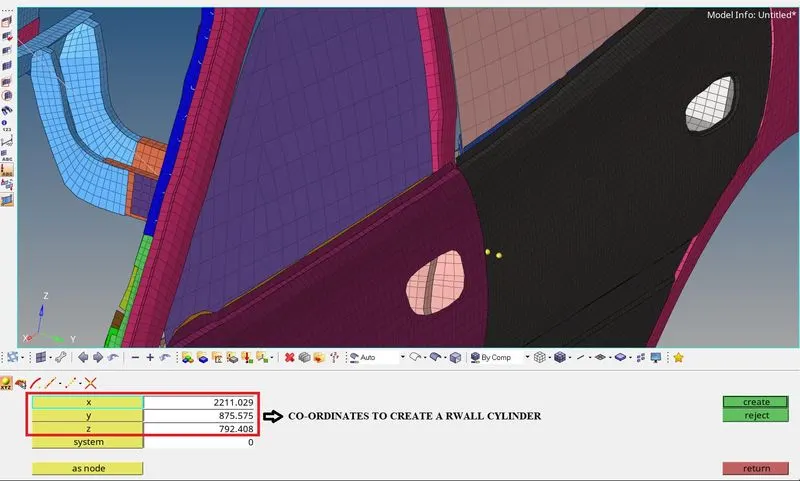
Co-ordinates X, Y, and Z values
- It is a Shell element with no thickness (gap) and infinite thickness.
- A search tolerance is given (optional) so that the nodes within the range will be taken as slaves.
- We are going to create an Infinite Cylinder-type Rigid wall.
Enter the coordinates of the Temp node [XM, YM, ZM] >> Enter the Direction of the Normal [0, 0, 1] >> Select GRNOD_ID 1: set of displayed nodes >> Dsearch : 1000/1500 >> ok
The rigid wall is facing in the direction of the Y-axis.
- We have to provide frictional parameters for the rigid wall Cylinder when the slave nodes come in contact
- Friction type [Slide] = 2: Sliding with friction
- Frictional Coefficient [FRIC] = 0.1
- The D-search distance we can use around the range of 1000 mm. All the Nodes within this distance will be considered as salve nodes for the contact between the car and the Rigid Wall Cylinder.
- We can add a separate set of nodes to this Rigid wall Cylinder that the system should consider for Slave nodes in the option of [grnod_ID1]as shown below figure. We can use this option and add all the nodes in the model to the Slave nodes.
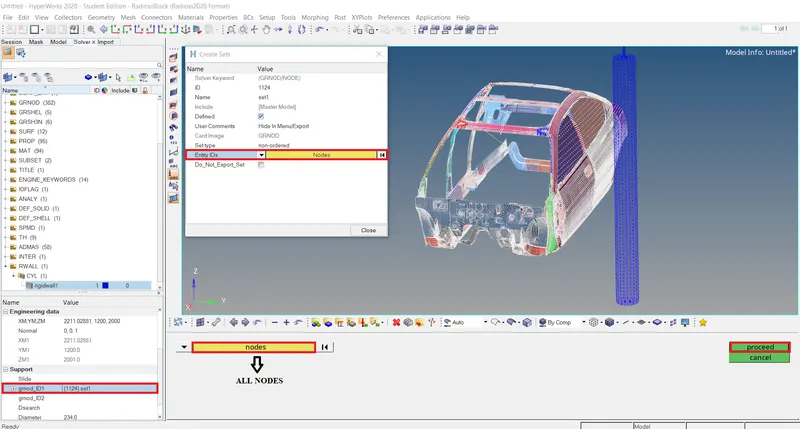
Selected Slave nodes
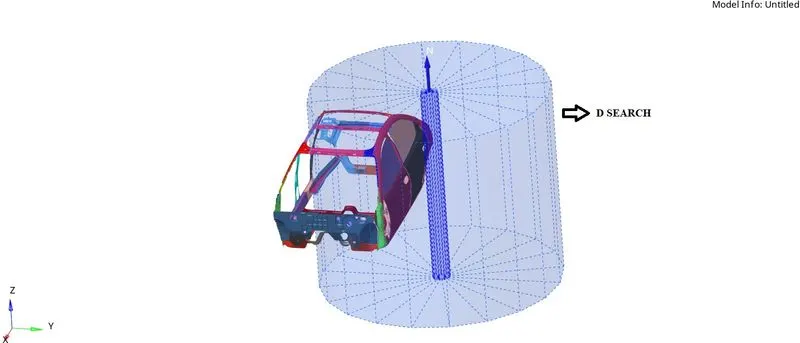
D-Search
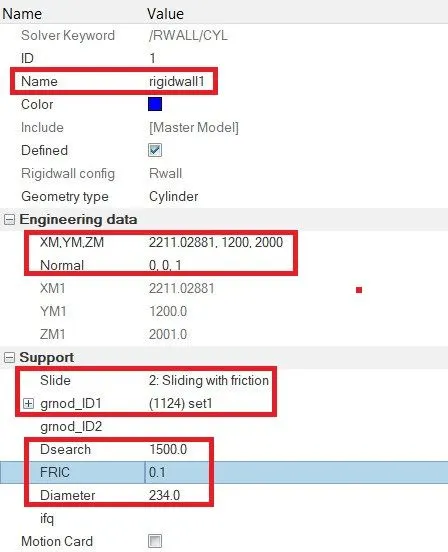
R-Wall Cylinder Tab
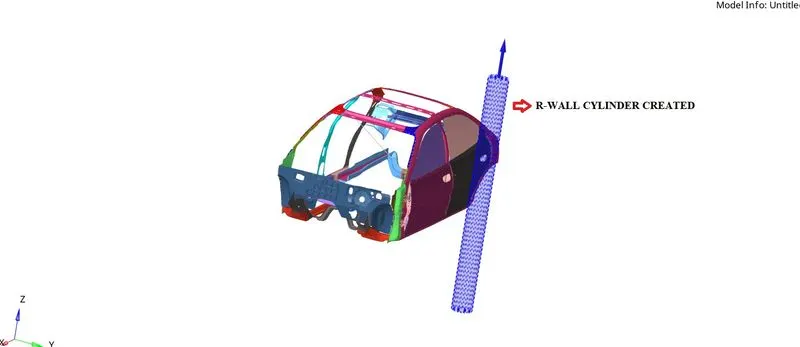
Rigid wall with infinite Cylinder created
CREATE VELOCITY:
Initial velocity 35 mph.
Converting 35mph into ms
1mph = 0.447 ms
So, 35mph = 15.6464 ms
- The initial velocity (Vi) is the velocity of the object before acceleration causes a change. After accelerating for some amount of time, the new velocity is the final velocity (Vf).
- Initial velocity = [Final velocity - (acceleration×time)]
- vi = vf - at.
- vi = initial velocity (m/s).
To create a velocity
Go to solver browser >> Create >> Boundary conditions (BC) >> Inivel
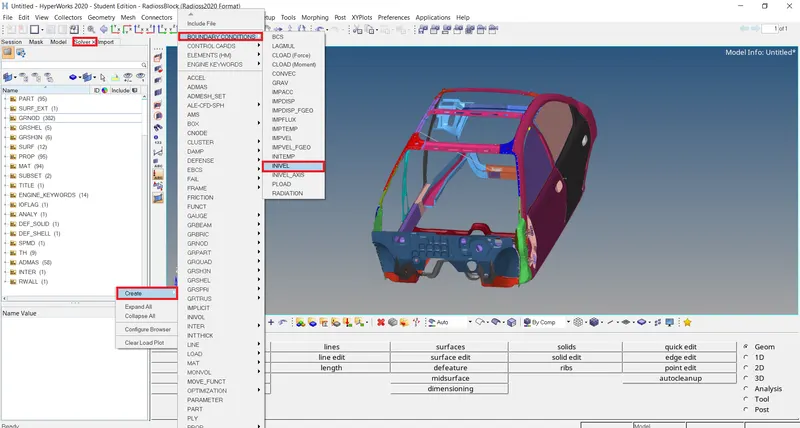
Creating velocity
Define the Node group on which specified initial velocities are applied(grnd_ID1).
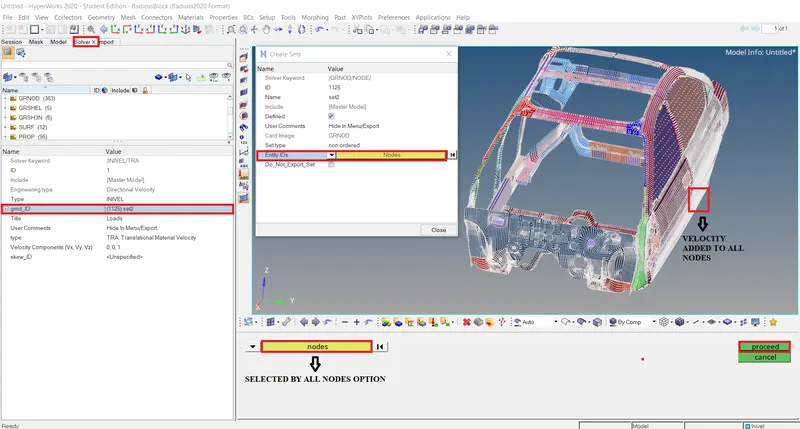
Selecting GRNOD_ ID 1 slave nodes
Define the Type of Velocity (Translational /Rotational).
Since we need to apply the velocity in a translational Y-Direction, define the velocity 15.646m/s
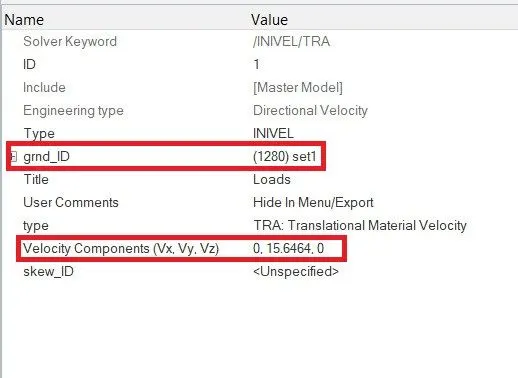
INIVEL Tab
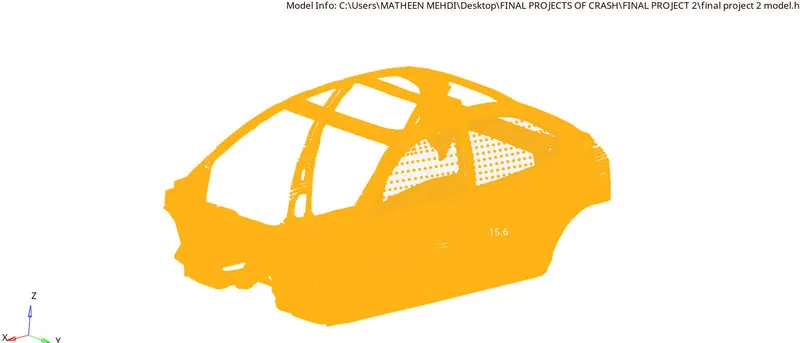
Review of inivel nodes
CREATE SECTIONAL FORCES:
Creation of Sections at B-Pillar and Driver rail in order to Study the sectional forces
We have to know how the forces are transmitted from the B-Pillar to the rails and the rate of deformation. It is done in order to ensure the safety of the passenger.
Certain components have to crash (deform) more than the other so that the forces are distributed correctly leaving very little force left to transmit inside the cabin.
We are creating sections for the following parts:
|
Sl. no |
1 |
|
DRIVER SIDE SECTION |
Driver rail |
|
B-PILLAR SIDE SECTION |
B-Pillar rail |
Create a moving frame: Use the Systems panel to create rectangular, cylindrical, and spherical coordinate systems. Use this function when you want to define nodes, loads, and constraints in a different coordinate system to create a section and Frame
Go to Slover browser >> Create >> Section >> SEC >> Rename as Driver cross section
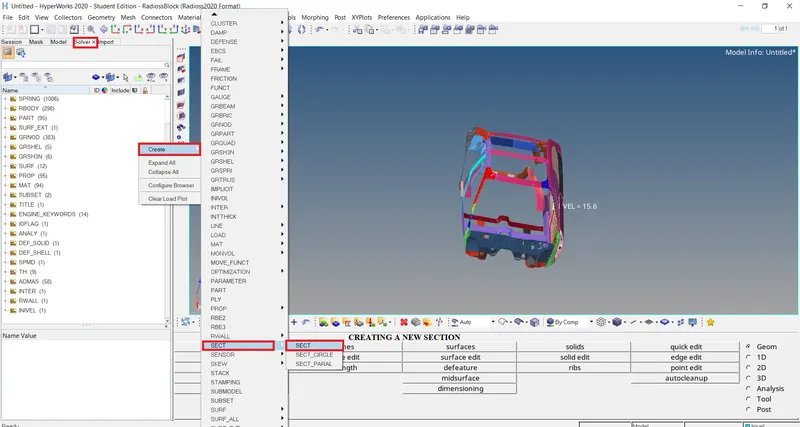
Creating section
Now when we create a section a new tab will display there, we have to select N1, N2, and N3 nodes
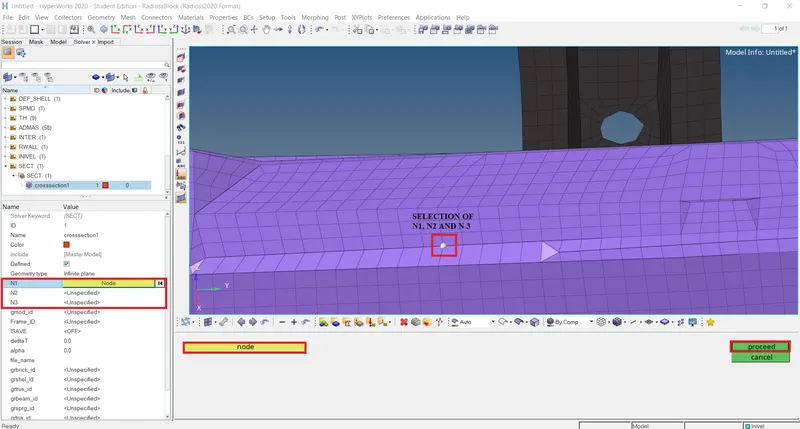
Selecting N1, N2, and N3
- We then need to select the three nodes on which we need the Frame system.
- In this case setup, we need to define around 6 sections.
- We need to make sure that the normal of all the sections defined need be in one particular direction. All the normal can be facing either the wall or even away from the wall. We need to make sure that they are in a single direction.
- We can create a Section just in the same way as we created a section system.
- We need to right-click in the solver browser and select frame
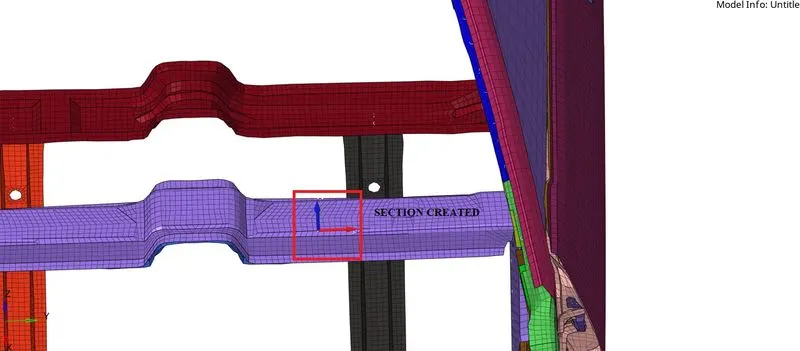
Section created
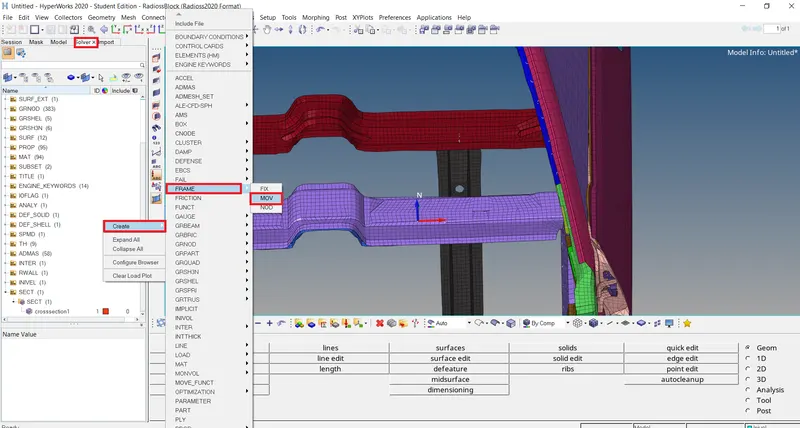
Creating moving frame
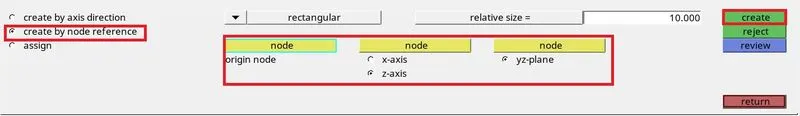
Selecting frame nodes
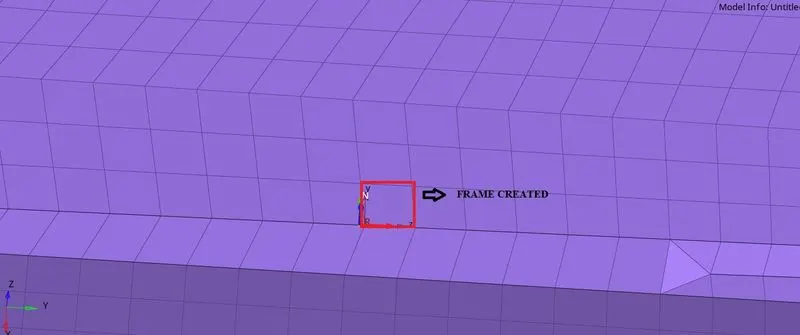
Frame created
Now assign this frame system in section
Define the Nodes with reference to the Axis of the Frame.
• Enter the values of Delta T and Alpha Value as 0.1 and 0.67 respectively.
• Define the cutting plane by a group of elements and its orientation by a group of nodes(grshell_ID)
• Hence, the sections will be created.
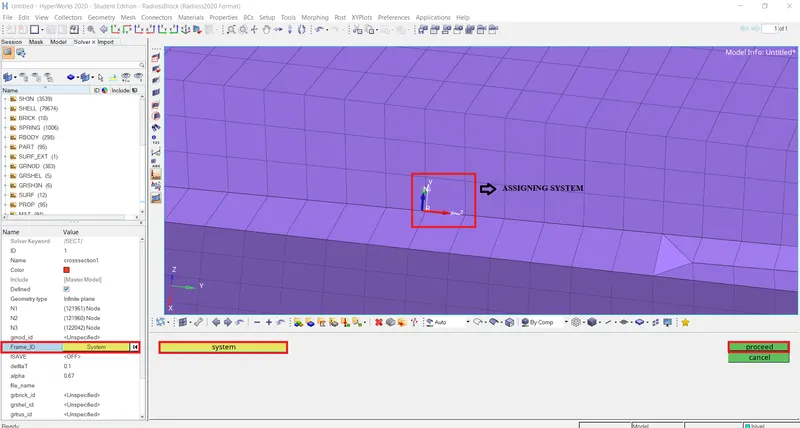
Assigning frame system
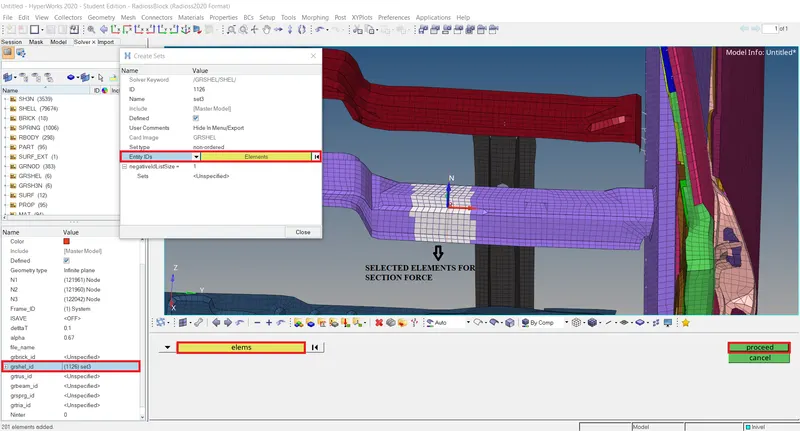
Selected elements for section forces
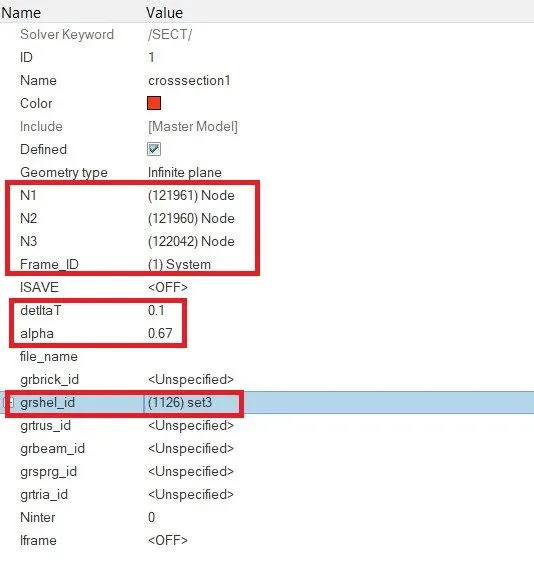
Section Tab
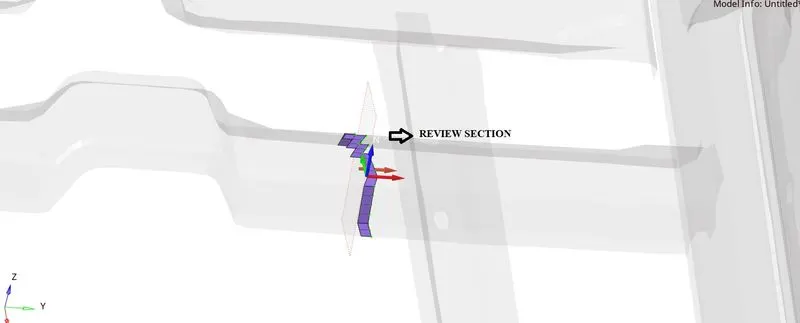
Final Section Created
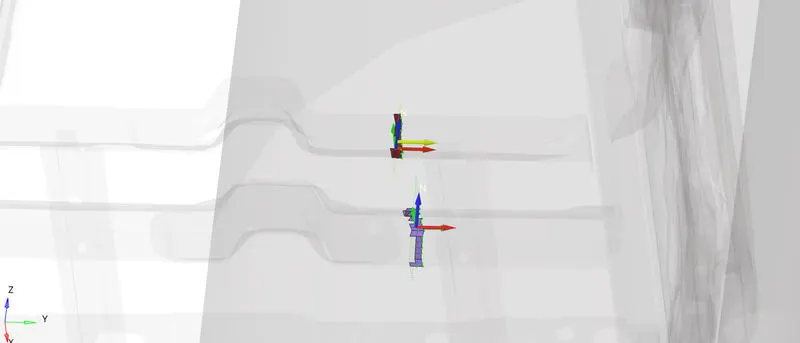
All Two section created
CREATE SPRINGS:
- We are planting Spring elements to study the intrusions (forces inside the cabin causing deformation/rupture).
- Create 3 parallel spring elements.
- Springs can be created from the 1D Panel > Springs
To create a spring first as temp node at that particular selected node then select another node on other to see deflection after crash simulation
After adding nodes now
Go to 1D page >> Springs >> Select first and Second node >> Create spring
Spring tab
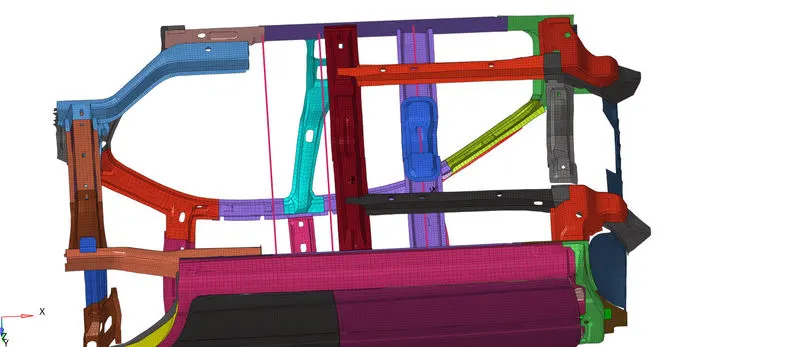
Springs created
CREATE PROPERTIES TO SPRINGS:
To create spring property
Go to model Browser >> Create >> Property >> Rename as Intrusion springs
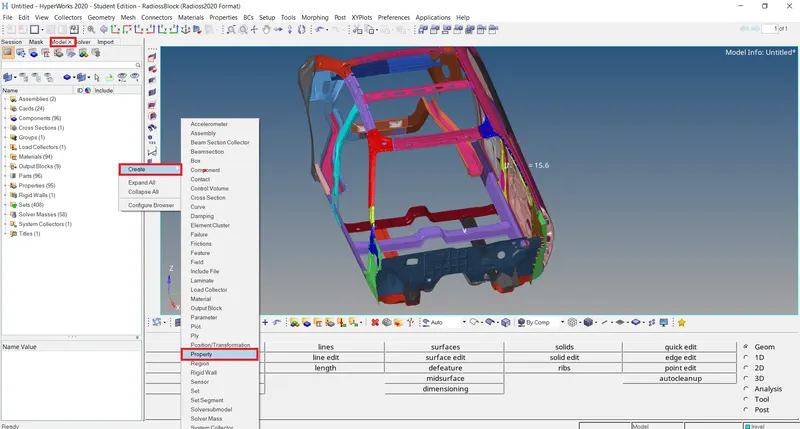
Creating new property for spring
After creating a property, a new tab will open there we have to select CARD image as P4 SPRING and Mass as 0.001, and Stiffness as 0.001
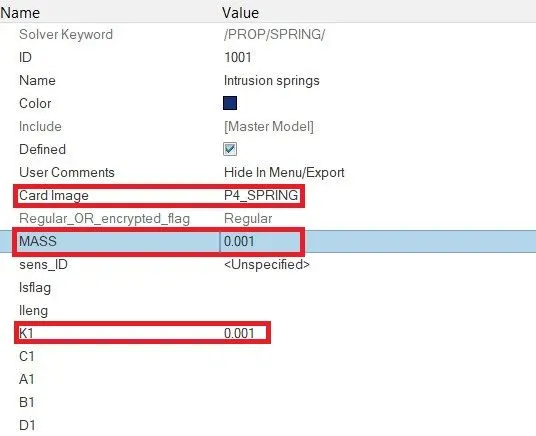
Changes CARD IMAGE as P4 spring
REQUESTING TH FOR INTRUSION SPRINGS, PEAK VELOCITY NODE, SECTION FORCE:
Delete existing TH and create new
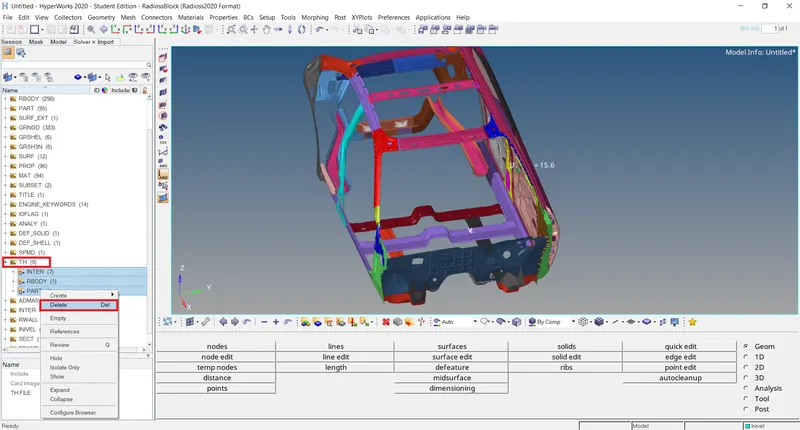
Delete existing TH
They are Output files that are requested in the Starter File.
- All the Global variables (Internal energy, Kinetic energy, Contact Energy, Hourglass Energy, etc.) are already requested by default.
- We have to call for additional Time History files for the boundary conditions that we have created for the frontal crash model.
- We can create the Output requests from within the Solver Browser:
Solver Browser > Right Click > Create > TH > Select the Output Request
|
Output Requests |
Boundary Conditions |
|
INTER |
i. Self-Impact |
|
SPRING |
i. Intrusion on the Fuel tank ii. Intrusion on the B-Pillar iii. Intrusion on the Hinge pillar |
|
RWALL |
i. Rigid Wall |
|
SECTION |
i. Driver Rail ii. B-Pillar Rail |
|
NODE |
i. Peak velocity node on (NODE ID 337773) |
To create TH
Go to Slover browser >> Right-click >> Create >> TH >> Select node >> ok
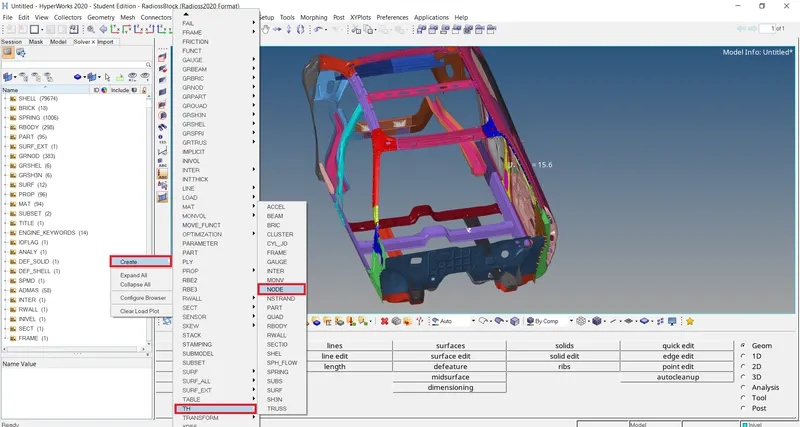
Creating TH for node
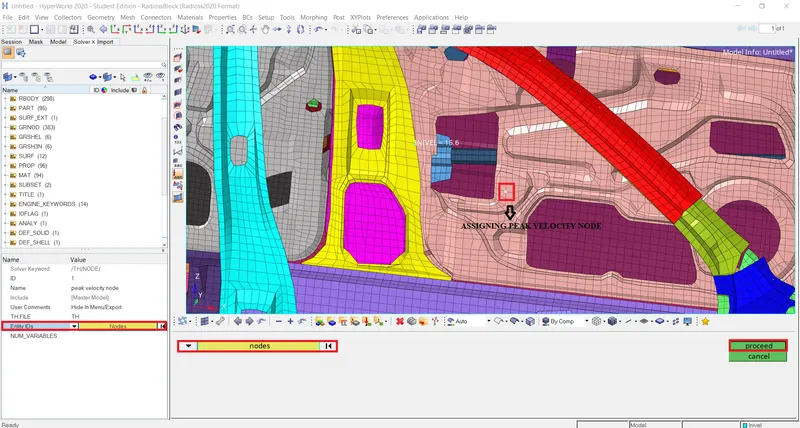
Assign Peak velocity node
Follow the same steps to create other TH as well
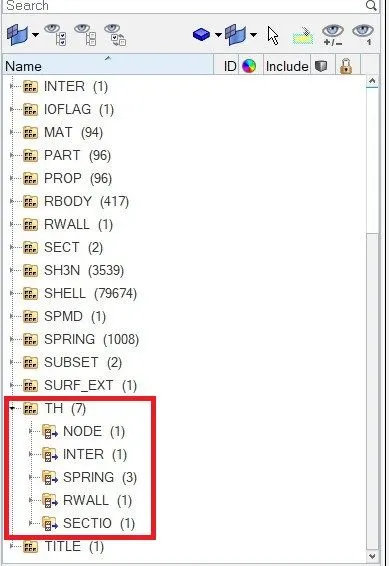
Output Requests
CREATE REQUIRED CARDS:
TIMESTEP CONTROL
|
Engine Card |
T SCALE [Scale factor] |
Tmin [Critical Timestep] |
Description |
|
ENG_DT_NODA |
0.67 |
0.0001 |
Mass is added to the node when the computed timestep becomes smaller than the critical timestep. |
|
ENG_DT_BRICK |
0.9 |
0.0001 |
Controls the timestep by small strain formulation on the elements if they cause the timestep to drop. |
|
ENG_DT_INTER |
0.9 |
0.0005 |
Uses the default constant timestep method. |
Enter T stop as 80ms and T freq as 5
Go to ENG_RUN enter T stop as 80ms
For T freq
Go to ENG_ANIM_DT enter T freq as 5
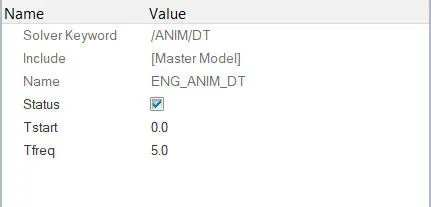
ENG_ANIM_DT card
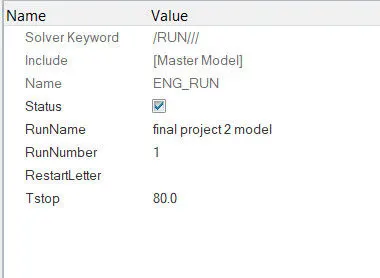
ENG_RUN card
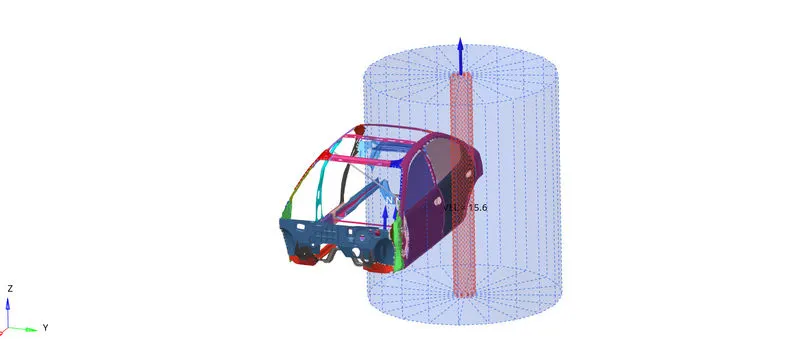
Final Step-Up
MODEL CHECKER:
This is the last and final check before giving it for simulation.
The Model checker will give us any warnings and Errors regarding the model definition and, the boundary and Kinematic conditions, etc.
For example:
- Boundary Condition is not defined properly
- Incompatible Kinematic Condition
- The Part Property or material is not defined properly, etc.
- We can avoid the Warnings as the solver will take care of them.
- But we must fix every Error in order to get a successful simulation free of problems.
Tools > Model checker > Radioss block > Check Runs
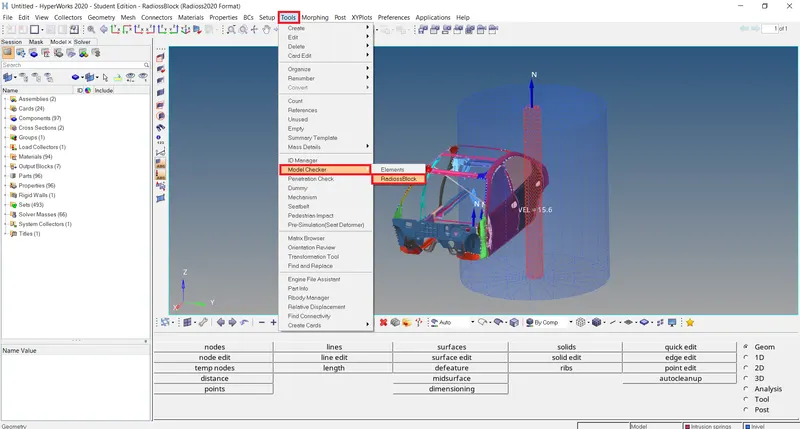
Model Checker
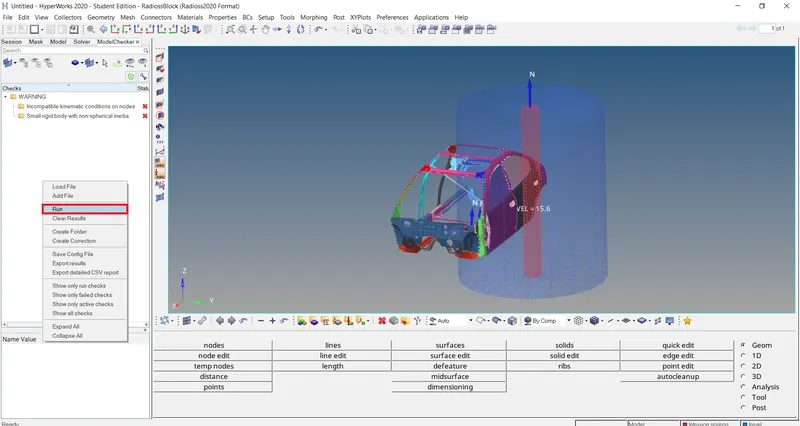
Run to Check Errors
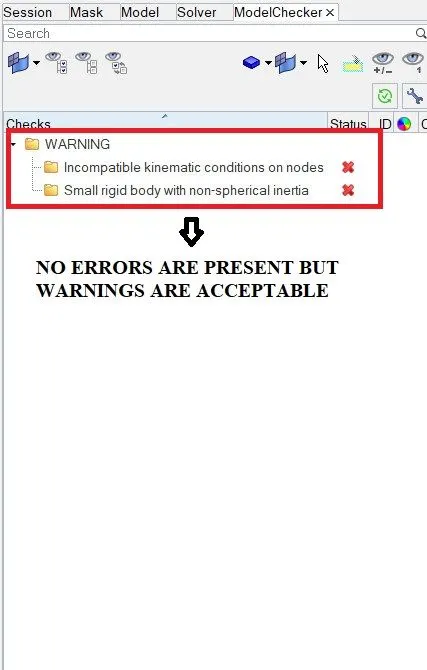
Model checker Tab
RUN THE ANALYSIS:
Analysis >> Radioss >> Input File: (File Location) >> Hit Radioss
The input file is the same Started file (contains model information) that we had just imported.
The animation video along with the frames will be saved in the same folder where the starter file exists.
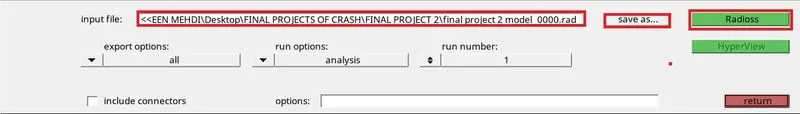
Analysis Tab
REVIEW THE SIMULATION :
We have to import the animation file in HyperView first:
HyperView >> FIRST_RUN. h3d >> Apply
- The tools to review the simulation are available on HyperView.
- HyperView is a post-processing and visualization environment for FEA that gives the output of the analysis in a simulation format that is user-friendly to understand.
From the simulation, we can review how the impact force acts and causes deformations and point of rupture on the model
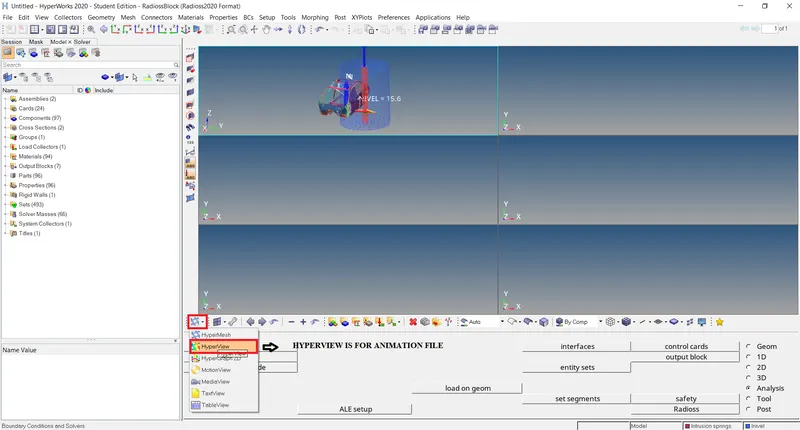
Selecting Hyperveiw
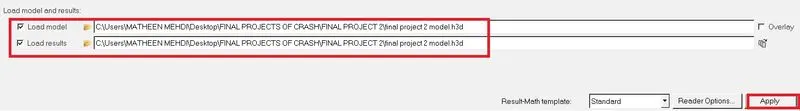
Select Animation file to open
ANIMATION FILE'S
1. Normal View
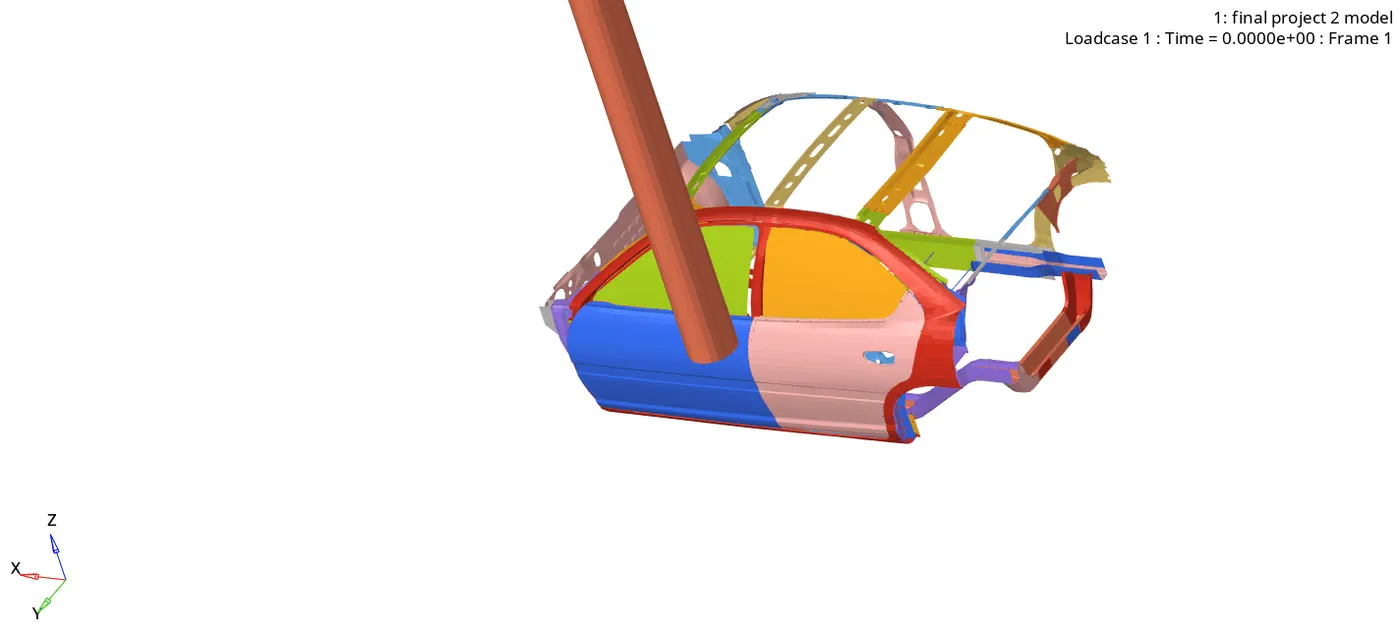
2. Von-misses
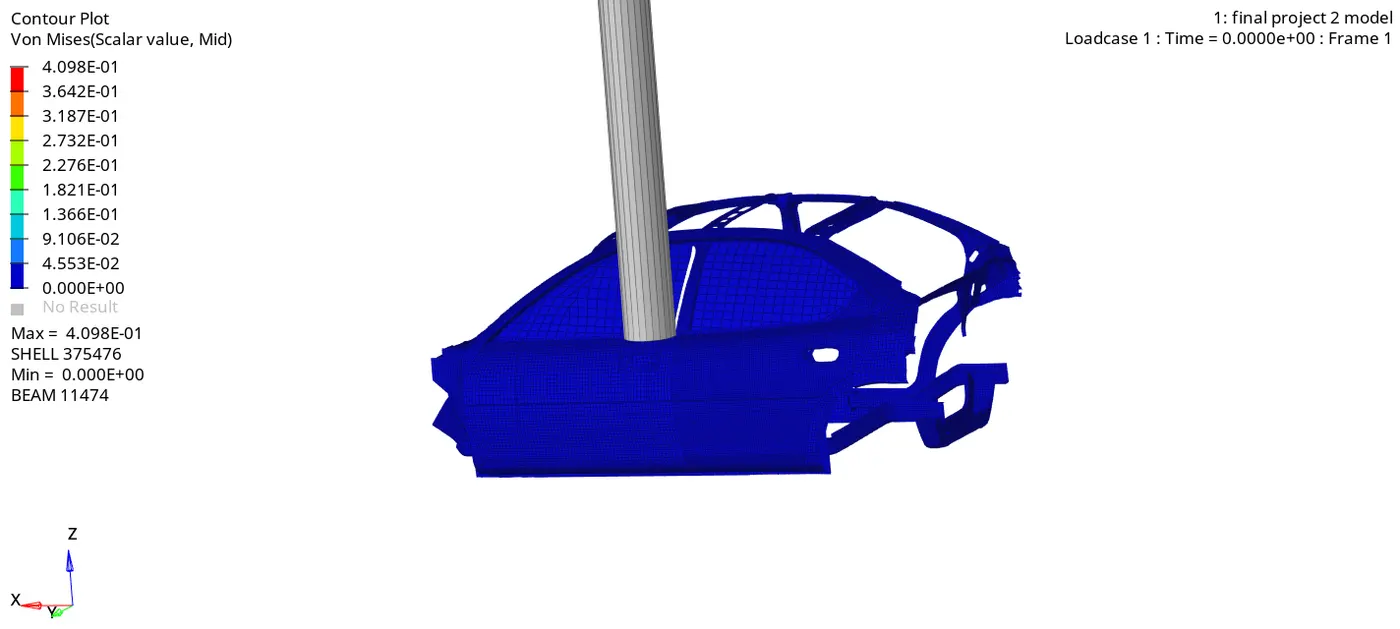
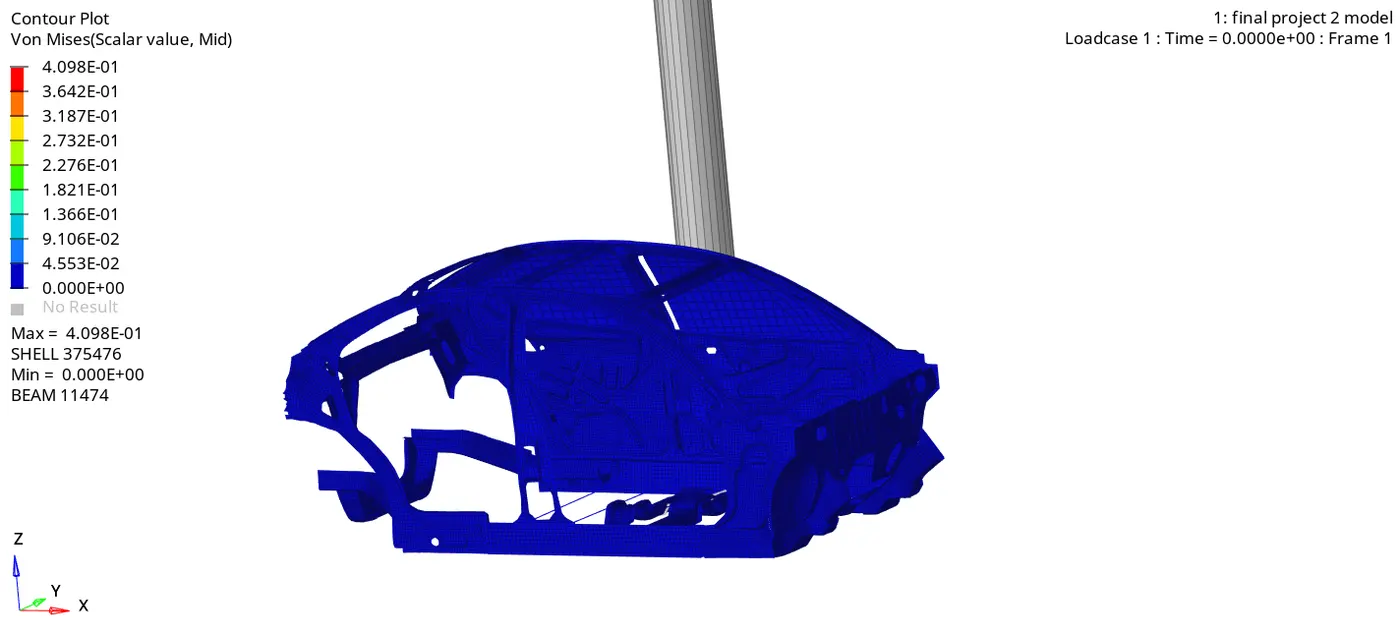
From the simulation, we can see that initially, the car is hitting the R-wall cylinder with a velocity of 15.64m/s while hitting the first impact is with B-Pillar then the forces going to transferred to the left and right and front direction in the roof rail and cross member in the bottom as shown in below figure here In each stage the forces going to reduce because of energy observed
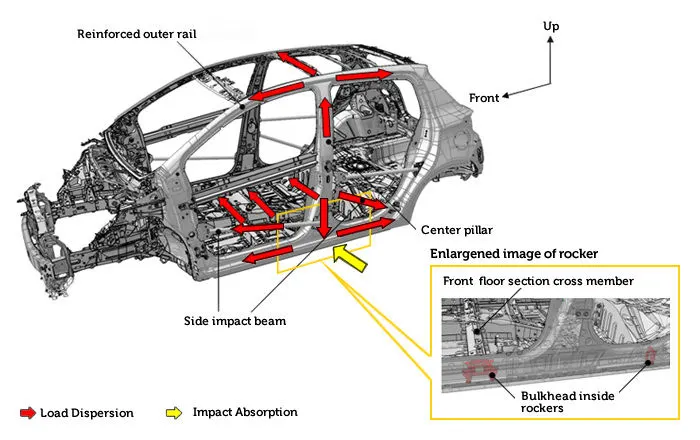
How the forces are transferred is shown in the above figure:
Results after simulation:
1) Energy and Mass error:
- At the end of the simulation, do the energy error and mass error checks and determine whether results would be acceptable
- Open the save location file and click on the output file of the simulation to check for the Energy error and Mass error.
- If the error is negative, it means that some energy has been dissipated.
- In the case of under-integrated elements (Belytschko shells, solids with 1 integration point), the Hourglass Energy can explain a negative Energy Error since it is not counted in the energy balance. The normal amount of Hourglass energy is about 10% to 15%.
- If the error is positive, there is an energy creation.
- In the case of using QEPH shell formulation or fully integrated elements, the Energy Error can be slightly positive since there is no Hourglass energy and the computation is much more accurate. An error of 1% or 2% will be acceptable.
- In the case of a larger positive energy, the source of this energy has to be identified. Incompatible kinematic conditions can lead to such a situation.
- If the error reaches ±99%, the computation has diverged; except in the first cycle of a run for which the initial energy of the system was null so that a relatively false energy balance often introduces large relative error.
After simulation run
Check the Starter Output File for Errors:
- A starter Output file of .out format is generated after analysis.
- The Output file contains the data during simulation, such as Cycle, Timestep, Energies, and Errors.
- We have to check for energy and Mass error which means that the solver did not need to add mass onto the nodes to reduce the timestep to further avoid the Hourglass Error.
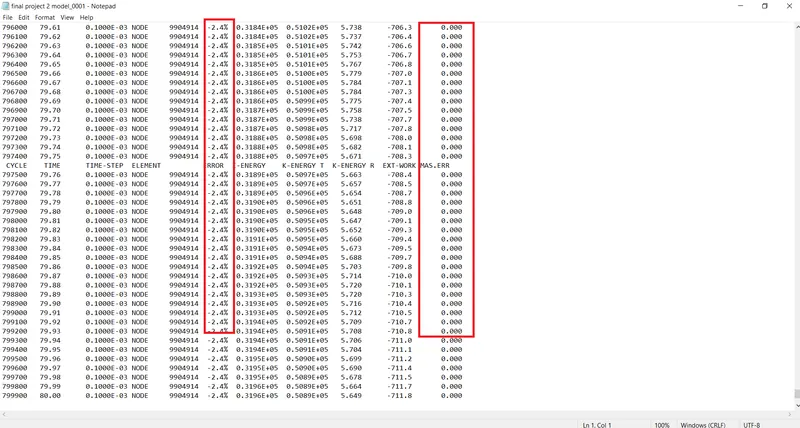
Starter out file
OBSERVATION:
- The Energy Error is Negative and has been linearly increasing up to -2.4% only, which is acceptable.
- Mass error is zero which is acceptable
- We can conclude that there are no errors in the analysis.
PLOT THE GRAPH AND COMPARE RESULTS:
Some basic definitions of energies:
- Energy: Energy, in physics, the capacity for doing work. It may exist in potential, kinetic, thermal, electrical, chemical, nuclear, or other various forms. In FEA we have Total Energy, Internal Energy, Kinetic energy, Contact energy and hourglass energy
- Total Energy (TE): Total Energy is the sum of Internal Energy, Kinetic energy & External Work
- Internal Energy (IE): The internal energy of a thermodynamic system is the energy contained within it. It is the energy necessary to create or prepare the system in any given internal state. It does not include the kinetic energy of motion of the system as a whole, nor the potential energy of the system as a whole due to external force fields, including the energy of displacement of the surroundings of the system. It keeps account of the gains and losses of energy of the system that are due to changes in its internal state
- Kinetic energy (KE): In physics, the kinetic energy (KE) of an object is the energy that it possesses due to its motion. It is defined as the work needed to accelerate a body of a given mass from rest to its stated velocity.
- Contact Energy (CE): Contact energy is the energy acting opposite to the system to prevent the penetration acting on the system due to the applied load case.
- Hourglass energy (HE): This is usually done by adding extra stiffness or viscosity across the diagonal which adds extra strain energy into the system and we call this Hourglass Energy.
The tools to plot the graph are available on Hypergraph.
Hypergraph 2D >> Data File >> FIRST_RUNT01 >> Apply
A hypergraph is a data analysis and plotting tool that represents the FEA from the simulation in graphs with respect to the selected unit system.
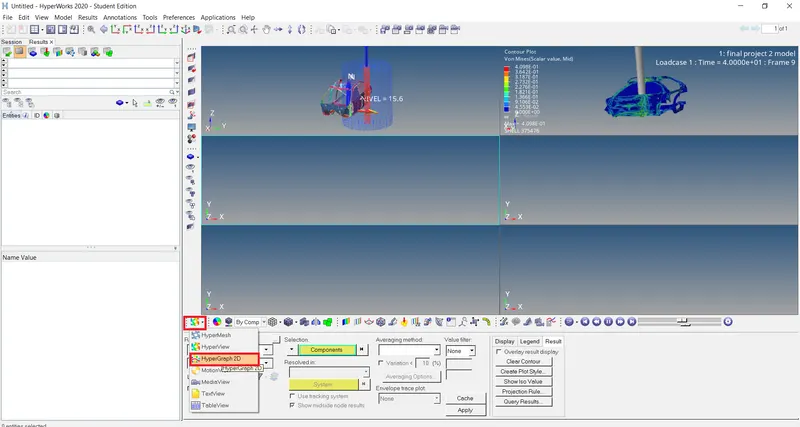
Selecting Hypergraph 2D
Selected T01 File (Time history file)
GLOBAL VARIABLE GRAPHS:
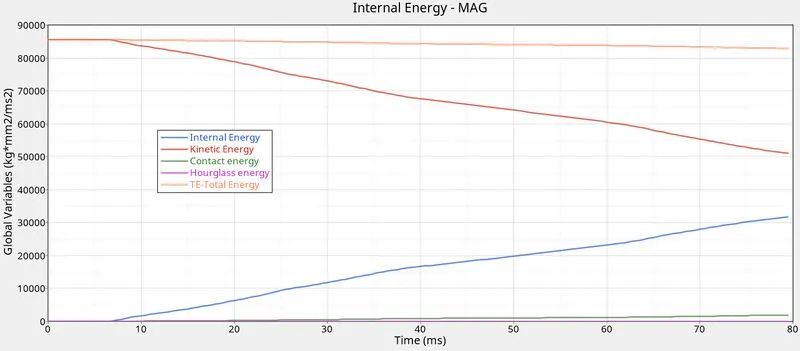
Global variable VS Time
INTERNAL ENERGY AND KINETIC ENERGY:
Internal energy is nothing but the Heat of the System. When the Kinetic Energy is Decreases, the Energy absorbed by the system increases i.e we all know that Energy neither be created nor be destroyed. Once the vehicle is moving with a certain velocity (Say 15.646m/s for the Model), the initial kinetic Energy will be High (Refer to Above Graph). Once the car is hit by the rigid cylinder, the vehicle starts deforming results in absorbing the Surrounding Energy and Stored it. Thus, internal Energy starts increasing. At the Maximum deformation, the Velocity will become Zero and thus the kinetic energy will also be dropping down to zero resulting there is no energy to absorb in the system. Thus, Internal Energy Remains Constant thereafter.
Once after the simulation, the maximum kinetic energy is found at 85576.9 kN/mm at t=0 and the maximum internal Energy is at 31806.4 kN/mm at t=79.5ms.
CONTACT ENERGY AND HOURGLASS ENERGY:
From the above graph, we can see that the Hourglass energy is almost negligible since we have used Improved integrated element formulation (QEPH).
Ideally, all of KE should be converted into IE and the Total Energy must remain constant, but in our case, since we have Hourglass Energy error, our Total Energy is decreasing. We can rectify this hourglass energy by further reducing the Timestep of the simulation and giving the Ideal Properties wherever we can. Our Requirement from an Ideal Simulation is that we have minimal Contact energy and maximum Energy absorption/Deformation in the elements. We can check the Energy error in the Engine output file, which has maxed out at -2.4% which is within the limits for it to be. Our Mass error is also 0% which means that the solver did not need to add mass onto the nodes to reduce the timestep to further avoid the Hourglass Error.
Contact Energy is nothing but the opposite energy generated from the System to Avoid Penetration. To avoid penetration, we have determined the Gap min value to 0.5. When the car is moving with a velocity of 35mph and hits the rigid wall, it starts deformation at the bumper section and hence the penetration of the elements occurs and thus the opposite reaction force also exerted in order to avoid the penetration. Hence the contact energy increasing gradually from zero. The maximum Contact energy found is 1913.36kN/mm at t=79.5ms.
PEAK VELOCITY :
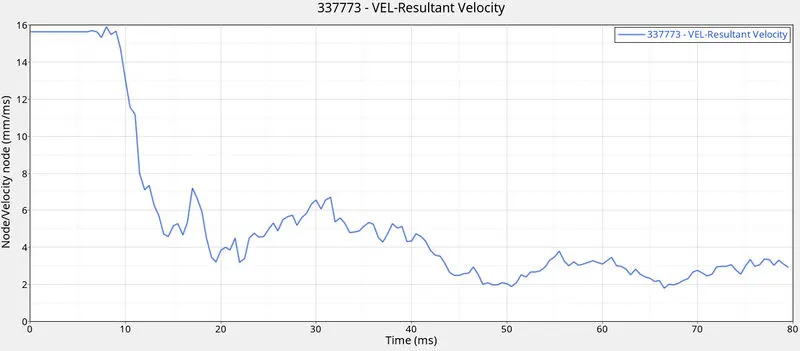
Peak velocity VS Time
As we all know that when the car hits the pole first impact will be the door and due to the deformation, the inner portion of the door might hit the passengers inside the car and lead to injuries. Hence it is important that the Peak velocity at the door region is to be calculated.
From the Graph, the peak velocity of the node on the door is 15.91m/s. As we seen from above graph there is fluctuations in the shock waves this is because of vibration occurred during the crash of the vehicle.
INTRUSION SPRINGS:
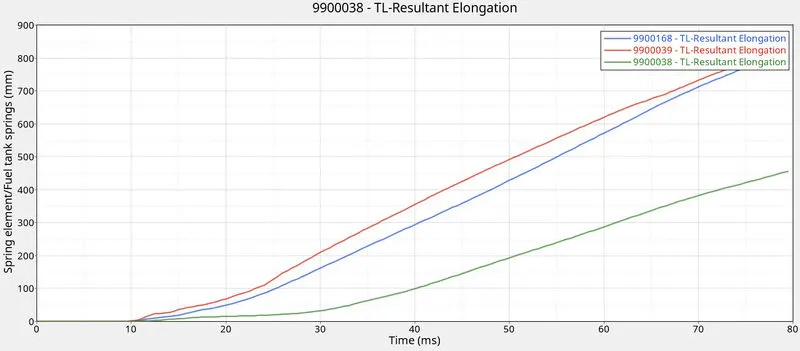
Intrusion springs VS Time
Intrusions are one of the important parameters while checking passenger safety in crashes. To know the intrusions at B-Pillar, Fuel tank, and Hinge Pillar we have placed a spring in these particular regions of B-Pillar, Fuel Tank and Hinge pillar from this we can see the intrusion at that particular region and we can also understand how much intrusion is happened in these regions. Here in this graph, we can see that the B pillar has the maximum intrusion, then come to the fuel tank and the least intrusion is seen at the hinge pillar. Here the red curve indicates the B-Pillar intrusion, Blue indicates the Fuel tank Intrusion, and the last green indicates the Hinge pillar intrusion.
Here at the B-Pillar, the spring elongation of 826.7mm. The B-pillar touches the rigid pole and the other side is crushed towards it, so its intrusion is so high. For the Fuel tank, the spring elongation is 822 mm and for the Hinge Pillar, it shows an elongation of 456.78mm.
Since due to the Node limitation in the software, we don’t have the full-scale model and many missed components like the rear axle, Fuel tank, etc. But in real condition, the rear axle, wheels, and the fuel tank give much more stiffness to the car and this might help to reduce the intrusion in a good manner. To reduce the intrusion in this model we can add one cross member near to the Fuel tank region
SECTIONAL FORCES:
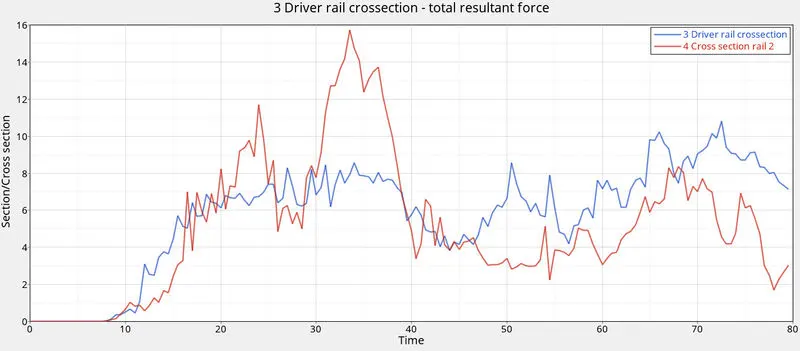
Cross-sections VS Time
The cross members are the parts that transfer the force from one side to another side when the impact occurs. The max section force at the B-pillar cross member is 15.74KN and for the driver cross member is 10.79KN. When the car hits the rigid pole, the force is transferred from the B pillar to cross members and then to the other side. In the above graph, we can see a rise in curves this is due to the force acting on the cross members, due to this force the cross members get bent, and the force passing through the cross members get reduced that is why we see the drop in resultant force in the graph. Even though it drops, it won’t come to zero, in the animation we can see that the bent cross members again get deformed so the curves move
Learning Outcome
- Learned how to set up a side crash test.
- Learned how the Rigid wall interface works and can lead to incompatible Kinematic conditions.
- Learned how Sectional forces are generated.
- Learned how the distribution of forces among the components during a side crash.
- Learned how some components are designed to deform in such a way to ensure the safety of the passengers inside the cabin.
- Learned how to check for Energy, mass, and momentum balance.
- Learned how to Debugging errors in order to get the right results.
- Learned how to place a node to see his peak velocity.
CONCLUSION:
The given model was simulated for the side crash using Radioss and the results obtained were validated. The graphical results were plotted for all the test cases. From the simulation, it can be observed that there was maximum deformation in the cabin, and also maximum intrusion was found in the cabin area. This is due to the limited number of nodes in the student version some of the BIW, engine blocks, suspension system, etc are removed, so the results are not as in real condition. After understanding these we will get to know what all things we should do on this car to make it safer. For example to decrease the amount of intrusion in the Fuel tank region we can introduce a cross member there.