Joint creation and Demonstration in LS-DYNA
Objective: To demonstrate spherical, revolute, cylindrical, and translational joints between two rigid and deformable bodies.
Theory: A distinguishing feature of multibody systems is the presence of joints that impose constraints on the relative motion of the various bodies of the system. Most joints used in practical applications can be modeled in the so-called lower pairs like spherical, revolute, cylindrical, and translational joints.
Spherical Joint: An aspherical joint is used to allow free rotation in two planes simultaneously while preventing translation in any direction, including rotating in those planes.
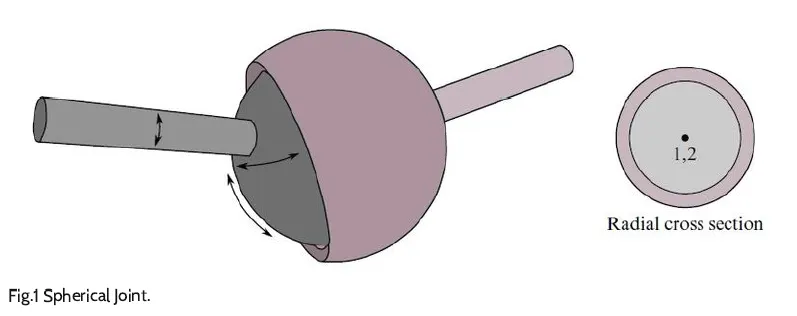
- The relative motion of the rigid bodies is constrained so that nodes that are initially coincident remain coincident. In the above figure, the socket’s node is not interior to the socket—LS-DYNA does not require that a rigid body’s nodes be internal to the body.
Revolute Joint: A revolute joint is one degree of freedom kinematic pair used frequently in mechanisms and machines. The joint constrains the motion of two bodies to pure rotation along a common axis.
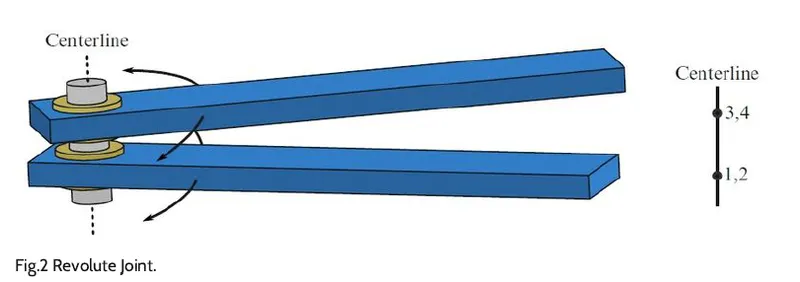
- As shown in fig: 2, Nodes 1 and 2 are coincident; nodes 3 and 4 are concurrent. Nodes 1 and 3 belong to rigid body A; nodes two and4 belong to rigid body B. The relative motion of the two rigid bodies is restricted to rotations about the axis formed by the two pairs of coincident nodes. This axis is labeled the “centerline.”
Cylindrical Joint: A cylindrical joint is two degrees of freedom kinematic pair used in mechanisms. It provides a single-axis sliding function and a single-axis rotation, allowing two rigid bodies to translate and rotate freely.
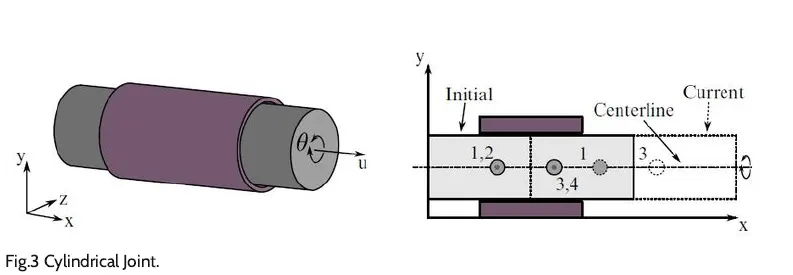
- This joint is derived from the rotational joint by relaxing the constraints along the centerline. This joint admits relative rotation and translation along the centerline, as shown in fig: 3.
Translational Joint: A Translational joint provides a linear sliding movement between two bodies.
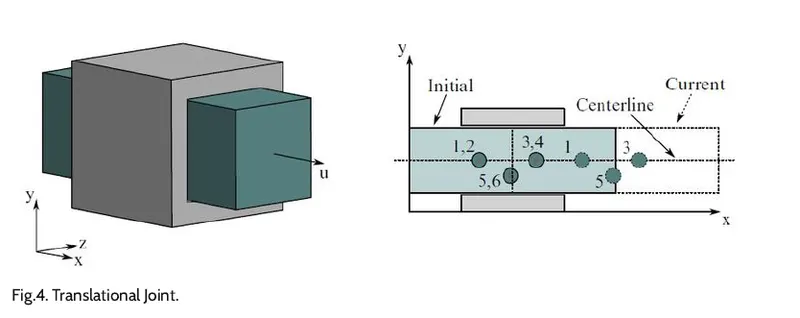
- This is a cylindrical joint with the third pair of off-centerline nodes, which restrict rotation. Aside from translation along the centerline, the two rigid bodies are stuck together.
Procedure:
- The different types of joints are created between two rigid bodies in LS-DYNA using the keyword *CONSTRAINED_EXTRA_NODES and between two deformable bodies using *CONSTRAINED_NODAL_RIGID_BODY.
a. Spherical Joint between two rigid bodies:
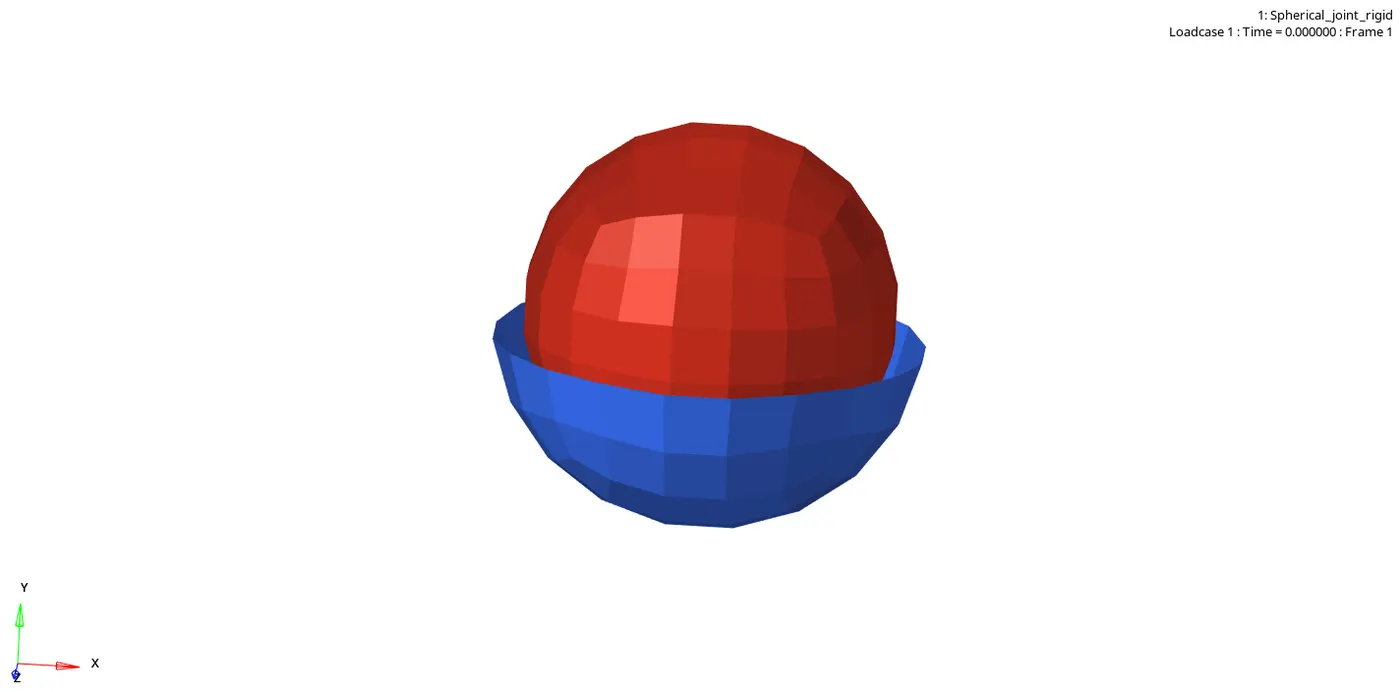
- Open LS-PrePost, using options under Element and Mesh>>Shape Mesher>> Entity>>Sphere Shell, create two parts as shown in Fig: 5.
- The elements of the outer sphere shell are deleted using option Element editing to get the necessary shape.
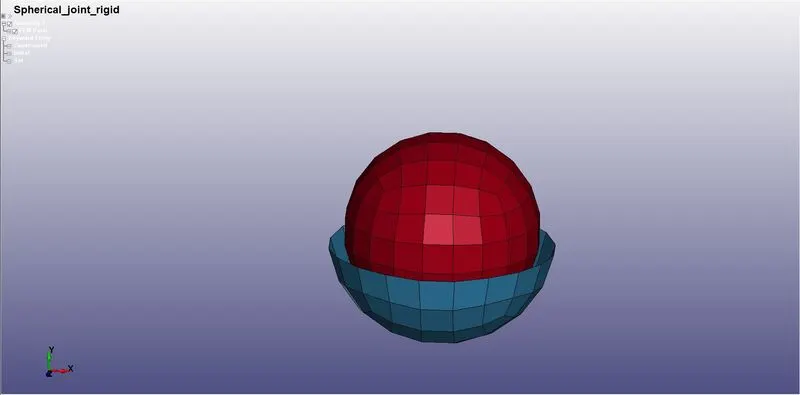
Fig 5: Sphere and outer casing.
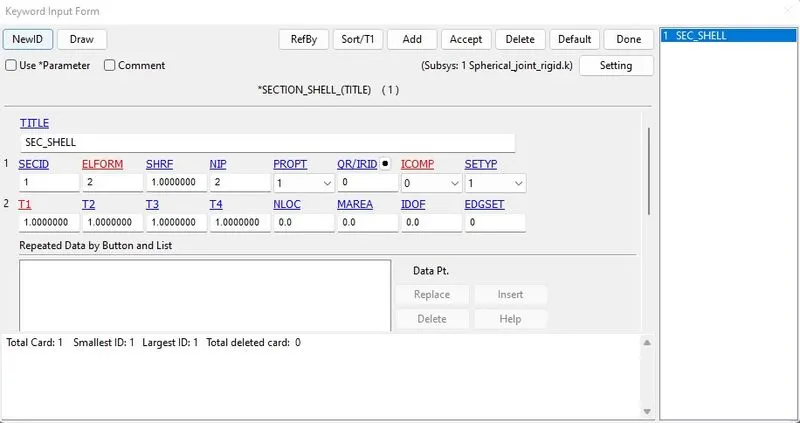
Fig 6: Section card is defined.
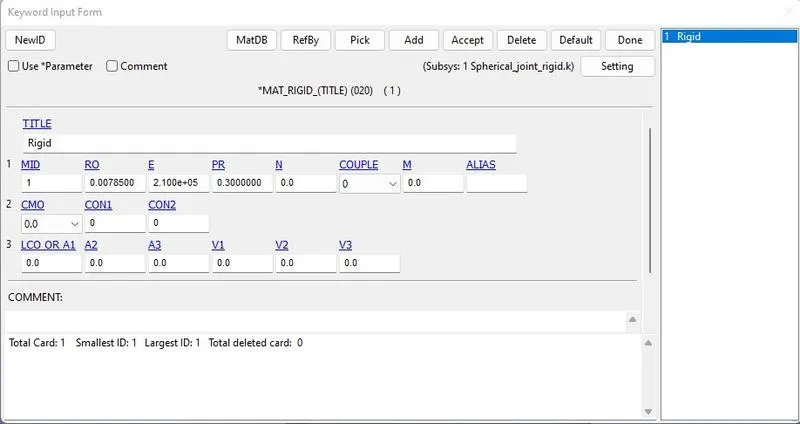
Fig 7: Material card is defined.
- The Section and material property are assigned to the parts.
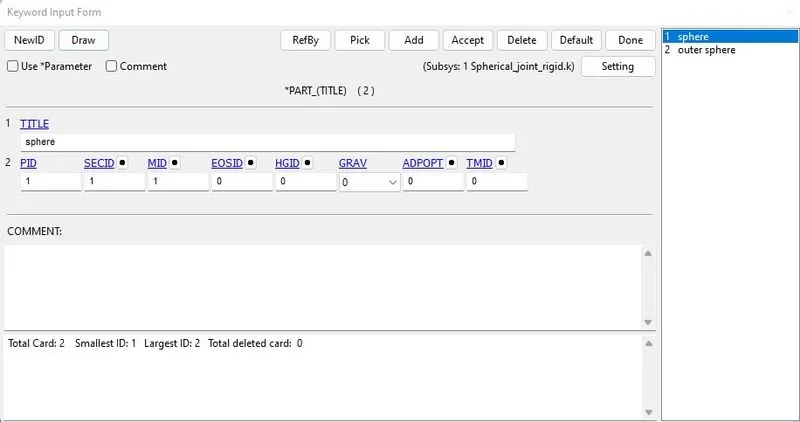
Fig 8: Material and section properties are assigned to the parts.
- A pair of nodes is created using the option under Element Tools>>Node Editing>>Create, i.e., node 305 and 306. Node 305 is constrained to part 1 and node 306 to part 2 using *CONSTRAINED_EXTRA_NODES card.
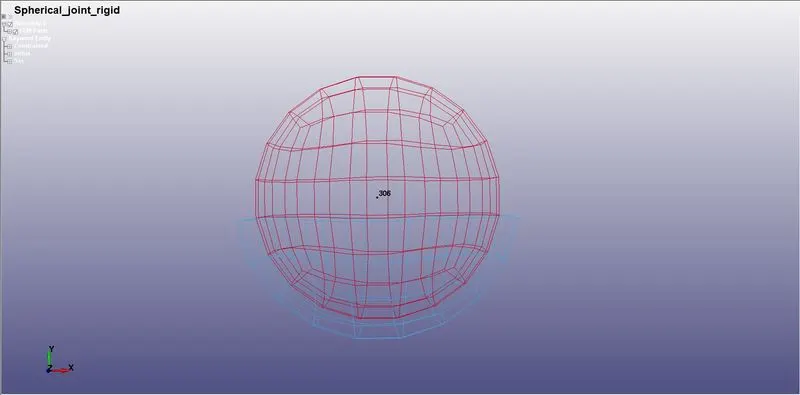
Fig 9: Two nodes are created at the center.
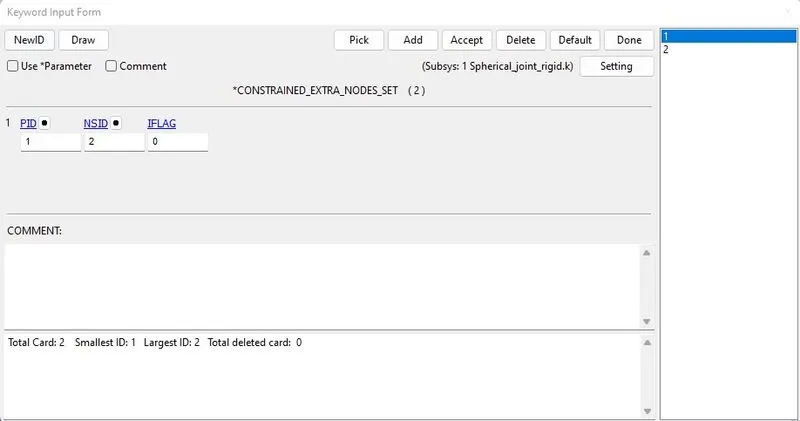
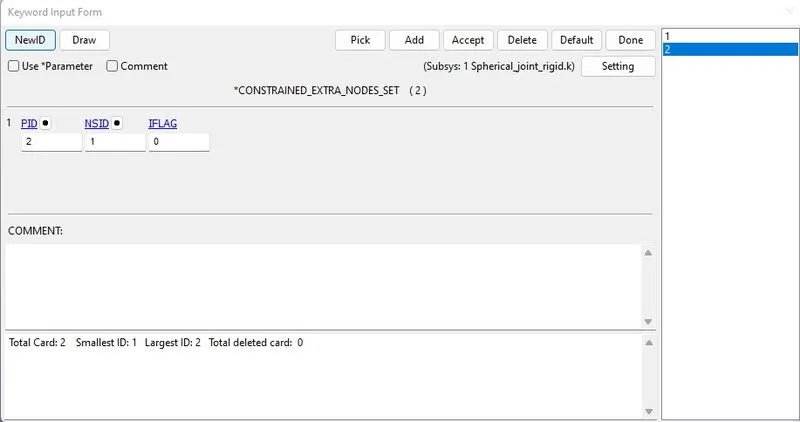
Fig 10: Created two nodes are constrained.
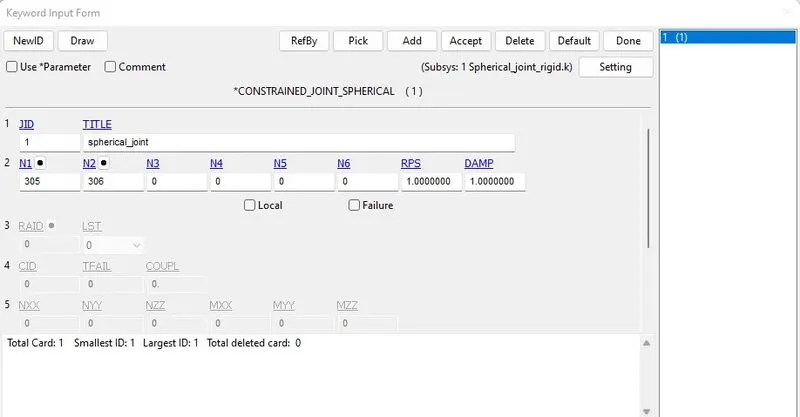
Fig 11: Spherical joint card is created.
- The spherical joint is created using *CONSTRAINED_JOINT_SPHERICAL card with one node pair, i.e., node N1 is 305 for part 1and Node N2 is 306 for part 2.
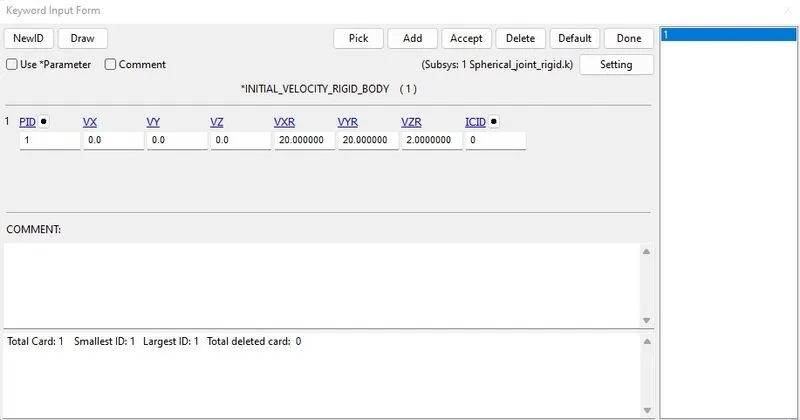
Fig 12: Velocity card is defined.
- The value of the Initial time step size (DTINIT) is set as 0.01ms.
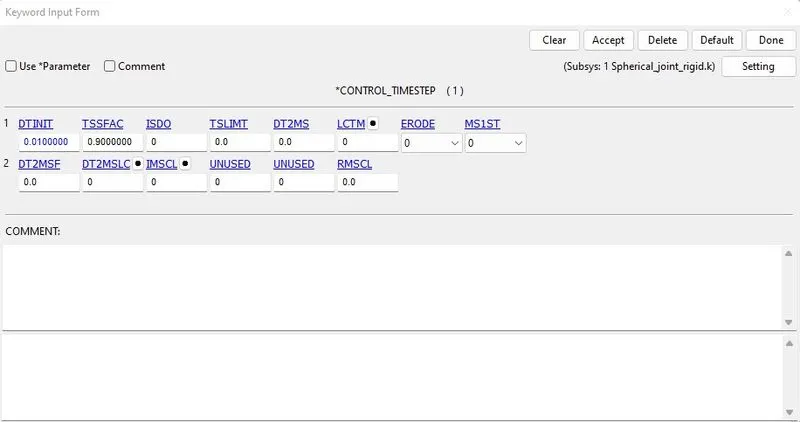
Fig 13: Timestep card is defined.
- The value of the Initial time step size (DTINIT) is set as 0.01ms.
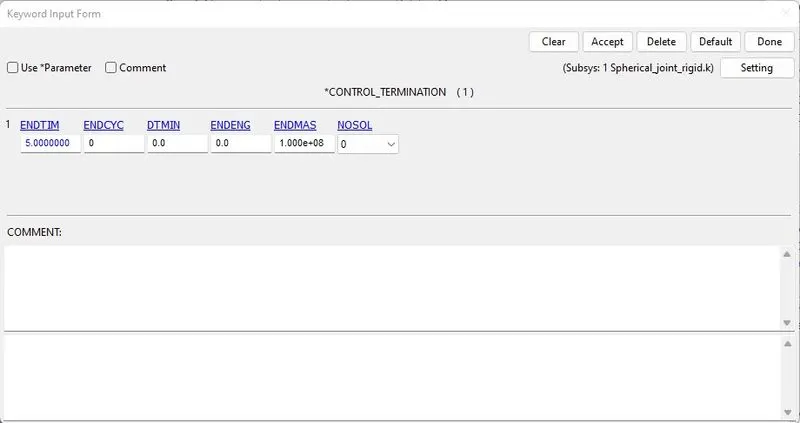
Fig 14: Termination card is defined.
- The termination time is set as 5 ms.
- The keyword file is saved using a proper name with the ‘.k’ extension and made to run in the LS-DYNA program manager.
b. Spherical Joint between two deformable bodies:
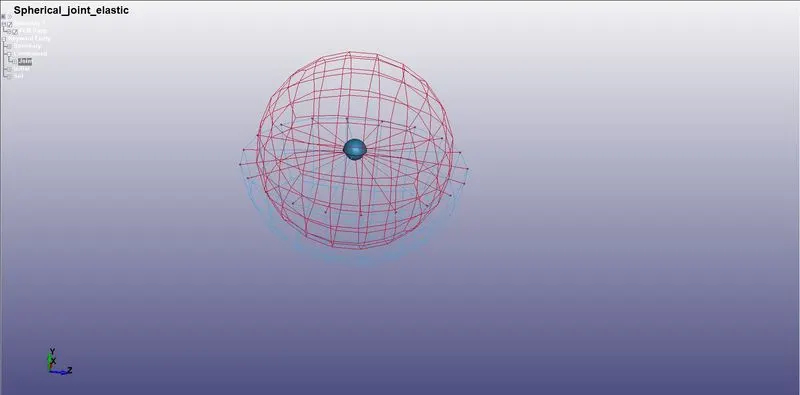
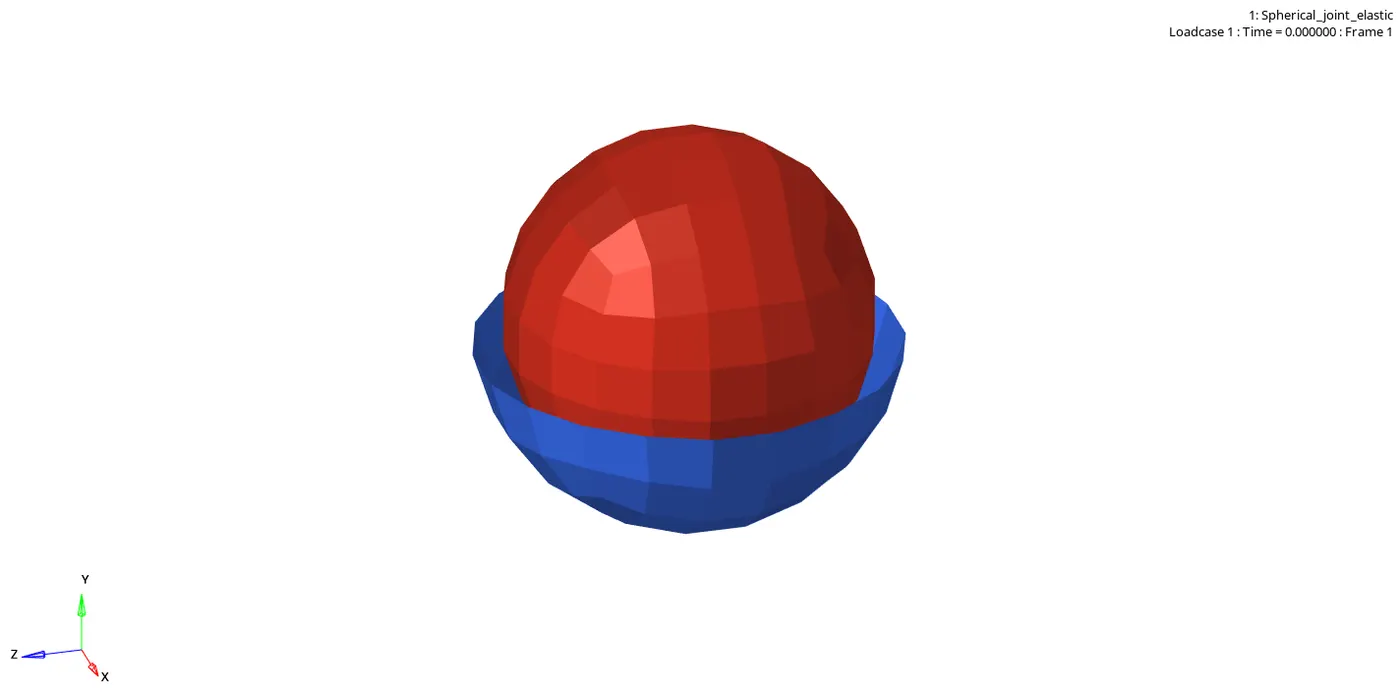
- The parts for the spherical joint are created and assigned with section and material properties similar to the rigid spherical joints.
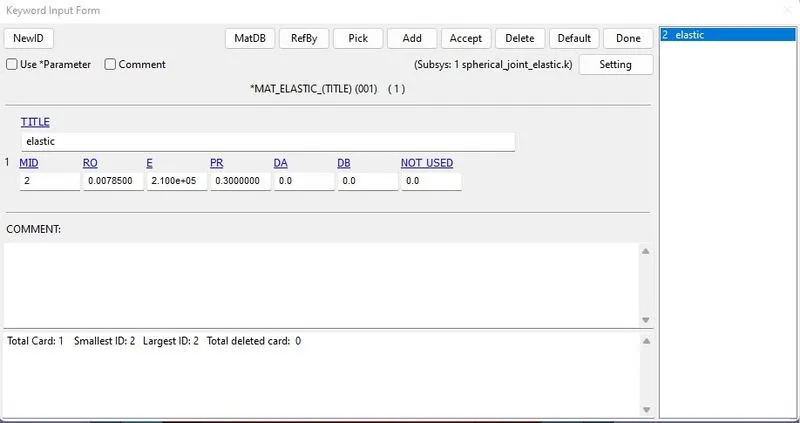
Fig 15: Material card is defined.
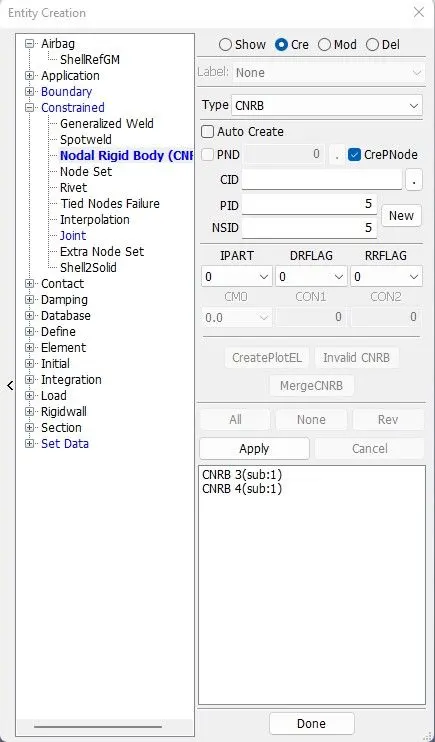
- Using Create Entity>>Constrained>>Nodal Rigid Body (CNRB) option, the nodes generated are linked between two deformable parts for creating a spherical joint.
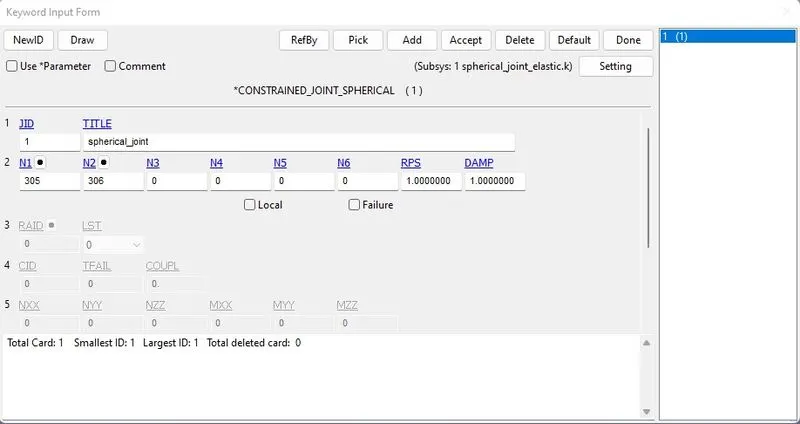
- The spherical joint is created using *CONSTRAINED_JOINT_SPHERICAL card with one node pair, i.e., node N1 is 305 for part 1and Node N2 is 306 for part 2.
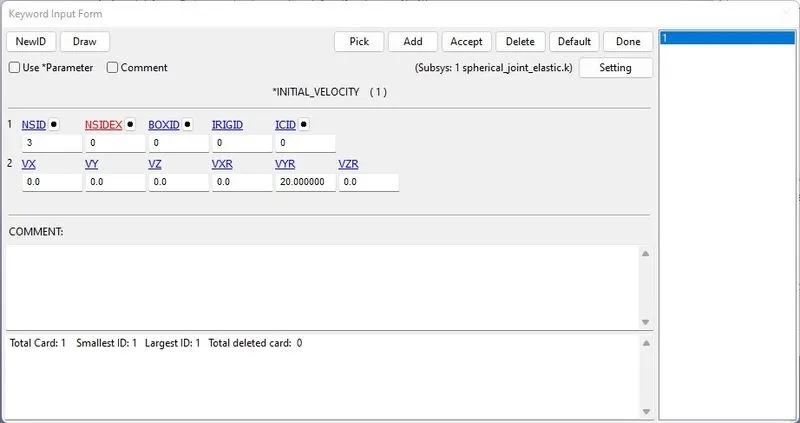
- The initial 20 mm/ms velocity is assigned to the rotational X, Y, Z-axis moving part.
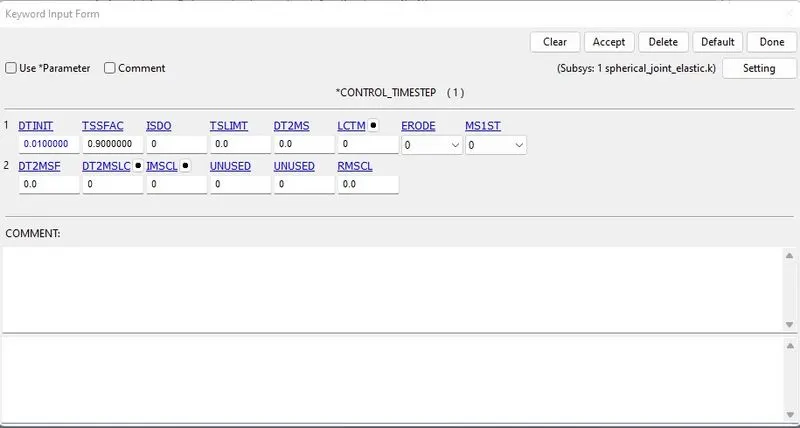
- The value of the Initial time step size (DTINIT) is set as 0.01 ms.
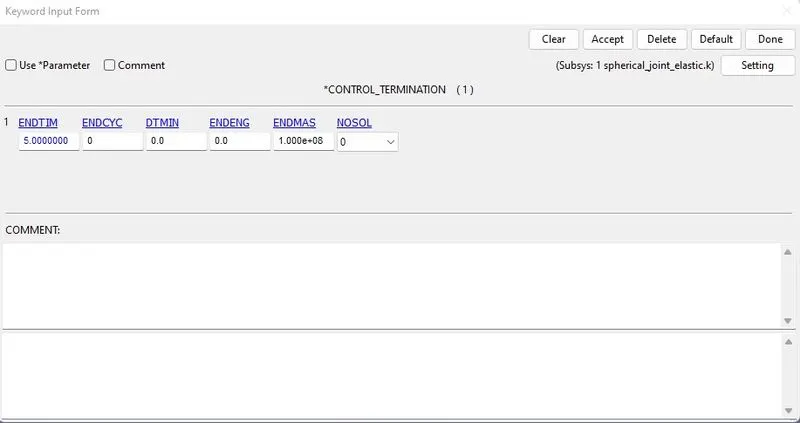
- The termination time is set as 5 ms.
- The keyword file is saved using a proper name with the ‘.k’ extension and made to run in the LS-DYNA program manager.
c. Revolute Joint between two rigid bodies:
- Open LS-PrePost, using options under Element and Mesh>>Shape Mesher>> Entity>>4N Shell, create two parts as shown in fig.14, i.e., the red plate being part 1 and the blue plate is part 2.
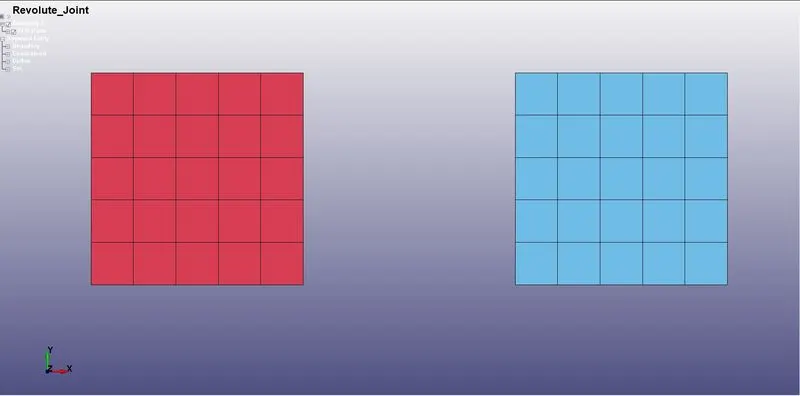
Fig: FE Model for Revolute Joint.
- The material and section properties assigned to the parts are the same as that of the spherical Joint.
- Two pairs of nodes are created using the option under Element Tools>>Node Editing>>Create, i.e., node 501-502 and 503-504. The nodes 501 and 503 are constrained to part 1 and nodes 502 and 504 to part 2 using *CONSTRAINED_EXTRA_NODES cards.
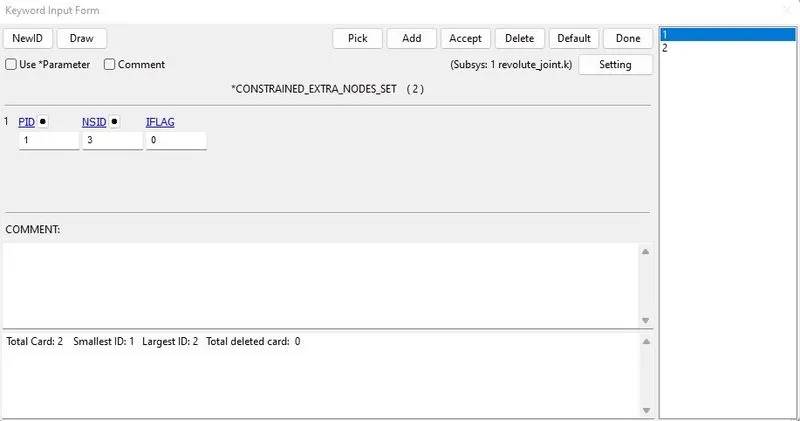
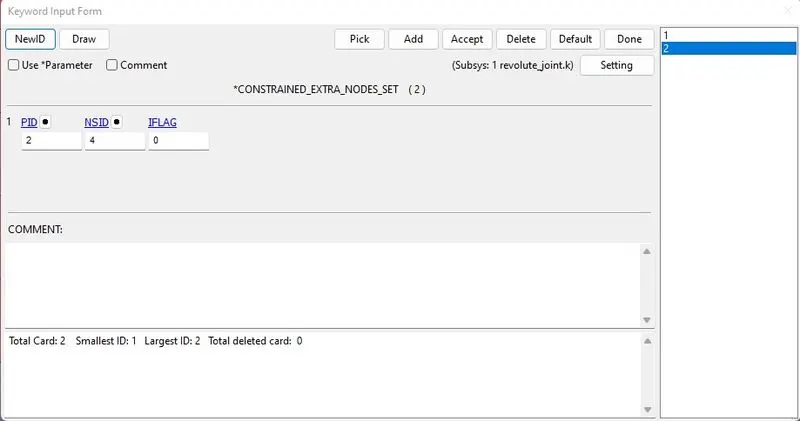
Fig: Nodesets constrained to part 1 and part 2.
- The revolute joint is created using the *CONSTRAINED_JOINT_REVOLUTE card with nodes N1 and N3 of part 1 and N2 and N4 of part 2.
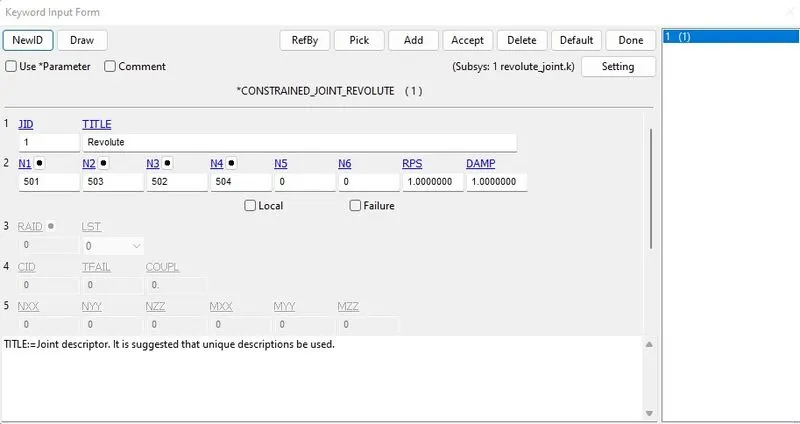
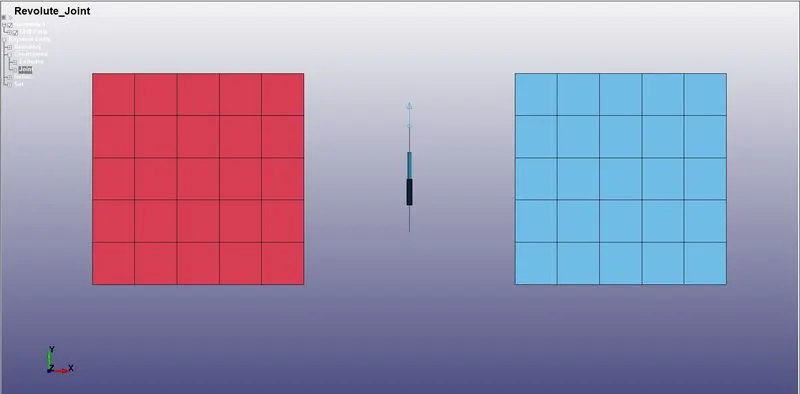
Fig: Revolute joint creation.
- The nodes of part 1, as shown in fig.17, are constrained in all degrees of freedom.
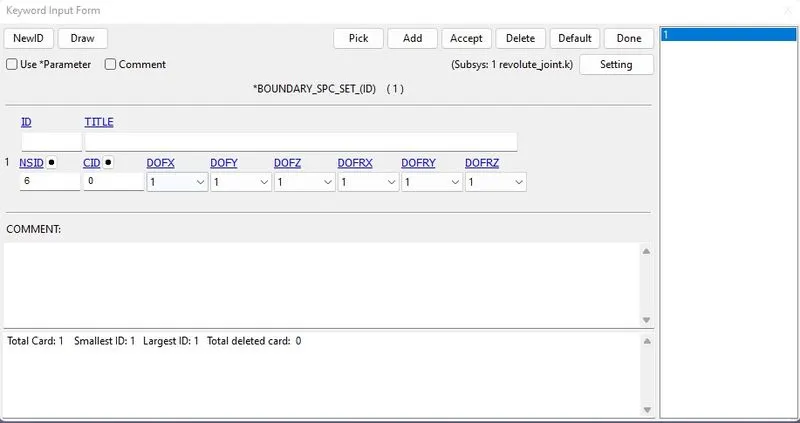
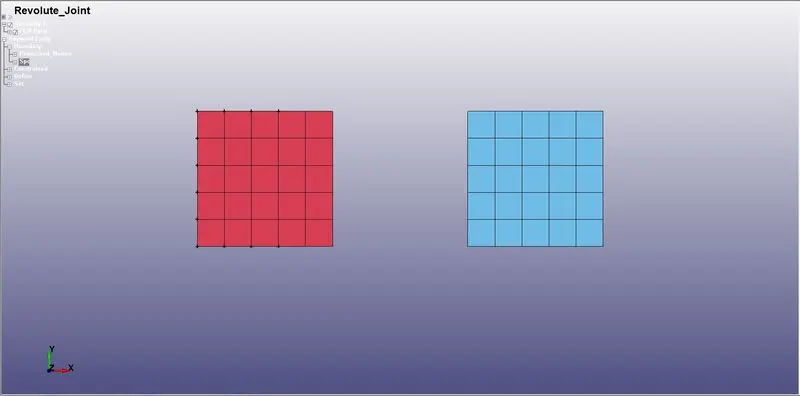
Fig: Boundary SPC set with all dof’s fixed on part 1.
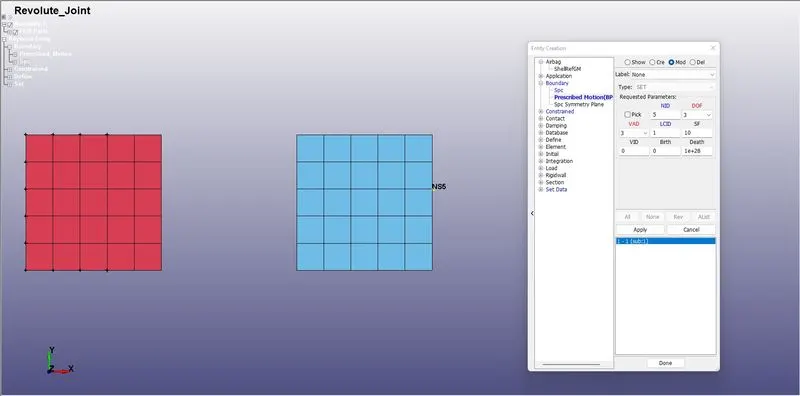
Fig: Boundary prescribed motion on the node-set 5.
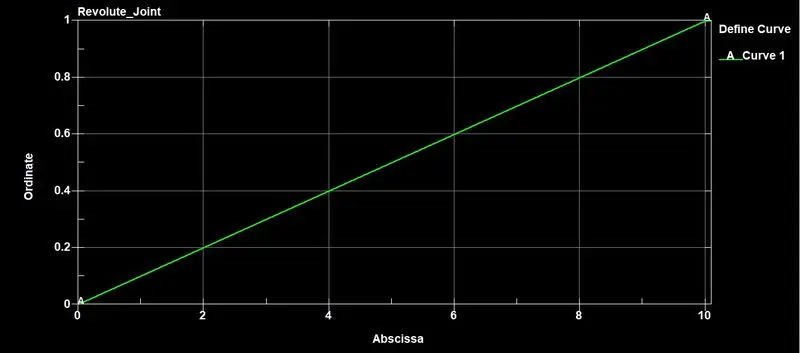
Fig: Displacement Load curve (LCID).
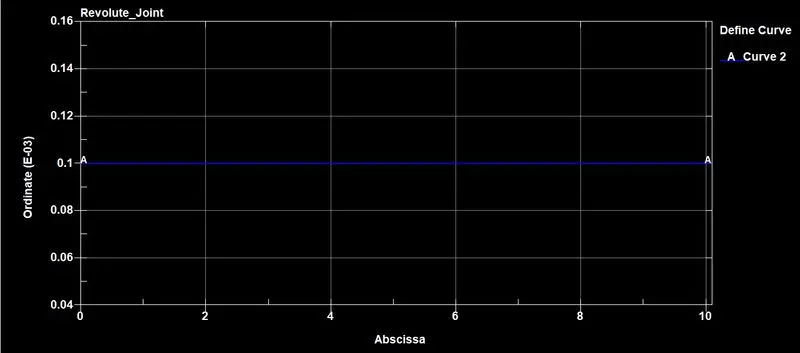
Fig: Timestep curve (LCTM).
- The control timestep is defined using the LCTM curve.
- The termination time is set as 10 ms.
- The keyword file is saved using a proper name with the ‘.k’ extension and made to run in the LS-DYNA program manager.
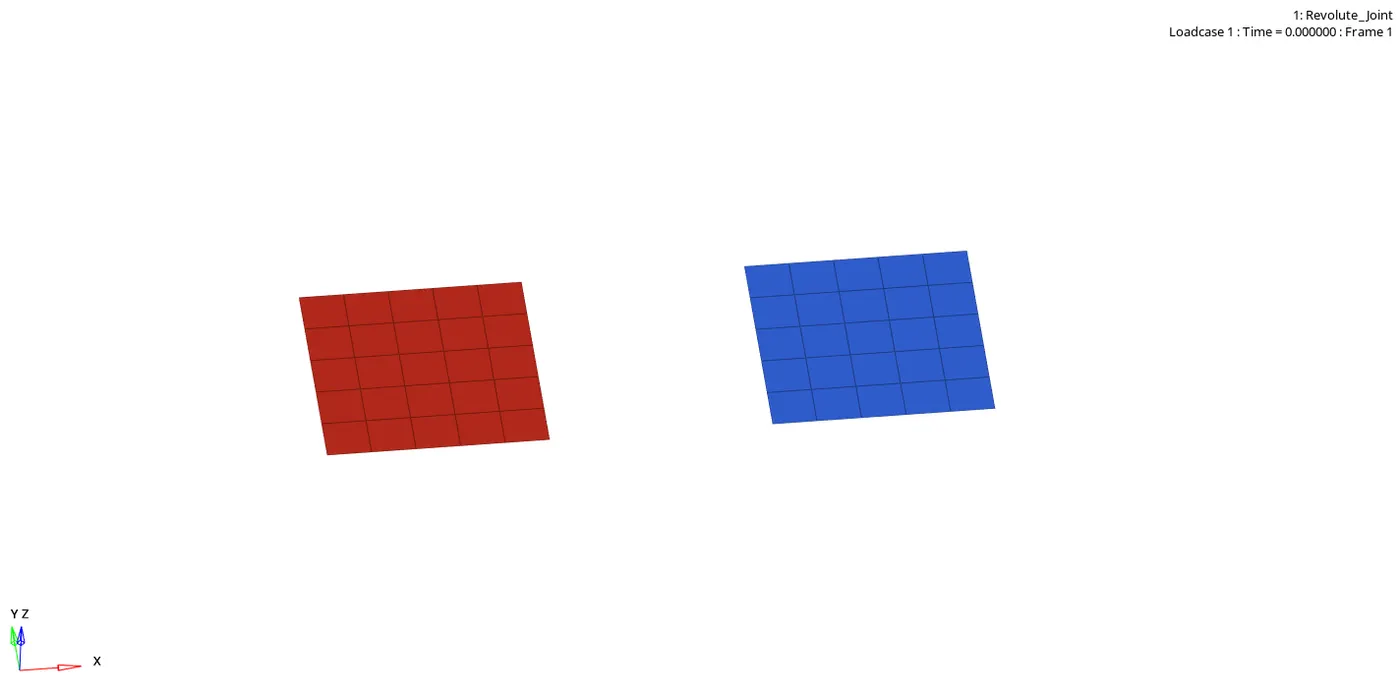
d. Revolute Joint between two deformable bodies:
- The parts for the revolute joint are created and assigned with section and material properties (*MAT_ELASTIC) similar to the revolute rigid joints.
- Two pairs of nodes are created using the option under Element Tools>>Node Editing>>Create, i.e., node 501-502 and 503-504.
- The nodes 501 and 503 are constrained to part1 and nodes 502 and 504 to part 2 using *CONSTRAINED_NODAL_RIGID_BODY under creating Entity option.
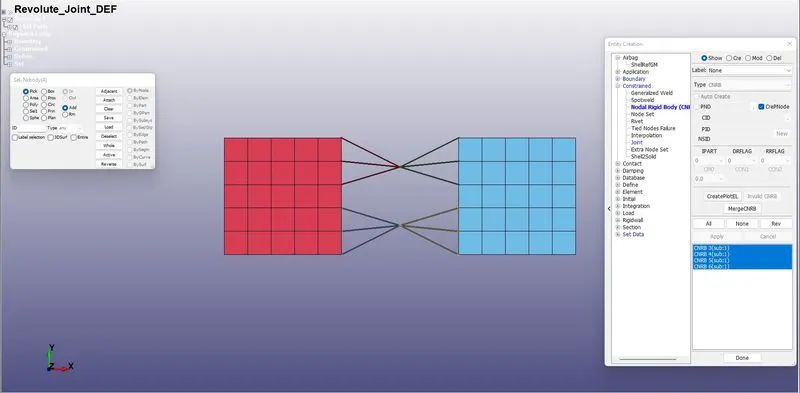
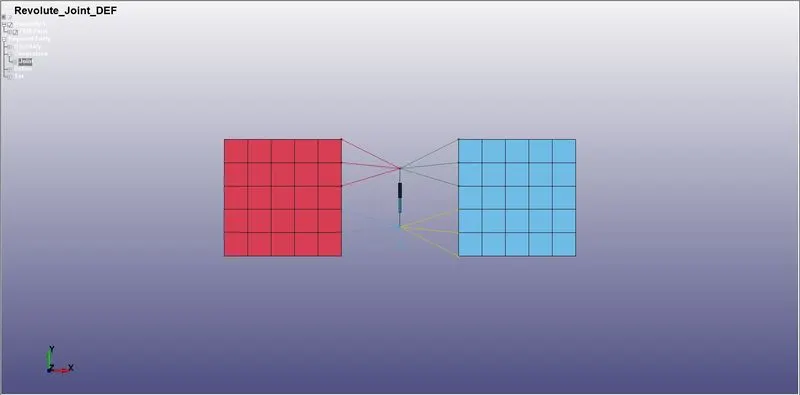
Fig: Revolute joint created with CNRB.
- The revolute joint is created using the *CONSTRAINED_JOINT_REVOLUTE card with nodes N1 and N3 of part 1 and N2 and N4 of part 2.
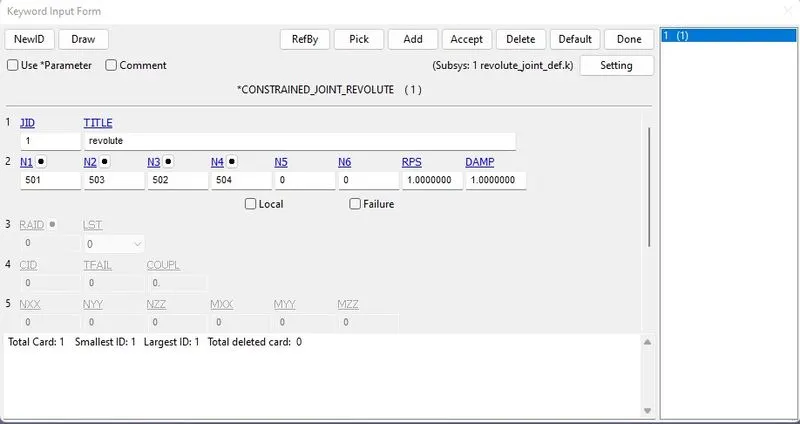
- The nodes of part 1 are constrained in all degrees of freedom using boundary SPC set, and boundary prescribed motion is assigned to node-set five similar to revolute rigid joints.
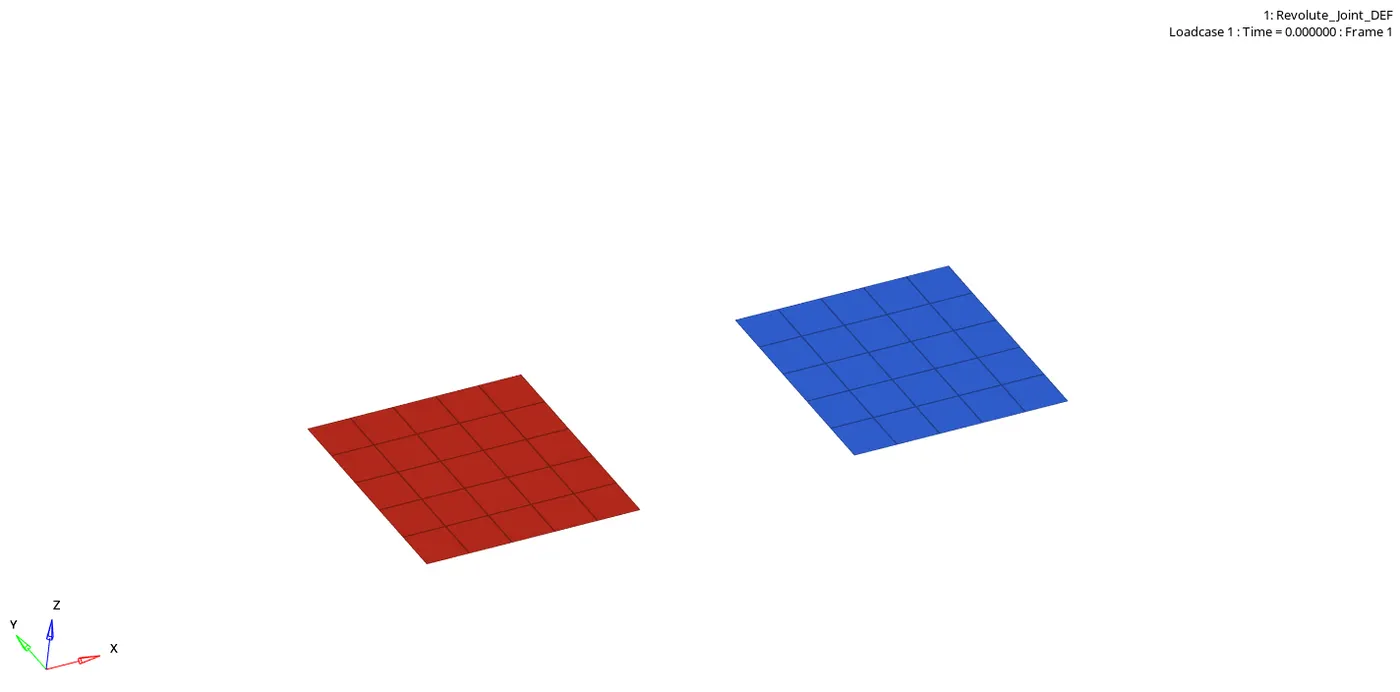
- The control timestep is defined using the LCTM curve.
- The termination time is set as 10 ms.
- The keyword file is saved using a proper name with the ‘.k’ extension and made to run in the LS-DYNA program manager.
e. Cylindrical Joint between two rigid bodies:
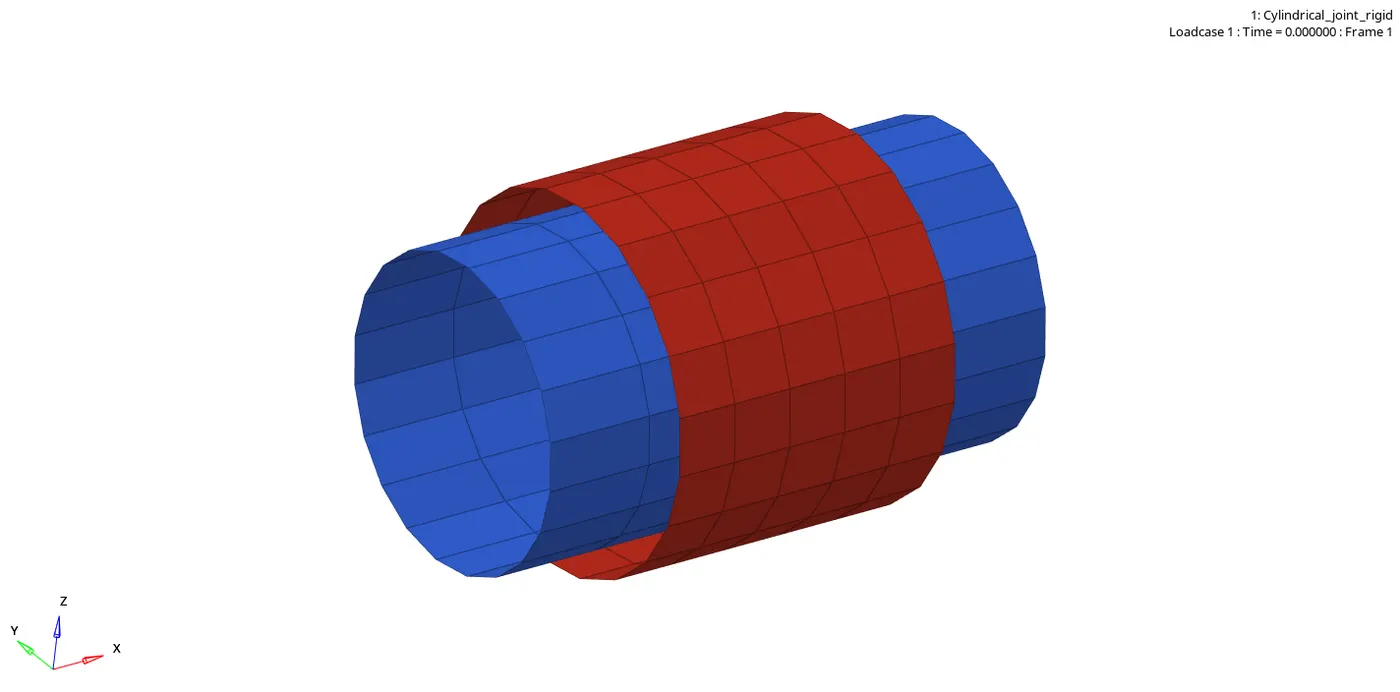
- Open LS-PrePost, using options under Element and Mesh>>Shape Mesher>> Entity>>Cylinder Shell, create two parts, i.e., the red cylinder being part 1 and the blue cylinder is part 2.
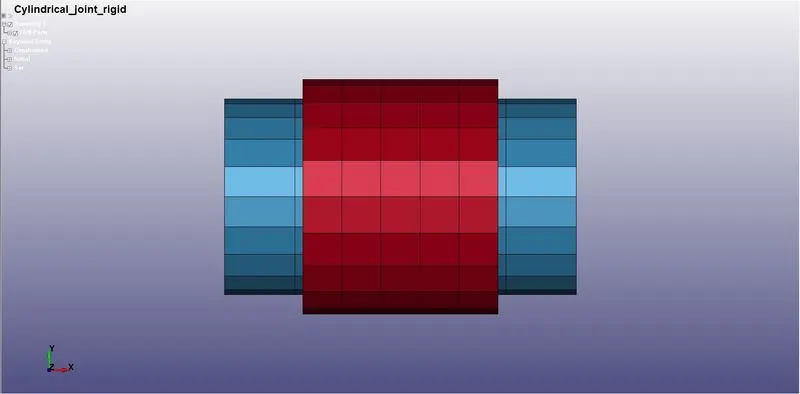
Fig: FE Model for Cylindrical Joint
- The material and section properties assigned to the parts are the same as that of the spherical Joint.
- Two pairs of nodes are created using the option under Element Tools>>Node Editing>>Create, i.e., node 501-502 and 503-504.
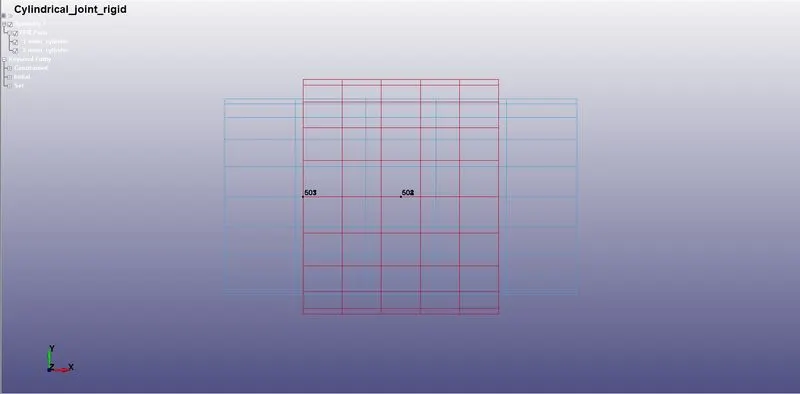
- The nodes 501 and 503 are constrained to part 1 and nodes 502 and 504 to part 2 using *CONSTRAINED_EXTRA_NODES card.
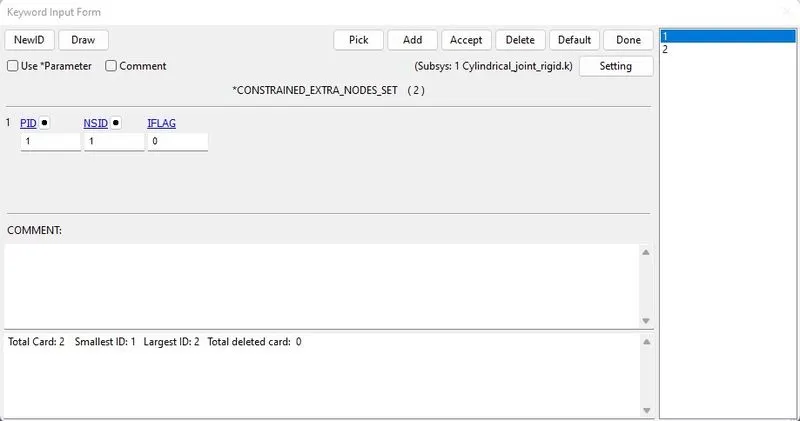
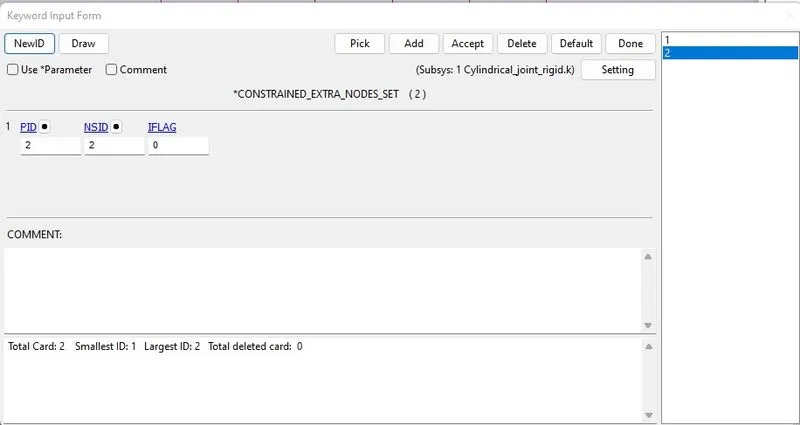
- The cylindrical joint is created using *CONSTRAINED_JOINT_CYLINDRICAL card with nodes N1 and N3 of part 1 and N2 and N4 of part 2.
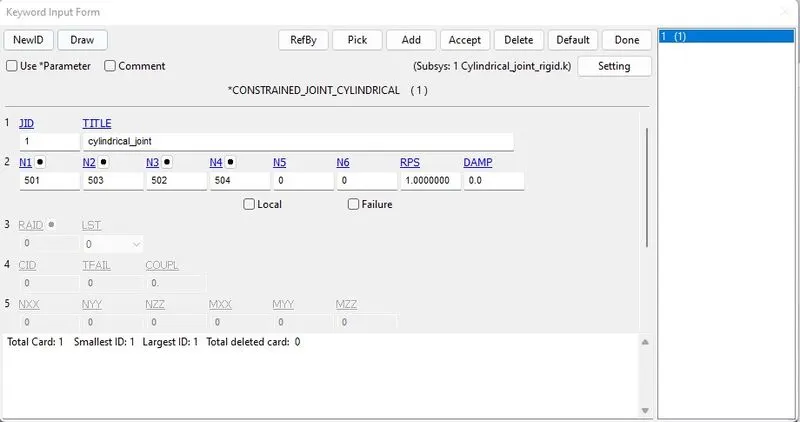
Fig: Cylindrical joint creation.
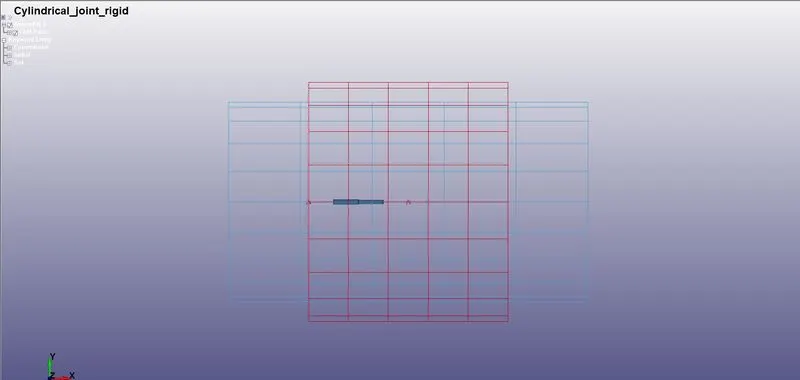
- The initial velocity of 10 mm/ms is assigned to part 1 in the X-axis.
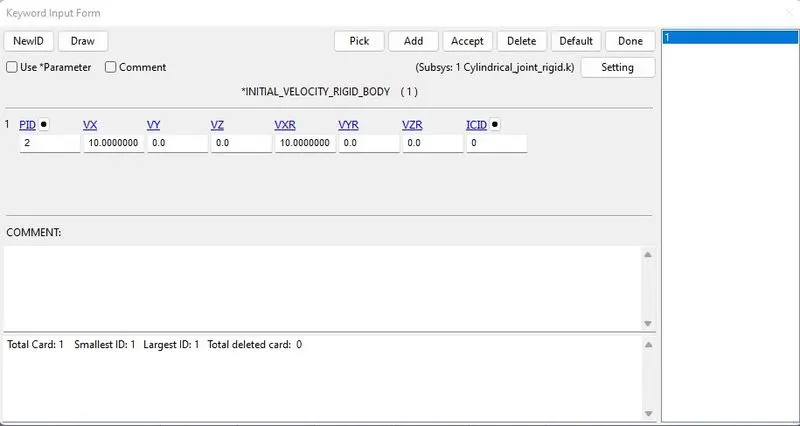
Fig: Initial velocity.
- The value of the Initial time step size (DTINIT) is set as 0.01 ms.
- The termination time is set as 5 ms.
- The keyword file is saved using a suitable name with‘.k’extension and made to run in the LS-DYNA program manager.
f. Cylindrical Joint between two deformable bodies:
- The parts for cylindrical joints are created and assigned with section and material properties (*MAT_ELASTIC) similar to the cylindrical rigid joints.
- Two pairs of nodes are created using the option under Element Tools>>Node Editing>>Create, i.e., node 501-502 and 503-504.
- The nodes 501 and 503 are constrained to part 1 and nodes 502 and 504 to part 2 using *CONSTRAINED_NODAL_RIGID_BODY under creating Entity option.
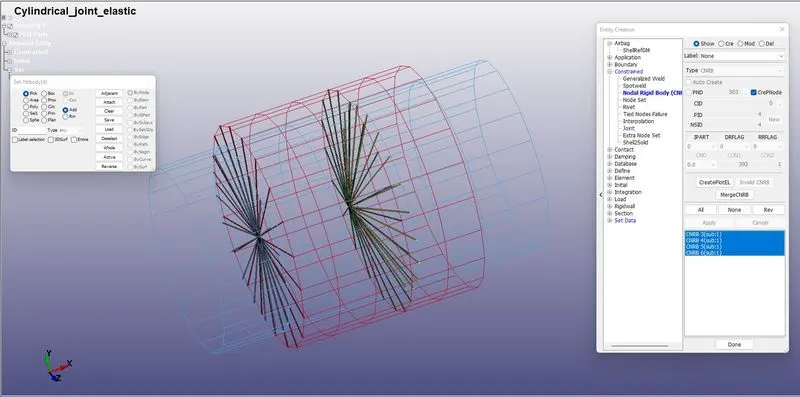
- The cylindrical joint is created using *CONSTRAINED_JOINT_CYLINDRICAL card with nodes N1 and N3 of part 1 and N2 and N4 of part 2.
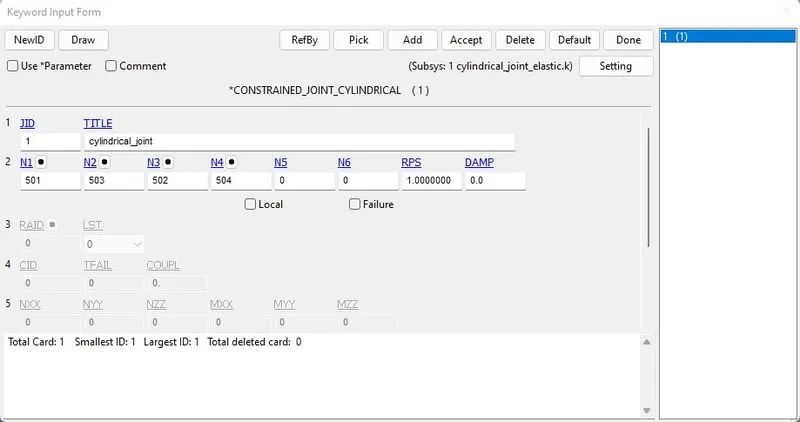
Fig: Cylindrical joint created with CNRB.
- The initial velocity of 10 mm/ms is assigned to part 1 in the X-axis.
- The value of the Initial time step size (DTINIT) is set as 0.01 ms.
- The termination time is set as 5 ms.
- The keyword file is saved using a proper name with the ‘.k’ extension and made to run in the LS-DYNA program manager.
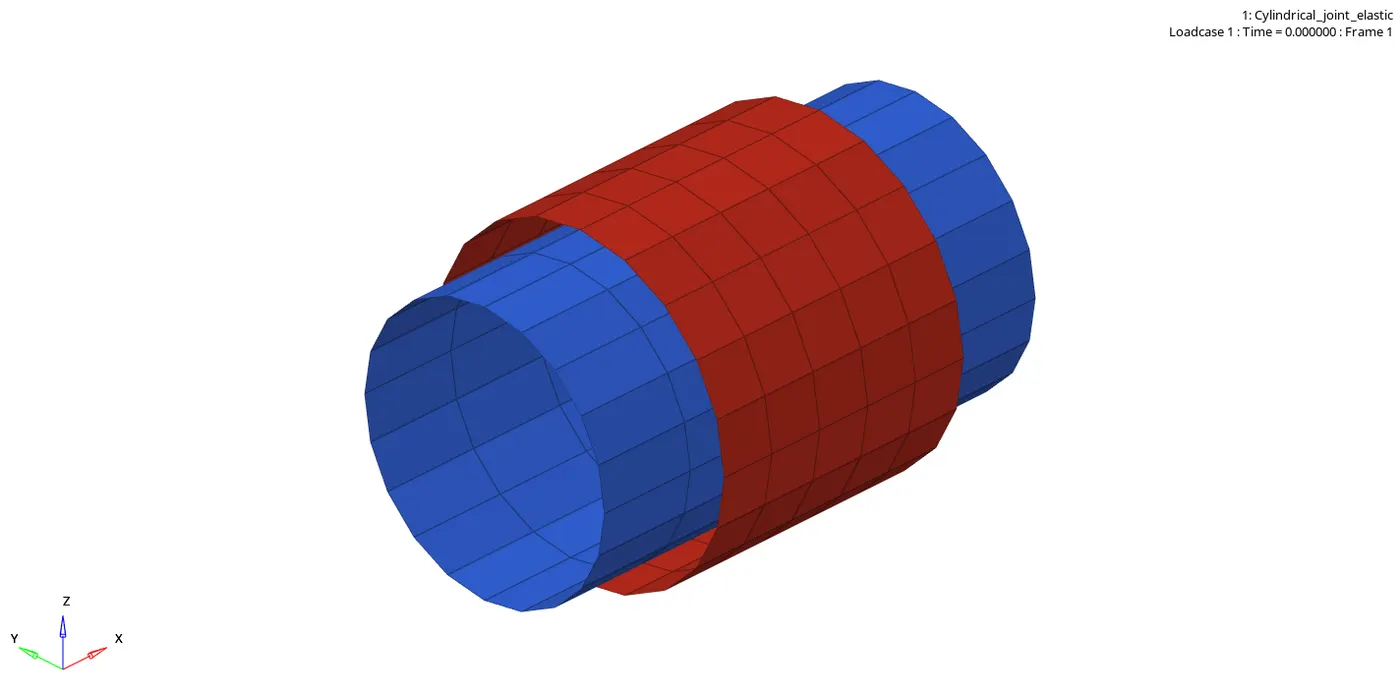
g. Translational Joint between two rigid bodies:
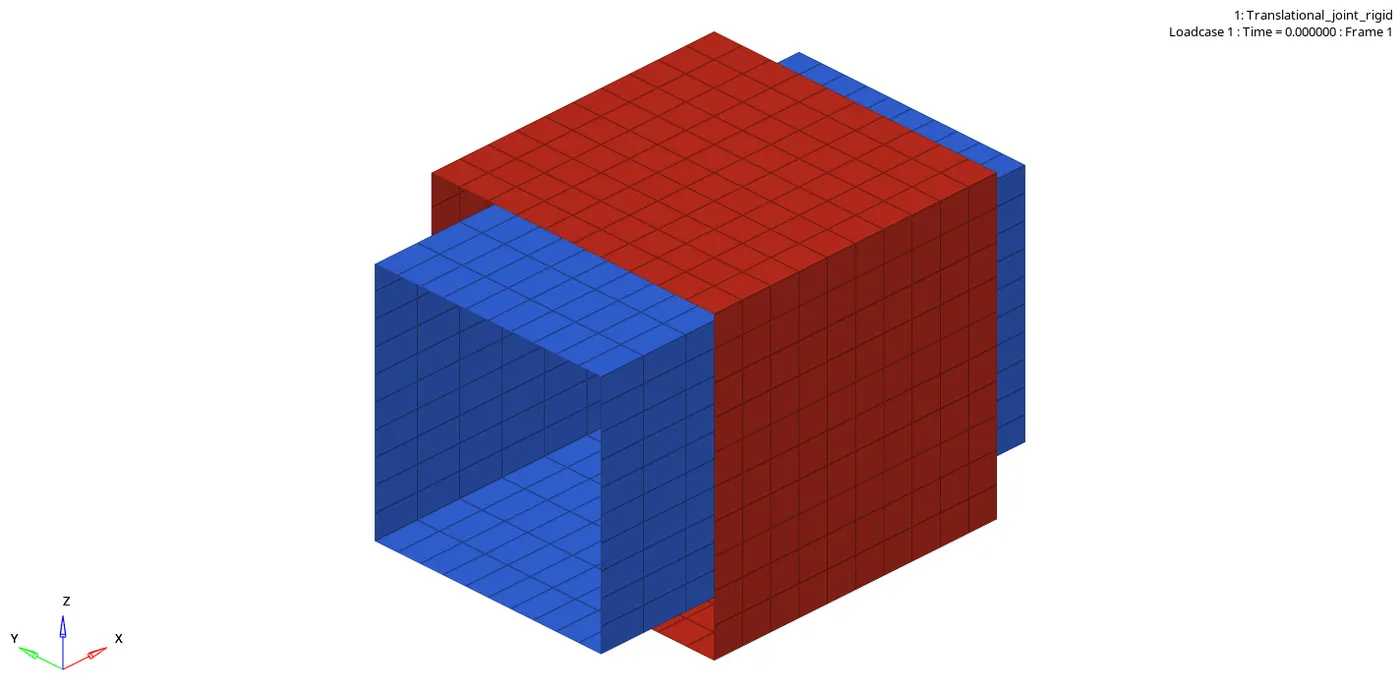
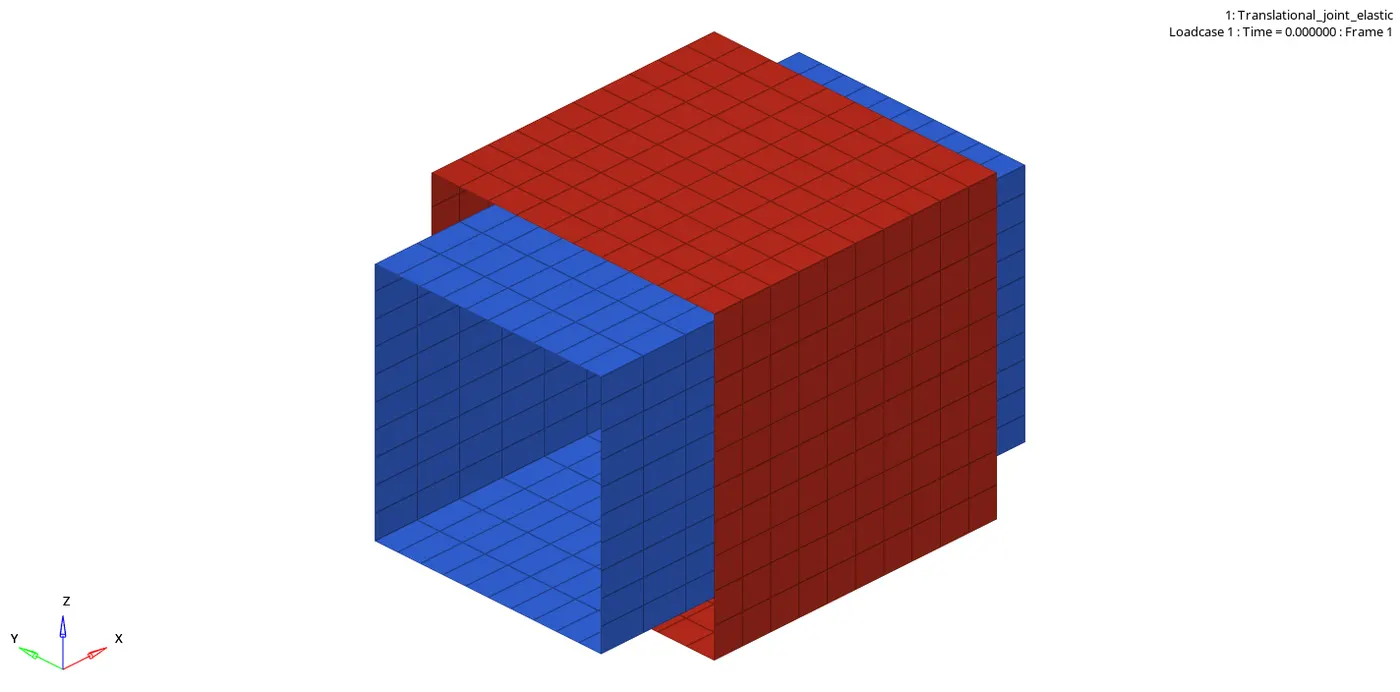
- Open LS-PrePost, using options under Element and Mesh>>Shape Mesher>> Entity>>Box Shell, create two parts, i.e., the red box being part 1 and blue box is part 2.
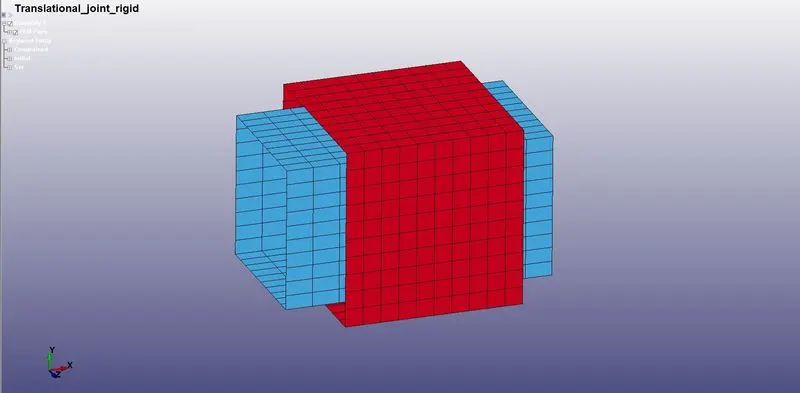
Fig: FE Model for translational Joint.
- The material and section properties assigned to the parts are the same as that of the spherical Joint.
- To define the Translational joint, three pairs of nodes are created. Using the Element Tools>>Node Editing>>Create option, two pairs of nodes are created, 1001-1002 and 1003-1004, coincident and collinear.
- The third pair, 1005-1006, is coincident and slightly away from the axis of the other two pairs but in-between the two pairs.
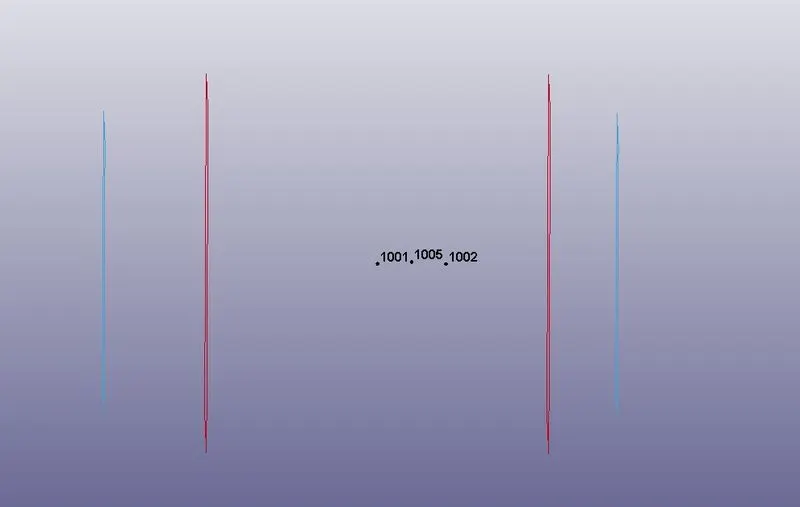
- The nodes 1001, 1003, and 1005 are constrained to part 1 and nodes 1002, 1004, and 1006 to part 2 using *CONSTRAINED_EXTRA_NODES card.
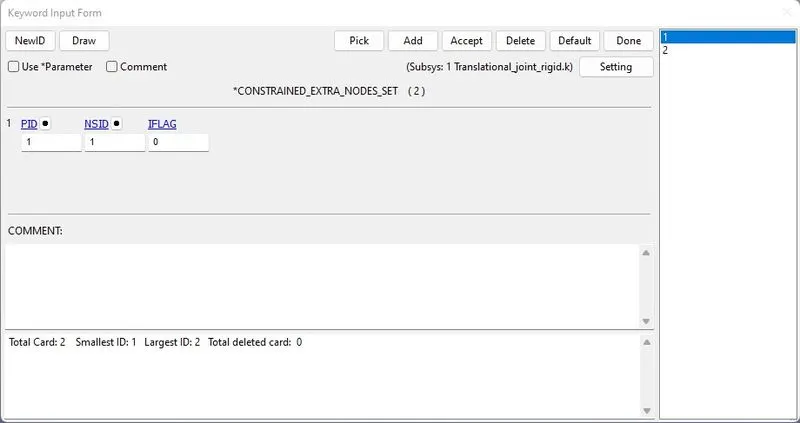
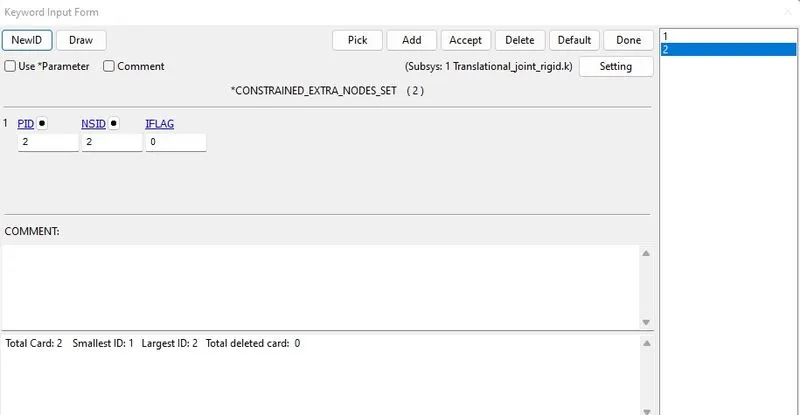
- The translational joint is created using *CONSTRAINED_JOINT_TRANSLATIONAL card with nodes N1, N3, and N5 of part 1 and nodes N2, N4, and N6 of part 2
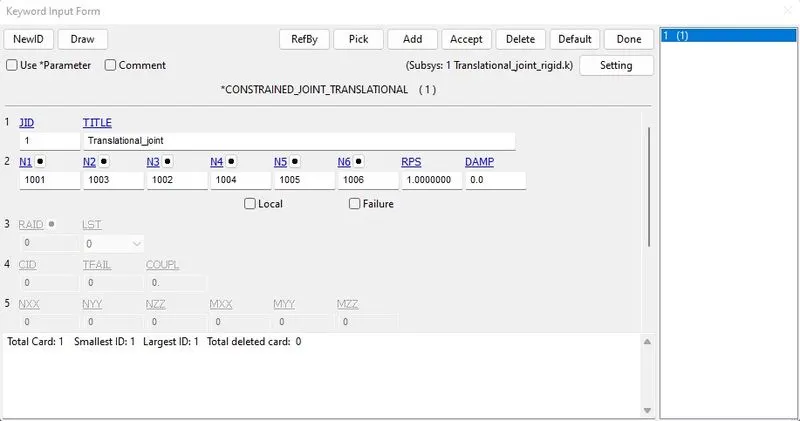
Fig: Translational joint creation.
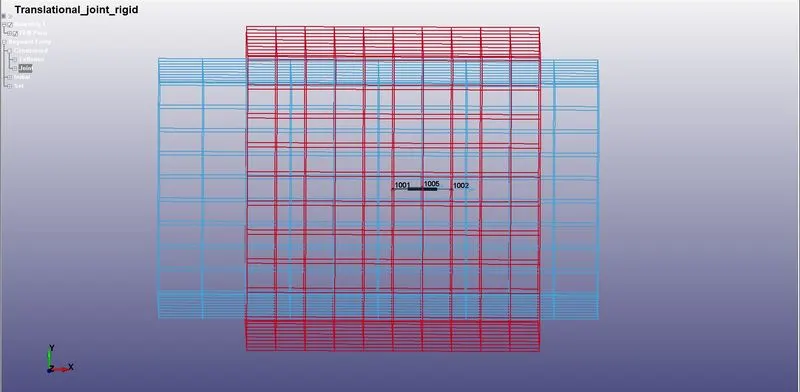
- The initial velocity of 10mm/ms is assigned to part 1 in the X-axis.
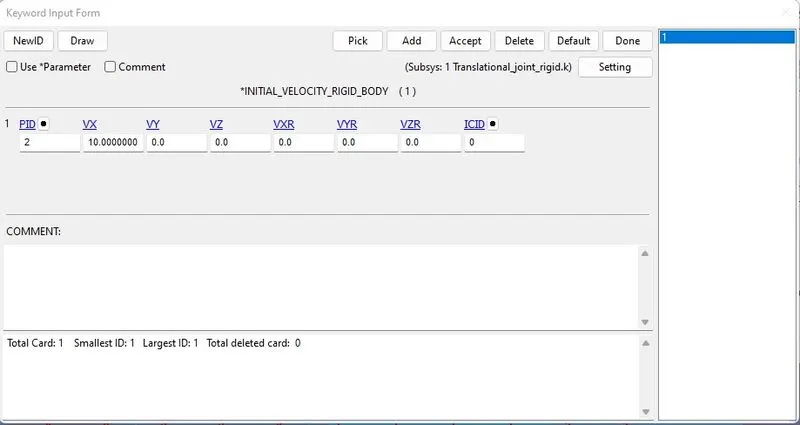
Fig: Initial velocity.
- The value of the Initial time step size (DTINIT) is set as 0.01 ms.
- The termination time is set as 5ms.
- The keyword file is saved using a proper name with the ‘.k’ extension and made to run in the LS-DYNA program manager.
h. Translational Joint between two deformable bodies:
- The parts for translational joint are created and assigned with section and material properties (*MAT_ELASTIC) similar to the rigid translational joints.
- To define the Translational joint, three pairs of nodes are created. Using the Element Tools>>Node Editing>>Create option, two pairs of nodes are created, 1001-1002 and 1003-1004, coincident and collinear.
- The third pair,1005-1006, is coincident and slightly away from the axis of the other two pairs but in-between the two pairs.
- The nodes 1001, 1003, and 1005 are constrained to part 1 and nodes 1002, 1004, and 1006 to part 2 using *CONSTRAINED_NODAL_RIGID_BODY under create entity option.
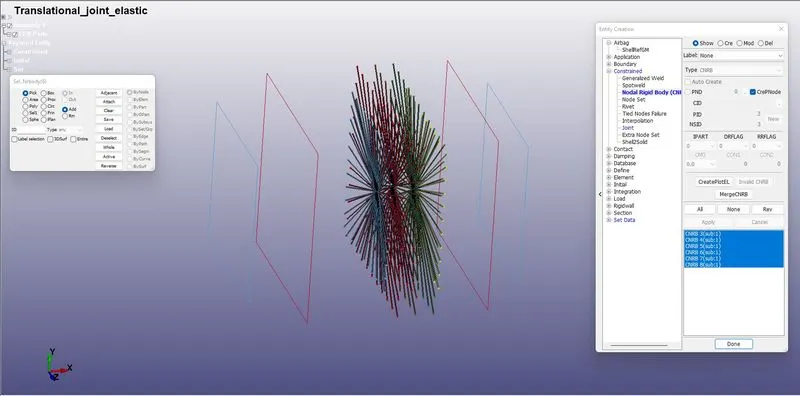
- The translational joint is created using *CONSTRAINED_JOINT_TRANSLATIONAL card with nodes.
- N1, N3, and N5 of part 1 and nodes N2, N4, and N6 of part 2.
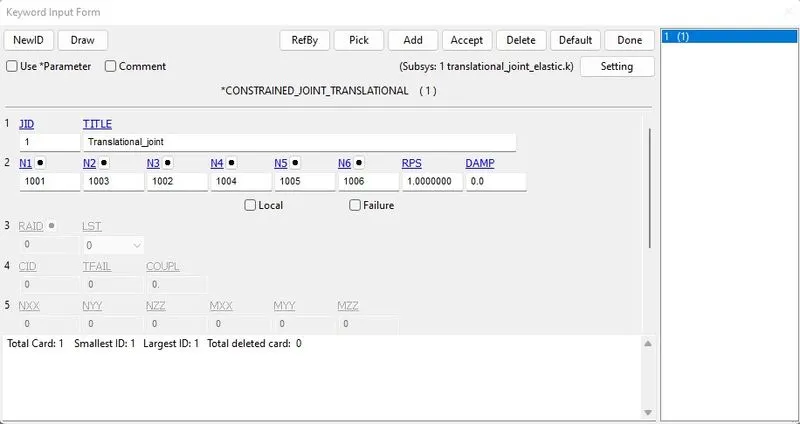
Fig: Translational joint created with CNRB.
- The initial velocity of 10 mm/ms is assigned to part 1 in the X-axis.
- The value of the Initial time step size (DTINIT) is set as 0.01 ms.
- The termination time is set as 5 ms.
- The keyword file is saved using a proper name with ‘the .k’ extension and made to run in the LS-DYNA program manager.
Conclusion: The keyword files necessary to demonstrate spherical, revolute, cylindrical, and translational joints between two rigid bodies and two deformable bodies are created and simulated.