Side Pole Crash Simulation of Neon Dodge under FMVSS Regulation
Objective: To perform side pole crash analysis on the scaled-down model of neon dodge under FMVSS conditions.
Procedure:
- Import the given 0000.rad file into hypercrash.
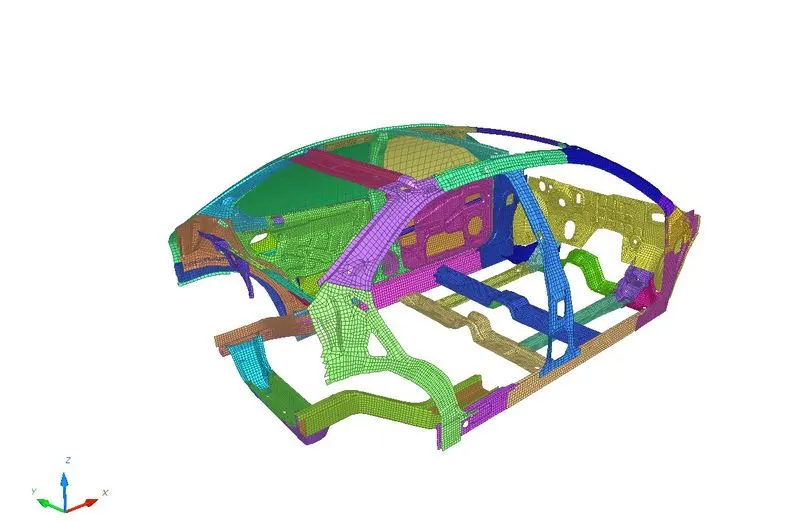
Fig 1: Neon dodge scaled-down BIW model.
- The units are checked in the rad file, and it is Kg mm ms.
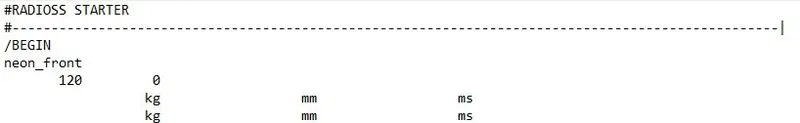
Fig 2: Units in the starter file.
- The penetrations are checked in the model from check all solver contact interfaces from the quality menu.
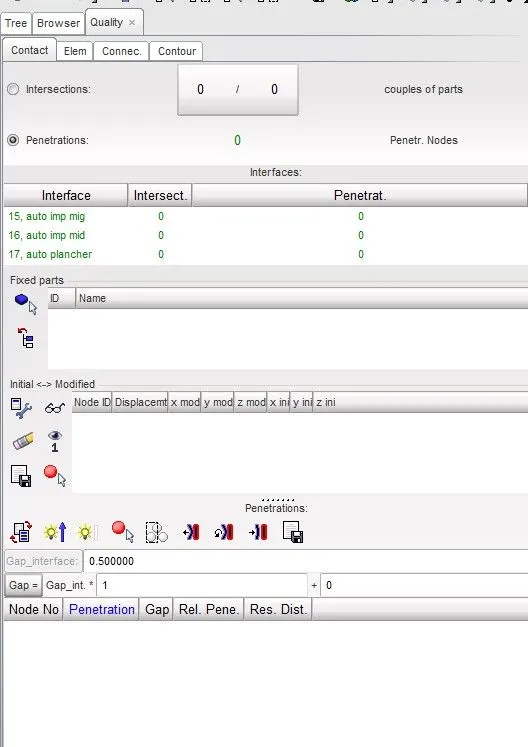
Fig 3: Penetrations and intersections check in the model.
- From the check, we can see that there are no penetrations and intersections in the model, and we can move on to further pre-processing steps.
- Mass of the whole model is checked using the balancing option in the mass tab. The computed mass of the BIW comes out to be 166 kgs which should be increased to 700 kgs to incorporate the real-world crash scenario.
- The model's center of gravity is located above the gear lever, which should be lying beneath the driver seat.
- To bring the center of gravity to the exact location, additional mass is added to the nodes to get the computed mass to 700 kgs and obtain the precise location of the CG.
- CG plays a significant role in the crash scenario, which decides the pitching and yawing motion of the vehicle after the impact occurs.
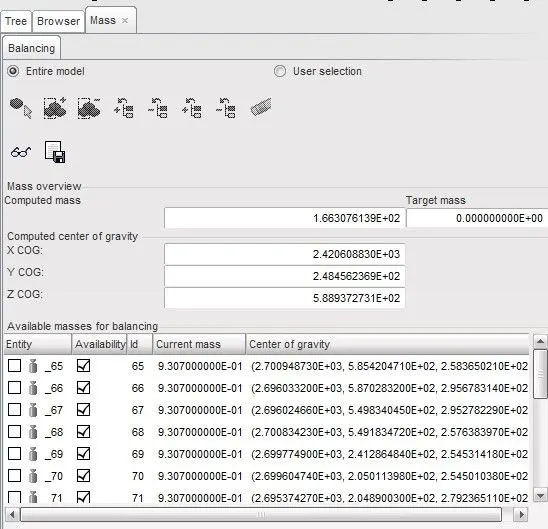
Fig 4: Mass of the BIW model and the coordinates of the center of gravity.
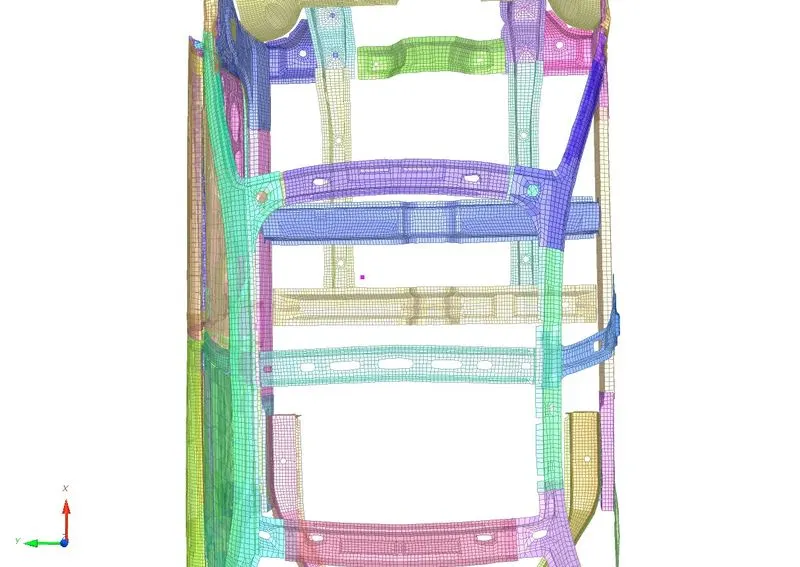
Fig 5: Center of gravity of the BIW is represented by a pink dot at the mod of the model.
- From the loadcase menu added mass option is available. While creating a new mass, keep the type0:Mass is added to each node of the node group.
- A few nodes are selected from the model, and the mass is distributed so that the COG is lying towards the driver side.
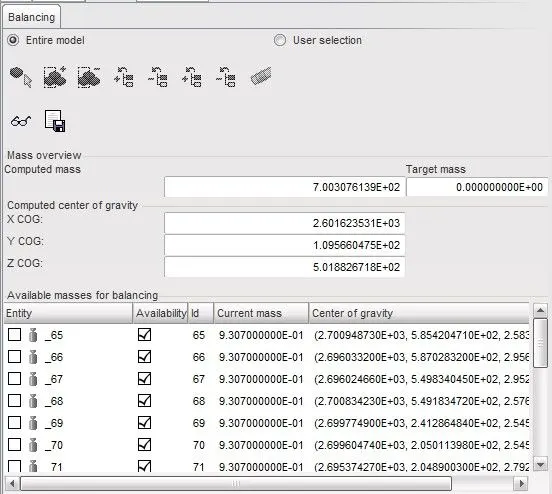
Fig 6: The computed mass is brought to 700kgs.
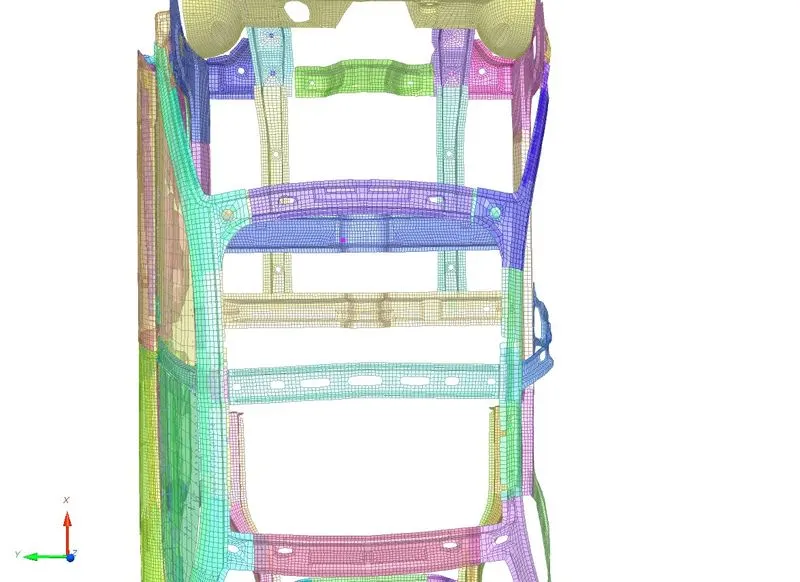
Fig 7: The COG of the model is located on the cross beam lying towards the driver side.
- We are exporting the file from the hypercrash to hypermesh to create a rigid wall.
- In the model browser, a new rigid wall is created with the following inputs.
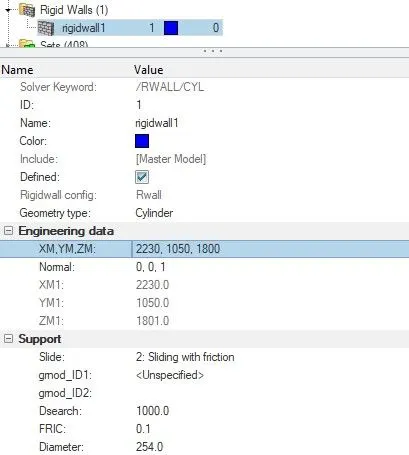
Fig 8: Rigid cylinder is created with the following data.
- The friction is set to 0.1.
- The search distance for the slave nodes is entered as 1000mm.
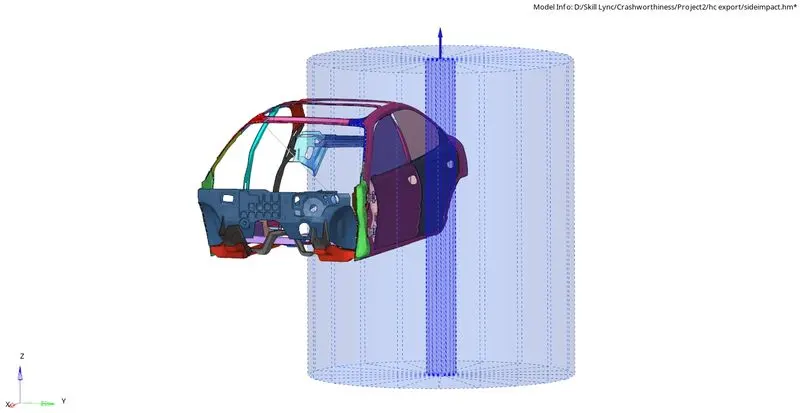
Fig 9: Rigid cylinder is created parallel to the B-pillar with a small gap.
- Delete the existing contact groups and create two new groups with a type 7 interface.
The recommended properties for creating a type 7 interface are:
Istf=4:Stfac is a stiffness scale factor, and the interface stiffness is computed from both master and slave characteristics.
Igap=2:Variable gap + gap scale correction of the computed gap.
Idel=2:When an element is deleted, the corresponding segment is removed from the master side of the interface.
Stmin=1:Minimum stiffness in contact to avoid too soft contact.
Gapmin>=0.5:Minimum thickness.
Inacti=6:Gap is variable with time, but initial penetration is computed.
Iform=2:Stiffness (incremental) formulation.
- A friction of 0.2 is entered.
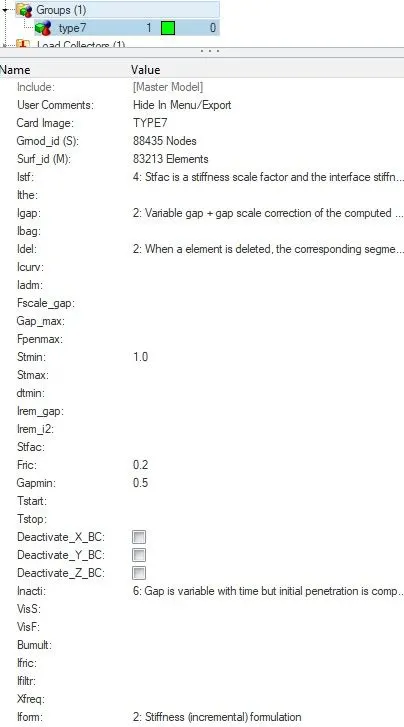
Fig 10: Type 7 contact is created between all the nodes in the model with the required contact parameters.
- Initial velocity is applied to all the nodes with 35mph.
- In the loadcase menu, the initial velocity option is provided.
- All the nodes from the graphics are selected, and a value of 15.6464 is entered in the Y velocity column.
- 1mph= 0.447 mm/ms
- The type is set to translational.
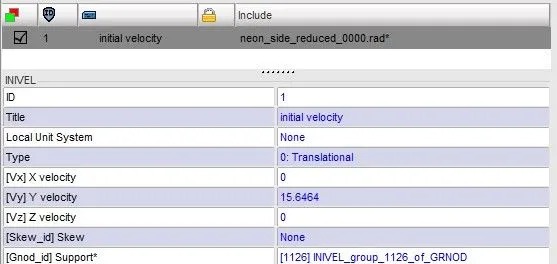
Fig 11: Initial velocity is applied to all nodes of the BIW.
- Moving frames are created in the seat reinforcement and on the mid rail at B-pillar components to obtain forces transmitted through them.
- MOV Frames can be created from the solver browser.
- Three nodes must be selected at the desired locations, and these three nodes have a specific meaning for the definition of the frame.
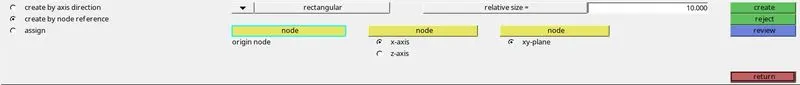
Fig 12: Options for creating a MOV frame with three nodes.
- two MOV frames are created on the components.
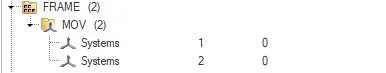
Fig 13: Two moving frames are created at the desired location.
- After the creation of these moving frames, cross-sections are created based on these frame ids.
- Cross-sections in the model can be created from the SECT option in the solver browser.
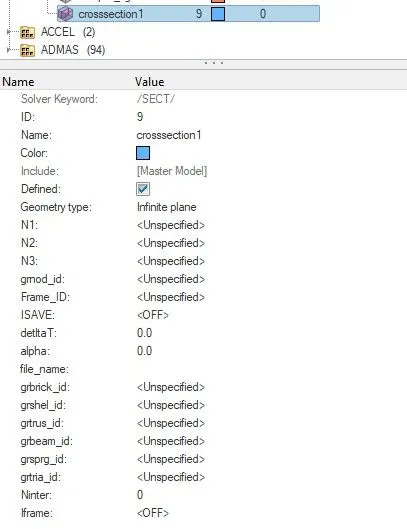
Fig 14: Options for creating cross-sections.
- Geometry type is set to an infinite plane; N1, N2, and N3 values are defined the same as the frame nodes.
- Fame_ID is selected, and a set of elements around the axis is selected, where the forces are monitored.
- deltaT value is set to 0.1.
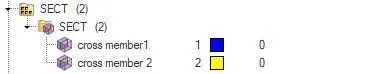
Fig 15: Cross-sections are created in the area of interests.
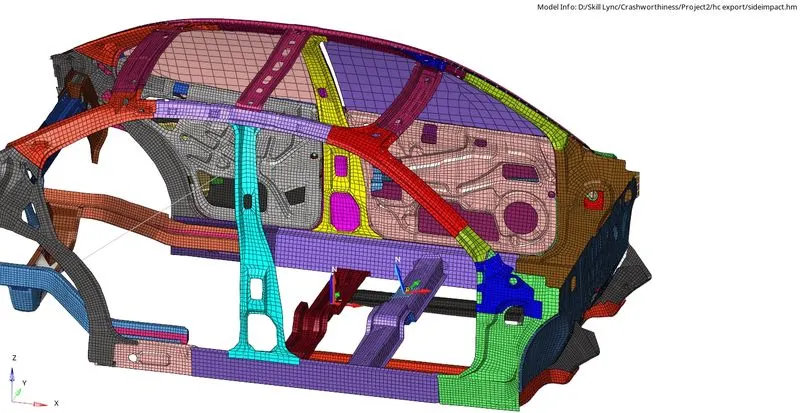
Fig 16: Cross-sections represented on the model.
- For measuring the intrusions at the hinge pillar , B-pillar and at the fuel tank moving skews are created. Also to measure inner door velocity.
- MOV skew can be created from the solver browser.
- Three nodes must be selected at the desired locations, and these three nodes have a specific meaning for the definition of the skew.
Fig 17: Options for creating a MOV skew with three nodes.
- Four MOV frames are created on the components.
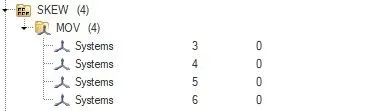
Fig 18: Four moving frames are created at the desired location.
- For all the defined cross-sections, and nodes output requests must be created to determine the required data quantities.
- To create these outputs, there is already a TH folder in the solver browser, and few default outputs requests are defined.
- New output requests are created by selecting the appropriate entity.
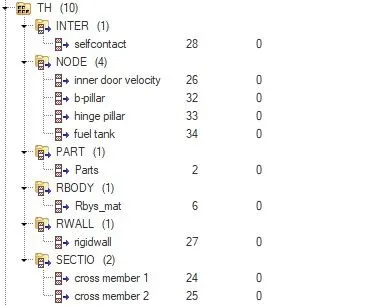
Fig 19: TH is defined for every entity separately.
- Once everything is set up correctly, the model checker is run in the hypermesh and hypercrash.
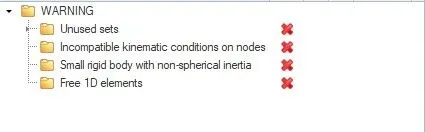
Fig 20: Model checker result in hypermesh.
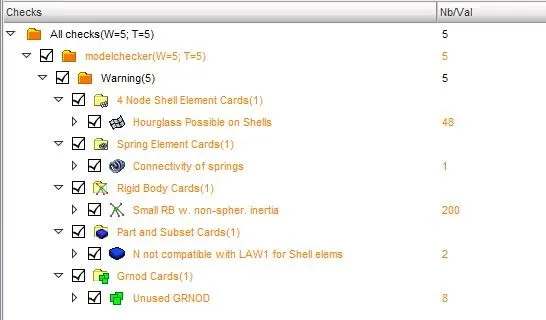
Fig 21: Model checker result in hypercrash.
- From the check, there are only warnings popped and no warnings.
- Warnings can be ignored; any errors must be rectified to run the simulation without any problem.
- Now we can proceed to run our simulation. Navigate to the analysis tab and choose the radioss option.
- Input file option will be available to save the starter and engine file in the desired location.
- In the options bar, "-nt 6" is entered, which denotes parallel processing for the simulation.
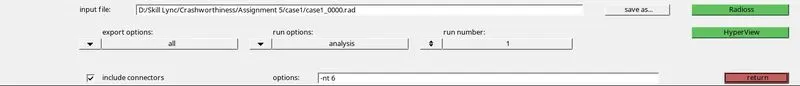
Fig 22: Saving the file with an appropriate name.
- Once all the options are selected correctly, click on the radioss button to run the simulation.
- A separate window pops up and shows the calculation going on, and it might take up to few seconds to minutes based on the complexity of the solution.
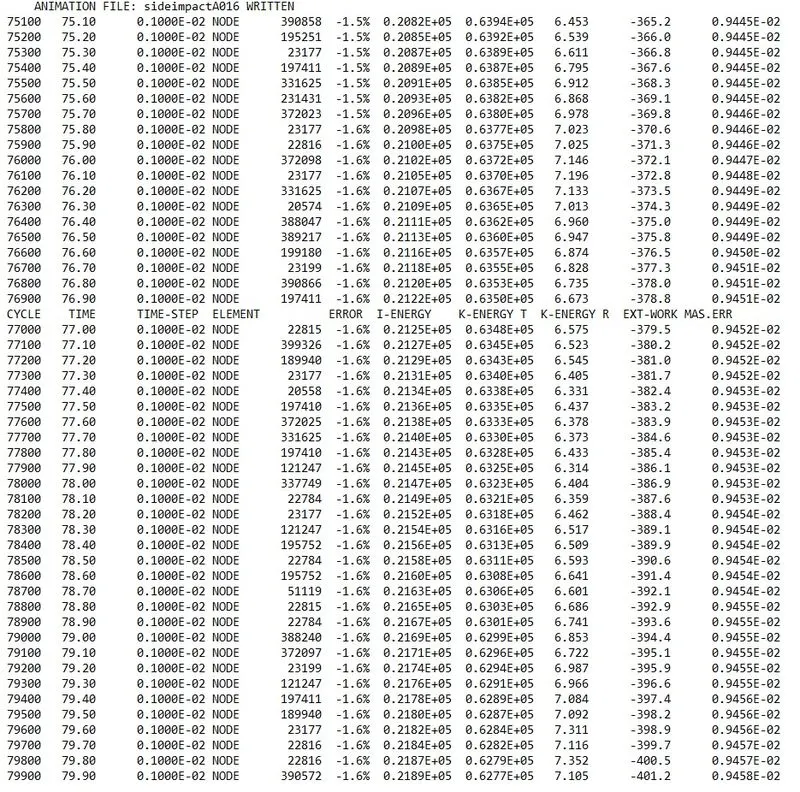
Fig 23: 0001.out files contains the solution information.
- We can check for the energy and mass error from the engine output file whether it lies within the permissible limit or not.
- The energy error starts from 0.0 to -1.6%, and the mass error is 0.9458E-02. Both are in the acceptable range, and we can proceed with the post-processing of our results.
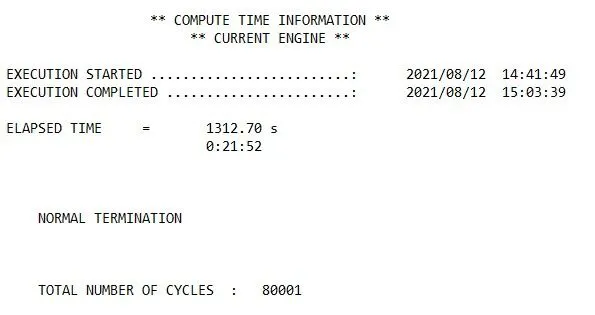
Fig 24: Compute time information.
- ELAPSED TIME = 1312.70 s
- TOTAL NUMBER OF CYCLES: 80001
Results and discussions:
- For post-processing, the results Hyperview and hypergraph are used.
- When hyperview is open, we need to load the model and results file of our simulation.
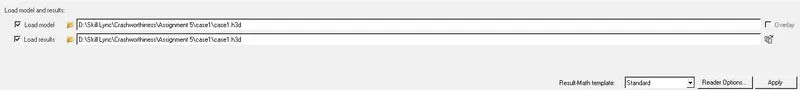
Fig 25: Options for loading the animation file.
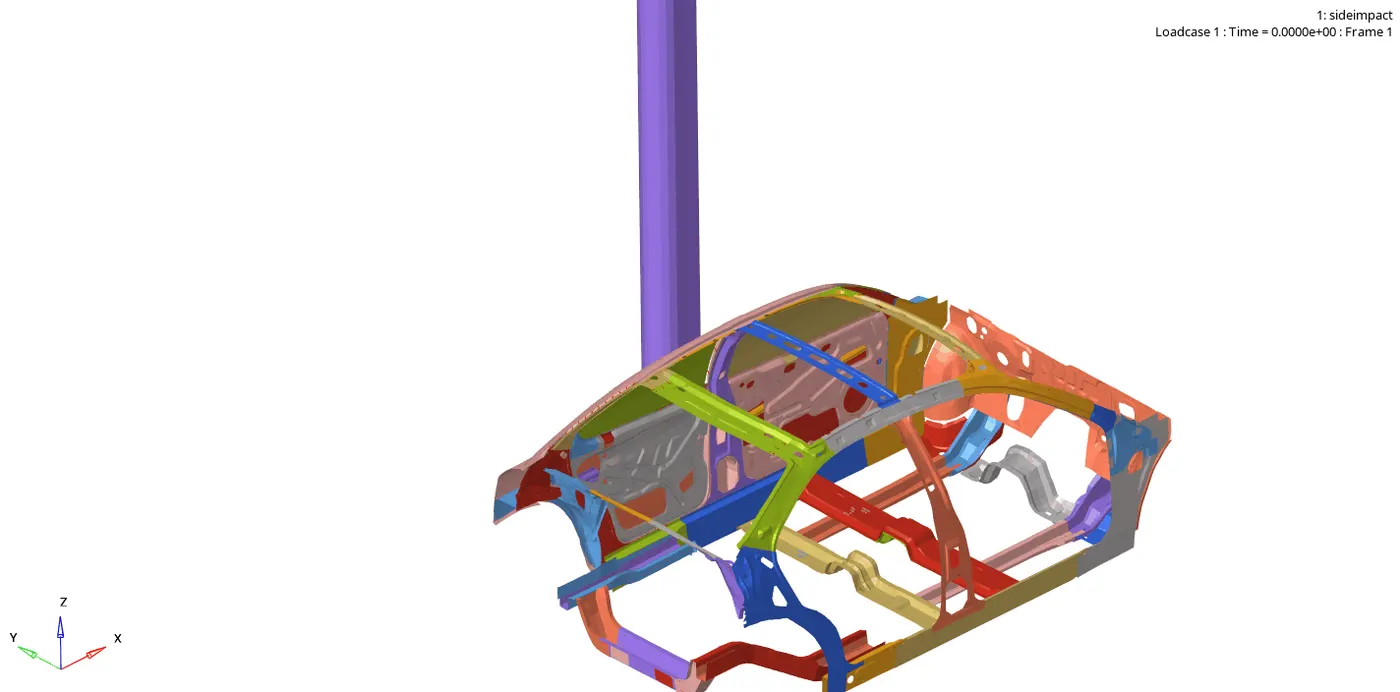
- The above animation represents the vehicle crashed into the rigid wall.
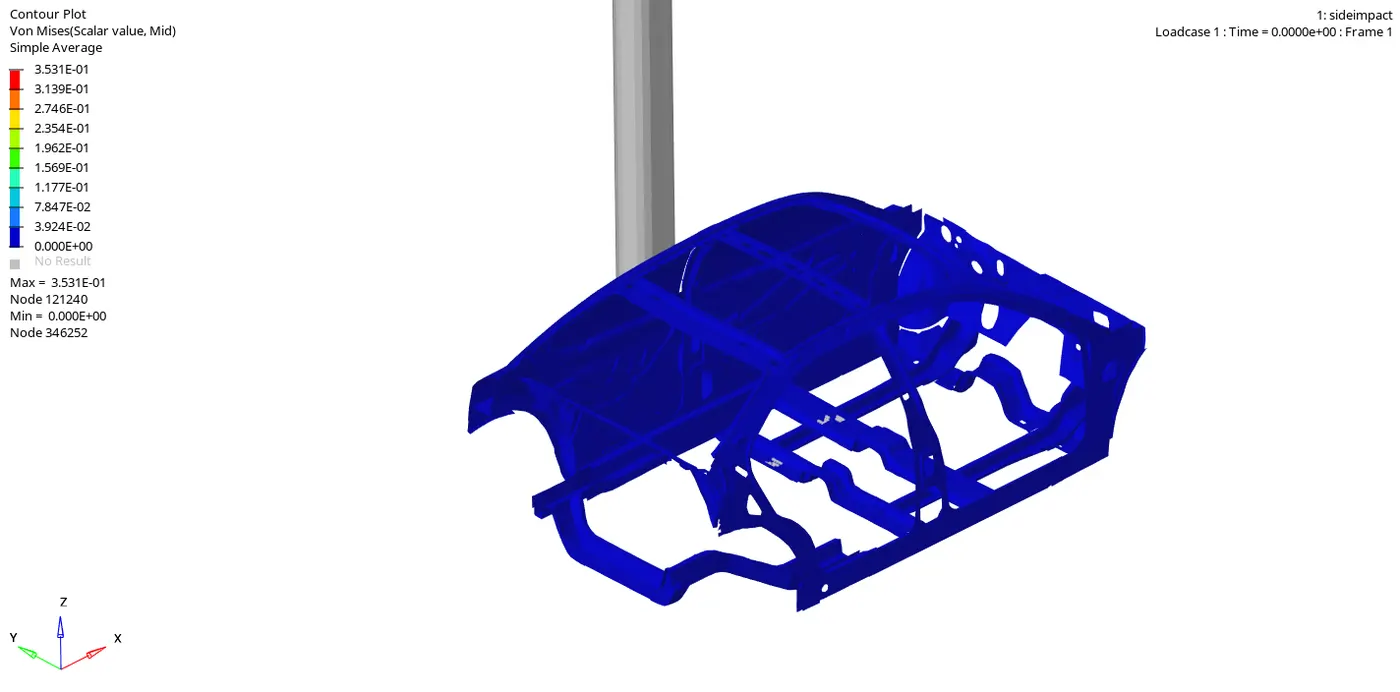
- The above animation represents the von mises stresses generated in the BIW, and the maximum value is 3.531E-01.
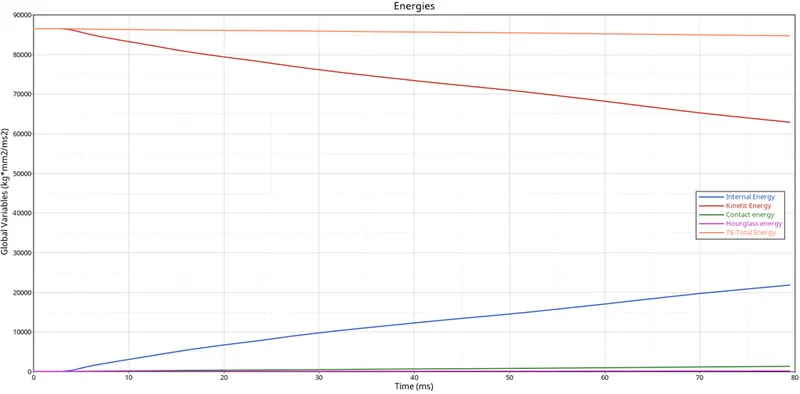
- The above plot shows the Total energy, Kinetic energy, Internal energy, hourglass energy, and contact energy.
- The total energy is the summation of an internal, kinetic, hourglass, and contact energy.
- Internal energy is the sum of kinetic and potential energy in a system.
- The hourglass energy is controlled because of the element formulation.
- The vehicle is given an initial velocity of 35 mph; when it moves with such speed, the system builds kinetic energy. At 0 milliseconds, we can observe the system has the highest kinetic energy and zero internal energy. As the vehicle hits the rigid wall, all the kinetic energy is exhibited on the body, internal energy starts to increase, and the kinetic energy in the system decreases.
- Contact Energy is the opposite force generated from the System to Avoid Penetrations. The gap min value is set to 0.5. When the car moves with a velocity of 35mph and hits the rigid wall, it starts deformation from the B-pillarr section. Hence, penetration of the elements happens; an external force acts on these elements to avoid penetrations. Therefore the contact energy increases gradually.
Cross Member Forces:
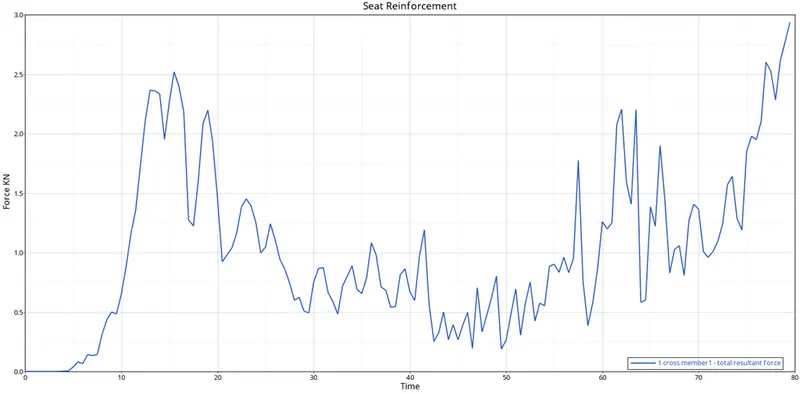
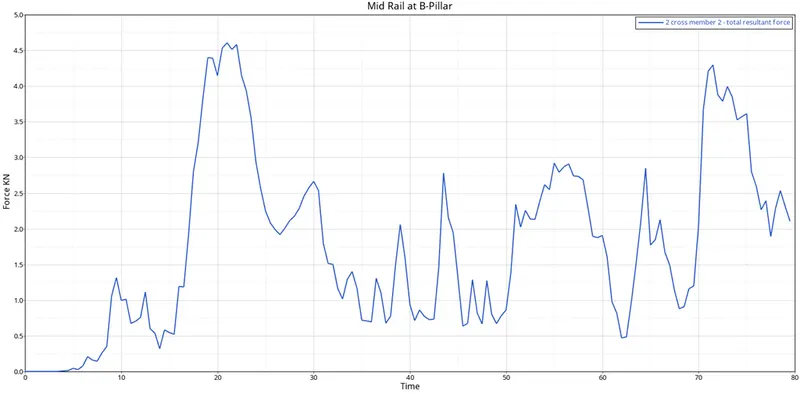
Cross members take the maximum amount of forces in a side impact and these components are very crucial. These members prevent the deformation os the car body inward and hence keep the passenger safe. The maximum sectional force in the seat reinforcement is observed as 2.9KN at 80ms. In the mid rail cross member at the B-Pillar 4.6KN force was recorded at 23 ms.
Intrusions:
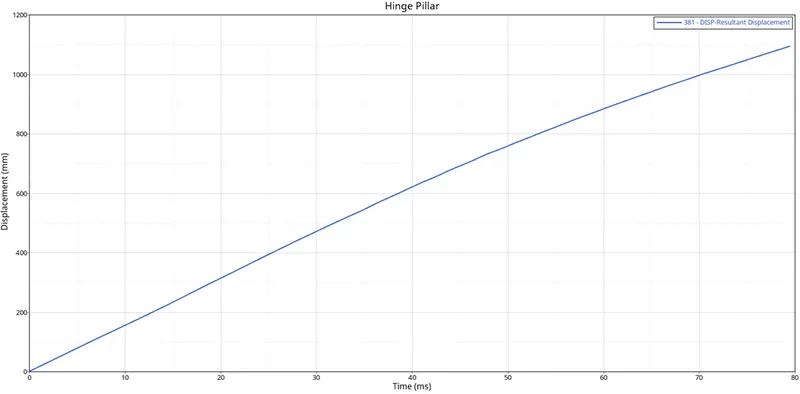
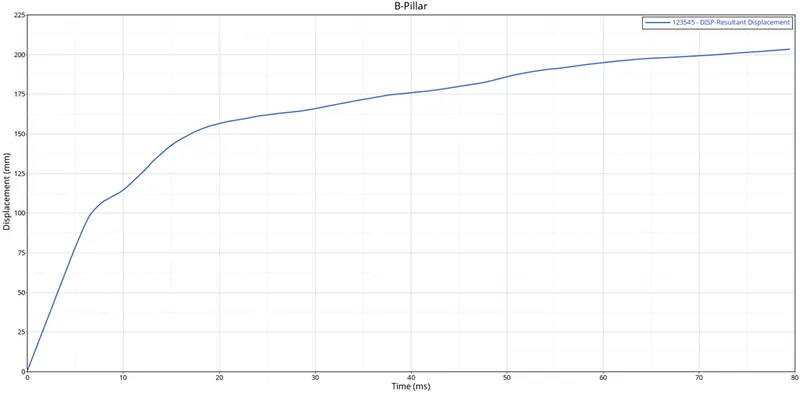
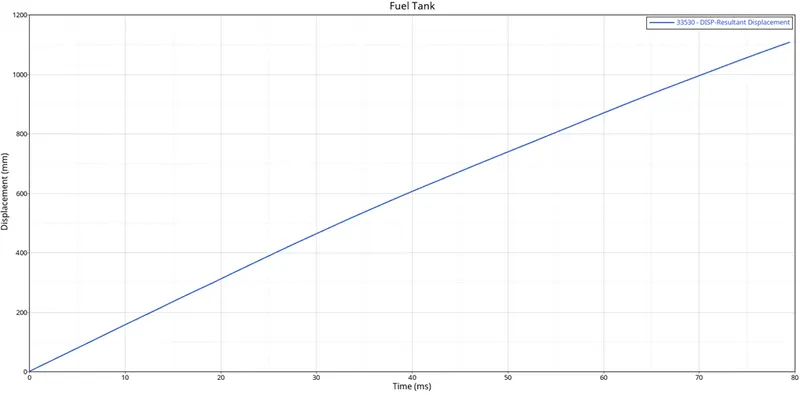
From the above plots we can see the displacement at these locations during the crash. The intrusions harm the occupant and also damage crucial elements like the fuel tank of the vehicle. So the intrusion at the B-pillar and near the fuel tank are studies to see the extend of the intrusion. The B-pillar has a very high intrusion of 205 mm, also it has taken up the maximum force during the collision. The fuel tank and the hinge pillar was displaced almost to the same distance of 100mm.
An alternative way to decrease the intrusion near the fuel is by adding reinforcements and cross members which absorb the forces. Also composite materials which deform less at very high forces can also be employed to mitigate the intrusion.
Inner Door Velocity:
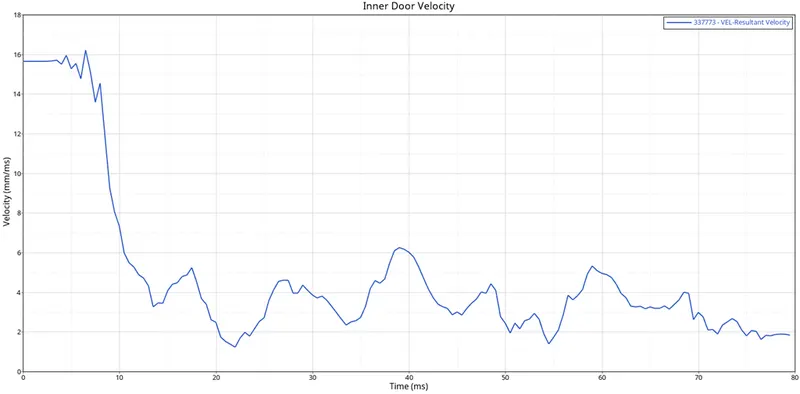
The peak velocity of the door was recorded at 16.3 mm/ms at 7ms. This measurement is velocity is important because the inner side of the door might hit the passenger and causes injuries. After the peak velocity, there is a drop in the velocity and there are ups and downs in the curve as the crash continues.
Conclusion:
Aside pole impact crash simulation was conducted on the scaled-down model of neon doge under FVMSS regulation. Graphs were plotted for the intrusions near the b-pillar, fuel and and at the hinge pillar to check the occupants safety and the fuel tanks damage. The driver side's door velocity is also taken into account.