Basics of DC Motor Control using MATLAB/Simulink
Week 7 Challenge: DC motor control
AIM:
(1) Modify the model of Speed control of a DC motor using BJT H-bridge such that armature current doesn’t shoot up when motor changes direction from forward to reverse using MATLAB/Simulink.
(2) Refer and compare the model of The Four-Quadrant Chopper DC Drive (DC7) block with H-bridge model.
(3) Create a suitable EV model using DC7 Block and explain in brief.
SOLUTIONS:
(1) Study on the Speed control model of a DC motor using BJT H-bridge and experiment with the model to minimize the motor's armature current.
Answer:-
The example shows the simulation of an H-bridge used to generate a chopped voltage and to control the speed of a DC motor.
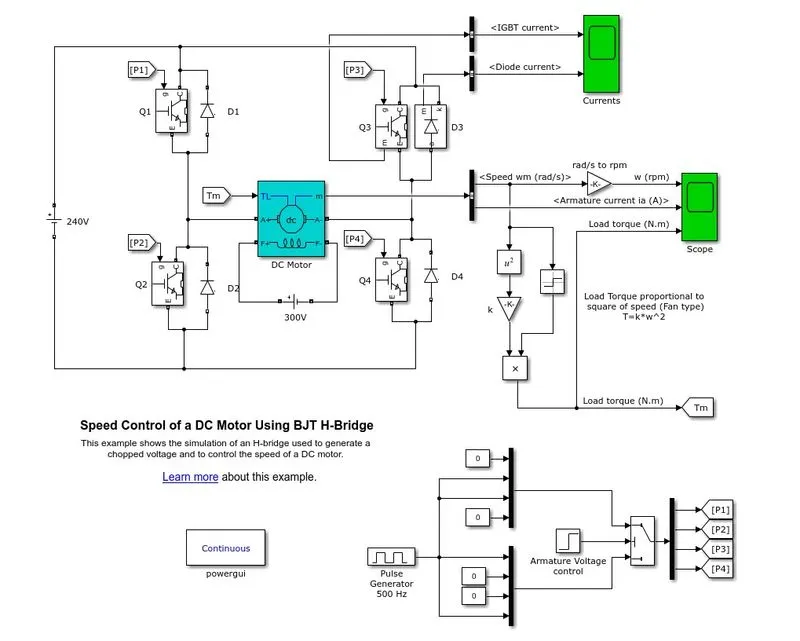
fig (i) Simulink model of Speed control of a DC motor using BJT H-Bridge
The Bipolar Junction Transistor (BJT) when used for power switching applications, operates as an IGBT. When it is conducting (BJT operating in the saturated region), a forward voltage Vf is developed between collector and emitter (in the range of 1 V). Therefore, the IGBT block can be used to model the BJT device.
The IGBT block does not simulate the gate current controlling the BJT or IGBT. The switch is controlled by a Simulink® signal (1/0). The DC motor uses the preset model (5 HP 24V 1750 rpm). It simulates a fan type load (where Load torque is proportional to the square of speed). The armature means voltage can be varied from 0 to 240 V when the duty cycle (specified in the Pulse Generator block) is varied from 0 to 100%.
The H-bridge consists of four BJT/Diode pairs (BJT simulated by IGBT models). Two transistors are switched simultaneously: Q1 and Q4 or Q2 and Q3. When Q1 and Q4 are fired, a positive voltage is applied to the motor and diodes D2-D3 operate as free-wheeling diodes when Q1 and Q4 are switched off. When Q2 and Q3 are fired, a negative voltage is applied to the motor and diodes D1-D4 operate as free-wheeling diodes when Q2 and Q3 are switched off.
Motor Specification:
- Power = 5 HP
- Rated voltage = 240V
- Rated Speed = 1750rpm
Simulation:
At the time of simulation, the motor starts in a positive direction with a duty cycle of 75% (mean DC voltage of 180V). At t= 0.5 sec., the armature voltage is suddenly reversed and the motor runs in the negative direction.
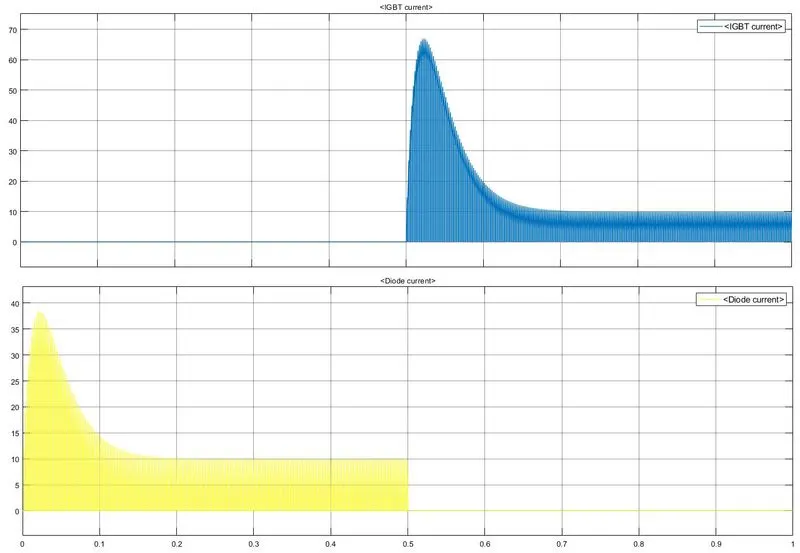
fig (ii) The output graph of the IGBT current & Diode current
Observation:
(1) Pulse width (percentage of period) = 75%
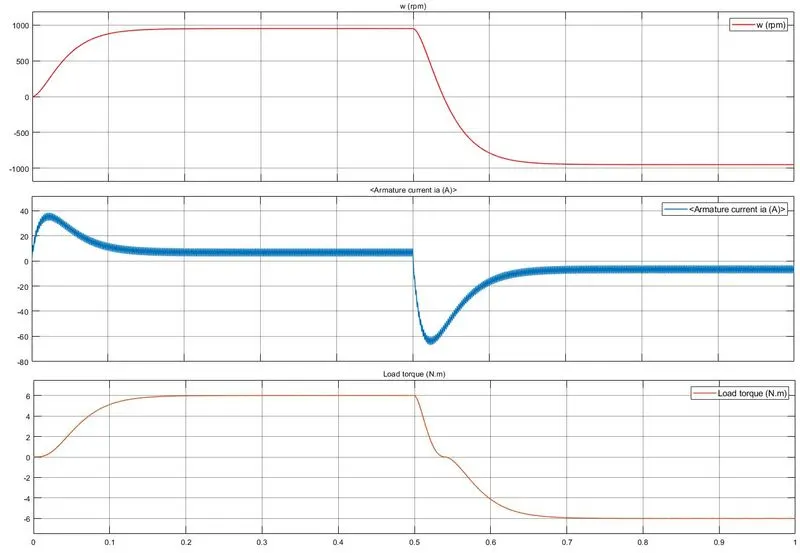
fig (iii) Output graph of Speed, Armature current and Load Torque for 75% duty cycle
Comments:
- Speed is proportional to the applied load.
- The initial spike of current is observed in the armature is very high for this duty cycle.
- The torque of 6N-m is applied to the motor initially and at time =0.5 sec, the direction of rotation is reversed and a negative torque of the same magnitude can be observed.
(2) Pulse width (percentage of period) = 50%
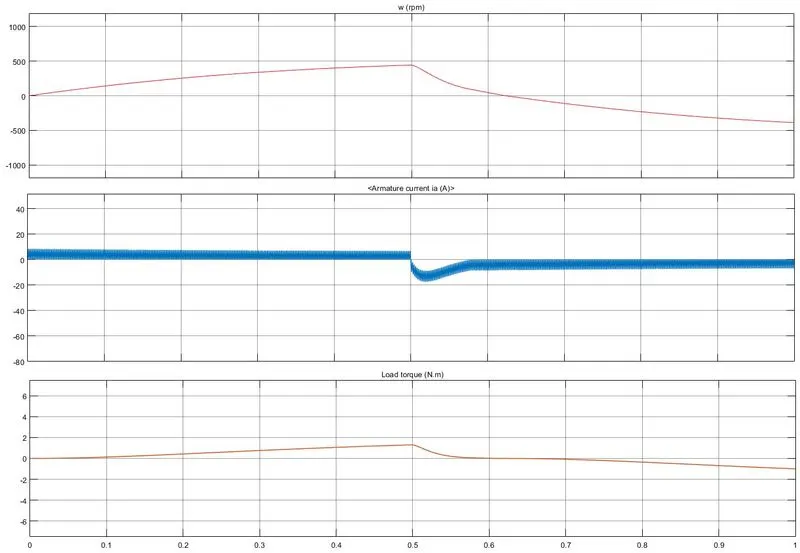
fig (iv) Output graph of Speed, Armature current and Load Torque for 50% duty cycle
Comments:
- By reducing the duty cycle, the shoot up in the armature current is reduced with the decrease in the torque also.
- As we know that the armature resistance of a motor is very small, generally less than one ohm, therefore the starting current would be very large.
- As the motor speed increases, the back emf increases and the difference in supply voltage & back emf also goes on decreasing. This results in a decrease of armature current until the motor attains its stable rated speed. Under this condition, the armature current reaches its desired rated value.
- To optimized the armature current, we need to control the duty cycle for each period of time.
-------------------------------------------------------------------------------------------------------------------------------------------------------------------------------
(2) Comparing the model of "The four-quadrant chopper DC drive (DC7)" with the H-bridge model.
Answer:-
The example shows the DC7 four-quadrant chopper DC drive during speed regulation.
The 200 HP DC motor is separately excited with a constant 150 V DC field voltage source. The armature voltage is provided by an IGBT converter controlled by two PI regulators. The converter is fed by a 515 V DC bus obtained by rectification of a 380 V AC 50 Hz voltage source. In order to limit the DC bus voltage during dynamic braking mode, a braking chopper has been added between the diode rectifier and the DC7 block.
The first regulator is a speed regulator, followed by a current regulator. The speed regulator outputs the armature current reference (in p.u.) used by the current controller in order to obtain the electromagnetic torque needed to reach the desired speed. The speed reference change rate follows acceleration and deceleration ramps in order to avoid sudden reference changes that could cause armature over-current and destabilize the system. The current regulator controls the armature current by computing the appropriate duty ratios of the 5 kHz pulses of the four IGBT devices (Pulse Width Modulation). For proper system behaviour, the instantaneous pulse values of IGBT devices 1 and 4 are opposite to those of IGBT devices 2 and 3. This generates the average armature voltage needed to obtain the desired armature current. In order to limit the amplitude of the current oscillations, a smoothing inductance is placed in series with the armature circuit.
fig (v) Simulink model of an example of 4 Quadrant chopper DC7 drive
Simulation:
- Before starting the simulation, set the initial bus voltage to 515 V via the GUI block ('Initial States Setting' button and 'Cbus' variable).
- Start the simulation. You can observe the motor armature voltage and current, the four IGBT pulses and the motor speed on the scope. The current and speed references are also shown.
- The motor is coupled to a linear load, which means that the mechanical torque of the load is proportional to the speed.
- The speed reference is set at 500 rpm at t = 0 s. Observe that the motor speed follows the reference ramp accurately (+400 rpm/s) and reaches steady state around t = 1.3 s.
- The armature current follows the current reference very well, with fast response time and small ripples. Notice that the current ripple frequency is 5 kHz.
- At t = 2 s, speed reference drops to -1184 rpm. The current reference decreases to reduce the electromagnetic torque and causes the motor to decelerate with the help of the load torque.
- At t = 2.2 s, the current reverses in order to produce a braking electromagnetic torque (dynamic braking mode). This causes the DC bus voltage to increase.
- At t = 3.25 s, the motor reaches 0 rpm and the load torque reverses and becomes negative. The negative current now produces an accelerating electromagnetic torque to allow the motor to follow the negative speed ramp (-400 rpm/s). At t = 6.3 s, the speed reaches -1184 rpm and stabilizes around its reference.
Ouput graph:
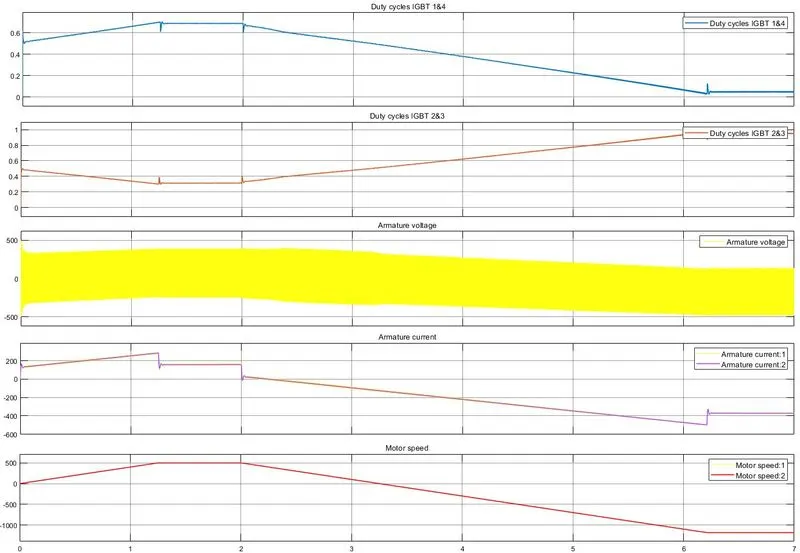
fig (vi) Output graph of the duty cycles of the switches, armature voltage, armature current and the motor speed
Chopper circuit:
Chopper circuits are known as DC to DC converters. Similar to the transformers of the AC circuit, choppers are used to step up and step down the DC power. They change the fixed DC power to variable DC power. Using these, DC power supplied to the devices can be adjusted to the required amount.They can convert the steady constant DC voltage to a higher value or lower value based on their type.DC choppers are more efficient, speed and optimized devices. These can be incorporated on electronic chips. They provide smooth control over the DC voltage.
There are 4 switches with diodes along with the supply voltage, resistor, inductor and the back emf in series. The operation happens in 4 modes by closing the 2 diagonally opposite switches at a time.
Modes:
- Forward Motoring mode.
- Forward Regenerative braking mode.
- Reverse Motoring mode.
- Reverse Regenerative braking mode.
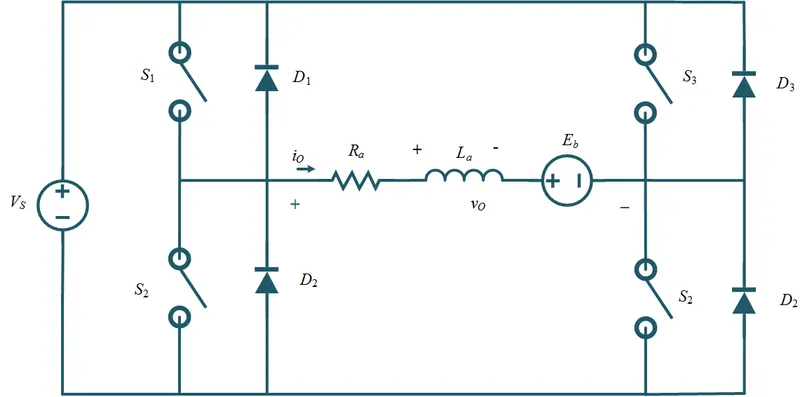
fig (vii) Circuit diagram of chopper DC drive
Working principle:
(1) 1st Quadrant
- When S1 is in operating condition, the current flows from supply voltage through S1, armature resistance, & inductor to the output load.
`V_s=V_o` - When S1 is OPEN, the load current freewheels through S4 and D2.
- In this quadrant, induced current & output voltage remains positive.
- It may be noted that it operates as a step-down chopper in this case.
(2) 2nd Quadrant
- For this quadrant, S2 is operated while keeping the S1, S3 & S4 OPEN. When S2 is CLOSE, the DC source in the load drives current through S2, D4, E and L. Inductor L stores energy during the on the period of S2.
- When S2 is turned CLOSE, the current is fed back to the source through D1 & D4. It should be noted at this point that (E+Ldi/dt) is more than the source voltage Vs. As load voltage Vo is positive and Io is negative, it is the second quadrant operation of the chopper. Since the current is fed back to the source, this simply means that load is transferring power to the source.
- In this quadrant, configuration operates as a step-up chopper.
(3) 3rd Quadrant
- For this quadrant, S1 is kept OPEN, S2 is kept CLOSE and S3 is operated. When S3 is CLOSE, the load gets connected to the source and hence load voltage is equal to source voltage. But carefully observe that the polarity of load voltage Vo is opposite to what shown in the circuit diagram. Hence, Vo is assumed negative and it may be seen that Io is flowing in the direction opposite to shown in the circuit diagram and hence negative.
- Now, when S3 is CLOSE, the negative load current freewheels through the S2 and D4. In this manner, Vo and Io both are negative.
- Hence, the chopper operates in the third quadrant with both the power voltage and current are negative.
(4) 4th Quadrant
- To obtain this quadrant operation, S4 is operated while keeping S1, S2 and S3 OPEN. The polarity of load emf E needs to be reversed in this case too like third quadrant operation.
- When S4 is turned CLOSE, positive current flows through S4, D2, L and E. Inductance L stores energy during the time S4 is CLOSE. When S4 is made OPEN, the current is fed back to the source through diodes D2 & D3.
- Here the load voltage is negative, but the load current is always positive. This leads to chopper operation in the fourth quadrant.
- Here, power is fed back to the source from the load and the chopper acts as a step-up chopper.
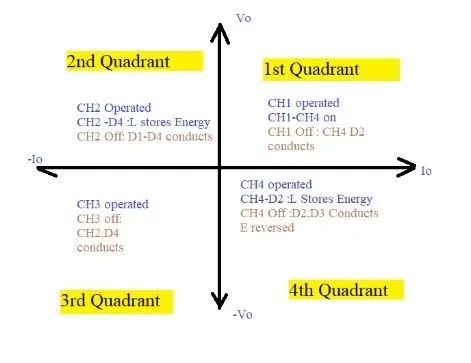
fig (viii) Four Quadrant representation of the Chopper circuit
Comparison:
| Parameters | 4 quadrant chopper DC drive (DC7) | H-bridge drive |
| Braking | Regenerative barking is possible | Dynamic braking can be achieved |
| Current flow | The current values are chopped but not continuous | Current values are continuous |
| To change the direction of motor | Current signals are interrupted with one another | The polarity of the current is changed |
| Application | Automobiles to control motor speed and direction | Robotics & Electro-Mechanical devices to control DC motor speed and direction |
-------------------------------------------------------------------------------------------------------------------------------------------------------------------------------
(3) Simulink model of EV using DC7 block.
Answer:-
For this problem, we need to change a few parameters from the example of 4 Quadrant chopper DC7 drive. We replace the following things:
- DC battery source.
- Drive Cycle (WOT).
- Current measurement block.
- Vehicle load characteristics base on the torque equation.
`T= 24.7 + 0.0051 omega^2`
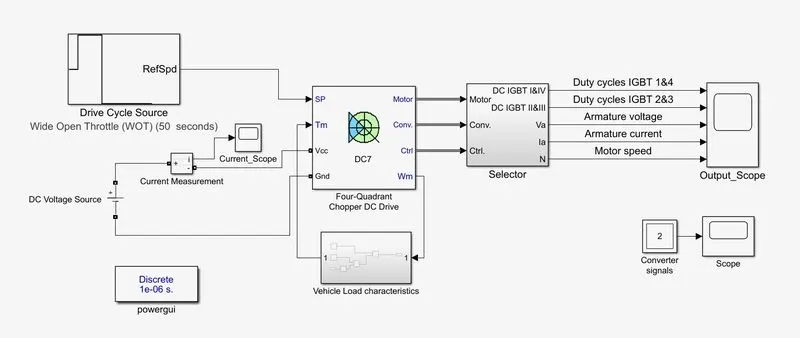
fig(ix) Simulink model of the EV using DC7 block
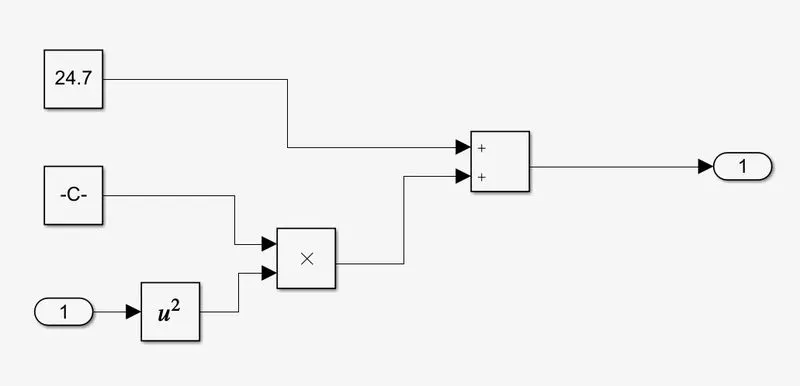
fig (x) Simulink block diagram of Vehicle load characteristics using the toque equation
Results:
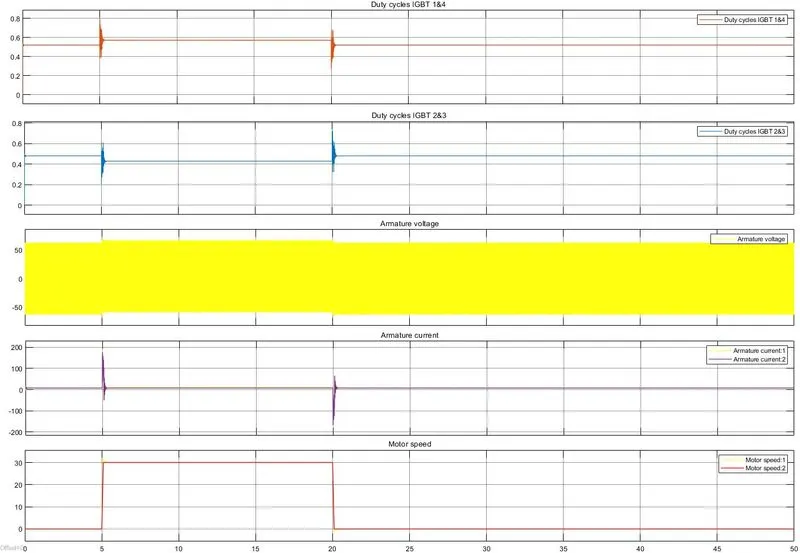
fig(xi) The output graph w.r.t. the default values of WOT drive cycle.
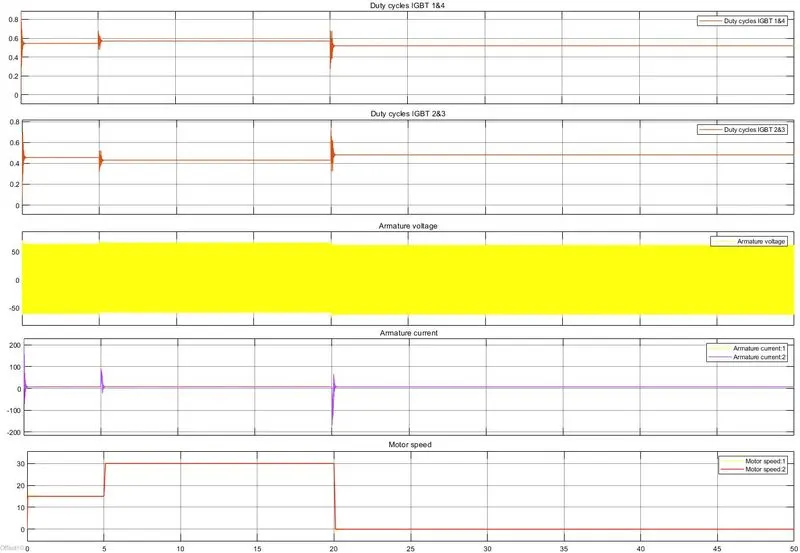
fig (xii) The output graph w.r.t. the change in initial speed in the WOT drive cycle.
-------------------------------------------------------------------------------------------------------------------------------------------------------------------------------
CONCLUSION:
(1) To reduce the shoot up armature current, we need to change the pulse width of the duty cycle.
(2) Studied and explain the chopper circuit and the comparison with the BJT H-Bridge.
(3) Successfully model an EV using DC7 block.
REFERENCE:
- https://in.mathworks.com/help/physmod/sps/ug/speed-control-of-a-dc-motor-using-bjt-h-bridge.html
- https://in.mathworks.com/help/physmod/sps/ug/dc7-four-quadrant-chopper-200-hp-dc-drive.html
- https://www.elprocus.com/a-brief-introduction-to-chopper-circuits/#:~:text=DC%20chopper%20works%20on%20DC,efficient%2C%20speed%20and%20optimized%20devices.
- https://skill-lync.com/projects/multi-quadrant-operation-of-dc-motor-in-simulink