DussehraFestive scholarship on Skill-Lync courses, this week onlyFestive scholarship is openOffer ends Wed, 21 Oct, 11:59 pm IST.

Dussehra 2026

Start your next chapter this Dussehra

Tell us where you want to work. A counsellor will match you to the right course and confirm the festive scholarship you qualify for.

  • Festive scholarship on course fees, confirmed on your call
  • Free 20-minute call to map the right course to your goal
  • Real industry projects and placement support with every course

Offer ends Wed, 21 Oct, 11:59 pm IST

3,905 engineers placed since 2019 · 1,277 hiring companies

By submitting you agree to our Terms and Privacy Policy.

You're on the list

Browse courses
Electrical · PG program

Post Graduate Program inElectric Vehicle Design & Development

A holistic Electric Vehicle course providing advanced industry-oriented training for electrical engineers. Our EV course provides students the option of enrolling in four major tracks based on their career choices. Skill-Lync’s Electric Vehicle design course perfectly combines theoretical and practical learning and trains engineers for the future of automation

★ 4.9· 17 reviews

Duration
48 weeks
Content
513 hours
Courses
7
Projects
59
Mode
Online
Overview

What you'll
be able to do.

Skill-Lync offers this program to give engineers the set of skills needed to thrive in the EV industry. There are four specialization tracks in this program, each focusing on an important facet of the EV industry. You get to enroll in one track that you want to further your skills in.

By choosing the Embedded Software track, you will learn about the hardware and software interfaced in the development of embedded systems for EV applications. You will also learn about electronic control units in EVs, bare metal programming, software verification and validation, Linux driver development, and C++.

In the Model-Based Development track, you will learn about the model-based approach in the development of EVs. You will also learn about AUTOSAR architecture and automotive embedded systems. By choosing this track, you will get extensive hands on experience in simulating and assessing electric and hybrid electric vehicles using software like MATLAB and Simulink.

The E-Drive System for EV track gives you an understanding of power converter topologies, the design of power converters, and the use of MATLAB and Simulink in designing and simulating power components. You will also learn how to study the efficiency of these power components using software tools.

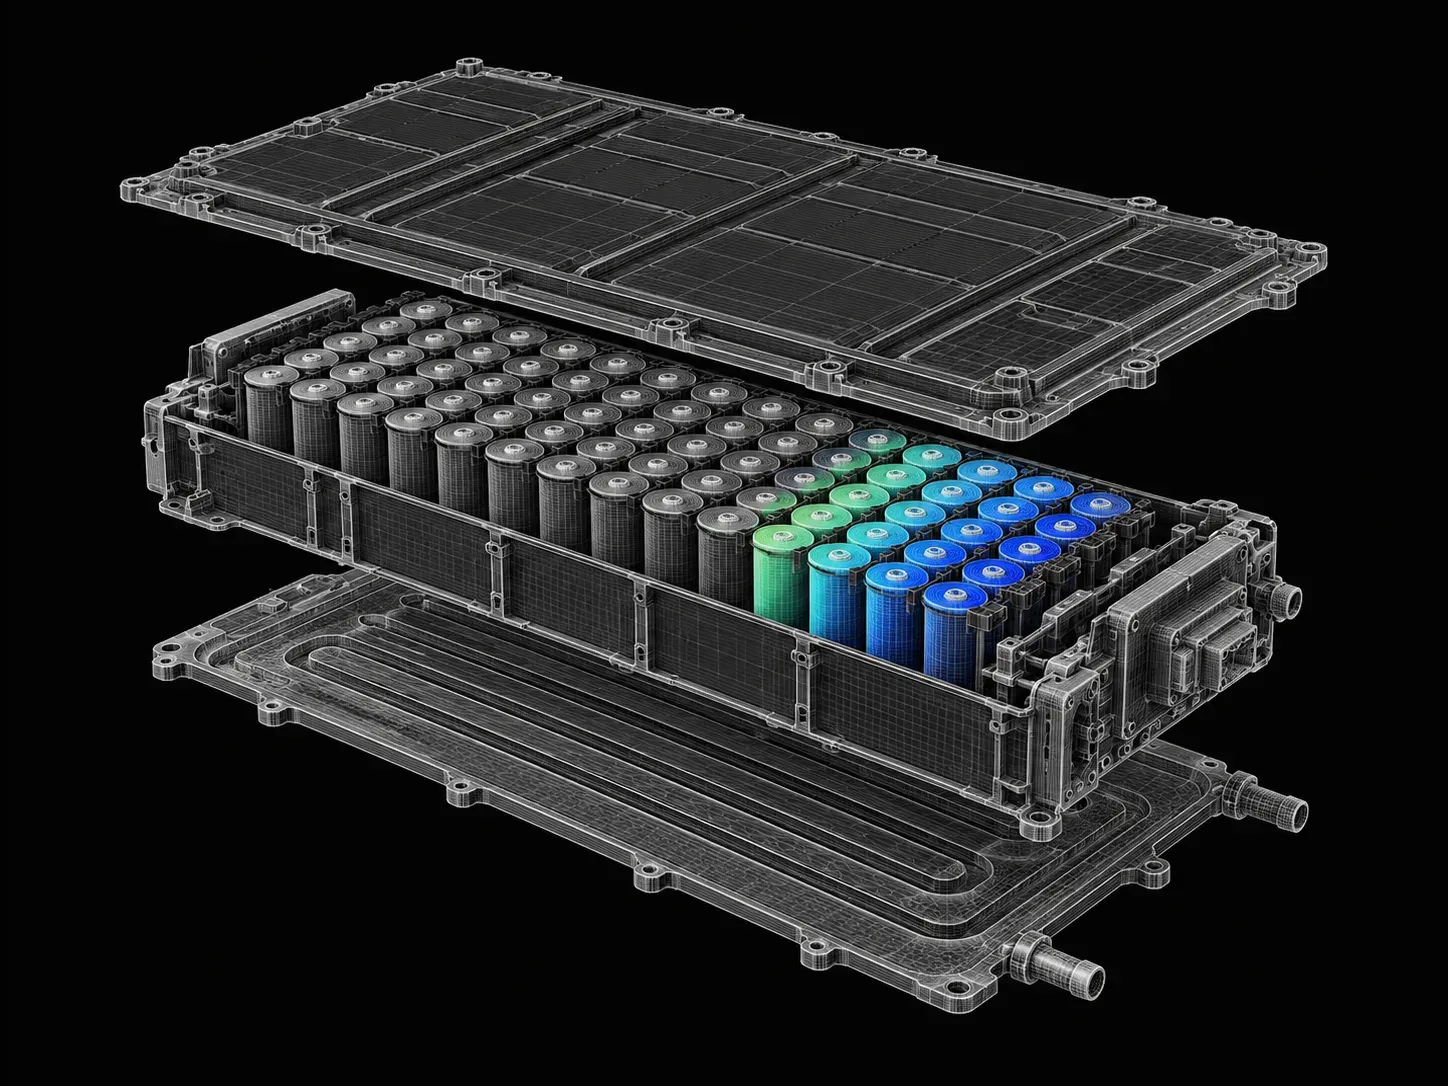
The EV System and Wiring Design track will take you through the design, simulation, and modeling of EVs and their individual parts. This track will teach you about powertrain architecture and battery design.

Why this program

  • Learners get the opportunity to specialize in a track of their interest.
  • Learners get a thorough understanding of concepts and software tools in the track they choose.
  • This program offers exposure to modern trends and standard practices following in the industry.
  • After completing this course, the students will gain a better understanding of the concepts of Electric Vehicles, PCB Design, Embedded Systems, Power Converters, and Software Verification and Validation.
  • This program is integrated with software tools like MATLAB, Simulink, Python, Altair Embed, Altium Designer, and Ansys Maxwell. This gives learners a practical and applied understanding of the theoretical concepts taught.
  • The courses in this program have been developed by top experts in the industry.
  • Learners will get the industry-relevant skills needed to have them job ready.
  • This program will have you working with the following hardware:
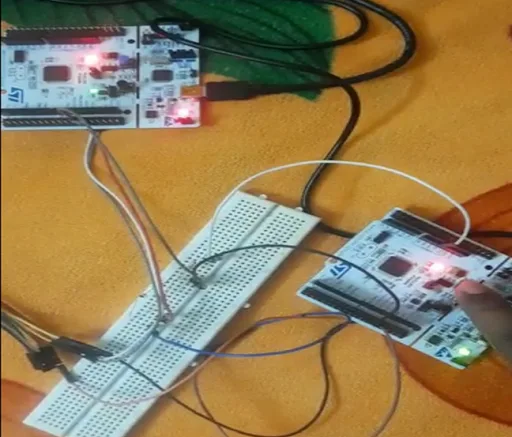
    • STM32 Nucleo-64 development board with STM32F334R8
    • USB Logic Analyzer 24M 8CH, MCU ARM FPGA DSP Debug Tool
    • Official Arduino Sensor Kit
    • Stepper Motor and ULN2003 Stepper Motor Driver
    • BeagleBone Black

Here are some of the roles you can apply to after completion of this program:

  • PCB/Hardware Design Engineer
  • Embedded Systems Engineer
  • Battery Systems/Design Engineer
  • Electric Vehicle Design Engineer
  • ADAS Design/Testing Engineer
  • Power Electronics Engineer
  • Machine Learning Engineer

Higher education can be pursued in the following domains:

  • Masters in Electronics and Drive
  • Masters in Automotive Engineering
  • Masters in Automobile Engineering
  • Masters in Data Science
Tools you'll use
MATLABSimulinkSocketCANLINUXC++ANSYS MaxwellAltium DesignerLTspiceC ProgrammingSTM32CubeIDEAVR ATmega328SimulIDEMicrochip StudioEmbedded LinuxMbed SimulatorArm Cortex M4 - STM32CAN ProtocolLRDA Tool SuiteCATIA V5
Curriculum

4 tracks to choose from,
5–10 courses each.

Get the full syllabus ↓
  1. 01Embedded Programming Essentials18 modules
    1. C Language for Embedded Programming, C Input /Output Functions, C Data Types for Embedded Programming, C Language OperatorsW01
      • What an Embedded System is
      • Traits and Architecture of an Embedded System
      • Embedded Hardware and Software
      • Why C-language is Preferred for Embedded SW Development
      • Installing Tool Chain
      • Installing STM32CubeIDE
      • Installing GCC Compiler
      • Creating a New Project
      • Basic Elements of a C-Program
      • C-Program Layout
      • Standard I/O - Library
      • getchar and putchar
      • printf and sprintf
      • scanf and sscanf
      • C Data Types
      • Signed Data Representation
      • Data Type - Overflow/Underflow Issues
      • C99 Data Types
      • Fixed Point and Floating-Point Representation
      • FPU Usage
      • ‘Enum’ and ‘Typedef’
      • Operators in C
      • Operators Precedence and Associativity
    2. C Control Statements, Function Prototypes, Introduction to Pointers, C Storage Classes and Type QualifiersW02
      • Control Statements in ‘C’ language
      • ‘if-else’
      • Loops for Iterations
      • Switch Case for Multiple Selections
      • Tips and Traps for Switch-Case
      • ‘if-else’ vs ‘switch’
      • ‘goto’ Statement and Labels
      • Introduction to vFunctions
      • Advanced Control Flow with ‘setjmp( )’ and ‘longjmp( )’
      • Functions ()
      • Function Prototypes
      • Recursive Function
      • Function Pitfalls
      • Introduction to Pointers
      • Call by Value Vs Call by Reference
      • Pointer Arithmetic
      • Functions as ‘Pointer'
      • C Storage Classes
        • Automatic
        • External
        • Static
        • Register
    3. C Compilation Process, C Preprocessor Directives, Arrays in C, Arrays to Functions, and Array of Function PointersW03
      • Stages of the Compilation Process
        • Pre-processing
        • Compilation
        • Assembling
        • Linking
      • GCC Commands for Each Stage
      • Preprocessor Directives in C
      • Macros and their Types
      • Conditional Compilation
      • #pragma
      • Introduction to Arrays
      • Array Initialization
      • Accessing Array Elements
      • 2D Arrays
      • 3D Arrays
      • Pointers and Arrays
      • Passing Array Elements to a Function
      • Array of Pointers
      • ‘Function’ as ‘Pointer’ - Function Pointers
      • Array of Function Pointers
    4. Command Line Arguments, Variadic Functions, Strings and String Functions in C, Structures in C, Unions and Bitfields in CW04
      • Command Line Arguments in C
      • Variadic Functions in C
      • Strings in C language
      • String Functions from
      • Structure Declaration in C
      • Array of Structures
      • Pointer Objects to Structure
      • Memory Allocation of Structure and Structure Padding
      • Structure Padding Comparison
      • Bit Fields
      • Unions
    5. Advanced Function Arguments, Advanced Pointers-Void Pointers, File Operations in C, Standard Libraries CW05
      • Function Pointers
        • Passing Function Pointers as Arguments to a Function
      • Inline Functions
      • Passing a String as a Function Argument
      • Returning a String from a Function
      • Passing Arrays to Function Arguments
      • Returning Multiple Values from a Function
      • Passing Structure Pointers as Function Arguments
      • Passing an Array of Structures to a Function
      • Double Pointers with Example
      • Void pointers with Example
      • Miscellaneous Features
      • File I/O Handling
      • Read and Write Operations
      • Error Handling Mechanisms
      • General Properties of C Library
      • Functions of C Library
      • Need for Libraries - Static vs. Dynamic Libraries
      • Utility Functions
    6. C Memory Management, Dynamic Memory Allocation, Modular C Programming, Modular C Programming, and C Program OptimizationW06
      • C Memory Model
      • Dynamic Memory Allocation on Heap
      • Miscellaneous Memory Functions
      • Variable Length Arrays
      • Creating a User-Defined Library
      • Makefile Project in STMCubeMX IDE
      • Creating a Custom Makefile
      • Introduction to Debugging
      • Debugging using GDB Tool
      • Debugging using Preprocessor Directives
      • Optimization for Memory Usage and Execution Speed
      • Optimization Methods
      • Code Level Optimization
    7. Stack and Stack Operations, Queue and Queue Operations, Linked List, Finite State MachineW07
      • Fundamental Concepts of Data Structures
      • Operation on Data Structure
      • Arrays and Array Operations
      • Stack and Standard Stack Operations
      • Fundamental Concepts of Queue
      • Operations performed in Queue
      • Different Types of Queue
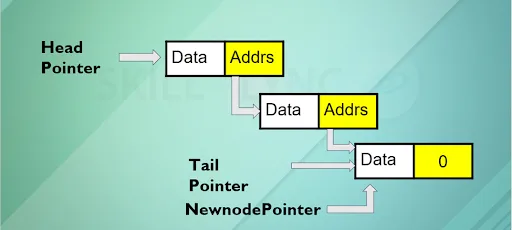
      • Fundamental concepts of Linked List
      • Types of Linked List
        • Singly Linked List
        • Doubly Linked List
        • Circular Linked List
        • Doubly Circular Linked List
      • Introduction to FSM (Finite State Machine)
      • State Diagram
      • Explanation of State Diagram
      • State Table
      • Implementation of State Machine
      • Mealy State Machine
      • Moore State Machine
    8. Process Management in C, Embedded Design PatternsW08
      • Threads
      • Memory Model of Threads
      • Library
      • Process Vs Threads
      • IPC Mechanism
      • Different Design Patterns of Embedded System
      • Hardware Adapter Pattern
      • Observer Pattern
      • Debounce Pattern
      • Interrupt Pattern
      • Polling Pattern
    9. C and Embedded C StandardsW09
      • C Standards
      • K&R C
      • K&R Standards
      • ANSI C
      • C90 Standards
      • C99 Standards
      • C11 Standards
      • Embedded C
      • C-General Coding Standards
      • Embedded C Standards
    10. AUTOSAR C Rules and MISRA C GuidelinesW10
      • Common Pitfalls in C Language
      • Overstepping of Array Boundaries
      • Example of Faulty Code
      • Buffer Overflow
      • Stack Overflow
      • Glimpse into AUTOSAR and MISRA
      • Prominent MISRA C Rules
    11. Introduction to C++ and OOPS-Part 1W11
      • Introduction of C++
        • What is C++?
        • Program Paradigm
        • ANSI/ISO Vs Standard C++
        • C++ Syntax and Structure
        • C++ Language Fundamentals
        • Benefits of C++ over C
      • C vs C++
        • Procedural Vs OOP
        • Compiling a C Program in C++ Environment
        • Undefined Behavior in C and C++
        • Void * in C vs C++
        • Name Mangling
        • Use of Extern C in C++ Programming
        • Structures in C Vs Class in C++
      • C++ Vs Java
        • Similarities between C++ and Java
        • Exception Handling in C++ vs Java
        • Default Virtual Behavior in C++ Vs Java
        • Floating Point Operations and Property of Associativity in C, C++, and Java
      • Dynamic Memory Allocation
        • malloc()
        • calloc()
        • realloc()
        • free
        • new
        • delete
        • malloc Vs new
        • free Vs delete
      • Object Oriented Programming
        • OOP’s Concepts - Briefing
        • Class
          • Default Access Specifier in a Class
          • Access Modifiers
          • Constructor
          • Destructor
          • Assignment Operator
          • Copy Constructor
          • Default Member Functions in a Class
        • Object
    12. OOPS - Part 2W12
      • Object-Oriented Programming
        • Encapsulation
        • Abstraction
        • Message Passing
        • Dynamic Binding
        • Data Hiding
        • Inheritance
          • Use of Inheritance
          • Modes of Inheritance
          • Types of Inheritance
            • Single Inheritance
            • Multiple Inheritance
            • Hierarchical Inheritance
            • Multiple Inheritance
            • Hybrid Inheritance
          • Multipath Inheritance
        • Diamond Problem
    13. OOPS - Part 3W13
      • Object-Oriented Programming
        • Polymorphism
          • Compile Time Polymorphism
            • Function Overloading
            • Operator Overloading
          • Runtime Polymorphism
            • Function Overriding
            • Virtual Keyword
            • VTable
            • Vptr-V Pointer
            • Virtual Functions
            • Abstract Class
            • Pure Virtual Function
            • Interface Vs Abstract Class
    14. Constructor and DestructorsW14
      • Constructor and Destructor
        • Virtual Constructor
        • Virtual Destructor
        • Virtual Copy Constructor
        • Shallow Copy Vs Deep Copy
        • Default Constructor and Copy Constructor
        • Copy Constructor and Assignment Operator
        • Dangling Pointer
        • Void Pointer and Opaque Pointer
        • Null Pointer and Wild Pointer
        • Private Constructor
        • Private Destructor
        • Copy Elision
        • Explicit Keyword
    15. Keywords in C++W15
      • Static Keyword in C++
        • Static Variables in a Function
        • Static Variables in a Class
        • Static Members of Class - Static Class Objects
        • Static Member Functions in a Class
      • Const Keyword in C++
      • Mutable Keyword in C++
      • Friend Function and Friend Class in C++
      • This Pointer in C++
        • ‘this’ Pointer
        • Types of ‘this’ Pointer
        • Delete ‘this’
    16. Type CastingW16
      • Type Casting in C++
        • Implicit Cast
        • Explicit Cast
        • dynamic_cast
        • static_cast
        • reinterpret_cast
        • const_cast
      • Member Initializer List in C++
        • Use of Initializer Lists
        • Member Initializer Lists
    17. Exception HandlingW17
      • Exception Handling in C++
        • Exception Handling in C++
        • Base Class and Derived Class Exception Handling
        • Catch Block in C++
        • Object Destruction
        • Stack Unwinding in C++
      • Templates in C++
        • Introduction to Templates
        • Function Templates
        • Class Templates
        • Template Specialization
    18. Multi-ThreadingW18
      • Multithreading in C++
      • Posix Threads
      • Std::thread
      • Inter-Process Communication
      • What is IPC?
      • Various Methods in IPC
      • Smart Pointers
      • Use of Smart Pointers
      • Types of Smart Pointers
      • Auto Pointer
      • Unique Pointer
      • Shared Pointer
      • Weak Pointer
  2. 02Fundamentals of Embedded Systems12 modules
    1. Role of Embedded Systems in Mechatronic SystemsW01

      Embedded systems are used in the control of mechanical parts in mechatronic systems. Analog control is now being replaced with digital controllers like microprocessors or microcontrollers. It is important for learners to understand the basics of embedded systems, and their application in electronic control units used in the automotive industry.

      In this week, you will learn about

      • Basics of Embedded Systems
      • Basics of Automotive ECUs
      • Case Studies and Reference Designs of ECUs
    2. ARM (MCU) ArchitectureW02

      The Advanced RISC Machines (ARM) architecture processor is a 32-bit microcontroller. As these processors are Reduced Instruction Set Computers (RISC), they consolidate all their functions down to a single chip. ARM processors are widely used in electronic gadgets like mobile phones. It is important to understand the basics of ARM processor architecture and their applications when learning about embedded systems.

      In this week, you will learn about

      • Basic Features of ARM Processor
      • Products Details and Product Roadmap
      • ARM Cortex Processor Internals
      • Cortex Microcontroller Software Interface Standard (CMSIS)
      • ARM Cortex M4 Programming Model
    3. Sensors, Actuators, and Instrumentation ClusterW03

      Embedded systems have sensors and actuators. Sensors convert physical inputs into electrical signals that are then fed to the processor. Actuators take the resulting electrical signals from the processor and convert them into a physical output. Both sensors and actuators are important parts of embedded systems, due to which learners must understand associated concepts and terminologies.

      In this week, you will learn about

      • System Basics
      • Basic Concepts of Sensors and Actuators
      • Types, Functions, and Applications
      • Sensor Terminology
      • Technology of Sensors and Role of Sensors and Actuators in Automotive Systems
      • Automotive Instrumentation Cluster Basics
      • Actuators
    4. Embedded Systems DevelopmentW04

      Embedded systems are designed differently depending on their requirements and applications. It is important to understand the different embedded systems, and how they vary in applications.

      In this week, you will learn about

      • Embedded Systems Bare Metal Programming
      • Philosophy
      • General Real Time Operating System (RTOS) Concepts
      • Bare Metal vs. RTOS
      • Bare Metal/RTOS/OS: Comparison
      • Examples of Bare Metal, RTOS, OS Development
    5. Software Development Life CycleW05

      The software development life cycle (SDLC) elaborates on the process involved in designing and developing software. It defines each phase of the process, and how it optimizes the quality of software. Embedded systems also go through an SDLC to develop a high quality model. It is important to understand each phase of the SDLC and how each one relates to the development of embedded systems.

      In this week, you will learn about

      • Basics of SDLC
      • Phases of SDLC
      • SDLC Models
      • SDLC Frameworks
    6. Introduction to Safety StandardsW06

      The Motor Industry Software Reliability Association (MISRA) C coding guidelines offer a defined framework for developing and testing codes for automotive software. They focus on improving the safety and security of embedded systems. To think at an industry level, it is important to understand the safety standards and their implications in embedded systems.

      In this week, you will learn about

      • Different Safety Standards in Various Domains
      • Secure Programming in C
      • Less Secure Areas of C Program
      • Secure C Coding Standards MISRA C
    7. Get Started with Tinkercad, SimulIDE, MBED PlatformW07

      Arduino is used in the development of embedded systems. It has an AVR microcontroller that can be programmed to perform a specific application. Tinkercad is used in the designing, programming, and simulation of Arduino based systems. SimulIDE can also be used for the simulation of electronic circuits. It is important to understand these simulators and their use in embedded systems.

      In this week, you will learn about

      • What is Arduino?
      • Why Arduino?
      • Most Common Arduino Platforms
      • What is Tinkercad?
      • How to use Tinkercad & Simulate Circuits
      • Download and Install SimulIDE
      • Blink Program and Simulation in SimulIDE
      • Introduction to Mbed
      • CMSIS
      • ARM Microcontroller Introduction
    8. Arduino Digital Pins, GPIO Input/Output Modes, and Methods of Programming Digital GPIOW08

      Pins on an Arduino board can be configured according to user needs. Each pin can be configured as either an input or output pin. SimulIDE is used to execute Arduino codes. It is important to understand the input and output configurations of Arduino, as well as how SimulIDE can be used to simulate circuits.

      In this week, you will learn about

      • Demonstration of the Working of Dio Pins - Led Chaser
      • Voltmeter Project in Simul Ide
      • L298 Motor Driver in Simulide
      • Relay in Simulide
      • Digital Inputs
      • Digital Outputs
    9. Introduction to Analog Data, Analog to Digital Conversion, Digital to Analog Conversion, Analog Data, ADC, and DAC in MbedW09

      While analog data is continuous in nature, digital data is discrete in nature. There are analog to digital converters (ADC) that change analog data into digital data. Embedded systems need ADCs to acquire and process signals from the environment. It is important to understand the basics of analog and digital data, as well as ADCs.

      In this week, you will learn about

      • Analog Data
      • NTC circuit example
      • Analog to digital conversion
      • Digital to analog conversion
      • Working with analog pins and simulate a code
      • Simulate a code for Thermometer using TMP36 Sensor in Tinkercad Simulator
      • LDR in SIMULIDE
      • Voltmeter in SIMULIDE
      • Libraries in Mbed
      • Reading and logging data from analog inputs
      • DAC in Mbed
      • Analog Output in Mbed
    10. Timers in AVR based Microcontrollers, Concepts of PWM, and PWM in MbedW10

      Arduinos can be programmed to have timers that are used to measure and record events with time. It makes use of a counter that counts according to the clock frequency. It is important to understand how timers are configured in Arduino boards, and how they can be simulated using SimulIDE.

      In this week, you will learn about

      • Timers in Arduino UNO
      • Blink using timers
        • 500ms Blink Example code
      • Need of PWM
      • Fade
      • Simulation of Illustrating the analogWrite() function
      • H bridge
      • DC motor control
      • Servo motor mechanism
      • Servo mechanism- PWM pin in SIMULIDE
      • Timers in ARM based microcontrollers
    11. Interrupts, Demonstration, and AdvantagesW11

      Interrupts can be programmed into Arduinos to prioritize processes and execute them immediately. The microcontroller will then finish executing the block of code it is on, and immediately shift to the high priority code. It is important to understand how to program interrupts into Arduinos.

      In this week, you will learn about

      • About Interrupts
      • Demonstration of Interrupts using Push Buttons
      • Advantages of Interrupts with Example
      • Polling Method
        • Simulating a Code for Blinking the LED
      • Problems in Polling Method
      • Example of Interrupts in Mbed
    12. Serial Communication Protocols W12

      Serial communication transfers data as binary pulses. UART is a communication protocol which uses asynchronous serial communication. There is also a serial peripheral interface that is a synchronous protocol used to transfer data at higher speeds. It is important to understand the different communication protocols used in embedded systems.

      In this week, you will learn about

      • Introduction to Serial Communication
      • Types of serial communication
      • UART communication protocol
        • Simulate a code for communication between two Arduino using UART protocol
      • I2C communication Protocol
        • Simulate a code for communication between two Arduino using I2C protocol
      • SPI communication Protocol
        • Simulate a code for communication between two Arduino using SPI protocol
  3. 03AVR Bare Metal Programming- Live Sessions8 modules
    1. Arduino Vs Bare Metal Programming and Compiling Program with Custom Make FilesW01
      • Memory Blocks of Microcontroller
      • Measuring Memory Occupied by the Code using Arduino Library
      • Measuring Clock Cycles taken by the Instructions of Arduino Library
      • Internal I/O Circuit Diagram of Microcontroller
      • Accessing Registers using Specific Address
      • Comparison of Code Size and Clock Utilization of Arduino Library and Bare Metal Coding
      • Need for Writing a Custom Make File
    2. Pinout and Features of Atmega328 and AVR ArchitectureW02
      • Pin Out Details of Atmega328
      • Pin Description at a Glance
      • Features of Atmega38
      • AVR Architecture
    3. Setting up Microchip Studio for AVR using SimulIDE to Simulate the Target Environment and Input & Output Ports of Atmega328W03
      • Setting up Microchip Studio
      • Introduction to SimulIDE
      • Flashing the Code on the Virtual Atmega328 Microcontroller in SimulIDE
      • I/O Pin Block Diagram
      • I/O Ports and their Functions
      • Register Description of I/O ports
    4. Debugging the Code in Microchip Studio and Basics of Timers, Counters, and PWMW04
      • Starting a Debugging Session
      • Various Windows of Debugging
      • Adding Breakpoints
      • Timer Clock Sources
      • Counter Unit
      • Output Compare Unit
      • Compare Match Output
      • Modes of Operation
    5. LCD Interface and Basics of ADCW05
      • Deep Dive into 2*16 LCD Display
      • Common Commands for HD78044 LCD
      • Simulation of LCD Interfacing
      • Basics of ADC
      • Registers Associated with ADC of Atmega328
    6. Analog Comparator and InterruptW06
      • Introduction to Interrupt
      • Interrupt Service Routine(ISR)
      • Registers Associated with Interrupt
      • Code and Simulation of ISR
      • Introduction to Analog Comparator
    7. Communication Protocols and Non-Volatile MemoriesW07
      • Basics of UART, SPI, and I2C
      • Harvard and Von-Neumann Architecture
      • Program Memory Map
      • Write to and Read from the Flash Memory
      • Concepts of the Boot Loader
      • EEPROM
      • Program to Store Data into EEPROM
    8. Saving Power and Code ProtectionW08
      • Concept of Power Saving
      • Power Reduction Register
      • Different Sleep Modes of Atmega
      • Wake Up Sources
      • Watchdog Timer
  4. 04Software Verification and Validation and System Testing for Hand Code8 modules
    1. Introduction to Verification and Validation and System TestingW01
      • What is verification? (Real-world examples)
      • What is Validation and how it is different from verification? (Real-world examples)
      • Identifying Verification and Validation from the V- Cycle
      • Developer’s Mindset Vs Tester’s Mindset
      • Explaining various stages of validation (Unit Testing, Integration Testing, System Testing) with regards to verification phases in V-cycle
        • System Testing
        • Blackbox Testing
        • Functional Testing
        • Smoke Testing
      • Usage of V-model in present Agile world
      • SAFE (Scaled Agile Framework) concepts to illustrate ARTs
    2. Test Case Development from Requirements – IW02
      • Introduction to Test Coverage Levels (C0, C1, MCDC)
      • Introduction to Different Test Design Techniques
      • Choosing Test Design Techniques for Various System Requirements (Examples)
    3. Test Case Development from Requirements – IIW03
      • Test Cases Vs Test Specification
      • Writing a Test Plan
      • How to Write a Test Case for the Requirements?
      • Usage of Doors to Create Test Cases for the Requirements (Traceability)
      • Hands-on Examples (Using Excel) [CLIMA, BSW]
    4. Static Analysis and MISRA-C GuidelinesW04
      • What is MISRA-C?
        • How are we using it for Safety-critical SW?
      • Important Rules of MISRA-C
        • How to identify and fix them?
      • What is Static Analysis?
        • Where is Static Analysis in V-cycle?
      • Explaining Errors in Static Analysis (Case Studies)
      • Heuristics Vs Formal Methods
      • Hands-on Examples
    5. Unit Testing and Integration TestingW05
      • Unit Testing and Integration Testing
        • Why do we need it?
      • Why do we need SIL?
      • SIL Levels and Coverage Levels
      • Stub Functions
      • Hands-on Examples
    6. Automation and CI/CDW06
      • Overview of Test Automation
      • Introduction to Constructs of Infrastructure for CI/CD
      • Introduction to Git Hub
    7. Tool Introduction, Familiarization and Static AnalysisW07
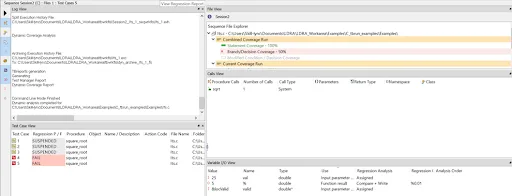
      • Overview of LDRA Toolsuite
      • Analysis Scope Definition
      • UI View and Usage
      • LDRA -Tbrun, Tbvision, and TBReports Overview
    8. Unit Testing and Integration TestingW08
      • Unit White Box Testing of Simple Project - (Array, Structure, Pointer, Linked lists)
        • Adding Test Cases, Executing Tests, and Understanding Test Report
        • Fixing Defects Detected from Tests
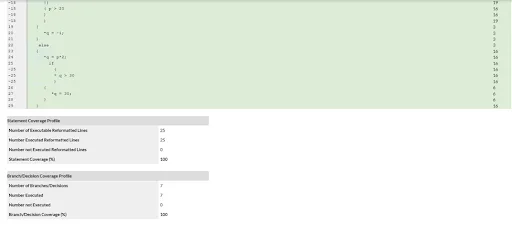
        • Analyzing Coverage and Adding Test Case to Increase Coverage
        • Generating Test Cases using Different Techniques
          • MC/DC, Equivalence Class, Boundary Check, etc., using MCDC Planner
        • Stubs
      • Unit Blackbox Testing of Simple Project
        • Adding Test Cases, Executing Tests, and Understanding Test Report
      • Integration Testing
        • Adding Test Cases, Executing Tests, and Understanding Test Report
        • Identifying and Fixing Defects Detected from Tests
  5. 05Device Drivers and Serial Communication Protocols7 modules
    1. Theoretical Introduction to ARM on-chip peripherals W01
    2. Bare metal programming with board bring up W02
    3. Driver development for GPIO, UART, SPI, I2C interfacesW03
    4. Hands-on Peripheral Interfacing using SPI/I2C Interfaces W04
    5. Theoretical Introduction on CAN, Ethernet, ARINCW05
    6. CAN Driver Development (Hands-on)W06
    7. CAN data analysis and visualization (Hands-on)W07
  6. 06Introduction to C++ Programming12 modules
    1. Introduction to C++W01
      • Introduction to C++
        • What is C++?
        • Program Paradigm
        • ANSI/ISO vs Standard C++
        • C++ Syntax and Structure
        • C++ Language Fundamentals
        • Benefits of C++ over C
      • C vs C++
        • Procedural vs OOP
        • Compiling a C Program in C++
        • Undefined Behavior in C and C++
        • Void * in C vs C++
        • Name Mangling
        • Use of Extern C in C++ Programming
        • Structures in C vs Class in C++
      • C++ vs Java
        • Similarities between C++ and Java
        • Exception Handling in C++ vs Java
        • Default Virtual Behavior in C++ vs Java
        • Floating Point Operations and Property of Associativity in C, C++, and Java
    2. Environment Setup & Fundamentals in C++W02
      • Environment Setup for CPP Programming
        • Compiler setup
        • Online compilers
        • Eclipse/ Visual Studio Setup
        • First Program
        • Understanding compilation- Build Pipeline
        • Preprocessing, Compiling, Assembling, and Linking
      • C++ Basics
      • Data Types and Modifiers
        • Built-in Datatypes
        • User-defined or Abstract Data Types
      • Variables in C++
        • Declaration and Scope of Variables
        • Global Variables
        • Local Variables
        • Static Variables
        • Extern Variables
        • Auto Variables
      • Operators in C++
        • Arithmetic Operators
        • Bitwise Operators
        • Relational Operators
        • Conditional Operators
        • Sizeof Operators
        • Assignment Operator
        • Unary Operator
        • Pre-Increment vs Post-increment Operators
      • Loop Types in C++
        • For
        • While
        • Do-while
      • Decision Making in C++
        • If
        • else-if
        • if-else-if
        • nested-if
        • switch
    3. Strings and ArraysW03
      • Strings in C++
      • Arrays in C++
      • Functions in C++
        • Call by Value
        • Call By Reference
        • Inline Functions
        • Function Pointers
        • Pointer to Function
    4. Pointers and ReferencesW04
      • Pointers in C++
      • References in C++
      • File Handling in C++
        • File Operations
      • File Handling through C++ Class
        • f-stream
        • if-stream
        • of-stream
    5. DMA and OOPS Part 1W05
      • Dynamic Memory Allocation
        • malloc()
        • calloc()
        • realloc()
        • free
        • new
        • delete
        • malloc vs new
        • free vs delete
      • Object-Oriented Programming
        • OOP’s Concepts - Briefing
      • Class
        • Default access specifier in a class
        • Access Modifiers
        • Constructor
        • Destructor
        • Assignment Operator
        • Copy Constructor
        • Default member functions in a class
      • Object
    6. OOPS Part 2W06
      • Encapsulation
      • Abstraction
      • Message Passing
      • Dynamic Binding
      • Data Hiding
      • Inheritance
        • Use of Inheritance
        • Modes of Inheritance
      • Types of Inheritance
        • Single Inheritance
        • Multiple Inheritance
        • Hierarchical Inheritance
        • Multiple Inheritance
        • Hybrid Inheritance
        • Multipath Inheritance
      • Diamond Problem
    7. OOPS Part 3W07
      • Polymorphism
      • Compile Time Polymorphism
        • Function Overloading
        • Operator Overloading
      • Runtime Polymorphism
        • Function Overriding
        • Virtual Keyword
        • VTable
        • Vptr- V Pointer
        • Virtual Functions
        • Abstract Class
        • Pure Virtual Function
        • Interface vs Abstract Class
    8. Constructors and DestructorsW08
      • Constructors and Destructors
        • Virtual constructor
        • Virtual Destructor
        • Virtual Copy Constructor
        • Shallow Copy vs Deep Copy
        • When does the compiler create default constructor and copy constructor?
        • When do you write your own Copy constructor and Assignment Operator?
        • Dangling Pointer
        • Void Pointer and Opaque Pointer
        • Null Pointer and Wild Pointer
        • Private Constructor
        • Private Destructor
        • Copy Elision
        • Explicit Keyword- Can constructors and Destructors be called explicitly?
    9. Keywords in C++W09
      • Static Keyword in C++
        • Static Variables in a Function
        • Static Variables in a Class
        • Static Members of Class- Static Class Objects
        • Static Member Functions in a Class
      • Const keyword in C++
      • Mutable Keyword in C++
      • Friend Function and Friend Class in C++
      • This Pointer in C++
        • ‘this’ pointer
        • Type of ‘this’ pointer
        • delete ‘this
    10. Type CastingW10
      • Type Casting in C++
        • Implicit cast
      • Explicit cast
        • dynamic_cast
        • static_cast
        • reinterpret_cast
        • const_cast
      • Member Initializer List in C++
        • Use of Initializer Lists
        • Cases where we use Member initializer lists
    11. Exception HandlingW11
      • Exception Handling in C++
        • Why do we need Exception Handling in C++
        • Base Class and Derived Class Exception Handling
        • Catch Block in C++
        • Object Destruction
        • Stack Unwinding in C++
      • Templates in C++
        • How do Templates work?
        • Function Templates
        • Class Templates
        • Template Specialization
    12. MultithreadingW12
      • Multithreading in C++
        • Posix threads
        • Std :: thread
      • Inter-Process Communication
        • What is IPC
        • Various methods in IPC
      • Smart pointers
        • Use of Smart Pointers
      • Types of Smart Pointers
        • Auto pointer
        • Unique pointer
        • Shared pointer
        • Weak pointer
  7. 07Introduction to Automotive Cybersecurity and Vehicle Networks12 modules
    1. Week - 01 Introduction to Automotive CybersecurityW01
      • In this session, we will:
        • Introduce students to automotive cybersecurity as a concept and teach them about its rise to prominence in the automotive industry.
        • A technical review of relevant case studies will give students an idea of what the process of hacking a car is like.
    2. Week - 02  Introduction to Different In-Vehicle Network Technologies, OBDII and EOBDW02
      • This lecture will cover the technical features of CAN, LIN, FlexRay, K-Line, Automotive Ethernet, and CAN FD.
      • Students will learn about different IVN types and where each is used, with emphasis on what applications each is suited for based on price, bandwidth, and other factors.
      • The different ports mandated to be on vehicles which grant access to some of these networks.
    3. Week - 03 Advanced CAN Bus Concepts, Physical Attributes of CAN BusW03
      • Since the CAN bus will be the main area of focus for the hands-on portions of this course, a deeper look will be taken at the CAN protocol.
      • Students will learn about the different parts of a CAN frame, how they are relevant from a security perspective, and more. They will learn about CAN arbitration and about error states in CAN.
      • Physical attributes of CAN buses such as wiring patterns, termination, and what they will look like on wiring diagrams/technical documents will also be covered.
    4. Week - 04 Building Your Digital WorkstationW04
      • This week’s content will assist the student in setting up their virtualization environment for the remainder of the course’s hands-on work.
      • We will walk the students through setting up a Linux Virtual Machine, installing the necessary programmes for the CAN bus content later on, and an introduction to some of the software that will be used in this course
    5. Week - 05 Building Your Virtual CAN BusW05
      • This course will take students through the process of setting up their own virtual CAN bus using the open source tools they set up the previous week
      • Students will learn how to use the tools at their disposal to read data from a CAN bus
      • Set up a CAN controller
      • Troubleshooting, and more
      • Parts of this week’s content will feature hardware that the students may not have access to, but it should still serve as useful knowledge
    6. Week - 06 Advanced applications for open source CAN toolsW06
      • This week, students will learn about the more advanced applications of CAN bus
      • This includes:
        • Filtering data from a network
        • Logging data
        • Replaying data
      • Writing basic programs to achieve certain functionality with their devices.
    7. Week - 07 Setting up Virtual Infotainment System SimulationW07
      • This week, students will be walked through the setting up of the Infotainment Cluster Simulator and shown some of its features
      • Students will be taught the importance of being able to reverse-engineer CAN bus messages in the absence of a DBC file
      • The format of a DBC file will be explored as well, showing students how CAN buses are structured in the industry
      • This will lay the foundation for CAN bus message reverse-engineering
    8. Week - 08 CAN Bus Hardware, CAN Bus SoftwareW08
      • This course will introduce students to some of the CAN bus products available on the market
      • We will look at some of the most commonly used hardware tools for interfacing with a CAN bus and some of the most common software tools that go with them
      • Expensive, industry-grade hardware and software will be reviewed, but cheaper hardware and open-source software will also be included
      • Differing strengths and weaknesses of each product will be discussed, and a few live demonstrations will be given for some of the programs
    9. Week - 09 Cyber Attacks on a CAN Bus, Security Measures for CAN BusW09
      • This week, some of the possible attacks against a vehicle’s CAN network will be explored
      • We will go over the details of the attacks, what makes them effective, and possible countermeasures to them
      • In tandem with this topic, we will discuss some possible security measures that can be applied to CAN bus including encryption, authentication, and transport-layer protocols
    10. Week - 10 Vehicle Networking Architecture, Where to Find in-Vehicle NetworksW10
      • This lecture will contextualise how different subsystems can be connected to one another throughout a vehicle
      • Students will learn how modern vehicle networks are organized and connected to one another and how information is shared
      • Part of this lecture will also discuss how to find different vehicle networks in vehicles, as not all networks are available from the easily accessible diagnostic ports
    11. Week - 11 Planning a Vehicular Penetration TestW11
      • This week, students will learn the process of carrying out a vehicle penetration test
      • This process includes:
        • The discussion phase with the customer
        • Identifying targets of engagement
        • Planning an attack on the target
      • The technical aspects of a penetration test including
        • Scanning
        • Enumeration
        • Exploitation
        • Post-exploitation
    12. Week - 12 International Automotive Cybersecurity Legislation, Advanced Applications for Logged CAN Bus DataW12
      • To conclude the course, a look will be taken at some of the international legislation surrounding automotive cybersecurity. Multinational standards such as the UN WP29 will be examined, but also country-specific legislation will be looked at.
      • The final session will show how more expensive, industry-grade hardware and software can be used to recreate a vehicle’s driving session, allowing for advanced incident reconstruction and digital forensics.
  8. 08Linux Driver Development12 modules
    1. IntroductionW01
      • Introduction to Linux
      • Getting the Kernel Source
      • Kernel Configuration
      • Kernel Building
      • Kernel Installation
      • Kernel Upgradation
    2. Linux Kernel ModuleW02
      • Application Vs Kernel Module
      • Hello World Module
      • Compilation - In-tree and out-tree
      • KConfig Framework
      • Loading and Unloading Module
      • Module Parameters
    3. Character Driver W03
      • Major and Minor Numbers
      • Data Structures
      • Char Driver Registration
      • File Operations - Open, Release, Read, and Write
      • Testing with User Space Application
    4. Debugging TechniquesW04
      • Debug by Printing
      • Debug by Querying
      • Debug by Watching
      • System Faults
    5. Concurrency and Race ConditionW05
      • Concurrency
      • Semaphores and Mutex
      • Completions
      • Spinlocks
      • Alternatives to Locking
    6. Advanced Character DriverW06
      • Ioctl
      • Blocking I/O
      • Poll
      • Asynchronous Notification
      • Seeking a Device
      • Access Control on Device File
    7. Timers and MemoriesW07
      • Jiffies
      • Software Timer
      • Workqueues
      • Tasklets
      • Memories
      • Kmalloc and kzalloc
      • devm_kzalloc
    8. BeagleBone BringupW08
      • Cross Compiler
      • Buildroot Setup
      • Uboot - Environmental Variables
      • Parameter Passing to Kernel
      • SD Card and Nand Flash Booting
    9. Platform Devices - I2C InterfacingW09
      • Platform Devices and Drivers
      • Device Tree
      • I2C Client Drivers
      • Misc Subsystem
      • Interfacing with MPU6050 Sensor
    10. Interrupt HandlerW10
      • Communicating with Hardware
        • Using I/O Ports
        • Using I/O Memory
      • Writing the BBB UART Driver
      • Interrupt Handlers
      • Top and Bottom Halves
      • Writing the BBB UART Interrupt Handler
    11. Sysfs and GPIO InterfacingW11
      • Device Model - Kobjects and Ksets
      • Sysfs - Creation and different attributes
      • GPIO Subsystem
        • Legacy Integer-based
        • Descriptor based on Device Tree
      • GPIO and Sysfs
      • Example Code – Led Interfacing to BBB
    12. BeagleBone Network ApplicationW12
      • Network Application
      • HTTP Server
      • Database - Mysql
Industry projects

59 projects
you'll ship.

Our projects are designed by experts in the industry to reflect industry standards. By working through our projects, Learners will gain a practical understanding of what they will take on at a larger-scale in the industry. In total, there are 59 Projects that are available in this program.

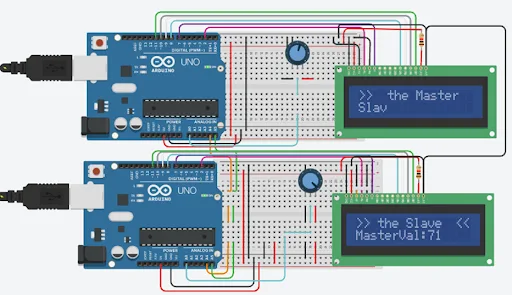
Interfacing a 16*2 LCD with 2 Arduino’s using (I2C) Communication Protocol
Fundamentals of Embedded Systems

Interfacing a 16*2 LCD with 2 Arduino’s using (I2C) Communication Protocol

In this project, learners will have to interface a 16*2 LCD display with two Arduino microcontroller boards. Learners will have to configure communication between the Arduino and 1…

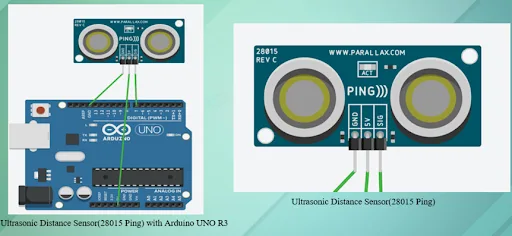
Measuring the Distance of an Object Using Ultrasonic Sensor
Fundamentals of Embedded Systems

Measuring the Distance of an Object Using Ultrasonic Sensor

Learners will have to measure the distance of an object using an ultrasonic sensor, and enhance the sensor data using the moving average filter. In addition to this, learners will …

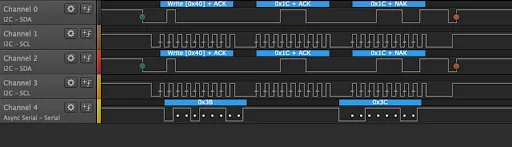
Write a Driver for I2C and Use the USB Logic Analyzer to Analyze the I2C Frames
Device Drivers and Serial Communication Protocols

Write a Driver for I2C and Use the USB Logic Analyzer to Analyze the I2C Frames

During this project work, the students will write a driver for I2C communication protocol. Also, they will use the USB logic analyzer to analyze the I2C frames.

Write a CAN Driver for STM32 Controller and Analyze the CAN Data Frames
Device Drivers and Serial Communication Protocols

Write a CAN Driver for STM32 Controller and Analyze the CAN Data Frames

During this project work, the students will write a CAN driver for the STM32 controller and they should analyze the CAN data frame in loopback mode. Also, they should connect two S…

Static Code Review Analysis
Software Verification and Validation and System Testing for Hand Code

Static Code Review Analysis

During this project work, the students will generate a code review that is compliant with the MISRA C 2012 coding guidelines. Also, the code review report should be complaint with …

Dynamic Analysis – White Box Testing
Software Verification and Validation and System Testing for Hand Code

Dynamic Analysis – White Box Testing

During this project, the students will perform Dynamic Analysis – White Box Testing based on the given input data. They will create manual and automatic testcases using TB Extreme …

User Interfaces for Working with “Sets”
Embedded Programming Essentials

User Interfaces for Working with “Sets”

In this project, you will have to use the C programming language to implement interfaces for mathematical set theory. This requires the development of two linked lists and the impl…

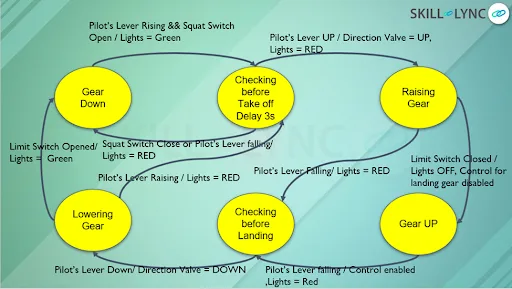
Finite State Machine for Aircraft Landing Gear System
Embedded Programming Essentials

Finite State Machine for Aircraft Landing Gear System

You will have to develop a code using C programming to control the retraction and extension of an airplane’s landing gear. The objective of this project is to implement logic…

Automobile Maintenance System
Embedded Programming Essentials

Automobile Maintenance System

Build an object-oriented library that can be used to track automobile maintenance. There will be a set of syntax given, which the students have to use in order to create the librar…

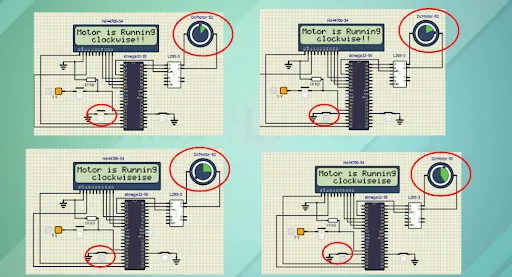
DC Motor Control Using L293 Driver
AVR Bare Metal Programming- Live Sessions

DC Motor Control Using L293 Driver

During this project work, the learners will implement a DC motor control using an L293 driver and print the running status of the motor on an LCD screen. Also, they will simulate t…

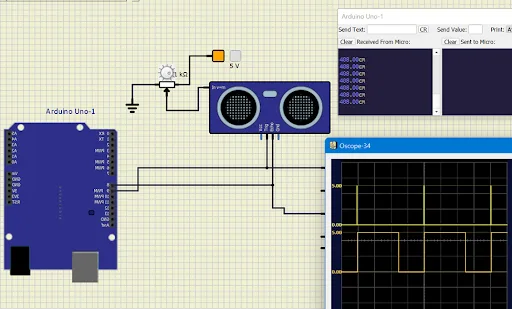
Interfacing HC-SR04 Ultrasonic Sensor with Atmega328p
AVR Bare Metal Programming- Live Sessions

Interfacing HC-SR04 Ultrasonic Sensor with Atmega328p

During this project work, the learners will interface the HC-SR04 ultrasonic sensor with an Atmega 328P. This hardware can be used for rear parking assistance. They will also simul…

IT Inventory Management
Introduction to C++ Programming

IT Inventory Management

During this project work, the students should find the best vendor from whom purchases can be made based on the number of commodities and reasonable prices to pay based on the prov…

+ 47 more projects in the full syllabus

Placements

546 learners placed
from this program.

Companies
186
Median CTC
3.5 LPA
20253.6 LPA
E Drift Electric
Power Electronics Engineer

Yogesh K.
20255.5 LPA
SANDHAR
Assistant Manager

Himanshu C.
20255.5 LPA
Hitachi
Embedded Engineer

Sanket A.
20249.5 LPA
Accenture
Sap Security Senior Analyst

Shivani T.
20243 LPA
Dhoot transmission
Jr Design Engineer

Aditya U.
20243.5 LPA
Tata Power EV Charging Solutions Ltd
EV Engoineer

Salil
Fee

One fee.
Everything included.

Become job ready with our comprehensive industry focused curriculum for freshers & early career professionals

Premium
₹2,75,000
Inclusive of all chargesEMI from ₹14,375/month
  • Career Service Assurance
  • Personalized Career Services Mentorship
  • 1 Year Access
  • Personalized Page
  • Live Individual & Group Sessions
  • Personalized & Hands-On
  • Job-Oriented Industry Relevant Curriculum
Check eligibility →
FAQ

Questions,
answered.

What is an electric vehicle?

An automobile that uses an electric motor rather than a conventional IC Engine is called an EV car or Electric Vehicle. The advantages of electric vehicles include zero tailpipe emission and reduced noise and vibration. 

Skill-Lync provides an electric vehicle certification course for you to upskill yourself and pursue a career in this domain.

What companies are there to hire after I have completed this course?

As one of the best electric car courses, it provides placement training and helps you to get placed. Our students are being hired by many electric car companies, including Tata Elxsi, Tata Technologies, and OLA Electric.

What software skills are taught in this course, and how well are these tools used in the industry?

The electric vehicle engineering course covers various programs, including MatLab, Simulink, Altium, and more. These are industry-standard tools used by electric vehicle design or manufacturing companies.

Will the candidates get merit certificates upon course completion?

While course completion certificates will be given to all students, merit certificates will only be given to the candidates who have successfully made it to the top 5% of the class as a token of appreciation for their hard work and passion.

What are some of the organizations that recruit candidates who have completed this course?

Among some of the organizations recruiting students upon completion of this PG program include Ford, Bajaj, Mahindra, Tata Motors, TVS, Maruti, Force, Renault, Valeo, Hella, Motherson, Greaves cotton, Uno Minda,  Yulu, Magneti Marelli, Magna, Denso, Continental, Delphi, and more.

What are some of the course deliverables?

This course's main deliverables include learning advanced engineering concepts from industry experts, building your professional portfolio, and interacting with a dedicated team of technical support engineers to clarify all your doubts.

How will this certification program assist in MS or PhD?

This electric car design course program is designed to be directly mapped to a typical PG course in automotive controls or electronics. This will be hugely beneficial to your path to MS or PhD and will put you way ahead of fellow students.

Next step

Not sure it's
the right fit?

A counsellor will walk you through the syllabus, projects and fee options — and tell you honestly if another course suits you better.

Get the syllabus + a call back

We'll email the full syllabus and call within one working day.

By submitting you agree to our Terms and Privacy Policy.

Call usEnquire

Talk to a career counsellor

Free 20-minute call. We'll map the right course to where you want to work.

By submitting you agree to our Terms and Privacy Policy.