Week-4 Challenge WOT Condition Part-2
AIM -
1. To differentiate between mapped and dynamic model of engine, motor and generator.
2. To determine how the model calculate miles per gallon.
3. To run the HEV Reference Application with WOT drive cycle.To Change the grade and wind velocity in the environment block,Also comment on the results.
4. To compare the simulated results of hybrid and pure electric powertrains , keeping all other parameters same.
THEORY -
What is Power Train Blockset ?
Powertrain Blockset provides fully assembled reference application models of automotive powertrains, including gasoline, diesel, hybrid, and electric systems. It includes a component library for simulating engine subsystems, transmission assemblies, traction motors, battery packs, and controller models. Powertrain Blockset also includes a dynamometer model for virtual testing. MDF file support provides a standards-based interface to calibration tools for data import.
Powertrain Blockset provides a standard model architecture that can be reused throughout the development process. We can use it for design tradeoff analysis and component sizing, control parameter optimization, and hardware-in-the-loop testing. We can customize models by parameterizing components in a reference application with our own data or by replacing a subsystem with our own model.
OBJECTIVE 1 - Difference between Mapped and Dynamic model of engine , motor and generator.
Mapped Model -
1. Mapped engines represent macro engine behavior as a set of lookup tables (brake torque, fuel flow, air mass flow, exhaust temperature, efficiency, and emissions) as functions of commanded load and measured engine speed.
2. Mapped engine models are suitable for analysis and design activities that do not require engine subsystem dynamic characteristics, for example, in engine and transmission powertrain matching analysis for fuel economy, emissions, and performance tradeoffs.
3. It is use when we have engine data from a dynamometer or a design tool like GT-POWER.
4 .It is also used for quasi steady-state engine simulations.
Dynamic Model -
1. Dynamic engines decompose engine behavior into individual component models that account for engine dynamics, most notably intake airflow and turbocharger dynamics.
2. Dynamic engine models are suitable for designing control, estimator, and diagnostic algorithms that depend on dynamic subsystem states, for example, in closed-loop AFR control algorithm development.
3. It is used when we need a more detailed dynamic model and have component-level data.
4. It also used when we have to analyze the impact of individual engine components on the overall performance.
Changing Model From Mapped To Dynamic -
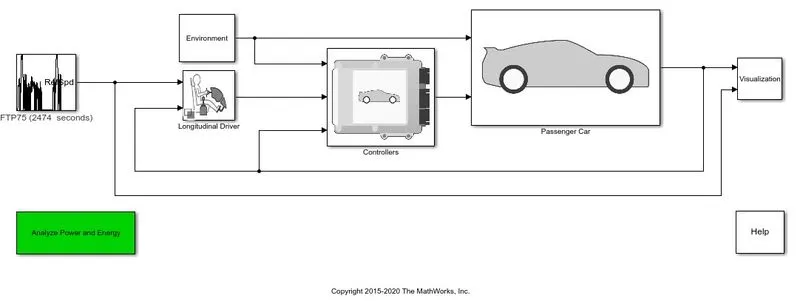
I have taken the Pure EV model -
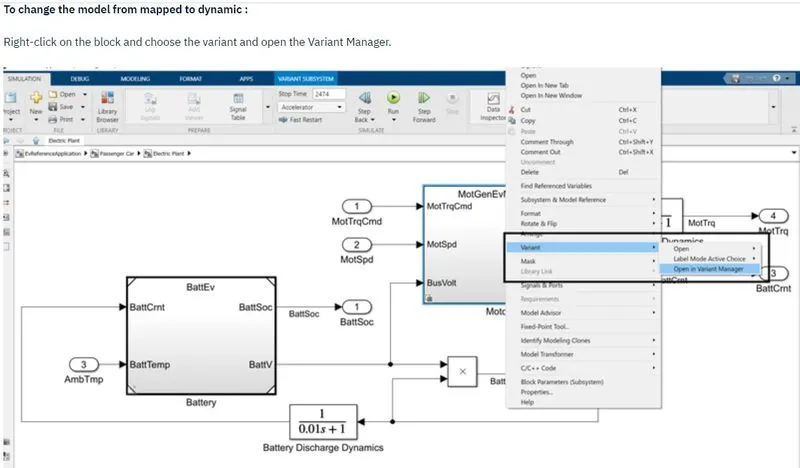
To change the Mapped Model to Dynamic Model -
- First click on the passenger car block .
- After clicking on blocks will open as shown in above figure .
- Select the motor block and Right click on it .
- Choose the variant .
- Open variant manager .
- Dynamic model option will select it .
- Model will changed to Dynamic from Mapped.
OBJECTIVE 2 - To determine how the model calculate miles per gallon.
- EV refrence vehicle model is open in Matlab .
- Performance calculation block is there which is shown below.
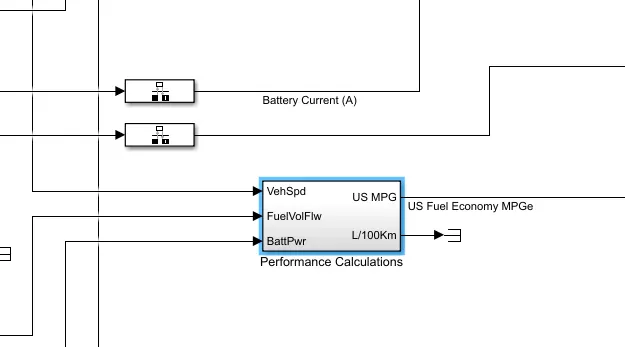
3. After clicking on the Performance calculation block , blockset will open which is shown below.
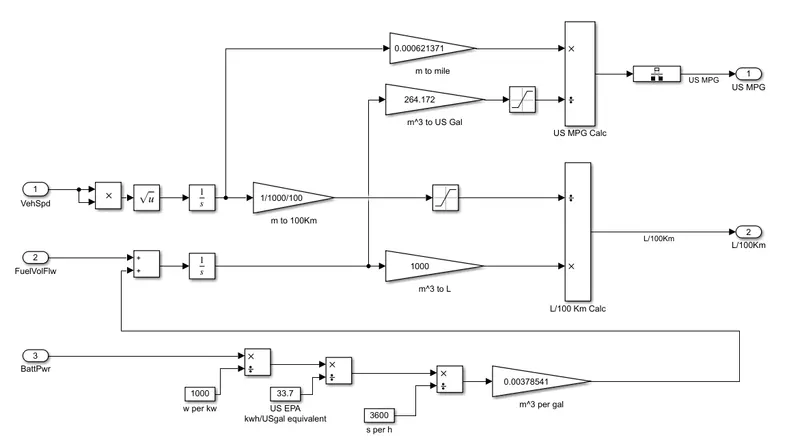
- First vehicle speed is multiplied and than square root is taken , after that the value is integrated and than it is converted into miles.
- Miles value is than divided by US galon to get US MPG.
- To convert Battery power output into US gal equivalent,this block first divided by 1000 and after that it is divided by 33.7 and finally it is divided by 3600 to get m^3 per gal as output.
- The above value is now feed as input Fuel volume flow and than integrated to get total volume.
- The value is now converted into gallons ,after dividing it is used as MPG.
Factors Considered To Model Fuel Flow Are -
- Vehicle Speed
- Fuel Volume Flow
- Battery Power
OBJECTIVE 3 - To run the HEV Reference Application with WOT drive cycle.To Change the grade and wind velocity in the environment block,Also comment on the results.
THEORY -
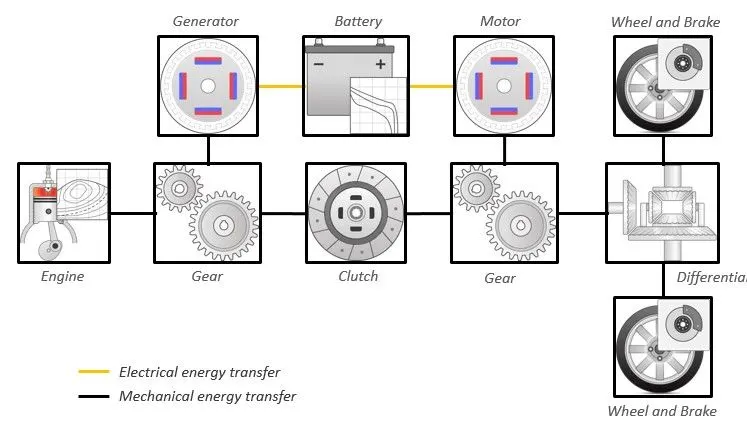
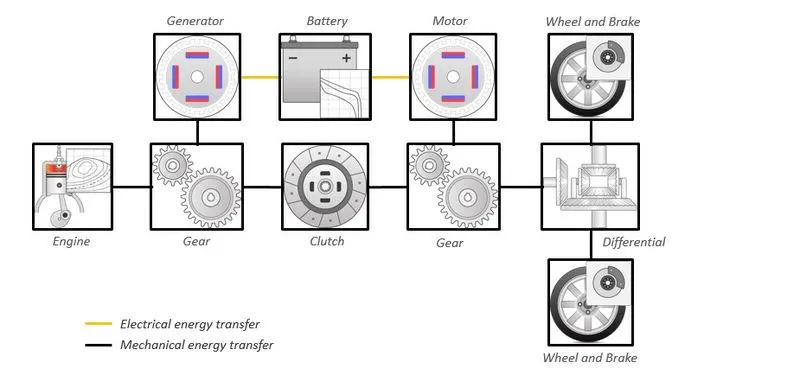
The hybrid electric vehicle reference application represents a full multimode hybrid electric vehicle (HEV) model with an internal combustion engine, transmission, battery, motor, generator, and associated powertrain control algorithms. Use the reference application for powertrain matching analysis and component selection, control and diagnostic algorithm design, and hardware-in-the-loop (HIL) testing.
By default, the HEV multimode reference application is configured with:
-
Mapped motor and generator
-
1.5–L spark-ignition (SI) dynamic engine
This diagram shows the powertrain configuration
Changing The Grade and Wind Velocity in teh environment Block -
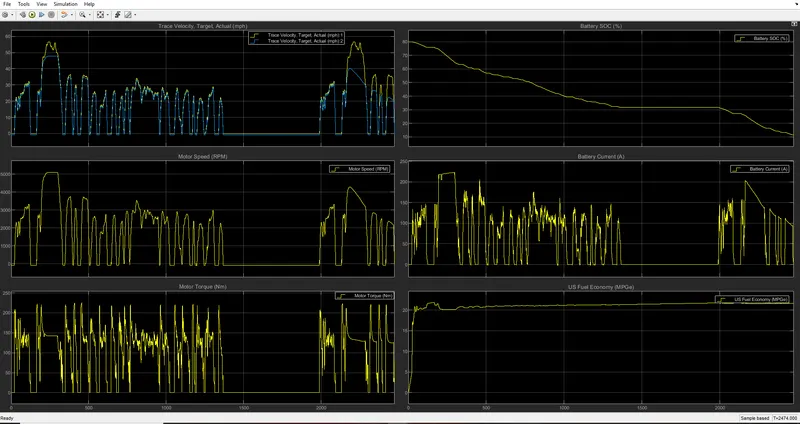
Grade Value is changed to 10 and wind velocity is changed to 20 by clicking in the Environment Block Parameter .
RESULTS OBTAINED -
Conclusion -
- Battery SOC Maximum value is 80% and its minimum value is aprrox 10% this means battery is drying when there is change in grade and velocity parameter.
- Maximum value of Battery Current is 230 A and its value decreases and goes to 0 A.
- US Fuel Economy MPGe is also increases and its maximum value goes to 23 MPGe .
OBJECTIVE 4- To compare the simulated results of hybrid and pure electric powertrains , keeping all other parameters same.
- Hybrid Electric Power Train
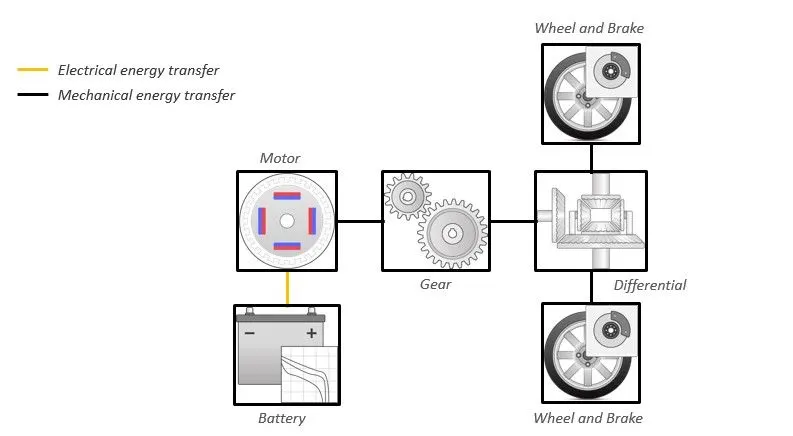
2. EV Power Train
COMPARING - Simulation Results Of HEV and EV-
PLOT 1 - HEV Power Train Output
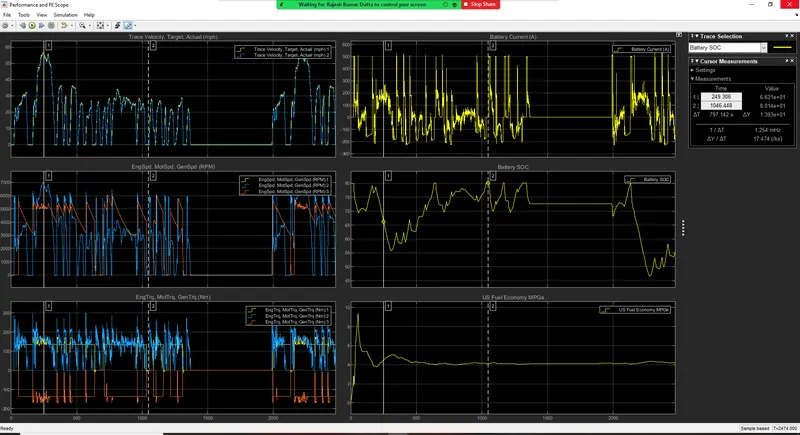
PLOT 2 - EV Power Train Output -
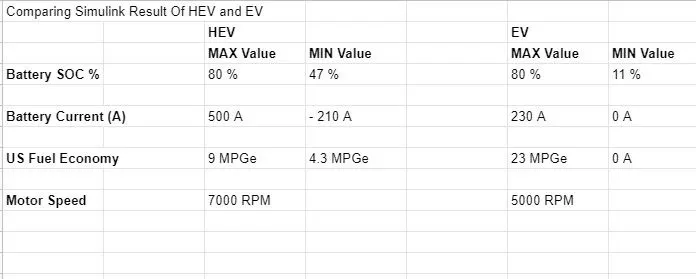
Comparing Simulink Result Of HEV and EV -
CONCLUSION -
- SOC is maximum for HEV as compared to EV.
- Due to charging and discharging Battery Current is changing in HEV.
- Fuel Economy is High for EV as compared to HEV.
- Motor Speed is maximum for HEV as compared to EV.