P1 Hybrid Vehicle
Title: Forward energy based Fuel Consumption Model for P1 Hybrid Vehicle
Objectives:
- Estimating the fuel consumption of P1 Hybrid Drive for different drive cycle.
- To compare the hybrid model with conventional model
1. Introduction
With global declination the fossil fuel and tight emission norms by the government of respective country has made an emergency to increase the fuel economy of the vehicles. In the view of above mentioned problem a technology called Hybrid Electric Vehicle (HEV) has immersed and is capable of addressing the above mentioned problem. The key in the technology is the use of another propulsion system which consists of battery and electric motor. Battery is used as energy storing device while motor is used as an electric torque actuator. This extra drivetrain allows the greater flexibility for engine operation as well as fulfilment of the power request delivered by the wheel.
When compared to conventional power train, HEV powertrain gives numerous advantages. The use of electric motor able the downsizing of the internal combustion engine with fulfilment of power request by the wheel. With electric motor hybrid power train enables us to captures the waste kinetic energy while braking to electric energy via. the features named as regenerative braking. Due to this sorts of features an optimal control strategies has to be developed for overall smooth performance of the vehicle[1]. Figure 1 shows different control strategies used in HEV vehicle. The input for the HEV control unit is shown below[2]:
- Battery SOC
- Vehicle Speed and Power demand
- Vehicle acceleration
- Present road load etc.
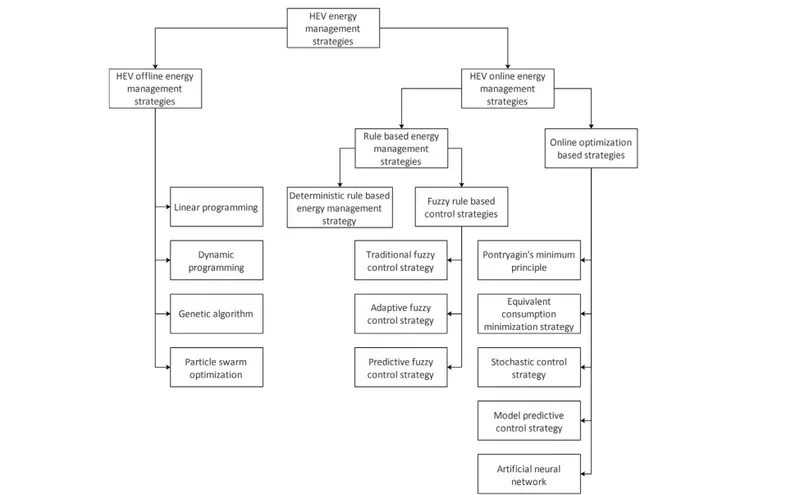
Figure1:Showing different control strategies for HEV[1].
Based on the above mentioned input the controller decides on which mode the vehicle needs to be in. The different modes in a HEV are as follow[1]:
- Engine alone mode
- Electric Motor alone
- Assist Mode (Both motor and engine operated)
- Trickle charging mode (Some power of the engine is used to charge battery)
- Regenerative Braking
In this project P1 hybrid vehicle is mode by considering forward energy based model. The control strategies used for this model is rule based control strategies. In P1 hybrid vehicle, battery and motor is integrated with the engine flywheel which enables the system for idle start stop and regenerative braking. In rule based control strategies the control rule are frequently based on heuristics, engineering intelligence, or mathematical models and are aimed at enabling the ICE to operate at high efficiency points, as well as enabling energy recuperation via regenerative braking [3–6]. The development of rule-based HEV control methods is generally articulated in two steps: the definition of the relevant rules for the powertrain control, and the calibration of the strategy, which is typically carried out by means of simulations on a vehicle model.
2. Model Development
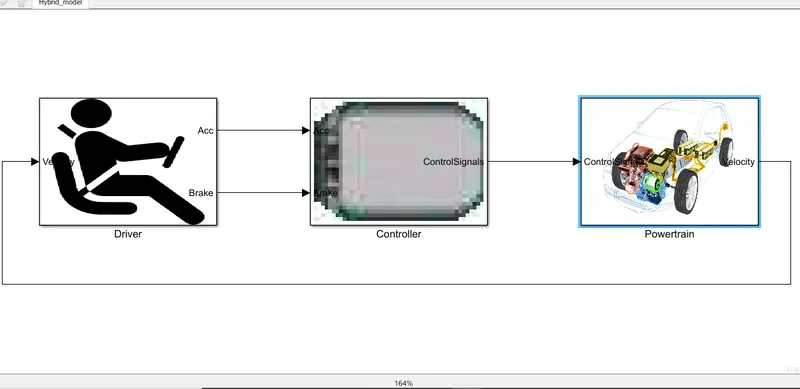
A forward based model has a driver model which provides torque demand for engine, motor and for braking for meeting the desired speed as per the drive cycle which is shown in figure 2.It uses a PI controller for providing the demand torue with reference to speed trace in the drive cycle. It also contains the powertrain model for vehicle dynamic and engine and controller model. From powertrain model velocity of vehicle is fed to the driver model and based on that speed and error , accleration and brake command are provided to other blocks.The models used in this project are as follow:
- Driver Model
- Controller Model
- Powertrain Model
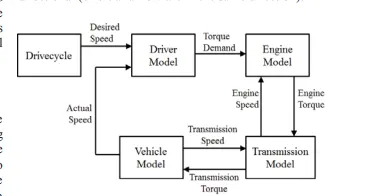
Figure 2: Forward based Model
2.1 Driver Model
The driver model is used to provide accleration and braking requirement based on the difference between actual speed of the vehicle and reference speed. The accleration and braking requirement is given by the PI controller for given error. For this model, the proportional gain of 50 and integrator gain of 5 is used as a PI controller constant. Some block is provided for automatically stopping the simulation when time at the drive cycle ends.Figure 3 shows the driver block which is used in this project.
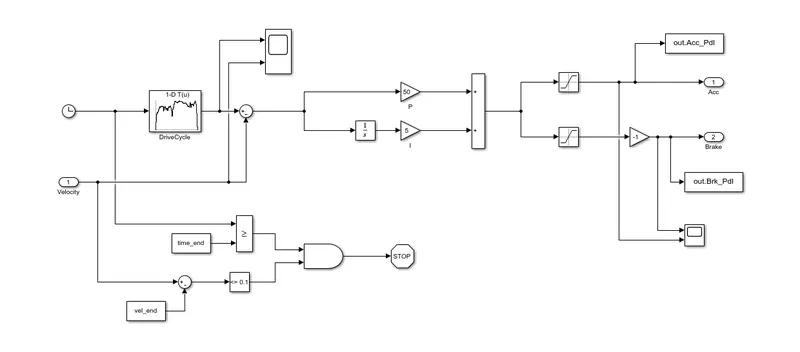
Figure 3: Driver Model Used for this project.
2.2 Controller
The control request from the driver block is fed into the controller block and based on this different control action is performed. The controller block consists of a master controller, Engine control unit, Brake control unit, Transmission Control unit and motor control unit. From the master control unit different signal is send to the other controller to perform action according to the modes. The figure 4 shows the controller unit for P1 hybrid model.
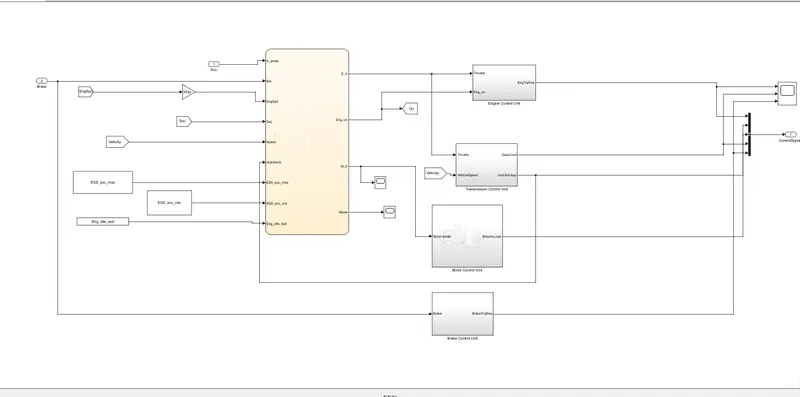
Figure 5: Controller for P1 hybrid model
2.2.1 Master Control Unit
Master control unit is the main control unit for hybrid vehicle.This control unit decides which operation/modes the vehicle should be in. For P1 hybrid two features have been intrgrated i.e. Start and stop and regenerative braking.The figure 6 shows the controller logic and based on the input like accleration, braking, Soc level, vehicle speed different modes is selected.
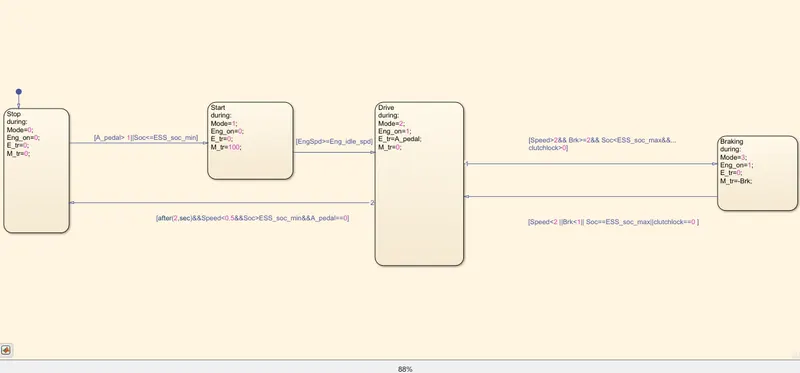
Figure 7: Master controller for the hybrid vehicle
2.2.2 Engine control Unit
Based on the engine throttle coming from the master controller, a torque request is supplied to the powertrain blockset. To integrated idle start stop feature, a variable called as engine on is used which value is 0 for engine off and 1 for engine on. The value of engine on is determined by the master controller based on the modes which the vehicle is in. This helps to save fuel when the vehicle is in idling. Figure 8 shows the engine control unit used for this project.
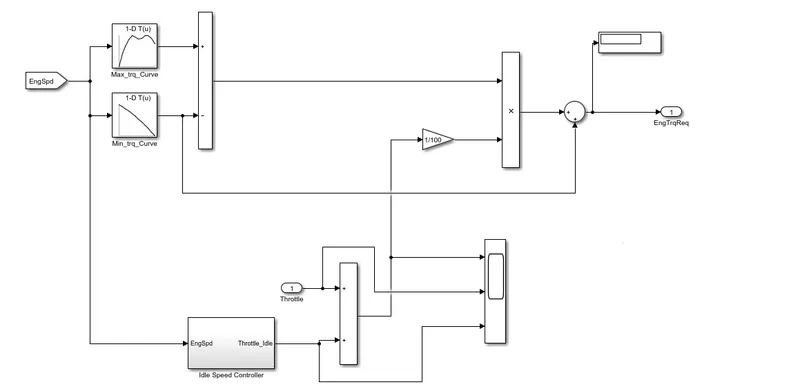
Figure8: Engine control unit block set
2.2.3 Transmission Control Unit
In transmission control unit, based on the throtle request from the master controller and vehicle speed a gear command and clutch lock up command is generated. This command is generated based on the control logic/transmission shift logic define by using the state flow. Figure 9 shows the transmission control unit and transmission shift logic.
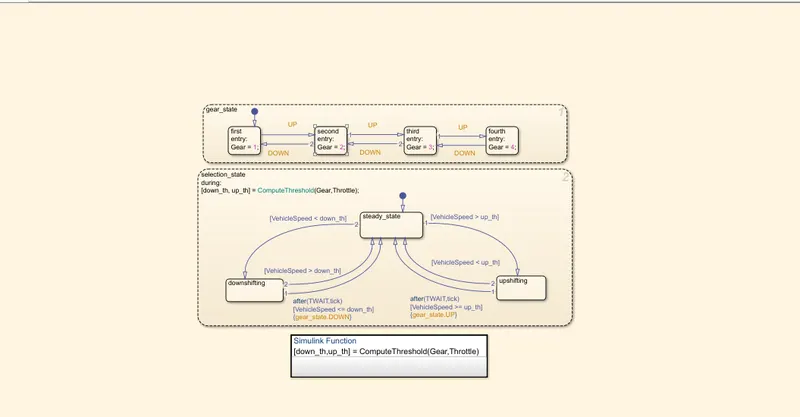
Figure 9: Transmission Control Unit and Shift logic
2.2.4 Motor Control Unit
In this unit, motor throttle request is fed in as a input and based on the speed of motor and throttle , either motoring torque or generating torque is selected from the look up table. This torque is multiplied to get the electric motor torques request. Since the engine is integrated with the electrical machine, the speed of engine is taken as an input speed for a motor. Figure 10 shows the Motor control unit
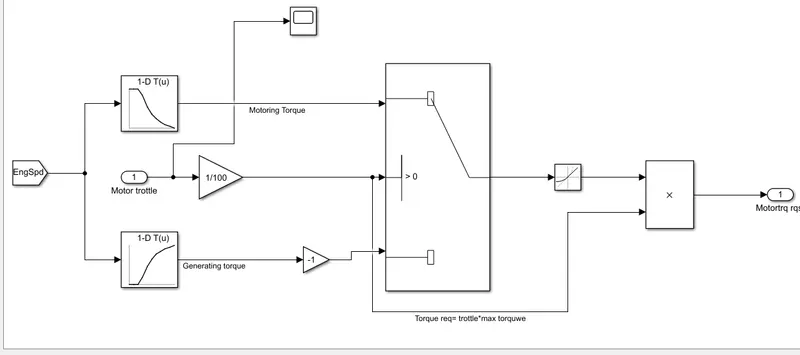
Figure 10:Motor Control Unit
2.2.5 Brake Control Unit
In this control unit , the braking request from the driver is fetch as an input and based on the braking action of the driver brake torque request is send to the driver.Figure 11 shows the barke control unit used in this project.
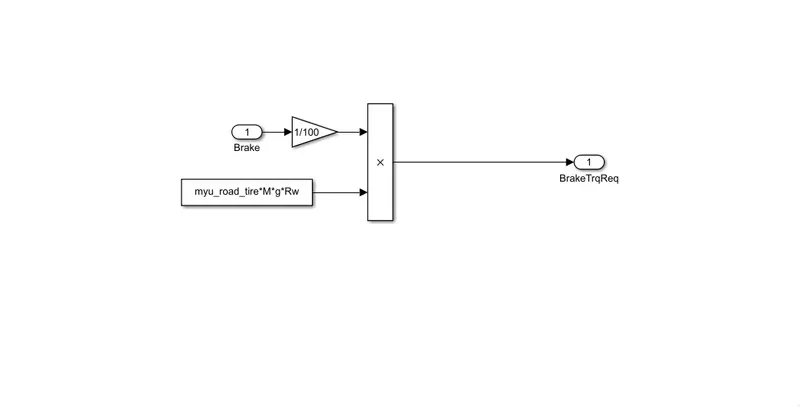
Figure 11: Barke Control Unit
All this control signal from the controller is fetch to the bus creator , which merges the signal and send it to the powertrain block.
2.3 Powertrain
In powertrain we consists for Engine block, transmission blocki, differential block, Motor, battery, Wheels and vehicle body.The control signal form the controller block is send to the powertrain block and based on which the velocity of the vehicle is determined.
2.3.1 Engine Block
In this block based on the engine speed and torque request from the controller , fuel consumption is taken out by ussing a looknup table,The torque from the engine is also calculated based on the torque request and engine speed and based on the torque engine speed is also calculated at the transmission block. Figure 12 shows the arrangement of simulink block in the engine subsystem.
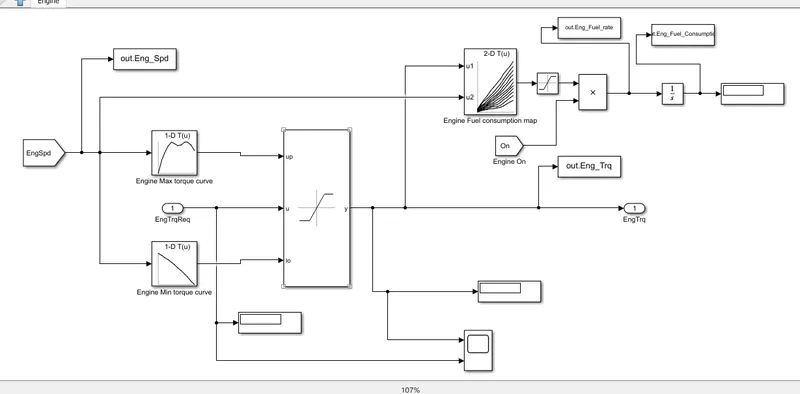
Figure 12:Simulink Block arrangement for Engine Subsystem.
2.3.2 Motor
In motor subsystem also, based on the the motor torque request from the controller and engine speed the torque and input power to the motor is calculated. The engine speed is considered because it is considered that engine and motor are running at the same speed in P1 hybrid Vehicle. Figure 13 shows the simulink block arrangement for the Motor subsystem.
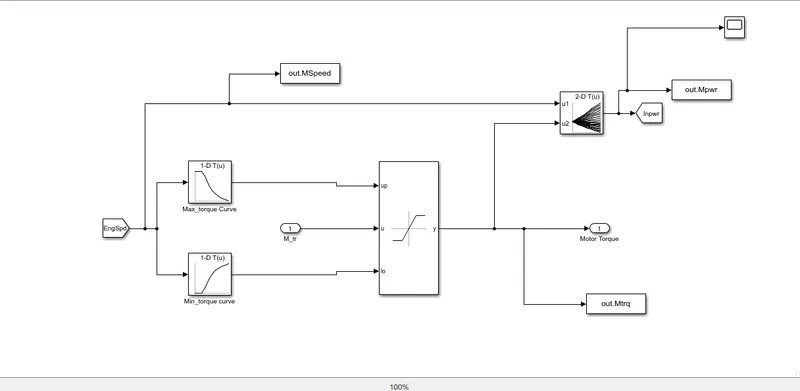
Figure 13: Simulink Block Arrangement for the Motor subsystem.
2.3.3 Battery
In battery subsystem,based on the input power demand from the motor, the current from the battery is considered. And based on the current drawn , SOC level of the battery is calculated by considered the technique called as columb counting. The Voltage of the battery being the function of the SOC level of the battery, so the open circuit voltage is calculated by SOC level of battery.Figure 14 shows the simulink block arrangement for the battery subsystem.
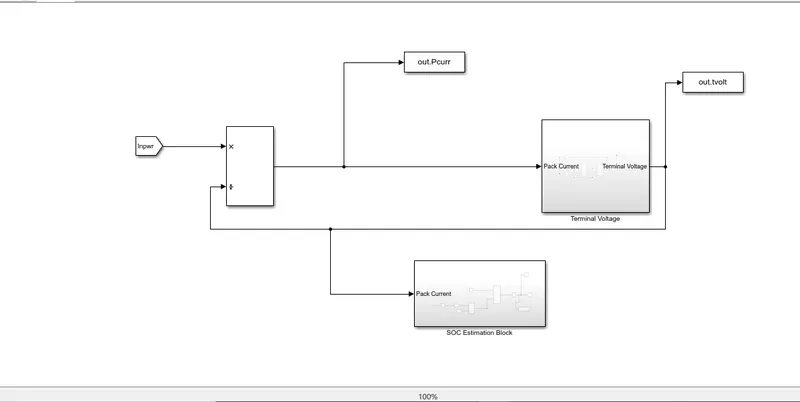
Figure 14: Simulink Block arrangement for the battery subsystem.
2.3.4 Crankcase
In this block,the torque from the engine and torque from the motor is added and combined torque is the result torque from the system.
2.3.5 Transmission
In the transmission subsystem,based on the input crank torque and Transmission In speed,the torque from the torque converter is calculated. Basedon the gear command from the controller, gear ratio is selected by considering the gear and gear ratio data from the lookup table. product of gear ratio and torque from the torque converter gives us the total output torque from the transmission. Based on the nature of torque its efficiency is assigned and output torque is calculated. Figure 15 shows the block arrangement for the transmission subsystem.
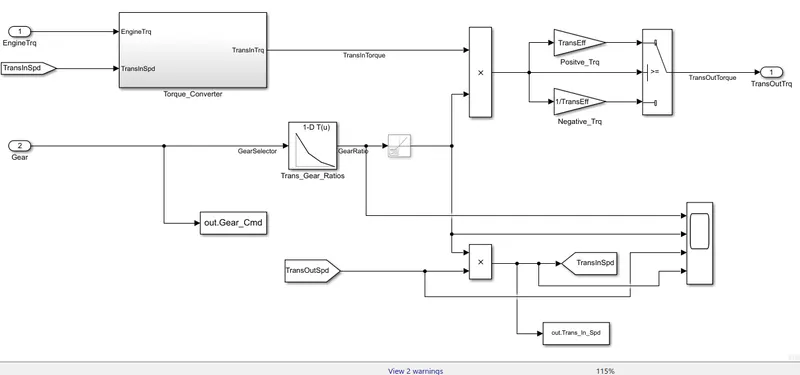
Figure 15: Simulink Block arrangement for the transmission subsystem.
2.3.6 Differential
In differential subsystem,transmission output torque is multipled with final drive ratio of the system and based on the nature of the torque, negative or positive axle torque is calculated.
2.3.7 Wheels
In wheel subsystem, the brake torque request from the brake contoller is fetch in. Based on the brake torque request and axle torque, traction force is calculated by considering the wheel speed. And the traction force is send to the vehicle body subsystem.
2.3.8 Vehicle Body
In vehicle body subsystem, all the resistive/ resistance force is calculated.The resistance force is subtracted from the total tractive force and result is divided by the mass of the vehicle to obtain the accleration of a vehicle. The integration of accleration is done to find out the velocity of the vehicle. This velocity is again reverted back to the driver block and based on which driver applies brake or accleration by comparing the velocity with the given drive cycle. Figure 16 shows the simulink block arrangement for the Vehicle body subsystem.Figure 17 shows the above mentioned subsystem arrangement for the powertrain block.
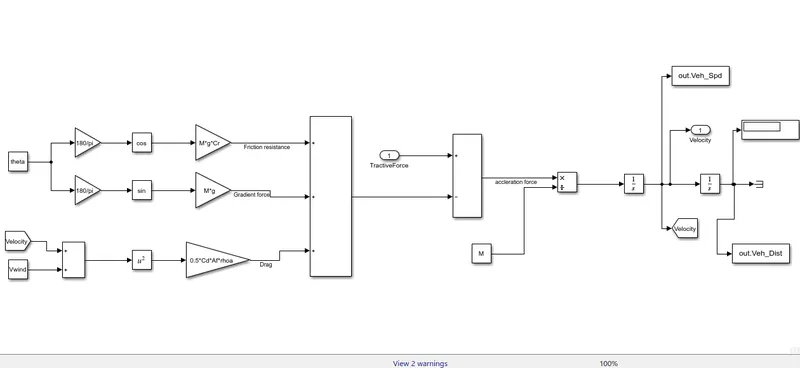
Figure 16: Simulink Block arrangement for vehicle body subsystem.
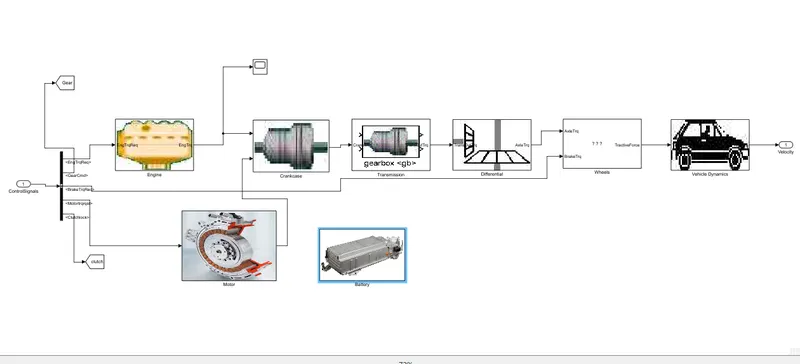
Figure 17: Subsystem arrangement for the powertrain block.
Logic or Formula Considered while Modelling the P1 Hybrid System
In Controller SubSystem
a) Logic for master Controller
Master controller is developed in such a way that,based on the input to it ,vehicle will go to certain mode define by the transition conditions. The Modes considered were Stop , Start, Drive and Braking and based on the modes different value for Engine on condition, Engine throttle ,Motor throttle was given. The transition from one mode to another is given below:
1) Stop To Start
A_pedal>0||Soc<=ESS_soc_min
2) Start To Drive
EngSpd>Eng_idle_spd
3) Drive To Braking
Speed>=2&& Brk>=2&& Soc<ESS_soc_max&&...
clutchlock>0
4) Drive To Stop
after(2,sec)&&Speed<0.5&&Soc>ESS_soc_min&&A_pedal==0
5)Braking To Drive
Speed<1 ||Brk<1|| Soc==ESS_soc_max||clutchlock==0
Table 1: Value for Different Variable For each Modes
| Modes | Eng_tr | M_tr | Mode | Eng_On |
| Stop | 0 | 0 | 0 | 0 |
| Start | 0 | 100 | 1 | 0 |
| Drive | A_pedal | 0 | 2 | 1 |
| Braking | 0 | -Brk | 3 | 1 |
b) Engine Controller
Based on the engine speed,From look up table a torque is determined. and that torque is multiplied by acceration request.
1) Engine torque=Function(Engine_Speed)
2)Engine torque request=Engine torque*Eng_tr*1/100.
c) Motor Control Unit
Since the engine and motor are considered to be coupled, Based on the engine speed we are determining the torque from the motor. Since the motor can be operated for motoring and generating condition. When the M_tr is positive than motoring torque is considerd and for negative case generating conditions is considered.
Motor torque=Function(Engine_Speed)
Motor torque request=M_tr*Motor torque *1/100
d) Brake Control unit
Brake Torque request= friction coefficient betn tire and road*Mass of vehicle*aclrn due to gravity*tire radius
In Powertrain
1) Engine
a) Engine Torque=Function(Engine Speed,Eng_troque request)
b)Engine_Fuel Consumption=Function(Engine Torque ,Engine Speed)
2)Motor
a) Motor Torque=Function(Engine_Speed,M_torque request)
b)Motor Input Power=Function(Engine Speed,Motor Torque)
Key Formulas
Speed Ratio, S.R =wt/wp
Torque Ratio,T.R=Tt/Tp
Capacity factor,K=wp/`sqrtT_(p)`
Road Friction ,Fr= CrMgcos`theta`
Gradient Force,Fg=Mgsin`theta`
Drag force,Fd =`1/2rhoA_fC_dv^2`
Total road load,Fl=Fr+Fg+Fd
Accleration ,a= (Total traction force-Total road load)/M
velocity,v=`int a dt`
where,M is the mass of the vehicle, g is the accleration due to gravity,`theta` is the inclination of road,Af is the frontal area of the vehicle,wt and wp is the speed of the turbine and pump respectively. Tt and Tp is the torque from turbine and pump respectively.`rho` is the density of air
Steps:
Initally the data for model is loaded by using the init file. Than the simulink model is run.After running the simulink Model,Post processing Script is run. To Know the result for another drive cycle,we have to change the value for drive cycle.
Initilization Matlab Script
%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%%
% Description:

%% Initialization File
% Initialization file for loading the variables for the Conventional vehicle simulation model

%% Vehicle Parameters
M = 1500;       % Vehicle weight [kg]
Cr = 0.015;     % Rolling resistance coefficient
Rw = 0.35;      % Rolling radius [m]
Cd = 0.33;      % Drag coefficient
Af = 2;         % Frontal area [m2]
rhoa = 1.225;   % Air density [kg/m3]
Vwind = 0;      % Wind velocity [kmph]
g = 9.81;       % Gravitational acceleration [m/s2]
theta = 0;      % Slope [deg]
myu_road_tire = 1; % Coefficient of friction between tire - road interface

%% Powertrain Parameters
FDR = 3.73;                         % Final Drive Ratio / Diff Ratio
DiffEff = 0.99;                     % Differential efficiency (assumed independent of operating conditions)

NumGear = 4;                        % Number of gears in transmission
TransGear = [1:NumGear];            % Transmission Gears
TransRatio = [3.06, 1.62, 1, 0.7];  % Corresponding Transmission ratios
TransEff = 0.90;                    % Transmission efficiency (assumed independent of operating conditions)

TC_SR = [0, .5, .6, .7, .8, .87, .92, .94, .96, .97, 1];   % Torque Converter Speed Ratio (Matlab default) -> TurbSpd/PumpSpd
TC_TR = [2.232, 1.5462, 1.4058, 1.2746, 1.1528, 1.0732, 1.0192, 1, 1, 1, 1];   % Torque Converter Torque Ratio (Matlab default) -> TurbTrq/PumpTrq
TC_Cf = 1e-4 * [.72558, .66322, .63463, .59042, .51331, .4144, .29287, .22444, .12186, .04386, 0]; % Torque Converter Capacity Factor (Matlab default) -> PumpTrq/PumpSpd^2 [Nm/rpm^2]

load Vehicle_Data/Engine_data_1_9L_Saturn_95kW
load Vehicle_Data/Trans_Shift_map
load Vehicle_Data/EM_Honda_Insight_10kW
load Vehicle_Data/ESS_NiMH6


ESS_init_soc = 0.8;
ESS_soc_max = 0.9;
ESS_soc_min = 0.6;


%% Driver Parameters
Kp = 10;                    % P gain for driver PI model
Ki = 1;                     % I gain for driver PI model
Drive_Cycle_Select =6;     % Drive cycle selection

% Drive cycle values in m/s

if Drive_Cycle_Select == 2
    load DriveCycles/UDDS;

elseif Drive_Cycle_Select == 2
    load DriveCycles/HWFET;

elseif Drive_Cycle_Select == 3
    load DriveCycles/FTP;

elseif Drive_Cycle_Select == 4
    load DriveCycles/US06;

elseif Drive_Cycle_Select == 5
    load DriveCycles/NEDC;

elseif Drive_Cycle_Select == 6
    load DriveCycles/WLTP;

end

time_end = cyc_time(end);
vel_end = cyc_vel(end);
Simulink Model:
Post Processing Script:
%%Extracting data from simulink simulation

Time=out.tout;  %Extracting time
A_pedal=out.Acc_Pdl;  %Acclerator pedal position
B_pedal=out.Brk_Pdl; %Brake pedal position
Ef=out.Eng_Fuel_Consumption; %Fuel consumption data
Es=out.Eng_Spd;  %Engine Speed data
Et=out.Eng_Trq; %Engine Torque data
Gc=out.Gear_Cmd; %Gear command data
Tin=out.Trans_In_Spd*30/pi; %Transmission In speed
Tout=out.Trans_Out_Spd*30/pi; %Transmission Out speed
Dis=out.Veh_Dist; %distance travel during drive
V=out.Veh_Spd; %Vehicle speed
M_tr=out.Mtrq; %Motor torque
M_spd=out.MSpeed;%Motor Speed
Mp=out.Mpwr;%Motor power
Volt=out.tvolt;%Terminal Voltage
Soc=out.Tsoc; %SOC
C=out.Pcurr; %Pack Current
Fu=out.Eng_Fuel_rate; %Fuel supply to the engine
Ws=out.wspeed; %Vehicle wheel Speed
Ws=Ws.Data(:,1);
Ws=Ws*30/pi;
%%Since some of the above mention varible are in double time series so only
%%extracing data which are only required

Es=Es.Data(:,1)*30/pi;  %Extracting data and changing it to rpm
Et=Et.Data(:,1); %Torque in Nm
Dis=Dis.Data(:,1)/1000;  % changing distance to Km
V=V.Data(:,1); %chaning m/s to km/hr
Ef=Ef.Data(:,1);
M_tr=M_tr.Data(:,1); %Motor Torque
M_spd=M_spd.Data(:,1); %Motor Speed
Mp=(Mp.Data(:,1)/1000); %Motor power in KW
Volt=Volt.Data(:,1); %Pack Terminal Voltage
Soc=Soc.Data(:,1); %Soc of a battery pack
C=C.Data(:,1);%Pack Current
Fu=Fu.Data(:,1);

%%Calculating kmpl for the drive cycle
Pw=(Et.*Es*pi/30)/1000;  %Power in KW
rho_p=0.7197; %density of petrol
T_dis=Dis(end); %Total distance in Km
T_fuel=Ef(end); %Total Fuel consumed
Vol=(T_fuel/1000)/rho_p;  %Total litre of fuel
Milage=T_dis/Vol;


%%Plotting Engine, Transmission and Wheel Speed with respect to time
figure(1)
subplot(3,1,1)
title('Speed of Different component with respect ot Time');
hold
plot(Time,Es); %Plotting Engine speed with respect to time
xlabel('Time in Seconds');
ylabel('Engine Speed in RPM');

subplot(3,1,2)
plot(Time,Tin,'Displayname','Transmission Input Speed');
hold
plot(Time,Tout,'Displayname','Transmissin Output Speed');
xlabel('Time in Seconds');
ylabel('Transmission Speed in RPM');
legend

subplot(3,1,3)
plot(Time,Ws);
xlabel('Time in Seconds');
ylabel('Wheel Speed in RPM');
hold off
%
% %Plotting Engine Torque, Power, Fuel rate and Fuel consumption
figure(2)
title('Engine Behavior with respect to Time');
hold
subplot(2,2,1)
plot(Time,Et);
xlabel('Time in second');
ylabel('Engine Torque N-m');

subplot(2,2,2)
plot(Time,Pw);
xlabel('Time in second');
ylabel('Power in KW')

subplot(2,2,3)
plot(Time,Fu);
xlabel('Time in second');
ylabel('Fuel consumption in gm/s');

subplot(2,2,4)
plot(Time,Ef);
xlabel('Time in Second');
ylabel('Total fuel(gm) consumed in t second');
hold off

%Plotting accleration, brake,gear command, real vs desired speed and
%distance with respect to time

figure(3)
subplot(2,2,1)
plot(Time,A_pedal,'Displayname','Acclrn press');
hold
plot(Time,B_pedal,'Displayname','Brake Press');
xlabel('Time in second');
ylabel('Percentage %');
legend

subplot(2,2,2)
plot(Time,Gc);
xlabel('Time in second');
ylabel('Gear number');

subplot(2,2,3)
plot(Time,Dis);
xlabel('Time in second');
ylabel('Distance in Km');

subplot(2,2,4)
plot(cyc_time,cyc_vel,'Displayname','Desired Speed');
hold on
plot(Time,V,'Displayname','Actual Speed');
xlabel('Time in Second');
ylabel('Velocity in m/s');
legend
hold off

%% Plotting engine operating points on engine fuel map
figure(4);
hold on
title('Engine Operating Points','fontsize',12);
p1=plot(Eng_map_spd*30/pi,Eng_max_trq,'linewidth',2,'color','r');
p2=line([Eng_map_spd(end)*30/pi Eng_map_spd(end)*30/pi],[0 Eng_max_trq(end)]);
set(p2,'linewidth',1,'linestyle','--','color','k');
p3=line([Eng_map_spd(1)*30/pi Eng_map_spd(1)*30/pi],[0 Eng_max_trq(1)]);
set(p3,'linewidth',1,'linestyle','--','color','k');
[c,h] = contour(Eng_map_spd'*30/pi,Eng_map_trq,Eng_fuel_map','ShowText','on');
contour(Eng_map_spd'*30/pi,Eng_map_trq,Eng_eff_map','ShowText','on')
clabel(c,h);
xlabel('Engine Speed [rpm]');
ylabel('Engine Torque [Nm]');

% figure(5)
title('Engine Fuel Consumption Map [g/s]');
p4 = plot(Es,Et,'.','color','k');
legend([p1 p4],{'Max Curve','Operating Points'});
axis([Eng_map_spd(1)*30/pi Eng_map_spd(end)*30/pi 0 Eng_map_trq(end)]);
hold off

% %  Plotting for motor characteristics
figure(5)
subplot(2,2,1)
hold on
title('Speed of Motor in rpm')
plot(Time,M_spd*30/pi);
subplot(2,2,2)
hold on
title('Torque of Motor in Nm');
plot(Time,M_tr);
subplot(2,2,3)
hold on
title('Power of a Motor in KW')
plot(Time,Mp)
hold off

%%Operating point for motor
figure(6)
hold on
title('Operating region for a motor')
plot(EM_map_spd*30/pi,EM_max_trq,'linewidth',2,'color','b','Displayname','Maximum Torque');
plot(EM_map_spd*30/pi,EM_max_gen_trq,'linewidth',2,'color','r','Displayname','Maximum Generating Torque')
plot(M_spd*30/pi,M_tr,'.','color','k','Displayname','Operating Point');
contour(EM_map_spd'*30/pi,EM_map_trq,EM_eff_map','ShowText','on','Displayname','Efficiency');
legend
hold off

%%Ploting for Battery
figure(7)
subplot(2,2,1)
hold on
title('Voltage for Battery')
plot(Time,Volt);
subplot(2,2,2)
hold on
title('SOC Level of Battery')
plot(Time,Soc)
subplot(2,2,3)
title('Current from the battery')
hold on
plot(Time,C)
hold off


%plotting drive cycle
figure(8)
plot(cyc_time,cyc_vel);
xlabel('Time in Second');
ylabel('Velocity in m/s');
Based on the need of the cycle the cycle is selected from the initialization script. For UDDS cycle , we have selected the Drive cycle as 1 and for HWFET we have to select it as 2.
3. Result
The model had been run for the different cycle and different parameters were analysised and compared with the conventional vehicle model.
3.1 Comparision for Different Drive Cycle
Two drive cycle UDDS and HWFET were considered and different system level parameters were analysised.
3.1.1 Comparision for Speed for engine,wheel and Transmission for both Drive cycle.
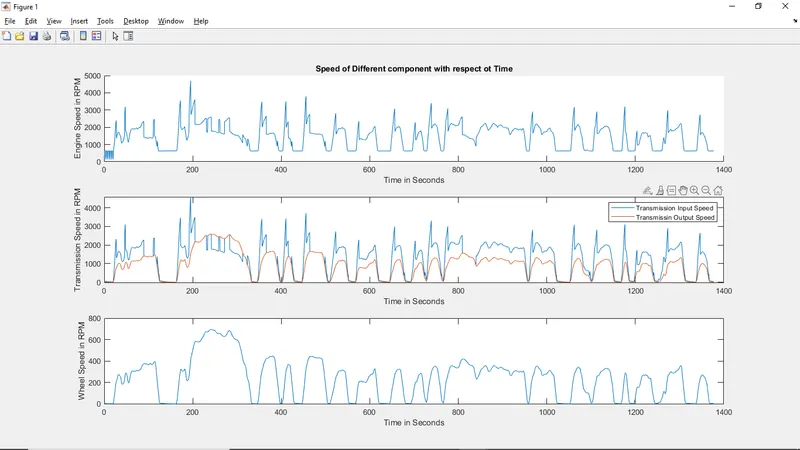
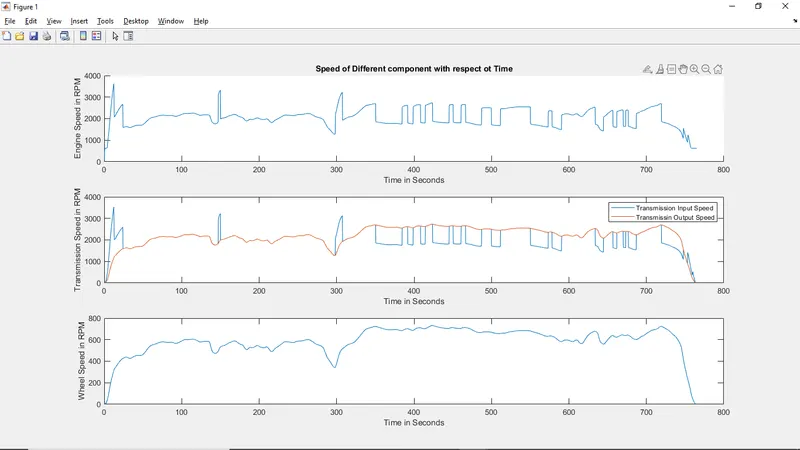
Figure 18 shows the speed of the engine wheel and transmission system for UDDS cycle while the figure 18 b shows the same for the HWFET cycle. In the UDDS cycle we can observe the average speed of the wheel transmission and engine is higher in case of the HWFET cycle as the vehicle has to propel with higher velocity as compared with UDDS cycle. It was also observed that in UDDS cycle ,there is frequent rise and fall in the speed of the wheel, engine and transmission than HWFET cycle. This is due to the frequent stop start condition in urban driving condition.
a b
Figure 18: a) Speed of the different component for UDDS cycle b) Speed of the different component for HWFET cycle.
3.1.2 Engine Analysis for HWFET cycle and UDDS cycle.
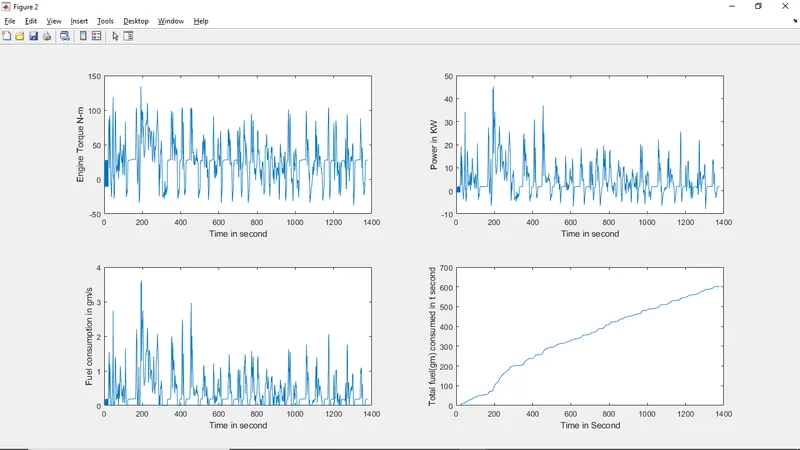
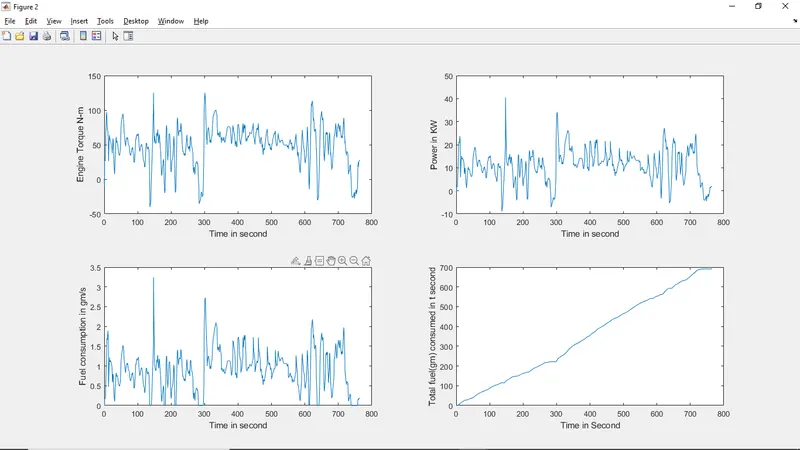
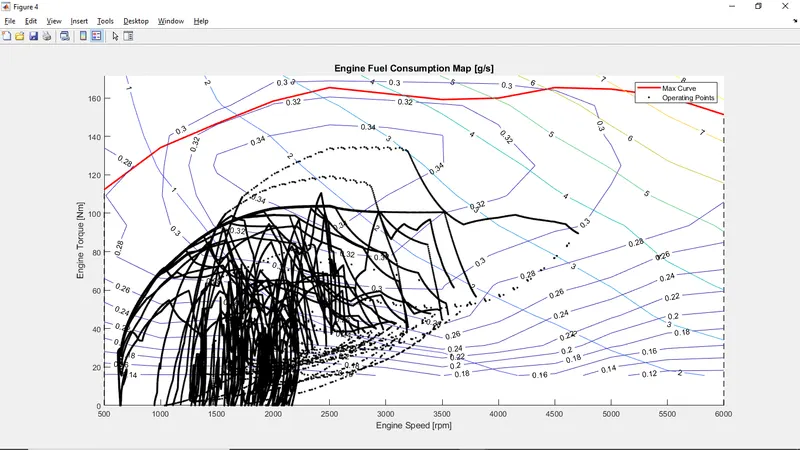
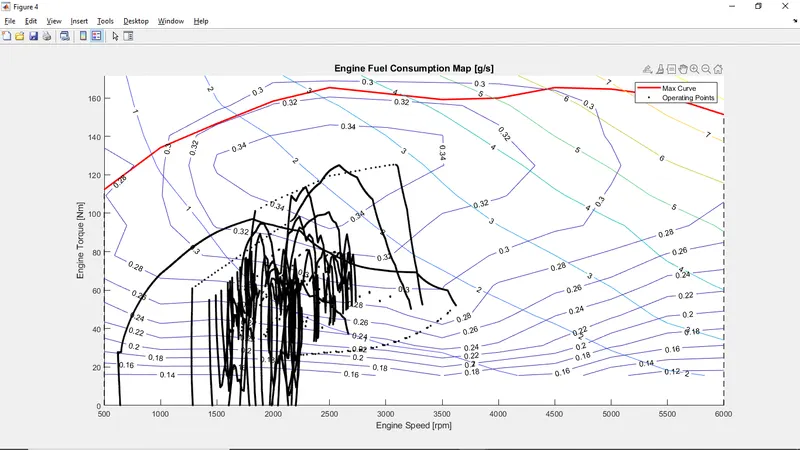
In UDDS cycle, we can observen that,there is frequent rise and fall in engine power and torque while for HWFET cycle, the fall and rise is compartively smaller than the UDDS cycle as shown in the figure 19 a and 19b. This enables the HWFET cycle to work in the more efficient region as shown in figure 19c and 19d as compared with UDDS cycle which lower the fuel consumption rate. The highest fuel consumption rate for UDDS cycle is around 4 gm/sec, while for HWFET cycle it is around 3.2 gm/sec.In HWFET cycle the works more in a higher efficient region when compared with the UDDS cycle. In HWFET cycle we can observe the minimum amount of negative torque from the engine when compared with UDDS cycle, as in highway vehicle neednot have to deal with frequent start stop condition. At the end of the drive cycle,the overall consumption of the was around 700 gm for HWFET cycle and around 600 gm for UDDS cycle.
a b
c d
Figure 19: a)Engine Performance for UDDS cycle b)Engine performance for HWFET cycle c) Engine fuel consumption map and operating point for UDDS cycle d) Engine fuel consumption map and operating point for HWFET cycle
3.1.3 Acclerator, Barke pedal position and Gear Selected for different drive cycle
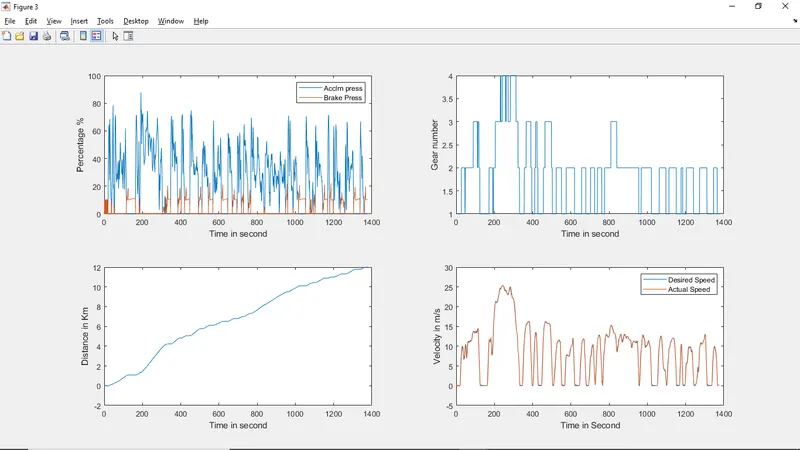
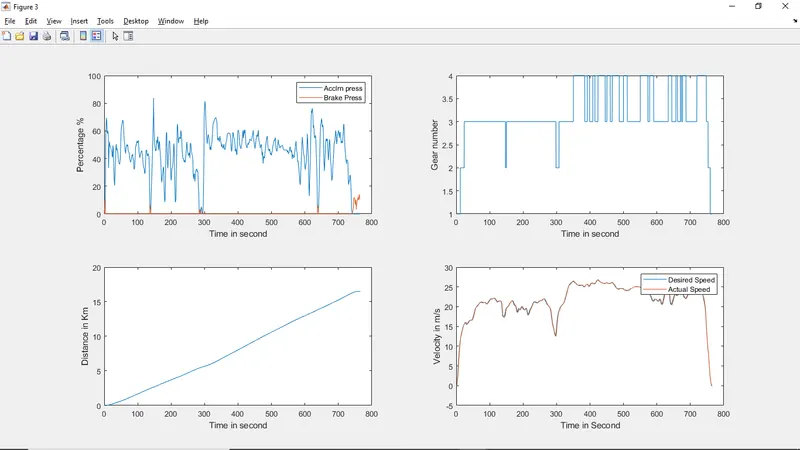
Figure 20a shows the brake pedal and acclerator pedal position for UDDS cycle.We can observe that when the vehicle is following the UDDS cycle the use of the brake pedal is quite often and the intensity for the pedal is pressed is also high as compared with the HWFET cycle in figure 20b. The vehicle is often in a higher gear for the HWFET cycle as compared with the UDDS cycle. The vehicle has cover the distance of around 12 km for the UDDS cycle and around 17km for HWFET cycle.
a b
Figure 20 a)Acclerator , Brake pedal position and Gear selected for UDDS cycle b) Acclerator brake pedal position and gear selected for HWFET cycle.
3.1.4 Analysis of an Electric Powertrain
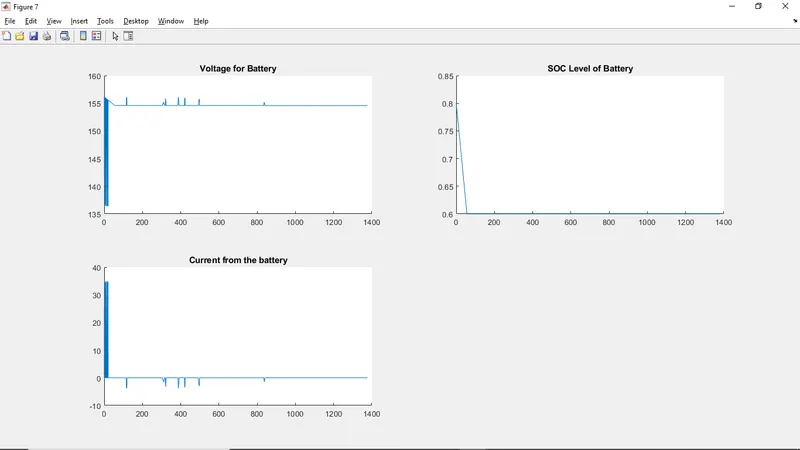
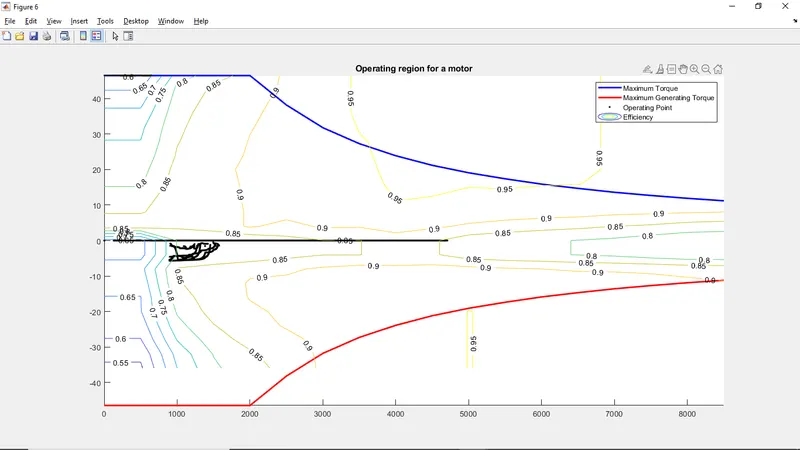
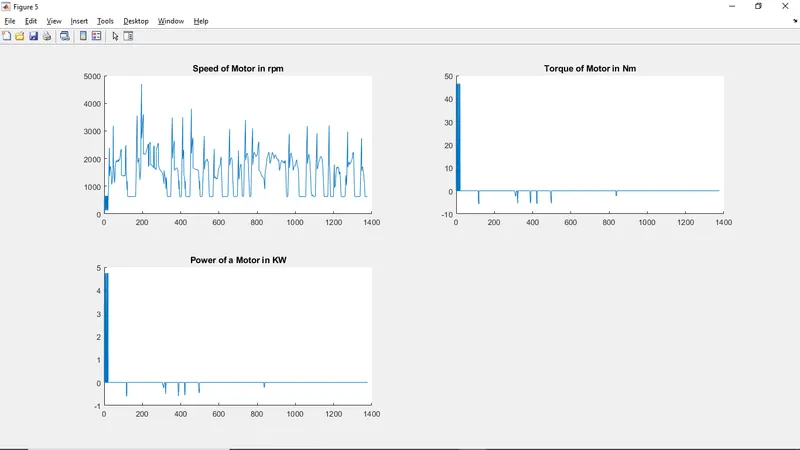
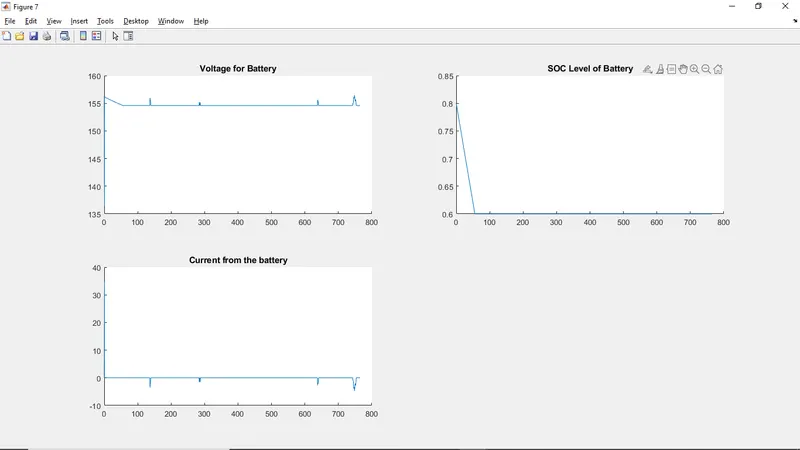
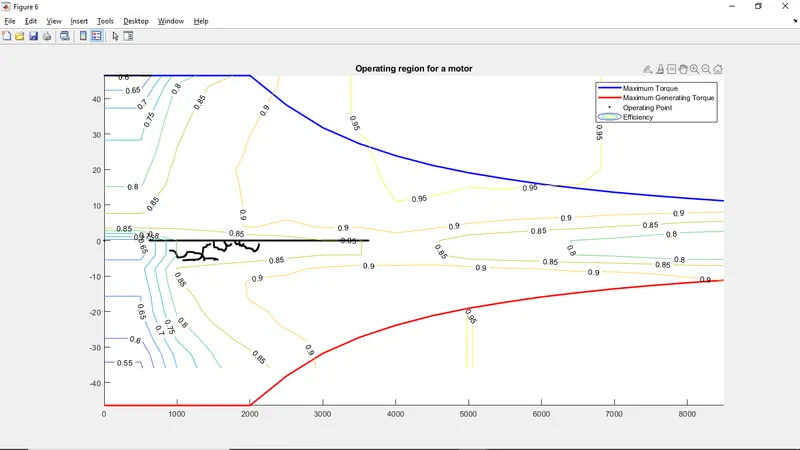
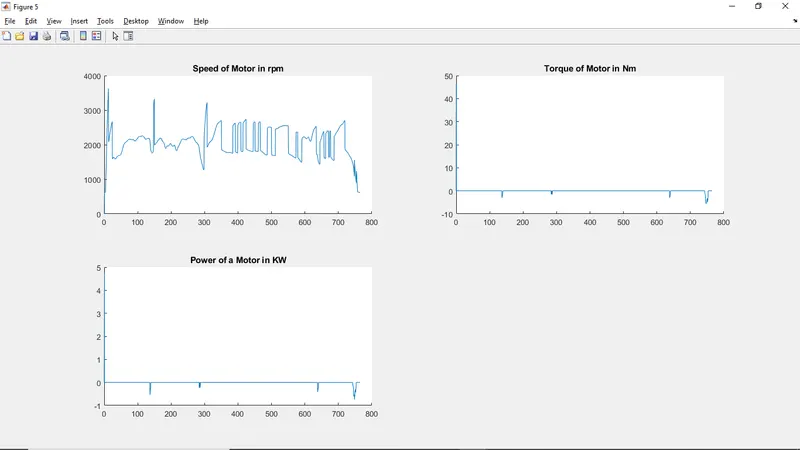
In analysis of electric powertrain the component like battery and motor were analysized.In figure 21a ,21b and 21c we can observe that character of motor and battery for the UDDS cycle. In figure 2b we can observe the battery is working/operating point is at the generating region.In figure 22 a ,22b and 22c we can observe the character of the battery and motor for vehicle when it is moving in an HWFET cycle.Here we can observe that the vehicle is not going on regenerating phase much as compared with the UDDS cycle since brake pedal werenot used frequently.
a b
c
Figure 21: a)Voltage,current and SOC of the battery for UDDS cycle b)Motor operating point for UDDS cycle c)Motor speed, power and torque for UDDS cycle
a b
c
Figure 22:: a)Voltage,current and SOC of the battery for HWFET cycle b)Motor operating point for HWFET cycle c)Motor speed, power and torque for HWFET cycle
3.2 Comparision with Conventional Vehicle
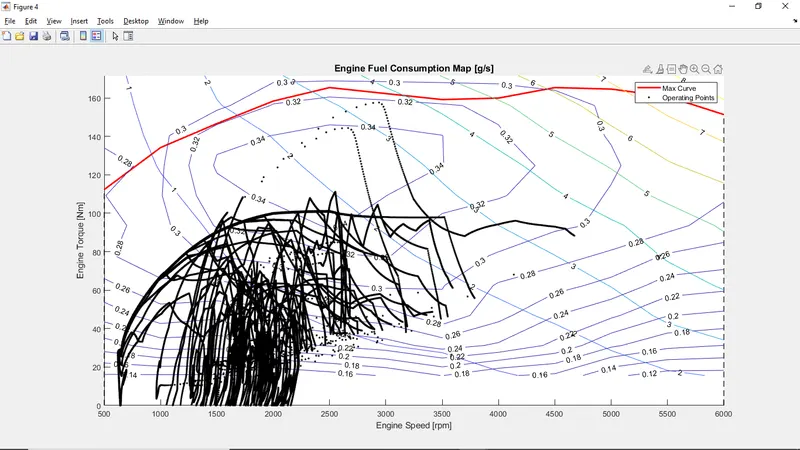
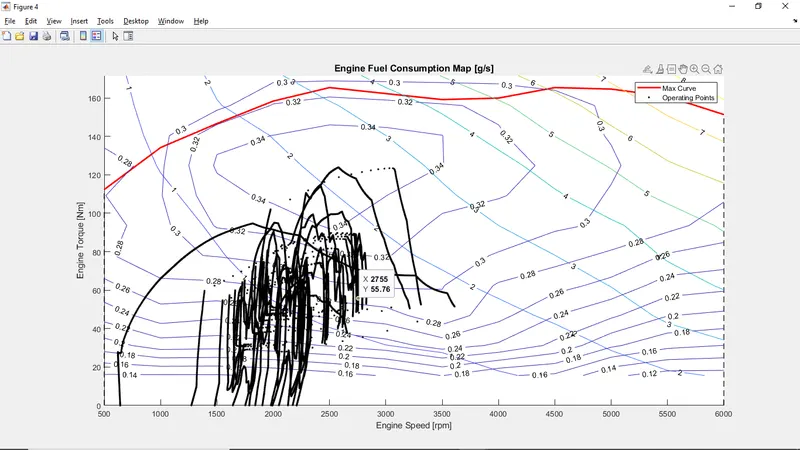
Figure 23 a is the engine fuel consumption map with its operating point when we have considered the hybrid vehicle and figure23b is the engine fuel consumption plot with itsoperating point when we have considered the conventional vehicle for UDDS cycle.We can oberve comparitively large amount of cluster of operating point for conventional vehicle than for hybrid vehicle. This is due to the start stop feature in the hybrid vehicle which stops the engine when it is idealing. In figure 24 a and 24b is the engine fuel consumption for the HWFET cycle for hybrid vehicle and conventional vehicle. There is some better in terms of the fuel consumption since the HWFET cycle is not subjected to frequent start and stop so similar kind of operating region were observed for the HWFET cycle. The milage for the conventional vehicle when UDDS cycle was considered was around 14.2044 kmpl and for hybrid it was slightly better with 14.2964 kmpl.For HWFET cycle, the milage was increased to 17.1572 kmpl for hybrid vehicle as compared with 16.501 kmpl for the conventional vehicle. Since, the applied hybrid vehicle was only capable for the start stop and regenerative braking ,milage can be further increase when P2,P3 or above model were considered in which more features like motor assist or EV alone mode is also available.
a b
Figure 23 a)Engine performance map with its operating point for hybrid vehicle in UDDS cycle. b)Engine perfromace map with its operating point for conventional vehicle in UDDS cycle.
a b
Figure 24 a)Engine performance map with its operating point for hybrid vehicle in HWFET cycle. b)Engine perfromace map with its operating point for conventional vehicle in HWFET cycle.
Conclusion:
The system level analysis was done for the P1 hybrid vehicle and compared the fuel consumption aspect or milage with the conventional vehicle.