Project 1 (Mini Project on Vehicle Direction Detection
Aim:-
- Development of MATLAB Simulink model as per requirement data given in the question
- Tag the requirements to the Simulink model and name them requirement 1 and requirement 2
- If choosing code generation, Storage class for Input signals: ImportedExtern; Storage class for Output signal: Export to File; Storage class for local signals: localizable; Storage class for calibration signals: Constant
- Selecting time for the constant signals as 0.01s
Procedure
Step 1)
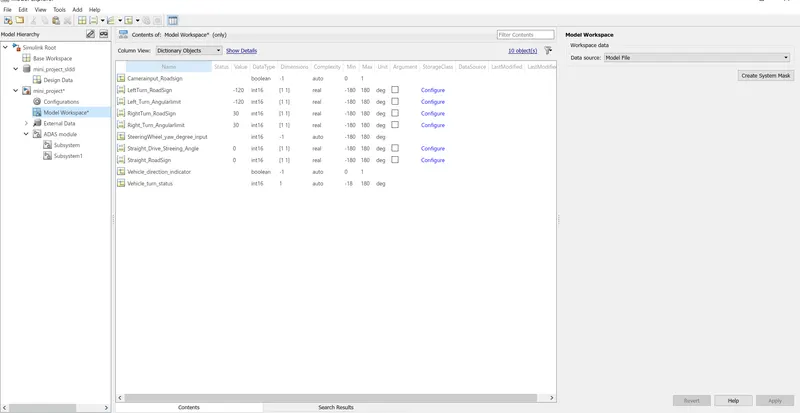
first, give the input to the SLLD dictionary as given below and in that, we need to select these things as
- Signal: for the five signals those were Vehicle_Turn_Status, CameraInput_RoadSign,SteeringWheel_YawDegreeInput,Vehicle_Direction_Indicator
- Three signals are input and we need to provide the signal as input and one is output from which we can accept the output from the signal
- Simulink parameter: We have got the various constants and these values will be as calibration constant.
- they are except these 4 values . are Right_Turn_AngularLimit, Left_Turn_AngularLimit,Straight_Drive_Steering_Angle,RightTurn_RoadSign,LeftTurn_RoadSign,Straight_RoadSign.
we can see from the above vehicle and here in form of a certain value and some initial value will be there and we can see that these were given in the value to give input.
here in the given question is that we need to save the certain available in the following Storage class
for that, we have to save
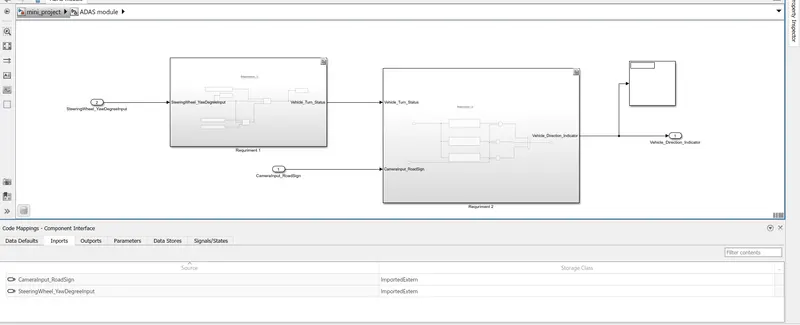
- Storage class for Input signals: ImportedExtern
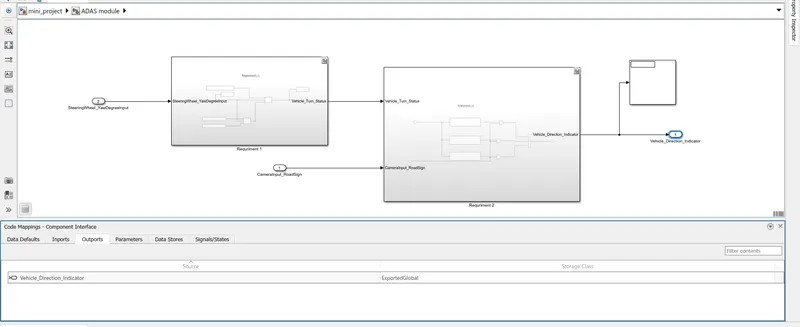
- Storage class for Output signal: Export to File
- Storage class for local signals: localizable[We have a problem in Matlab so we cant save the storage class in localizable and constant]
- Storage class for calibration signals: Const.
below are some of the images for the above SLDD
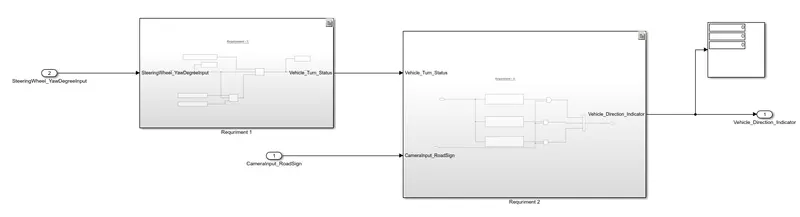
step 2)Presentation of the model
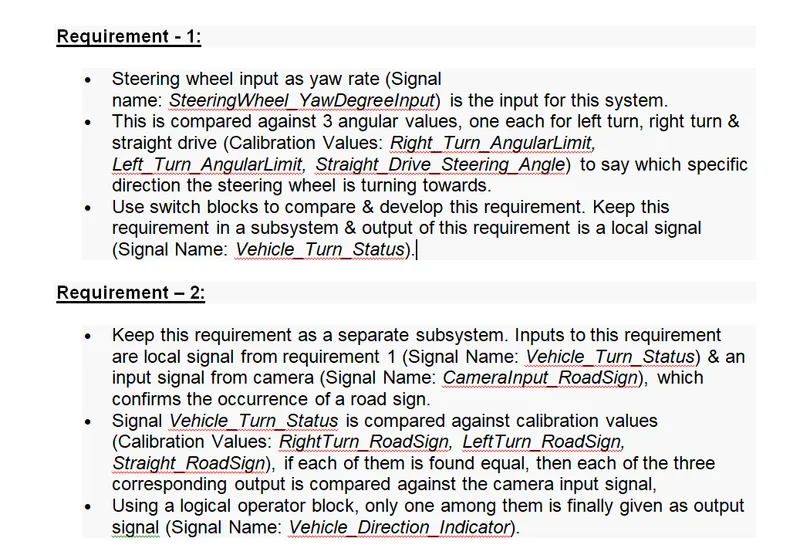
we have 2 requirements and they are
In requirement 1 is that we need to get the input from the camera and steering yaw input and output will be vehicle indicators
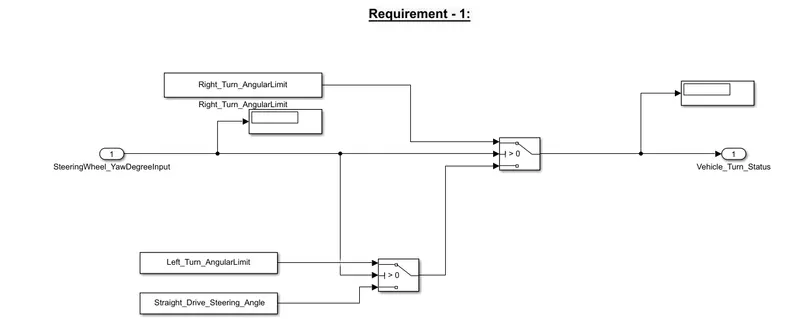
here we had got the input as steering yaw and we need to compare with right angular, left angular and straight input and this input have been given as that have shown.
so it will compare the data then it will give the output.
here output will be in the form of int16 data.
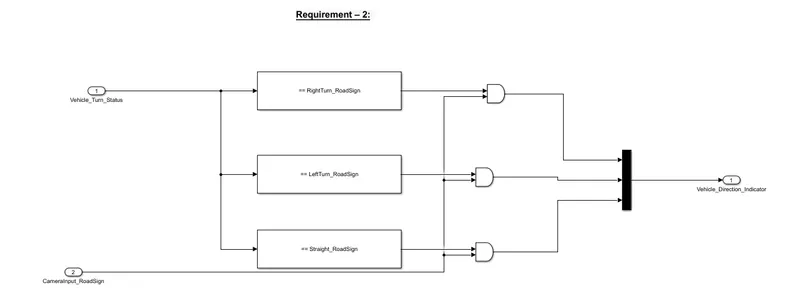
Here we have to give the input which is the output of 1 block and then we need to compare it with the given data of the already data and the input will be havening the int 16 and the right left and the road will be given and they will be compared with the data then it would be given as roadsign
it would be given as and the reason is both inputs will be high then only as output will be high
Now it ig given to Mux then the output will be given
now we had given it as 2 blocks and then made it a sub-block.
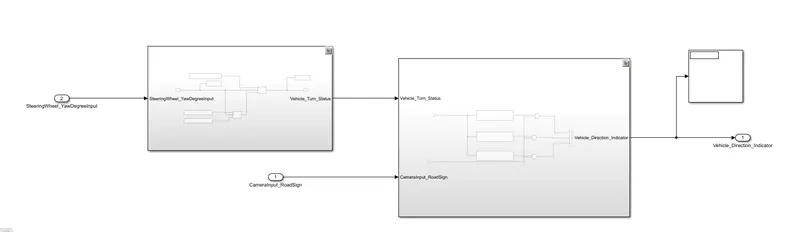
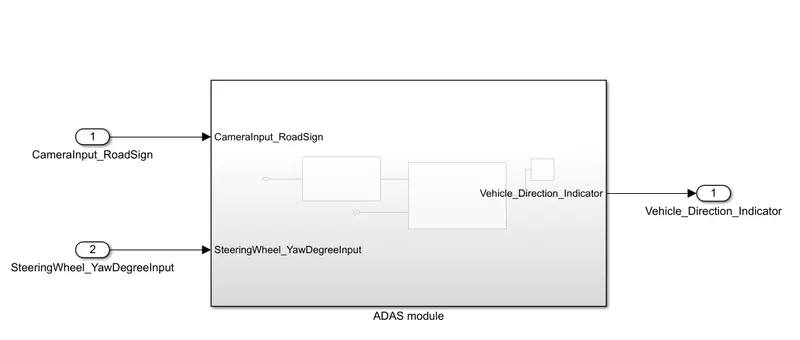
now we need to make it a requirement then we need to go to then we can select the mark through the world
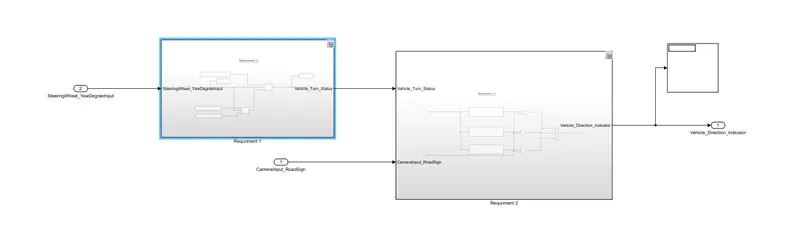
Result:
- we had done an SLLD with the given data
- Modelled an ADAS with given specification and it done modelled as per that
- we had linked as given
- The output will be observed as per given that.