Week-7 Challenge: DC Motor Control
AIM:-
1. A. Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’.
B. Comment on the armature current shoot-up from the scope results.
C. Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
2. Develop a 2-quadrant chopper using Simulink & explain the working of the same with the relevant results. (Refer to the article - Multiquadrant operation of the motor)
3. Explain in a brief the operation of the BLDC motor.
1. A. Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’.
The Bipolar Junction Transistor (BJT) when used for power switching applications, operates as an IGBT. When it is conducting (BJT operating in the saturated region), a forward voltage Vf is developed between collector and emitter (in the range of 1 V). Therefore, the IGBT block can be used to model the BJT device.
The IGBT block does not simulate the gate current controlling the BJT or IGBT. The switch is controlled by a Simulink signal (1/0). The DC motor uses the preset model (5 HP 24V 1750rpm). It simulates a fan type load (where load torque is proportional to the square of speed). The armature means voltage can be varied from 0 to 240 V when the duty cycle (specified in the Pulse generator block) is varied from 0 to 100%.
The H-bridge consists of four BJT/Diode pairs (BJT simulated by IGBT models). Two transistors are switched simultaneously: Q1 and Q4 or Q2 and Q3. When Q1 and Q4 are fired, a positive voltage is applied to the motor, and diodes D2-D3 operate as free-wheeling diodes when Q1 and Q4 are switched off. When Q2 and Q3 are fired, a negative voltage is applied to the motor, and diodes D1-D4 operate as free-wheeling diodes when Q2 and Q3 are switched off.
DC MOTOR DRIVING USING H BRIDGE:-
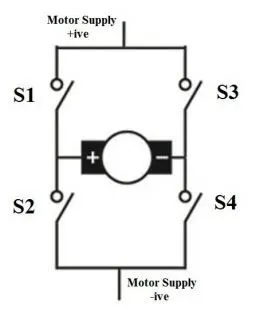
H Bridge is a simple electronic circuit that enables us to apply voltage to load in either direction. It is commonly used in robotics applications to control DC motors. By using the H bridge we can run the DC motor in clockwise or anticlockwise directions. This circuit is also used to produce alternating waveforms in inverters.
Basic H Bridge Diagram is given below:
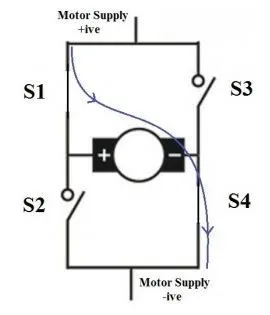
When switches S1 and S4 are switched on, the motor runs in a clockwise direction.
When switches S2 and S3 are switched on, the motor runs in an anticlockwise direction.
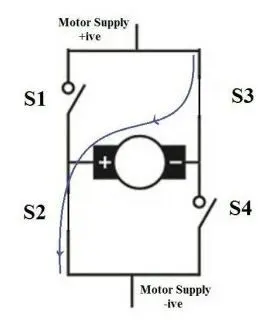
In actual practice, these switches are replaced by transistors. Nowadays H bridge ICs such as L29D and L293 are available.
WHAT IS A DC CHOPPER?
DC to DC converter is very much needed nowadays as many industrial applications are dependent upon DC voltage source. The performance of these applications will be improved if we use a variable DC supply. It will help to improve the controllability of the equipment also. Examples of such applications are subway cars, trolleybuses, battery-operated vehicles, etc. We can control and vary a constant DC voltage with the help of a chopper.
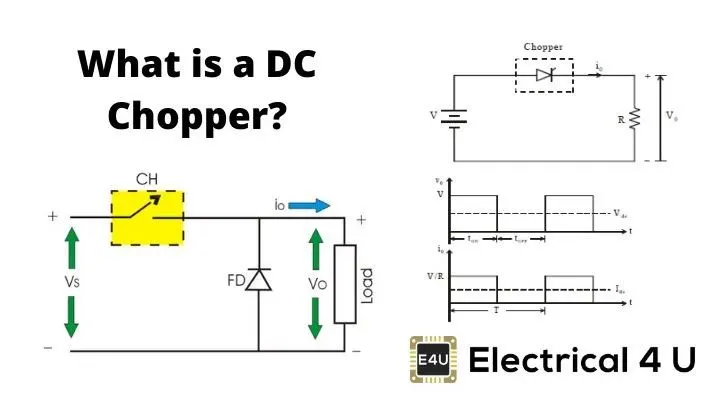
Chopper is a basically static power electronics device that converts fixed DC voltage/ power to variable DC voltage or power. It is nothing but a high-speed switch that connects and disconnects the load from the source at a high rate to get variable or chopped voltage at the output.
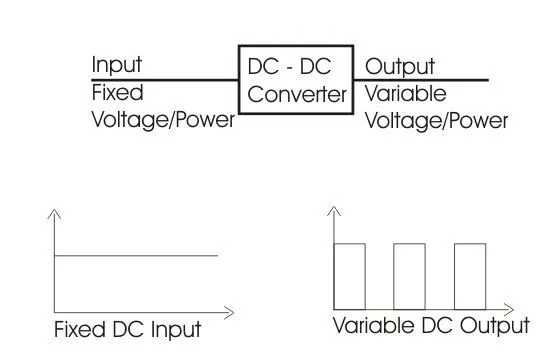
The chopper can increase or decrease the DC voltage level on its opposite side. So, the chopper serves the same purpose in DC circuit transfers in the case of AC circuits. So, it is also known as a DC transformer.
1. B. Comment on the armature current shoot-up from the scope results?
Explain and run MATLAB demo "Speed Control of a DC Motor using BJT-H Bridge". The armature current shoot-up from the scope results are to be observed.
- Open the MATLAB and click on the help option and type "Speed Control of a DC Motor using BJT-H Bridge" in the search option.
- Then results tap opens, and then select the model and click on the open model.
- Models open in Simulink environment. Screenshot of block diagram given below:-
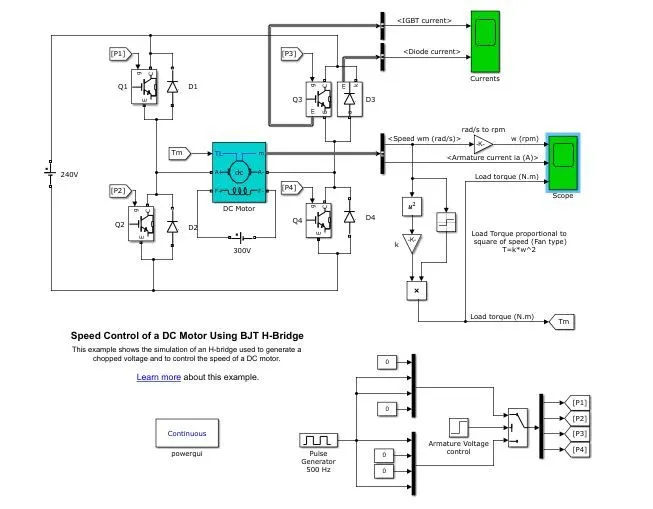
- Run the model as it is and observes the graphs of the armature current.
- Check the outputs. Follow the same for 75% and 50% just to check if the armature voltage is decreased sharply after half of the simulation time.
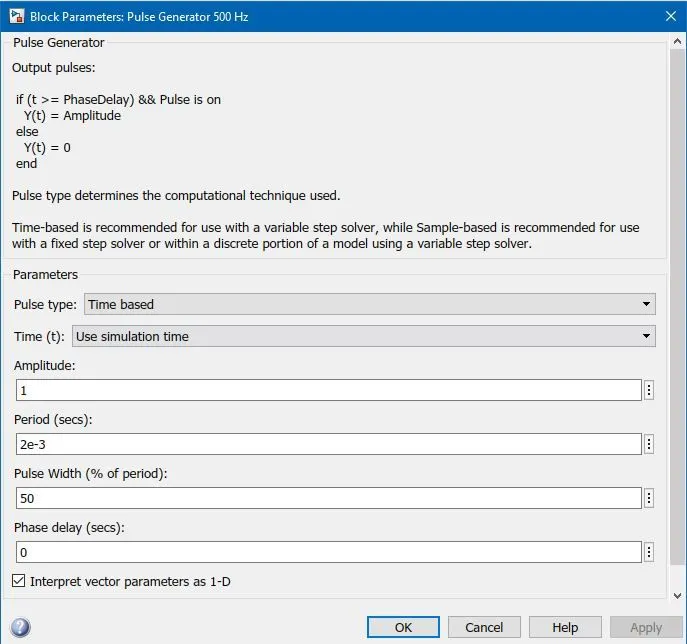
Pulse generator block parameter for 50% pulse width given below:-
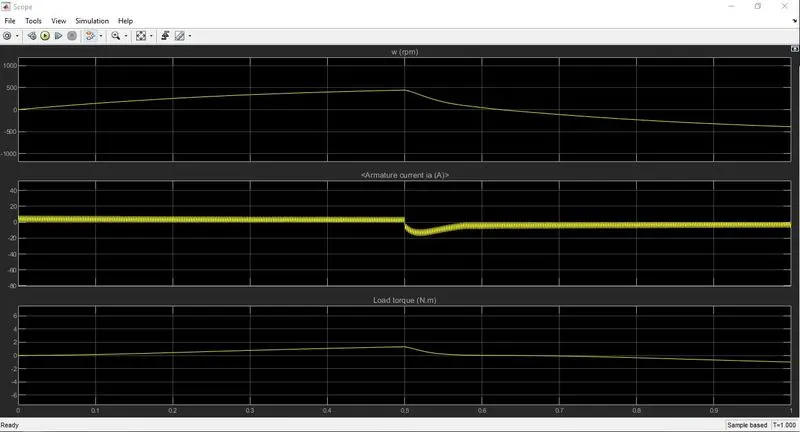
RESULTS:-
Pulse generator block parameter for 75% pulse width given below:-
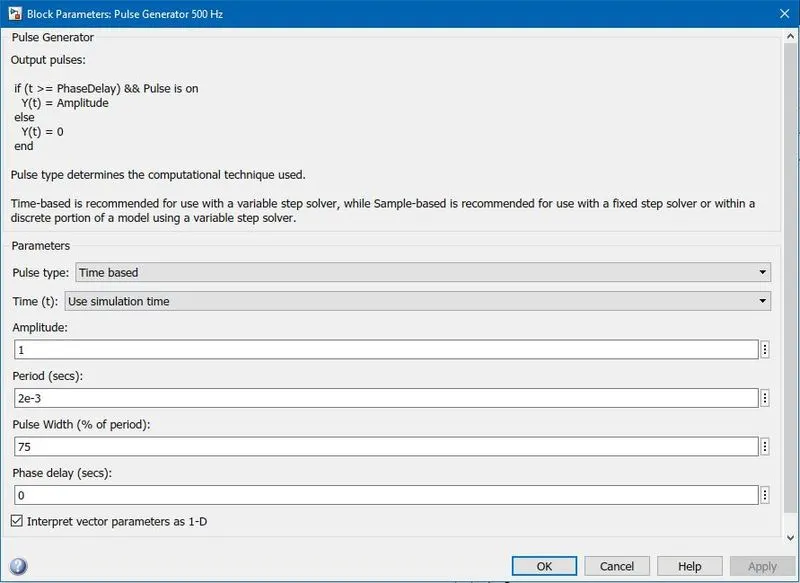
RESULTS:-
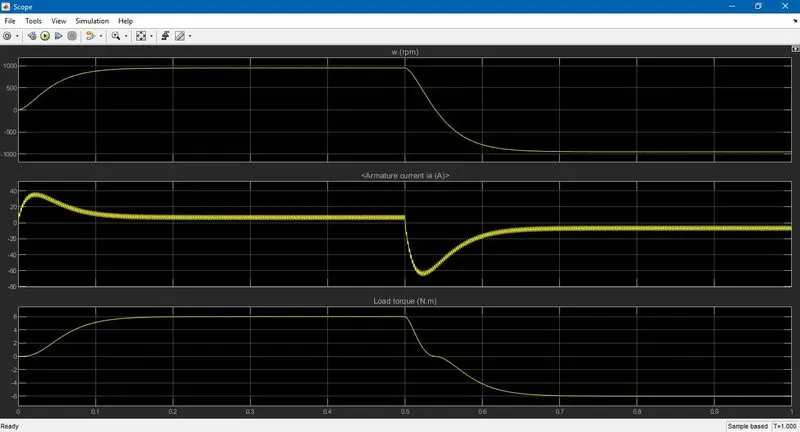
Therefore when pulse width decreases, the voltage applied across the DC motor decreases and the armature current finally decreases.
1. C. Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
The Four-Quadrant Chopper DC Drive (DC7) block represents a four-quadrant, DC-supplied, chopper (or DC-DC PWM converter) drive for DC motors. This drive features closed-loop speed control with a four-quadrant operation. The speed control loop outputs the reference armature current of the machine. Using a PI current controller, the chopper duty cycle corresponding to the commanded armature current is derived. This duty cycle is then compared with a sawtooth carrier signal to obtain the required PWM signals for the chopper.
The main advantage of this drive, compared with other DC drives, is that it can operate in all four quadrants (forward motoring, reverse regeneration, reverse motoring, and forward regeneration). In addition, due to the use of high switching frequency DC-DC converters, a lower armature current ripple (compared with thyristor-based DC drives) is obtained. However, four switching devices are required, which increases the complexity of the drive system.
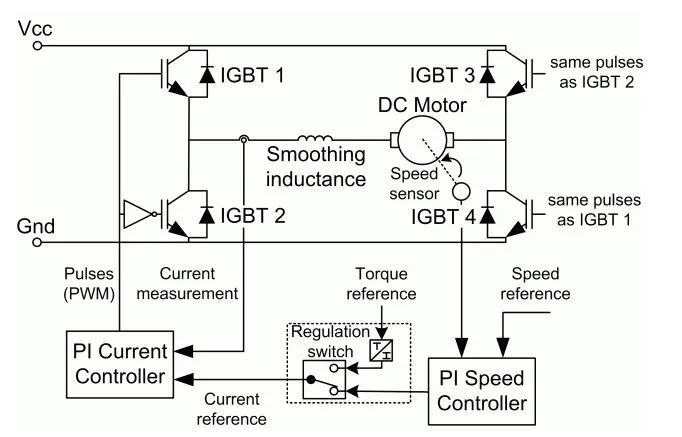
The Four-Quadrant Chopper DC drive block uses these blocks from the Electric Drives/Fundamental Drive blocks library:-
- Speed Controller (DC)
- Regulation Switch
- Current Controller (DC)
- Chopper
The below figure shows the schematic of the 4 quadrant chopper DC drive:-
This example shows the DC7 Four-Quadrant Chopper DC drive during speed regulation:-
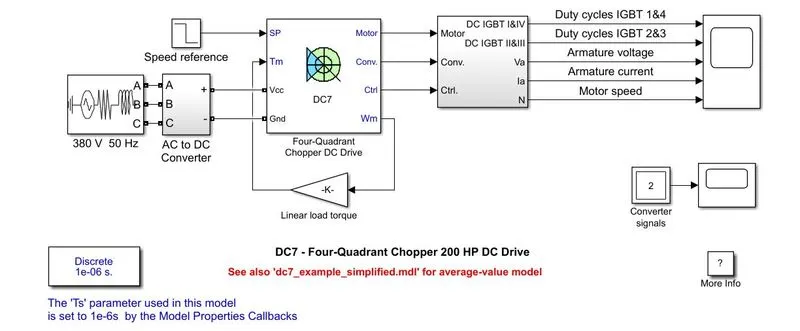
OUTCOMES:-
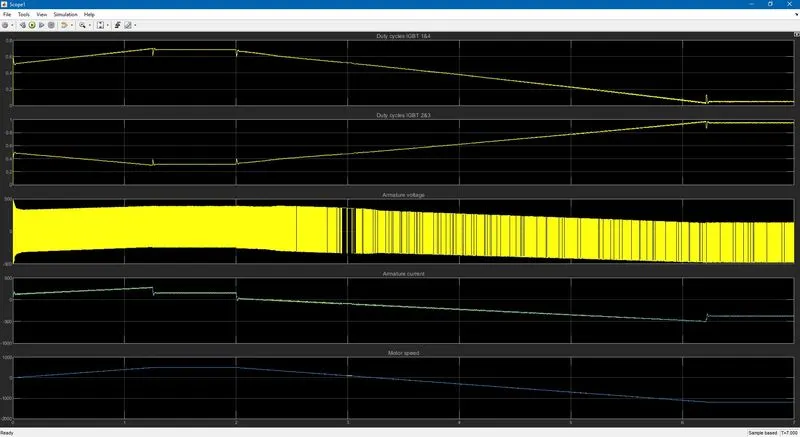
Difference between H Bridge and Four Quadrant Chopper DC Drive:-
| H Bridge | Four Quadrant Chopper DC Drive |
| Widely Used in Robotics. | Widely Used in Automobile. |
| Higher armature current ripple. | Lower armature current ripple due to the high switching frequency of DC-DC converters. |
| Only two quadrants of operation are possible. They are forward motoring and reverse motoring. | It can operate in all four quadrants (forward motoring, reverse regeneration, reverse motoring, and forward regeneration). |
| Less Complex. | More Complex. |
| Simulation is continuous and simulation time is more. | Discrete and Simulation time is less. |
2. Develop a 2-quadrant chopper using Simulink & explain the working of the same with the relevant results. (Refer to the article - Multiquadrant operation of the motor)
Two Quadrant Chopper:- In this type of chopper, the average voltage will be always positive but the average load current might be positive or negative. The two switches CH1 and CH2 should not be turned on simultaneously as the combined action may cause a short circuit in supply lines. For regenerative braking and motoring, this type of chopper configuration is used.
We will always get a positive output voltage `V_o` as the freewheeling diode FD is present across the load. When the chopper CH1 is on the current flows from source to load. The inductor stores energy. When C1 turns OFF the freewheeling diode starts conducting and the output voltage `V_o` will be equal to `V_s`. The direction of the load current `i_o`will is reversed. The current `i_o`will be flowing towards the source. The load current will be negative when the CH2 is on. The current completes its path through diode D2.
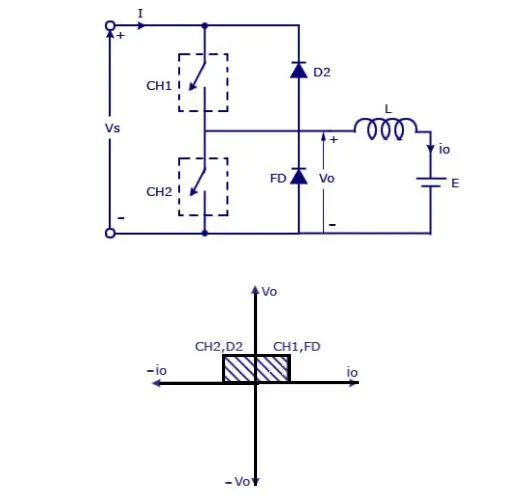
Application:- Class-C or Type-C choppers are used for motoring and regenerative braking of DC motors.
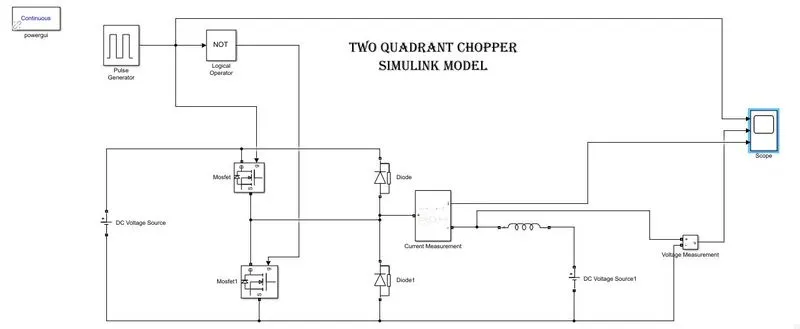
Simulink Model for Two Quadrant Chopper:-
PULSE GENERATOR BLOCK PARAMETERS ARE GIVEN BELOW:-
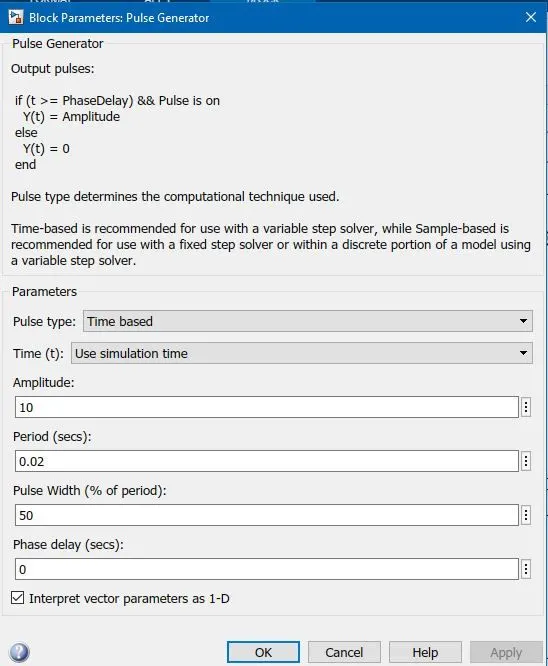
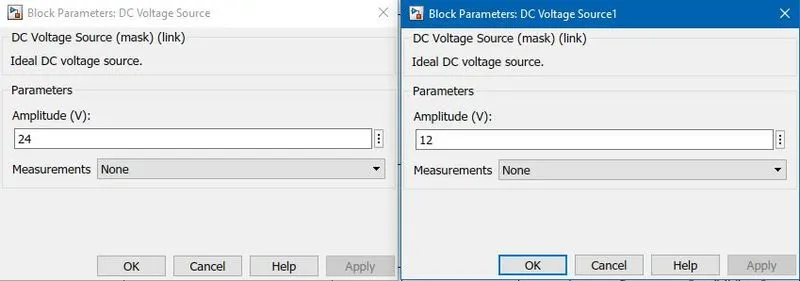
An Amplitude of 10 is chosen so that we could see the pulse clearly.
DC VOLTAGE SOURCE BLOCK PARAMETERS ARE GIVEN BELOW:-
RESULTS:-
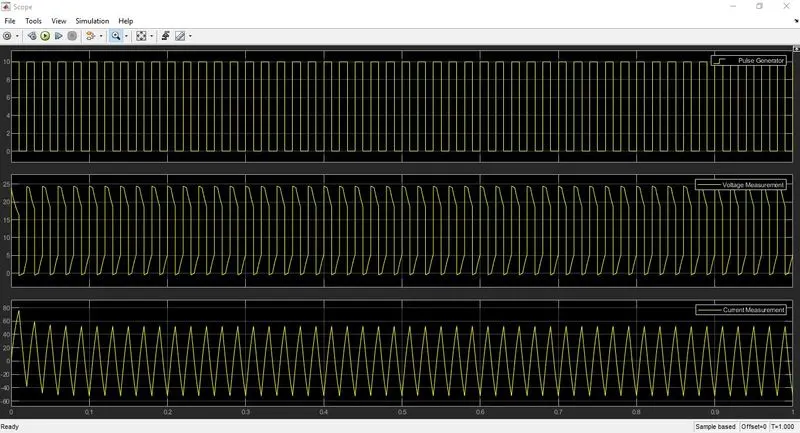
Hence, we could see clearly that the voltage is always positive but the current becomes both positive and negative. Hence, the Type C chopper is simulated and verified.
3. Explain in a brief the operation of the BLDC motor.
A brushless DC electric motor (BLDC motor or BL motor), also known as an electronically commutated motor (ECM or EC motor) or synchronous DC motor, is a synchronous motor using a direct current (DC) electric power supply. It uses an electronic closed-loop controller to switch DC currents to the motor windings producing magnetic fields which effectively rotate in space and which the permanent magnet rotor follows. The controller adjusts the phase and amplitude of the DC current pulses to control the speed and torque of the motor. This control system is an alternative to the mechanical commutator (brushes) used in many conventional electric motors.
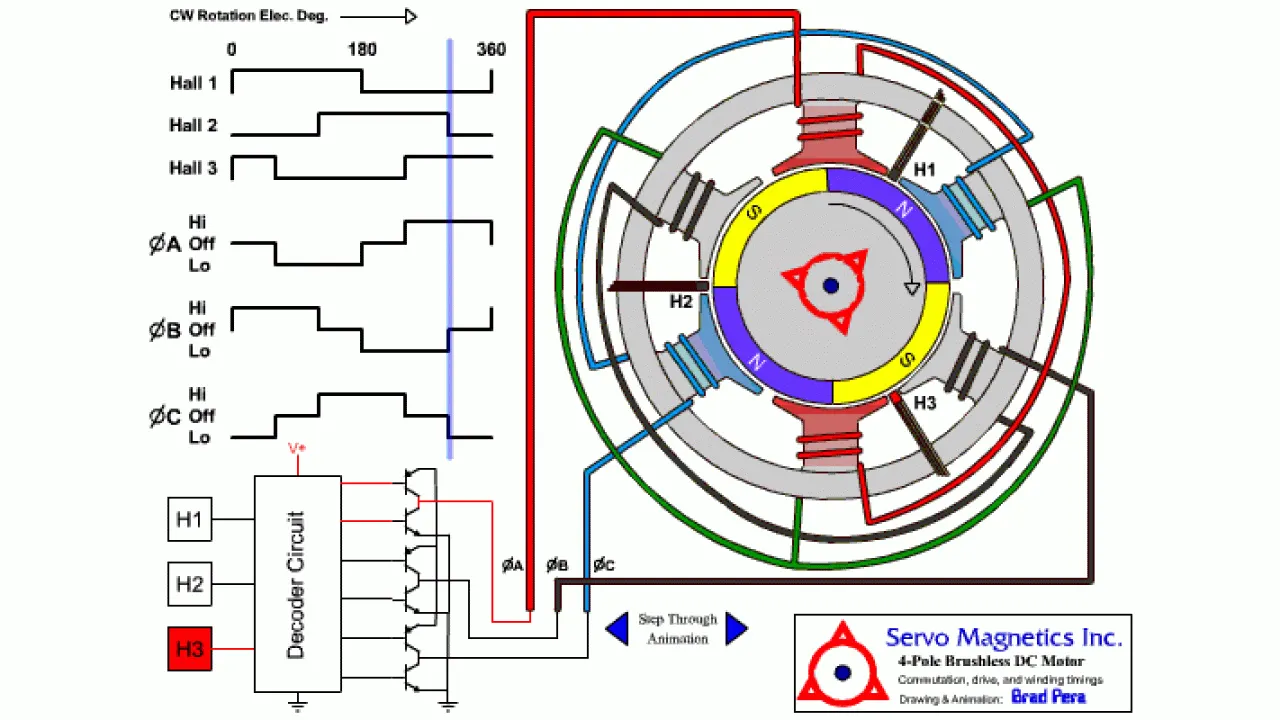
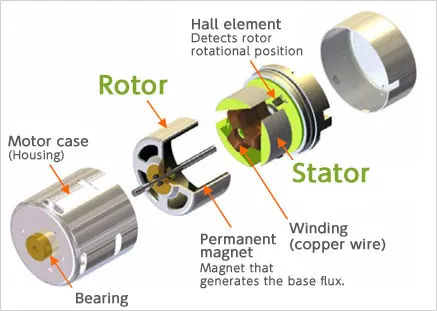
The construction of a brushless motor system is typically similar to a permanent magnet synchronous motor (PMSM), but can also be a switched reluctance motor, or an induction (asynchronous) motor. They may also use neodymium magnets and be outrunners (the stator is surrounded by the rotor), in runners (the rotor is surrounded by the stator), or axial (the rotor and the stator are flat and parallel).
The advantages of a brushless motor over brushed motors are high power-to-weight ratio, high speed, nearly instantaneous control of speed (rpm) and torque, high efficiency, and low maintenance. Brushless motors find applications in such places as computer peripherals (disk drives, printers), hand-held power tools, and vehicles ranging from model aircraft to automobiles. In modern washing machines, brushless DC motors have allowed the replacement of rubber belts and gearboxes by a direct-drive design.
REFERENCES:-
https://en.wikipedia.org/wiki/Brushless_DC_electric_motor