Simulink Model - DC Motor Control
Objective:
- A. Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’. B. Comment on the armature current shoot-up from the scope results. C. Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model
- Develop a 2-quadrant chopper & explain the working of the same with the relevant results. (Refer to article - Multiquadrant operation of motor )
- Explain in a brief about operation of BLDC motor.
#1A Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’.
Simulink Model: 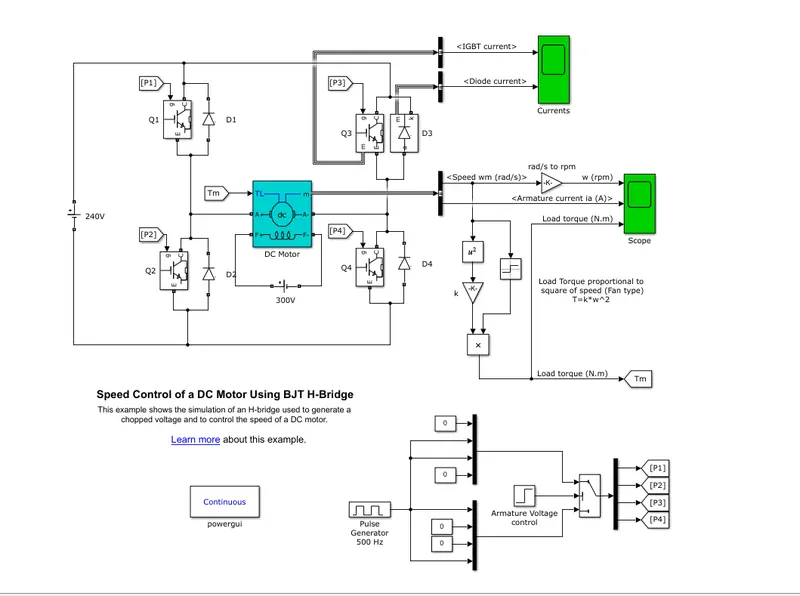
This model consists of a H bridge with 4 BJT-Diode Pair. The inputs such as duty cycle and step time are given from 'Pluse Generator Block', 'Armature Voltage Control' Block.
This H Bridge is made up of four switches Q1,Q2,Q3,Q4 and four diodes D1,D2,D3,D4. As IGBT can be used a switches which can be either in off or on position. When the motor is coasting it generates electricity due to the flexibility of this
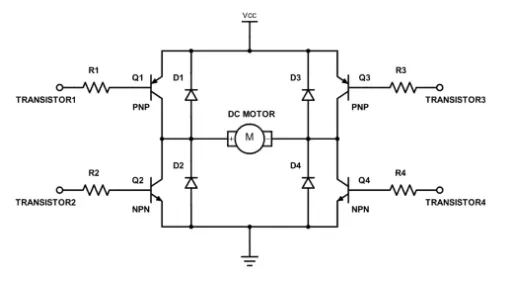
Different Modes Available:
- If Switch Q1 and Q4 is closed, this will cause the current to flow from the source, through Switch 1 and then through the load, then through Switch Q4, then down to the ground. This is known as Forward motion of the motor.
- If Switch Q2 and Q3 is closed, this will cause the current to flow from the source, through Switch 3 and then through the load, then through Switch 2, then down to the ground. This is known as Reverse motion of the motor.
- If Switch Q1,Q3 or Q2,Q4 is Closed, then both sides of the motor have no potential difference and this is called as Brake mode.
- If Switch Q1,Q2 or Q3,Q4 is closed, then it will cause a short and burn out the H-bridge.
- If only one switch or none are closed, in this state the motor will be just coasting.
Working of Model:
- The DC motor uses the preset model (5 HP 24V 1750 rpm). It simulates a fan type load . The armature mean voltage can be varied from 0 to 240 V when the duty cycle (specified in the Pulse Generator block)is varied from 0 to 100%.
- The H-bridge consists of four BJT/Diode pairs (BJT simulated by IGBT models).
- Two transistors are switched simultaneously: Q1 and Q4 or Q2 and Q3. When Q1 and Q4 are fired, a positive voltage is applied to the motor and diodes D2-D3 operate as free wheeling diodes when Q1 and Q4 are switched off.
- When Q2 and Q3 are fired, a negative voltage is applied to the motor and diodes D1-D4 operate as free wheeling diodes when Q2 and Q3 are switched off.
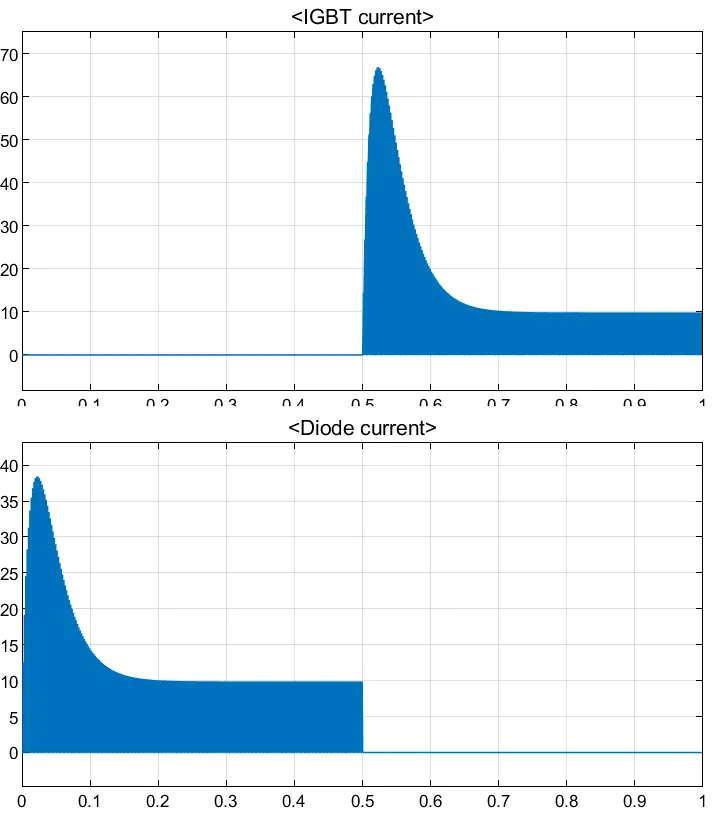
The Above graphs shows the current paasing through IGBT and Diode. So for 0 to 0.5 sec current is flowing through the diode D3 and 0.5 to 1 sec the current is passing through Q3.
Here Load torque is proportional to the square of angular velocity.
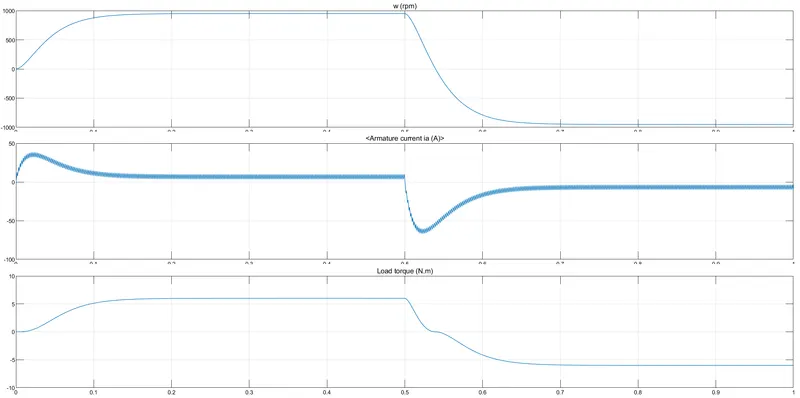
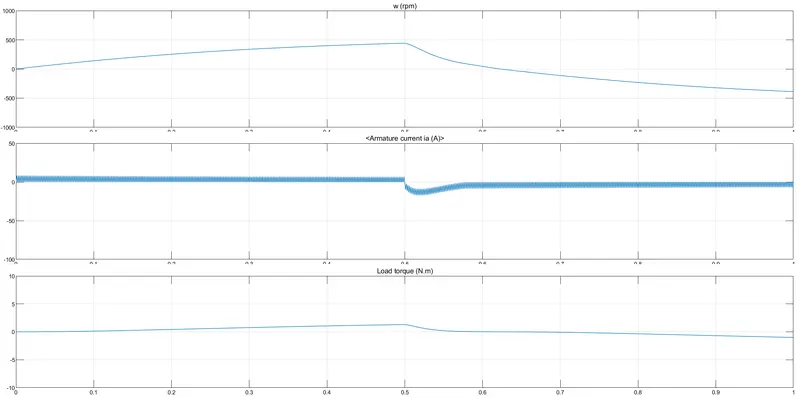
The above plot shows that at the begining of the cycle there is a sudden peak in armature current, the same repeats in opposite direction whenthe motor rotates in opposite direction.
B. Comment on the armature current shoot-up from the scope results.
As the principle of Pluse Width Modulation (PWM)
The average value of Voltage (and Current) fed to the load is controlled by turning the switch between supply and load on and off at a fast rate. The PWM switching frequency has to be high enough not to affect the load, which is to say that the resultant waveform perceived by the load must be as smooth as possible.
The peaks can be remove by reducing the duty cycle.
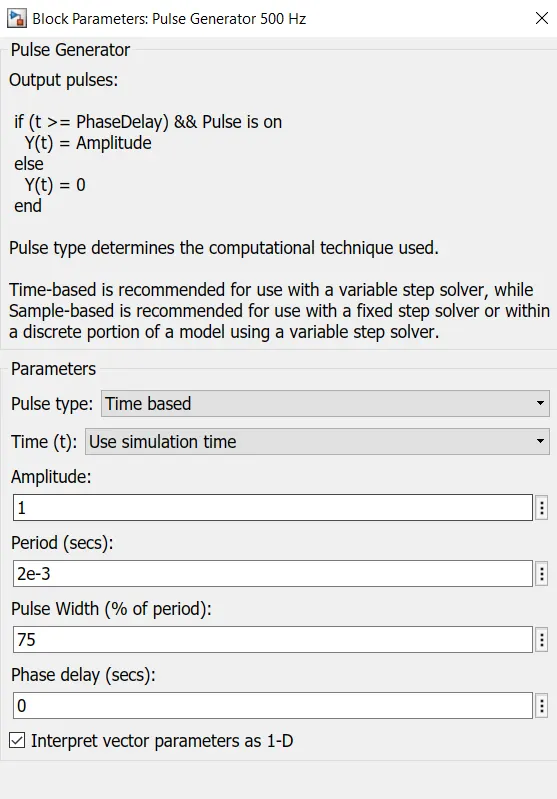
Initial Value:
Following plot show the output when the Pluse Width value is changed 50%:
As there is a peak when the motor is switching directions, Dutycycle is furture reduced to 40% and the following plot shows the output:
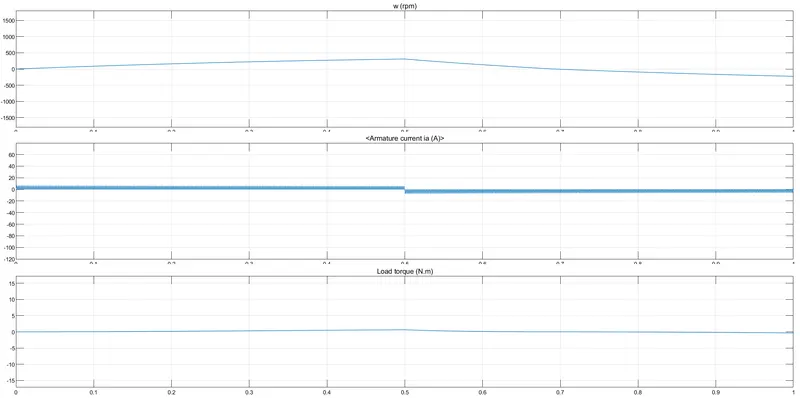
As the Duty cycle is reduced to 40% there is no sudden peak in the output.
C. Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge mode
Four Quadrant Chopper:
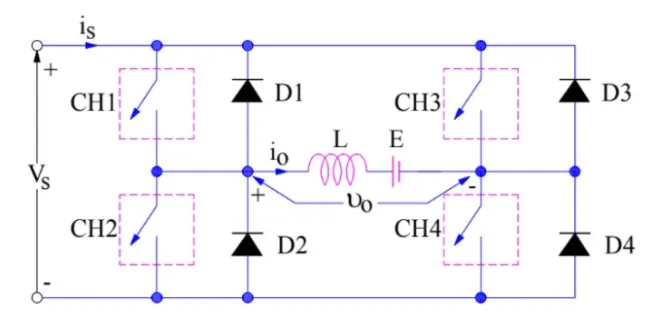
The Four Quadrants of Operation:
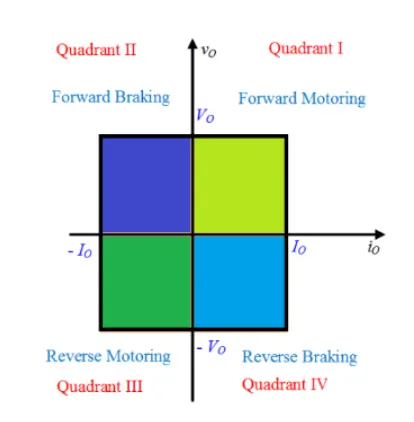
Operation of Quadrant 1
- switch CH1 turned on:
- As CH1 turned on, Switches CH1 and CH4 conduct, output voltage vo and the output current i, both are positives, power flows from source to load and inductor stores energy, the motor rotates in the forward direction hence called forward motoring.
- Switch CH1 turned off:
- Switch CH1 turned off but switch CH4 and diode D2 conducts, output current i, is positive and the output voltage vo becomes zero, inductor release energ, the motor rotates in the forward direction hence called Forward motoring.
Quadrant II
- Switch CH2 turned on
- Let us assume that the motor is running in the forward direction. Here switch CH2 operated, Switch CH and diode D4 conducts, output voltage v. is zero and E, is responsible for the negative output current io. machine behave as generator and inductor stores energy.
- Switch CH2 turned off
- Here diode D4 and diode D1 conducts, output voltage v, becomes positive and the output current i, is negative, inductor release energy using diodes D4 and D1 power flows from load to source and hence called as Forward braking. This is also konw as Regenerative braking.
Quadrant III
- Switch CH3 turned on
- The polarity of back emf Eb must be reversed. Here switch CH3 operated, Switches CH3 and CH2 conducts, output voltage vo and the output current i, both are negatives, power flows from source to load and inductor stores energy, the motor rotates in the reverse direction hence it is called as reverse motoring.
- Switch CH3 turned off
- Switch CH3 turned off but switch CH2 and diode D4 conducts, output current i, is negative and the output voltage v, becomes zero, inductor release energy and freewheeling action using diode D4 takes place, the motor rotates in the reverse direction, So the polarity of back emf is reversed. hence called as Reverse motoring.
Quadrant IV
- Switch CH4 turned on
- The polarity of back emf must be reversed. If that the motor is running in the reverse direction. Here switch CH4 operated, Switch CH4 and diode D2 conducts, output voltage vo is zero and E, is responsible for the positive output current io. machine behave as generator and inductor stores energy.
- Switch CH4 turned off
- The polarity of back emf must be reversed. Switch CH4 turned off, diode D2 and diode D3 conducts, output voltage vo becomes negative and output current i, is positive, inductor release energy using diodes D2 and D3. power flows from load to source and hence called as reverse braking.
Simulink Model:
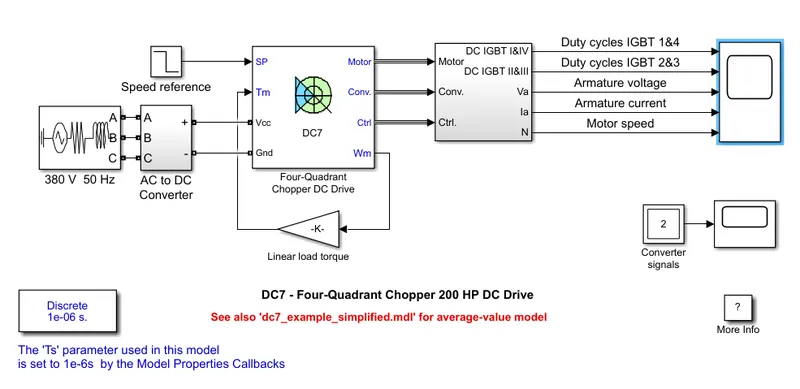
Comparing Four Quadrant Chopper and H- Bridge:
| Four Quadrant Chopper characteristics: | H-BRIDGE characteristics : |
| 1. Regenerative braking is possible. | 1. Regenerative braking is not possible but dynamic braking can be achieved. |
| 2. The current values are chopped not continuous hence simulation takes less time. | 2. The Current values are continous. |
|
3. Widley used in automobiles to control DC motor speed and direction. |
3. Widley used in robotics and electro-mechanical devices to control DC motor speed and direction. |
|
4. To change to direction of motor current signals are interrupted with one another. |
4. To change the direction of motor only the polarity of the current is changed. |
#2 Develop a 2-quadrant chopper & explain the working of the same with the relevant results. (Refer to article - Multiquadrant operation of motor )
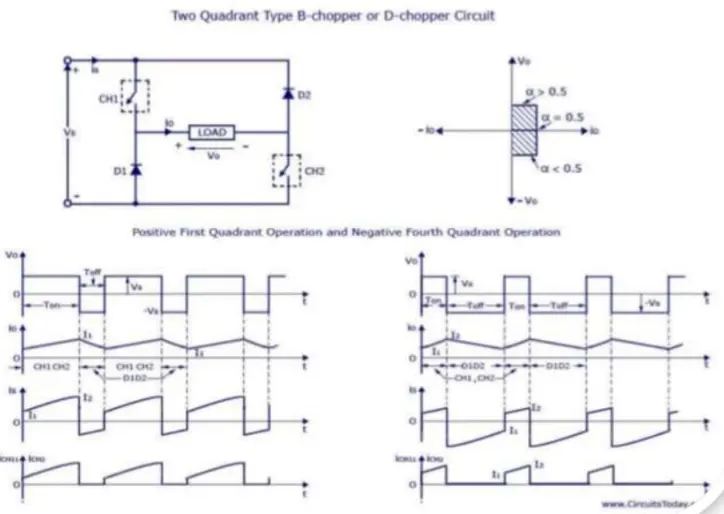
There are two types of Two Quadrant choppers:
Type C chopper Type D chopper
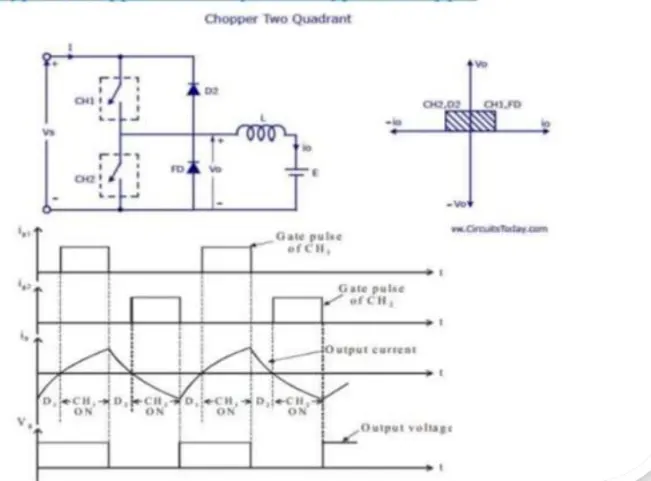
Type C Chopper:
We will always get a positive output voltage V0 as the freewheeling diode FD is present across the load. When the chopper is on the freewheeling diode starts conducting and the output voltage V0 will be equal to VS . The direction of the load current i0 will be reversed. The current i0 will be flowing towards the source and it will be positive regardless the chopper is on or the FD conducts. The load current will be negative if the chopper is or the diode D2 conducts. Two Switches should not be turned on simultaneous, as it shortcircuits the system.
The average voltage will be always positive but the average load current might be positive or negative. The power flow may be life the first quadrant operation ie from source to load or from load to source like the second quadrant operation. The two choppers should not be turned on simultaneously as the combined action my cause a short circuit in supply lines. For regenerative braking and motoring these type of chopper configuration is used.
Type D Chopper:
When the two choppers are on the output voltage v0 will be equal to Vs . When v0 = – Vs the two choppers will be off but both the diodes D1 and D2 will start conducting. V0 the average output voltage will be positive when the choppers turn-on the time will be more than the turn off time its shown in the wave form below. As the diodes and choppers conduct current only in one direction the direction of load current will be always positive.
The power flows from source to load as the average values of both v0 and i0 is positive. From the wave form it is seen that the average value of V0 is positive thus the forth quadrant operation of type D chopper is obtained.
#3 Explain in a brief about operation of BLDC motor.
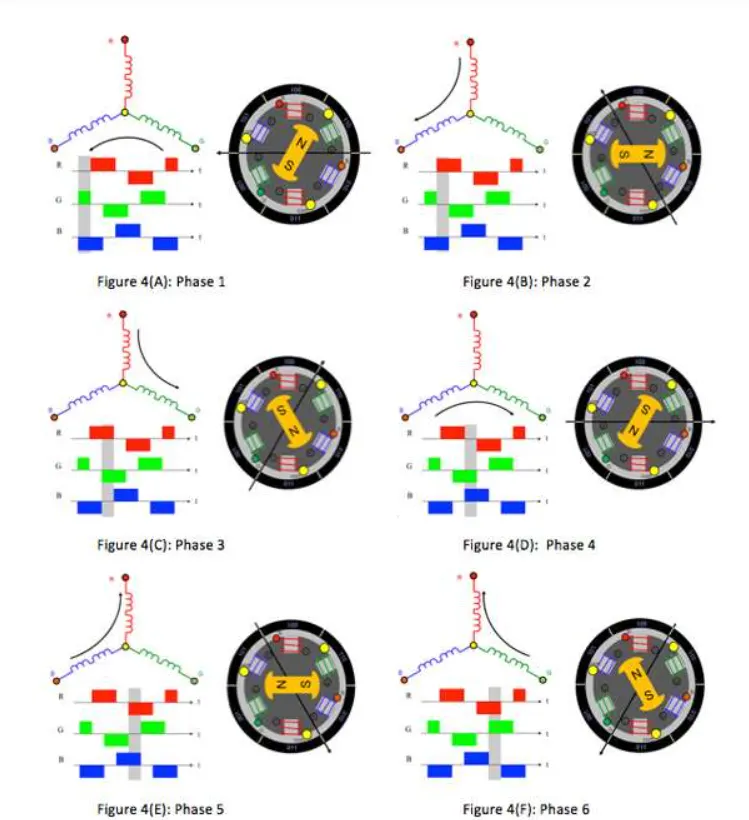
BLDC motor consists of a Stator and Rotor.
Stator windings of a BLDC motor are connected to a control circuit. The control circuit energizes proper winding at proper time, in a pattern which rotates around the stator.
The rotor magnet tries to align with the energized electromagnet of the stator, and as soon as it aligns, the next electromagnet is energized. Thus the rotor keeps running.
Commutator helps in achieving unidirectional torque in a typical dc motor.
Commutator and brush arrangement is eliminated in a brushless dc motor. And an integrated switching circuit is used to achieve unidirectional torque.
Below Figure shows a 3 Phase DC motor
Advantages of BLDC motor:
- Higher efficiency and reliability
- Lower acoustic noise
- Smaller and lighter
- Greater dynamic response
- Better speed versus torque characteristics
- Higher speed range
- Longer life