Week-4 Challenge WOT Condition Part-2
POWERTRAIN BLOCKSET
AIM:- To configure the control strategies in Powertrain Blockset.
OBJECTIVE:- a) To know about Mapped and Dynamic model of engine, motor and generator.
b) To change the model type from Mapped to Dynamic.
c) To calculate the model in miles per gallon.
d) To consider the factors to model fuel flow.
THEORY:-
Powertrain Blockset provides a fully assembled reference application models of automotive powertrains including gasoline, diesel, hybrid and electric systems. It includes a component library for simulating engine subsystems, transmission assemblies, traction motors, battery packs and controller models. MDF file support provide a standards-based calibration tools for data import. It provides a standard model architecture that can be reused throughout the development process. It can be used for design tradeoff analysis and component sizing, control parameter optimization and hardware-in-the loop testing. The models can be customized by parameterizing components in a reference application with own data or replacing a subsystem with your own model.
In order to customize a SI or CI reference application, a dynamic or a mapped engine and motor/generator model can be used.
MAPPED MODEL:- The model can be implemented by taking into account following consideration:
a) It uses a set of steady state lookup tables to characterize the engine performance .
b) The table provide overall engine characteristics, including actual torque, fuel flow rate, Brake-specific fuel consumption (BSFC) and engine-out exhaust emissions.
c) It can be used for quasi-steady state engine simulations.
d) It can be used if engine data from a dynamometer or a design tool like GT-POWER are available.
e) The model is used for fast system-level simulation when motor parameters are not defined.
MAPPED ENGINE:- The model contains two types of Mapped Engine i.e, Spark Ignition Mapped Engine and Compression Ignition Mapped Engine.
SI Mapped Engine CI Mapped Engine
These SI and CI mapped engine block implements a steady-state engine model using power, air mass flow, fuel flow, exhaust temperature, efficiency and emission performance look-up table. The block is used for:
- Hardware-in-the-loop (HIL) for engine control design.
- Vehicle-level fuel economy and performance simulation.
The block enable us to specify look-up tables for the engine characteristics.
An Actuator has been used which transmits Electronic throttle dynamics to the SI Mapped Engine with the help of transfer function block. It converts the source energy into mechanical motion. The emission of hydrocarbon (HC), carbon monoxide (CO) and nitrogen oxide (NOX) are shown in the three way catalytic convertor. The Mapped SI Engine with implicit turbocharger is given below:-
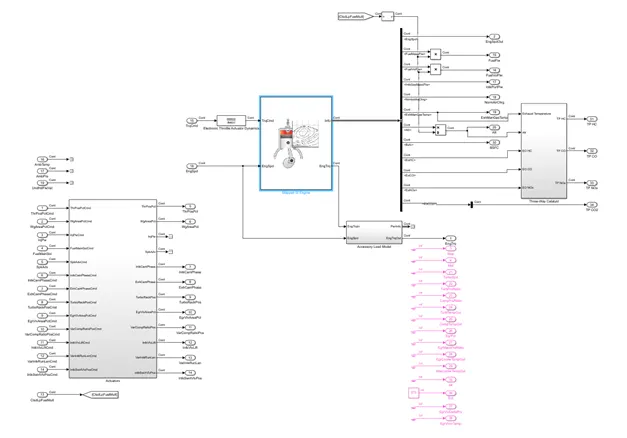
fig: 1.1
An Actuator has been used to inject pulsewidth dynamics to the CI Mapped Engine with the help of transfer function block. The different parameters configured using the CI Mapped Engine is given below:-
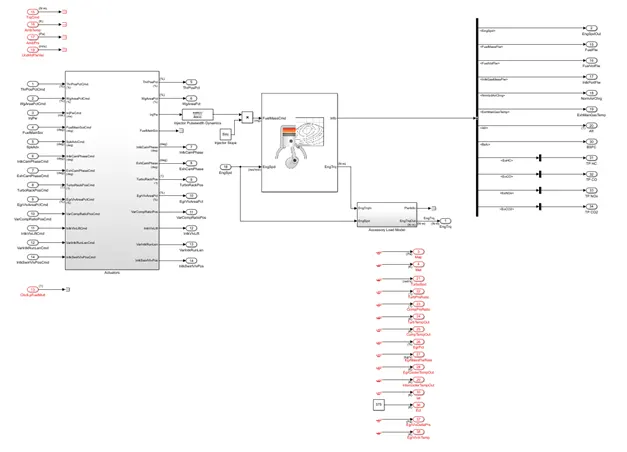
fig: 1.2
MAPPED MOTOR :- Mapped Motor with implicit controller.
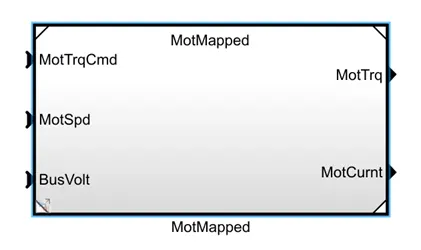
It implements a mapped motor and drive electronics operating in torque control mode. It specifies electrical torque range with a torque speed envelope or maximum motor power and torque. The Output torque tracks a torque reference demand and includes a motor-response and drive-response time constant. It specifies electrical losses as a single operating point that estimates loss across the operating range, measured loss, or measured efficiency.
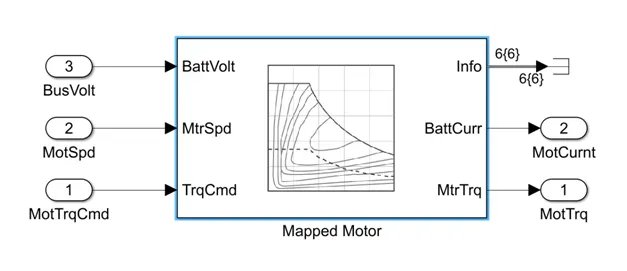
fig:1.3
MAPPED GENERATOR:-
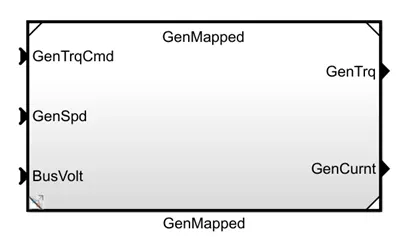
A Generator is a device that converts mechanical energy into electrical energy. In a Mapped Generator, steady-state lookup tables is used to characterize the engine performance. The Generator torque, speed and Bus voltage are taken as input which is converted to Torque and Current. The output torque tracks a torque reference demand and includes a generator-response and drive-response time constant. It specifies electrical losses as a single operating point that estimates loss across the operating range, measured loss, or measured efficiency.
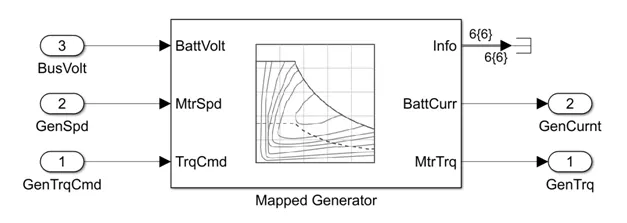
fig: 1.4
DYNAMIC MODEL:- The model can be implemented by taking into account the following consideration:
a) It decomposes the engine behavior into engine characteristics that are separated into lower-level components. By combining in this way, the model captures the dynamic effects.
b) It is used for a more detailed dynamic model and have component-level data.
c) It is used to analyze the impact of individual components on the overall performance.
DYNAMIC ENGINE:- The model contains two type of Dynamic Engine i.e, Spark Ignition Dynamic Engine and Compression Ignition Dynamic Engine.
SI Dynamic Engine CI Dynamic Engine
The SI and CI dynamic engine block implements ignition from intake to exhaust port. The engine block calculates Brake torque, Fuel flow, Air mass flow, Air-fuel ratio, Exhaust temperature and exhaust mass flow rate. The block is used for:
- Larger vehicle models.
- Hardware-in-the-loop (HIL) engine.
- Vehicle-level fuel economy and performance simulation.
The block simulate the result from the actual data given to the component of the model.
The SI dynamic model consist of Intake manifold, Throttle body, Intercooler, Exhaust manifold, Compressor and Turbine. The Intake manifold and Exhaust manifold implements a constant volume open thermodynamic system with heat transfer. The Throttle body implements an isentropic gas flow through an orifice. The velocity flow is limited by local acoustic velocity. The Intercooler implements heat exchanger. It determines heat transfer rate and downstream temperature based on the upstream temperature, effectiveness and temperature of the cooling medium. It assumes no pressure drop. The Environment intake is filtered through Air filter. The Air intake system collects the filtered air which is further fed to the Compressor. The Compressor determines the mass and heat flow rates between the volumes and required shaft torque. A turbocharger connects the Compressor and Turbine. The Turbine implements the exhaust side of turbocharger with a wastegate. The Dynamic SI Engine with turbocharger is given below:-
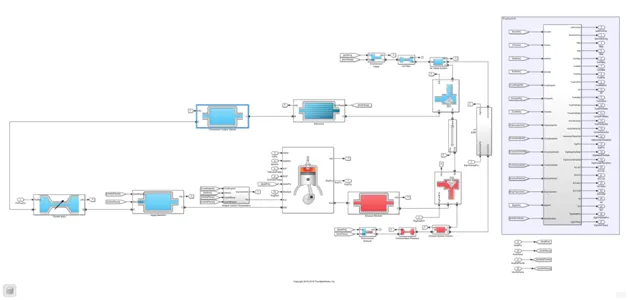
fig: 1.5
The CI dynamic model consist of Intake manifold, Intercooler,Exhaust manifold, EGR, Engine Coolant Temperature,Fuel system, Compressor, Turbocharger and Turbine. The functions are similar as discussed above. The dynamic CI engine with turbocharger is given below:-
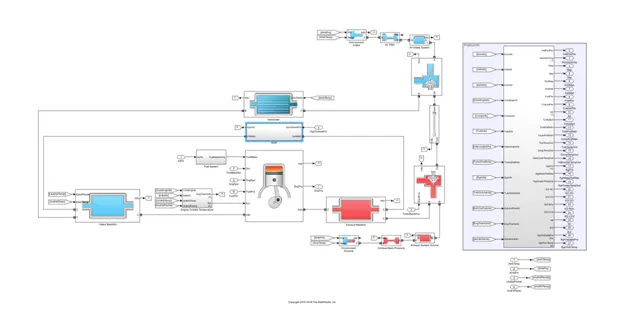
fig: 1.6
DYNAMIC MOTOR:- Interior permanent magnet synchronous motor (PMSM) with controller.
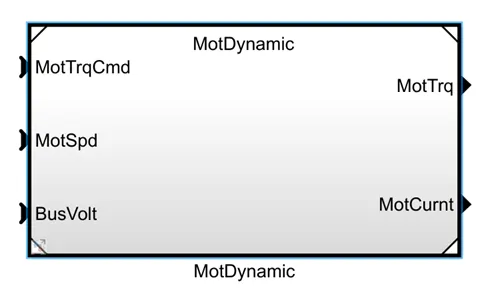
An interior Permanent magnet (PM) Controller, three-phase voltage Source invertor and a three-phase permanent magnet synchronous motor with sinusoidal back electromotive force is used. An interior Permanent magnet controller implements a torque based, field-oriented controller for an internal permanent magnet synchronous machine (PMSM) with an optional outer-loop speed controller. The torque control implements strategies for maximizing the torque amp (MTPA) and weakening the magnetic flux. A three-phase voltage source invertor generates line-to-neutral voltage which commands for a balanced three phase load.
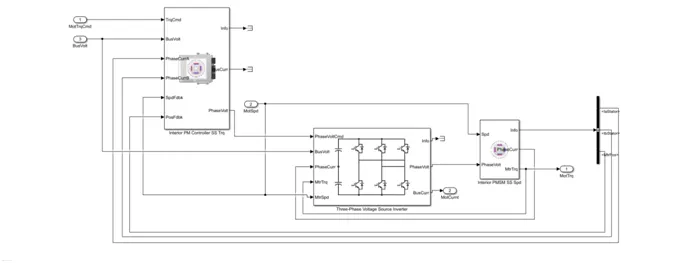
fig:-1.7
DYNAMIC GENERATOR:- Interior permanent magnet synchronous motor (PMSM) with controller.
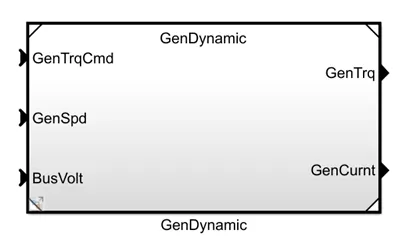
The dynamic generator uses similar components as that of dynamic motor. The only difference is that the dynamic generator uses the electrical energy to charge the battery and the battery is charged through regenerative braking.
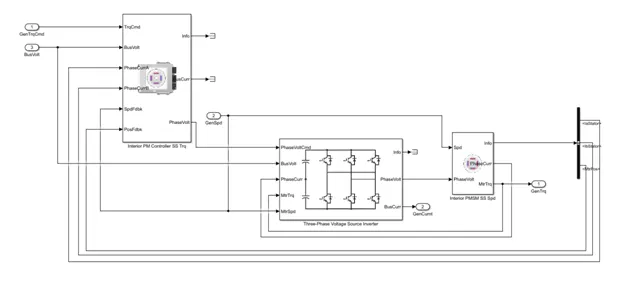
fig: 1.8
Transition from Mapped model to Dynamic model:-
- Open the “Powertrain Blockset” from the documentation window.
- Run the conventional vehicle reference application and examine the performance parameters.
- Explore the Hybrid Electric Vehicle Multimode Reference Application.
To create and open a working copy of the HEV reference application project, enter autoblkHevStart.
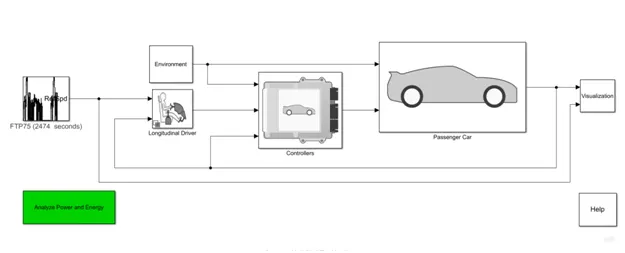
fig: 1.9
- Open the “Passenger car” block from the HEV application. It contains the Engine, Electric Plant and Drivetrain.
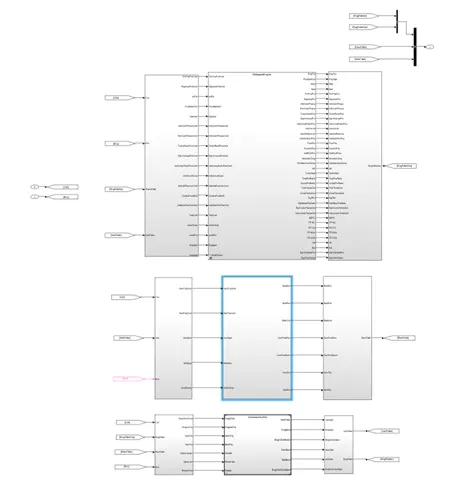
fig: 1.10
- The Electrical plant subsystem contains a Battery, Motor and Generator. The Motor subsystem has Mapped Generator and Dynamic Motor whereas the Generator subsystem has Mapped Generator and Dynamic Generator.
- The Engine subsystem contains a Mapped Engine and Dynamic Engine.
- The model can be switched from Mapped model to the Dynamic model with the help of “UPDATE MODEL”. Now, the model is capable to run on the actual data after simulation is completed.
- Now, the parameters can be configured from the dynamic model.
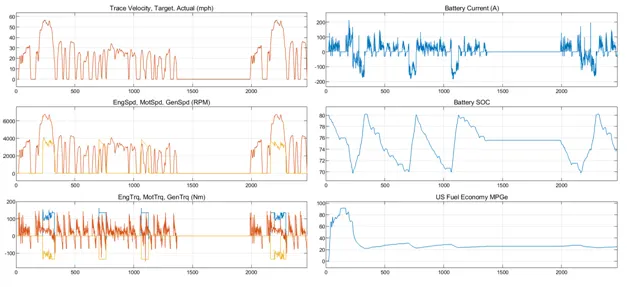
fig: 1.11
CALCULATION OF VEHICLE MODEL: The visualization block contains all the information related to the performance calculations of the system. The performance and Fuel economy scope shows the results obtained.
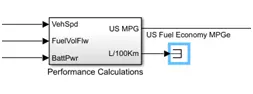
Miles per Gallon:- a) It is a rating determined by how far a car can travel on a gallon and it is measured in miles per gallon.
b) To convert m^3 to gallons, it’s helpful to know that 264.172 gallon is the same as one cubic meter of fuel volume and to convert meter to miles, 0.000621371 mile is equal to one meter.
c) As a result, dividing 0.000621371 by the car’s fuel volume in 264.172 gallon will give it’s figure in mpg.
d) The fuel efficiency is dependent on the mpg figure i.e, the more fuel efficient a car is, the higher the mpg figure. These figures are used by states to regulate the car manufactures .
e) The EPA has set new labels for the fuel economy of alternative fuel and advance technology vehicles with conventional internal combustion engine.
f) A common fuel economy metric is adopted for miles per gallon of gasoline equivalent (MPGe). A gallon of gasoline equivalent means the number of kilowatt-hours of electricity that is equal to the energy in a gallon of gasoline incase of an electric vehicle.
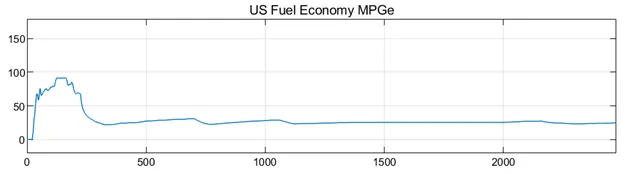
fig:1.12
FACTORS CONSIDERED TO MODEL FUEL FLOW
The vehicle speed, volume of fuel flow and the battery power are taken as input from port1, port2 and port3 respectively.
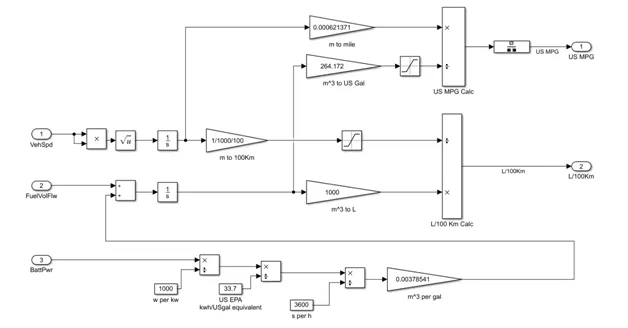
fig: 1.13
Vehicle Speed:- a) When vehicle speed increases,there is increase in fuel consumption and fuel economy decreases due to air resistance and rolling resistance. Thus, the vehicle speed in the given model is determined by the respective driving cycle.
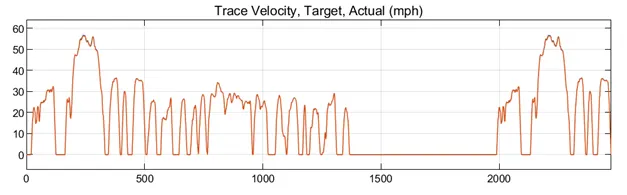
fig: 1.14
b) The distance covered by the vehicle is determined by integrating the vehicle speed. Thus, the total distance covered by the vehicle can be estimated.
c) The vehicle speed has also been used to calculate MPG (miles per gallon) for fuel economy.
Battery Power:- a) The Battery is used to power the electric motors of Hybrid Electric Vehicles (HEV). These batteries are usually rechargeable batteries and are typically lithium-ion batteries.
b) The Battery power is used for short durations. The HEV Batteries operate momentarily and share similarity with a starter battery by applying short power bursts for acceleration rather than long, continous discharges as with the EV.
c) In the given model the battery power is converted from watt-second to kilowatt-hour. Further, the model kwh is equal to the gallon equivalent as set by the EPA.
d) A dynamic embedded controller determines the engine operating point that minimizes Brake-specific fuel consumption while meeting or exceeding power required by the battery charging and vehicle propulsion subsystems.
e) The Battery State of Charge (SOC) for HEV in the given model is within the limits of 70% to 80%.
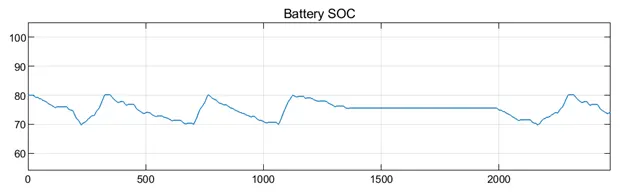
fig: 1.15
Volume of Fuel Flow:- a) The fuel taken from the fuel tank is passed through primary filter and mechanical lift pump which is further passed through the main engine fuel filter. The fuel is then taken to the fuel injection pump which is fed to the cylinders.
b) The volume of Fuel Flow and the Battery power is added which is further integrated. The obtained result is multiplied to 1000 using the Gain parameter block. This gives us the required conversion from one cubic meter to litres.
c) The fuel flow depends on the Driving cycle. Thus, regenerative braking takes place when battery is charging and the fuel economy is increased.
CONCLUSION:- In the given model the difference between the Mapped and Dynamic model has been stated. The model is successfully changed from Mapped to Dynamic model from the passenger car subsystems(fig: 1.9). The model calculates miles per gallon from the performance and fuel economy plot (fig: 1.12). The various factors responsible for the fuel flow has been studied under the given model (fig: 1.13).
WIDE OPEN THROTTLE (WOT)
AIM:- To run and simulate the results of HEV and pure EV.
OBJECTIVE:- a) To Run the HEV reference application with WOT drive cycle.
b) To change the grade and wind velocity in the environment block.
c) To Compare the simulated results of Hybrid and pure Electric powertrains.
THEORY:-
Wide Open Throttle response refers to an Internal combustion engine maximum intake of air and fuel that occurs when the throttle is placed inside the carbotor or throttle body are wide open providing the least resistance to the incoming air. Incase of an automobile the accelerator is pressed fully. At WOT manifold vacuum decreases, the higher manifold pressure in turn allows more air to enter the combustion cylinders and thus additional fuel is required to balance the combustion reaction. The additional air and fuel reacting together produce more power.
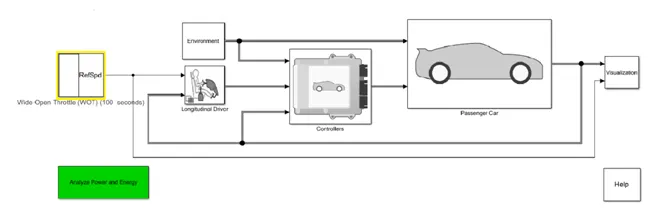
fig: 2.1
HYBRID ELECTRIC VEHICLE POWERTRAIN
The Hybrid Electric Vehicle reference application represents a full multimode Hybrid Electric Vehicle (HEV) model with an internal combustion engine, battery, transmission, motor, generator and associated powertrain control algorithm. The HEV multimode reference application is configured with:
- Mapped motor and generator
- 5L spark-ignition (SI) dynamic engine
The diagram shows the powertrain configuration:-
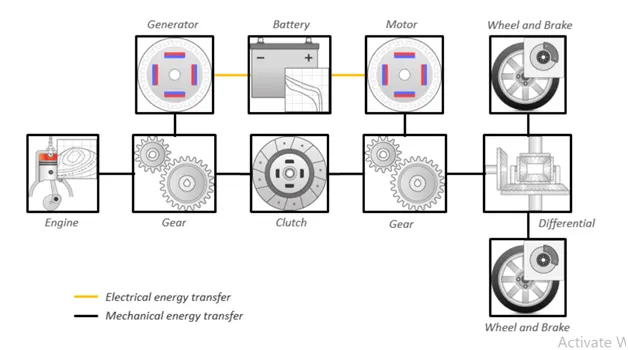
fig: 2.2
The model analyzes the energy consumption. It uses the power units and energy units properties to set the units. The results are used to analyze the energy and power losses at the component and system level. The final energy values for each subsystem are given below:-
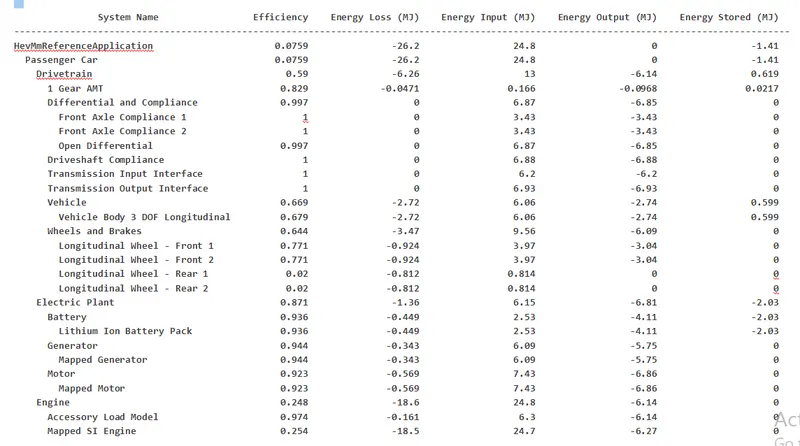
. 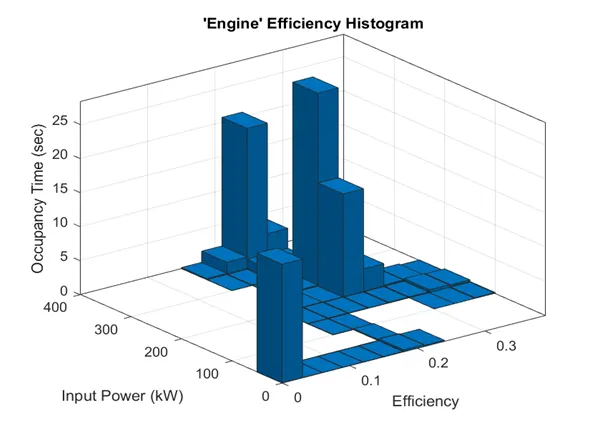
fig: 2.3
The Wide Open Throttle drive cycle has been applied to the HEV reference application (fig: 2.1). The Wide Open Throttle is used to configure initial reference speed, final reference speed and time. Thus, a step response is applied to the drive cycle as a source. The Simulation result for the WOT response is given below:
OBSERVATION:- The results obtained from HEV is given below:-
- When Grade = 0 and Wind velocity = 0m/s.
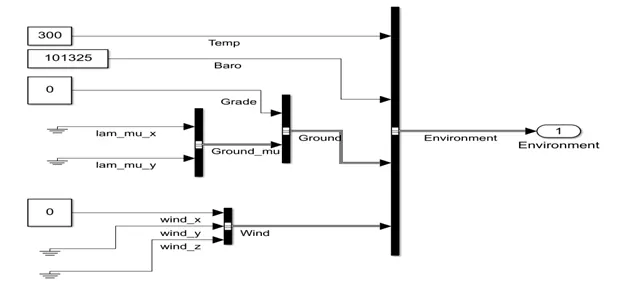
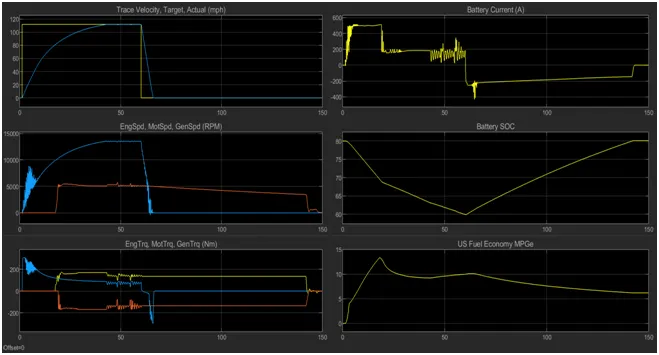
fig: 2.4
- At starting, the vehicle is at rest.When the throttle is pressed at 112mph the vehicle starts accelerating but the actual path followed is different. This difference is due to the limitation of the motor power. The motor power is limited by the Battery Current.
- The vehicle accelerates rapidly till 112mph in 42.636sec. At 112mph,the motor runs at a speed of 13540rpm.
- At starting due to high demand of current, the peak value of the Current is 514A at 6.7sec. This is the maximum value of the current provided by the given model for the Battery pack.
- The Battery discharges from 80% to 60% in 60 seconds. However, the Battery discharges rapidly from 80% to 68% for the first 20sec, this is due to the high demand of current.
- When brakes are applied the electric motor switches to generator mode. The wheels transfer the Kinetic energy via the drivetrain to the generator. Through its rotation the generator converts a portion of the energy to electrical energy. This energy is stored in a high voltage battery .
- The generative electric torque of the motor which is the result of energy generation decelerates the vehicle. At low speed, the electric motor can no longer supply sufficient generative braking torque and the friction brake must be activated. To maintain the required deceleration the braking torque from the friction brake is continously adapted to the current genrative braking torque. This process is known as torque blending.
- In regenerative braking mode, the motor speed is positive and the motor torque is negative. Thus, the motor power also becomes negative. This states that the Battery is in charging mode and the motor acts as a generator. The regenerative braking helps to extend the range and lower fuel consumption and CO2
- The current will grow negative, since the back emf voltage is greater than the effective voltage. It drops down to -412A when the battery is charging and the engine starts running at 172Nm.
- The maximum discharge current limit is higher than the maximum charge current limit. So, the vehicle Battery is discharged 20% in 60seconds. After 20seconds the Battery discharges slowly.
- The fuel economy is more efficient when the battery is discharging and less efficient when the battery is charging. The maximum value of fuel economy is 13.35mpg. However, the average fuel economy is 8.2mpg.
2. When Grade = 8 and wind velocity = 10m/s.
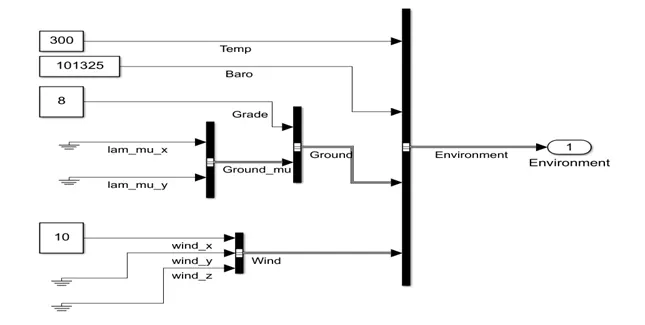
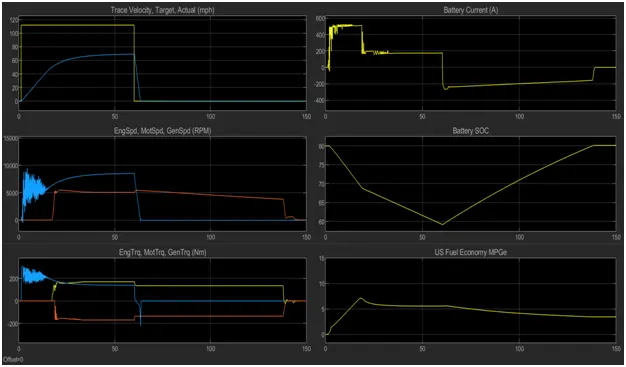
fig: 2.5
- The vehicle accelerates upto 69mph in 60sec. It is evident that the vehicle is not capable to achieve its target velocity. After it has achieved its maximum speed it starts to decelerate by applying brakes. The vehicle comes to rest within 4sec i.e, at 64 sec and remains at rest till the simulation time is completed.
- The difference in the Target path and the Actual path is due to the limitation of the motor power. The motor power is limited by the motor current.
- The maximum current is drawn at starting i.e, 529A at 10sec.
- The demand is high at starting therefore, the motor achieves its maximum speed i.e, 9433rpm at 4.3sec and its maximum torque i.e, 307Nm at 1.8sec. Soon, the motor speed drops down and then again it moves upward to achieve its maximum speed i.e, 8523rpm. The motor speed reduces when the vehicle decelerates and comes to rest.
- The regenerative Braking mode is generated when the vehicle is in deceleration mode. The Kinetic Energy released is stored in order to charge the Battery. Therefore, the Battery is in charging mode after 60sec.
- During deceleration the motor torque becomes negative and drops down to -220Nm due to decrease in motor speed. Later, it becomes zero when the vehicle is at rest.
- The Engine generates a maximum torque of 172Nm at 20sec. During this period the current drops down rapidly to 167A. The Engine torque remains constant at 170Nm. However, the Engine torque reduces to 135Nm and remains constant till the Battery is in charging mode.
- The Current will grow to -265A when the vehicle is in regenerative braking mode.
- The vehicle becomes less fuel efficient when the grade and wind velocity is increased from 0 to 8 and 10m/s respectively. The maximum value of the fuel economy is at 18sec and uses 7.1mpg. However, the average fuel economy is 5mpg for the given Driving cycle.
From the above results, it is evident that the vehicle performance and fuel economy is affected by increasing the Grade and Wind velocity. The Actual speed, motor speed, Battery Current and Fuel economy reduces with increase in the value of the Grade and Wind Velocity. However, the Battery SOC does not get affected for the given HEV reference model.
ELECTRICAL VEHICLE POWERTRAIN
The Electric Vehicle reference application represents a full electric vehicle model with a motor, generator, battery, direct-drive transmission, and associated powertrain control algorithm. The EV reference application is configured with a mapped motor and battery. The diagram shows the powertrain configuration:-
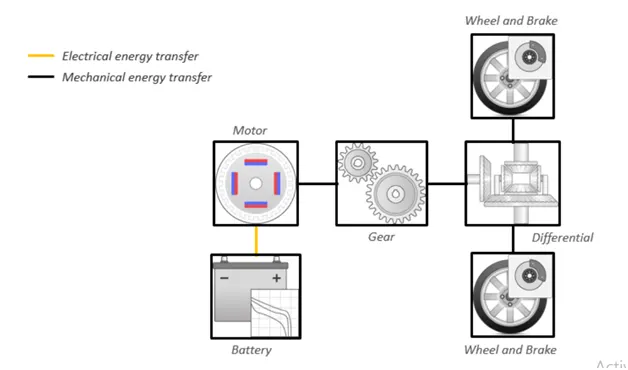
fig: 2.6
The model analyzes the energy consumption. It uses the power units and the energy units properties to set the units. The results uses to analyze power and energy losses at the component and system level. The final energy values for each subsystem is given below:-
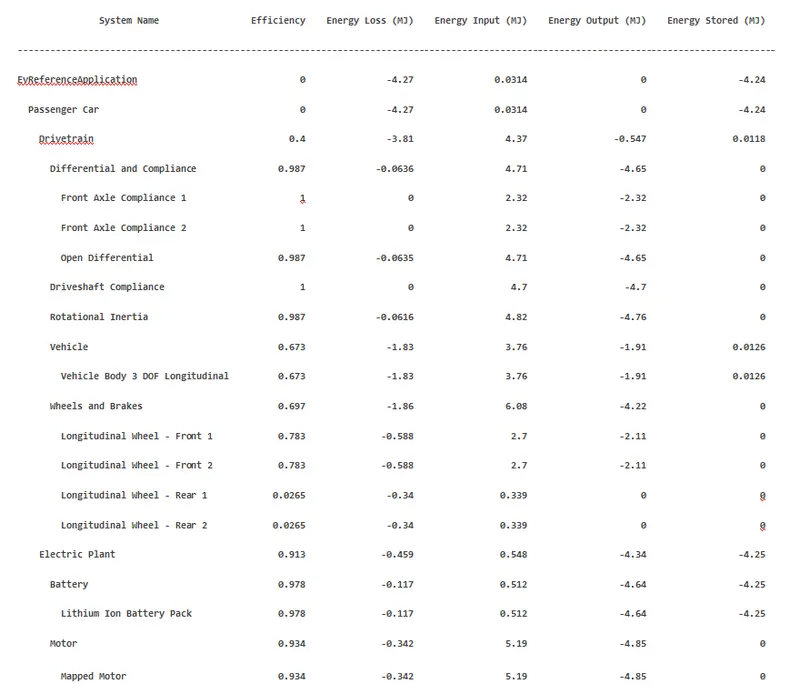
OBSERVATION:- The result obtained from the pure EV is given below:-
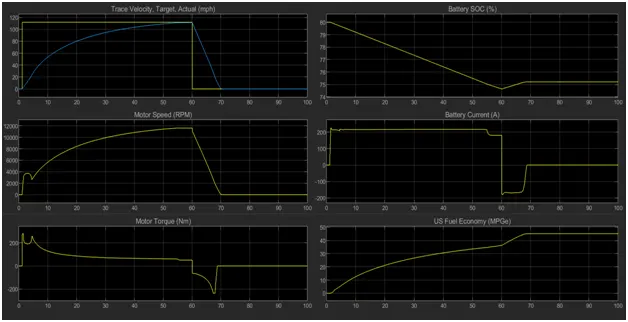
fig: 2.7
- The actual velocity of the Electric vehicle is 111mph. The difference between the actual velocity and the target velocity is due to the Battery Current. The motor power is limited by the Battery Current.
- The EV starts decelerating after 60sec. The deceleration caused due to braking results in the release of Kinetic Energy. The Energy is further stored to charge the Battery pack. However, the regenerative braking does not work when the battery is charged to 76%.
- The motor starts and runs to its maximum speed of 11630rpm in 60sec. However, the motor starts decelerating when the brakes are applied. The energy efficiency is based on the losses inside the motor during power conversion from electrical to mechanical energy. The motor has an efficiency of 93.4% and energy loss of -0.342MJ.
- The motor generates a torque that is greater than the load torque which indicates that the motor is accelerating. The motor torque is maximum at starting due to high demand of current. The maximum value of motor torque is 280Nm. However, after 60sec the load torque becomes greater than the generating torque.
- The battery discharges from 80% to 74.5% when the EV is accelerating however, when the motor starts to act as a generator the battery is starts to get charged.
- The current is constant at 216A for 60sec. The current will grow negative since, the back emf voltage is larger than the effective voltage. It drops down to -168A when the battery is charging.
- The fuel economy of an EV increases when regenerative braking takes place. The maximum value of fuel economy is 45mpg. However, the average fuel economy is 32mpg for the given Driving Cycle.
COMPARISON BETWEEN HEV AND EV
The table shows the comparison between the HEV and EV through simulation of script file and Performance and fuel economy scope of the respective models.
|
S.No |
HEV |
EV |
|
1. |
The Hybrid Electric Vehicle operates on an electric plant, drivetrain and an engine plant that runs on fuel. |
The Electric Vehicles operates on an electrical plant and drivetrain. |
|
2. |
The average efficiency of electric plant, drivetrain and engine 87.1%, 59% and 24.8% respectively. Therefore, it is less efficient. |
The average efficiency of electric plant and drivetrain is 91.3% and 40% respectively. Therefore, it is more efficient. |
|
3. |
The motor runs at a maximum rotational speed of 13540rpm having an efficiency of 92.3%. |
The motor runs at a maximum rotational speed of 11630rpm having an efficiency of 93.4%. |
|
4. |
The motor is more powerful due to high torque and rotational speed of motor. |
The motor is less powerful due to less torque and rotational speed of motor. |
|
5. |
The battery SOC is charged full from 60% to 80% due to the combination of Engine and regenerative braking. The HEV is independent of charging station. |
The battery SOC is charged from 74.5% to 75.5% during regenerative braking only. The pure EV are dependent on charging station for recharging of battery. |
|
6. |
They have high performance and range capacity. |
They are limited by performance and range capacity. |
|
7. |
The average fuel economy is 8.2mpg. Therefore, it consumes more fuel. |
The average fuel economy is 32mpg. Therefore, it consumes less fuel. |
The above comparison shows that Pure electric vehicles are more suitable for urban and short-distance passenger travel whereas Hybrid Electric Vehicles are more suitable for long-distance and large commercial vehicles.
CONCLUSION:- The HEV reference application with WOT response is simulated successfully (fig: 2.4). The grade and wind velocity is changed from the environment block (fig: 2.6). The results are obtained from the Performance and fuel economy scope and by running the script file for the given model. The HEV and pure EV are compared on the basis of efficiency, performance and range.