Week-11 Challenge: Braking
BRAKING
AIM :- To calculate braking energy using a defined drive cycle and contour plots for finding efficiencies of motor.
OBJECTIVE :- a) To calculate braking energy using a defined driving cycle.
b) To understand limitation of electric motor braking torque at a high speed.
c) To understand the co-ordination of electrical and mechanical brakes.
d) To plot contour of given motor speed, torque and efficiency values using MATLAB program.
THEORY :-
One of the most important features of electric vehicles (EVs) and hybrid electric vehicles (HEVs) is their ability to recover significant amounts of braking energy. The electric motors in EVs and HEVs can be controlled to operate as generators to convert the kinetic or potential energy of the vehicle mass into electric energy that can be stored in the energy storage and reused.
The braking performance of a vehicle is undoubtedly one of the important factors to affect vehicle safety. A successfully designed braking system for a vehicle must always meet two distinct demands. Firstly, in emergency braking, it must bring the vehicle to rest in the shortest possible distance. Secondly, it must maintain control over the vehicle’s direction. The former requires that the braking system be able to supply sufficient braking torque on all the wheels. The latter requires braking force to be distributed on all the wheels equally.
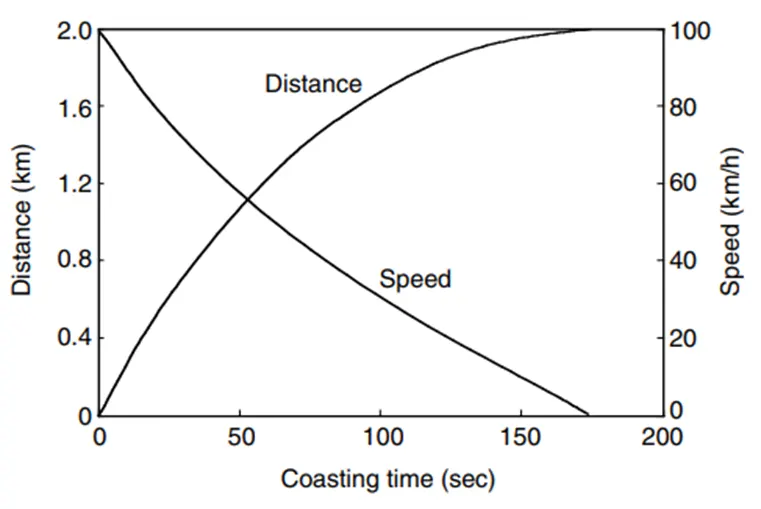
Fig: 1.1
Braking power and braking energy consumed by the front and rear wheels are closely related to the braking forces on the front and rear wheels. A full understanding of the braking force, braking power, and braking energy consume by the front and rear wheels in typical drive cycles is helpful in the design of regenerative braking systems.
Energy Consumption in Braking
When vehicles are driving with a stop-and-go pattern in urban areas, a significant amount of energy is consumed by frequent braking, which results in high fuel consumption.
A test cycle has been developed by using an MS Excel. The cycle is intended to correspond to realistic driving patterns in different conditions. During these tests the vehicle speed is almost constantly changing, and thus the performance of all the other parts of the system is also highly variable, which makes the computations more complex. Therefore, the operating cycle created is used to calculate the Braking Energy of the vehicle:
MS Excel file : https://docs.google.com/spreadsheets/d/1mFyw6yXMGOB8ugCSQxGnKhGqxzkN2JW6/edit?usp=sharing&ouid=105698778706441167018&rtpof=true&sd=true
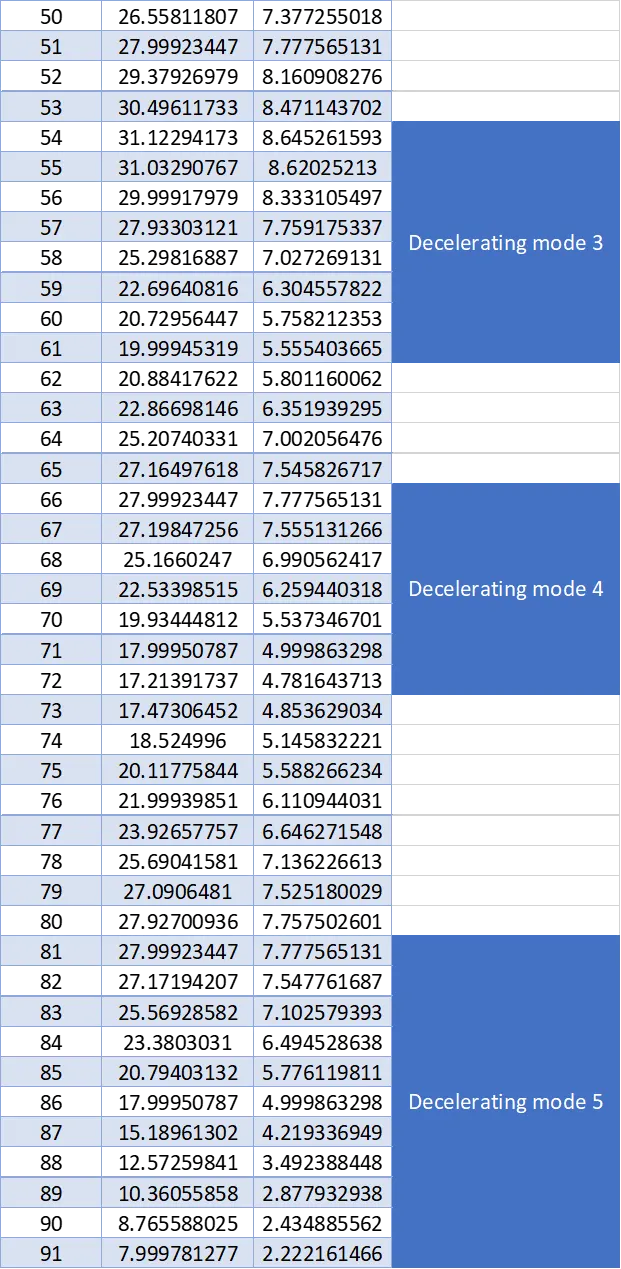
Fig: 1.2
This cycle is a simplified version of Indian Urban Driving Cycle, shown in Figure 1.3, which has the advantage that it only lasts 101 seconds, and so has only 101 data points., and for each second there is a different speed, as shown in Figure 1.2
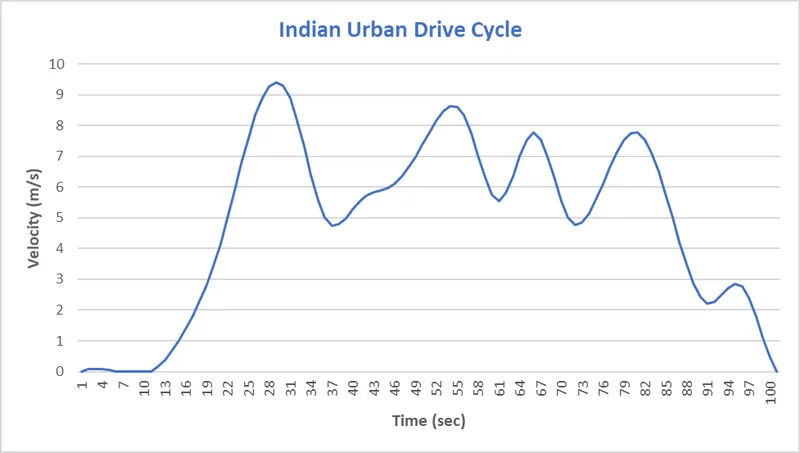
Fig: 1.3
This particular energy with conventional braking will be applied based on the classical brakes or the friction brakes. The amount of energy required for braking is,
Braking energy = 0.5*m*v2
m = Total weight of vehicle
v = Vehicle speed in m/s
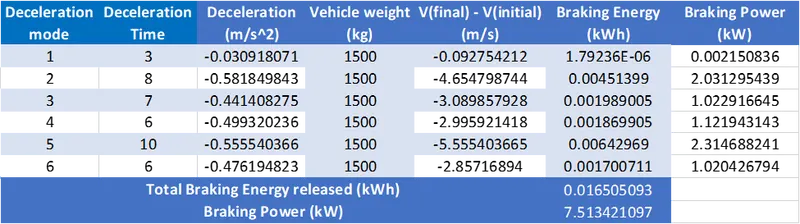
Fig: 1.4
Matlab code :https://drive.google.com/file/d/1r26J26vBeBhgj9VQ6CAuMaeaalBIbQ-i/view?usp=sharing
close all
clc
N=length(V); %Length of data
m=1500; %weight of Vehicle
%Loading the drive cycle
D=xlsread('indiandrivecycle','A2:C102');
%Time taken
T=D(:,1);
%Velocity of the vehicle
V=D(:,2);
%Converting Velocity in km/h to m/s
V=V./3.6;
for i=1:(N-1)
if V(i)>V(i+1)
v(i)=V(i+1)-V(i);
BE(i)= (0.5.*m.*(V(i)-V(i+1))^2)/(1000*3600); %Braking Energy
end
end
fprintf('Total Braking Energy is %d',sum(BE));
fprintf('Average Brake Energy is %d',mean(BE));
%Plot
figure(1)
subplot(2,1,1)
plot(T,V,'linewidth',1,'color','b')
xlabel('Time (sec)')
ylabel('Velocity (m/sec)')
title('Drivecycle')
subplot(2,1,2)
plot(BE,'linewidth',1,'color','r')
xlabel('Time (sec)')
ylabel('BE (kWh)')
Procedure :
- Create a mscript file in edit window .
- Find the length of the array V using ‘length()’.
- Load the drive cycle in workspace using ‘xlsread(‘’)’.
- Load the time and velocity values in an array.
- Convert the values in the matrix V from km/h to m/s.
- Create a ‘for loop‘ for performing iteration.
- Use if statement condition to evaluate the deceleration mode.
- Define the Braking energy inside the if statement.
- Evaluate the program, Save the M-file in current folder and Run the code.
- Plot the required data and print the result in the command window.
OUTPUT :- A significant amount of energy is consumed by braking. The graph plotted below in fig: 1.5 shows the Braking Energy released during decelerating mode. Braking a 1500kg vehicle for the given driving cycle consumes about 0.0165kWh of energy (0.5*m*v2).
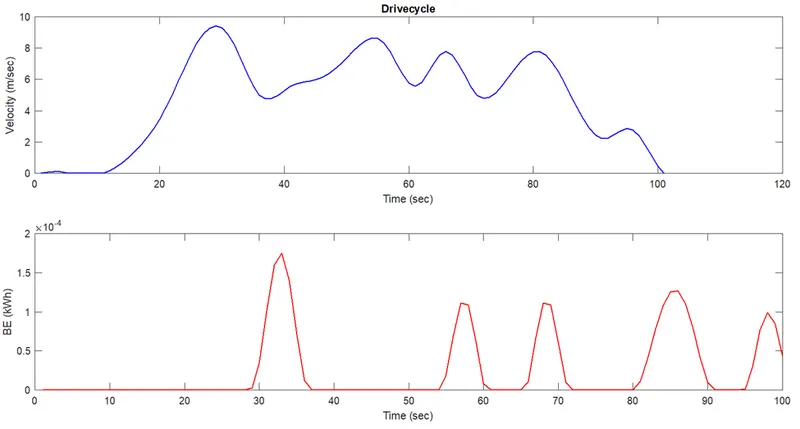
Fig: 1.5
However, under no brake condition the vehicle stops at very large distance and time, and based on the different driving cycle the amount of braking is going to get affected.
BRAKE CONTROL STRATEGIES
Regenerative braking in EVs and HEVs adds some complexity to the braking system design. There are two main problems: one is the distribution of braking forces required between the regenerative brake and the mechanical friction brake so as to recover the kinetic energy of the vehicle and the other is the distribution of the total braking forces on the front and rear axles so as to achieve a steady state braking. Usually, regenerative braking is effective only for the driven axle. The traction motor must be controlled to produce the proper amount of braking force for recovering the kinetic energy as much as possible and, at the same time, the mechanical brake must be controlled to meet the braking force command from the driver.
The contour plot in fig: 1.4. shows the speed-torque characteristics for GMEV1 traction motor. This characteristic naturally matches that of an electric motor that has a constant torque at the low-speed region and a constant power at the high-speed region.
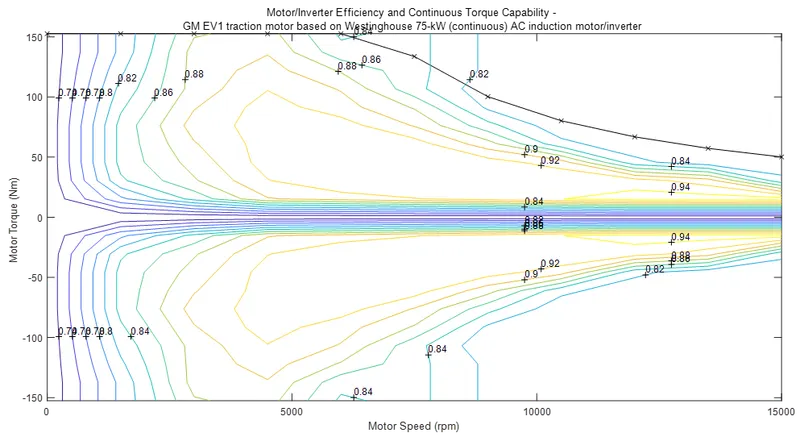
Fig: 1.6
It should be noted that the maximum regenerative braking force produced by an electric motor is closely related to the electric motor’s speed. At low speed (lower than its base speed), the maximum torque is constant and therefore higher acceleration power is possible. However, at high speed (higher than its base speed), the maximum torque decreases hyperbolically with its speed. Therefore, the mechanical brake torque at a given vehicle deceleration varies with vehicle speed.
But during braking, torque is negative. This is because as the motor operates in the field weakening region or above base speed, torque tends to be lower. Therefore, at low speed torque is high whereas at high speed torque is low. Thus, the braking torque of an electric motor is not as high as accelerating or starting torque.
BRAKING SYSTEM FOR EVs AND HEVs
Since, the braking torque required is much larger than the torque that an electric motor can produce. In EVs and HEVs ,therefore, mechanically frictional braking systems must coexist with electrically regenerative braking. Thus, the proper design and control of both mechanical and electrical braking systems are major concerns. Therefore, there are three different brake control strategies:
1. Series braking:- The braking force on the front wheels (driven axle) is divided into two parts: regenerative braking force and mechanically frictional braking force whereas the braking force on the rear wheels should be developed in order to meet the total braking force requirement. When the braking force demanded on the front wheel is less than the maximum braking force that the electric motor will produce, only electrical regenerative braking. When the commanded braking force is greater than the available regenerative braking force, the electric motor will operate to produce its maximum braking torque, and the remaining braking force is met by the mechanical brake system.
When the vehicle is braked with an acceleration rate, the braking forces on the front and rear wheels can be varied in a certain range. In this case, regenerative braking should be used in priority. If the available regenerative braking force (maximum braking force produced by the electric motor) is in this range.
- Optimal braking feel: The series braking system with optimal feel consists of a braking controller that controls the braking forces on the front and rear wheels. The control objective is to minimize the stopping distance and optimize the driver’s feel. The shortest braking distance and good braking feel require the braking forces on the front and rear wheels to follow the ideal braking force distribution curve I.
- Optimal energy recovery: The principle of the series braking system with optimal energy recovery is to recover the braking energy as much as possible in the condition of meeting the total braking force demanded for the given deceleration.
It should be noted that the series brake with both optimal feel and energy recovery needed active control of both electric regenerative braking and mechanical braking forces on the front and rear wheels. At present, such a braking system is under research and development
2. Parallel braking: The parallel brake system includes both an electrical (regenerative) brake and a mechanical brake. The parallel brake system has a conventional mechanical brake which has a fixed ratio of braking force distribution on the front and rear wheels. Regenerative braking adds additional braking force to the front wheels, resulting in the total braking force distribution curve. The mechanical braking forces on the front and rear axles are proportional to the hydraulic pressure in the master cylinder. The regenerative braking force developed by the electric motor is a function of the hydraulic pressure of the master cylinder, and therefore a function of vehicle deceleration. Because the regenerative braking force available is a function of motor speed and because almost no kinetic energy can be recovered at low motor speed, the regenerative braking force at high vehicle deceleration is designed to be zero so as to maintain braking balance. When the demanded deceleration is less than this deceleration, regenerative braking is effective.
The parallel braking system does not need an electronically controlled mechanical brake system. A pressure sensor senses the hydraulic pressure in the master cylinder, which represents the deceleration demand. The pressure signal is regulated and sent to the electric motor controller to control the electric motor to produce the demanded braking torque.
3. Antilock Brake System (ABS): Active control of the braking force (torque) of the electric motor is easier than the control of the mechanical braking force. Thus, antilock in braking with an electric brake in EVs and HEVs is another inherent advantage, especially for a vehicle with an electric motor on four wheels.
The fluid is discharged into the fluid accumulator through the electronically controlled three-port switches. This emulates the braking feeling of a conventional braking system. After receiving a braking pressure signal, the overall controller unit determines the braking torques of the front and rear wheels, regenerative braking torque, and mechanical braking torque, according to the traction motor characteristics and control rule. The motor controller commands the motor to produce correct braking torque, and the mechanical braking controller commands the electrically powered braking actuator to produce correct braking torques for each wheel. The braking actuators are also controlled to function as an antilock system to prevent the wheels from being locked completely.
MOTOR EFFICIENCY PLOT
The motor chosen for any application should be as efficient as possible. The operating range of electric motors, and where they operate most efficiently can be determined using contour plot. Furthermore, this can be done very effectively and quickly with MATLAB. A program for plotting efficiency contours for electric motor is:
Matlab script file :https://drive.google.com/file/d/1VtgngFh_ZgEW8Kc6z-Krfqb3ugGCpfj1/view?usp=sharing
clear all
close all
clc
speed = linspace(0,1000);
torque = linspace(0,500);
kc = 0.2; %Copper loss constant
ki = 0.006; %Iron loss constant
kw = 0.000010; %Windage loss constant
k = 20; %constant motor loss
[x,y] = meshgrid(speed,torque);
copper_loss = (y.^2)*kc;
iron_loss = x*ki;
windage_loss = (x.^3)*kw;
output_power = x.*y;
input_power = (copper_loss+iron_loss+windage_loss+output_power+k);
efficiency = (output_power./input_power);
n = linspace(0.7,0.95,10);
contourf(x,y,efficiency,n);
title('speed-torque efficiency')
xlabel('speed(rad/s)')
ylabel('torque(Nm)')
colorbar
Procedure :
- Set Arrays for speed and torque of the motor.
- Assign values to motor constants.
- Make a meshgrid for speed and torque of the motor.
- Define copper losses, iron losses and windage losses.
- Set the efficiencies for which the contour will be plotted.
- Plot the contour of the power output.
Output : This program was used to give the graph shown in Figure 1.7. A plot showing the efficiency of a motor at different torque-speed operating points. It shows the circular contours characteristic of the brushless DC motor.
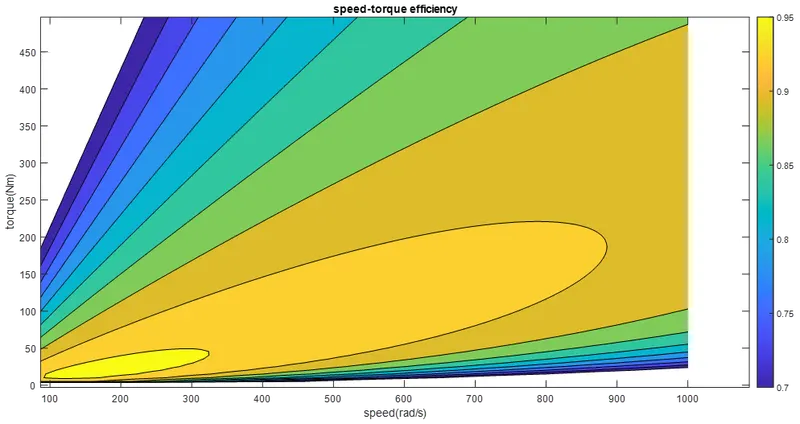
Fig: 1.7
The contour plot contains different color lines. These color lines represent different efficiencies for speed-torque characteristics. The x-axis corresponds to speed, y-axis to torque and z-axis to efficiency. Basically, it is a 3D surface where the contours are representing same values for a typical curve. The yellow curve represents the maximum motor efficiency of 95%, but this efficiency is only obtained for a fairly narrow range of conditions. It is quite possible for the motor to operate at well below 90% efficiency.
However, the efficiency of an electric motor is not so simple to measure. The problem is that it can change markedly with different conditions, and there is no single internationally agreed method of stating the efficiency of a motor.
CONCLUSION :- A drive cycle was developed using MS excel and braking energy of the vehicle was calculated. Then a mscript was developed in order to plot the braking energy curve with respect to the drive cycle. Also, we discussed the limitation of electric motor braking torque and understood the working of the electrical and mechanical braking system in EVs and HEVs. Further, the contour curve for motor speed, torque and efficiency using MATLAB code was developed.