Week -2
DOORBELL SIMULATION
AIM :- To make a simulink model of Doorbell using solenoid block.
OBJECTIVE :- a) To create a situation where the switch is closed for 2 seconds and then released.
b) To observe the physical movement of the plunger.
THEORY :-
When electric current is passed through a coil of wire, an electromagnet is created. Since, the electrical power is drawn from the battery which pulls the metal arm to hit the bell producing sound. Thus electric circuit is completed when the doorbell is pressed.
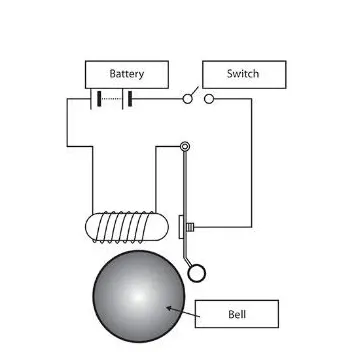
Fig 1.1 :-Doorbell
WORKING :-
A Pulse wave (fig :-1.3) has been used as an input signal having a phase delay of 2 seconds and having a period of 4 seconds. This signal is further fed to the electrical switch with the help of Simulink-PS Convertor. The Simulink-PS Convertor converts the simulink input signal to a physical signal. A switch is used to control the pulse signal. If the physical signal PS is greater than the threshold, then the switch is closed, otherwise switch is open. Here, the constant velocity source is Battery which is having infinite charging capacity. The battery is connected to both the switch and the solenoid which is the main source of electrical power. The solenoid block implements the electrical and mechanical characteristics. The mechanical part i.e, plunger is connected to an ideal translational motion sensor. This motion sensor measures velocity or displacement in a mechanical translational network. The sensor is ideal since it does not account for inertia, friction, delays, energy consumption and so on. The measurement is positive when the motion at R is greater than the motion at C. The measured physical signal is converted to simulink output signal with the help of PS-Simulink converter. Thus, the simulink output signal is fed to the scope. The scope enable us to plot the graph of the final result.
Matlab model:- https://drive.google.com/file/d/1jeZs2RZBC2BJOLfGyPb15lvLN-s6AyQt/view?usp=sharing
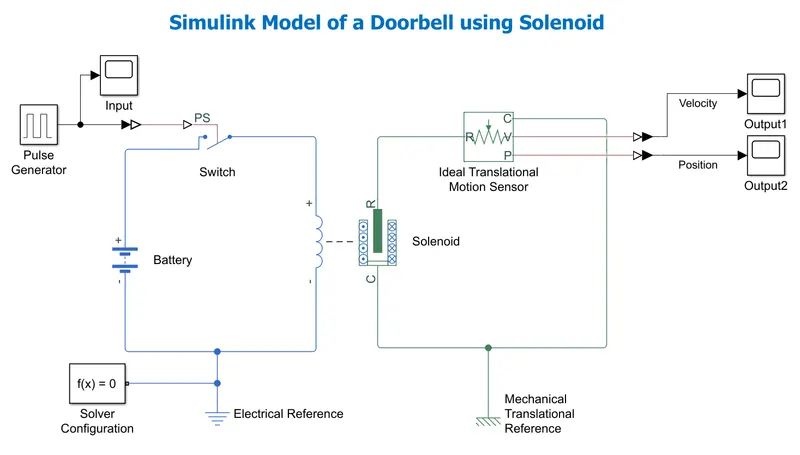
Fig :-1.2
Each physical system is represented by different set of colours i.e,
Electrical system – Blue colour
Mechanical system – Green colour
INPUT SIGNAL :- The input signal is generated with the help of Pulse Generator in scope 1.
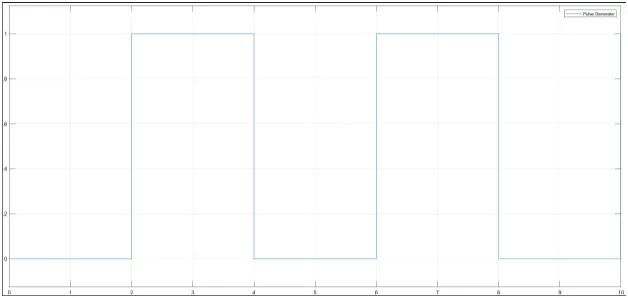
Fig :-1.3
OUTPUT 1 :- The output enable us to examine the velocity of the plunger at every 2 seconds in output 1. The maximum velocity of the plunger are 1.178e-02m/sec. The values of amplitude and frequency are 4.510e-04 and 250mHz. The rise time and fall time are 189.834ms and 5.121ms respectively. The pulse has a positive duty cycle and negative duty cycle whose values are 37.264% and 63.806%
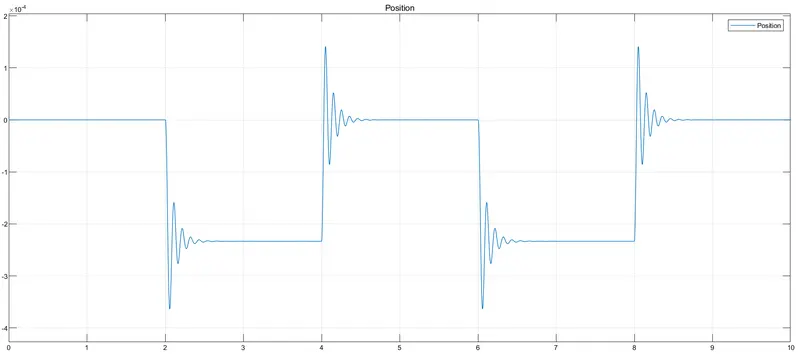
Fig : 1.5
OUTPUT 2 :- The output so obtained shows the position of the plunger displaced after every 2 seconds in scope 2. The values of amplitude and frequency are 2.374×10⁻⁴ and 250mHz respectively. The Rise time and Fall time are 20.849ms and 18.893ms respectively. The pulse has a positive Duty cycle and negative Duty cycle whose values are 49.855% and 50.145% respectively.
Fig : 1.6
CONCLUSION :- The simulink model was simulated successfully with the help of given blocks in Fig : 1.2. The result so obtained has been plotted successfully. However, It is evident from the given plot i.e, (Fig : 1.4 and Fig : 1.5) that harmonics appears after every 2 seconds resulting into displacement of the plunger and hitting the bell producing sound. This allows the switch to be closed for 2 seconds and then released. Hence, the doorbell rings after every 2 seconds.
THERMISTOR CONTROLLED FAN SIMULATION
AIM :- To make a simulink model of a fan controlled by thermistor.
OBJECTIVE :- a) To maintain temperature of 20°C from 0 to 10 seconds, 27°C from 10 to 30 seconds and 23°C from 30 to 50 seconds.
b) To turn ON Fan if the temperature is above 25°C otherwise turn off the Fan.
THEORY :- The fundamental blocks of Thermal, Electrical and Mechanical components have been used to model a thermistor controlled fan. The two major components involve a Thermistor and a D.C Motor which is explained below :-
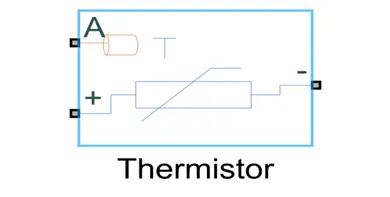
a) THERMISTOR :- It is a nonlinear resistor which is used as a heat sensitive device usually made up of semiconductor material whose :-
i) resistance changes very rapidly with change of temperature.
ii) temperature coefficient is very high.
iii) temperature coefficient can be both positive and negative.
The resistance of temperature T is
R=RₒeB(1/T-1/Tₒ)
Where,
- Rₒ is the nominal resistance at the reference temperature Tₒ
- B is the characteristic temperature constant
- The following equation describes the thermal behavior of the block
Q=Kdtc
Where,
- Q is the net heat flow into port A.
- Kd is the Dissipation factor.
- tc is the thermal time constant.
- dT/dt`is the rate of the change of temperature.
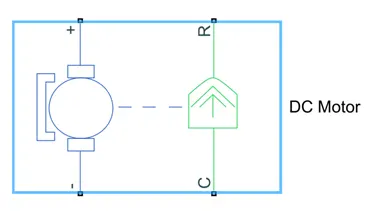
b) D.C Motor :- It is an electromechanical device which uses the interaction of magnetic fields and conductors to convert the electrical energy into rotary mechanical energy. It mainly consist of a “Stator” which is the stationary part and a “Rotor” which is the rotating part. It is commonly used actuator for producing continuous movement and whose speed of rotation can be easily controlled, making them ideal for use in application where speed control, servo type control or positioning is required. Thus, it is an ideal alternative for a Fan in a simulink model.
Matlab model:- https://drive.google.com/file/d/1bvtAwknKD_wPdA8oF0lWigO5KEotrwCq/view?usp=sharing
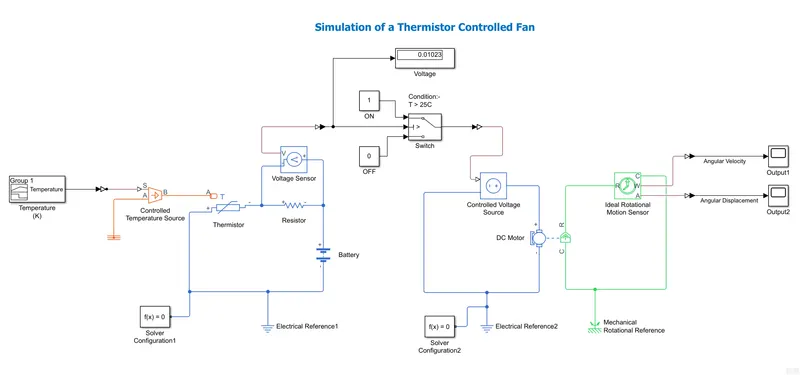
Fig: 2.1
WORKING :-
- A signal builder has been used to give a desired input signal (Fig 2.1) to the thermistor. The signal is converted to the desired physical signal with the help of Simulink-PS convertor.
- This signal is further transmitted to a controlled temperature source which act as an ideal energy source in a thermal network that can maintain a controlled temperature difference regardless of the Heat flow.
- A battery has been used which act as a constant voltage source having infinite charging capacity.
- A thermistor with negative temperature coefficient of resistance has been used for the input signal. When the supply voltage is switched on, the thermistor has a high resistance at first because it is cold. It thus limits the current to a moderate value. As it warms up, the thermistor resistance drops and an increased current flows through it.
- A voltage sensor is connected in parallel to the linear resistance which act as an ideal voltage sensor converting voltage measured between any electrical connection into a physical signal. The output from the volage sensor is fed to the switch having a threshold voltage of 0.01189V with the help of PS-Simulink convertor.
- The switch is closed when the temperature is above 25 otherwise it is open resulting into turning off the Fan.
- The output signal obtained from the switch is fed to the controlled voltage source with the help of Simulink-PS convertor into the D.C Motor.
- The D.C Motor helps to convert an electrical energy into a mechanical energy such that no electromagnetic energy is lost.
- The torque characteristics of the motor are measured with the help of an Ideal Rotational Motion sensor. The sensor is ideal since it does not account for inertia, delays, friction, energy consumption and so on.
- Thus, the final result is obtained in the form of the plot of angular velocity and angular displacement.
INPUT SIGNAL :- This signal is obtained with the help of Signal Builder. The temperature measured is in Kelvin and is represented on Y-axis whereas the time period is of 50 seconds taken on X-axis.
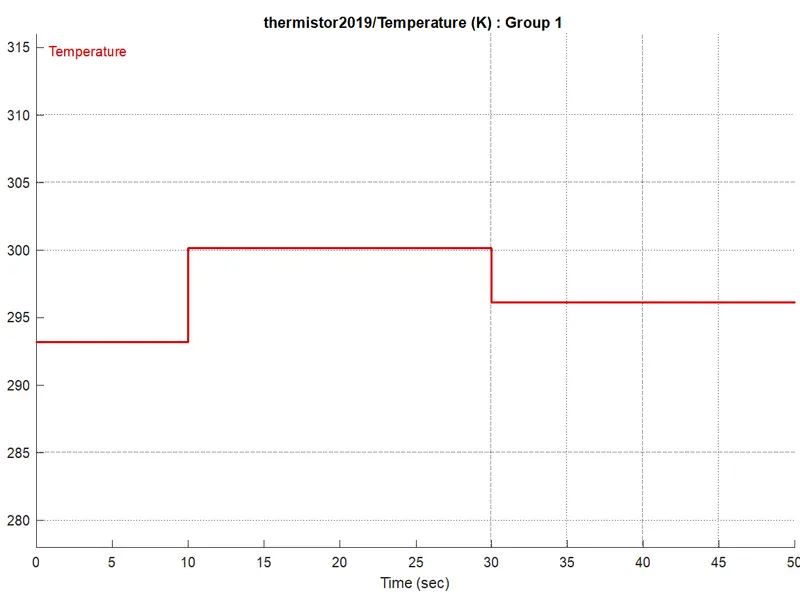
Fig : 2.2
OUTPUT SIGNAL 1 :- This signal enable us to examine the plot of Angular velocity with Time. The maximum value so obtained is 1.454×10³rad/sec at t=10.11seconds. Its Mean, Median and RMS values are 6.298×10²rad/sec, 1.758×10²rad/sec and 9.229×10²rad/sec respectively. The Rise time and Fall time are 17.777ms and 17,762ms respectively.
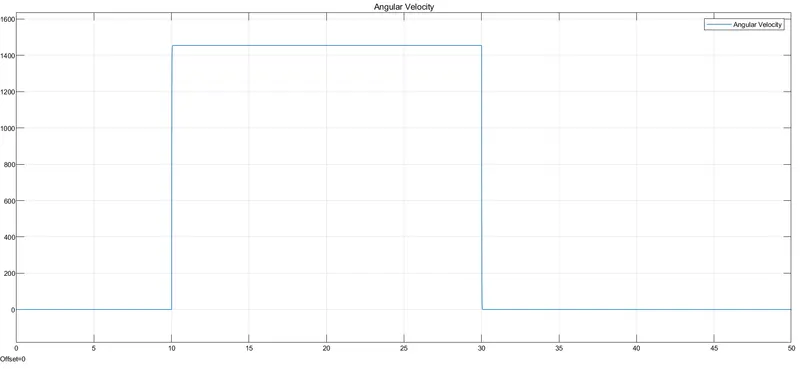
Fig : 2.3
OUTPUT SIGNAL 2 :- This signal enable us to examine the plot of Angular displacement with Time. The maximum value so obtained is 2.9090×10⁴rad at t=30.106seconds. The Mean, Median and RMS values are 1.361×10⁴rad, 3.242×10³rad and 1.959×10⁴rad respectively.
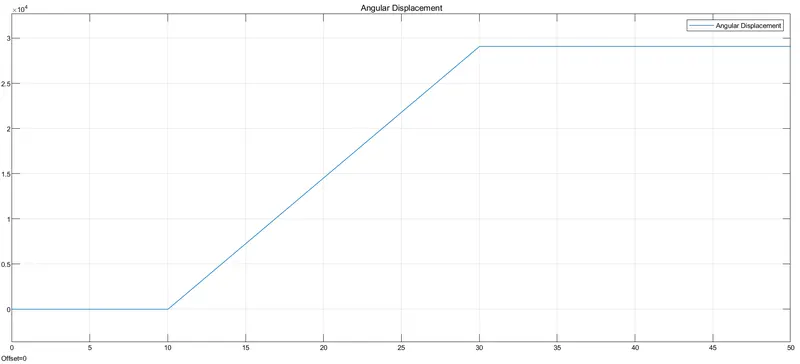
Fig : 2.4
CONCLUSION :- The simulation for the thermistor controlled fan was simulated successfully.The above result obtained from the plots in Fig 2.2 and Fig 2.3 it is evident that the fan is turn ON when the temperature is above 25 otherwise it is OFF. Hence, the fan was turned ON from 10second to 30seconds.