Week 3 - External flow simulation over an Ahmed body.
AIM
To simulate a flow over an Ahmed body with an air flow velocity of 25 m/s using Ansys fluent.
OBJECTIVES
- To create computational domain for the given Ahmed car body model in spaceclaim.
- To mesh the fluid domain with different mesh element size for different cases in order to do the grid independency test for those different cases.
- To run a external flow simulation over an Ahmed body by choosing the fluid as air and its properties, which flows at the inlet with velocity of 25 m/s.
- To run a external flow simulation over an Ahmed body by choosing the fluid as air and its properties, which flows at the inlet with velocity of 50 m/s.
- To find the drag co-efficient in the Ahmed body, and also to create velocity and pressure contours.
- To explain the reason for the negative pressure in the wake region.
- To explain the significance of the point of separation.
INTRODUCTION
We are going to simulate the flow over an Ahmed body with the air velocity of 25 m/s to capture the wake region that is formed behind the Ahmed body, which causes the drag force to the Ahmed body due the pressure difference of air in that region.
People working in vehicle aerodynamics use Ahmed body to validate their numerical model because experimental data from wind tunnel testing is available for Ahmed body. Once the numerical model is validated it is used to design new models of the ground vehicles.
THEORY
Ahmed Body
The flow around road vehicles (car, buses, truck) under normal operating conditions is principally turbulent. It is typically characterized by large scale separation and recirculating regions, a complex wake flows long trailing vortices, and interaction of boundary layer flow on vehicle and ground. In the design of ground vehicles, the crucial part is to decide the turbulent model according to the type of vehicle. The advanced modelling techniques and solving methods require hours and days of work for CPUs to calculate at precision. In aerodynamic flow around a vehicle, it is a three-dimensional flow and the design will have an influence on principle features such as the shape of the vehicle, aerodynamic drag, fuel consumption, noise production, and road handling.
By using wind tunnel experiments the designer have an understanding of airflow around the vehicle through extensive wind tunnel testing. But wind tunnel testing for every prototype is a time-consuming and costly process. Also, the reliability of the turbulence model and its long-lasting process of calculation is another challenge. In order to reduce time, it is necessary to use simplified computational technic and adopt a model to describe the mean effect of turbulence. Unfortunately, a simple turbulence model often fails to calculate the flow properly especially the position of flow separation on the rear slant is crucial in determining the aerodynamic drag but is an extremely difficult feature to calculate. To overcome the problem, S. R. Ahmed in 1984 described an Ahmed body with the standard results to test the various type of challenges and turbulence models. Ahmed body is a kind of baseline bluff body geometry for automobile bodies.
It is a simplified car body which is created mainly for comparing and so validating the computationally simulated results with the experimental results in order to check whether the simulation results are correct, and so can perform the external flow analysis computationally to reduce the drag force on the car by capturing the wake region formed behind the car surface.
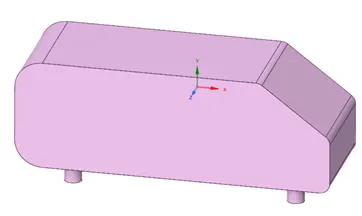
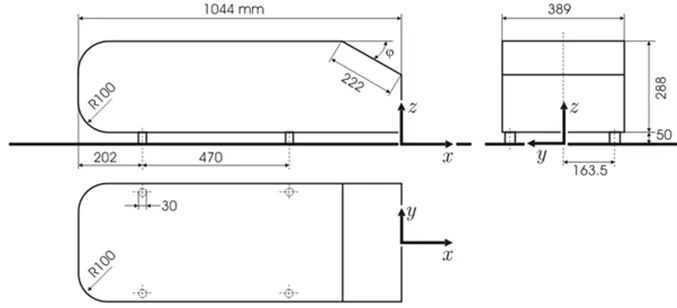
The Ahmed car body represents a generic car (passenger car) geometry which exhibits many of the flow features found in real-life cars despite its simplified geometry. The Ahmed body is a generic car model first proposed by Ahmed in 1984. All ground vehicles can be termed as bluff bodies moving close to the road surface. The analysed body is able to capture the essential features of the flow which characterize modern cars.
Importance in practical applications
The Ahmed body is a generic car body (a simplified vehicle model). The airflow around the Ahmed body captures the essential flow features around an automobile and was first defined and characterized in the experimental work of Ahmed. Although it has a very simple shape, Ahmed body allows us to capture characteristic features that are relevant to bodies in the automobile industry. This model is also used to describe the turbulent flow field around a car-like geometry. Once the numerical model in validated, it is used to design new models of the car. Car companies makes numerous attempts to develop modified designs to effectively reduce the aerodynamic drag force which occurs at the rear end without putting any constraints in the stability, comfort and safety of the passengers.
Boundary Layer
The boundary layer is a thin layer of a real fluid along the surface of an object in which viscosity effects fluid dynamics. When fluid flows over a plate, velocity near the surface much lower, and vorticity is present. The no-slip condition accounts for zero relative velocity at the plate and keeps on increasing until it reaches the free stream velocity U[Math Processing Error]∞. The fluid deceleration is transferred from one fluid layer to another fluid layer by viscosity and it forms a velocity gradient in the boundary layer.
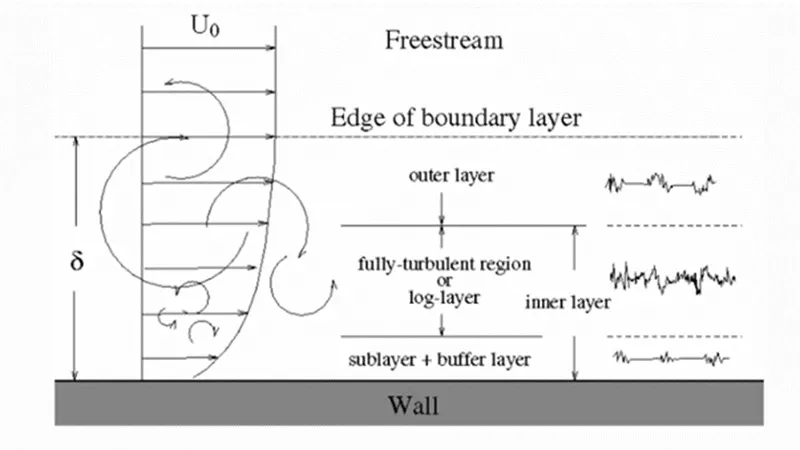
Since we dealing with the turbulent boundary layer and related phenomenon from the above figure it can be seen that in the turbulent boundary layer region flow near the wall has been analysed in terms of three layers.
- The inner layer or sublayer where viscous shear dominates.
- The outer layer or defect layer, where large scale turbulent eddy shear dominates.
- The overlapping layer or log layer where velocity profiles exhibit a logarithmic variation.
Near to the wall the flow is influenced by the viscous effects and independent of free stream parameters. However, the mean flow velocity depends on the distance from the wall(y), fluid density(ρ), viscosity(μ), and wall shear stress(τ).
Y+
Turbulent flows over a body is an essential phenomenon in computational fluid dynamics and are significantly affected by the shape of the body where viscosity affected regions have larger gradients in the solution variable. An accurate representation of the near-wall region determines a successful prediction of wall-bounded turbulent flows.
The reason for the need for Y+ is to distinguish different regions near the wall or in the viscous region. If we intend to resolve the effects near the well that is in the viscous sublayer then the size of the mesh should be small and dense enough near the wall so that almost all the effects are captured. The smallness, in this case, varies from problem to problem to identify the size Y+ comes into play. Based on the Y+ value first cell height can be calculated. The near-wall region is meshed using the calculated first cell height value with gradual growth in the mesh size so that the effects are captured and avoiding overall heavy mesh count.
Below the law of wall is finally displayed clearly and we can see four different length scales:
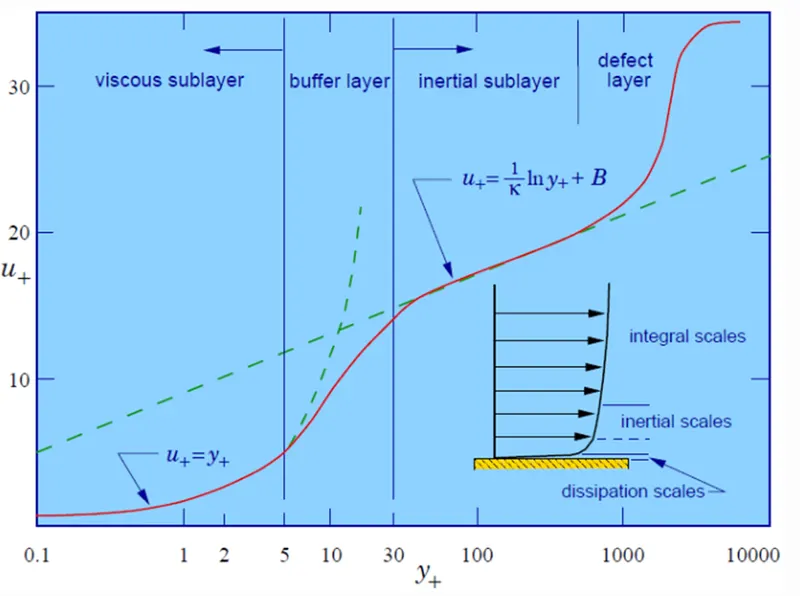
The above plot is a log-log plot, which means the curved line is linear variation and a straight line is a logarithmic variation. The existence of all these layers in the boundary layers made the near-wall treatment nonlinear and inconsistent. In 1905, Prandtl and his student Nikuradse normalized the axes into Y+ (The axis that is used to be the distance) and U+ (The axis that is used to be the velocity). They also wrote an equation that would fit U+ and Y+ near the wall. In the terms of Y+ value, we can say that
- In viscous sublayer - 1 < Y+ < 5
- In the transition layer - 5 < Y+ < 30
- In the log layer - 30 < Y+ < 500
From the above discussion, we can say that placing the first cell in the mesh region is very vital to determine the turbulent model as well as to compensate on the computational mesh and the time Y+ value for our case is in viscous sublayer so that we choose it is to be Y+ = 1.
Reason for the negative pressure in the wake region
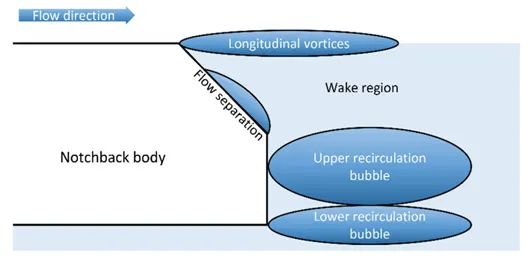
Wake region is the region where velocity gets decreased due to the sudden blunt geometry change behind the Ahmed body. The air flow nearer to the surface will undergo higher resistive force with higher velocity gradient compared to air flowing far away from the surface. Thus, the air flowing away from the surface tend to keep the air flowing with higher velocity. This is due to the viscosity of the fluid (air). Thus there is pressure difference occurs behind the Ahmed body due to which the pressure flows from the high pressure region to low pressure region.
When the air moving over the vehicle is separated at the rear end, it leaves a large low-pressure turbulent region behind the vehicle which is known as the wake. This contributes to the formation of pressure drag which affects the vehicle performance.
When the vehicle is moving at a certain velocity the fluid imparts viscous force to the vehicle as long as it is in the viscous sublayer of the boundary. When the fluid reaches the rear end of the vehicle it gets detached from the surface of the body causing negative pressure in the wake region. The movement of the fluid around the vehicles depends on the geometry of the car and the Reynolds number.
Significance of the point of separation :
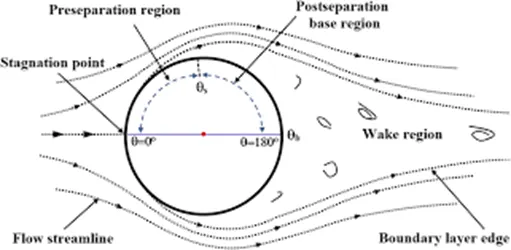
Point of separation occurs behind the Ahmed car body due to higher pressure gradient. This causes the resistive force called the drag force on the Ahmed body as pressure flows from high pressure region to low pressure region. The air flow nearer to the surface will have almost zero velocity with higher velocity gradient whereas the flow away from the surface will have a higher velocity. This will causes the flow separations behind the Ahmed body due the blunt geometry.
The point of separation will occur when there is a discontinuity in the surface or a region of the negative pressure gradient (a sharp end or rear portion of the car).
When the flow is attached to the body of the vehicle the viscous force will increase which will increase the pressure and a decrease in velocity before the rear end of the vehicle. As soon as the air encounters the sharp turn causing the velocity to decrease resulting in the negative pressure region which is in the wake region. The recirculation region happens beyond the point of separation.
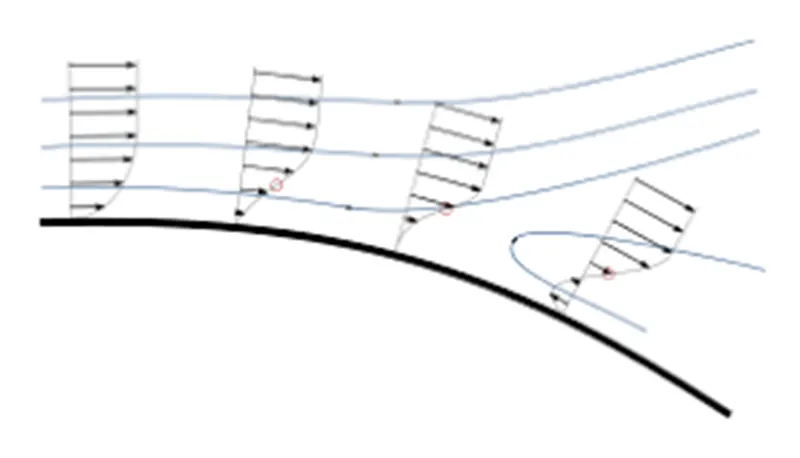
If the rate of change of pressure is large the mixing process will not occur and the boundary layer flow stops.
The above figure shows that at the point of turning the flow gets separated from the boundary layer and there is a region of recirculation after which the flow attaches itself to the boundary layer.
In order to reduce the separation of fluid from the boundary layer, it is advisable to have a smooth edge to reduce the effect of drag on the vehicle.
SOLVING AND MODELLING APPROACH
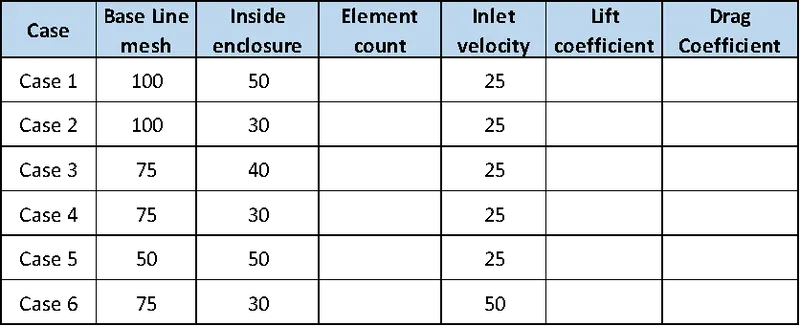
- Wind tunnel or enclosures are constructed around the given Ahmed body. Two different enclosures are used in order to reduce the number of elements. More the number of elements more the computational time.
- For the mesh independence study we vary the base line mesh size and the inside enclosure mesh size. In this case we have used a base line mesh sized of 100mm, 75mm and 50mm.
- Inside enclosure mesh size are varied as 50mm, 40mm and 30mm.
- In order to study the drag and lift coefficient, we are going to simulate by varying the velocity to 50m/s
- So total we have 6 cases.
PRE PROCESSING AND SOLVER SETTING
In our challenge we will create a flow simulation of air around a Ahmed Body. In general I will be explaining only one case and posting the screenshots of the other cases.
Case 1
Base line Mesh size - 100mm
Inside Enclosure Mesh size - 50mm
Inlet velocity - 25m/s
Geometry
- Import Ahmed body geometry in the Space Claim.
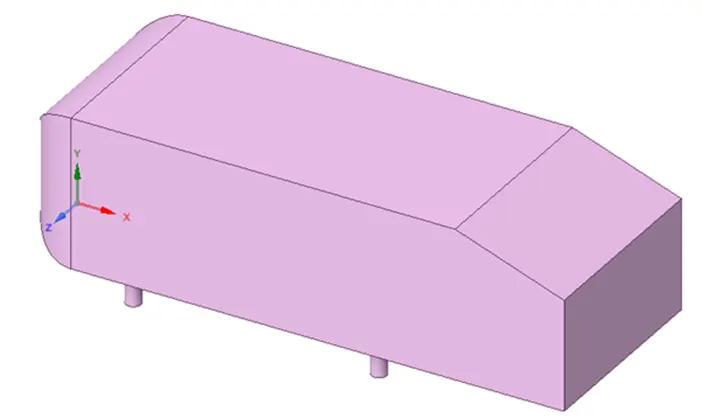
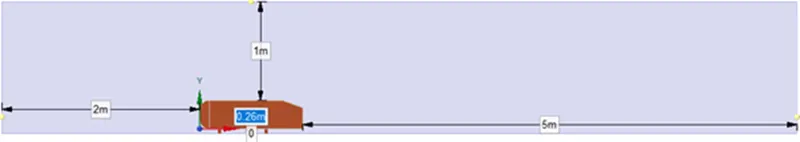
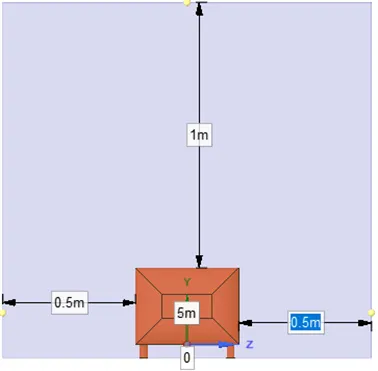
- Prepare an Enclosure for the Ahmed body
Side view
Front view
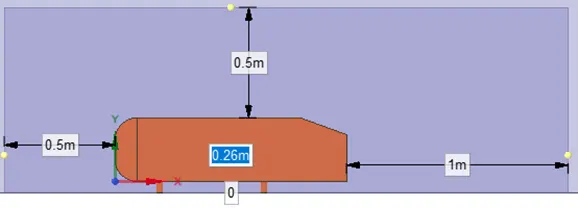
- Add another Enclosure of smaller dimensions.
Side view
Front view
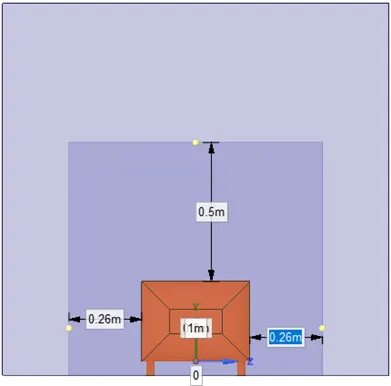
Final geometry after adding Enclosures is shown below:
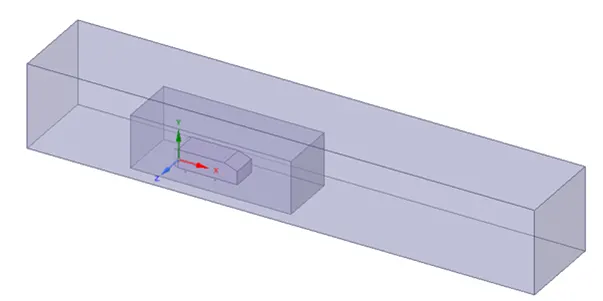
- Add an XY plane by clicking on origin. Then use the split body so that we cut the body into 2 equal half to reduce the cell count
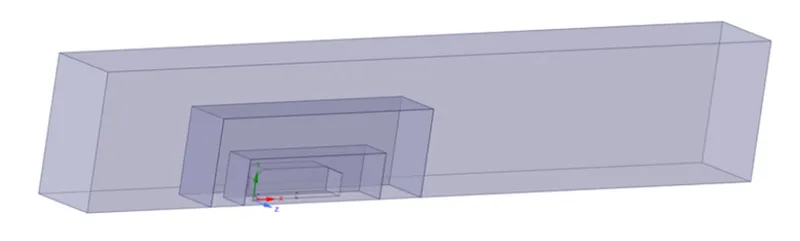
- View in section mode for the interference.
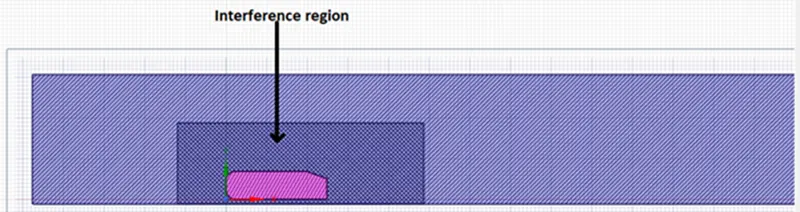
- In prepare section click on interference it will show interference region.
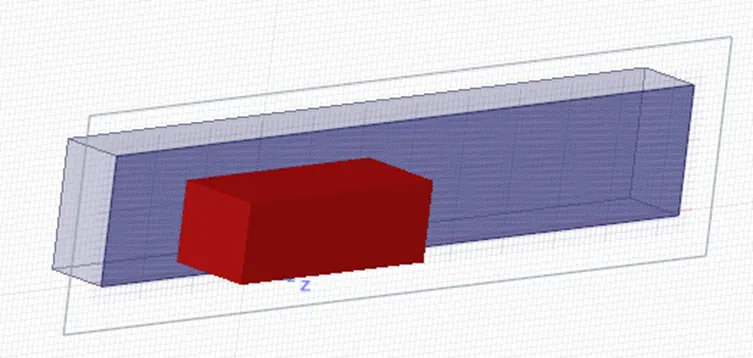
- Press on green tick and I will resolve the interference problem
Resolved interference
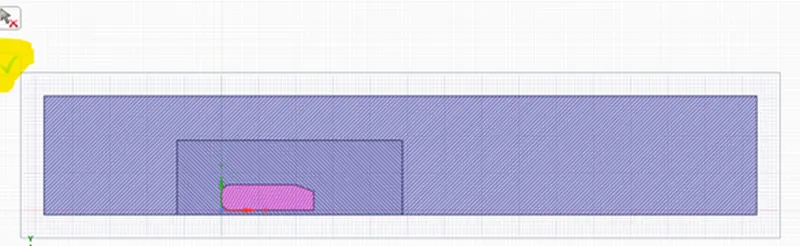
- Suppress the Ahmed body for physics.
Click on share topology
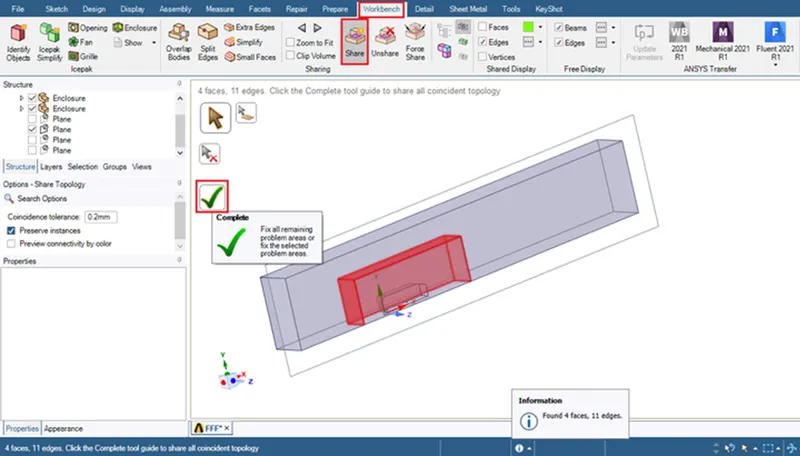
- Close SpaceClaim
Meshing-
- At first generate the mesh.
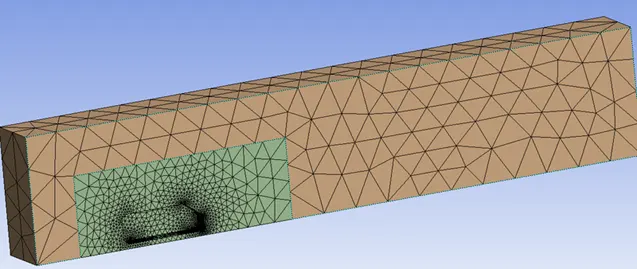
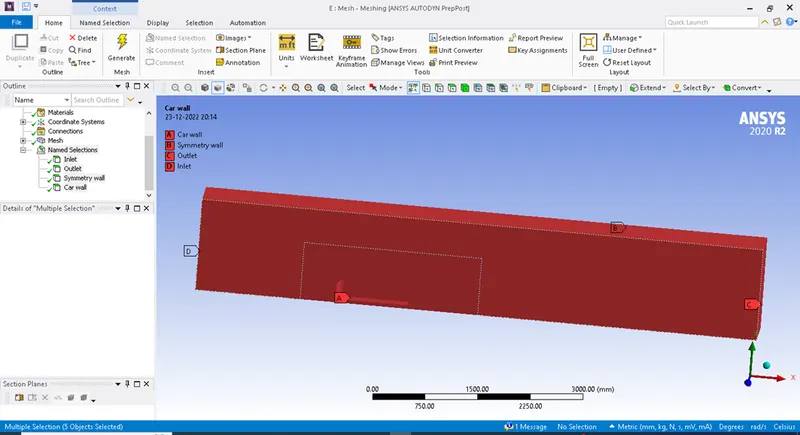
- Name the sections of the geometry such as inlet, outlet, symmetry wall, Car wall and fluid domain.
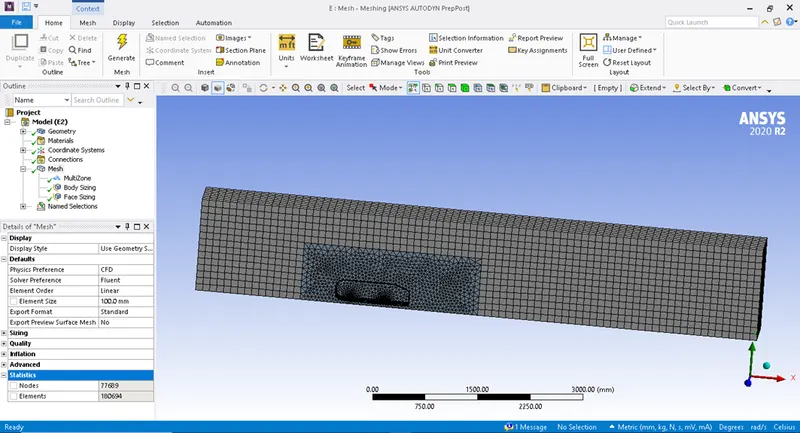
- Give method sizing, body sizing and face sizing to refine the mesh quality
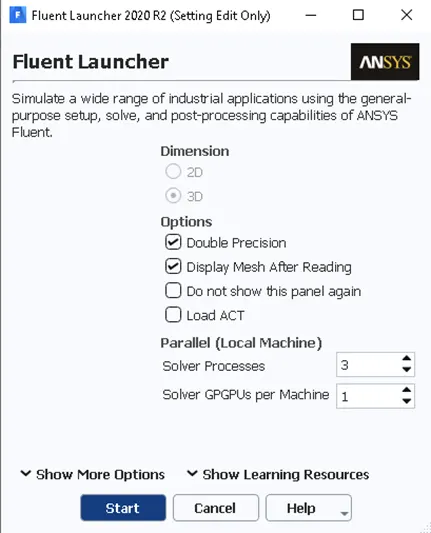
- After the meshing and face naming are done move on to Fluent Solver. In the fluent launcher select double precision, display mesh after reading and give the appropriate solver processors and GPUs.
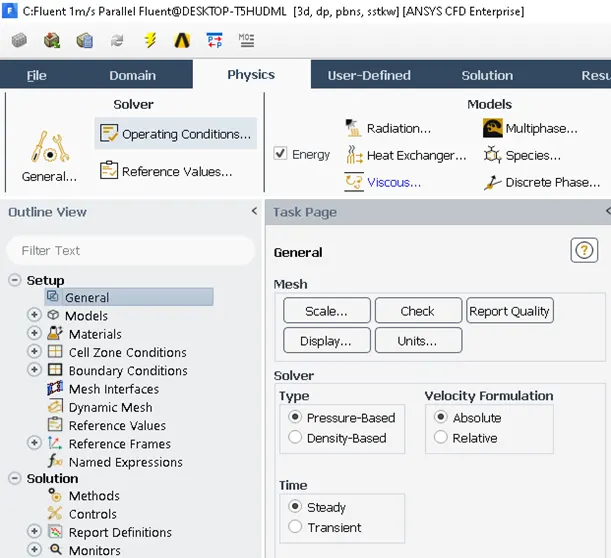
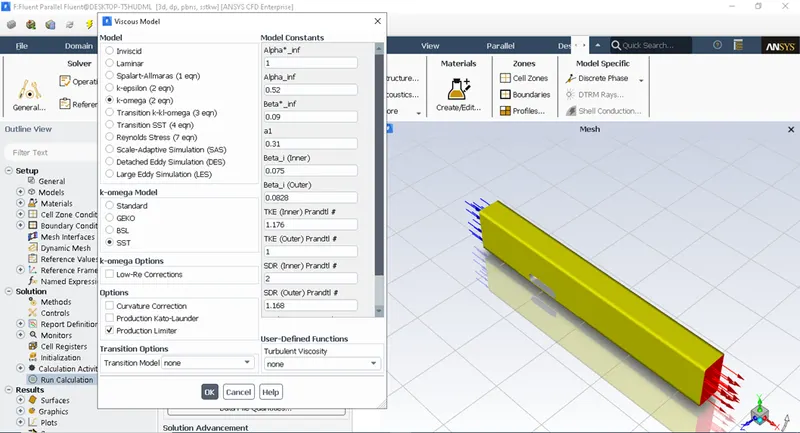
- For this simulation, K omega SST turbulence model
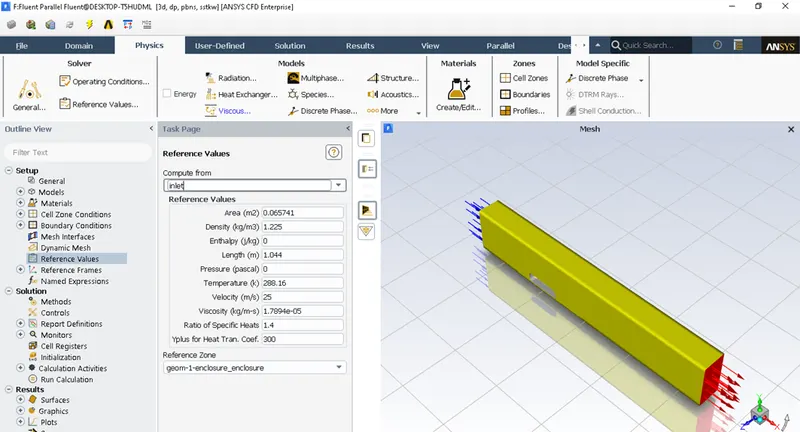
- Give the reference values. Select compute from inlet. Calculate and give the values of area 0.065741 and length 1.044m
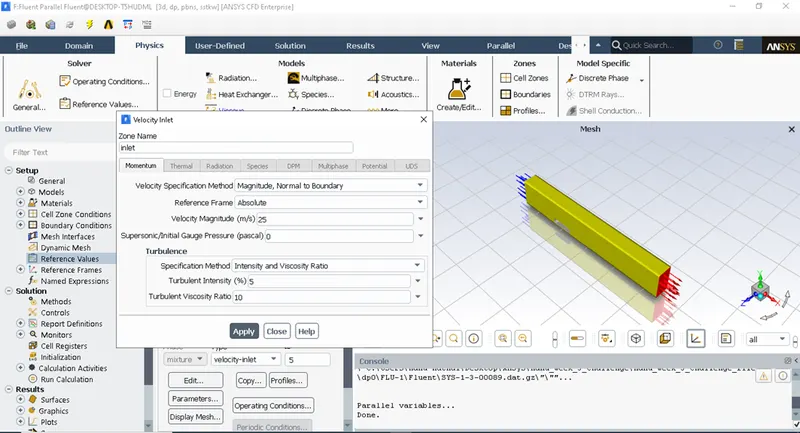
- Give the boundary conditions. The inlet velocity of the air is set to 25m/s
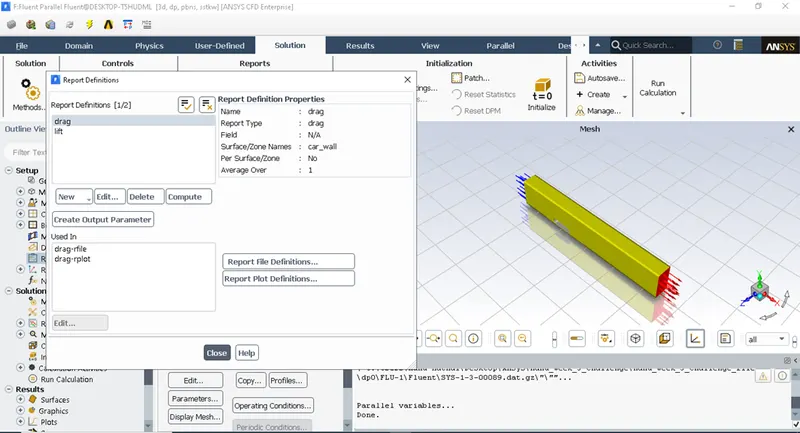
- Create report definitions for lift and drag coefficients.
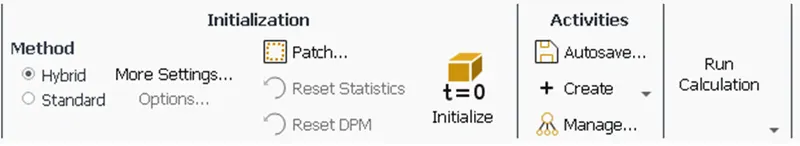
- After the physics part is done move to the solution part. Initialise the simulation first. click Initialize to initialize the boundary conditions. Hybrid method is selected before initialization. Click on Autosave to obtain a animation of the flow in the post results.
- Then run the calculation for a given number of iterations till the convergence is obtained. Depending upon the number of elements and model selected the time required for convergence varies. In the CFD module itself we can compute, measure, plot, animate, etc., if needed.
- After the solutions and calculations move to the result module to get different graphs, plots, contours, animations etc.,. Sectional views can be created if required.
RESULT
Case 1
Base line Mesh size - 100mm
Inside Enclosure Mesh size - 50mm
Inlet velocity - 25m/s
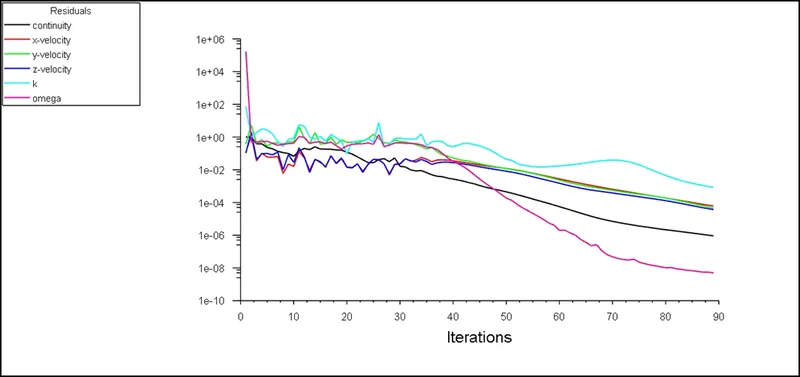
Residual
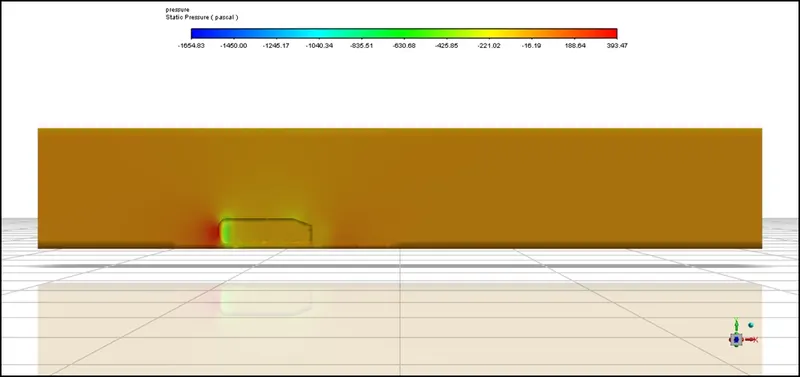
Pressure contour
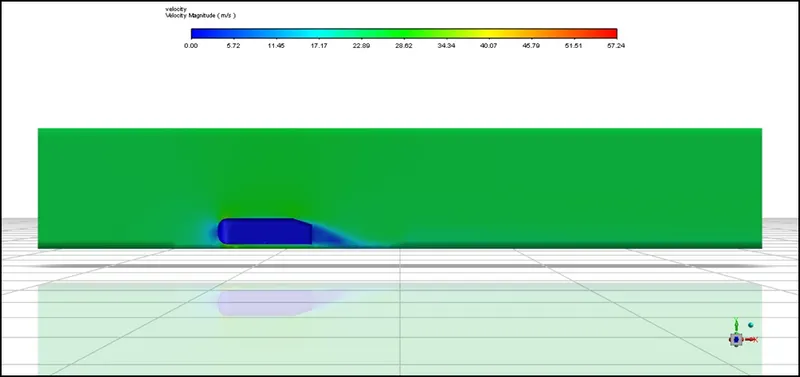
Velocity contour
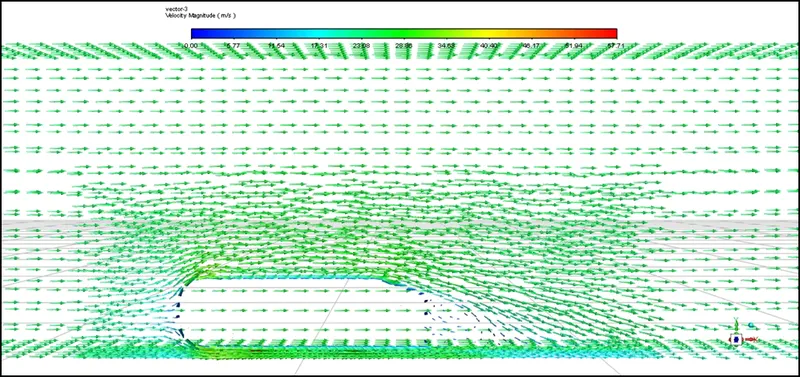
Velocity Vector
Pressure contour on Plane1
Velocity contour on Plane1
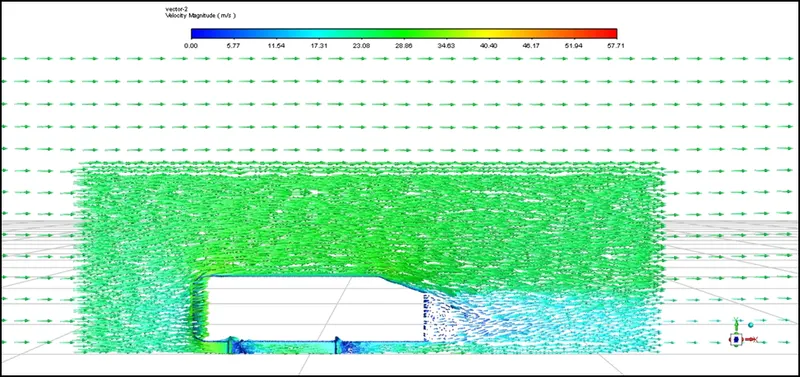
Velocity vector on plane1
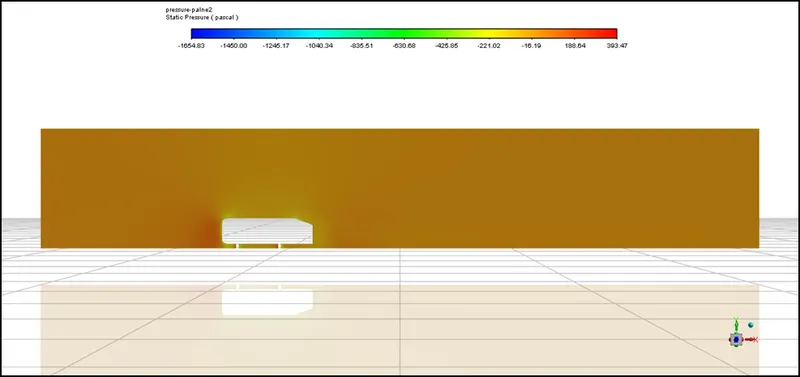
Pressure contour on Plane2
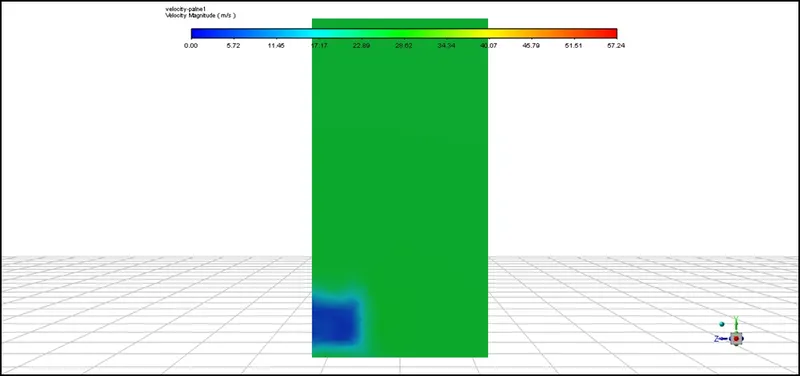
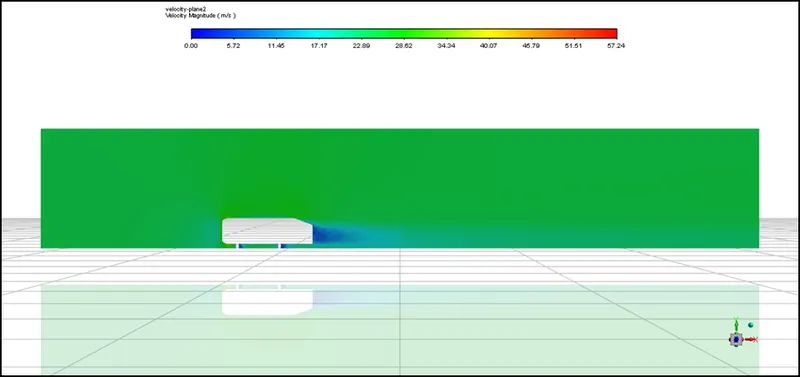
Velocity contour on Plane2
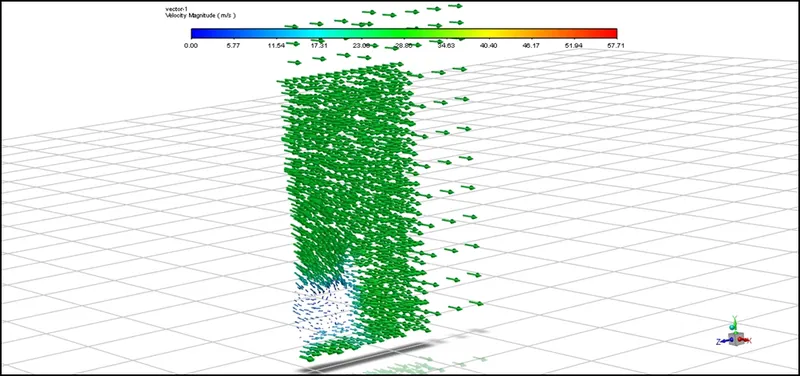
Velocity contour on Plane2
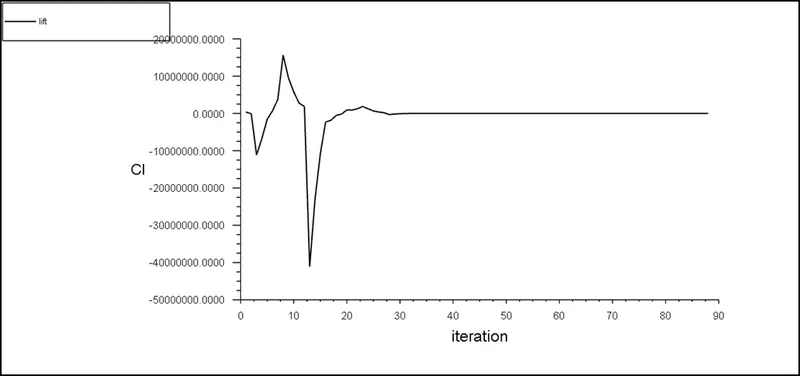
Lift Coefficient
Drag Coefficient
Case 2
Base line Mesh size - 100mm
Inside Enclosure Mesh size - 30mm
Inlet velocity - 25m/s
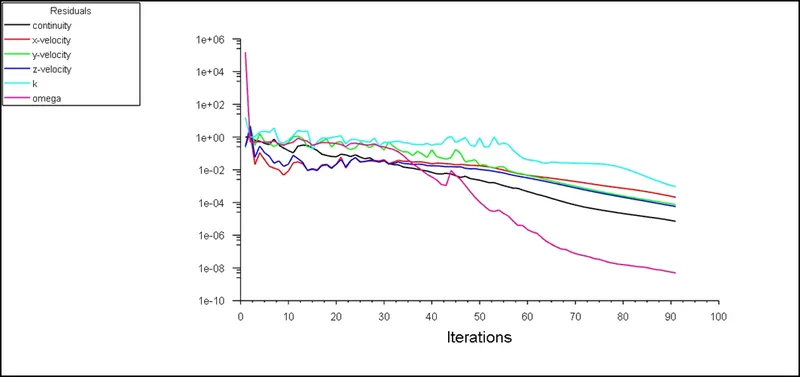
Residual
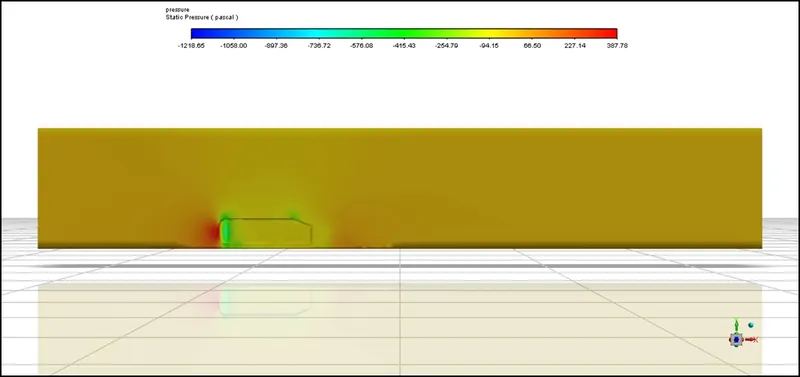
Pressure contour
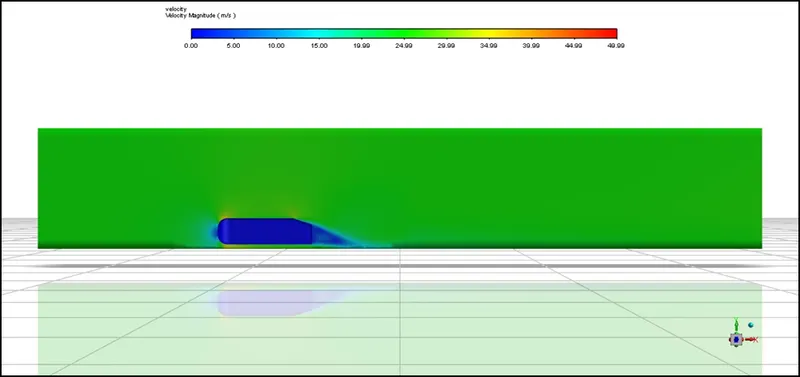
Velocity contour
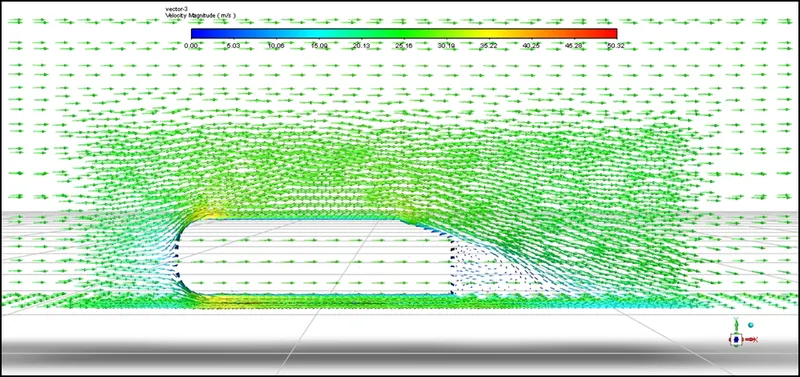
Velocity Vector
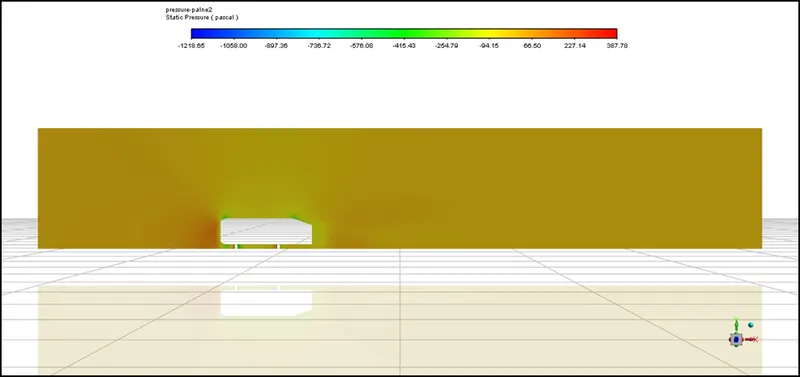
Pressure contour on Plane1
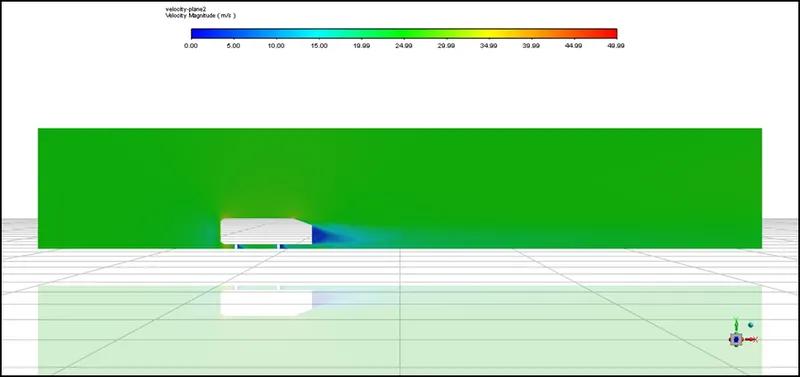
Velocity contour on Plane1
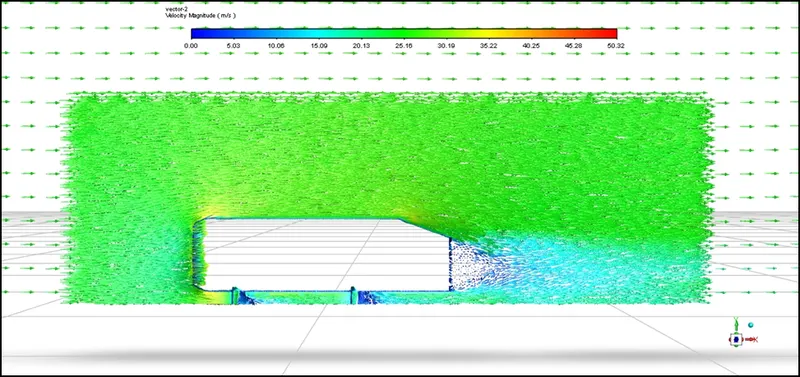
Velocity vector on plane1
Pressure contour on Plane2
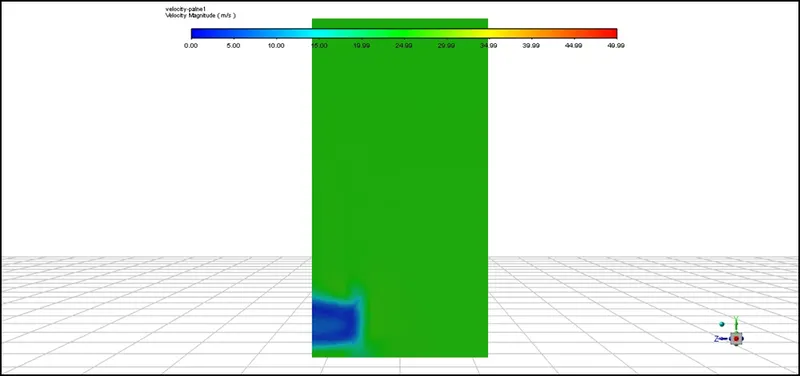
Velocity contour on Plane2
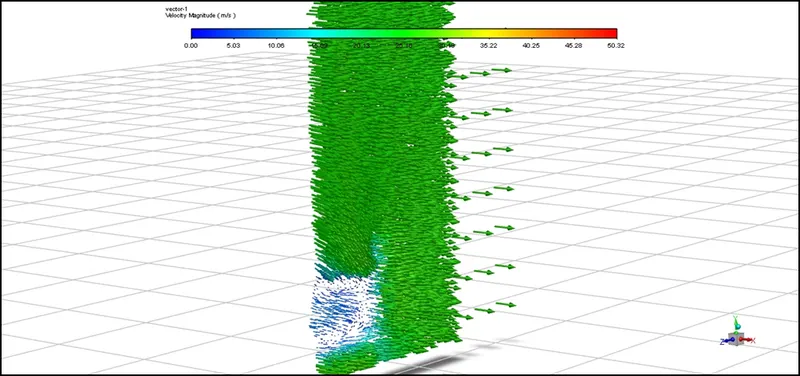
Velocity contour on Plane2
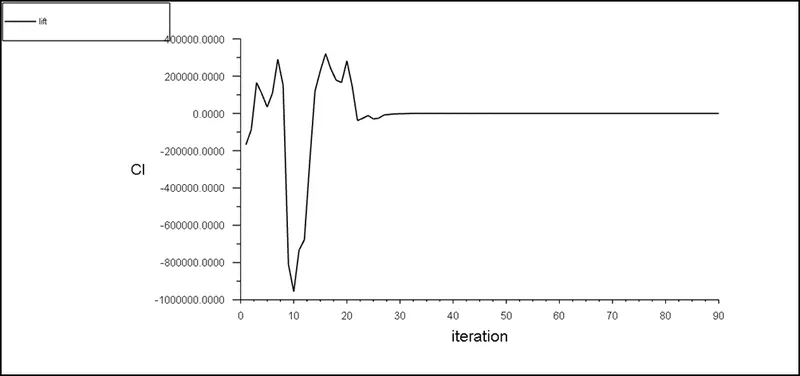
Lift Coefficient
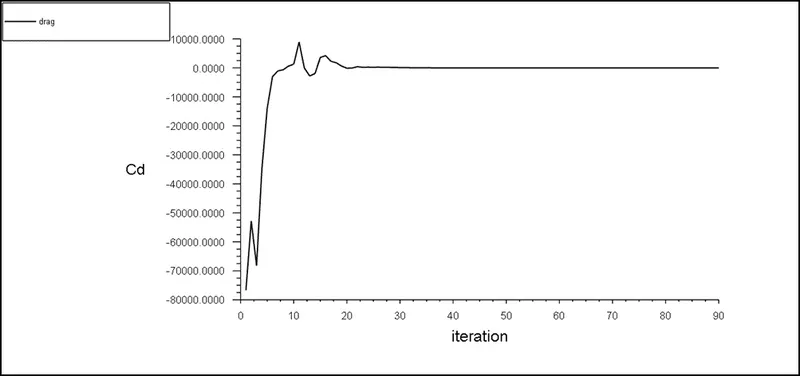
Drag Coefficient
Case 3
Base line Mesh size - 75mm
Inside Enclosure Mesh size - 40mm
Inlet velocity - 25m/s
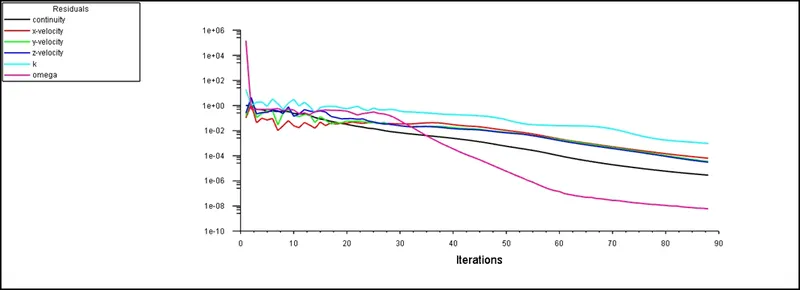
Residual
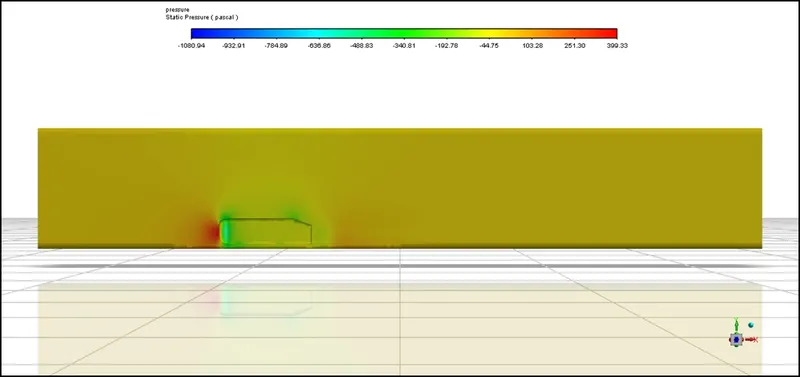
Pressure contour
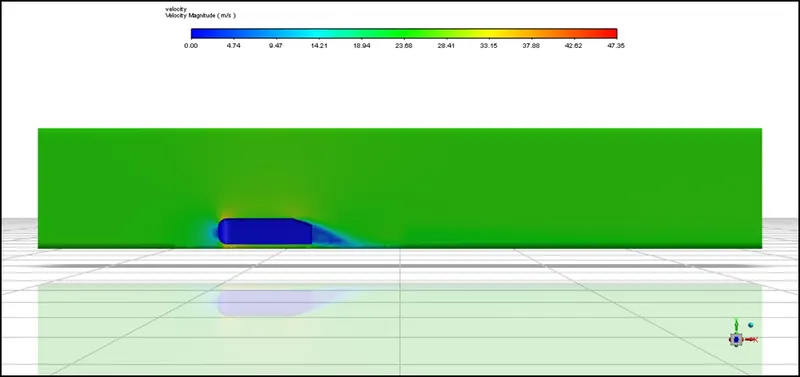
Velocity contour
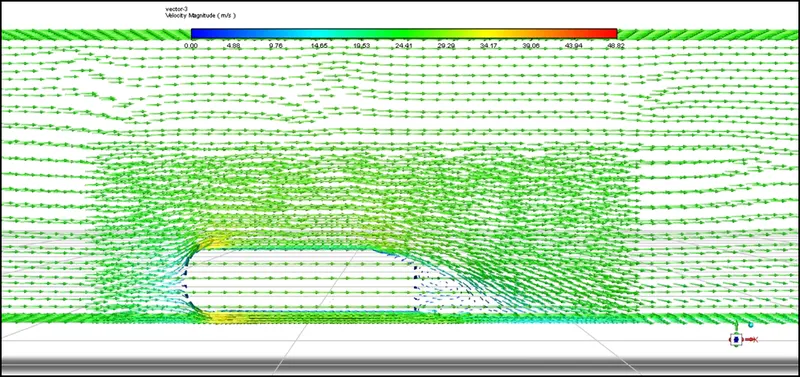
Velocity Vector
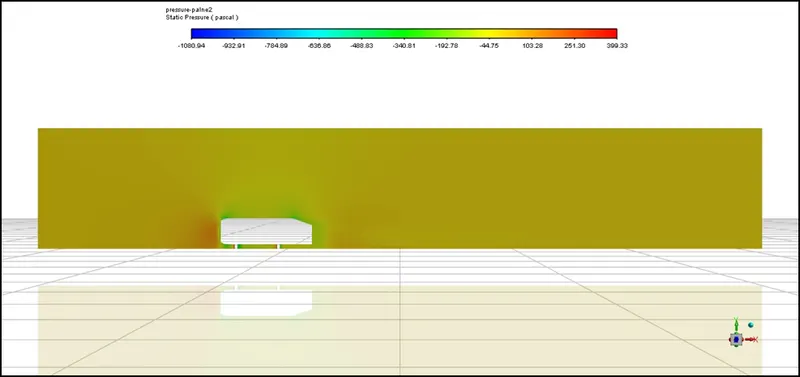
Pressure contour on Plane1
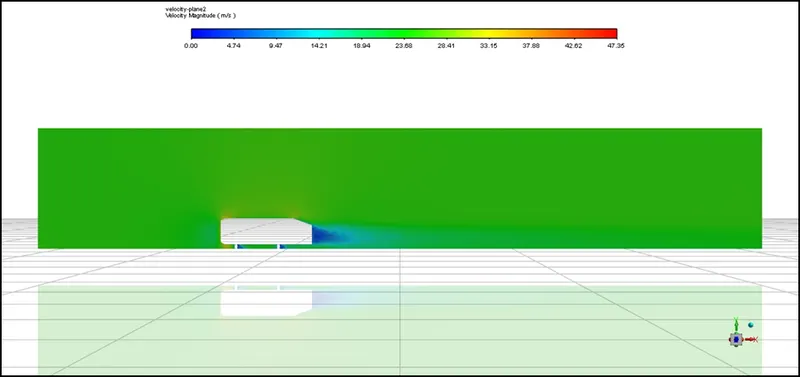
Velocity contour on Plane1
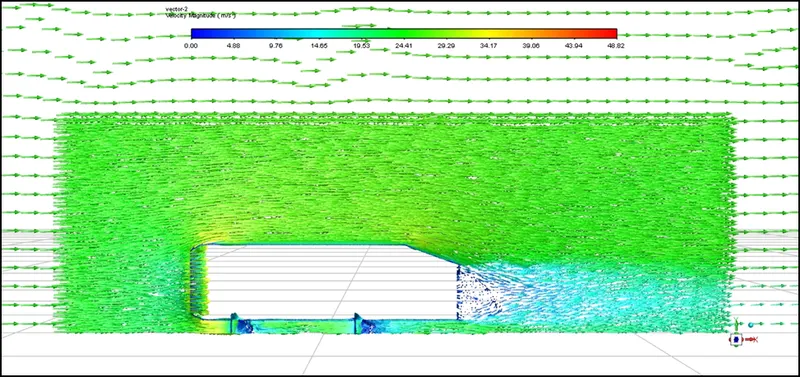
Velocity vector on plane1
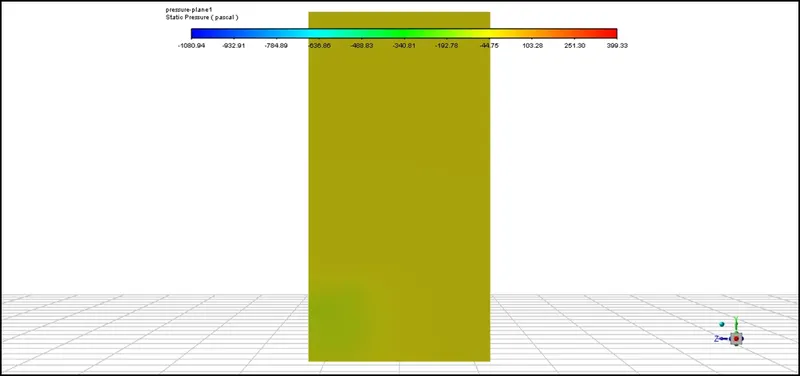
Pressure contour on Plane2
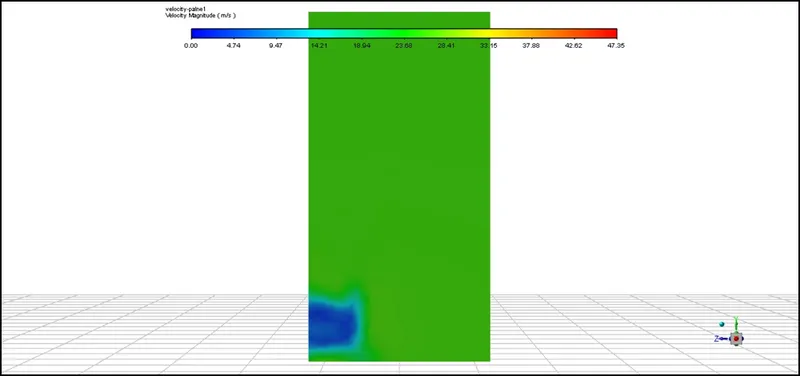
Velocity contour on Plane2
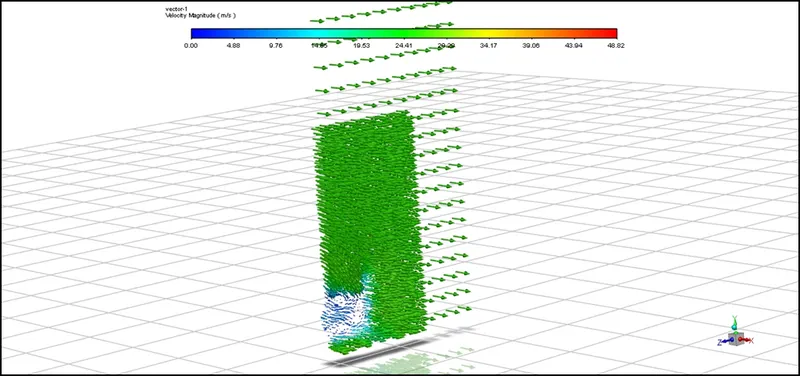
Velocity contour on Plane2
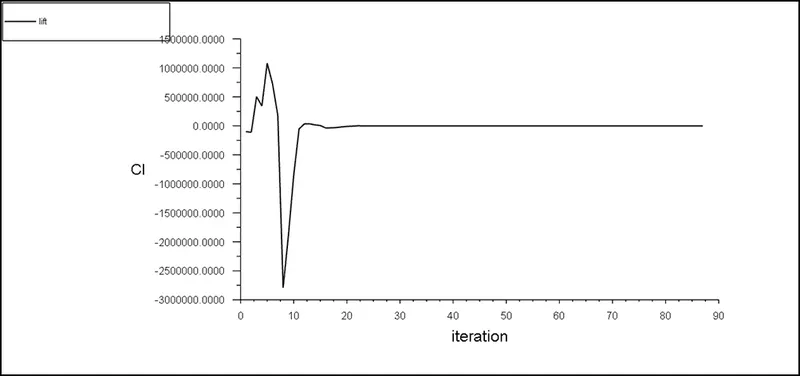
Lift Coefficient
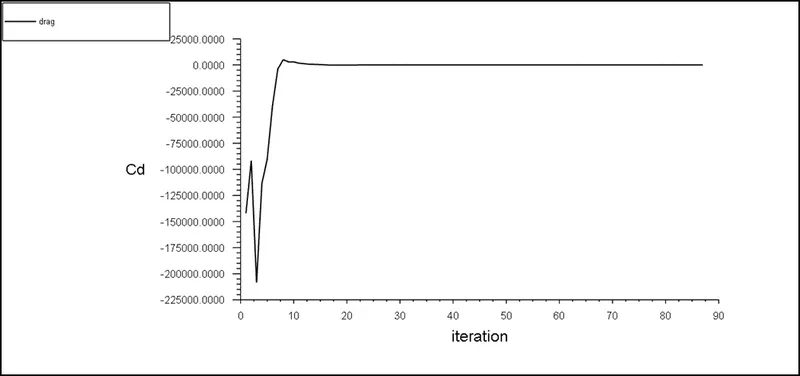
Drag Coefficient
Case 4
Base line Mesh size - 75mm
Inside Enclosure Mesh size - 30mm
Inlet velocity - 25m/s
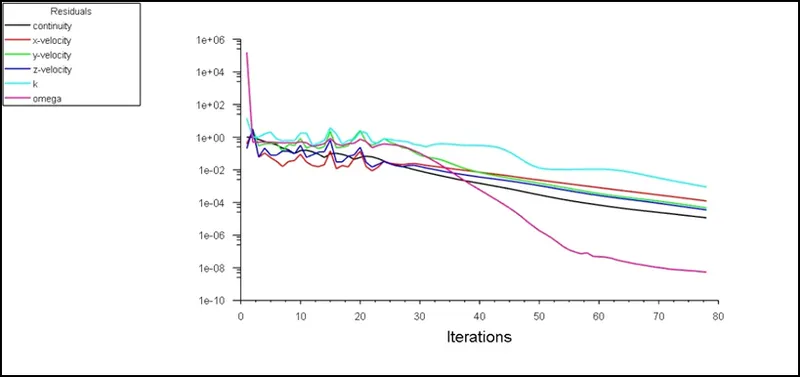
Residual
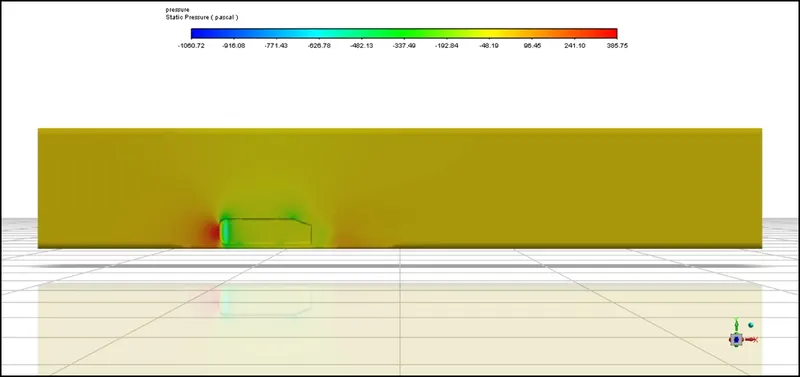
Pressure contour
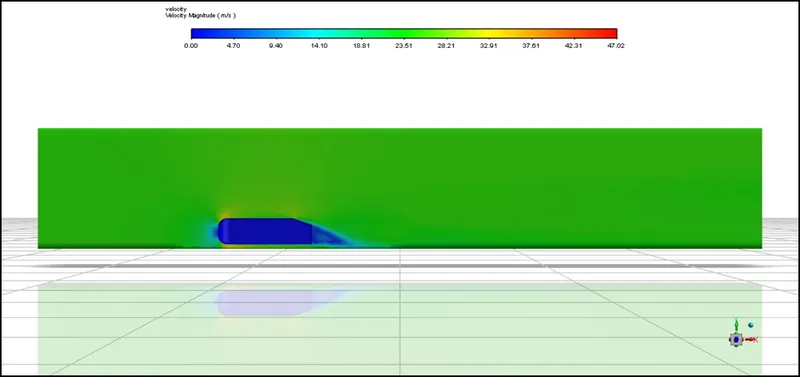
Velocity contour
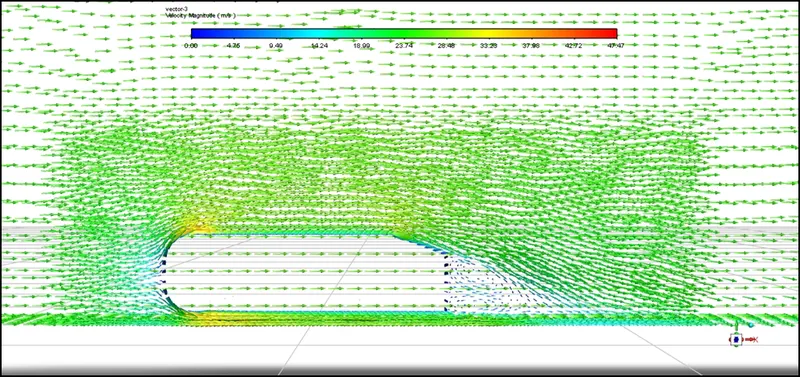
Velocity Vector
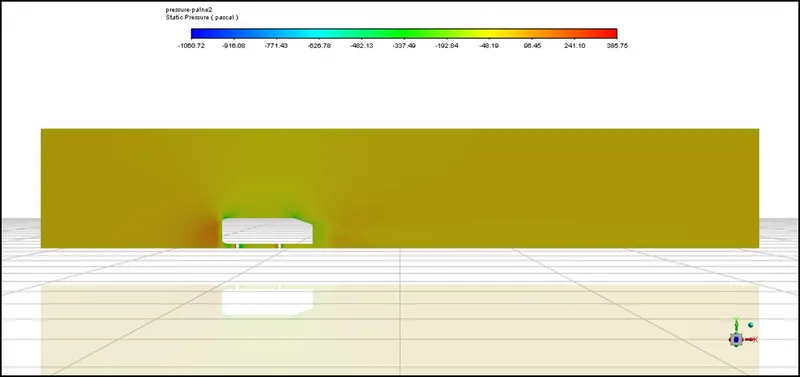
Pressure contour on Plane1
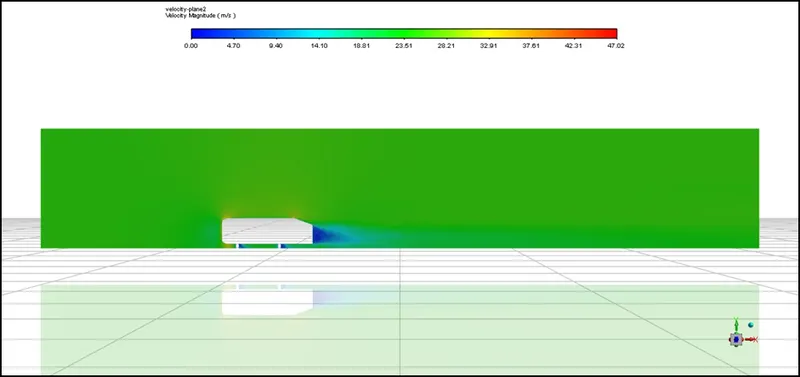
Velocity contour on Plane1
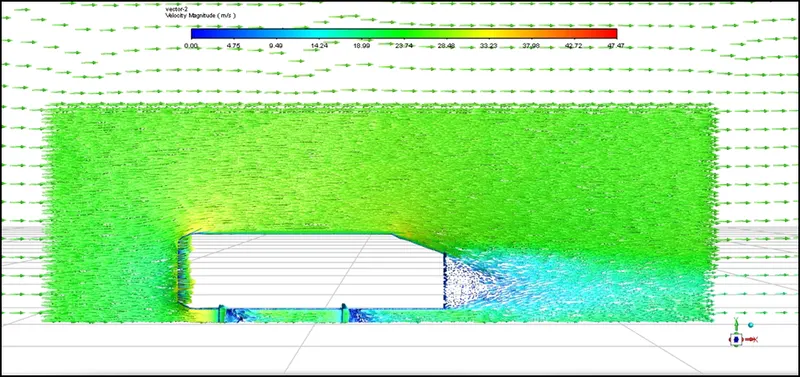
Velocity vector on plane1
Pressure contour on Plane2
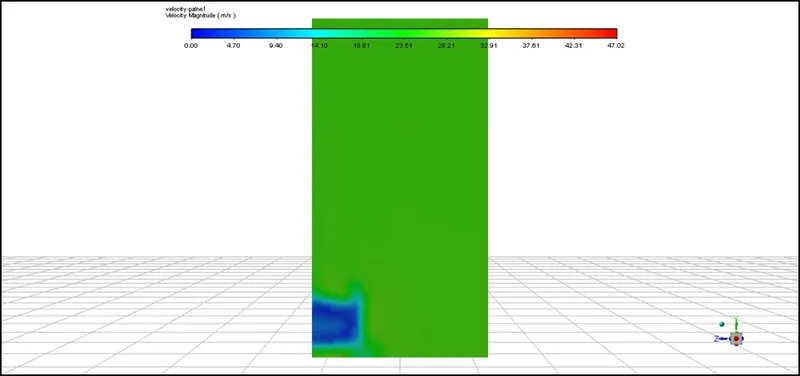
Velocity contour on Plane2
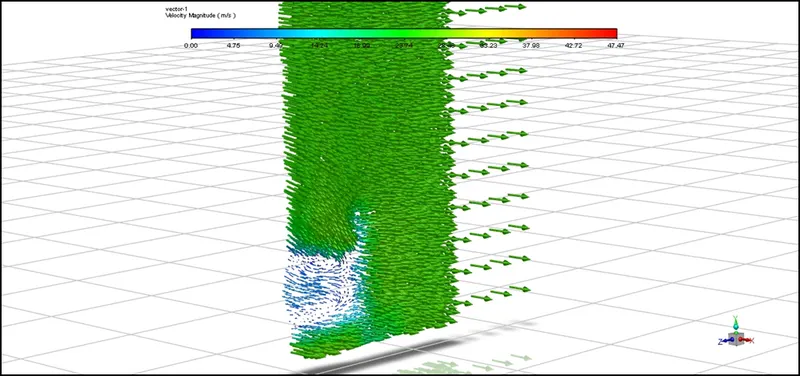
Velocity contour on Plane2
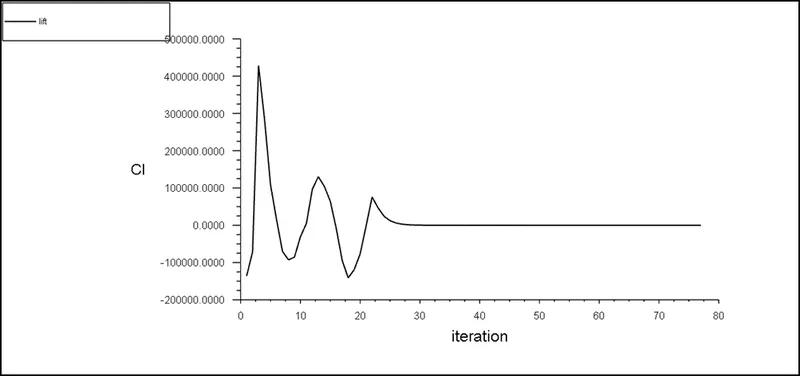
Lift Coefficient
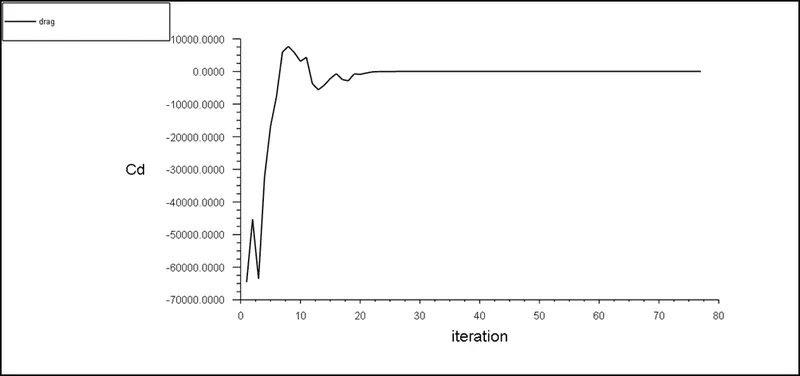
Drag Coefficient
Case 5
Base line Mesh size - 50mm
Inside Enclosure Mesh size - 50mm
Inlet velocity - 25m/s
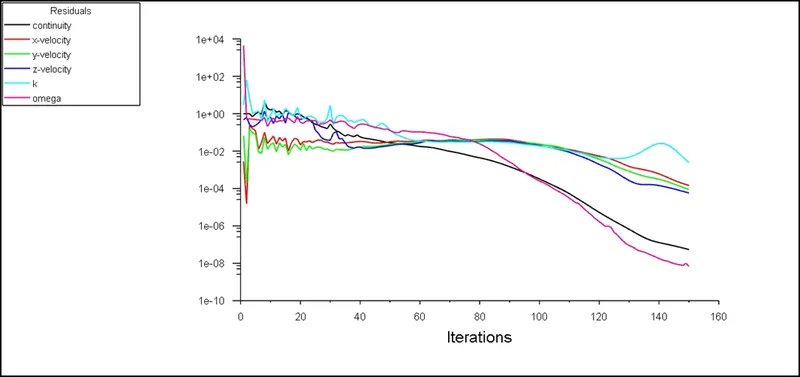
Residual
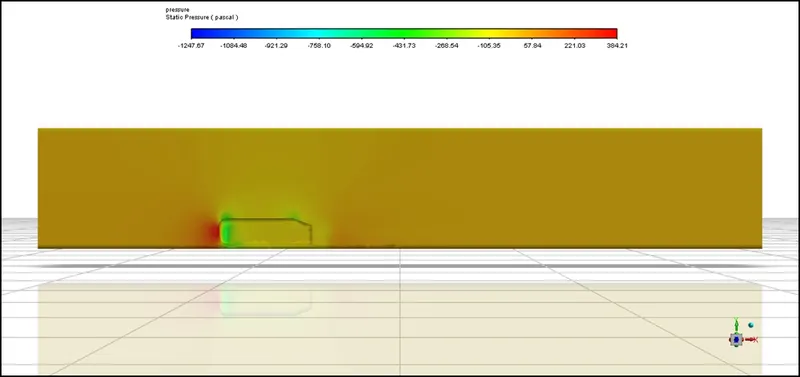
Pressure contour
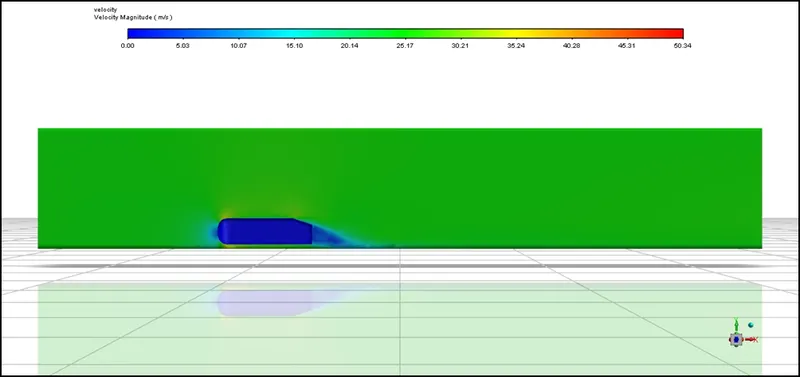
Velocity contour
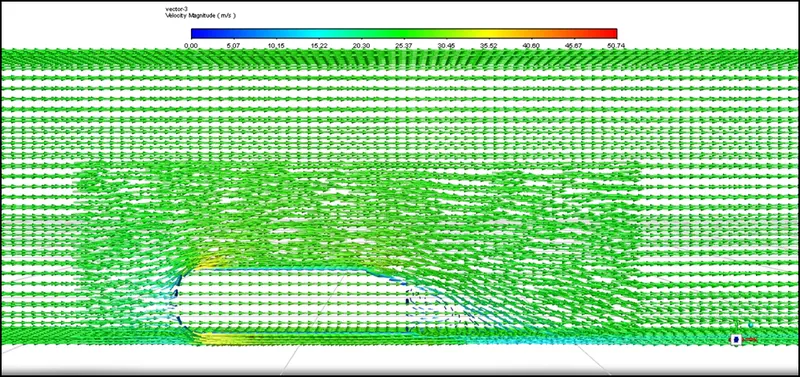
Velocity Vector
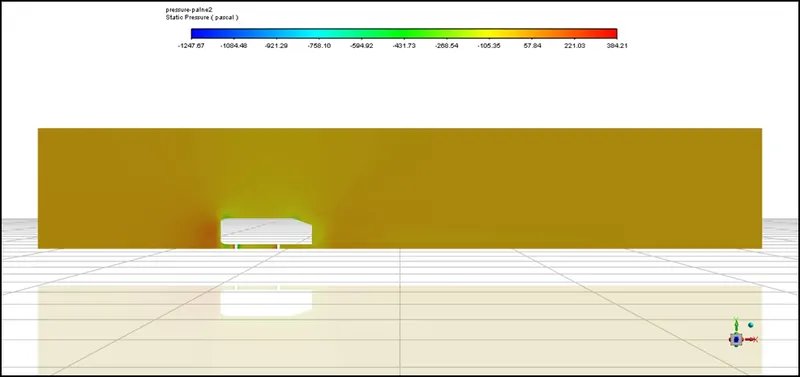
Pressure contour on Plane1
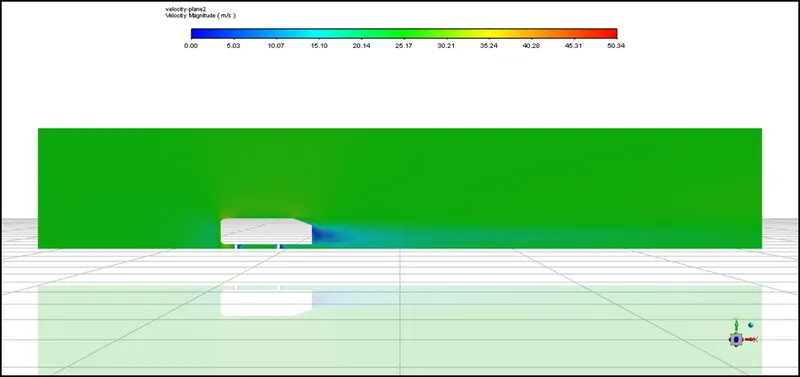
Velocity contour on Plane1
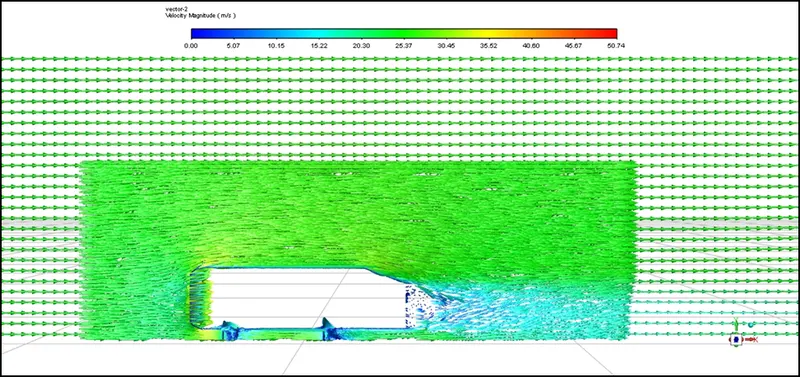
Velocity vector on plane1
Pressure contour on Plane2
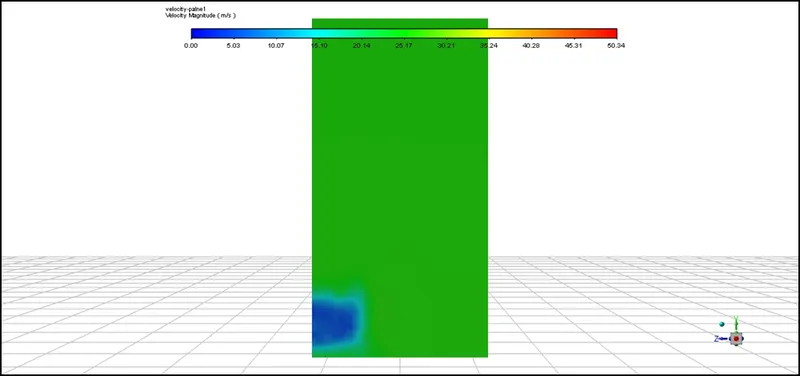
Velocity contour on Plane2
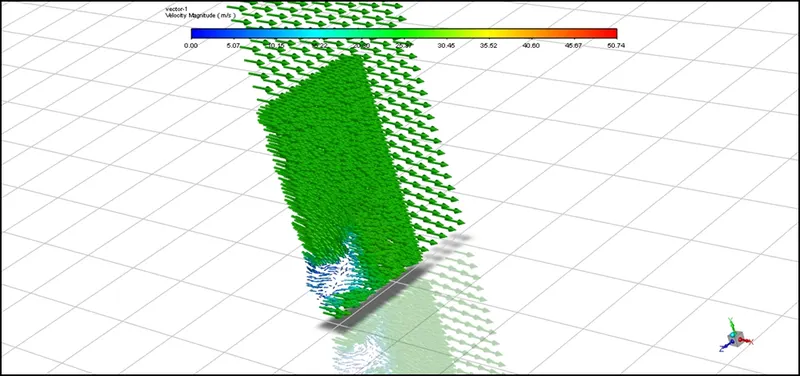
Velocity contour on Plane2
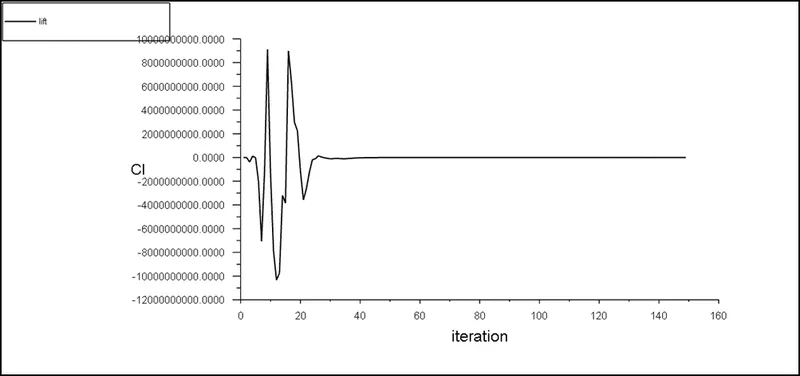
Lift Coefficient
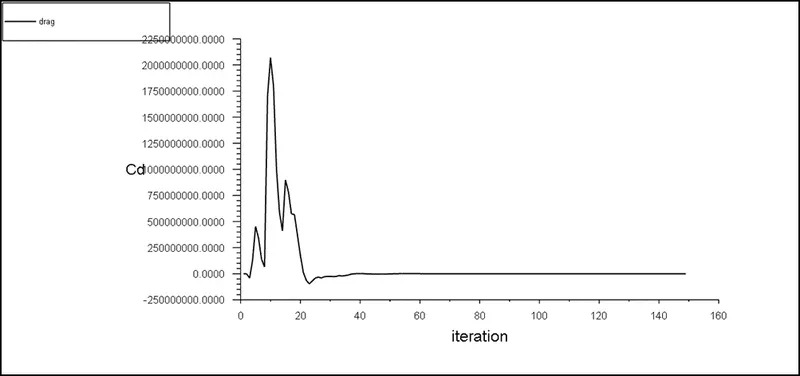
Drag Coefficient
Case 6
Base line Mesh size - 75mm
Inside Enclosure Mesh size - 30mm
Inlet velocity - 50m/s
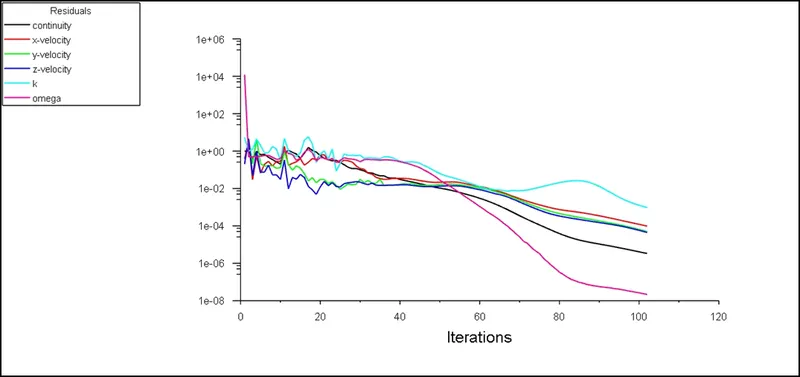
Residual
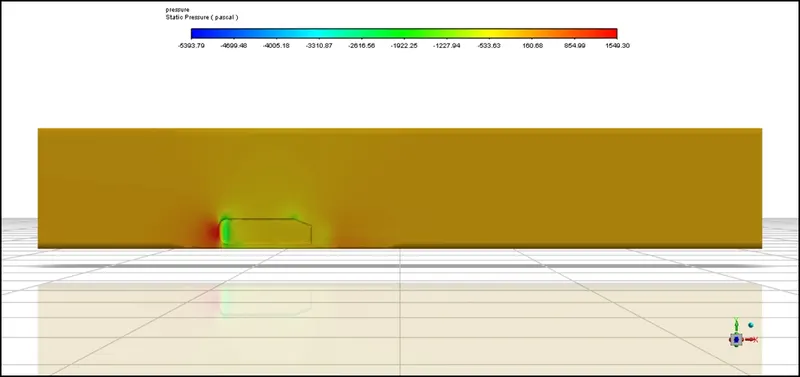
Pressure contour
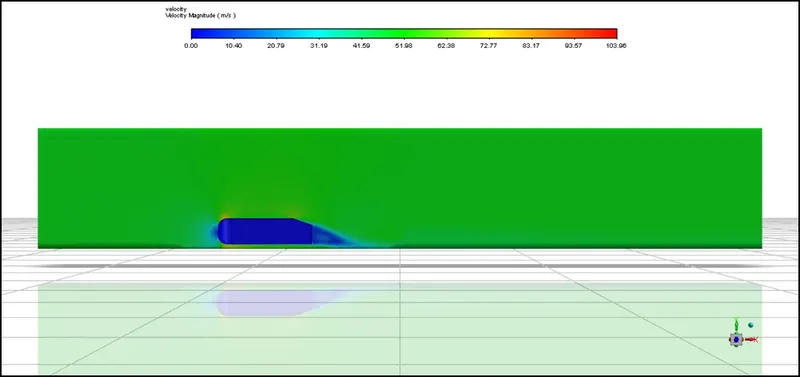
Velocity contour
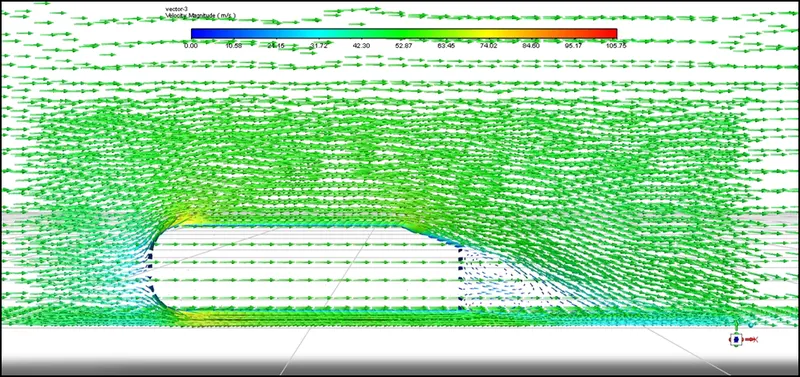
Velocity Vector
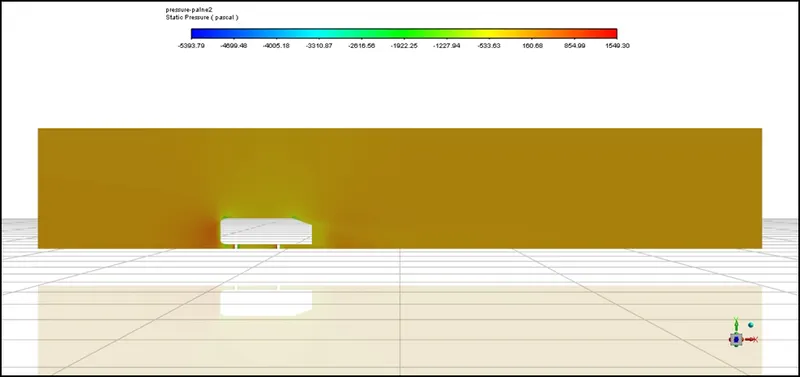
Pressure contour on Plane1
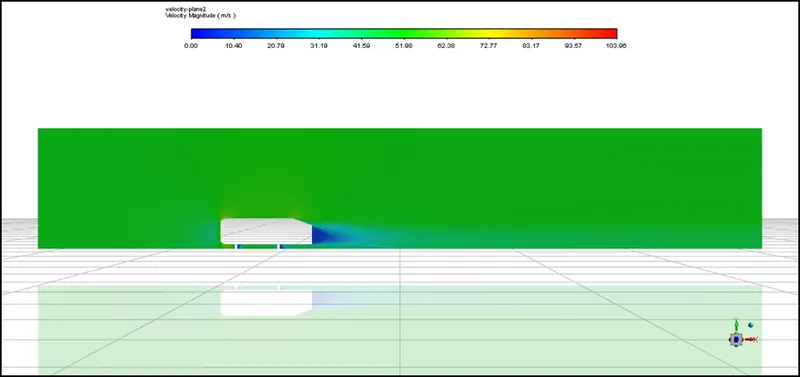
Velocity contour on Plane1
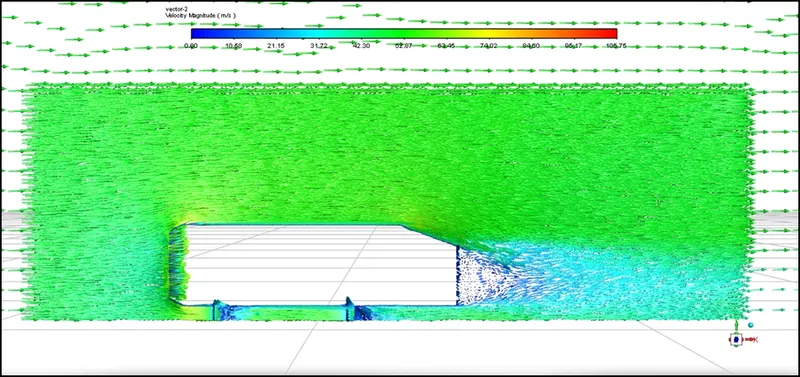
Velocity vector on plane1
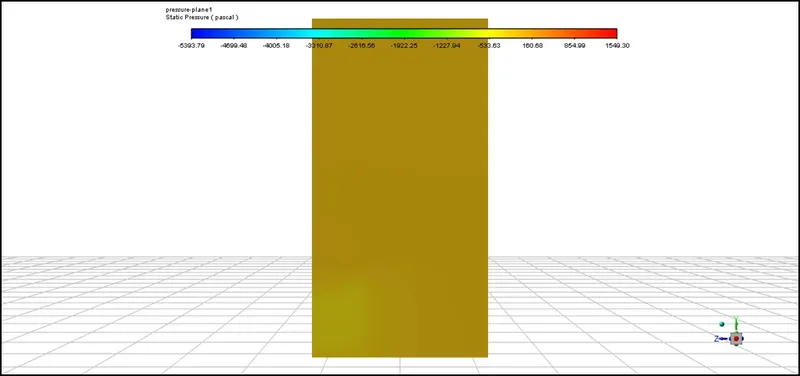
Pressure contour on Plane2
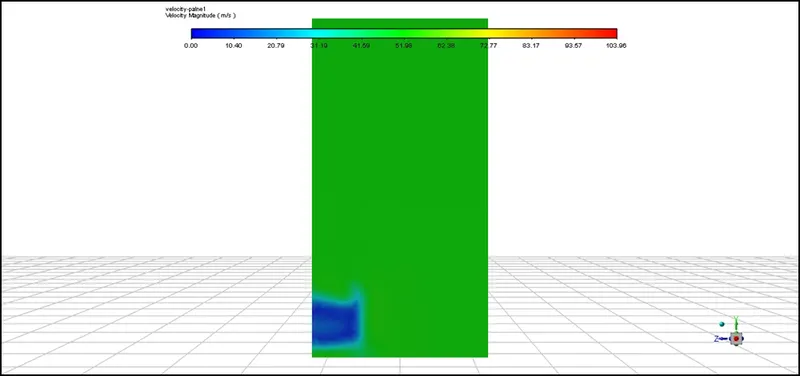
Velocity contour on Plane2
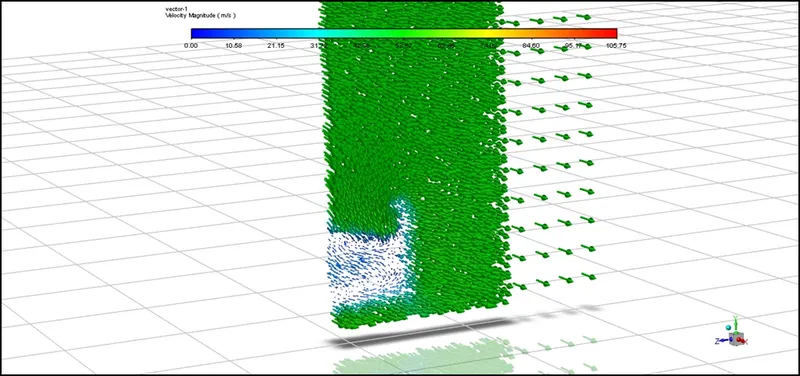
Velocity contour on Plane2
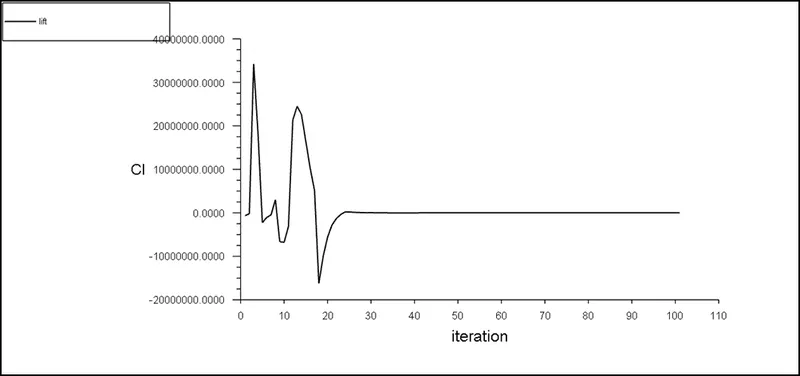
Lift Coefficient
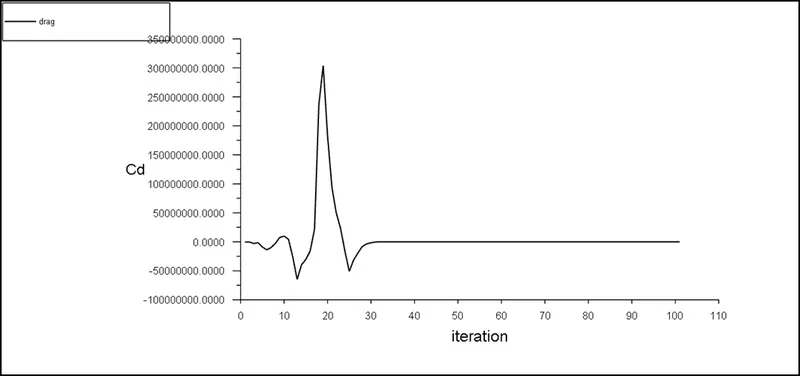
Drag Coefficient
Mesh Independence Study
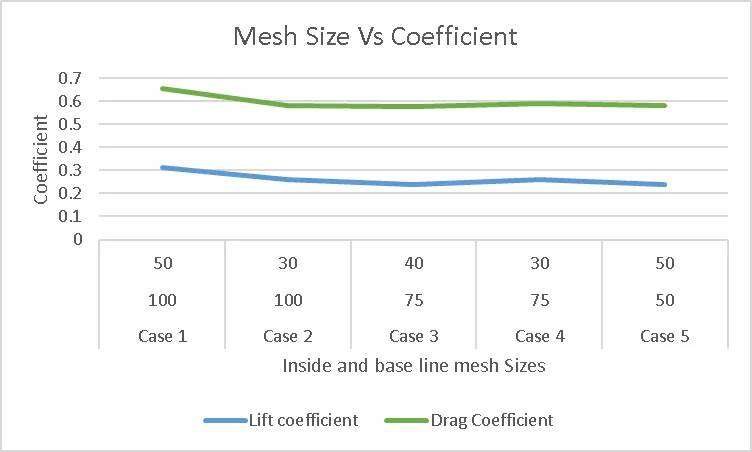
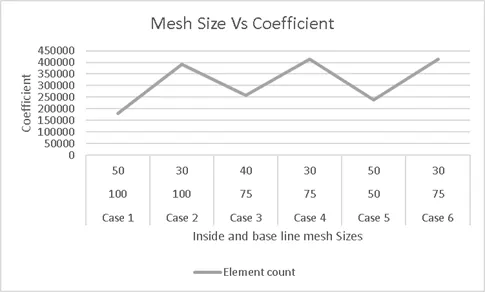
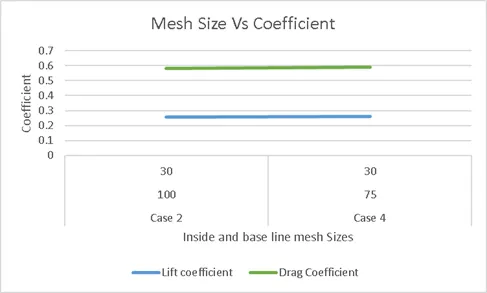
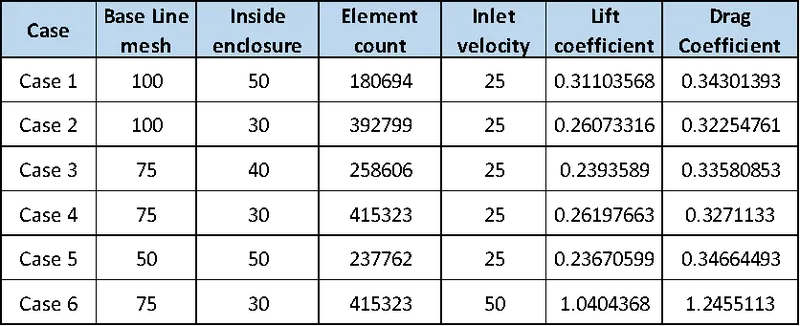
Mesh independence study was carried out for the Ahmed body simulation. Base line mesh was varied from 100mm, 75 mm & 50mm and the inside enclosure mesh sizes was varied from 50mm, 40mm & 30mm. It can be observed that as the mesh size decreases the number of element increases drastically. Since we have used multizone method for the outer enclosure the change in the mesh size do not affect much in the element count. This can be validated from the table comparing the case 2 and case 4 which has element count of 3.9 and 4.1 lakhs respectively.
The simulation was carried out for a velocity of 25m/s for the first 5 cases. It can be stated that there is not much significant change in the results as the element count increases. But the result is more accurate when element count increases which in turn increases the computational time. So one must be carefully while choosing the mesh size and the required accuracy of the result.
So in this simulation we can take Case 3 as the optimal solution as it gives comparatively accurate results and less computational time. The lift coefficient was found to be 0.239 and the drag coefficient was found to be 0.335
Inlet Velocity Study
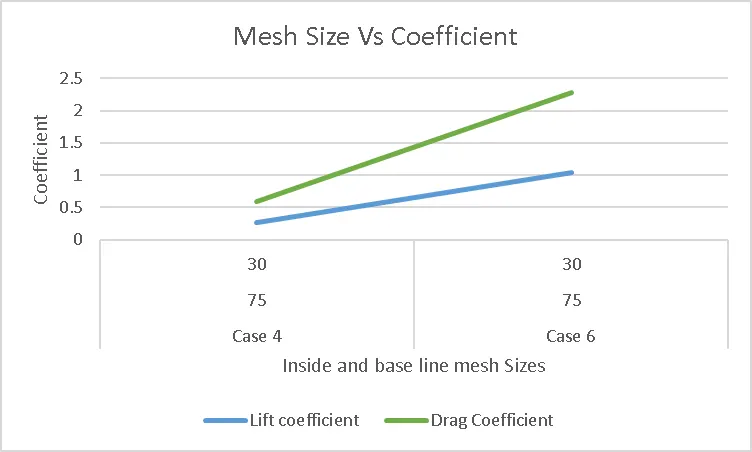
Inlet velocity study was carried out by varying the velocity of the inlet from 25m/s to 50m/s. It can be observed that the lift and drag coefficient increases as the velocity increases. More the velocity more the coefficients.
CONCLUSION
- The grid independency test is carried out to demonstrate the variation of the result with respect to the accuracy of the mesh. The need for a good quality mesh to achieve an accurate result.
- The need of choice of Y+ according to application and quality of result need to attain by calculating the y value. The value of the coefficient of drag primarily depends upon the accurate value of Y+ in such cases grid independency test plays an important role.
- In the boundary layer separation, the need of the correct location of the separation point while designing for the vehicle.
- The negative pressure in the wake region is primarily because there is no flow in that region. This can be further attributed to various factors such as separation and recirculation which is evident from the vector plot near the wake region.
- The point of separation occurs at the rear end of the vehicle, the separation occurs beyond this point where it can be observed that the flow recirculates and attaches it to the boundary layer.