Project 1 - Wiper control system and Vehicle speed calculation for ABS using Wheel Speed sensor
Develop the Simulink model based on the given descriptions for the below challenges and also create SLDD file and link the same to the model. Perform the complete V and V workflow for the obtained models.
- Wiper control system
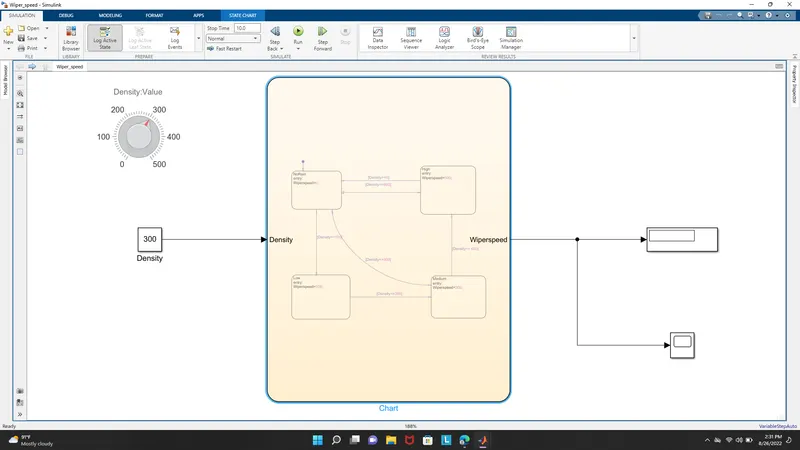
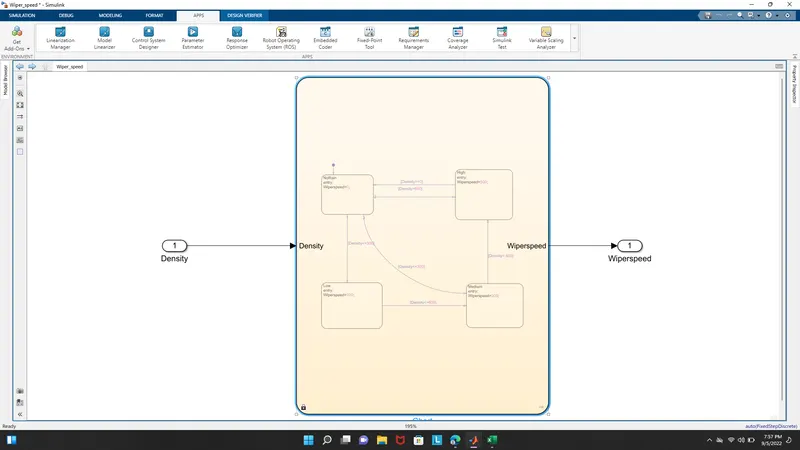
Develop Simulink/state flow model for wiper control system based on the given conditions.
Description of Challenge:
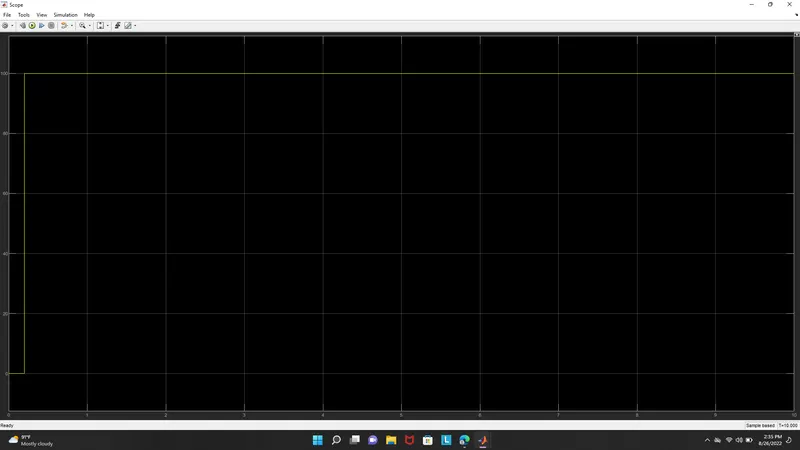
- If the density of the rain is low, then wiper rotates with low speed & the output signal should be 100rpm
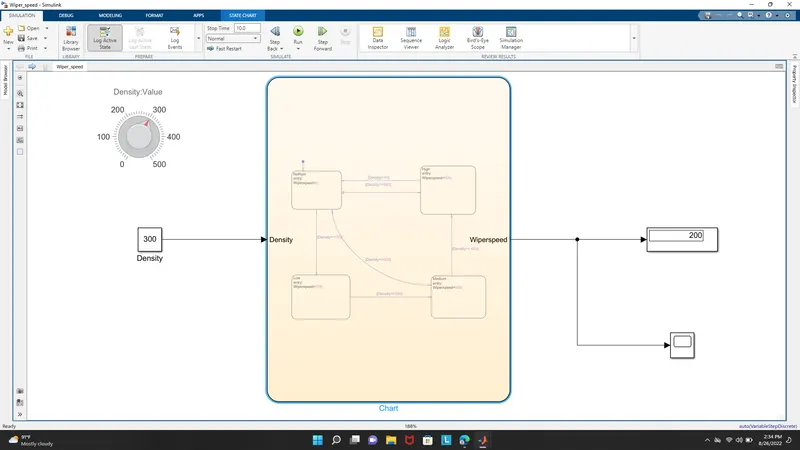
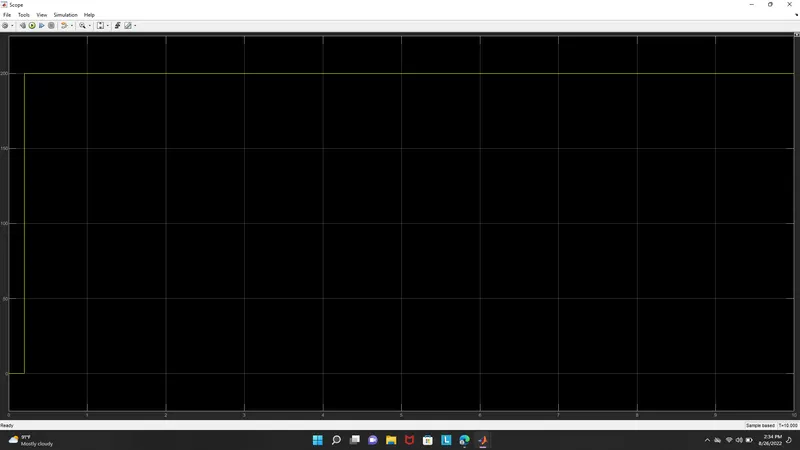
- If the density of the rain is medium, then wiper rotates with medium speed & the output signal should be 200rpm
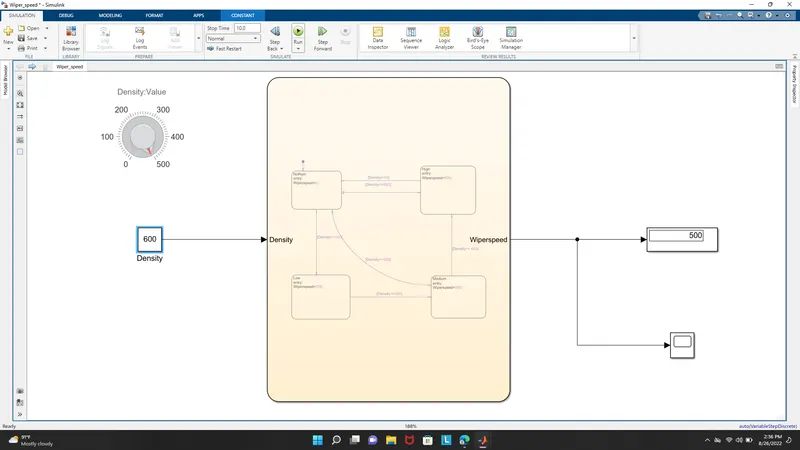
- If the density of the rain is high, then wiper rotates with high speed & the output signal should be 500rpm
Note: Rain density input comes from the external sensor, for the simulation purpose constant block with knob can be taken.
2.Vehicle speed calculation for ABS using Wheel Speed sensor
Develop Simulink/state flow model for the vehicle speed calculation unit inside the ABS system for the below conditions.
Description of Challenge:
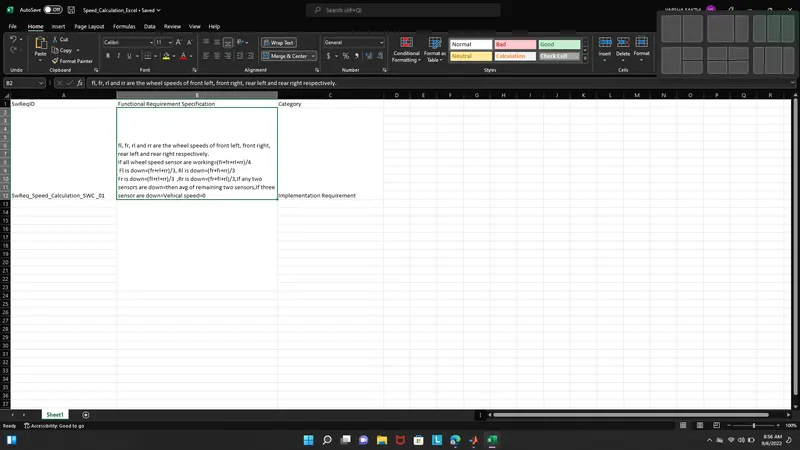
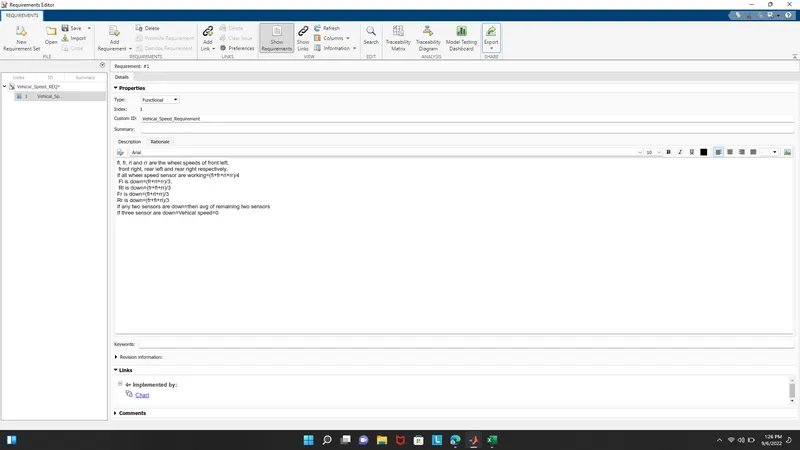
fl, fr, rl and rr are the wheel speeds of front left, front right, rear left and rear right respectively.
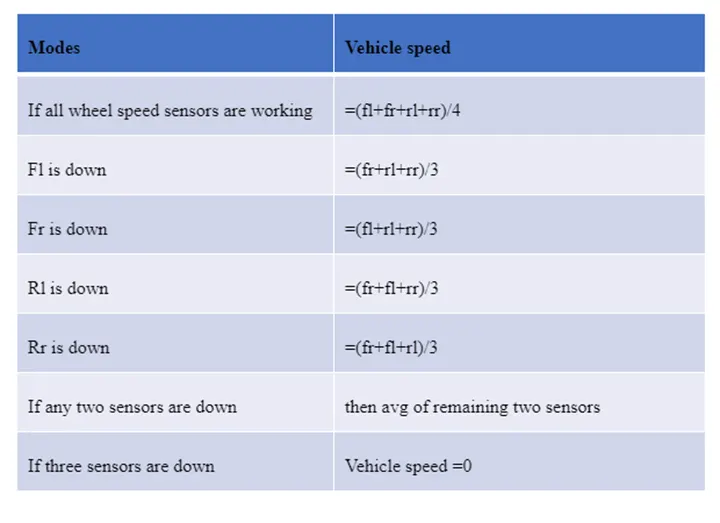
Note: Based on the conditions, requirements can be framed up.
1.Simulink/state flow modules for wiper control system
Aim:
To develop a Simulink/state flow modules for wiper control system based on the given conditions.
Conditions:
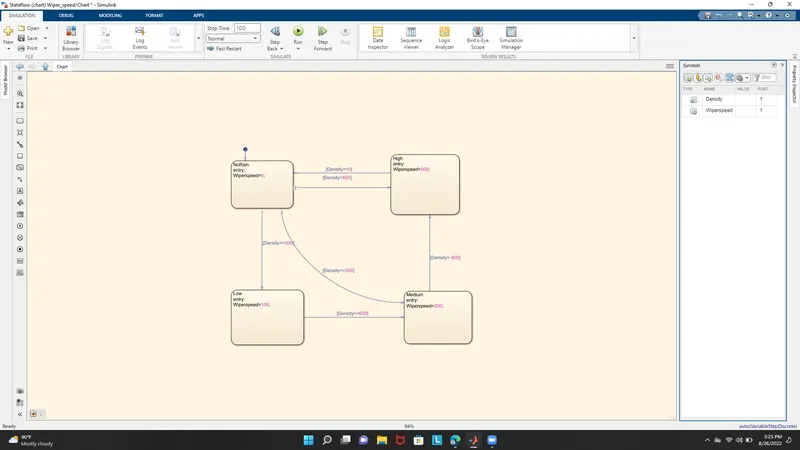
- If the density of the rain is low, then wiper rotates with low speed, the output signal should be 100rpm
- If the density of the rain is medium, then wiper rotates with low speed, the output signal should be 200rpm
- If the density of the rain is high, then wiper rotates with low speed, the output signal should be 500rpm
1. Simulink model file
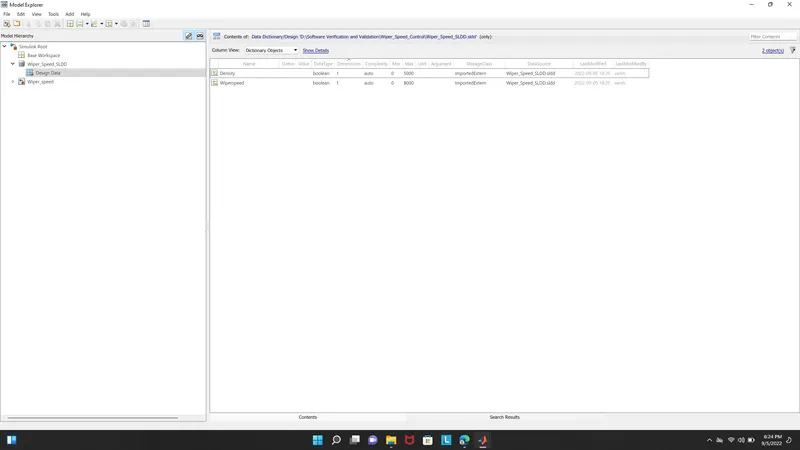
2.SLDD file
3. Requirement tagging report
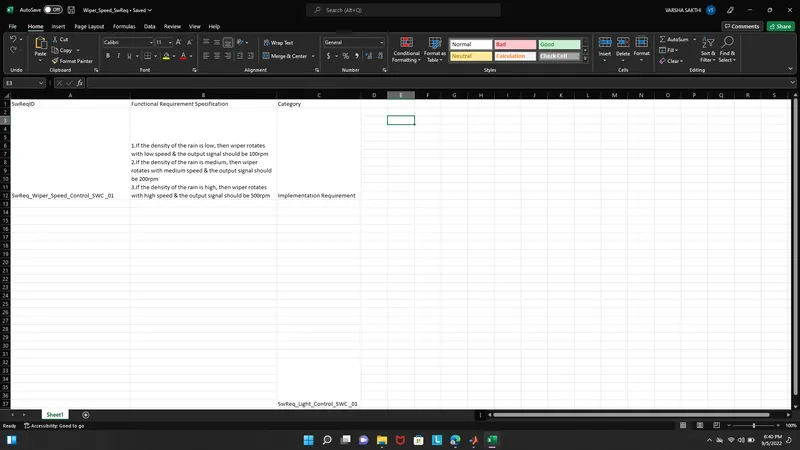
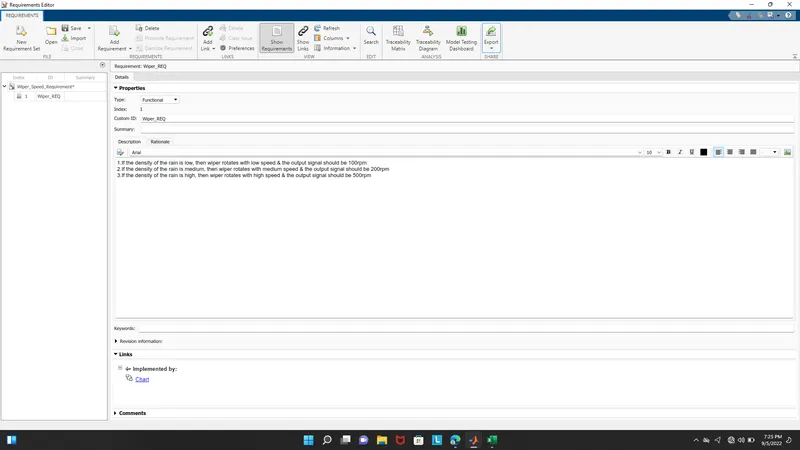
4.Model advisor - JMAAB compliance report
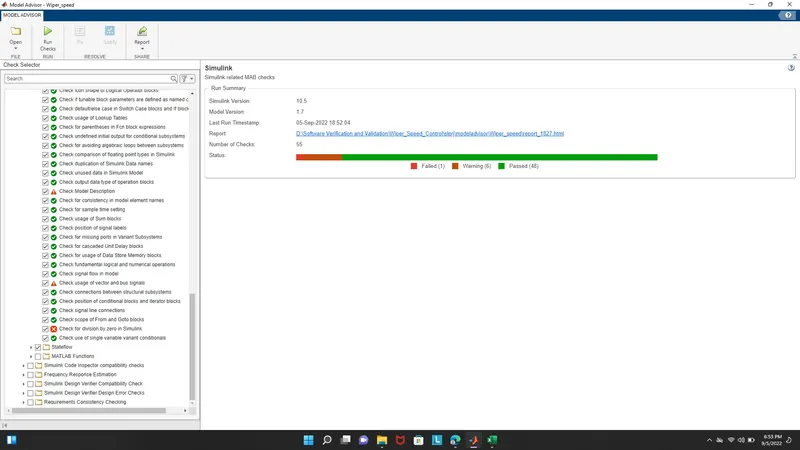
5.Fixed-point Tool
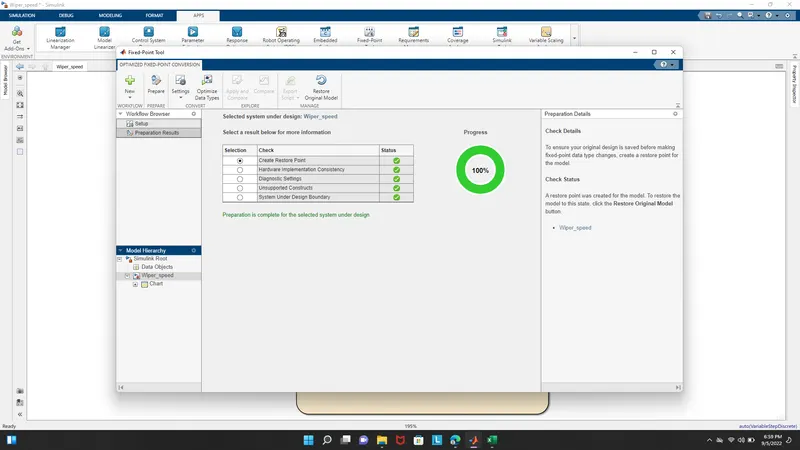
6.SLDV Design error detection report
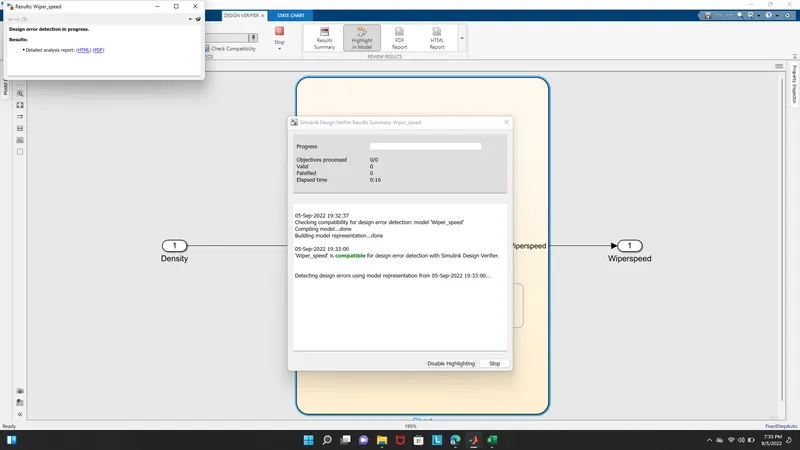
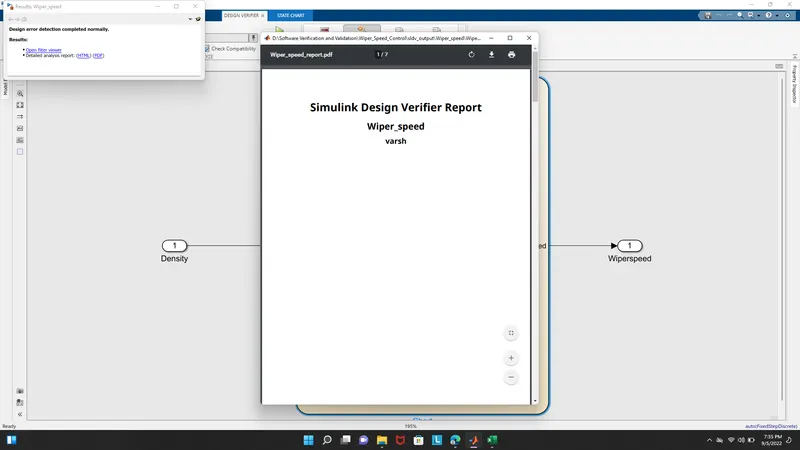
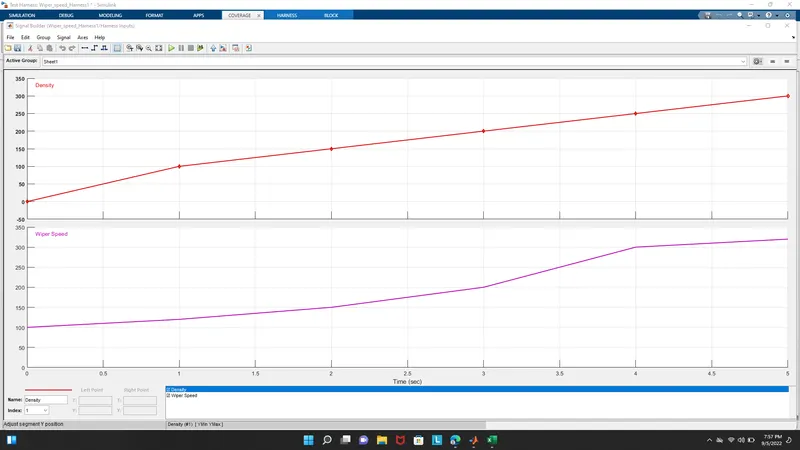
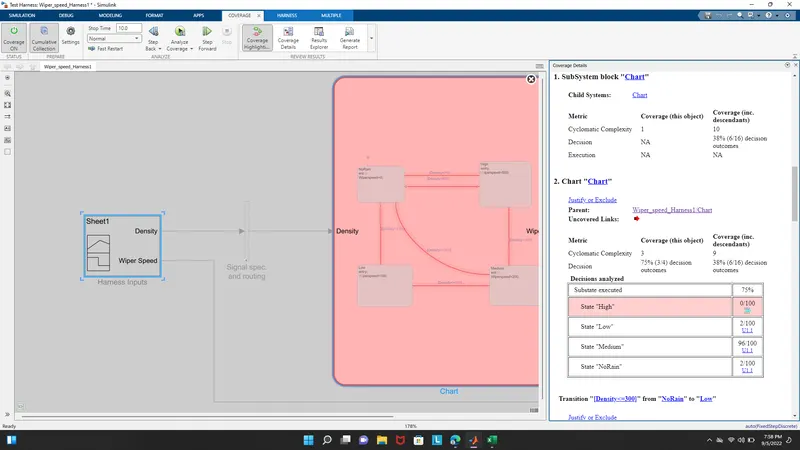
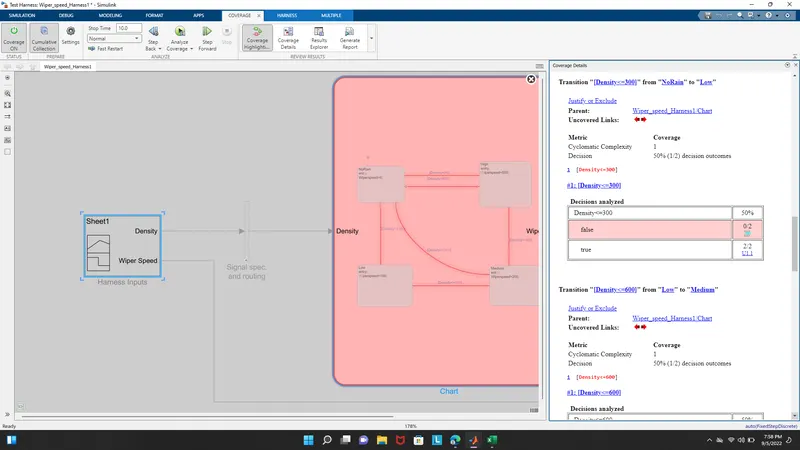
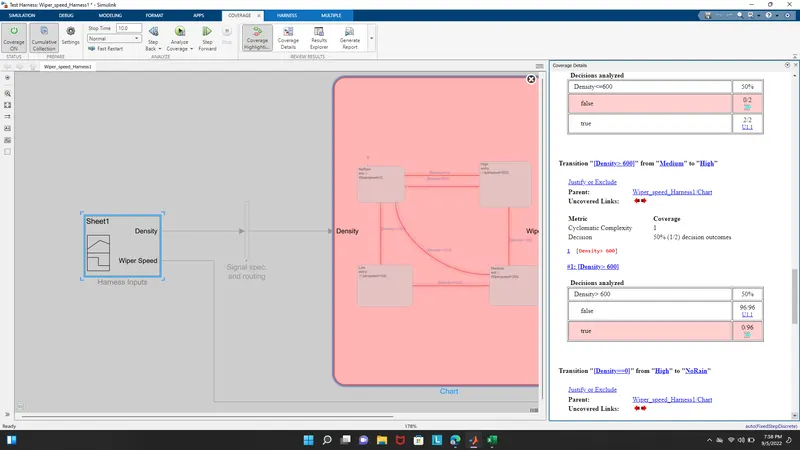
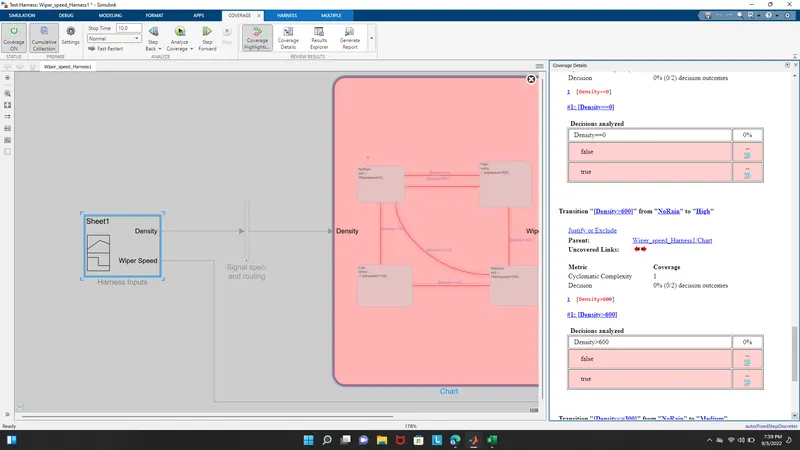
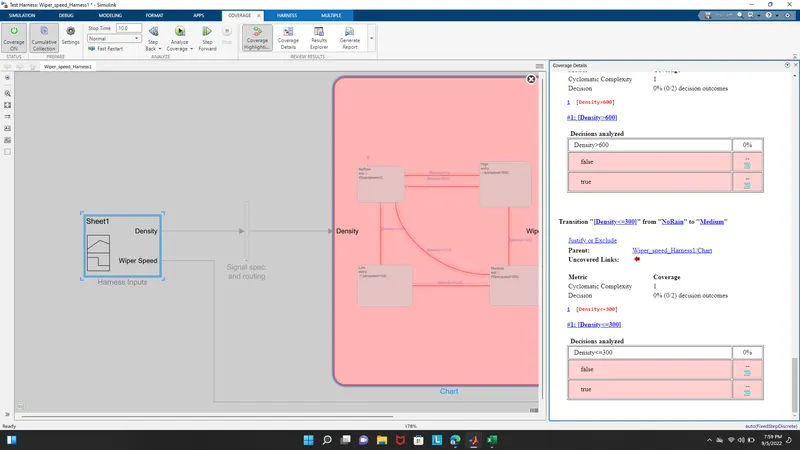
7.Functional test case, MIL, SIL harness, coverage Reports
MIL
Signal Builder
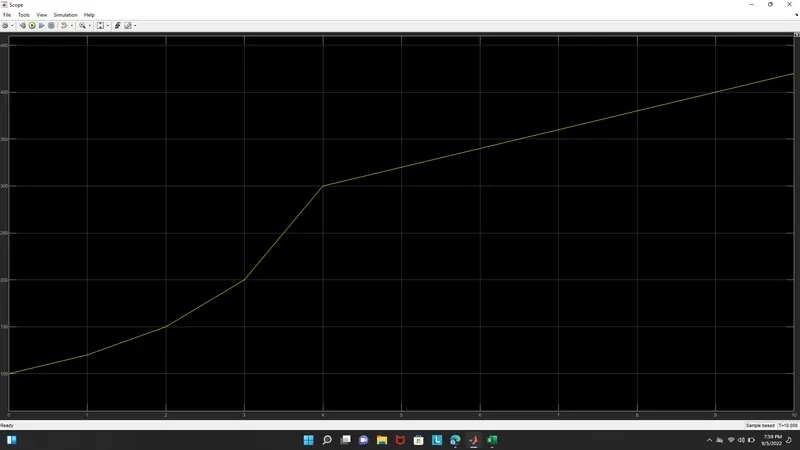
Output of Scope
SIL
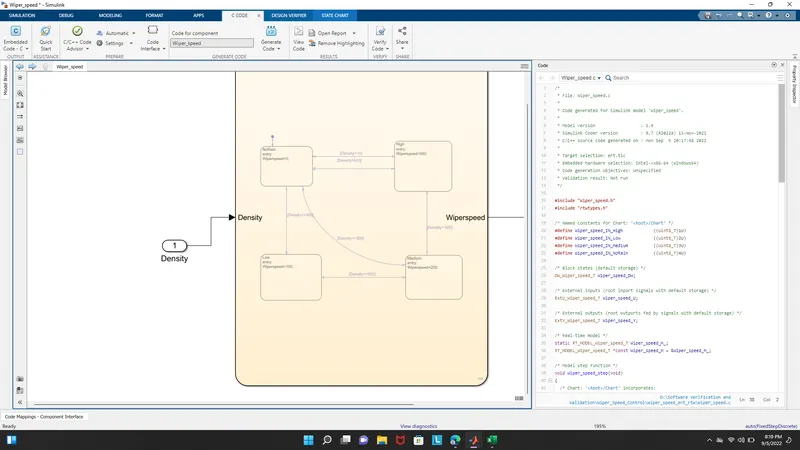
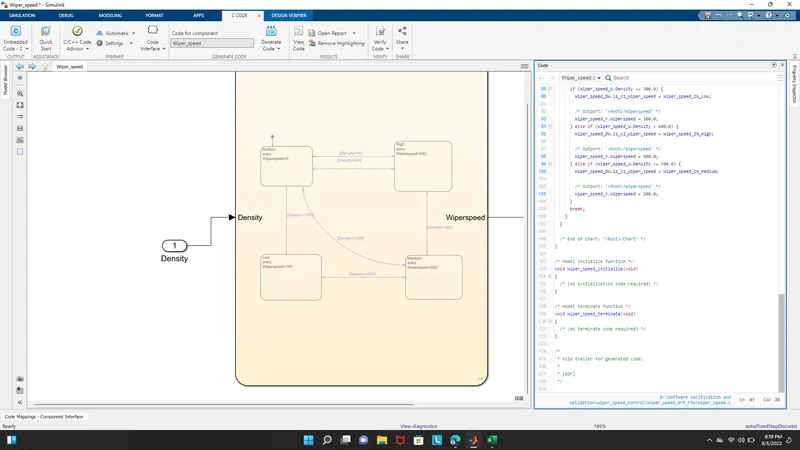
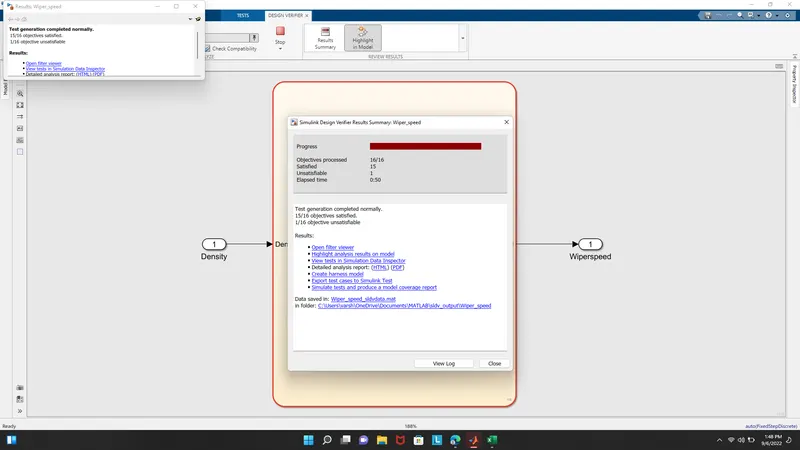
8.SLDV test generation report
9. Poly space analysis report / outputs
Steps to create a Polyspace Report:
- Initially, open the Polyspace in that new project click on start new project.
- The Project Properties dialogue box will open in that give the project name as we saved in the MATLAB,then select the location where it we need to save after that click Next or use the default location.
- Then ,it asks for the Projrct source,click on browserand select the folder where th .c file are generated then optionally we can add the include folder then clock on finish,the polyspace environment will open.
- In the configuraton settings option called Target & compiler select the source code language as c,change the target processor as X86_64.
- In the coding standards & code Metrics in that enable the check MISRA C:2004 also select the calculate the code metrics option
- After that go to bug finder analysis under that select the default one.
- Go to reporting enable the generate report option and ouput formet as PDF or any file we need
- Finally save the polyspace and run the Bug Finder.
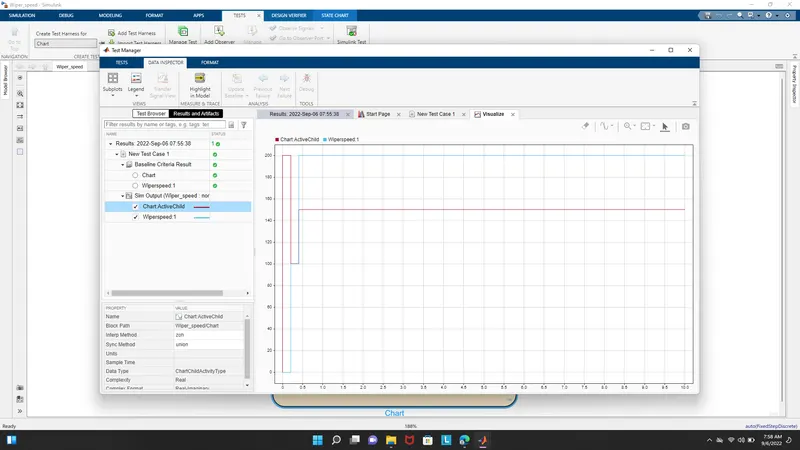
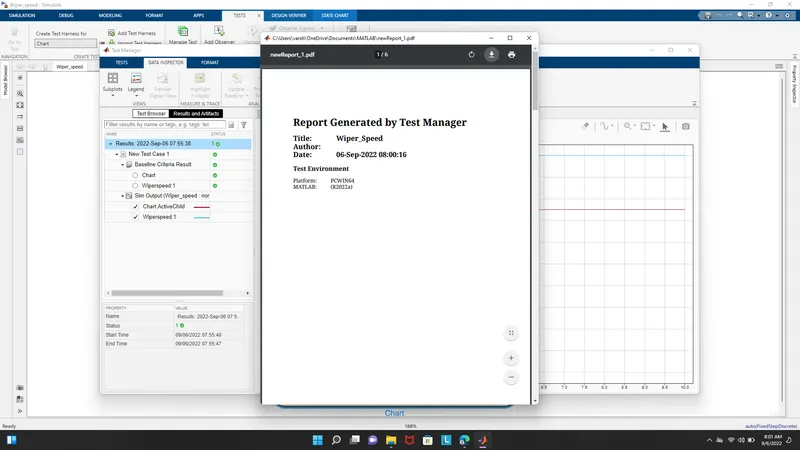
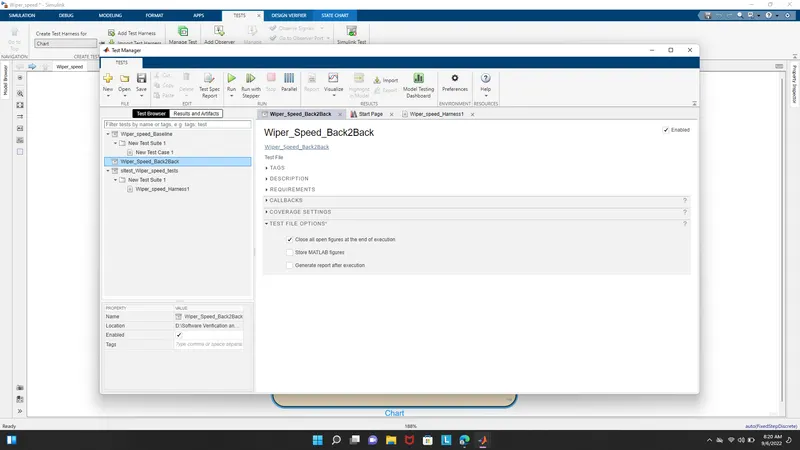
10.Test manager reports – baseline & back-to-back testing
Baseline Report
Back to Back Test Report
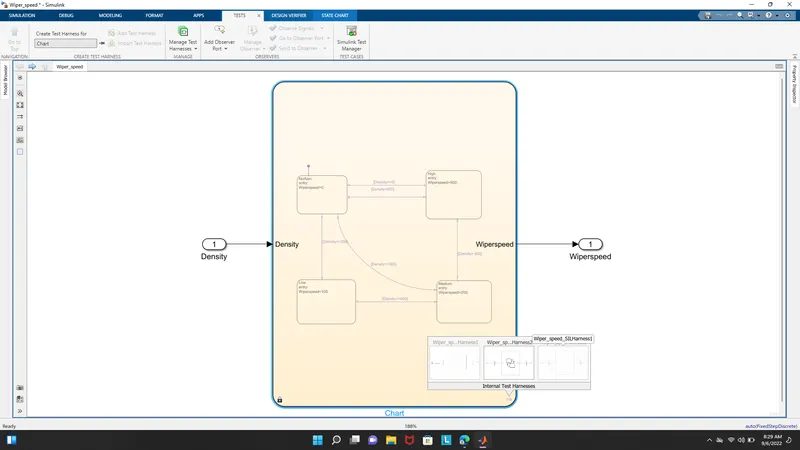
Output:
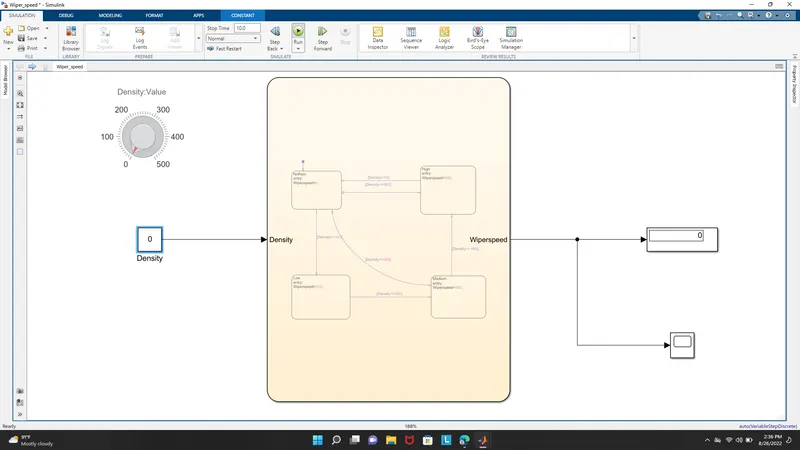
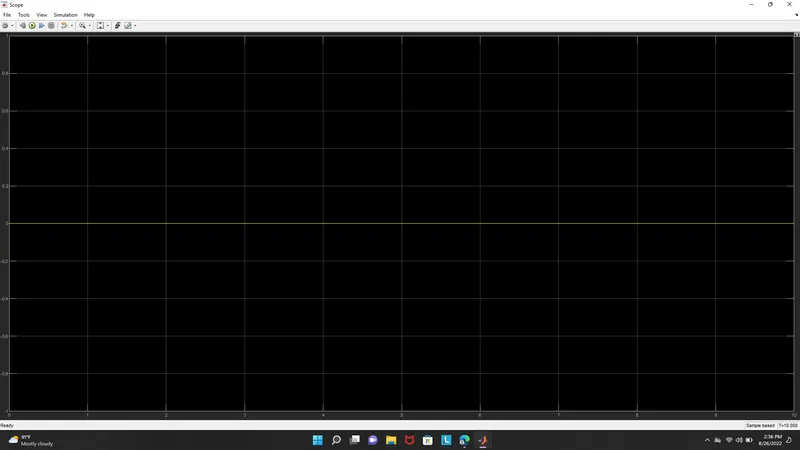
At off stage:
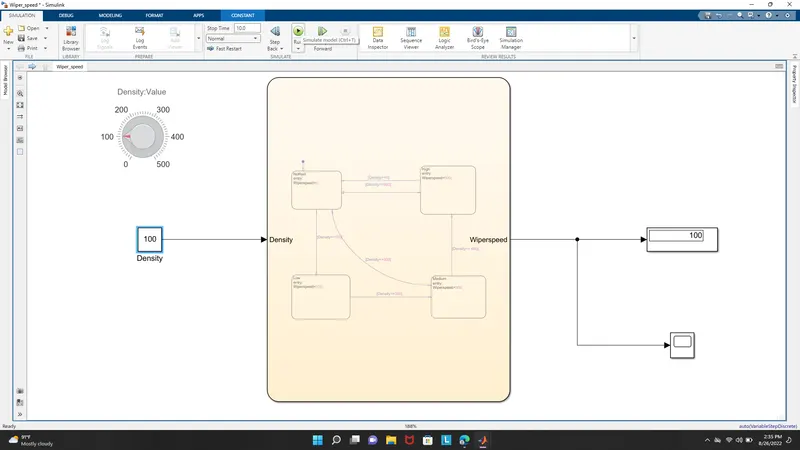
At low Density:
At Medium Density:
At high Density:
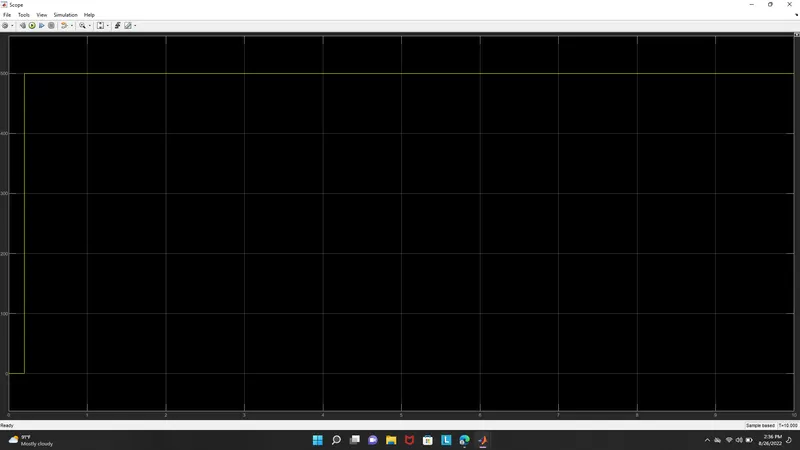
Resuli:
The expected output is obtained for the simulink model for wiper control system.
2.Simulink/state flow model for vehicle speed calculation unit inside the ABS system
Aim:
To create a simulink model for vehicle speed calculation unit inside the ABS system.
Condition:
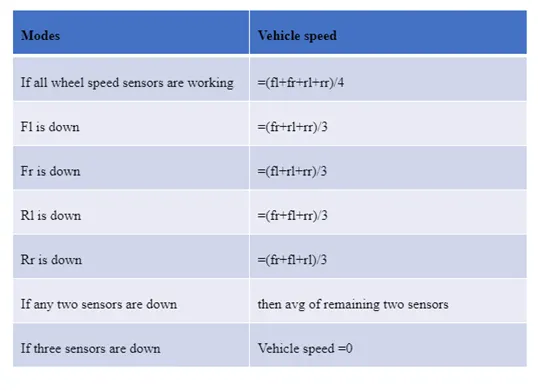
Description:
- fl-front left
- fr-front right
- rl-rear left
- rr -rear right
1. Simulink model file
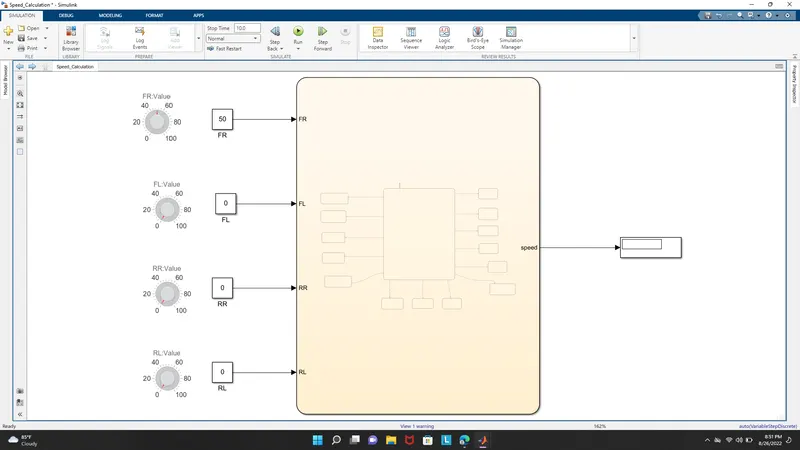
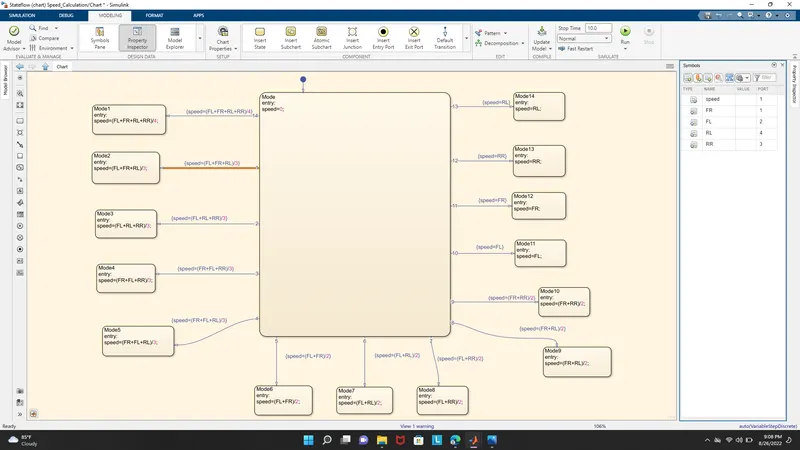
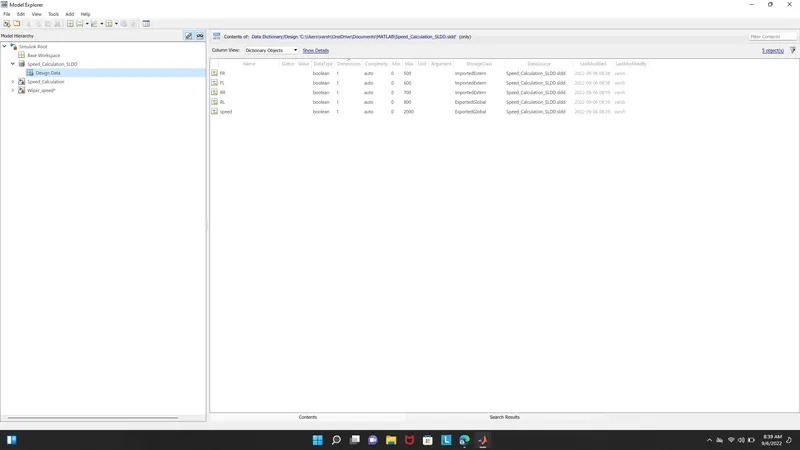
2.SLDD file
3. Requirement tagging report
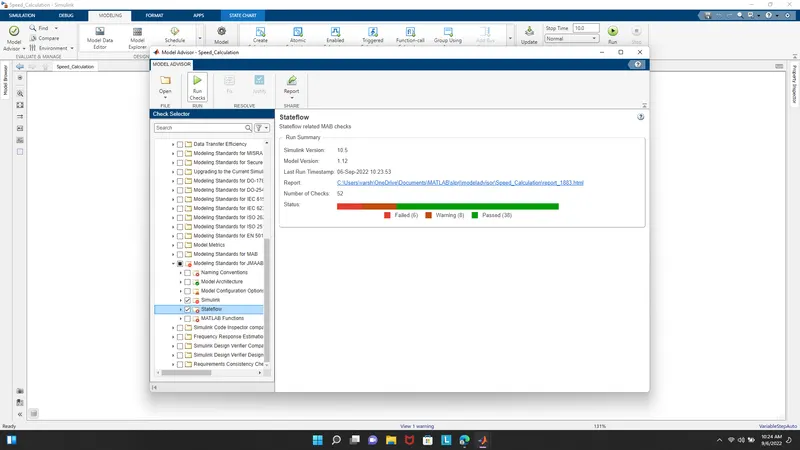
4.Model advisor - JMAAB compliance report
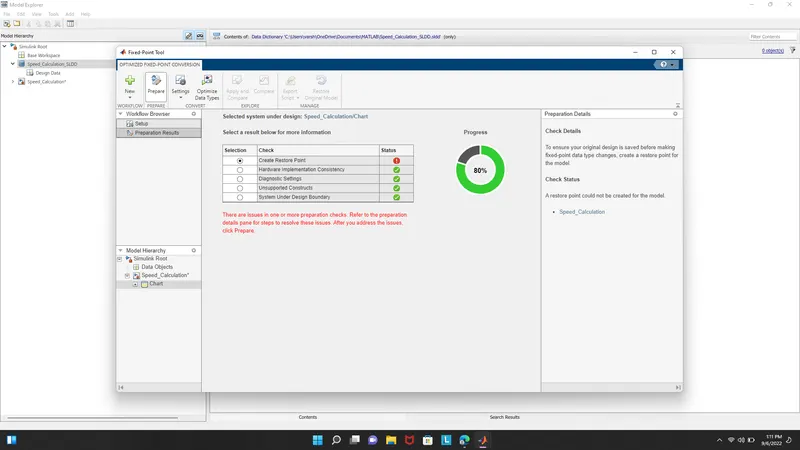
5.Fixed-point Tool
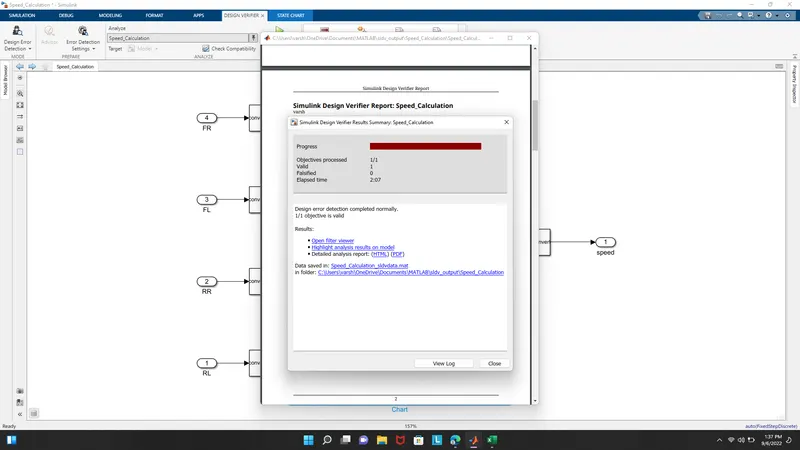
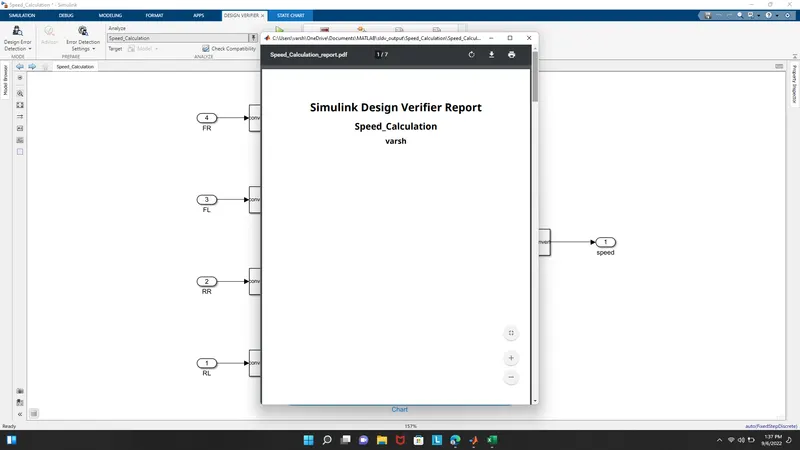
6.SLDV Design error detection report
7.Functional test case, MIL, SIL harness, coverage Reports
MIL
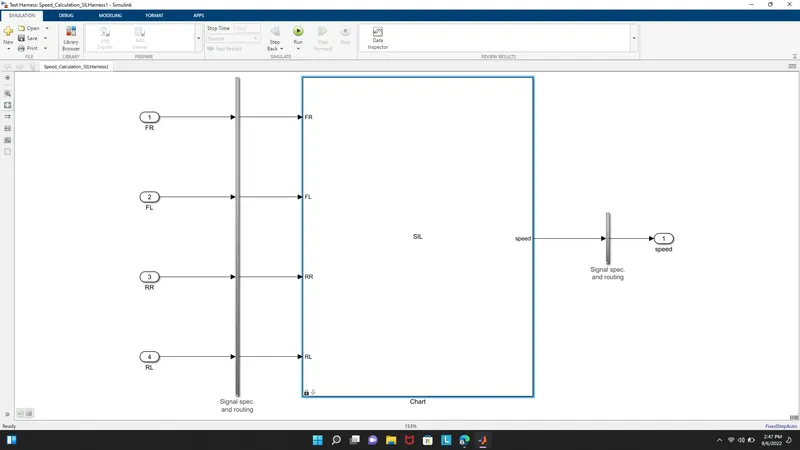
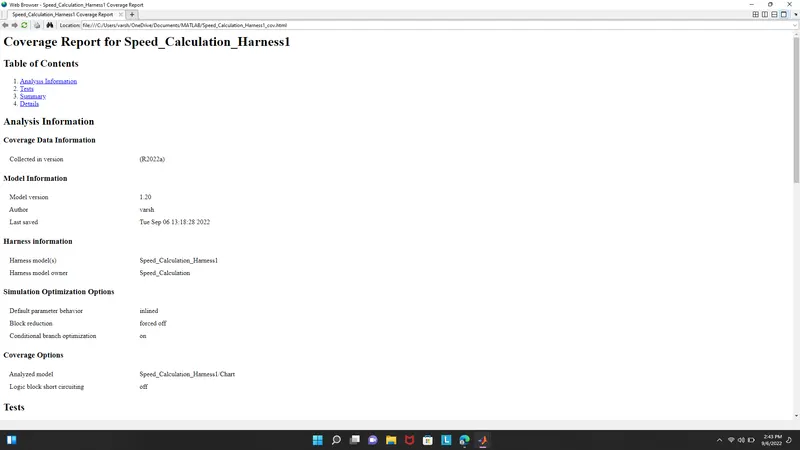
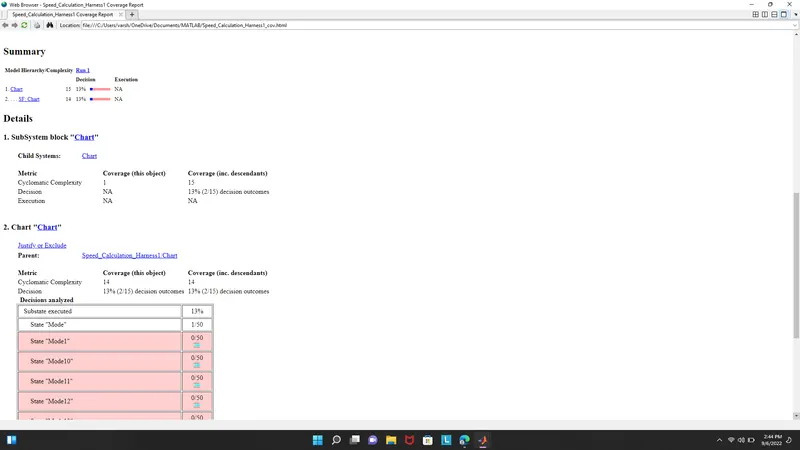
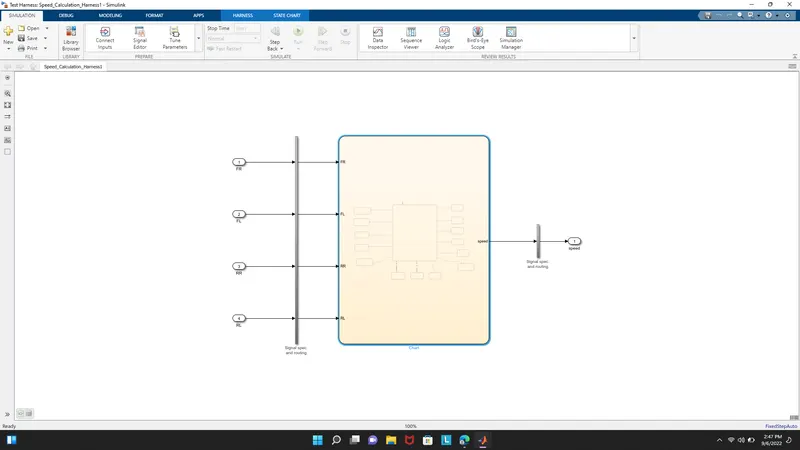
SIL
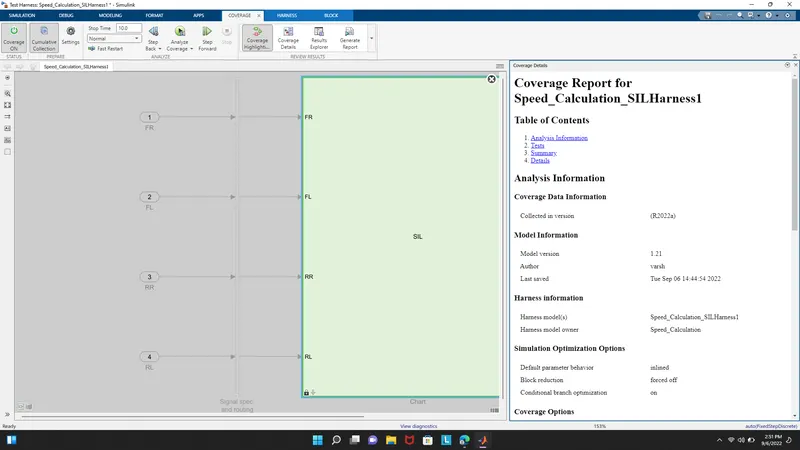
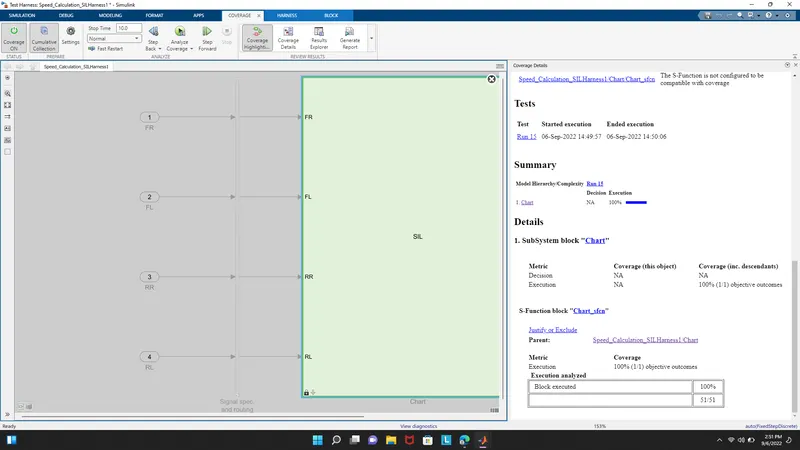
8.SLDV test generation report
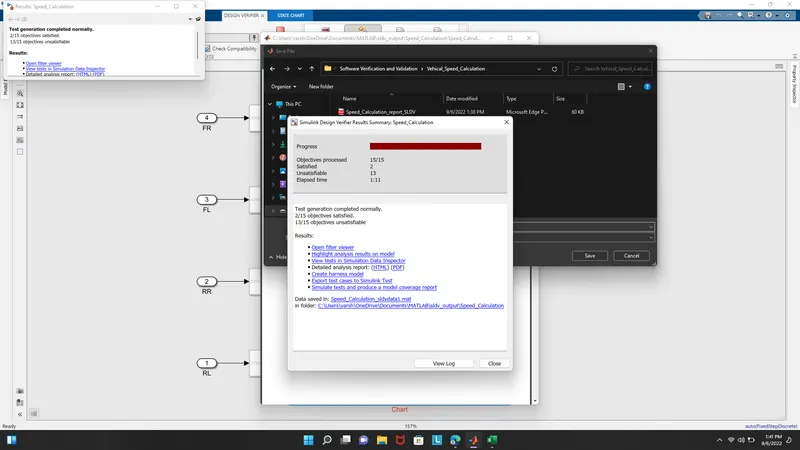
9. Poly space analysis report / outputs
Steps to create a Polyspace Report:
- Initially, open the Polyspace in that new project click on start new project.
- The Project Properties dialogue box will open in that give the project name as we saved in the MATLAB,then select the location where it we need to save after that click Next or use the default location.
- Then ,it asks for the Projrct source,click on browserand select the folder where th .c file are generated then optionally we can add the include folder then clock on finish,the polyspace environment will open.
- In the configuraton settings option called Target & compiler select the source code language as c,change the target processor as X86_64.
- In the coding standards & code Metrics in that enable the check MISRA C:2004 also select the calculate the code metrics option
- After that go to bug finder analysis under that select the default one.
- Go to reporting enable the generate report option and ouput formet as PDF or any file we need
- Finally save the polyspace and run the Bug Finder.
10.Test manager reports – baseline & back-to-back testing
Baseline Test Report
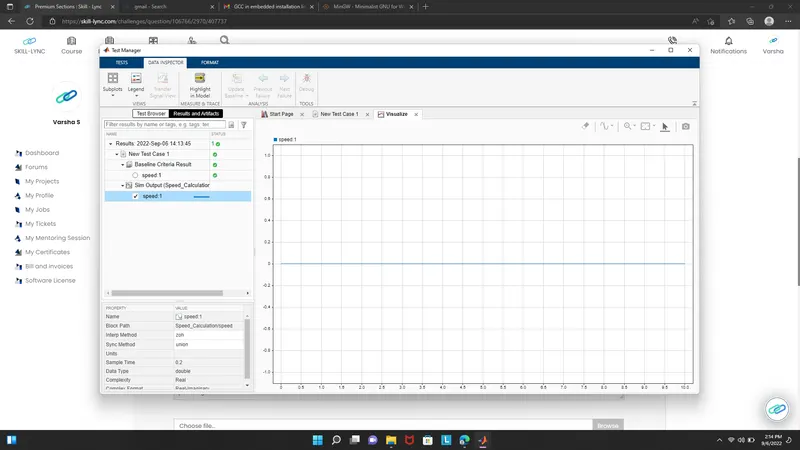
Back to Back Report
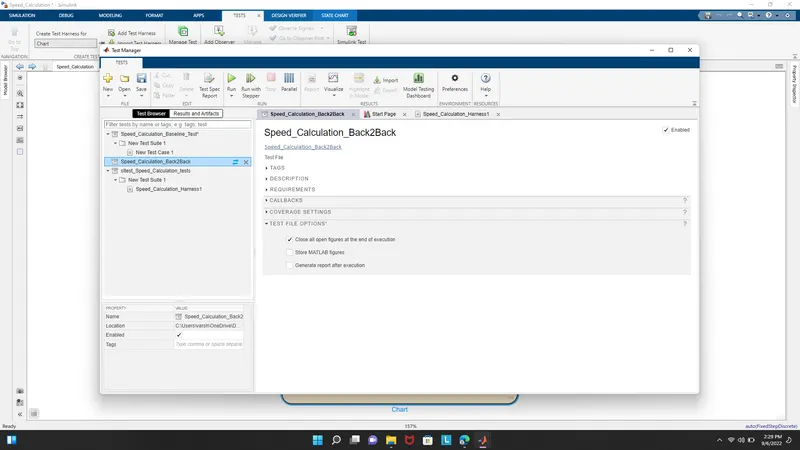
If all the wheel speed sensor are working
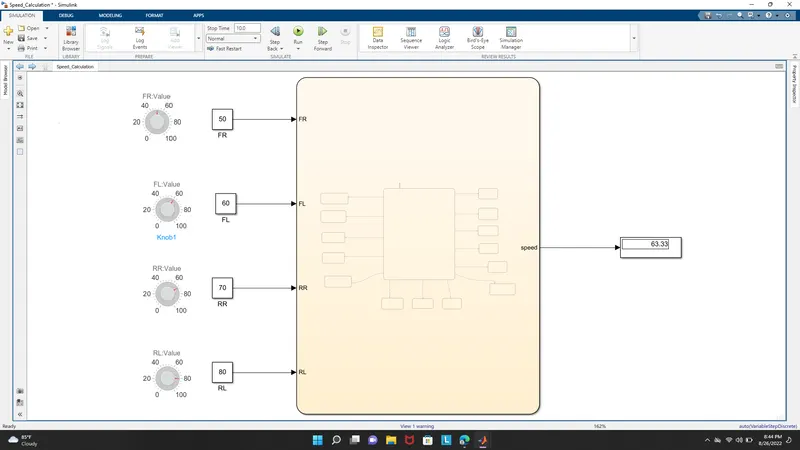
Output:
If any one wheel is down
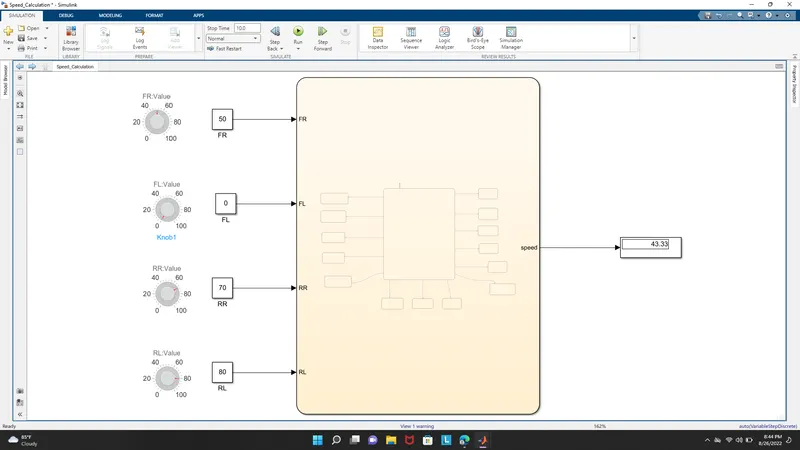
If any two wheel is down
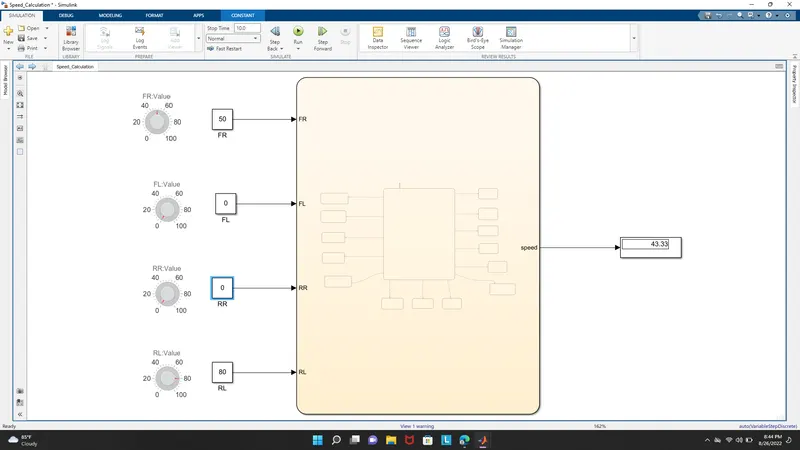
If any three wheel is down
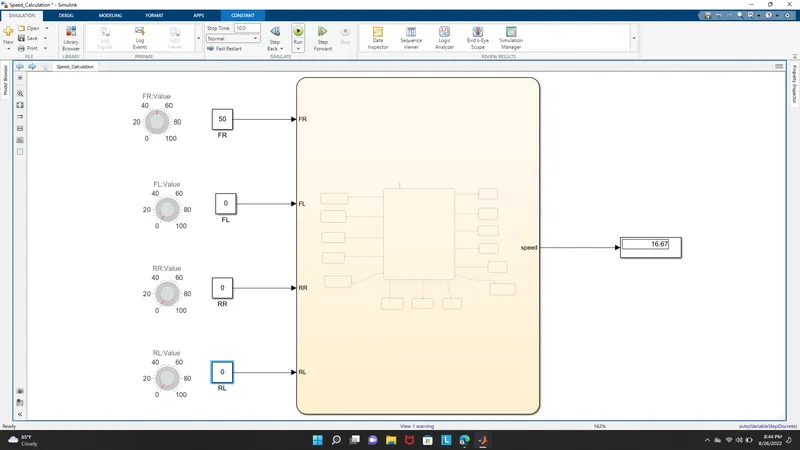
Result:
The expected output is obtained for the simulink model for vehicle speed calculation unit inside the ABS system.