Final Project: Electric Rickshaw modelling
Title (‘Create a MATLAB model of Electric Rickshaw which uses a battery and a DC motor.’)
Shaik_Thasleem_Ansari
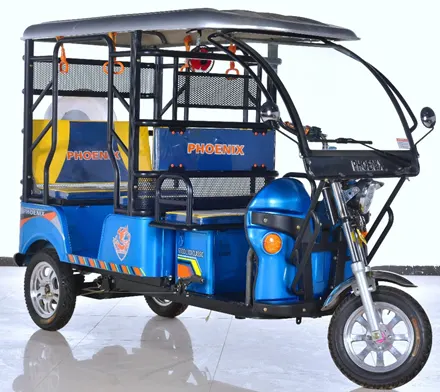
Electric Rickshaw:
Objectives:
- System level configurations
- Model parameters
- Results
- Conclusion
Aim: To create a mathematical model of an Electric Rickshaw which runs by using DC-Motor and DC-Voltage as a source.
Introduction:
In this report we came to know about the performance of Electric vehicle, and reaction of vehicle to Sudden accelerations and decelerations paths of the duty cycle, by using Simulink simulation software.
Simulink is the simulation software which is used to create the mathematical models of actual real-world systems, and simulate them by using Simulink software. Mathematical model is a combination of small systems which combined works like an actual system.
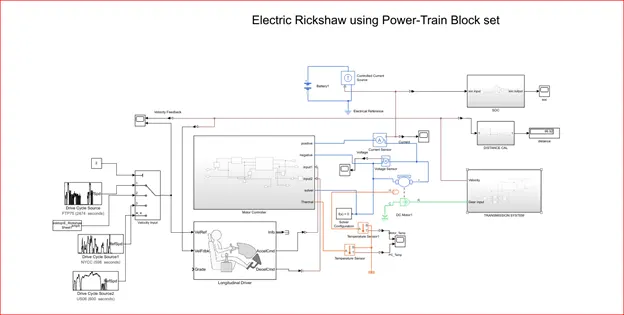
The mathematical model is created by using MATLAB Powertrain block set.
Theory:
“Electric Rickshaw” Name itself tells us that the vehicle receives propulsion power by using only electrical energy, this energy is supplied by Batteries which are arranged in series/parallel combination. These vehicles are becoming popular, thanks to the traditional “Internal Combustion” Engines.
Using electrical energy is one of the major advantages, because of that have a potential to reduce greenhouse gas emissions, reduce dependences on petroleum, can reduce the air pollution.
The performance of the Electrical vehicles can be increased by using more efficient power convertors and other electrical components.
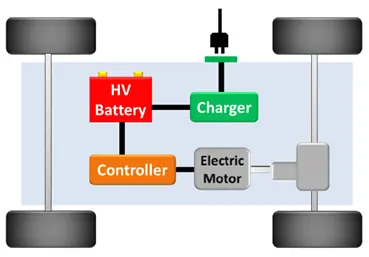
Battery:
Batteries are considered as the important component of the electric vehicle, not only provides propulsion power to vehicle but also decides the performance of the total vehicle. Design and to develop a perfect EV we need a perfect battery which provides enough amount of energy during every situation without any lag in supply.
Drive system:
Transfers the mechanical energy to the traction wheels in order to generate motion.
Electric motor:
Used to propel the electric Rickshaw, this can be an either a DC/AC Motor. Using perfect motor decides the performance of the electric vehicle.
Motor controller:
Which controls the flow of current from battery to motor, that controlled flow of voltage is used to control the movement of Motor which in further controls the movement of vehicle.
System level configurations:
- 300 V DC Voltage battery is used as a power source
100 V DC Motor is used in this Mathematical Model. FTP75 Drive cycle which runs about 2474 sec, NYCC runs for 598 sec and US06 runs for 600sec.
- Transmission system: H-Bridge are the blocks selected from the power train block set. Vehicle body simulated with 4 tires using Magic formula.
Model Parameters:
Transmission system:
The below picture is the subsystem of transmission system.
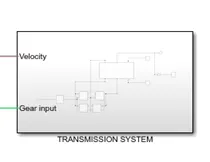
The below picture shows the connection between different powertrain blocks.
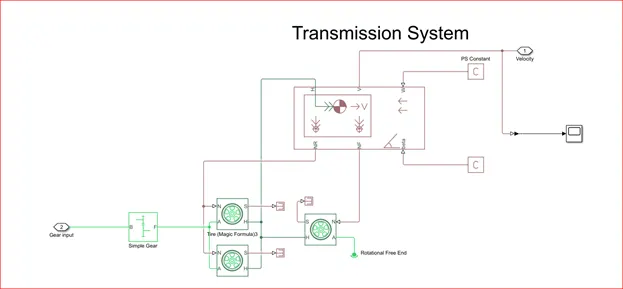
Mechanism which is used to transmits the generated power from motor to the driving wheels.
In this mathematical model vehicle body and tires blocks are used.
Tire:
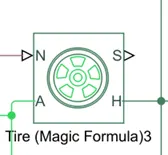
The Tire (Magic Formula) Represents the longitudinal behavior of a tire. This block is built from the Tire-Road interaction. The longitudinal direction is as same as direction of motion of tire on road.
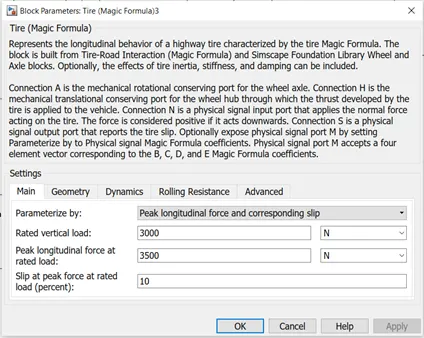
Block Parameters:
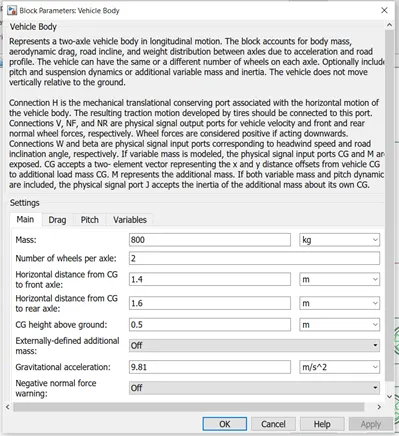
Vehicle Body:
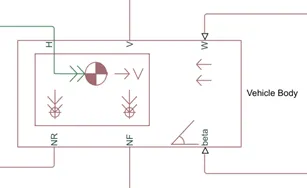
The above block Represents the vehicle body, which has two axles in longitudinal motion. The above has six ports which represents Hub connection, velocity, wind velocity, Normal to the front and rare axle and gradeability. It gives access to add the number of wheels to the per axle, pitch and suspension dynamics or additional variable mass of inertia.
Block Parameters:
Motor controller:
This is used to control the flow of power from the battery to the Motor in order to control the speed of the vehicle.
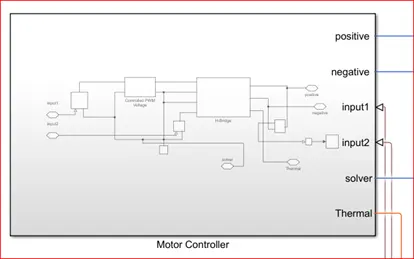
The below picture shows the connection between different controllers.
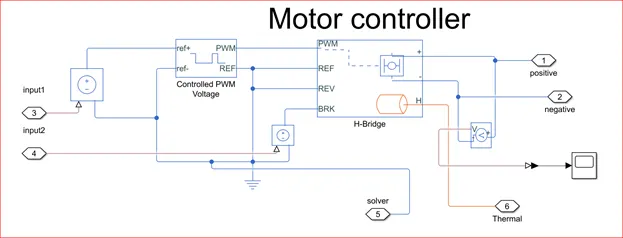
Block used to control the power flow are:
- H-Bridge with thermal port.
- Controlled PWM Voltage
- Controlled voltage source
- Voltage sensor
H-Bridge with thermal port:
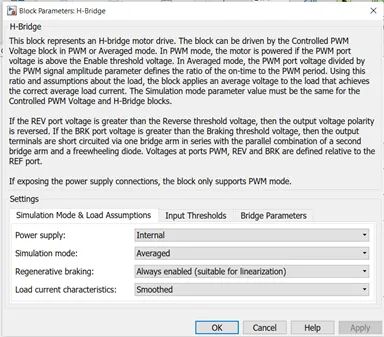
At switching condition Bipolar Junction Transistor is acts like IGBT. H-bride BJT is taken in order to maintain the Torque and Speed Characteristics of the DC Motor.
The control signals which are generated by Comparator, these signals are generated by Analyzing the position of Acceleration pedal and brake pedal.
The Switching operation is performed by the BJT semiconductor according to the received control signals. In this model GOTO and FROM blocks are used for sending and receiving the control signals.
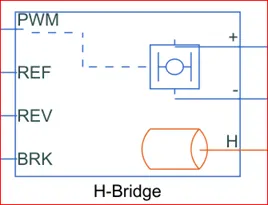
The above block has 4 ports they are Pitch Width Modulation Receiver, Reference port, Reverse Port, Brake port.
PWM Receiver is used to receive the controlled voltage signals from controlled PWM generator. PWM wave is generated by the OP-AMP by comparing the carrier signal and modulated signal and later send to the comparator, where the signals are modulated according the Movement of Accelerator pedal and Brake pedal.
Block Parameters:
PWM Generator:
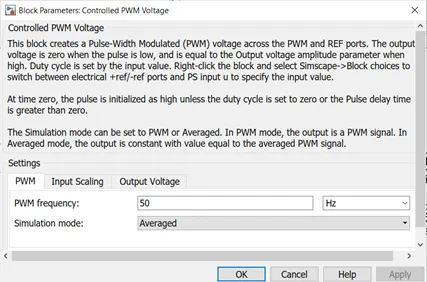
Pitch width modulation technique is a modulation technique generates different widths of voltages with respect to time which control the flow current in to the Load.
This technique is used in many applications where it needs to control the speeds and other parameters of load, by controlling the voltages supply with respect to time. This output is supplied to the microprocessor controller where it sends signals in form of 1 and 0 to gates drivers in-order to control the switching speed of transistor.
Block Parameters:
Longitudinal driver:
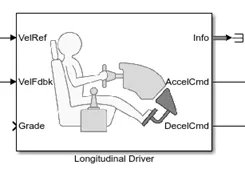
The above block is used to send the controlled signals of Acceleration and brake commands to the controlled PWM generator in order to generate the PWM signals. It receives the Feedback about the movement/velocity of DC Motor.
The whole movement of vehicle is totally depending on the longitudinal driver block.
Drive-Cycle:
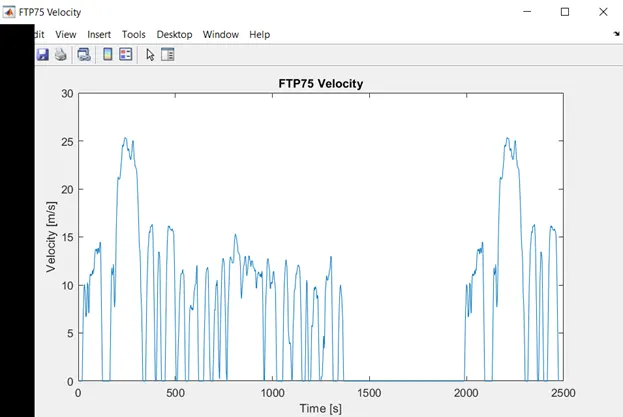
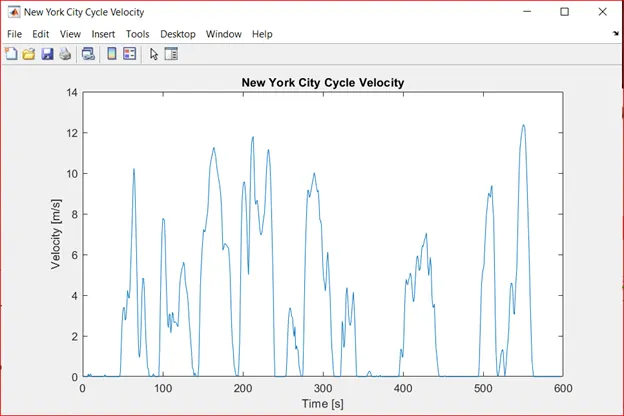
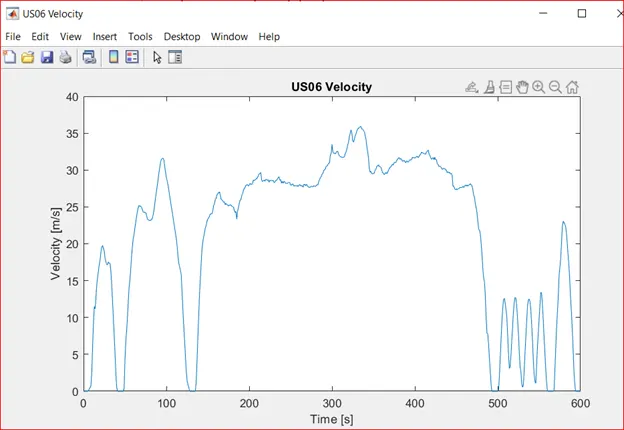
Drive cycle gives information about the speed of vehicle with respect to time, FTP75 drive cycle is used in this Mathematical Model. The vehicle runs about 2475 sec, From the above parameters the vehicle runs about 4.135Km.
Power source:
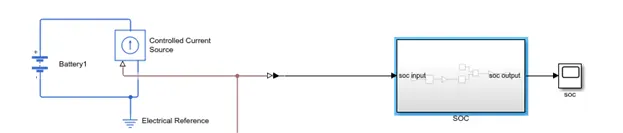
Where the Battery of 300 V is used to supply the power to DC Motor. Where the battery gets charged during decelerations and regenerative braking conditions, this battery charging condition is shown by state of charge block.
The below picture shows the connection of blocks like rate transition and time integrator in-order to obtain State of charge of the battery.
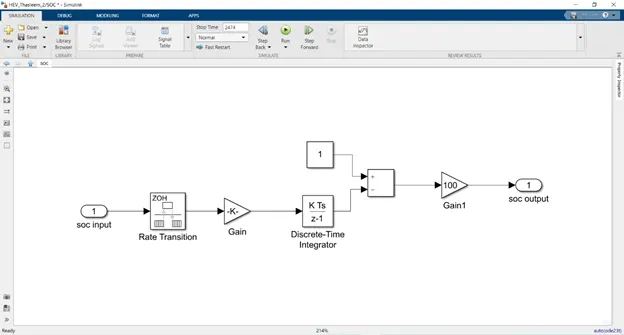
Mathematical Model of Electric Rickshaw:
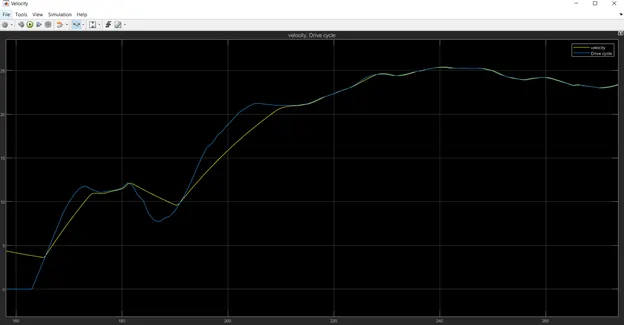
Velocity Feedback Results:
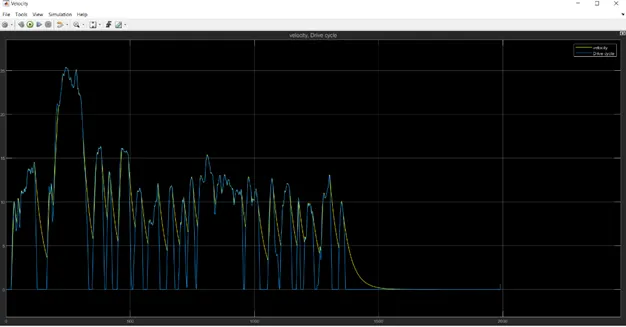
The above image shows the how the vehicle speed changes with respect to time. The blue curve represents the drive cycle path and yellow curve represent the vehicle speed. We can see that the vehicle does not follows the drive- cycle path perfectly there will be many reasons behind it, one of the reasons is the inertia of the vehicle, it does not let vehicle to conserve more amount of during short time, so the deceleration path is not that perfect as acceleration path.
Result:
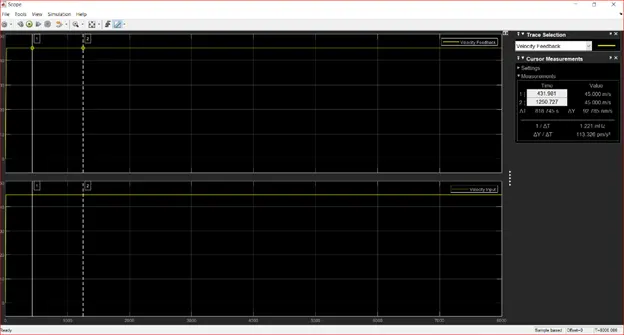
For any three standard driving cycles show energy consumption, temperature rise of motor and controller for 100 km constant speed driving at 45 kmph.
NYCC Drive cycle:
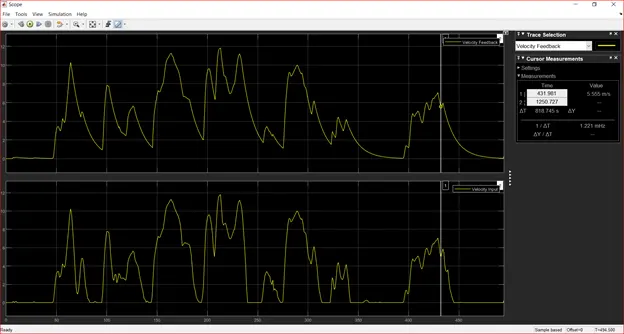
US06 Drive cycle Result;
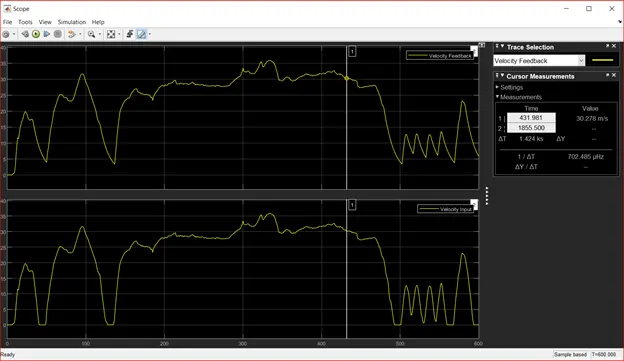
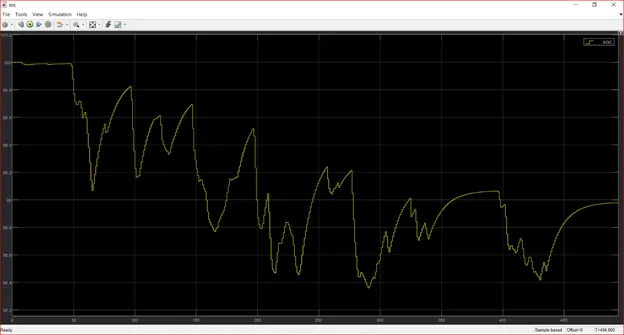
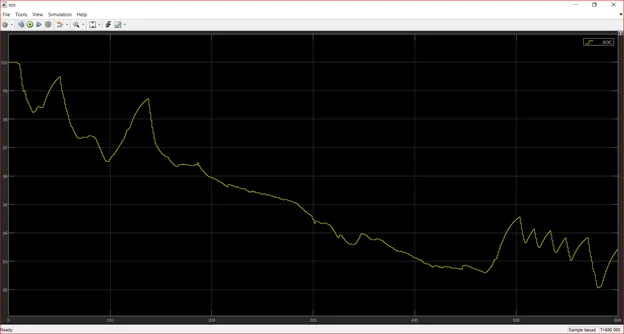
We can see the path discontinuity in below graph.
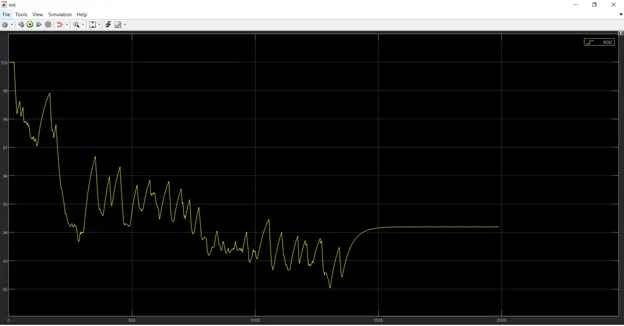
FTP75 SOC:
NYCC SOC:
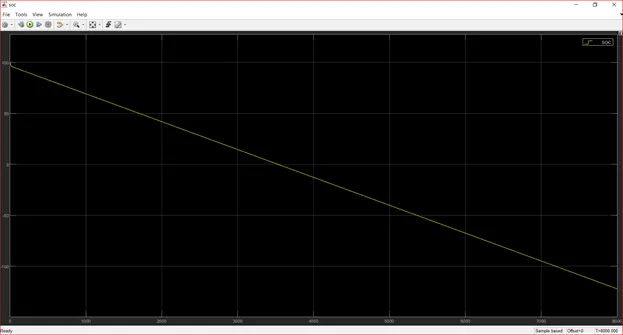
US06 SOC:
State of charge:
we can see the state of charge of the battery, it still has charge so that it can perform another drive cycle, to know how much distance vehicle can travel we need to add extra drive cycle.
to know the SOC (State of Charge) of the battery and to know how much distance vehicle can travel, the count of the drive cycle has to be increase to further 2/3 or even more.
From the below image we can see that the battery soc is about 100% at 0 sec, it starts decreasing when the vehicle gets accelerated, the battery gets charged when the vehicle gets decelerated.
At the end of the drive cycle the state of charge of battery remains at above 95%, it because of battery gets charged while the vehicle is decelerated.
Electric Rickshaw Temperature Management:
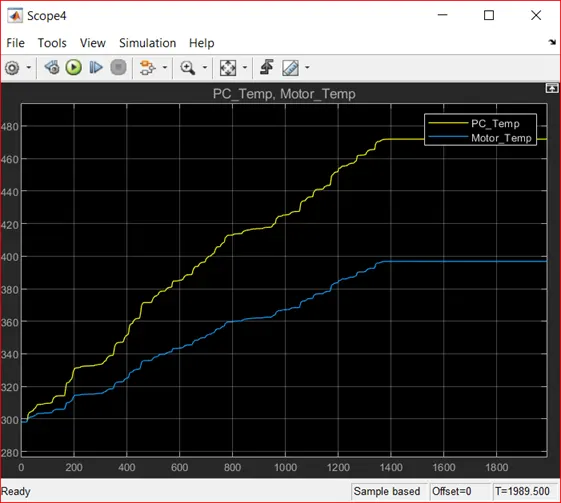
FTP75:
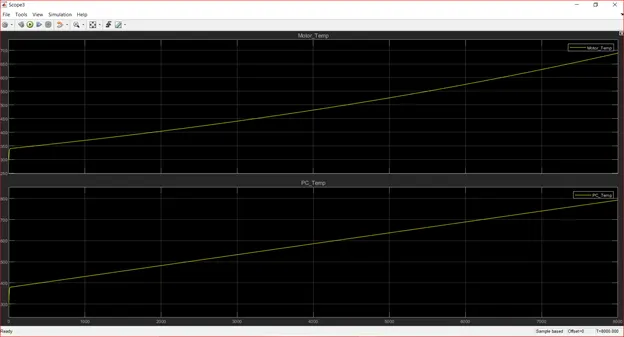
Type 2 drive cycle:
NYCC Drive Cycle:
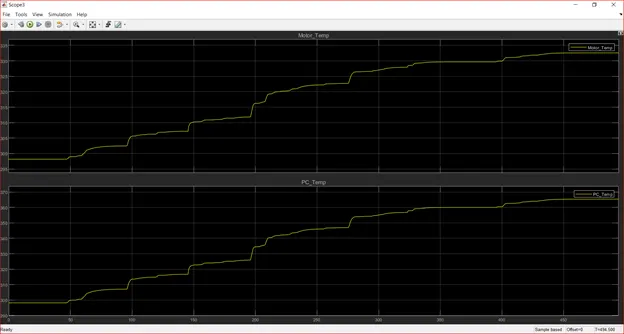
US06 Drive cycle:
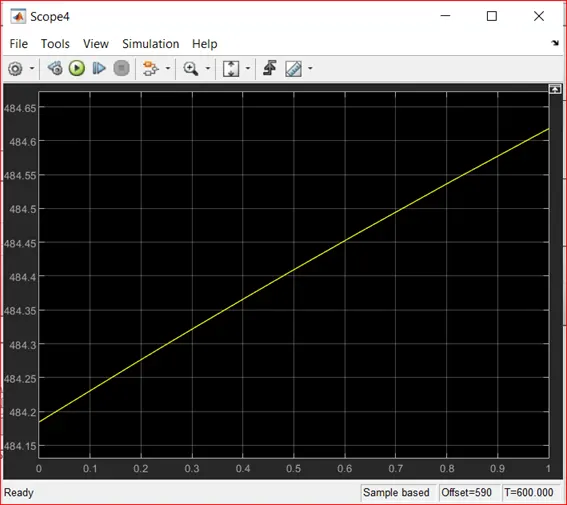
From the above results we can see that the temperature management of both DC-Motor and H bridge, The Temperature of both H-Bridge and DC Motor Management done by increasing and decreasing of Thermal Mass of both components. Thermal Mass of both components are kept as same 12000J/K, this value is further can increase if the vehicle is going to run for more time or according to load the vehicle is carrying.
Conclusion:
- Created a MATLAB model of electric car which uses a battery and a DC motor.
- Change in soc of battery is explained and calculated in above model.
- Temperature Management of both H-Bridge and DC motor get analyzed by using different drive cycles.
- Analysis on Change in vehicle speed with respect to time has been done.