Final Project: Design of an Electric Vehicle
Aim:
Introduction:
Electric car:
An electric car or battery electric car is an automobile that is propelled by one or more electric motors, using energy stored in batteries. Compared to internal combustion engine (ICE) vehicles, electric cars are quieter, have no exhaust emissions, and lower emissions overall. In the United States and the European Union, as of 2020, the total cost of ownership of recent electric vehicles is cheaper than that of equivalent ICE cars, due to lower fuelling and maintenance costs. Charging an electric car can be done at a variety of charging stations; these charging stations can be installed in both houses and public areas.
Out of all cars sold in 2020, 4.6% were plug-in electric, and by the end of that year there were more than 10 million plug-in electric cars on the world's roads, according the International Energy Agency. Despite rapid growth, only about 1% of cars on the world's roads were fully electric and pug-in hybrid cars by the end of 2020. Many countries have established government incentives for plug-in electric cars, tax credits, subsidies, and other non-monetary incentives. And several countries have legislated to phase-out sales of fossil fuel cars, to reduce air pollution and limit climate change.
The Tesla Model 3 became the world's all-time best-selling electric car in early 2020, and in June 2021, became the first electric car to pass 1 million global sales. Earlier models with widespread adoption include the Japanese Mitsubishi i-MiEV and the Nissan Leaf.
Electric cars or all-electric cars are a type of electric vehicle (EV) that has a rechargeable battery pack onboard that can be charged from the electric grid, and the electricity stored on the vehicle is the only source that drives the wheels for propulsion. The term "electric car" generally refers to highway-capable automobiles, but there are also low-speed electric vehicles with limitations in terms of weight, power and maximum speed that are allowed to travel on public roads.
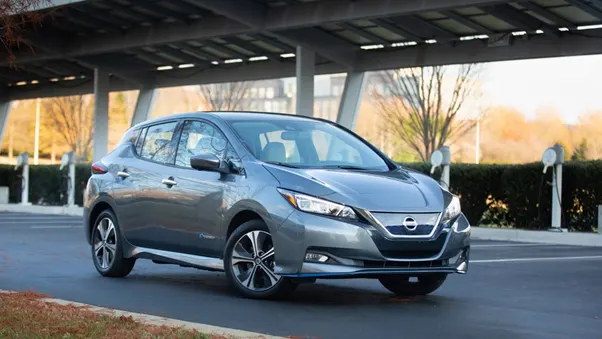
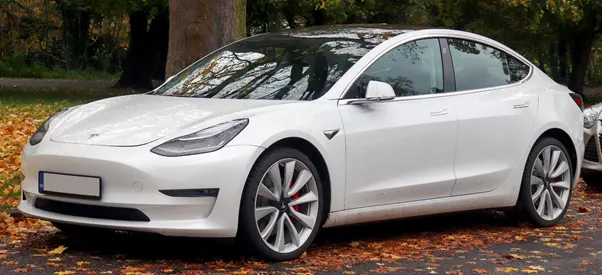
Battery Pack:
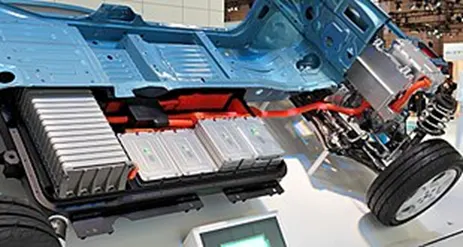
An electric-vehicle battery (EVB, also known as a traction battery) is a battery used to power the electric motors of a battery electric vehicle (BEV) or hybrid electric vehicle (HEV). These batteries are usually rechargeable (secondary batteries), and are typically lithium-ion batteries. These batteries are specifically designed for a high ampere -hour (or kilowatt-hour) capacity.
Electric-vehicle batteries differ from starting, lighting and ignition (SLI) batteries as they are designed to give power over sustained periods of time and are deep-cycle batteries. Batteries for electric vehicles are characterized by their relatively high power-to-weight ratio, specific energy and energy density; smaller, lighter batteries are desirable because they reduce the weight of the vehicle and therefore improve its performance. Compared to liquid fuels, most current battery technologies have much lower specific energy, and this often impacts the maximum all-electric range of the vehicles.
The most common battery type in modern electric vehicles are lithium-ion and lithium polymer, because of their high energy density compared to their weight. Other types of rechargeable batteries used in electric vehicles include lead-acid ("flooded", deep-cycle, and valve regulated lead acid), nickel-cadmium, nickel-metal hydride, and, less commonly, zinc-air, and sodium nickel chloride (zebra) batteries. The amount of electricity (i.e. electric charge) stored in batteries is measured in ampere hours or in coulombs, with the total energy often measured in kilowatt-hours.
Since the late 1990s, advances in lithium-ion battery technology have been driven by demands from portable electronics, laptop computers, mobile phones, and power tools. The BEV and HEV marketplace has reaped the benefits of these advances both in performance and energy density. Unlike earlier battery chemistries, notably nickel-cadmium, lithium-ion batteries can be discharged and recharged daily and at any state of charge.
The battery pack makes up a significant cost of a BEV or a HEV. As of December 2019, the cost of electric-vehicle batteries has fallen 87% since 2010 on a per kilowatt-hour basis. As of 2018, vehicles with over 250 mi (400 km) of all-electric range, such as the Tesla Model S, have been commercialized and are now available in numerous vehicle segments.
In terms of operating costs, the price of electricity to run a BEV is a small fraction of the cost of fuel for equivalent internal combustion engines, reflecting higher energy efficiency.
Create a MATLAB model of electric car which uses a battery and a DC motor. Choose suitable blocks from Powertrain block set.
EV Model on SIMULINK:
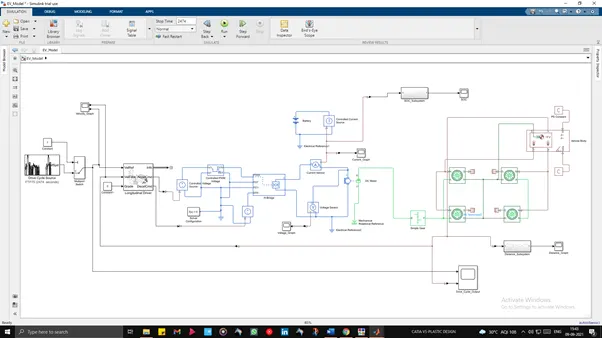
Different Blocks Explanation:
Drive Cycle Source –
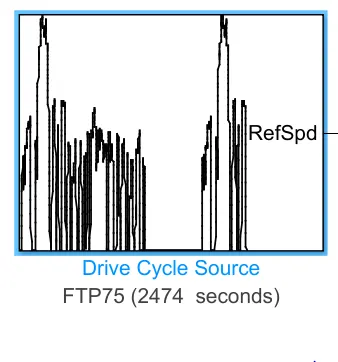
The Drive Cycle Source block generates a standard or user-specified longitudinal drive cycle. The block output is the specified vehicle longitudinal speed, which you can use to:
- Predict the engine torque and fuel consumption that a vehicle requires to achieve desired speed and acceleration for a given gear shift reference.
- Produce realistic velocity and shift references for closed loop acceleration and braking commands for vehicle control and plant models.
- Study, tune, and optimize vehicle control, system performance, and system robustness over multiple drive cycles.
- Identify the faults within tolerances specified by standardized tests, including:
- EPA dynamometer driving schedules1
- Worldwide Harmonised Light Vehicle Test Procedure (WLTP) laboratory tests
For the drive cycles, you can use:
- Drive cycles from predefined sources. By default, the block includes the FTP–75drive cycle. To install additional drive cycles from a support package, see Install Drive Cycle Data. The support package has drive cycles that include the gear shift schedules, for example JC08 and CUEDC.
- Workspace variables that define your own drive cycles.
- .mat, .xls, .xlsx, or .txt
- Wide open throttle (WOT) parameters, including initial and nominal reference speed, deceleration start time, and final reference speed.
To achieve the goals listed in the table, use the specified Drive Cycle Source block parameter options.
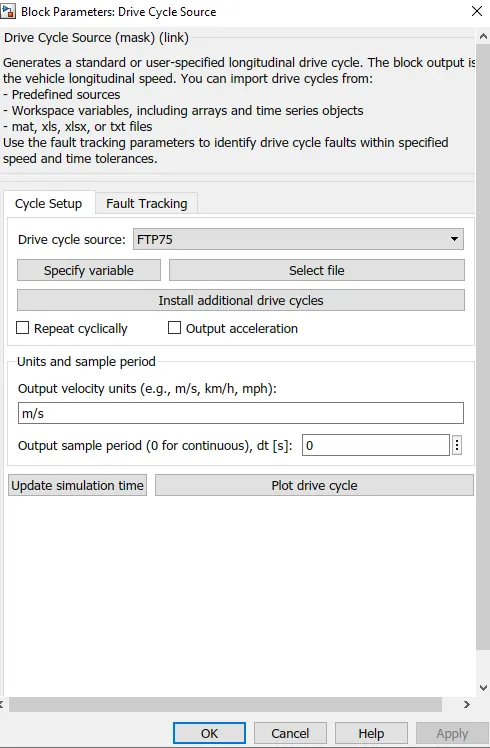
In this EV model ‘FTP75’ drive cycle source is selected. Make sure to click on the ‘update simulation time’ so that the stop time gets updated according to the Drive Cycle Source.
Longitudinal Driver:
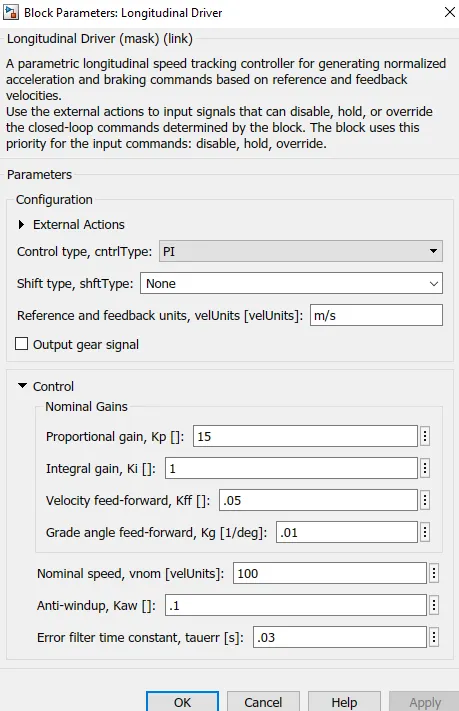
The Longitudinal Driver block implements a longitudinal speed-tracking controller. Based on reference and feedback velocities, the block generates normalized acceleration and braking commands that can vary from 0 through 1. You can use the block to model the dynamic response of a driver or to generate the commands necessary to track a longitudinal drive cycle.
Controlled voltage Source:
The Controlled Voltage Source block represents an ideal voltage source that is powerful enough to maintain the specified voltage at its output regardless of the current flowing through the source. The output voltage is V = Vs, where Vs is the numerical value presented at the physical signal port.
Controlled PWM Voltage:
The Controlled PWM Voltage block represents a pulse-width modulated (PWM) voltage source. The block has two modelling variants, accessible by right-clicking the block in your block diagram and then selecting the appropriate option from the context menu, under Simscape > Block choices:
- Electrical input ports— The block calculates the duty cycle based on the reference voltage across its ref+ and ref- This modelling variant is the default.
- PS input— Specify the duty cycle value directly by using an input physical signal port.
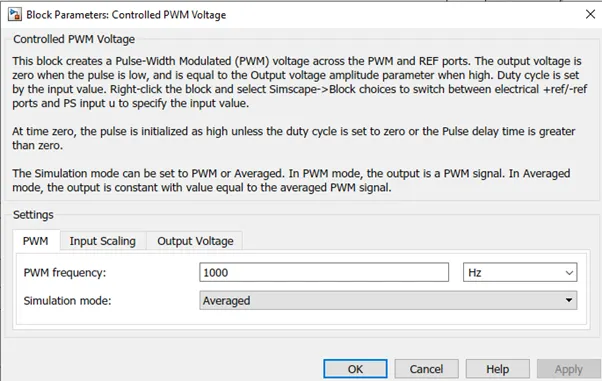
PWM frequency is set to 1000 Hz for this model
H Bridge:
The H-Bridge block represents an H-bridge motor driver. The block has the following two Simulation mode options:
- PWM— The H-Bridge block output is a controlled voltage that depends on the input signal at the PWM If the input signal has a value greater than the Enable threshold voltage parameter value, the H-Bridge block output is on and has a value equal to the value of the Output voltage amplitude parameter. If it has a value less than the Enable threshold voltage parameter value, the block maintains the load circuit using one of the following three Freewheeling mode options:
- Via one semiconductor switch and one freewheeling diode
- Via two freewheeling diodes
- Via two semiconductor switches and one freewheeling diode
The first and third options are sometimes referred to as synchronous operation.
The signal at the REV port determines the polarity of the output. If the value of the signal at the REV port is less than the value of the Reverse threshold voltage parameter, the output has positive polarity; otherwise, it has negative polarity.
- Averaged— This mode has two Load current characteristics options:
- Smoothed
- Unsmoothed or discontinuous
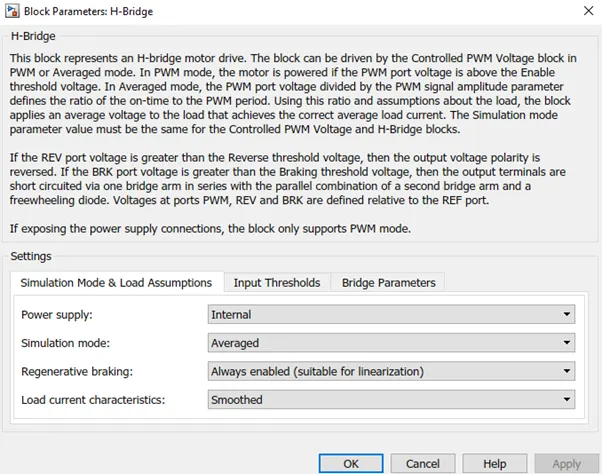
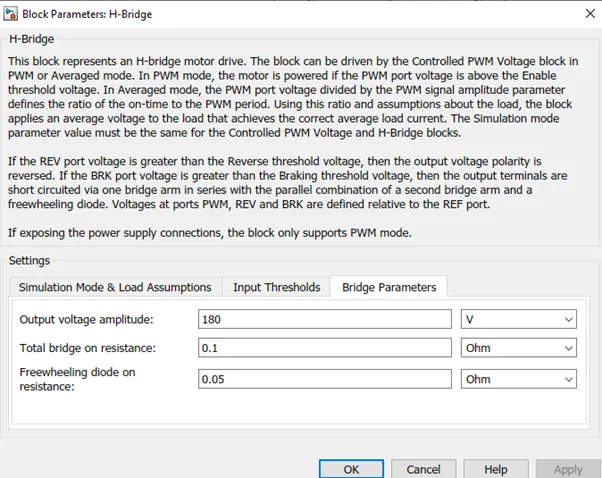
In this model ‘Power Supply’ is set to ‘Internal’ and ‘Simulation Mode’ is set to ‘Averaged’. In the ‘Bridge Parameters’ is set to 180 V and keeping the other parameters same.
DC Motor:
This block represents the electrical and torque characteristics of a DC motor. The block assumes that no electromagnetic energy is lost, and hence the back-emf and the torque constants have the same numerical value when in SI units. When a positive current flow from the electrical +ve to -ve ports, a positive torque acts from the mechanical C o R ports. Motor torque direction can be changed by altering the sign of the back emf or torque constant.
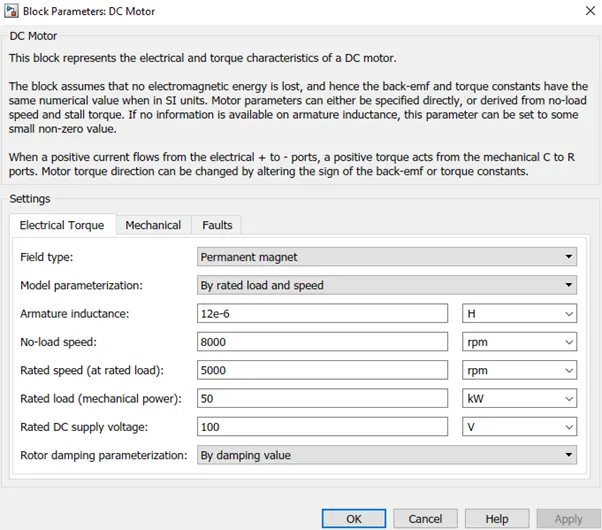
Parameters set for DC Motor are shown in the below image,
Current Sensor:
The Current Sensor block represents an ideal current sensor, that is, a device that converts current measured in any electrical branch into a physical signal proportional to the current. Connections + and – are electrical conserving ports through which the sensor is inserted into the circuit. Connection I is a physical signal port that outputs the measurement result.
The block has the following ports:
+
Electrical conserving port associated with the sensor positive terminal.
-
Electrical conserving port associated with the sensor negative terminal.
I
Physical signal output port for current.
Mechanical Rotational Reference:
The Mechanical Rotational Reference block represents a reference point, or frame, for all mechanical rotational ports. All rotational ports that are rigidly clamped to the frame (ground) must be connected to a Mechanical Rotational Reference block.
Electrical Reference block:
The Electrical Reference block represents an electrical ground. Electrical conserving ports of all the blocks that are directly connected to ground must be connected to an Electrical Reference block. A model with electrical elements must contain at least one Electrical Reference block.
Controlled Current Source:
The block represents an ideal current source that is powerful enough to maintain the specified current through it regardless of the voltage across it. The output current is I = Is, where Is is the numerical value presented at the physical signal port.
Battery:
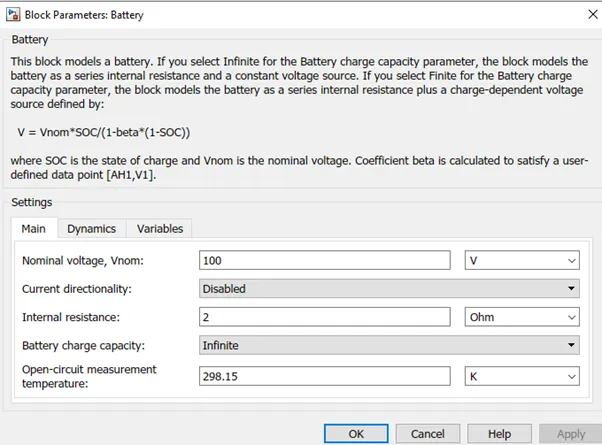
This block models a battery. If you select Infinite for the Battery charge capacity parameter, the block models the battery as a series internal resistance and a constant voltage source. If you select Finite for the Battery charge capacity parameter, the block models the battery as a series internal resistance plus a charge-dependent voltage source defined by:
V = Vnom*SOC/(1-beta*(1-SOC))
where SOC is the state of charge and Vnom is the nominal voltage. Coefficient beta is calculated to satisfy a user-defined data point [AH1,V1].
Rate of Transition:
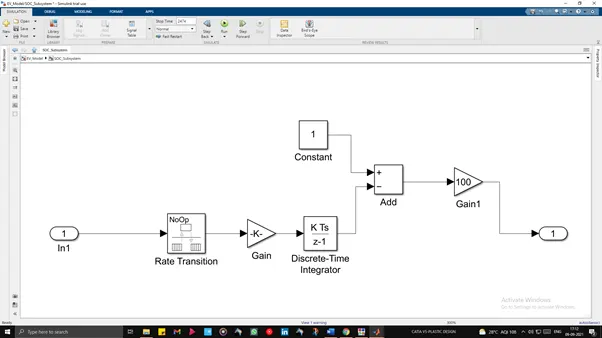
The Rate Transition block transfers data from the output of a block operating at one rate to the input of a block operating at a different rate. Use the block parameters to trade data integrity and deterministic transfer for faster response or lower memory requirements.
The behaviour of the Rate Transition block depends on:
- Sample times of the ports to which the block connects (see Effect of Synchronous Sample Times and Effect of Asynchronous Sample Times)
- Priorities of the tasks for the source and destination sample times (see Sample Time Properties in the Simulink®documentation)
- Whether the model specifies a fixed- or variable-step solver (see Compare Solvers in the Simulink documentation)
- Setting of model configuration parameters Device vendorand Device type (see Effects of Device Configuration)
Gain:
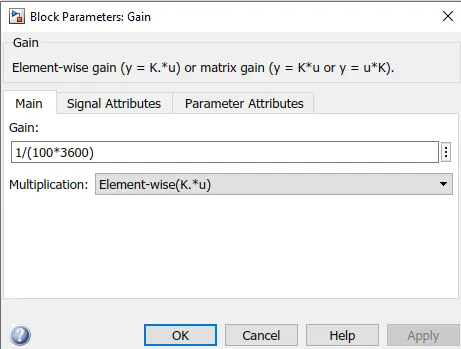
This block multiplies the input by a constant value (gain). The input and the gain can each be a scalar, vector, or matrix. We have set the gain to [1/ (100*3600)] which determines the rate of discharge of the battery.
Discrete-Time Integrator:
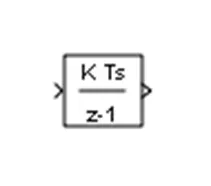
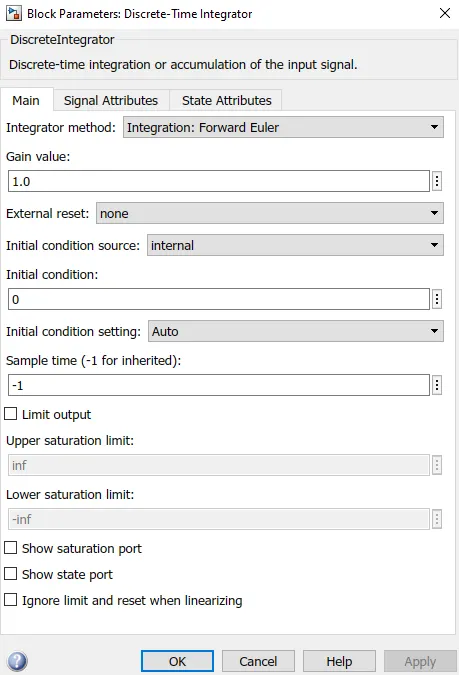
Use the Discrete-Time Integrator block in place of the Integrator block to create a purely discrete model. With the Discrete-Time Integrator block, you can:
- Define initial conditions on the block dialog box or as input to the block
- Define an input gain (K) value
- Output the block state
- Define upper and lower limits on the integral
- Reset the state with an additional reset input
Simple gear:
The Simple Gear block represents a gearbox that constrains the connected driveline axes of the base gear, B, and the follower gear, F, to corotate with a fixed ratio that you specify. You choose whether the follower axis rotates in the same or opposite direction as the base axis. If they rotate in the same direction, the angular velocity of the follower, ωF, and the angular velocity of the base, ωB, have the same sign. If they rotate in opposite directions, ωF and ωB have opposite signs.
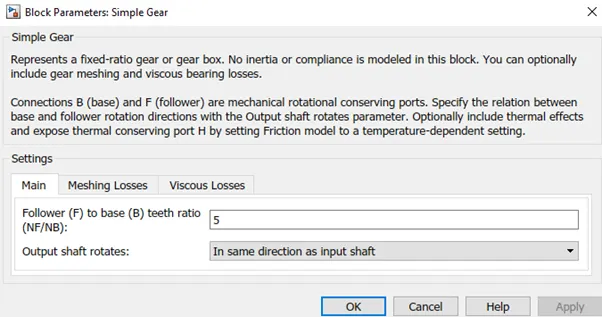
Parameters are changed according to the need of the Gear block:
Vehicle Body:
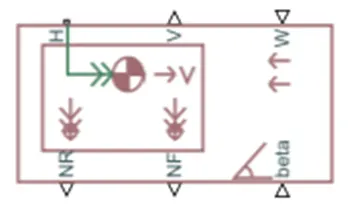
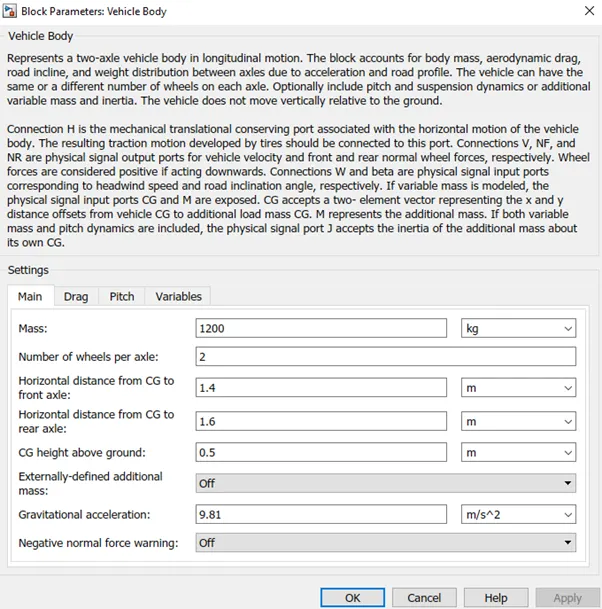
The Vehicle Body block represents a two-axle vehicle body in longitudinal motion. The vehicle can have the same or a different number of wheels on each axle. For example, two wheels on the front axle and one wheel on the rear axle. The vehicle wheels are assumed identical in size. The vehicle can also have a center of gravity (CG) that is at or below the plane of travel.
The block accounts for body mass, aerodynamic drag, road incline, and weight distribution between axles due to acceleration and road profile. Optionally include pitch and suspension dynamics. The vehicle does not move vertically relative to the ground.
The block has an option to include an externally-defined mass and an externally-defined inertia. The mass, inertia, and center of gravity of the vehicle body can vary over the course of simulation in response to system changes.
Tire (Magic Formula)
The Tire (Magic Formula) block models a tire with longitudinal behaviour given by the Magic Formula [1], an empirical equation based on four fitting coefficients. The block can model tire dynamics under constant or variable pavement conditions.
The longitudinal direction of the tire is the same as its direction of motion as it rolls on pavement. This block is a structural component based on the Tire-Road interaction (Magic Formula) block.
To increase the fidelity of the tire model, you can specify properties such as tire compliance, inertia, and rolling resistance. However, these properties increase the complexity of the tire model and can slow down simulation. Consider ignoring tire compliance and inertia if simulating the model in real time or if preparing the model for hardware-in-the-loop (HIL) simulation.
SOC Subsystem:
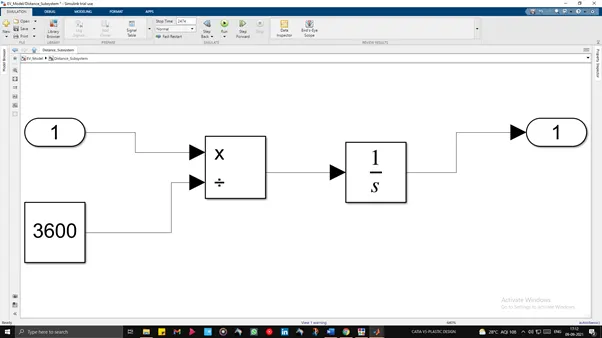
Distance Covered Subsystem:
Output Results:
Drive Cycle vs Vehicle body data
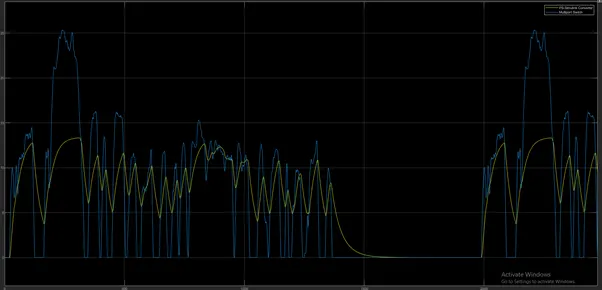
From the above graph it is evident that vehicle manages to follow the drive cycle to an appreciable extent. Bu the fact that the vehicle is not able to follow the drive cycle very closely in phases where the acceleration demanded by the drive cycle is high and abrupt cannot be denied. Also, at the deceleration phases of the drive cycle the vehicle is not able to decelerate to the required speed.
State of Charge (SOC):
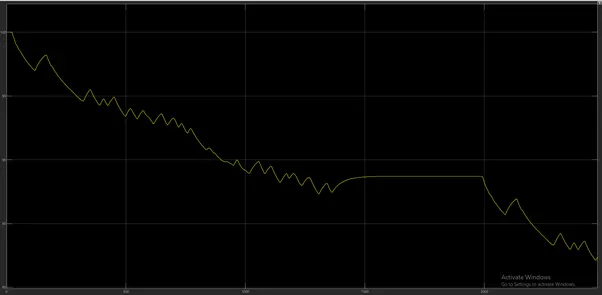
From the above graph we can see that the battery SOC has reduced from an initial condition of 100 % to around 82 % over the duration of the drive cycle. On observing graph carefully, we can conclude that battery has ben charged fractionally at certain points. This is due to regenerative braking during the deceleration phases of the drive cycle.
Distance Graph:
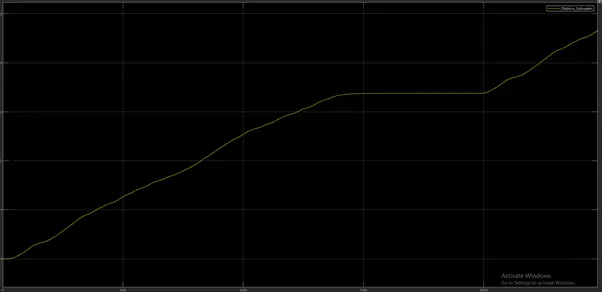
From the above graph we can say that during the drive cycle the vehicle has covered around 4.6 km.
Current graph:
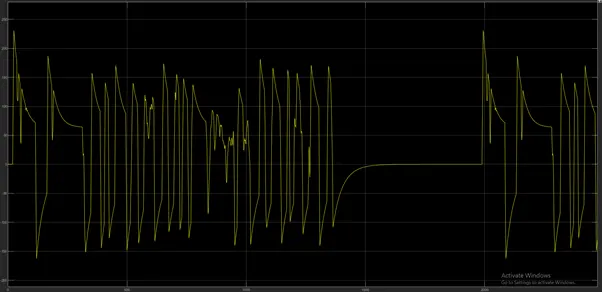
From the above graph we can conclude that the current varies between 250 A to -200 A.