Project 1 (Mini Project on Vehicle Direction Detection
Aim:
To make a model for vehicle direction determination and making the sldd file
Introduction:
Identifying the direction of the vehicle is one of the important & diverse features in Autonomous driving & Advanced Driver Assistance Features. This particular sub-feature of identifying the direction of vehicle is basically identifying the direction the vehicle is taking based on the camera input.
Camera reads the road signs & stores into its memory with unique values for left turn, right turn & straight drive. Depending on the direction it is taking, final indication is given to the driver – as an indication if he is driving in the recommended direction or not.
Vehicle Direction Determination can also be coupled along - side features like GPS systems to identify whether the vehicle is reaching its destination in an optimized manner. This sub feature can also be used along with Lane Detection, Highway Warning, Ramp Entry / Exit in Wrong Way Detection etc.
Objective:
- Development of MATLAB Simulink model as per requirement.
- Tag the requirements to the Simulink model
- MBD complaint changes, Data Dictionary creation and code generation
Requirement - 1:
- Steering wheel input as yaw rate (Signal name: SteeringWheel_YawDegreeInput) is the input for this system.
- This is compared against 3 angular values, one each for left turn, right turn & straight drive (Calibration Values: Right_Turn_AngularLimit, Left_Turn_AngularLimit, Straight_Drive_Steering_Angle) to say which specific direction the steering wheel is turning towards.
- Use switch blocks to compare & develop this requirement. Keep this requirement in a subsystem & output of this requirement is a local signal (Signal Name: Vehicle_Turn_Status).
Requirement – 2:
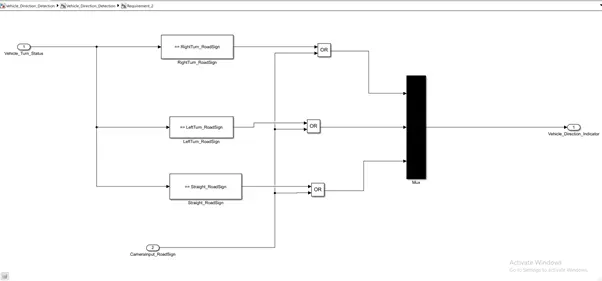
- Keep this requirement as a separate subsystem. Inputs to this requirement are local signal from requirement 1 (Signal Name: Vehicle_Turn_Status) & an input signal from camera (Signal Name: CameraInput_RoadSign), which confirms the occurrence of a road sign.
- Signal Vehicle_Turn_Status is compared against calibration values (Calibration Values: RightTurn_RoadSign, LeftTurn_RoadSign, Straight_RoadSign), if each of them is found equal, then each of the three corresponding output is compared against the camera input signal,
- Using a logical operator block, only one among them is finally given as output signal (Signal Name: Vehicle_Direction_Indicator)
Signals & Calibration Data List:
|
Signal / Calibration Name |
Signal Type |
Data Type |
Dimension |
Min |
Max |
Initial Value |
Units |
|
SteeringWheel_YawDegreeInput |
Input |
Int16 |
1 |
-180 |
180 |
- |
Deg |
|
CameraInput_RoadSign |
Input |
Boolean |
1 |
0 |
1 |
- |
- |
|
Vehicle_Turn_Status |
Local |
Int16 |
1 |
-180 |
180 |
- |
Deg |
|
Right_Turn_AngularLimit |
Calibration |
Int16 |
[1 1] |
-180 |
180 |
30 |
Deg |
|
Left_Turn_AngularLimit |
Calibration |
Int16 |
[1 1] |
-180 |
180 |
-120 |
Deg |
|
Straight_Drive_Steering_Angle |
Calibration |
Int16 |
[1 1] |
-180 |
180 |
0 |
Deg |
|
RightTurn_RoadSign |
Calibration |
Int16 |
[1 1] |
-180 |
180 |
30 |
|
|
LeftTurn_RoadSign |
Calibration |
Int16 |
[1 1] |
-180 |
180 |
-120 |
|
|
Straight_RoadSign |
Calibration |
Int16 |
[1 1] |
-180 |
180 |
0 |
|
|
Vehicle_Direction_Indicator |
Output |
Boolean |
1 |
0 |
1 |
- |
- |
Procedure:
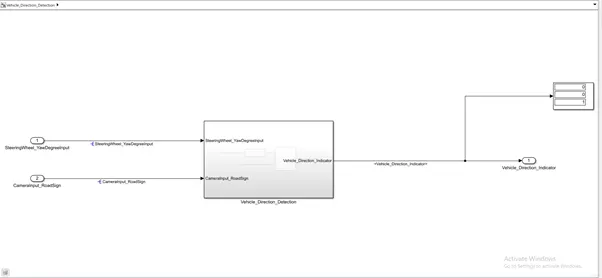
Create the Simulink model as per the given two requirements
Subsystems:
- Vehicle Direction Detection
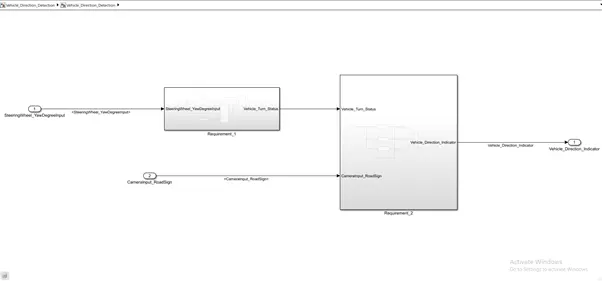
- Requirement 1
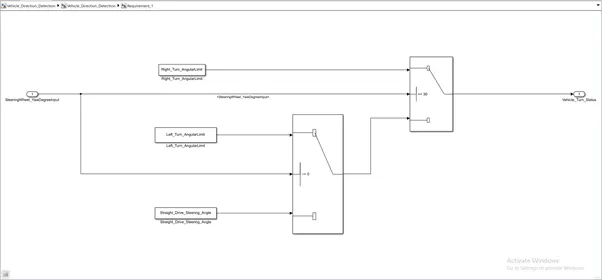
- Requirement 2
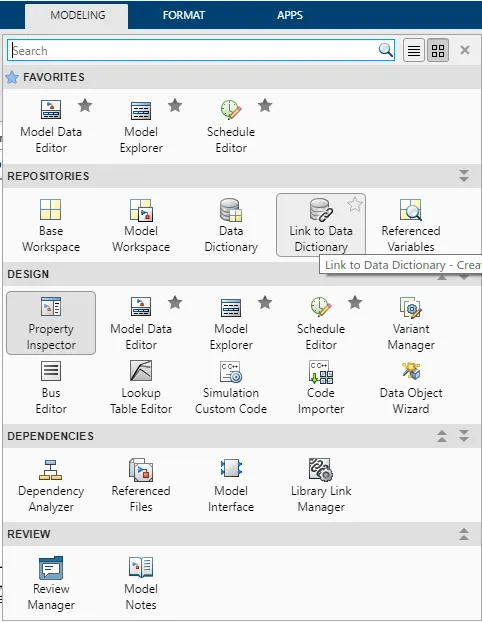
Now as per the given signals and calibration data list prepare the Simulink data dictionary file (.sldd). To prepare the sldd file first we need to select the ‘Link to data dictionary’ in the ‘Modelling’
Now click on the ‘Data Dictionary’ and select the ‘new’ option to create the new sldd file.
Now input the given parameters in the sldd file,
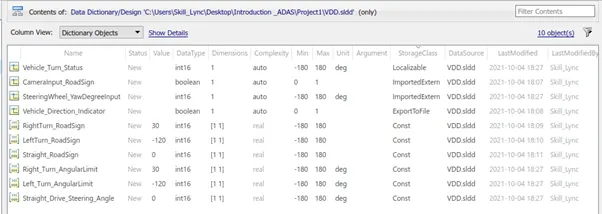
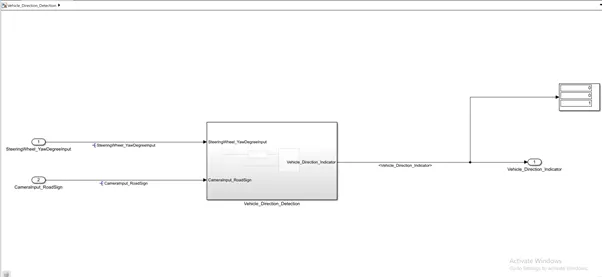
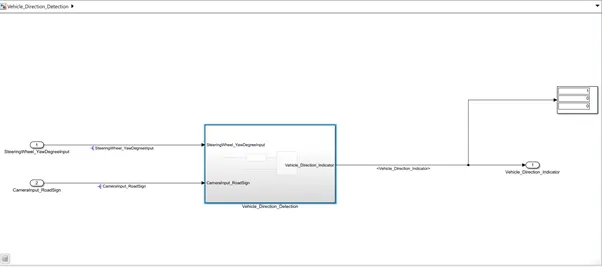
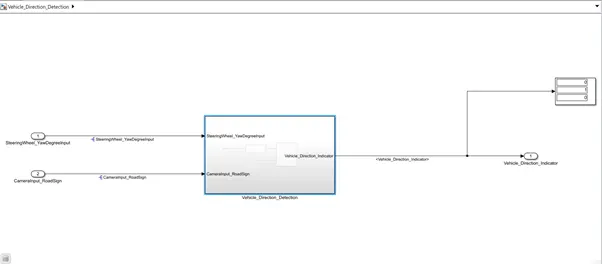
After simulating the above Simulink model using the sldd as an input, we get three outputs as follows,
For straight turn:
For Right Turn:
For Left Turn:
Now we need to generate code for the above model using Embedded C coder
Vehicle_Direction_Detection.c
/*

 * File: Vehicle_Direction_Detection.c

 *

 * Code generated for Simulink model 'Vehicle_Direction_Detection'.

 *

 * Model version                  : 1.2

 * Simulink Coder version         : 9.5 (R2021a) 14-Nov-2020

 * C/C++ source code generated on : Mon Oct  4 22:15:49 2021

 *

 * Target selection: ert.tlc

 * Embedded hardware selection: Intel->x86-64 (Windows64)

 * Code generation objectives: Unspecified

 * Validation result: Not run

 */


#include "Vehicle_Direction_Detection.h"

#include "Vehicle_Direction_Detection_private.h"


/* Exported data definition */


/* Const memory section */

/* Definition for custom storage class: Const */

const int16_T LeftTurn_RoadSign = -120;/* Referenced by: '/Constant' */

const int16_T Left_Turn_AngularLimit = -120;

                              /* Referenced by: '/Left_Turn_AngularLimit' */

const int16_T RightTurn_RoadSign = 30; /* Referenced by: '/Constant' */

const int16_T Right_Turn_AngularLimit = 30;

                             /* Referenced by: '/Right_Turn_AngularLimit' */

const int16_T Straight_Drive_Steering_Angle = 0;

                       /* Referenced by: '/Straight_Drive_Steering_Angle' */

const int16_T Straight_RoadSign = 0;   /* Referenced by: '/Constant' */


/* External outputs (root outports fed by signals with default storage) */

ExtY_Vehicle_Direction_Detect_T Vehicle_Direction_Detection_Y;


/* Real-time model */

static RT_MODEL_Vehicle_Direction_De_T Vehicle_Direction_Detection_M_;

RT_MODEL_Vehicle_Direction_De_T *const Vehicle_Direction_Detection_M =

  &Vehicle_Direction_Detection_M_;


/* Model step function */

void Vehicle_Direction_Detection_step(void)

{

  int16_T rtb_Switch;


  /* Switch: '/Switch' incorporates:

   *  Constant: '/Right_Turn_AngularLimit'

   *  Constant: '/Straight_Drive_Steering_Angle'

   *  Inport: '/SteeringWheel_YawDegreeInput'

   *  Switch: '/Switch1'

   */

  if (SteeringWheel_YawDegreeInput >= 30) {

    rtb_Switch = Right_Turn_AngularLimit;

  } else if (SteeringWheel_YawDegreeInput != 0) {

    /* Switch: '/Switch1' incorporates:

     *  Constant: '/Left_Turn_AngularLimit'

     */

    rtb_Switch = Left_Turn_AngularLimit;

  } else {

    rtb_Switch = Straight_Drive_Steering_Angle;

  }


  /* End of Switch: '/Switch' */


  /* Outport: '/Vehicle_Direction_Indicator' incorporates:

   *  Constant: '/Constant'

   *  Constant: '/Constant'

   *  Constant: '/Constant'

   *  Inport: '/CameraInput_RoadSign'

   *  Logic: '/Logical Operator'

   *  Logic: '/Logical Operator1'

   *  Logic: '/Logical Operator2'

   *  RelationalOperator: '/Compare'

   *  RelationalOperator: '/Compare'

   *  RelationalOperator: '/Compare'

   */

  Vehicle_Direction_Detection_Y.Vehicle_Direction_Indicator[0] = ((rtb_Switch ==

    RightTurn_RoadSign) || CameraInput_RoadSign);

  Vehicle_Direction_Detection_Y.Vehicle_Direction_Indicator[1] = ((rtb_Switch ==

    LeftTurn_RoadSign) || CameraInput_RoadSign);

  Vehicle_Direction_Detection_Y.Vehicle_Direction_Indicator[2] = ((rtb_Switch ==

    Straight_RoadSign) || CameraInput_RoadSign);

}


/* Model initialize function */

void Vehicle_Direction_Detection_initialize(void)

{

  /* (no initialization code required) */

}


/* Model terminate function */

void Vehicle_Direction_Detection_terminate(void)

{

  /* (no terminate code required) */

}


/*

 * File trailer for generated code.

 *

 * [EOF]

 */
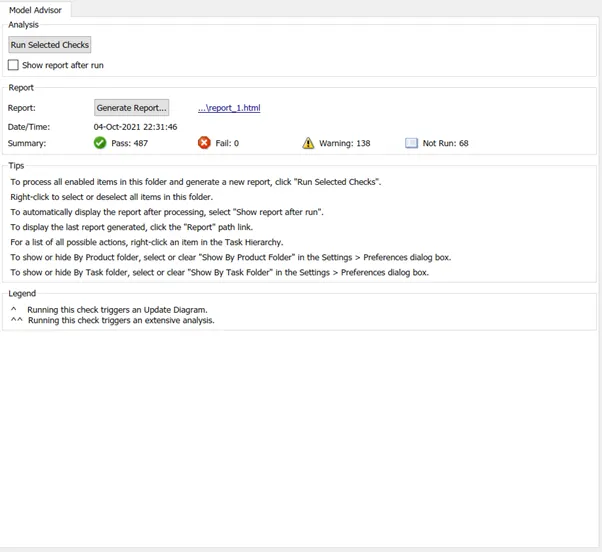
Model Advisor check: