External Aerodynamic Simulation Over A Formula SAE Car Using Transient Solver By Creating A Virtual Wind Tunnel In Converge CFD & Post-processing It In Paraview.
Abstract:- The experiment is focused on studying the flow characteristics over an FSAE car inside a virtually designed low subsonic wind tunnel created using the geometry editing tools available in Converge CFD software & the results obtained will be post-processed using Paraview. This paper describes the procedure to import an STL (an abbreviation of "stereolithography") geometry in Converge CFD software, cleaning of the "dirty" geometric model, and performing CFD analysis of a Formula SAE car. The virtual wind tunnel which will also be designed in Converge will have a length of 15 times the length of the car & breadth of 2.5 times the length of the FSAE car. We will be using a transient solver to analyze the fluid flow over the FSAE Car. Formula SAE is a college-level student design competition where every year students of universities all over the world build and compete with open-wheel formula-style race. The focus of the study is to investigate the aerodynamics characteristics of an SAE race car. Race car performance depends on elements such as the engine, tires, suspension, road, aerodynamics, and of course the driver. In recent years, however, vehicle aerodynamics gained increased attention, mainly due to the utilization of the negative lift (downforce) principle, yielding several important performance improvements. This review briefly explains the significance of the aerodynamic downforce and how it improves race car performance. Various methods to generate downforces such as inverted wings, diffusers, and vortex generators are discussed. Due to the complex geometry of these vehicles, the aerodynamic interaction between the various body components is significant, resulting in vortex flows and lifting surface shapes, unlike traditional airplane wings. Design tools such as wind tunnel testing, Computational Fluid Dynamics (CFD), track testing, and their relevance to race car development, are discussed in this paper. The study was performed by setting up the flow physics in Converge CFD package & used Cygwin as a solver. The results obtained were then post-processed using Paraview. The simulation was run using the k - `omega` SST turbulence model. We plot the negative Lift & Drag forces generated for each component of the race car & also visualize the velocity & Pressure contours at every time step during the simulation. We will be running the simulation for two different scenarios according to the race track requirement.
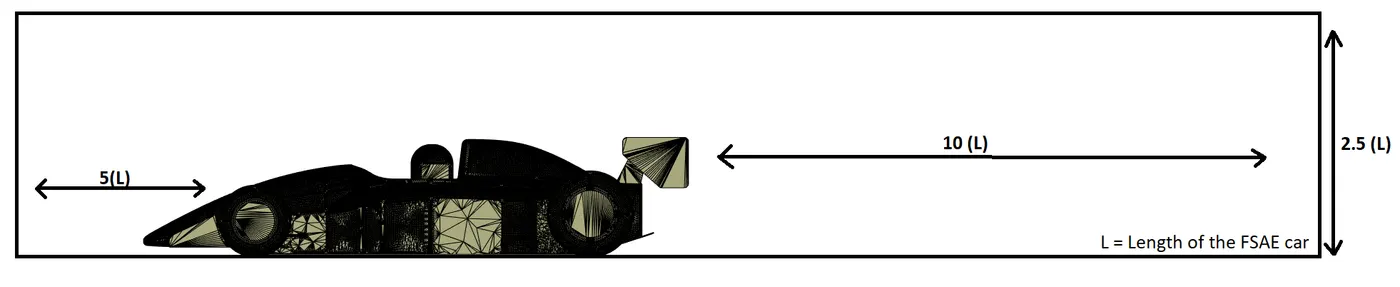
Fig:- Experimental Setup of an FSAE car inside a Virtual Wind Tunnel
Keywords: Aerodynamics, CFD, Formula Student Car, Inverted wings, Ground effect, Drag.
1. INTRODUCTION
The concept behind Formula SAE is that a fictional manufacturing company has contracted a student design team to develop a small Formula Style Race Car. Each student team designs builds and tests a prototype based on a series of rules, whose purpose is both ensuring on-track safety (the cars are driven by the students themselves) and promoting clever problem-solving. FSAE challenges students to build a formula-style racecar that must be low in cost, easy to maintain, and reliable, with high performance in terms of its acceleration, braking, and handling qualities. In order to get a good performance, the vehicle has to be aerodynamically efficient, this is where Computational Fluid Dynamics (CFD) Softwares comes into play. CFD helps users to calculate the design of aerodynamic components and is an important complement to wind tunnel work. CFD plays an important role in the development of front, rear, and auxiliary wings as well as in engine and brake cooling. CFD is intended to complement, rather than replace, the work in the wind tunnel. Through this project, we will be able to compute the total force generated on each of the components of the FSAE car for two different race tracks. The drag force is an unwanted force which normally acts against the driving force of the car & must be reduced. The downforce is useful to maintain the race car in the ground. In this project work, an attempt has been made to clean up a "dirty" design a formula- student (FS) car, record its aerodynamic characteristics through a transient solver and simultaneously capture the flow physics for each of the FSAE car components.
1.1. Aerodynamic drag (`C _D`):
When the fluid flows over the surface, the surface will resist its motion. This is called drag. Aerodynamic drag is the sum of pressure drag and viscous drag. The pressure drag is the most dominant one of both. The pressure drag is caused due to the shear forces acting between the two layers of fluid.
Aerodynamic drag `C_D` = Drag force/0.5ρ`v^2`A
Where ρ is the air density in kg/`m^3`, A is the effective frontal area in `m^2`, v is the velocity in m/s. There are two different types of flow, laminar and turbulent. Laminar flow is smooth where the adjacent layers of fluid will undergo sliding between each other. The turbulent is chaotic and random. It is normally unsteady, dissipative, and 3 dimensional. Reynold’s number decides whether the flow is laminar or turbulent. Over the surface, there is a thin layer of air exists. The velocity of the air is reduced due to the surface. This layer above the surface is called the boundary layer. The length of the boundary layer increases as we move away from the surface. The boundary layer initially will be laminar and transforms into turbulent as it moves further over the larger distance. When there are sudden changes in the surface this would lead to flow separation. Flow separation normally takes place when the upper layer of the fluid can no longer pull the lower layer of fluid within the boundary layer. The flow can be described by the Navier-Stokes equation. The Navier-Stokes equations govern the motion of fluids and can be seen as Newton's second law of motion for fluids. In the case of a compressible Newtonian fluid, this yields
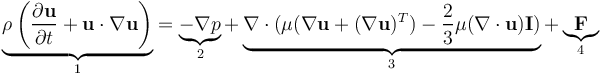
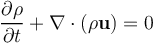
- Direct Numerical Simulation (DNS) – It solves the Navier-stokes equation numerically. It requires a very fine grid size and requires very high computer memory. It can solve all turbulence scales.
- Reynold’s Averaged Navier-Stokes Equation (RANS) – It gives the approximate time-averaged solution to the Navier-Stokes equation. The velocity field is fluctuating and it cannot solve all turbulence scales.
- Large-eddy simulation (LES) - It solves the large eddies. The simulation is time-dependent.
1.2. Aerofoil:
The amount of downforce created by the wings or spoilers on a car is dependent primarily on two things:
- The shape, including surface area, aspect ratio and cross-section of the device, and
- The device's orientation (or angle of attack).
A larger surface area creates greater downforce and greater drag. The aspect ratio is the width of the airfoil divided by its chord. If the wing is not rectangular, the aspect ratio is written AR=b2/s, where AR=aspect ratio, b=span, and s=wing area. Also, a greater angle of attack (or tilt) of the wing or spoiler, creates more downforce, which puts more pressure on the rear wheels and creates more drag.
(A) Front Wing
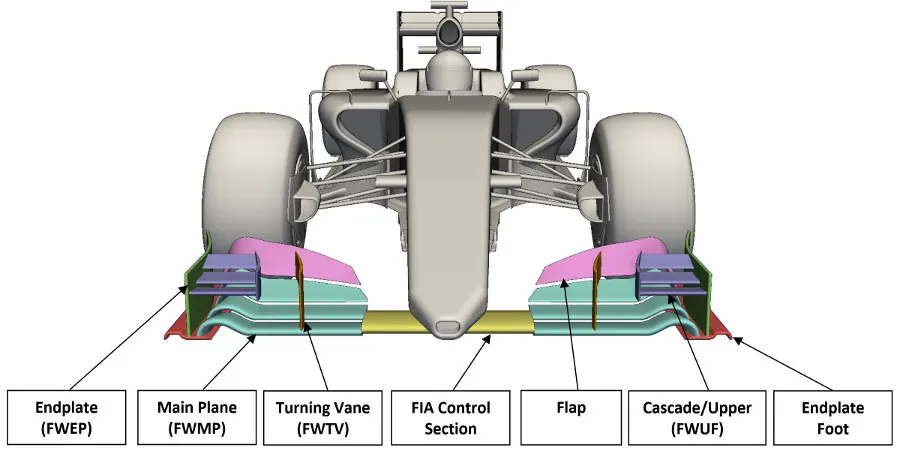
The function of the airfoils at the front of the car is twofold. They create downforce that enhances the grip of the front tires, while also optimizing (or minimizing disturbance to) the flow of air to the rest of the car. The front wings on an open-wheeled car undergo constant modification as data is gathered from race to race, and are customized for every characteristic of a particular circuit. In most series, the wings are even designed for adjustment during the race itself when the car is serviced. In addition to controlling the downforce, the front wings also control the total airflow around the Formula One car.
(B) Rear Wing
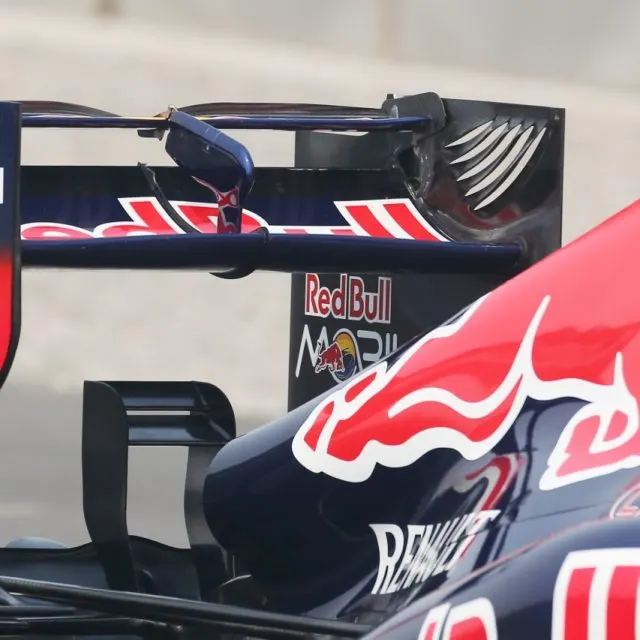
The flow of air at the rear of the car is affected by the front wings, front wheels, mirrors, driver's helmet, side pods, and exhaust. This causes the rear wing to be less aerodynamically efficient than the front wing, Yet, because it must generate more than twice as much downforce as the front wings in order to maintain the handling to balance the car, the rear wing typically has a much larger aspect ratio, and often uses two or more elements to compound the amount of downforce created (see photo at left). Like the front wings, each of these elements can often be adjusted when the car is serviced, before or even during a race, and are the object of constant attention and modification.
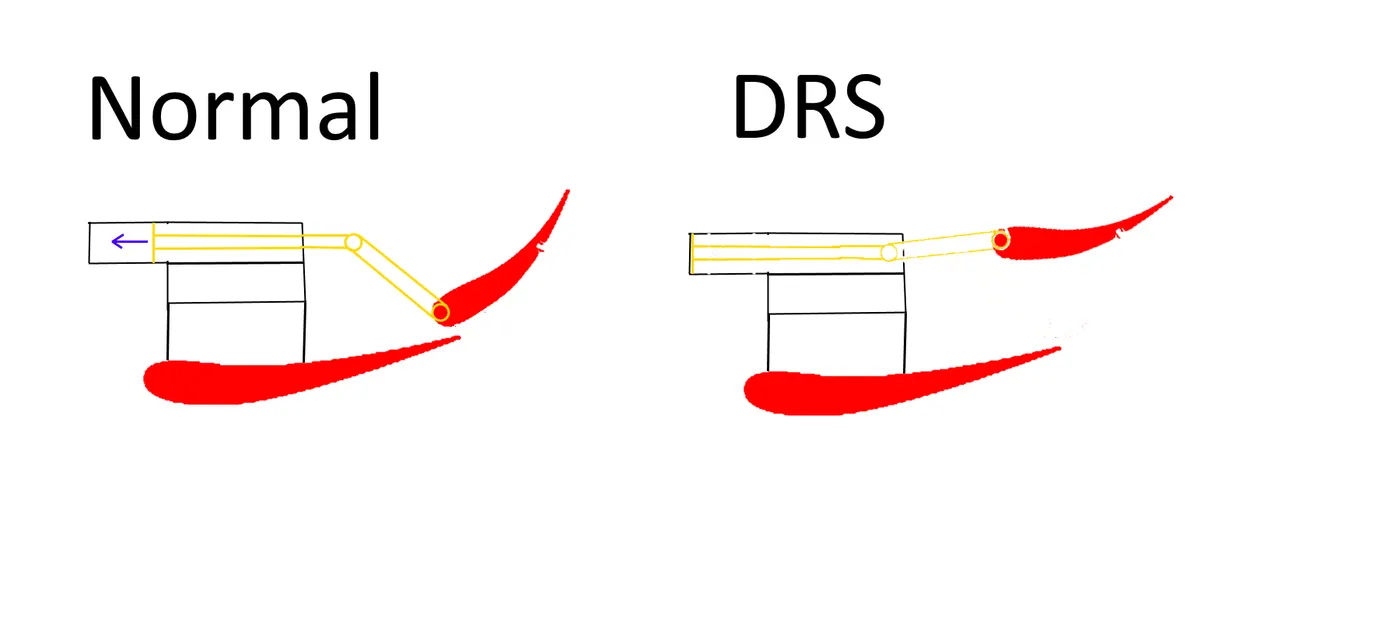
The Drag reduction system (or DRS) is a form of driver-adjustable bodywork aimed at reducing aerodynamic drag in order to increase top speed and promote overtaking in motor racing. It is an adjustable rear wing of the car, which moves in response to driver commands. The horizontal elements of the rear wing consist of the main plane and the flap. The DRS allows the flap to lift a maximum of 50 mm from the fixed main plane. This reduces opposition (drag) to airflow against the wing and results in less downforce. In the absence of significant lateral forces (straight line), less downforce allows faster acceleration and potential top speed. The effectiveness of the DRS will vary from track to track and, to a lesser extent, from car to car.
1.3. Ground Effect or Down Force In Formula Race Car:
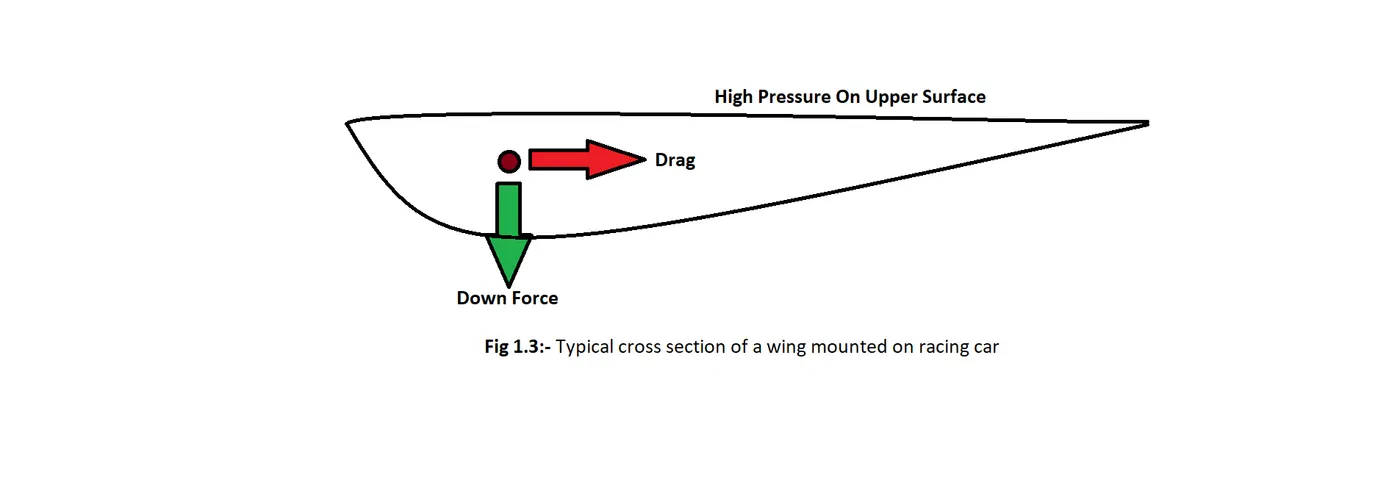
The same principles used for aircraft wings can be applied to the wings found on Formula One cars, but instead of producing lift, downforce is produced. In-car design, ground effect is a series of aerodynamic effects that have been exploited to create downforce, particularly in racing cars. The purpose of the downforce is to allow a car to travel faster through a corner by increasing the vertical force on the tires, thus creating more grip therefore a designer's aim is to increase the downforce and grip to achieve higher cornering speeds.
2. FSAE GEOMETRY CLEANING In Converge CFD
The design of the FSAE Car chassis was done using Solid Works. The pre-modeled FSAE car after being designed in Solidworks was imported into Converge Studio software as an STL file. In Converge, all the surface information is stored in the form of 3 entities vertices, edges & triangles. Therefore, any geometry created or exported from other CAD software (like in our case) into Converge is automatically converted into triangles & that is the fundamental entity in Converge CFD software, where every part of the geometry is assumed to be a triangle. After importing the STL file of the car into Converge we convert the dimensions. Since the geometry was created in solid works, the dimensions of the geometry are expressed in millimeters or ‘mm’ but Converge software package uses S.I unit systems i.e. ‘meters’ & thereby assumes that the geometry imported is in meters as shown in Fig 2.2. The bounding box tool available in the geometry editing tools is used to determine the dimensions of any geometry. To understand the dimensions of our car we can enable the bounding box feature in Converge Studio. Later we need to design the virtual wind tunnel on the basis of our FSAE car length.
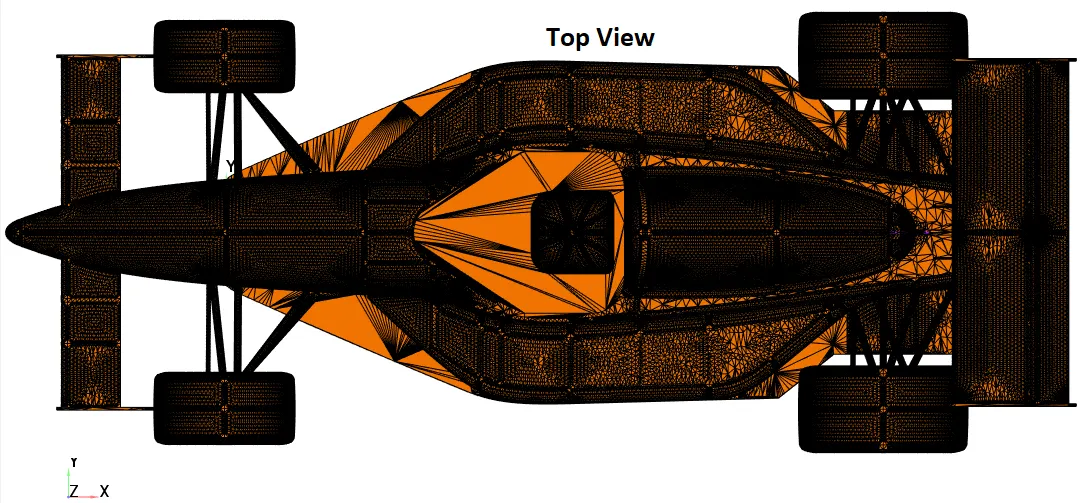
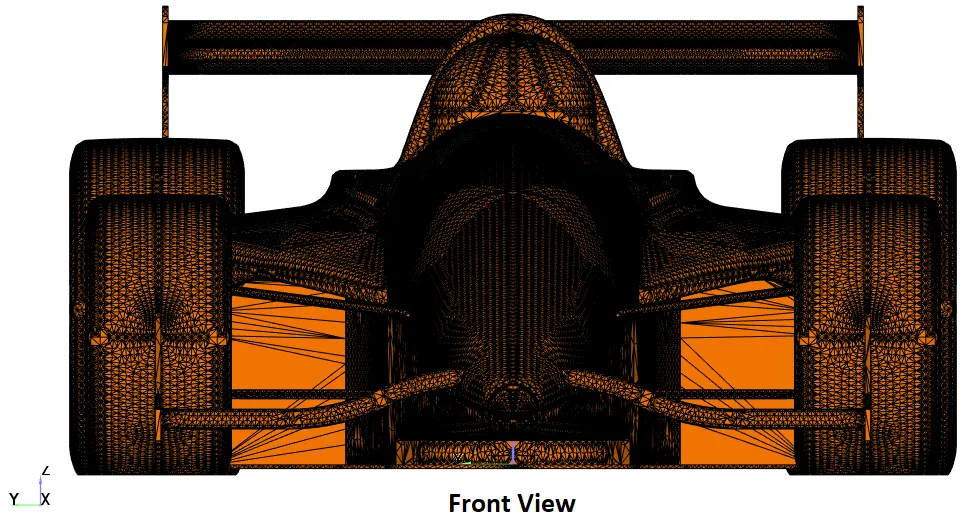
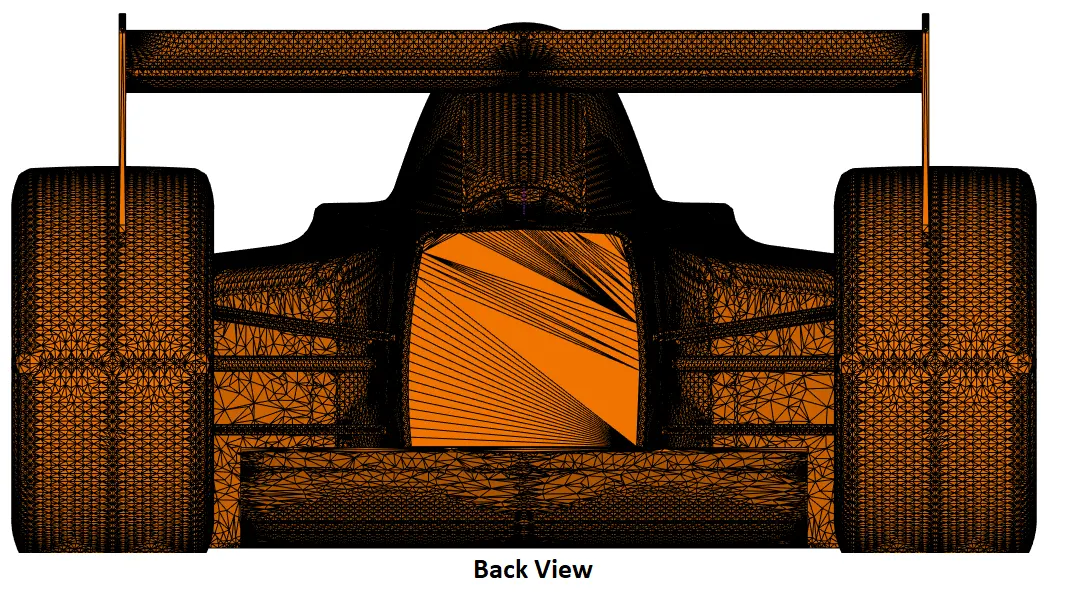
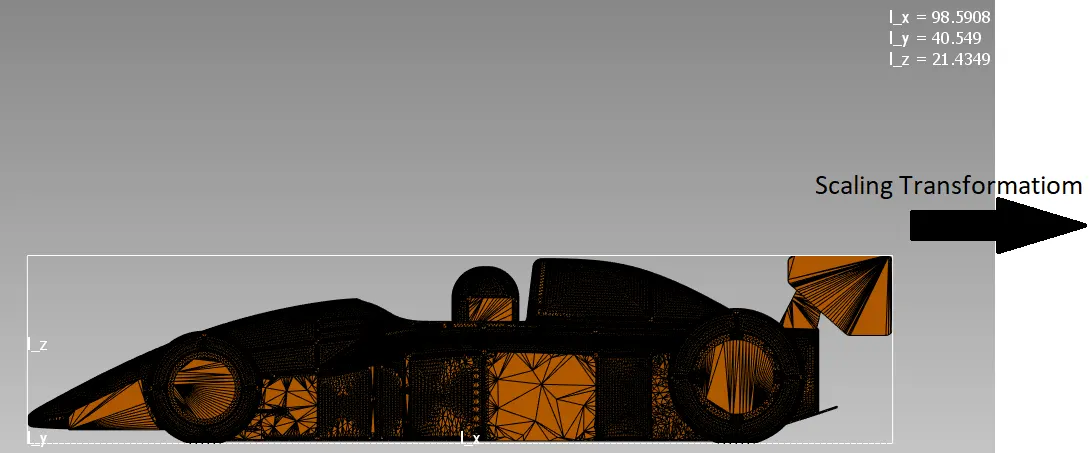
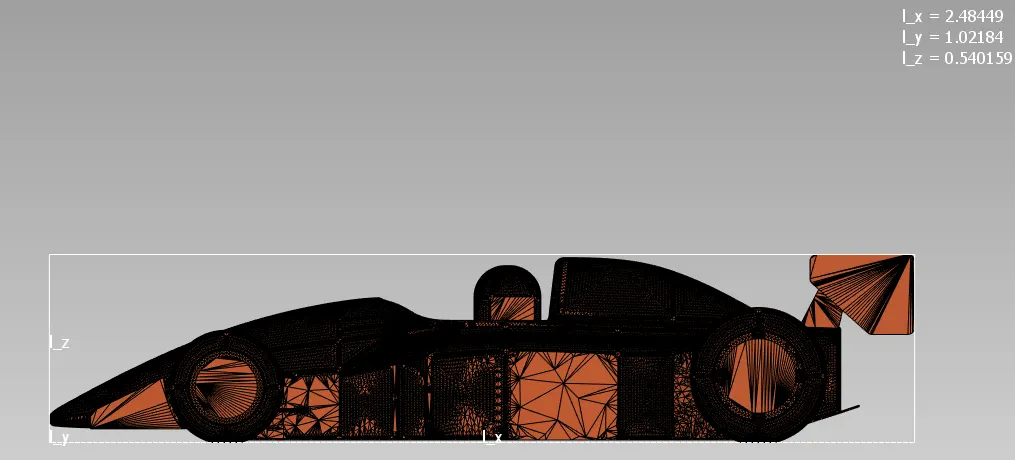
Fig 2.1:- Transforming dimensions of the FSAE car.
Once the dimensions of the geometry are transformed we run a diagnostic test to check for errors like intersection errors, open edges, or non-manifold edges. The result of our first diagnostic test is shown in Fig 2.2, we observe (48) Non-manifold problems in which one edge of the triangle is shared by more than 2 triangles & those triangles need to be fixed by deleting them & creating new triangles using ordered vertex method. Another kind of error observed is the "overlapping triangles" error. These errors were fixed by using the "delete" & "patch" tools.
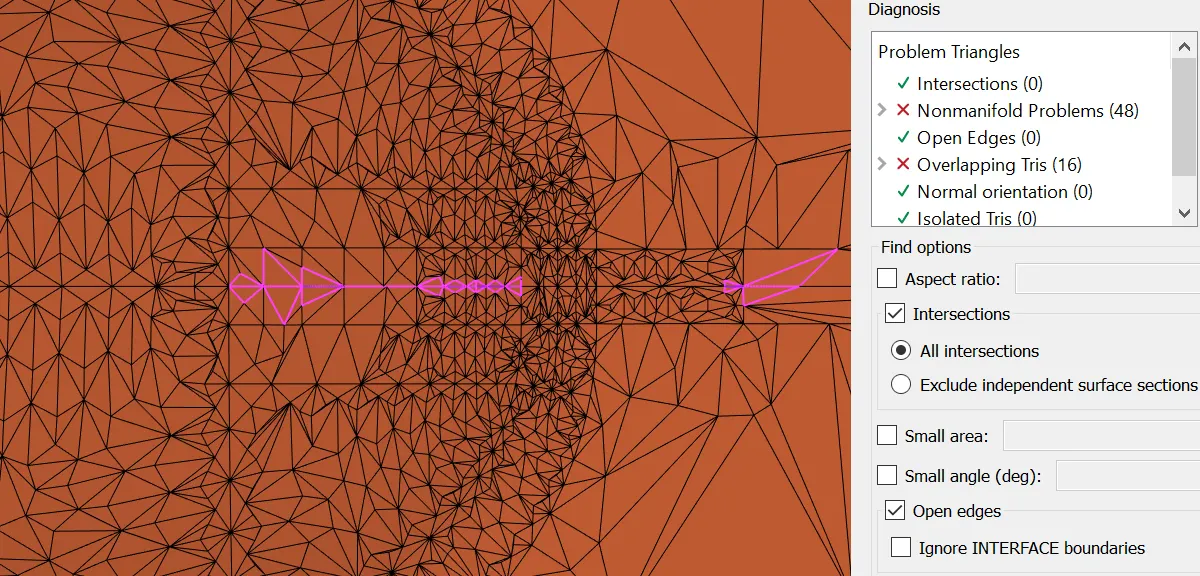 Fig 2.2:- Diagnosis Result with Errors.
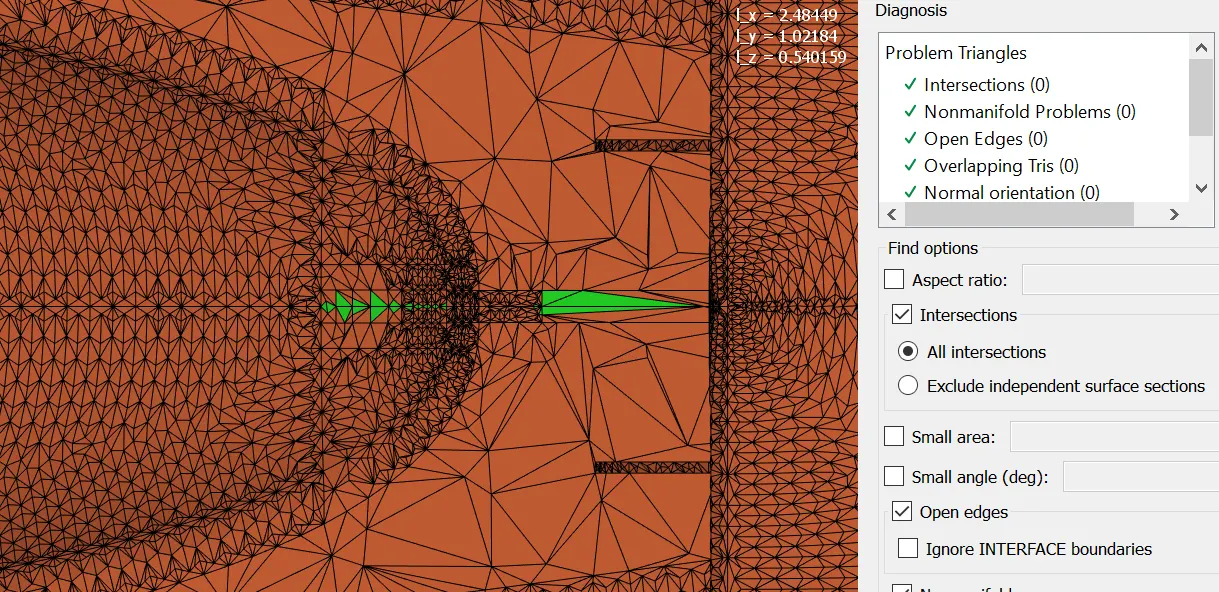 Fig 2.3:- Diagnosis Result with No-errors.
3. Boundary Flagging
Since the simulation was carried out with the Converge CFD Software, all the steps involved are applicable only for this particular software. In Converge after editing & fixing the errors of the geometry, the next stage of the process is to flag the boundaries of each of the components of the FSAE car. In Converge software all the surface information is stored in the form of 3 entities vertices, edges & triangles. Therefore, any geometry created or exported from other CAD software into Converge is converted into triangles & that is the fundamental entity in Converge, where every part of the geometry is assumed to be a triangle. The tool known as Fence was used to create boundaries around the FSAE components. The process of grouping these triangles into meaningful boundaries is known as boundary flagging. Each boundary is assigned with a distinct ID & color code as shown in Fig 3.1. For our geometry, we have 14 distinct surfaces - Rear wing, 2 Front Wings classified as Left (L) & Right (R) wing, Front & Rear Wheels, Underbody, Body & Suspensions.
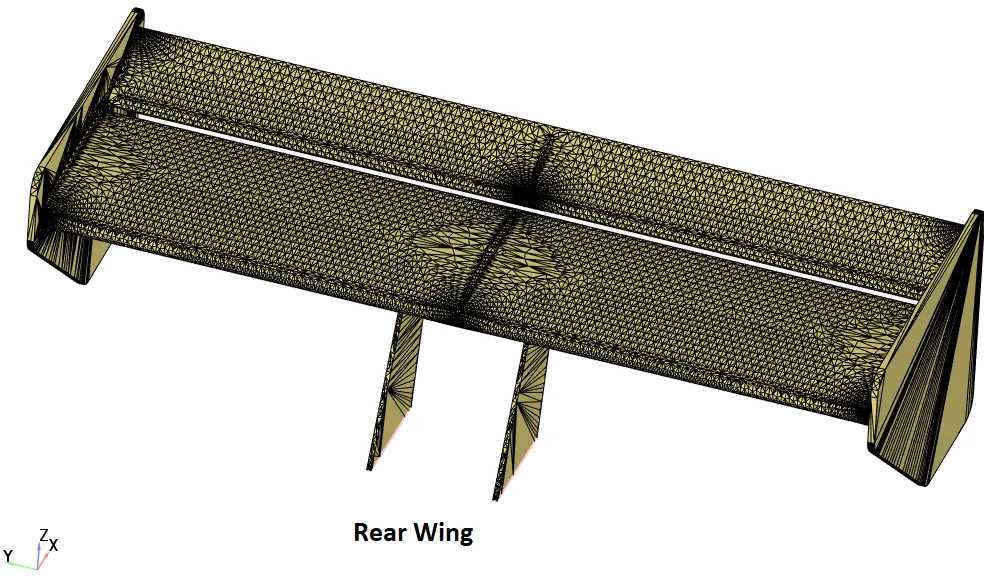
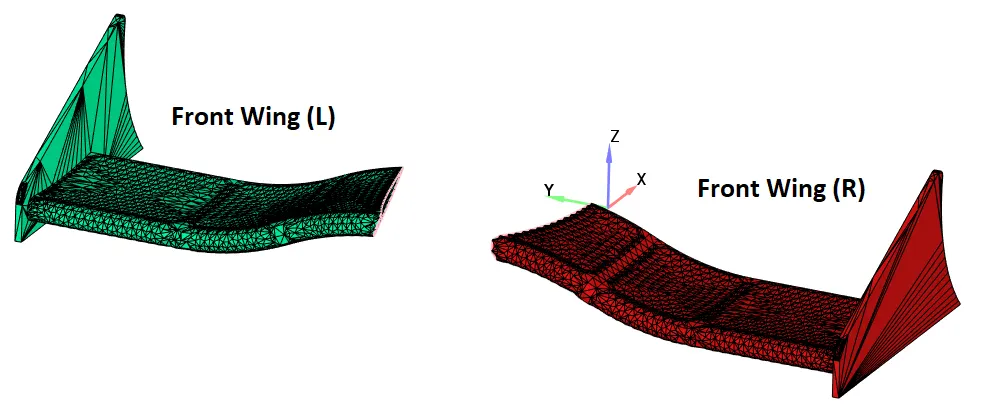
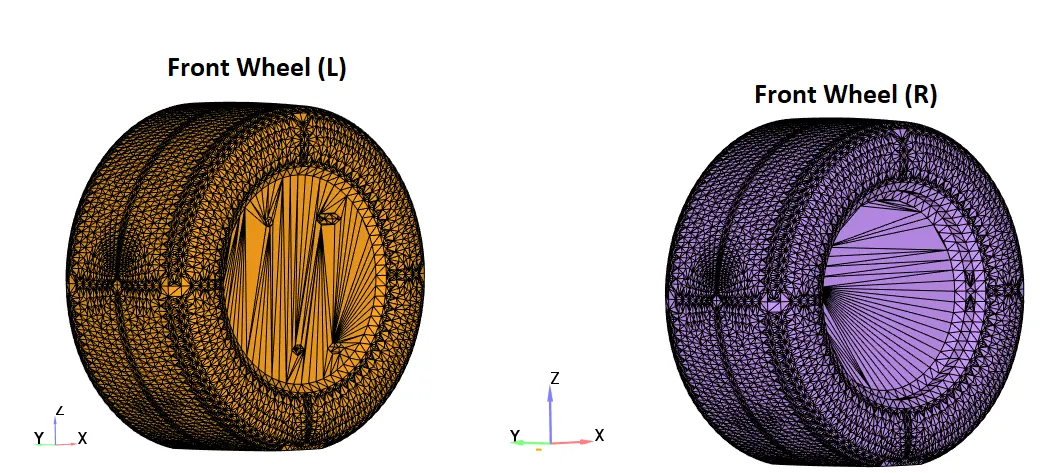
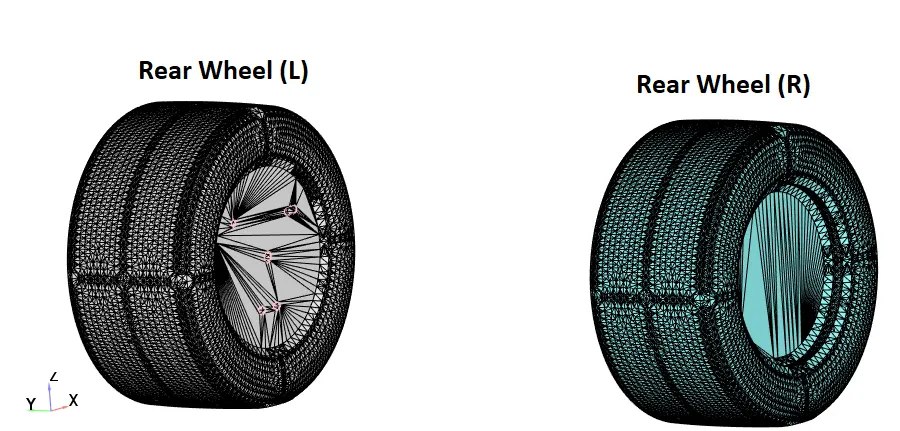
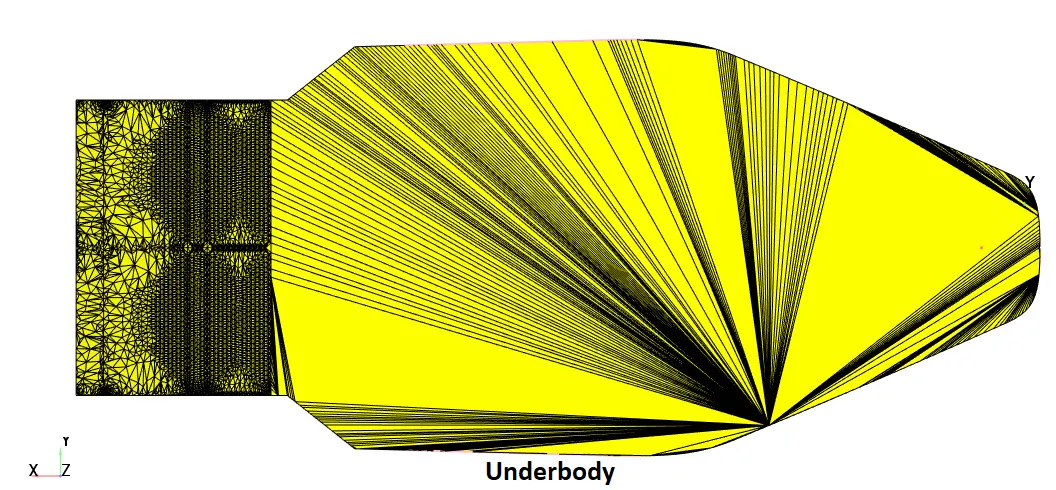
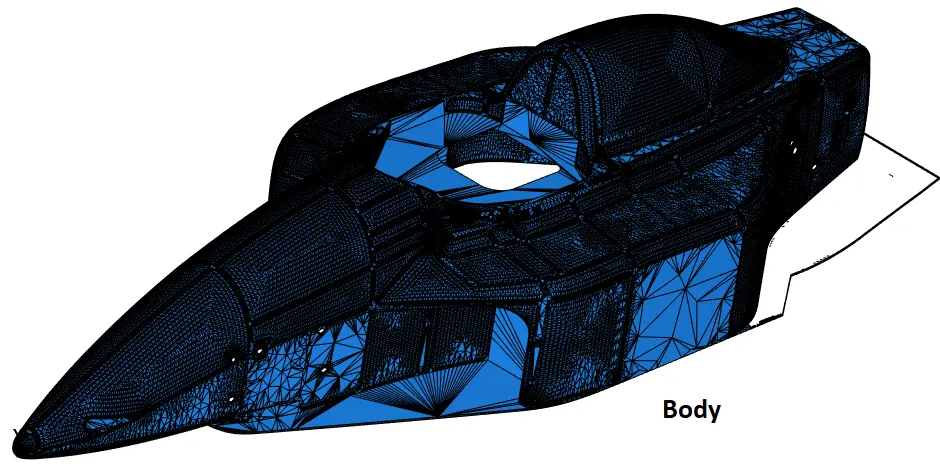
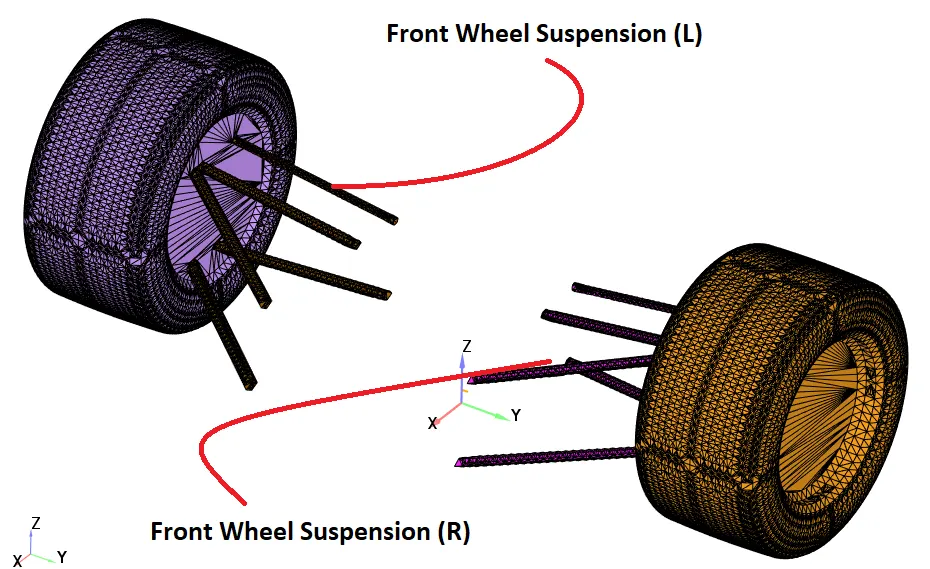
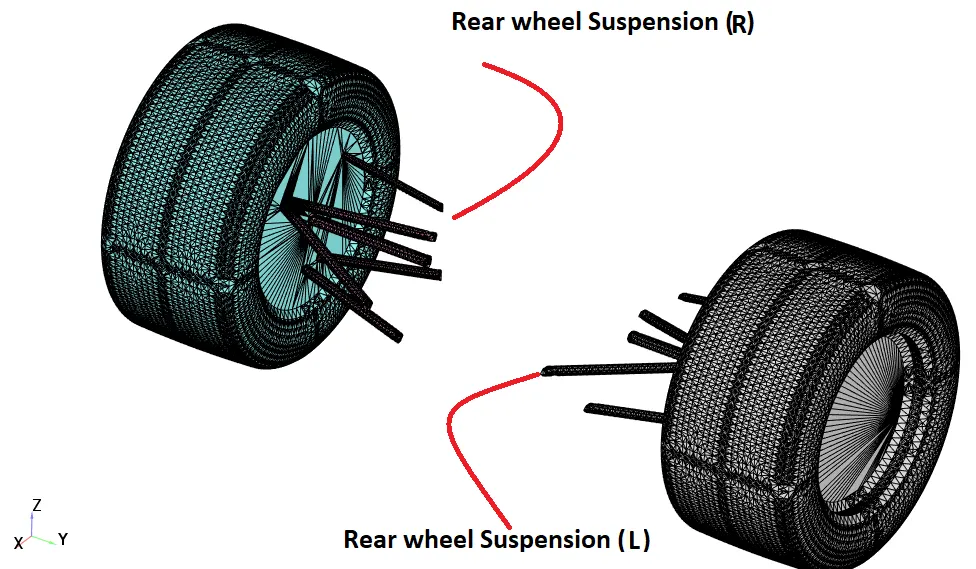
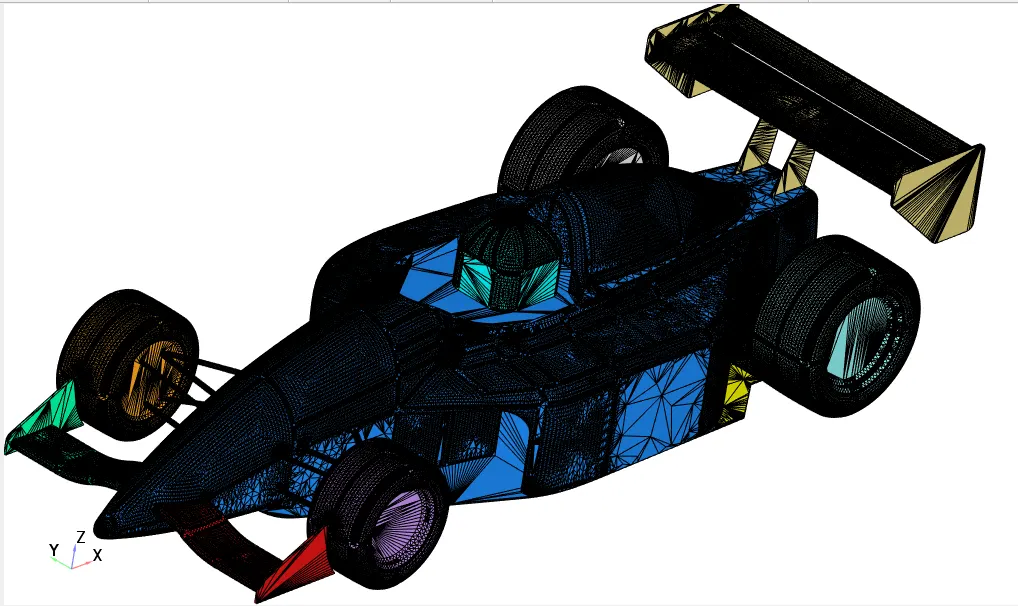
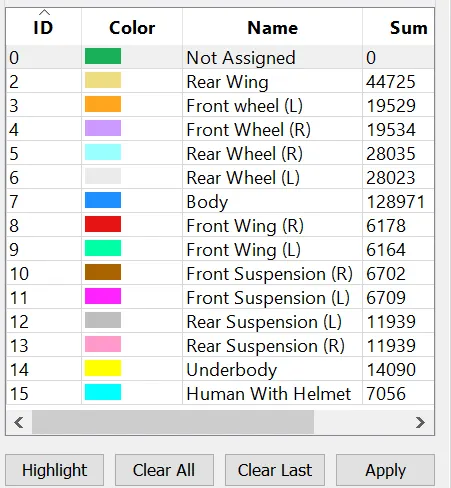
Fig 3.1:- Each Boundary assigned to a particular ID with a color code.
4. Designing the Virtual Wind Tunnel
Having assigned all the triangles to a specific boundary & naming the boundaries accordingly. Our next step involves the designing of the wind tunnel. The convention used to design the wind tunnel is to have 5 times the length (5L) of the FSAE car in the forward & 10 times the length (10L) of the FSAE car behind the car. This additional length behind the car is required to capture the flow physics i.e the wake region & the flow separation region behind the car. But before designing the wind tunnel, we have to modify the model the wheels of the car such that it doesn't touch the wind tunnel surface as this would create errors. We do this by deleting some triangles from the bottom surface of the wheel using the "Angle" method at 5°. Once we do that, we get an open edge shaped like a box for all the four wheels. These open edges will have several open vertices & these vertices would be used to connect the vertices of the bottom portion of the wind tunnel.
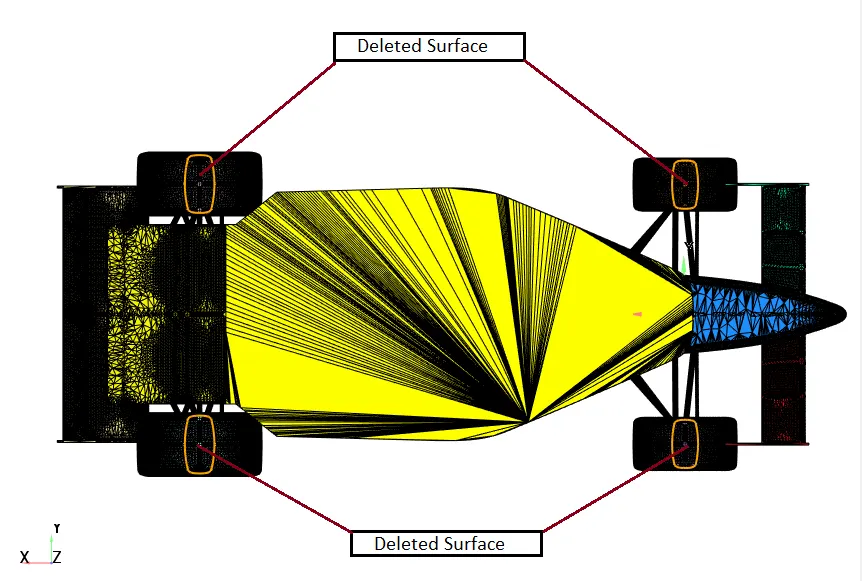
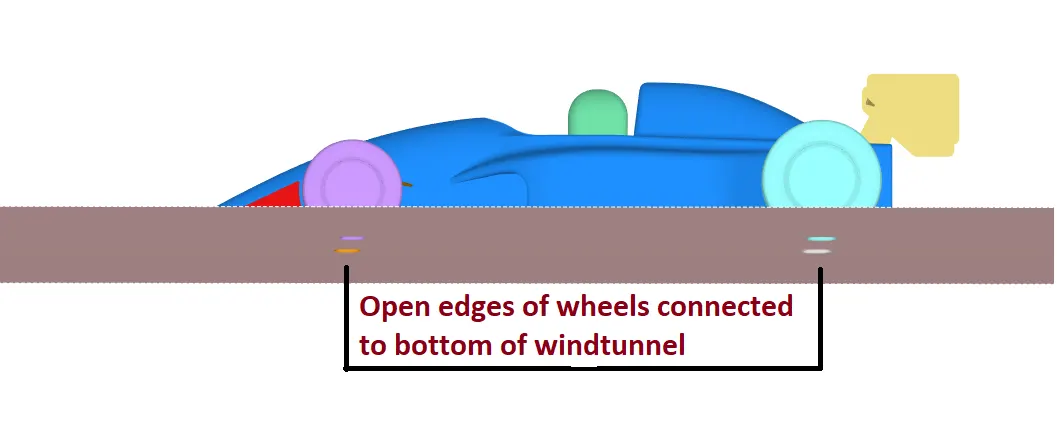
For our case, the dimension of the FSAE car is 2.48 m ~ 2.5 m as shown in Fig 2.1. Accordingly, our virtual wind tunnel will be of dimensions [5*(L)] i.e. (5*2.5) `=>` 12.5 m in the front of the FSAE car & [10*(L)] i.e. (10*2.5) `=>` 25 m in the back of the wind tunnel. Therefore, the total length of the wind tunnel for both cases will be 37.5 m with a height of 2.5 m.
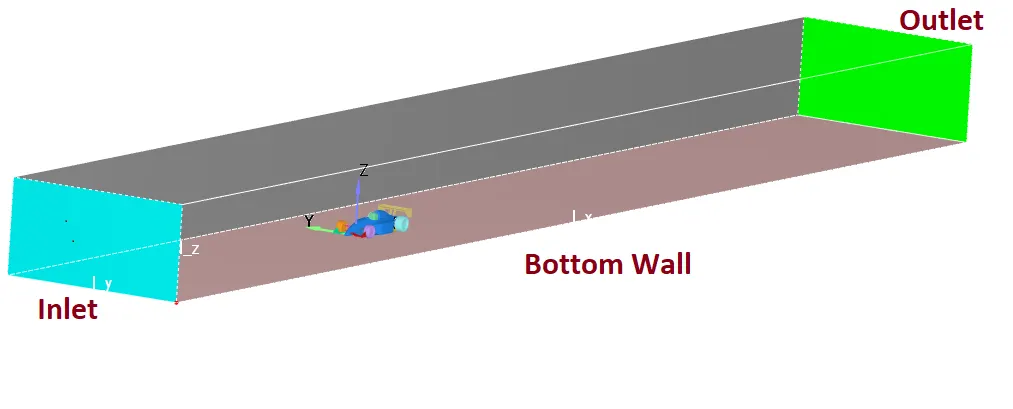
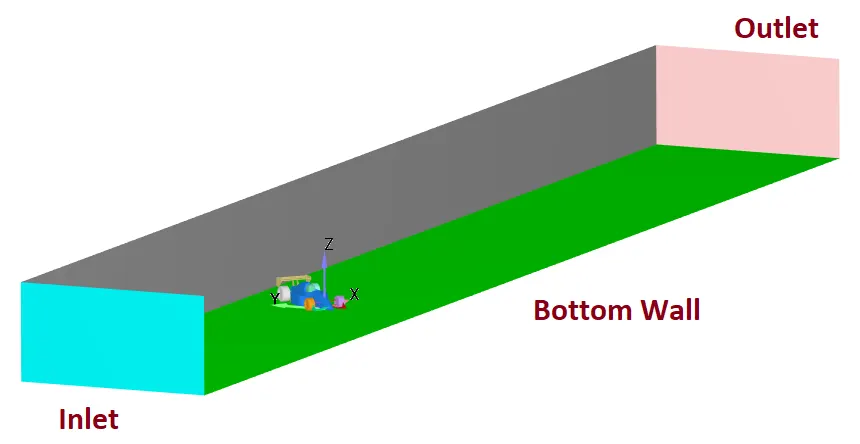
Fig 4.1:- FSAE car inside a wind tunnel for 2 cases [Case1: Straight Track, Case2: RaceTrack with curves].
5. Setting Up The Flow Physics For The Computational Model
The simulations were carried out with the Converge CFD Software. In Converge after editing the geometry, the next stage of the process is to set up the simulation parameters. This step involves specifying certain properties to capture the physics of the problem perfectly, such as materials used, simulation time parameters, solver parameters, initial & boundary conditions to solve the Navier Stokes equation which are PDE’s, defining body forces, type of fluid flow, species involved & grid size of the mesh.
We start setting up the time-based general flow simulation by first defining the Materials involved in the simulation. Since, we are simulation 2 different fluid flow inside a channel we choose ‘gas simulation’ and our choice of species are nitrogen (N2) & oxygen (O2), & we choose our pre-defined mixture as air. For gas simulation parameters we will be using the Redlich-Kwong equation of state with a critical temperature of 133K & critical pressure of 3770000pa. For global transport parameters, we use the default values of ‘turbulent Prandtl number’ and ‘Schmidt number’ which is 0.90 & 0.78 respectively.
The next parameter for our case setup is the Simulation Parameters, which include the ‘run parameters’, ‘simulation time parameters’ & the ‘solver parameters’. For the aerofoil problem, we will be running compressible gas flow using transient solver at full hydrodynamics simulation mode, since our geometry is simple & has no moving part & we also require to solve the NS equations. In addition to this, we will be using ‘density-based’ PISO Navier strokes solver. As for simulation time parameters, we will be running the simulation for an end time of 2.5 sec & 3.4 sec with an initial & minimum time step as (1e-07). Drag & Lift coefficient was calculated for both cases & the turbulent model used was k-ω SST.
[ Note:- To find the end time for a transient based simulation,
Flow-Through Time = Length of Wind Tunnel ÷ inlet velocity
We already know the length of the wind tunnel, which is 5 meters & to find the inlet velocity we use the Reynolds number; `Re = (rho VL) / (mu)`
where Re = Variable we need to find, ρ = 1.1839 kg/m^3 , V = 30 m/s for a straight racetrack & 22 m/s for racetrack with curves, L = 2.5 m (length of FSAE), μ = 1.84e-5 kg/ms. Solving we get the Re to be 2083333 for case 1 & 3471667 for case 2.
`therefore` flow through time or end time = `37.5/30` => 1.25 seconds for case 1 & `37.5/22` => 1.70 seconds for case 2
once we get the end time we multiply the value by at least (2) to allow the solution to converge & reach a stable condition]
As earlier, after designing the geometry, we grouped the triangles and assigned them to a particular boundary ID. Similarly, in Boundary Condition, we group the 18 boundaries & assign each of them to a volumetric region. To do so we add a volumetric region from Initial Conditions & Events & assign the volumetric region (Region 0) to each of the boundaries. These volumetric regions are required to set up the initial conditions for solving PDE's & will have a velocity of 30 m/s in the x-direction for case1 & 22 m/s in the x-direction for case2. Initial conditions are assigned at the volume whereas boundary conditions are given at boundaries. The Inlet & Outlet boundaries are inflow & outflow boundaries respectively, each component of the FSAE car is assigned to a stationary wall with a fixed surface following the ‘Law Of Wall’ & a temperature boundary condition of 300k which is also following the ‘Law Of Wall’. At the inlet boundary of the geometry, we defined a total pressure as Zero Normal Gradient (ZNG), Velocity of 31.4 m/s & temperature of 300K with Air being the species. At the outlet boundary of the geometry, we defined a total pressure of 101325 pa & temperature of 300K with Air being the species if backflow occurs.
The final parameter that we need to setup is defining the Mesh that is the Base grid size, for our case our base grid size along the entire geometry will be 0.38m for both the cases, with permanent box embedding near the FSAE car to capture the flow physics accurately as shown in Fig 5.1. The scale of embedding was 3 & the number of embedding layers will also be 3 near the components of the FSAE boundary this helps in refining particular areas in the domain. For 3D output files, we can calculate by dividing the end time with a number depending on our required output files. [`1.25/0.0025 = 500` & `1.7/0.017 = 1000`].
[ Note:- The grid scaling or the base grid size was calculated near the wall boundaries by taking the desired Y+ value, with inputs of the free-stream velocity, density characteristic length, dynamic viscosity in the pointwise Y+ calculator (https://www.pointwise.com/yplus/). The standard values of density & dynamics viscosity are based on the flat-plate boundary layer theory. The following equations are needed to be solved to obtain the wall spacing.
Reynolds Number => `Re = ( rho V L)/ mu` ; Skin Friction coefficient => `Cf = 0.0026/ (Re)^0.142` , non-dimensional number indicating the friction between the FSAE body & air ; Wall Shear Stress => `tauw= (Cf rho V^2)/2`; Friction Velocity => `Uf = ((tauw)/rho)^ 0.2`; Wall Spacing => `((Y^+) mu)/(Uf rho)`
Based on these calculations the wall spacing comes out to be 0.5mm or 0.00055 m, which is incredibly fine & would require a huge amount of computing power. Since the experiment has been carried out with a laptop such a fine grid will lead to the simulation running indefinitely. Hence, the base grid was increased to a value of 0.35 m for the x-y-z-axis. To make the mesh finner we added the box embedding & an embedding of scale 5 around all the components of the FSAE car.]
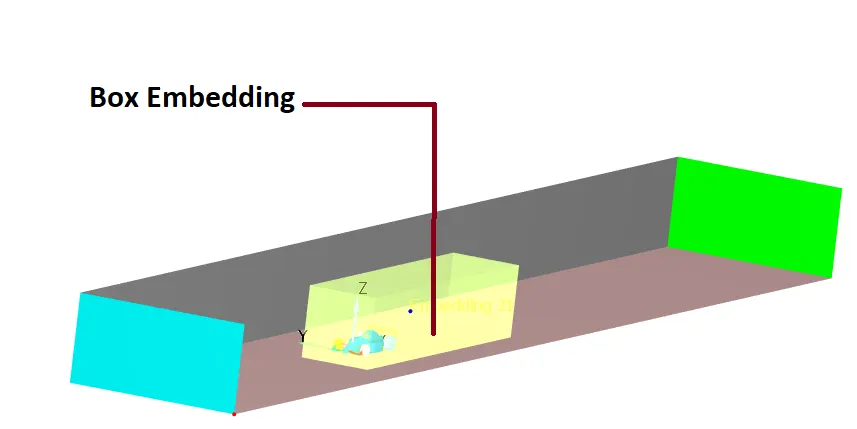
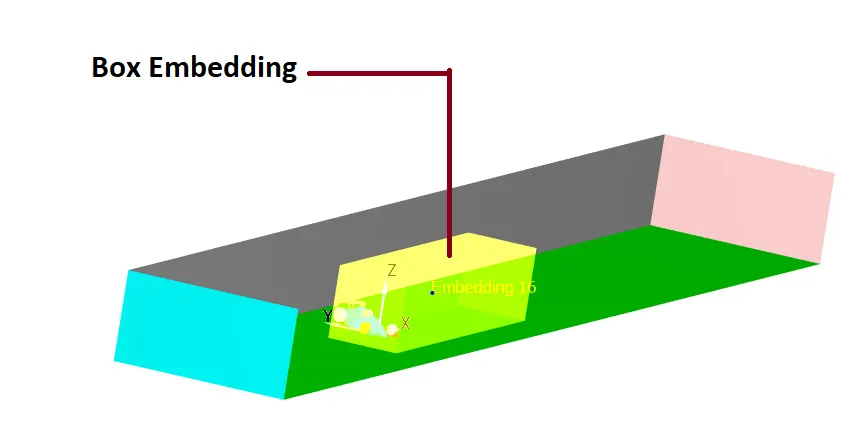
Fig 5.1:- FSAE car inside a Box Embedding for 2 cases [Case1: Straight Track, Case2: RaceTrack with curves].
6. Post Processing Results & Outputs For Both The Cases
The function of Converge studio is to set up the simulation & then create several input files which are then exported to a particular folder. To run these input files we use CYGWIN, a command-line interface that reads these inputs files & solves the complex PDEs of governing equation to generate several output files. These output files are then post-converted into 3D output files which are readable files for ParaView.
Results: Race-1
Racing track conditions - Lot of turns, Average lap speeds - 45kmph ; 70% turns at 45 degrees, 20% turns at 80 degrees & 10% turns at 20 degrees.
For Case 1, we have been given a racetrack condition that will comprise of 70% turns at 45°, 20% turns at 80° & 10% of turns at 20°. Instead of running the simulation for each case, we calculate the weighted average i.e. [(45° + 80° + 20°) / 3] => 48.33 ~ 49° which is the side-slip angle. Thus, the car was rotated at an angle of 49° & had a constant speed of 45 kmph.
A. Mesh
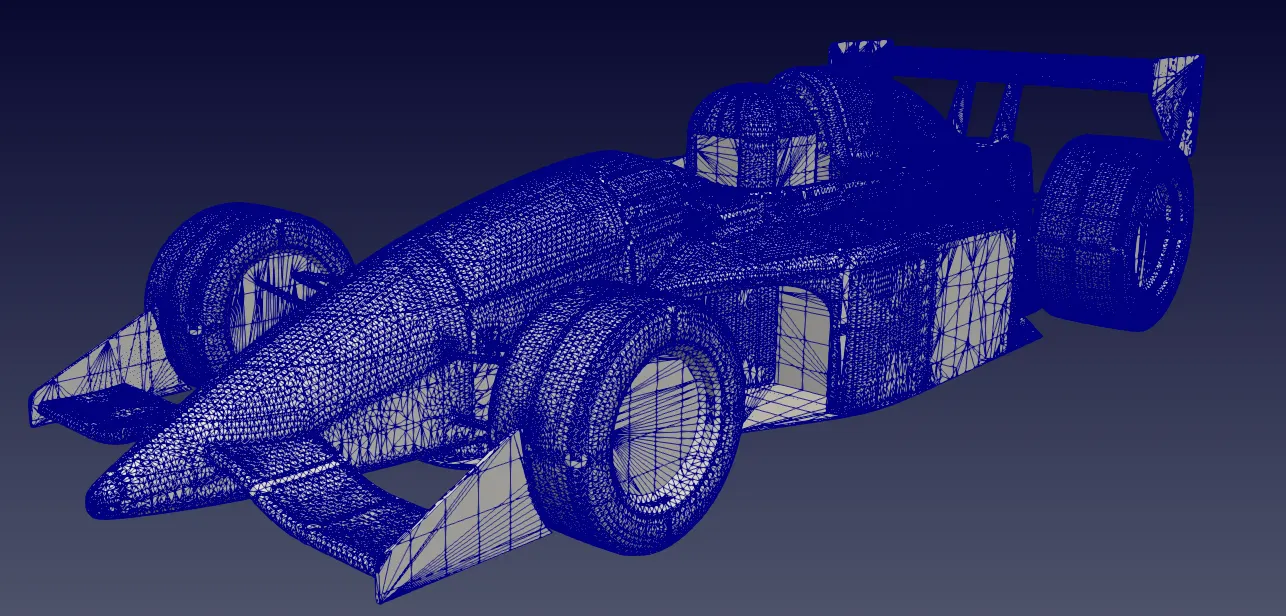
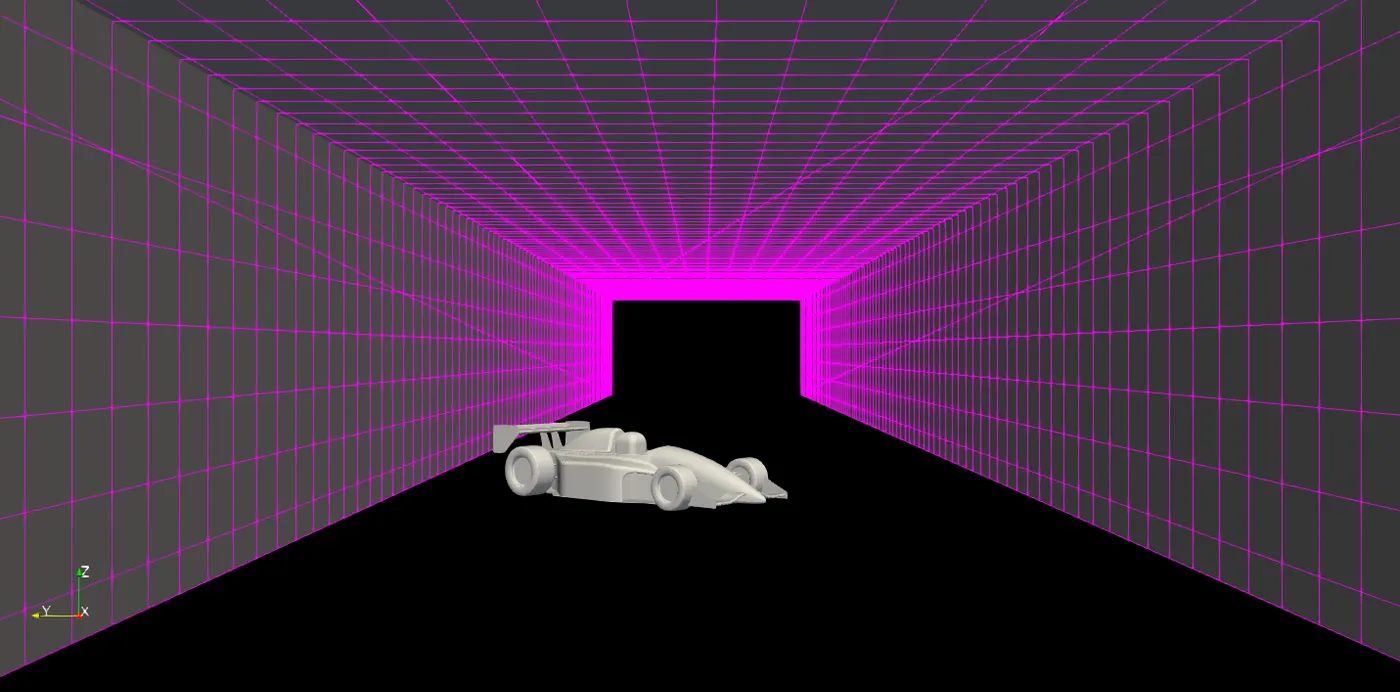
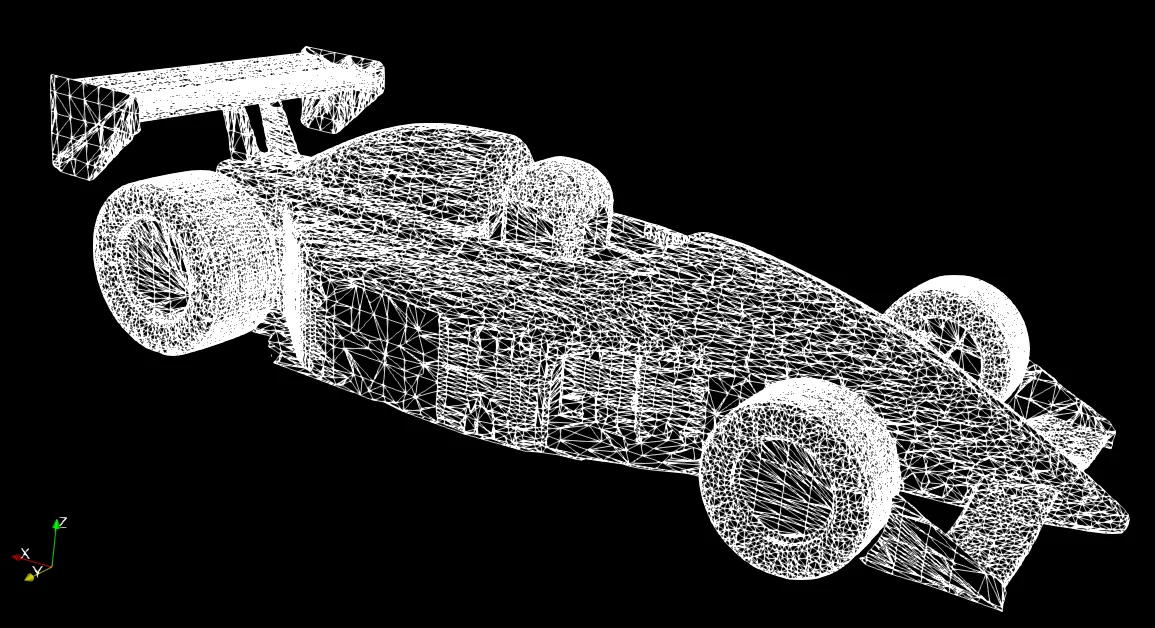
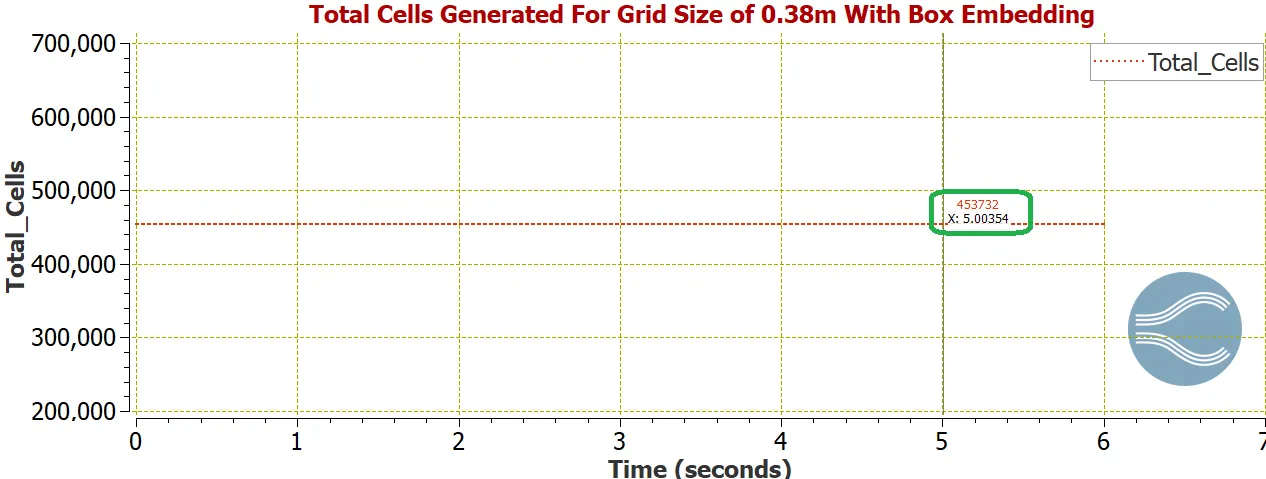
For case1, with a base mesh grid size of 0.38m, the total number of cells formed for the entire geometry is 453732 cells for the entire time period of the simulation for k-ω SST Turbulence Model. The smaller the mesh grid size the larger number of cells would be generated. At the boundary of the geometry, we observe a much finer mesh than compared to the entire surface, this is because we used ‘fixed embedding’ & 'box embedding' to refine the particular areas in the domain.
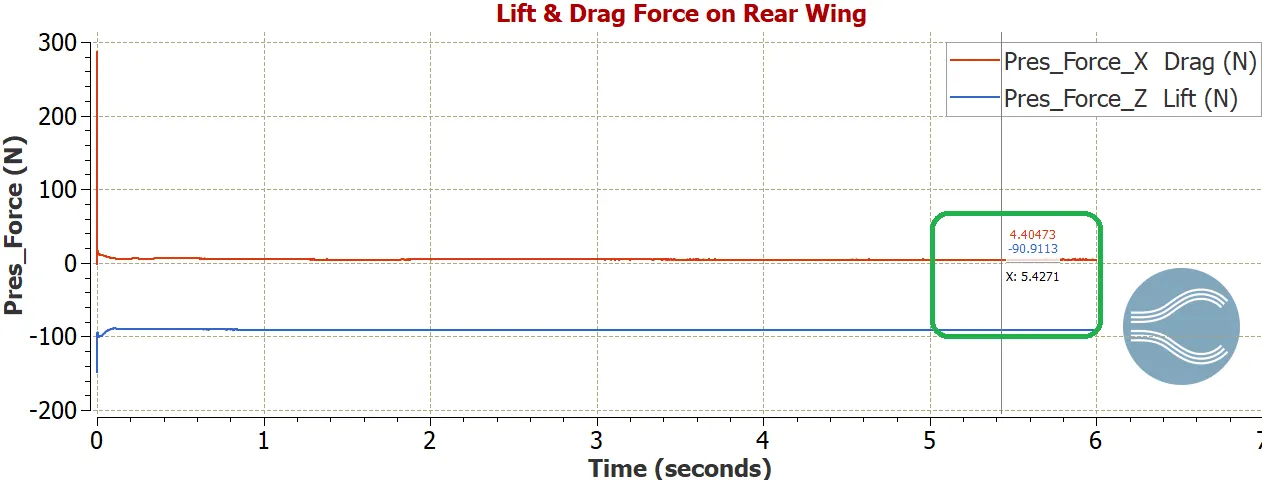
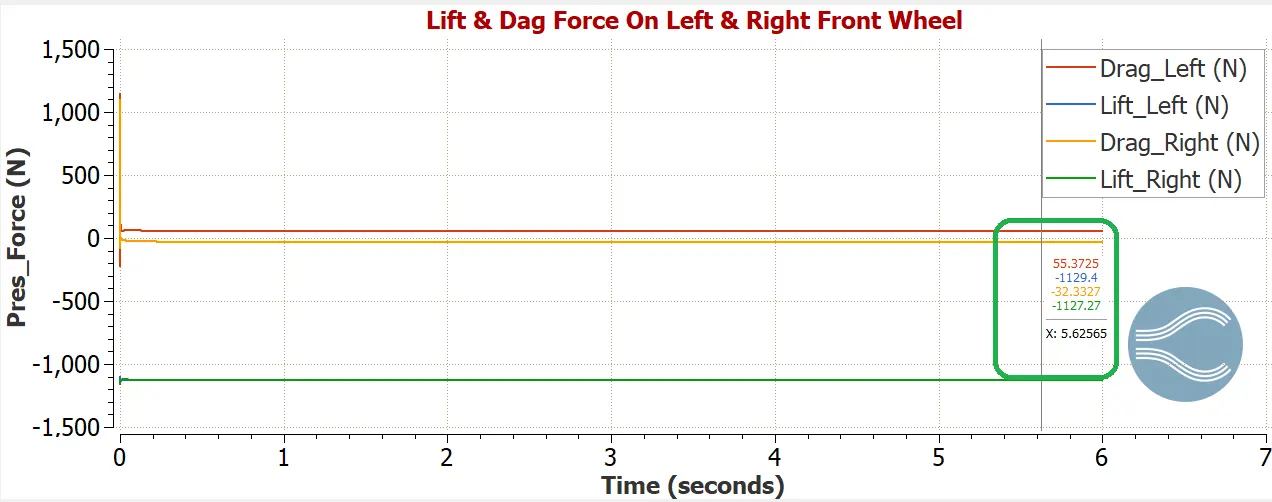
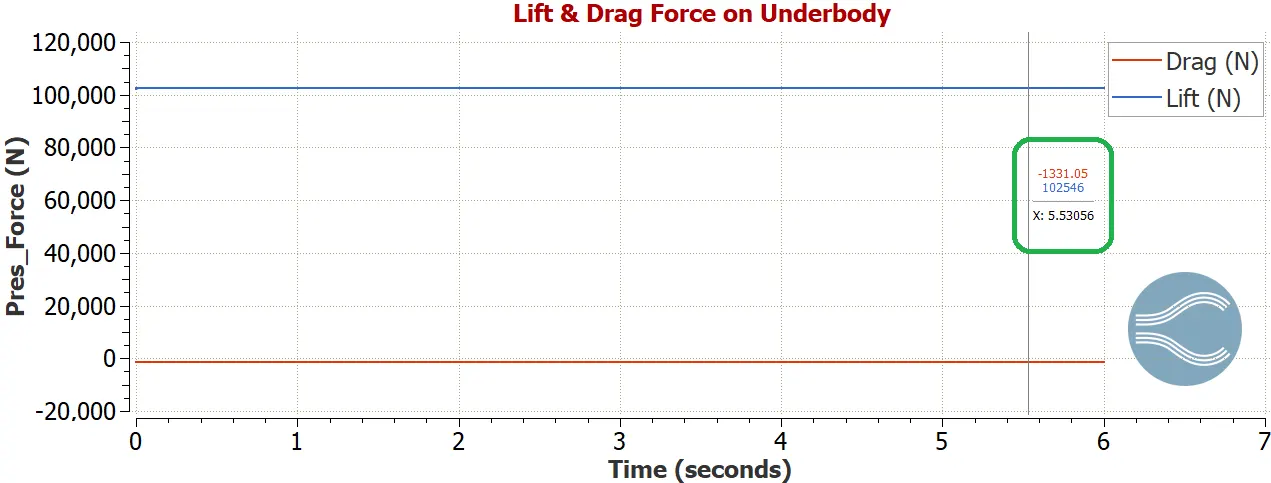
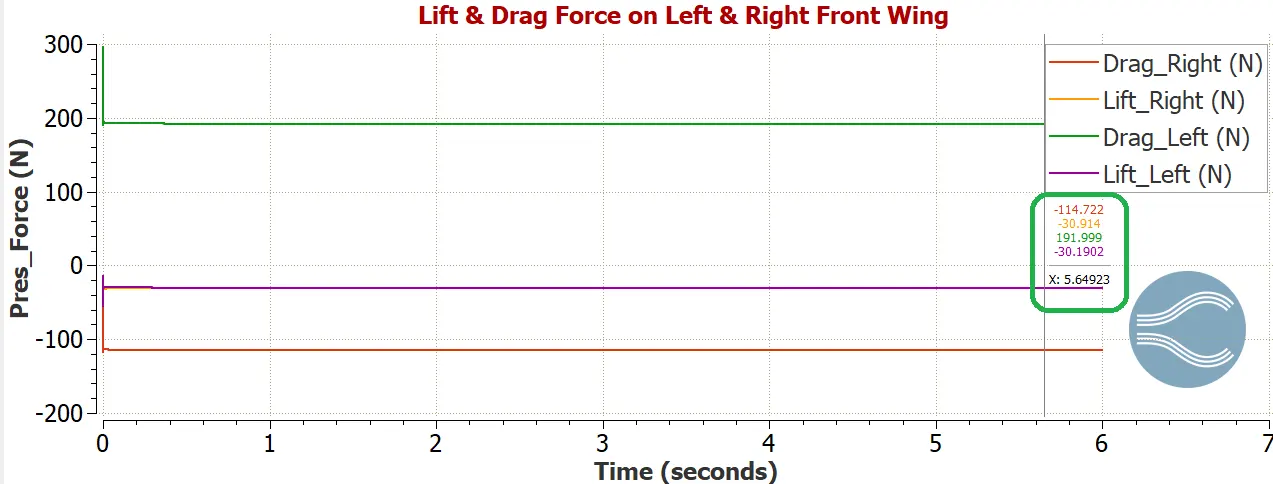
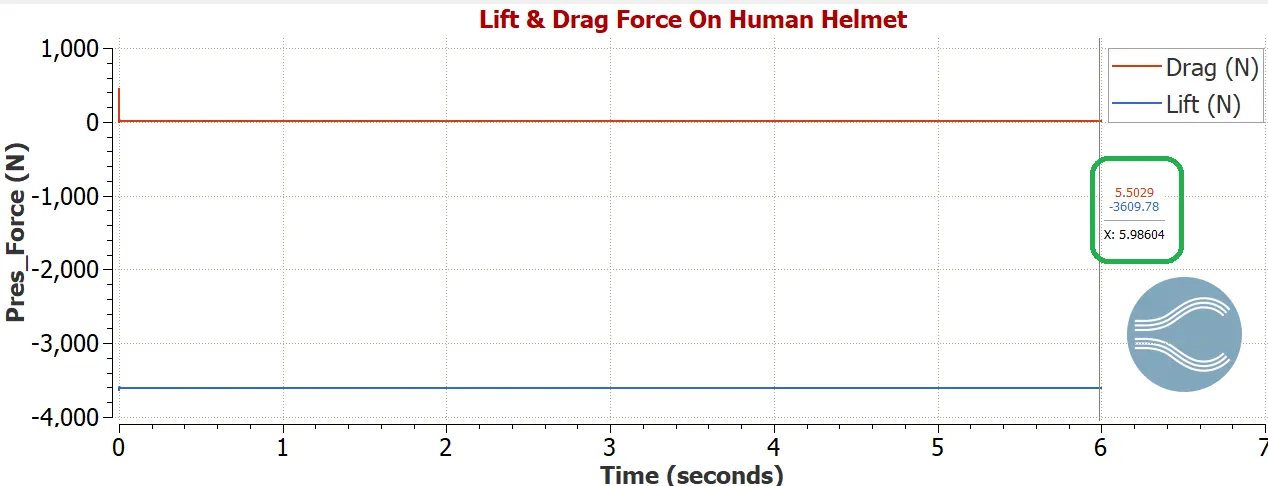
B. Lift & Drag force acting on each component of the FSAE car
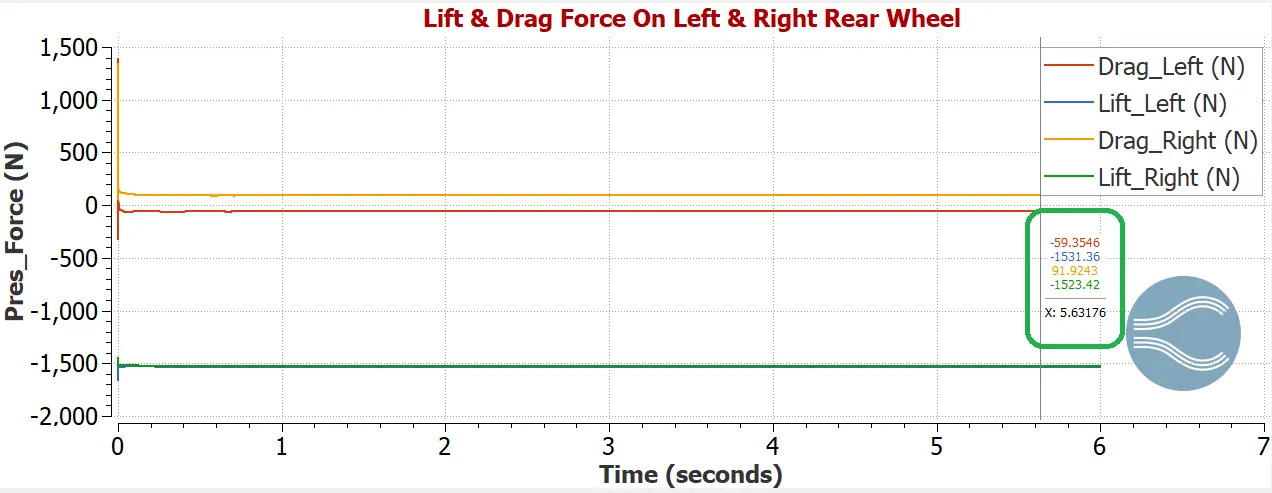
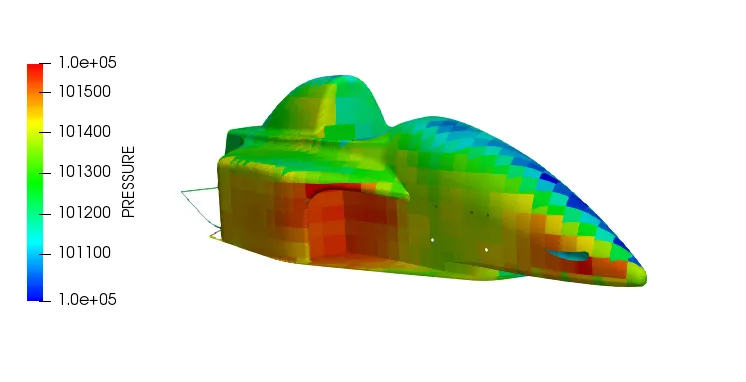
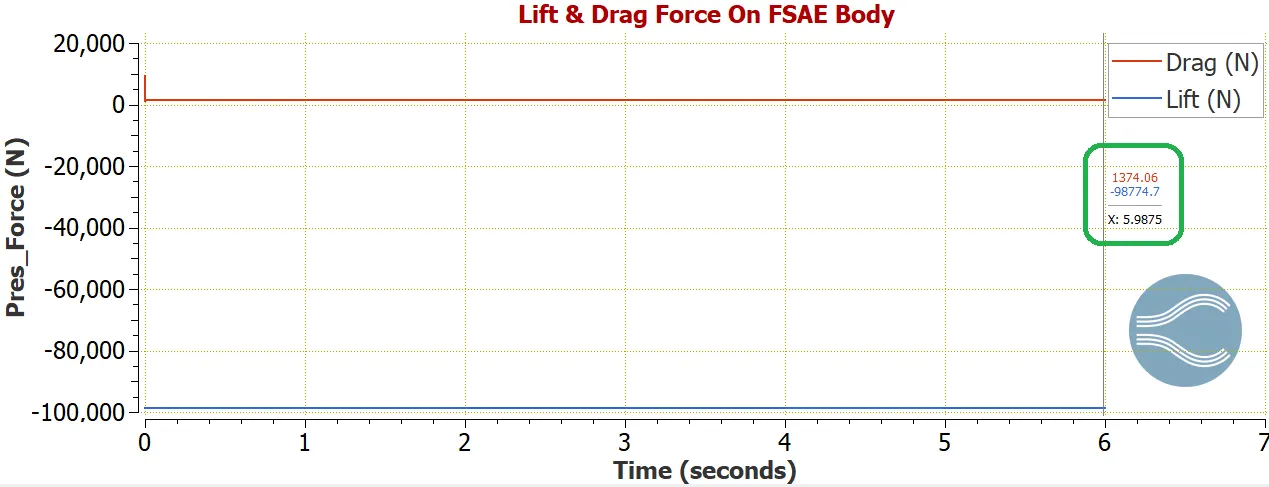
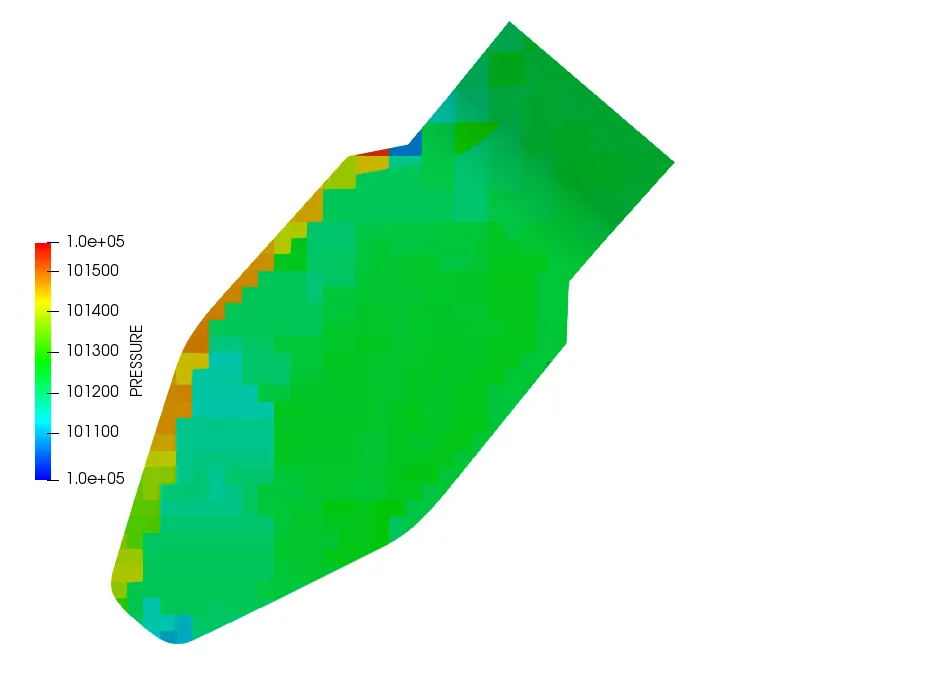
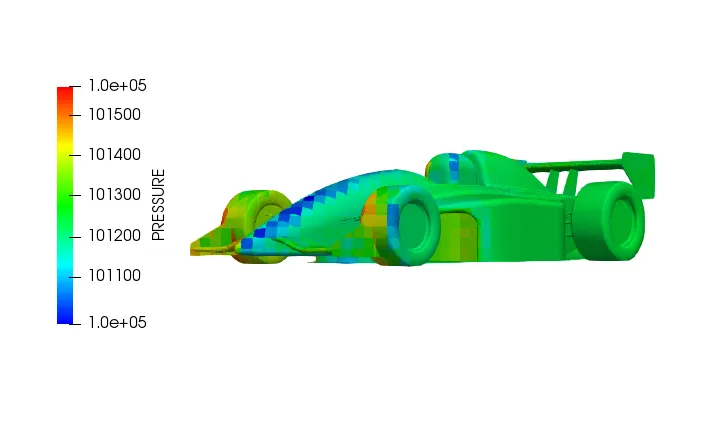
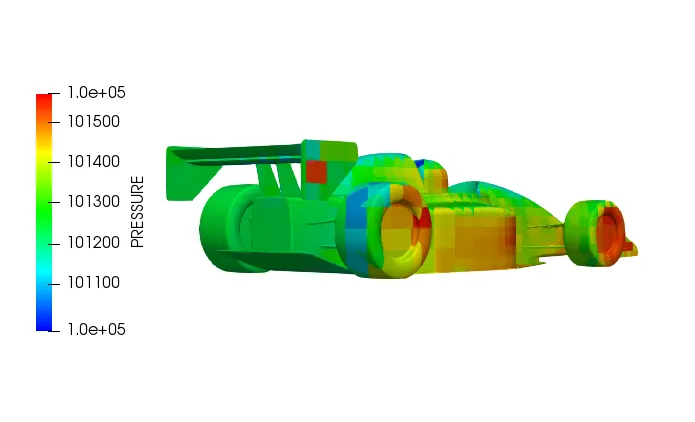
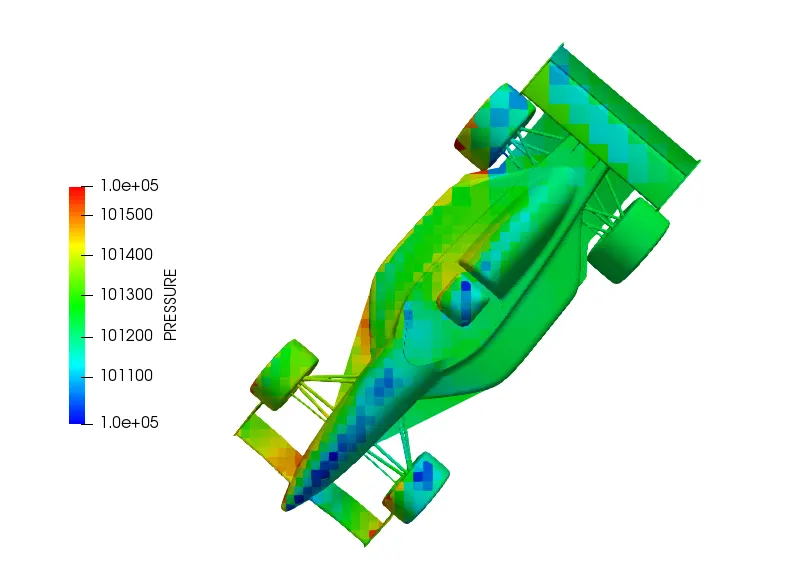
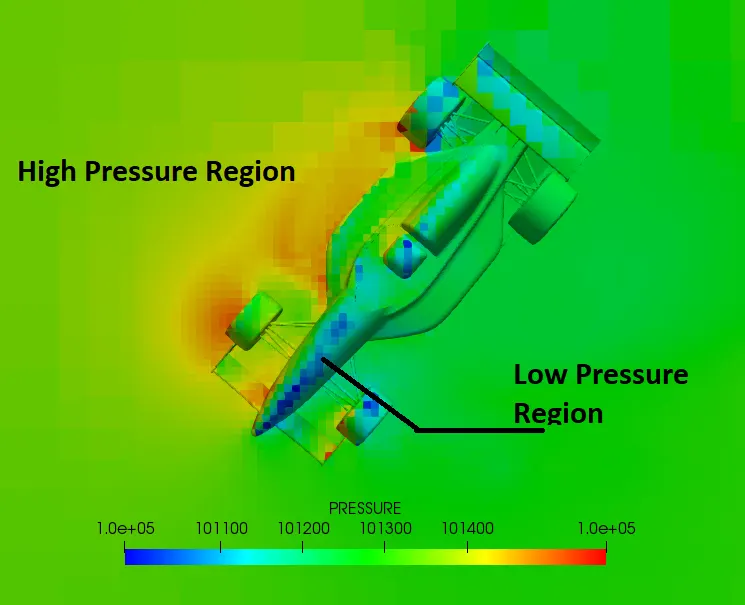
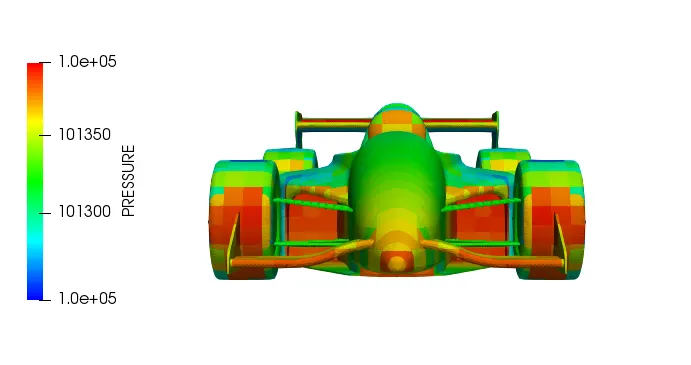
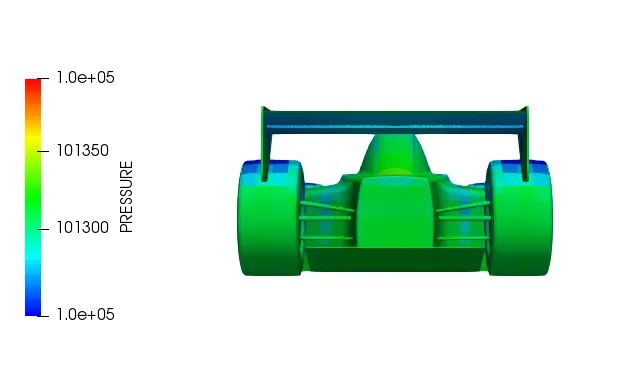
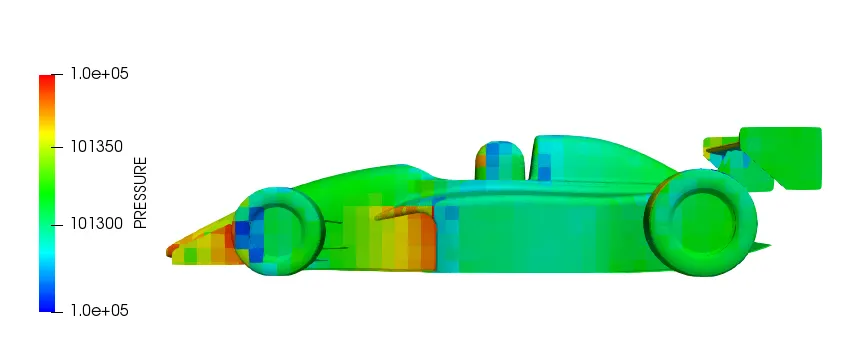
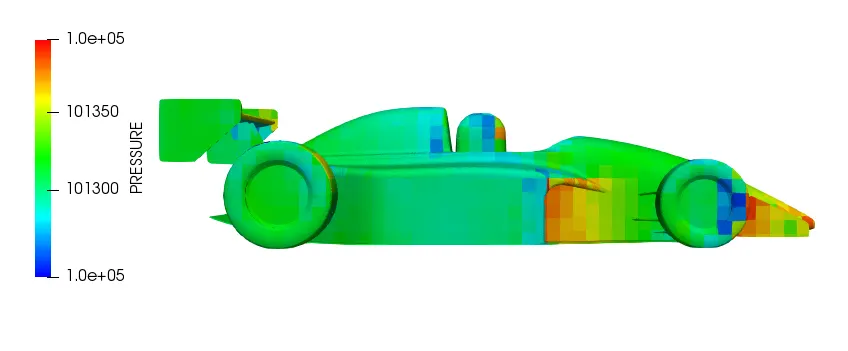
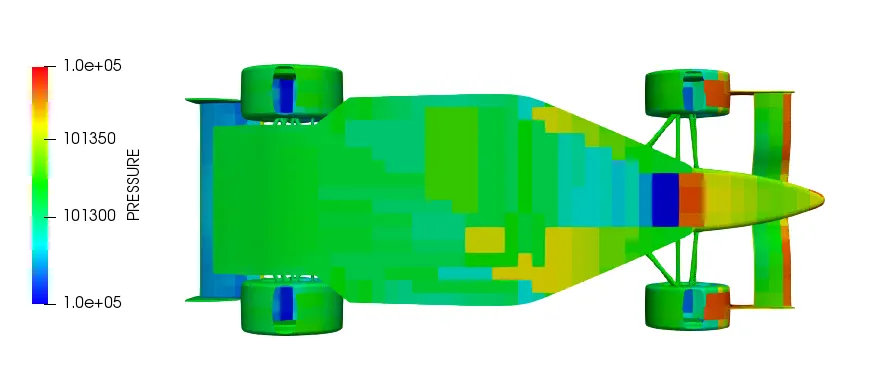
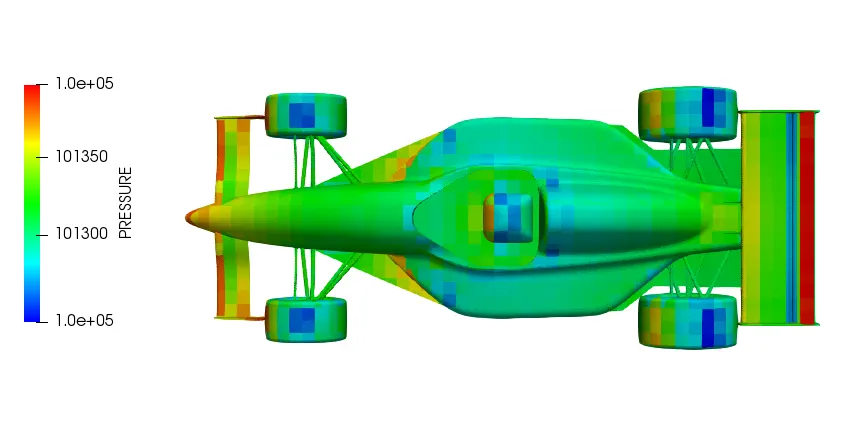
C. Pressure Contour Of The FSAE Car
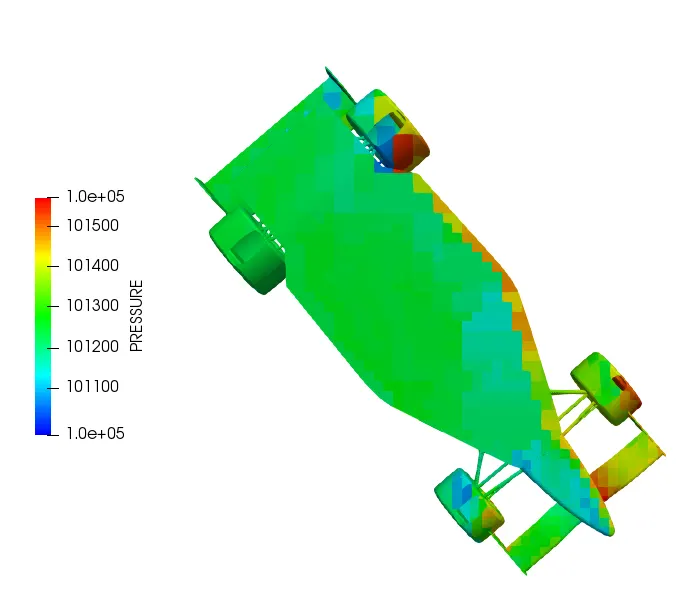
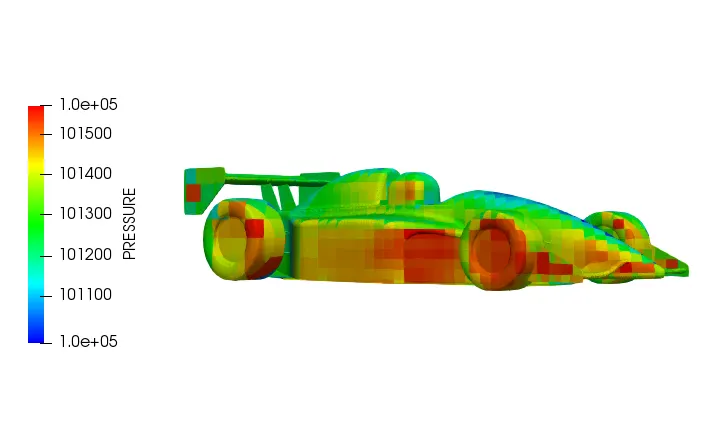
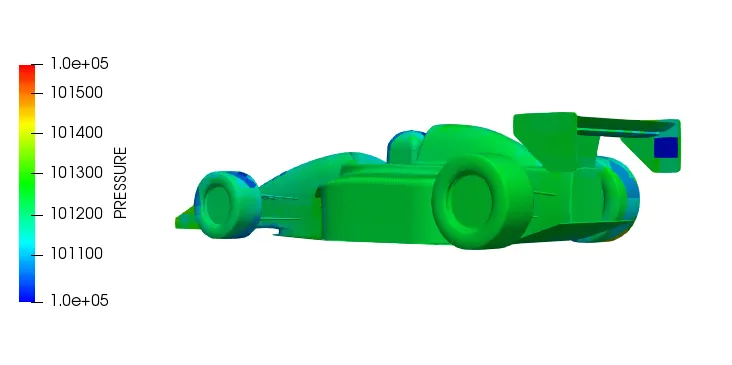
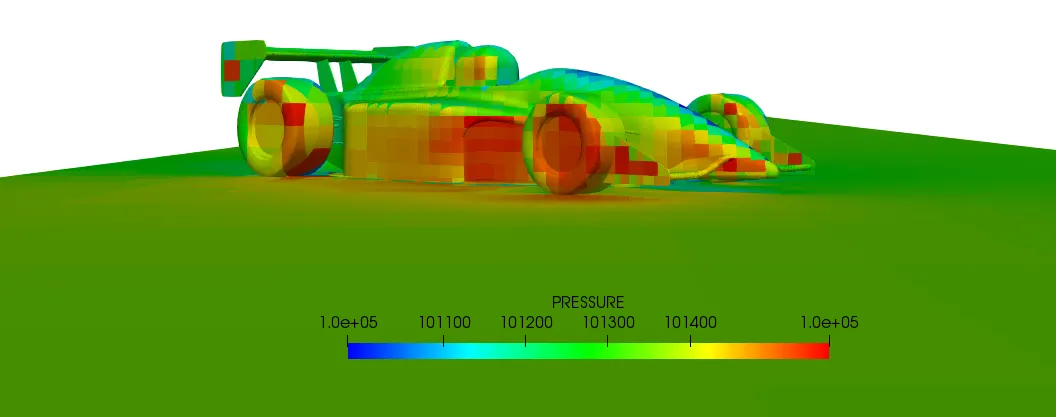
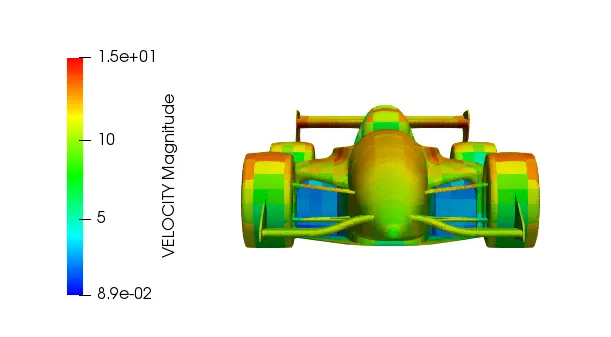
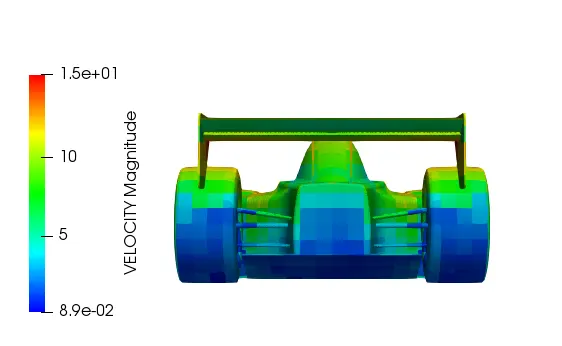
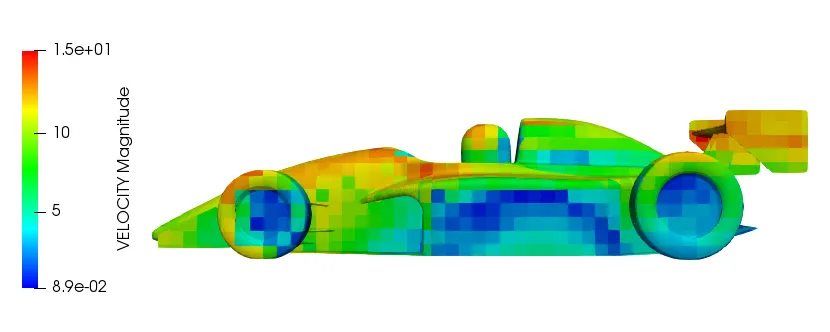
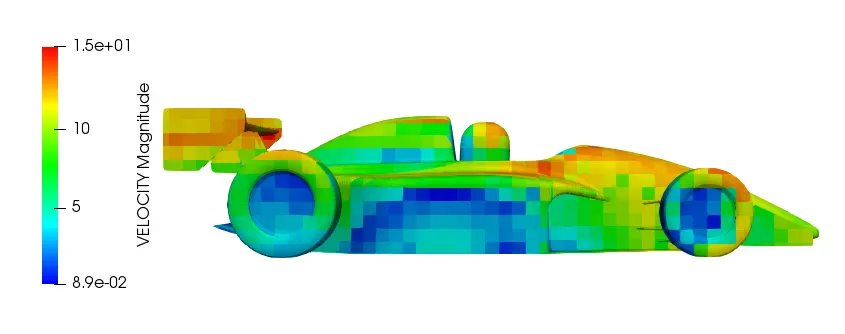
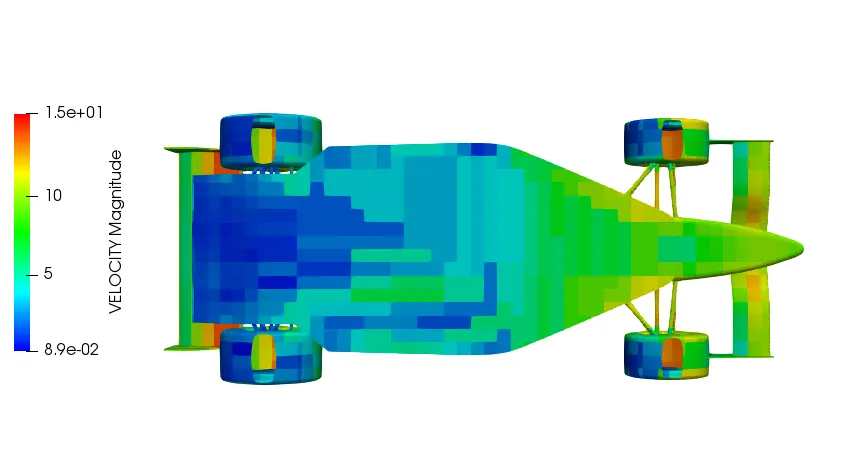
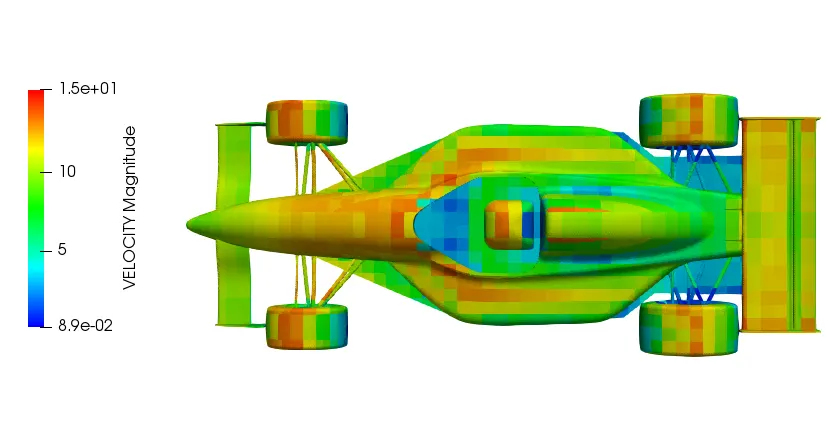
D. Velocity Contour Of The FSAE Car
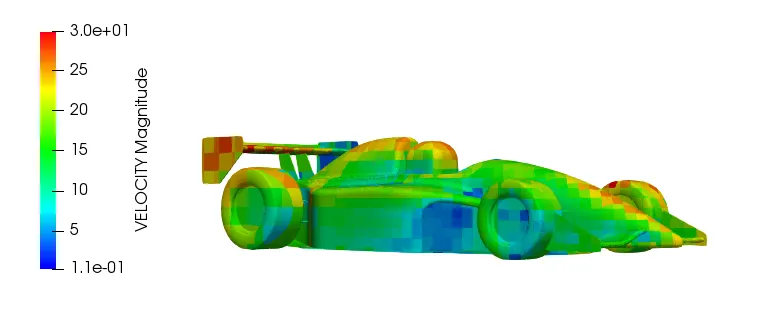
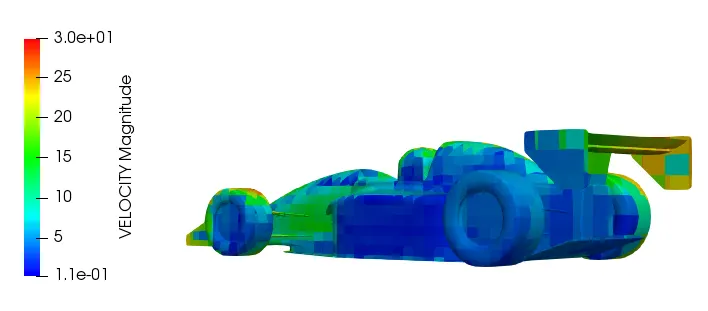
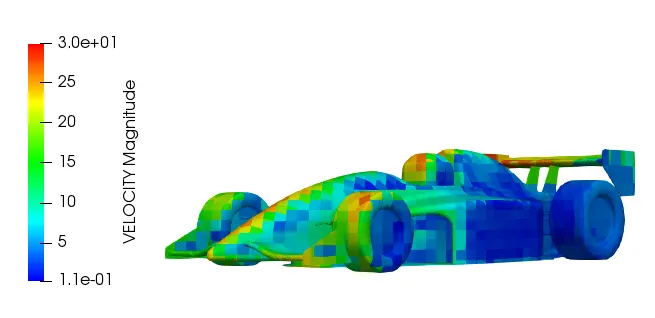
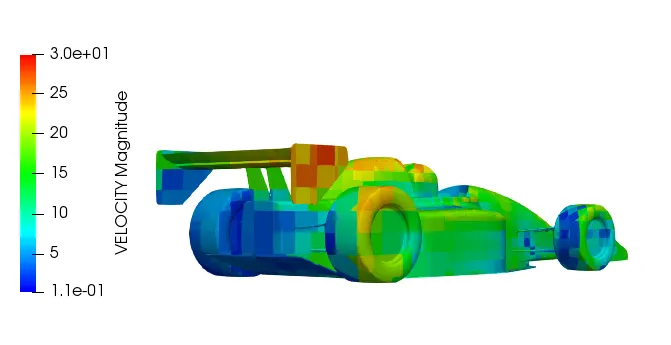
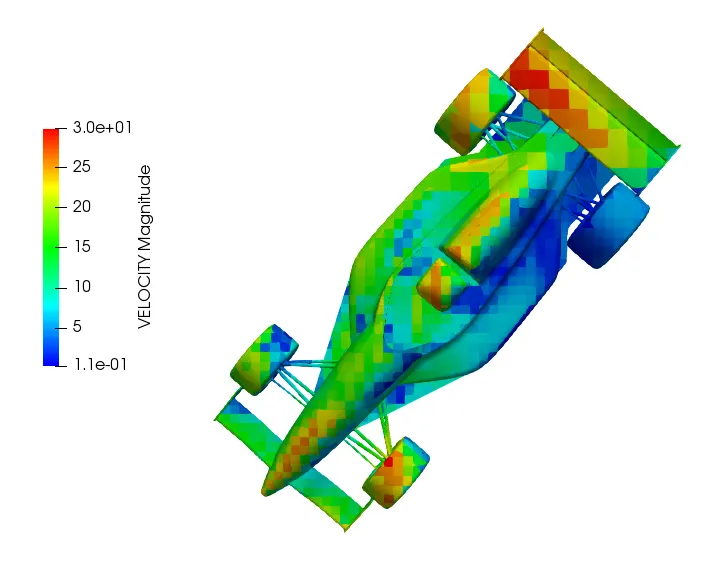
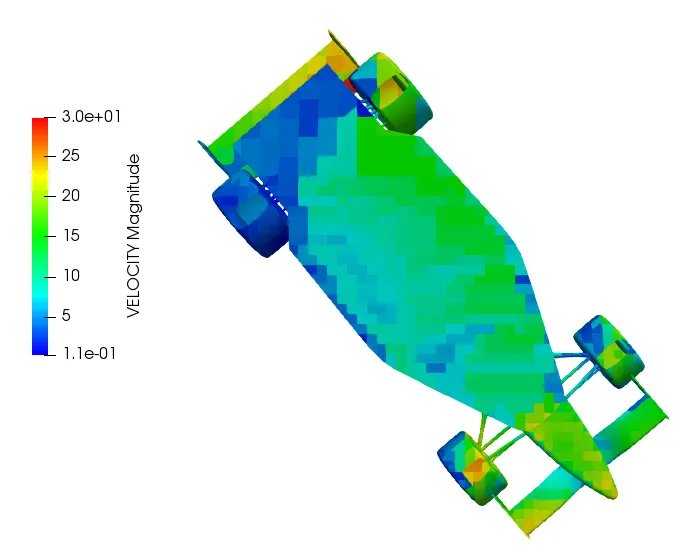
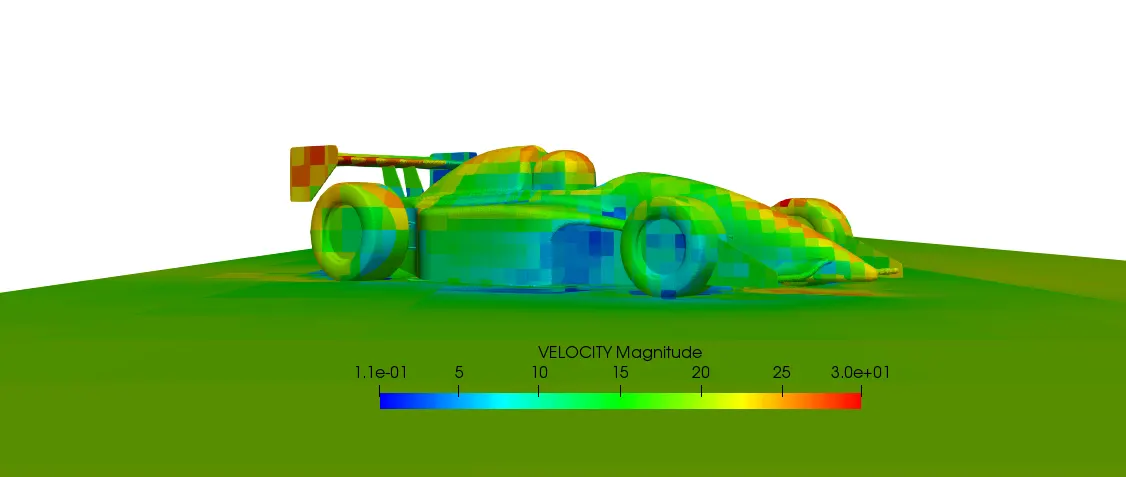
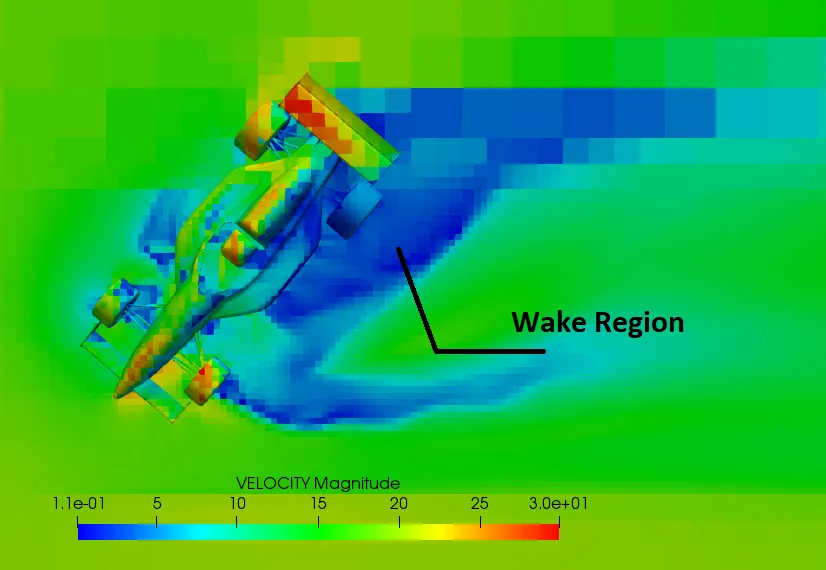
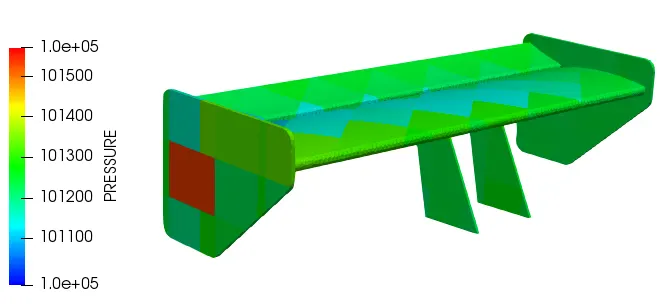
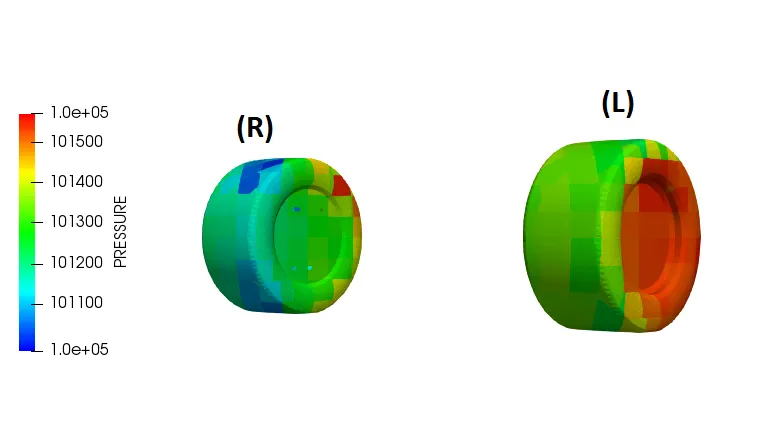
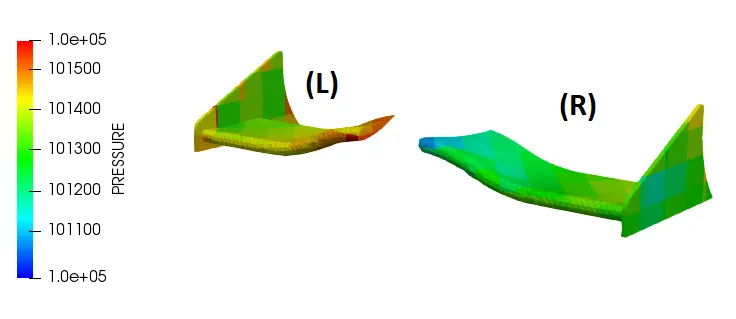
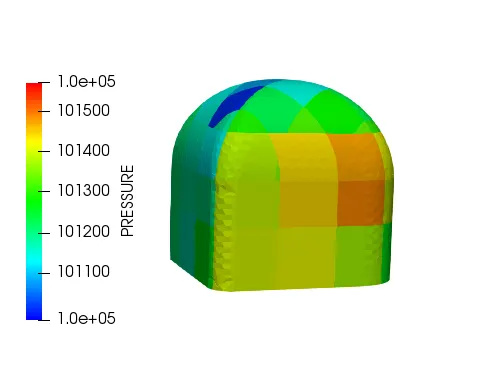
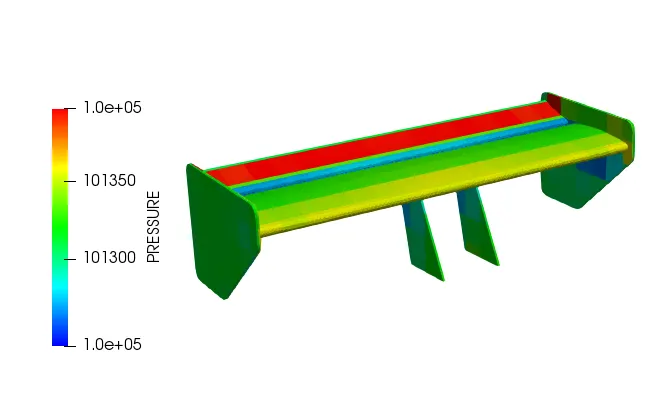
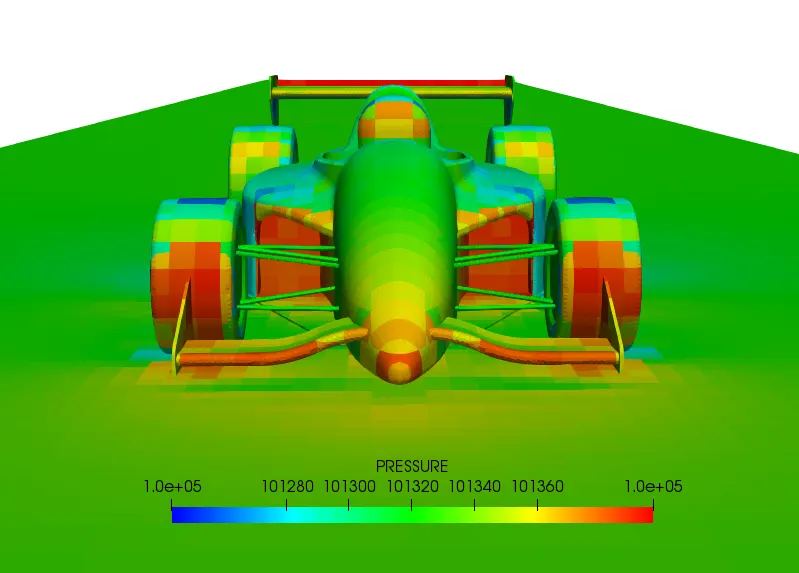
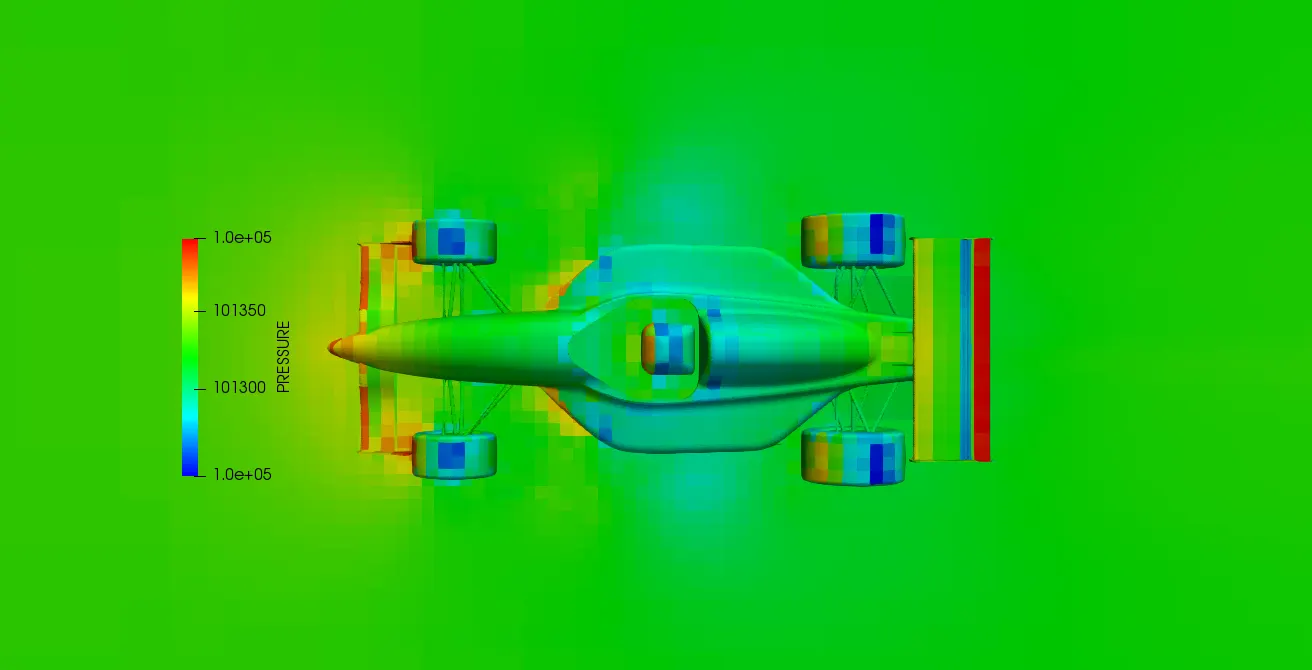
From the above Velocity & pressure profiles for the FSAE car, we observe a higher pressure on the windward side of the car where the wind is incident & a lower pressure on the leeward side of the vehicle at a 49° turn. This the source of the bulk of the form-drag & side-force come from. The incident pressure decomposes into drag force in the x-direction, side slip force in the y-direction & the negative lift force i.e. the downforce acts in the z-axis. There are certain regions of high pressure over the front wheel & wing that is facing towards the fluid flow. There are also regions of high pressure on the nose section of the body.
Results: Race-2
Racing track conditions - Straights; Average lap speed - 75kmph
A. Mesh
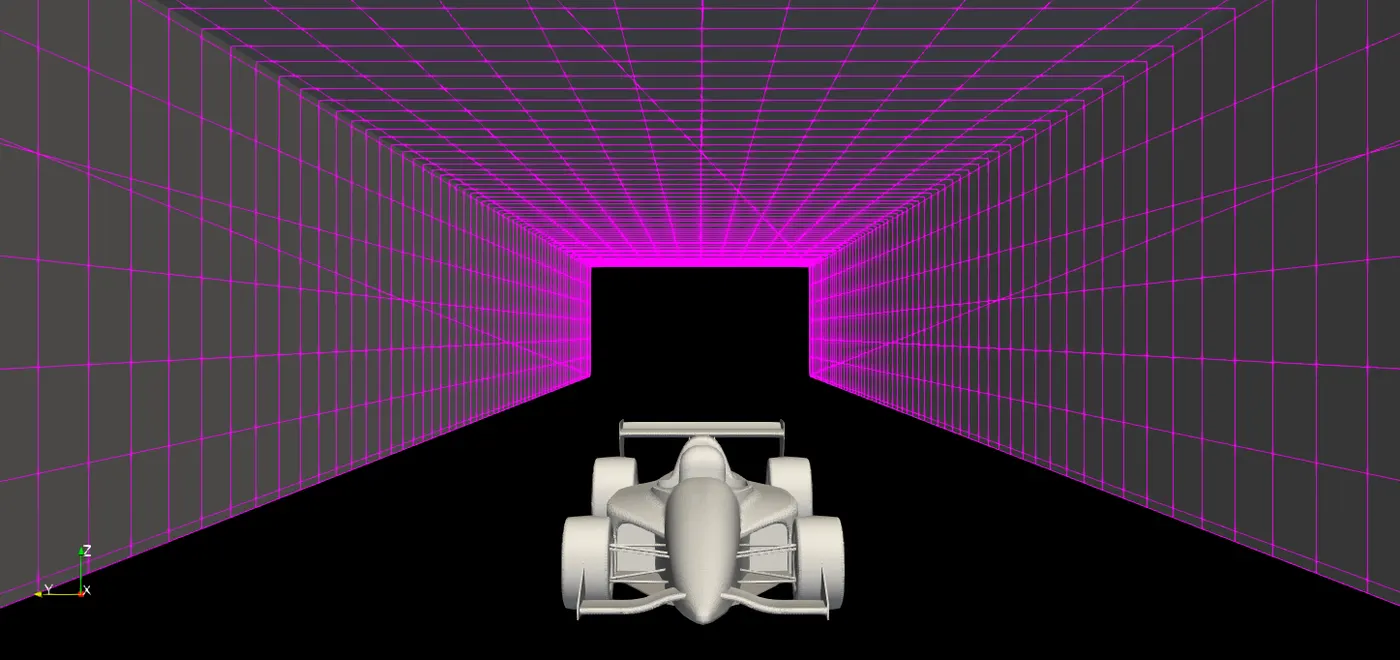
For case2, with a base mesh grid size of 0.38m, the total number of cells formed for the entire geometry is 453732 cells for the entire time period of the simulation for k-ω SST Turbulence Model. The smaller the mesh grid size the larger number of cells would be generated. At the boundary of the geometry, we observe a much finer mesh than compared to the entire surface, this is because we used ‘fixed embedding’ & 'box embedding' to refine the particular areas in the domain.
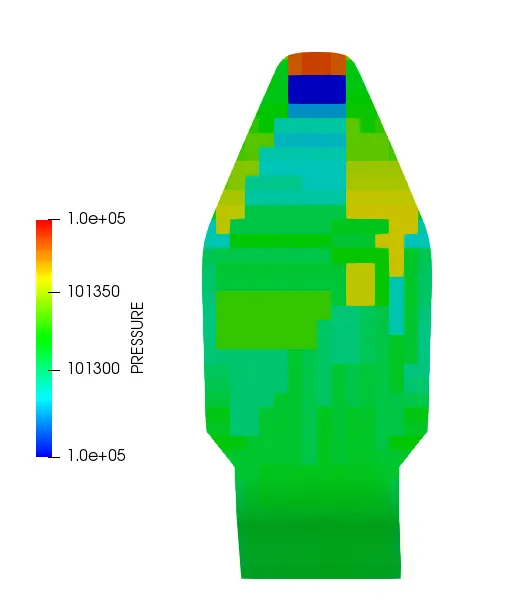
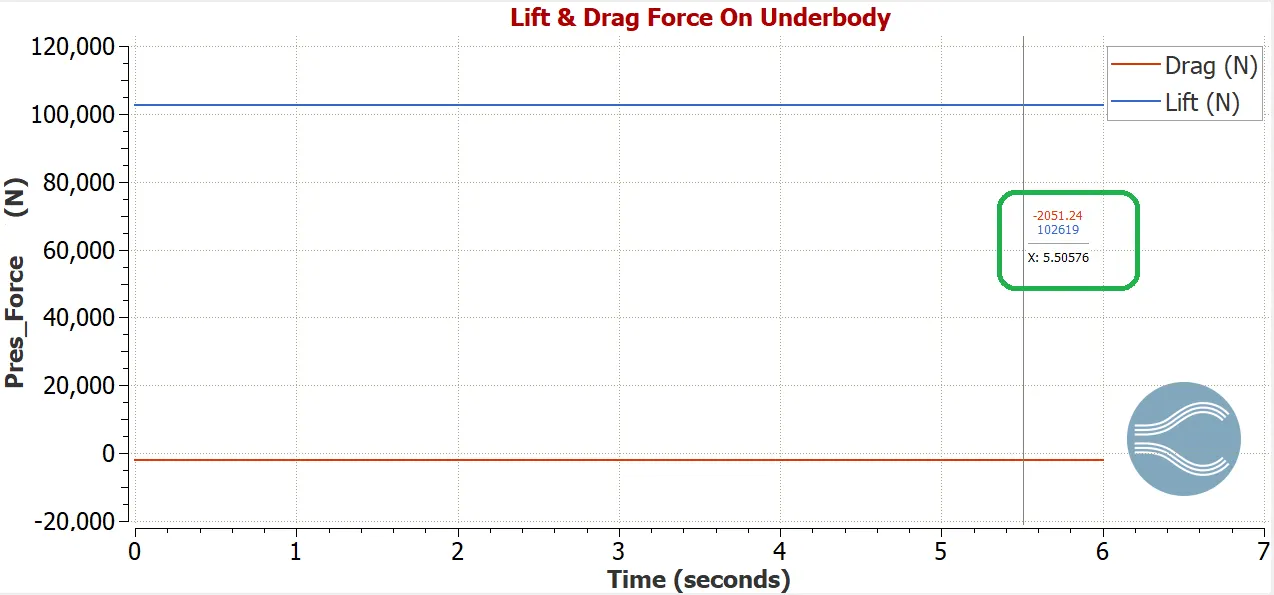
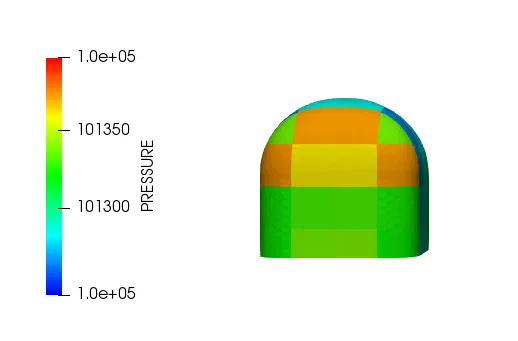
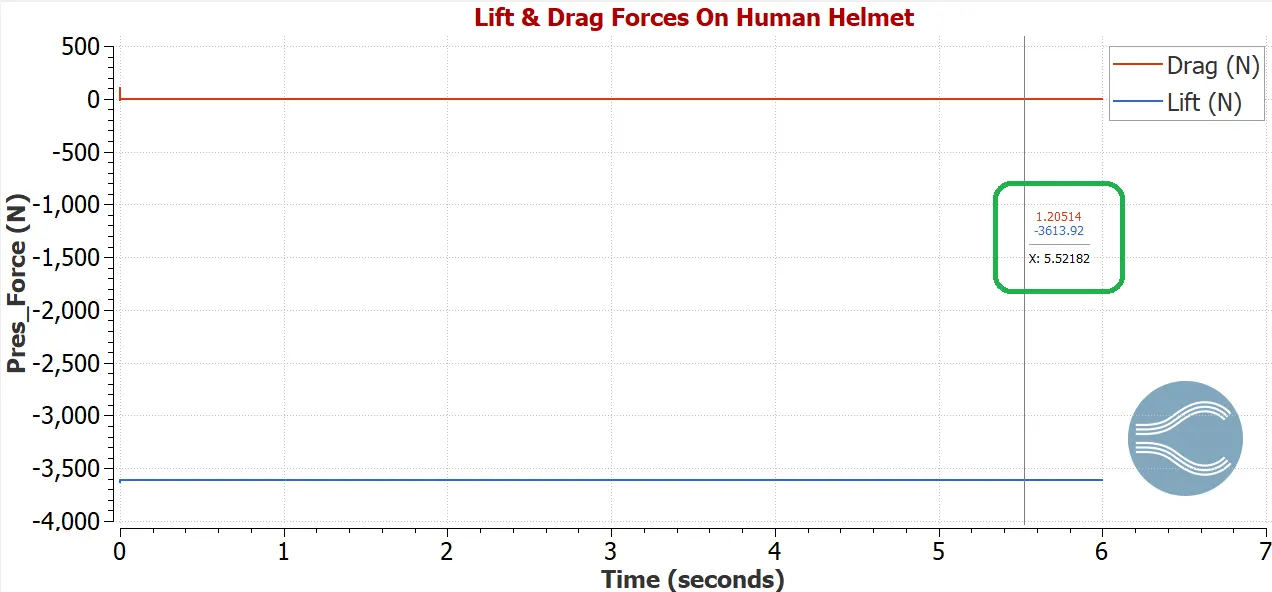
B. Lift & Drag force acting on each component of the FSAE car
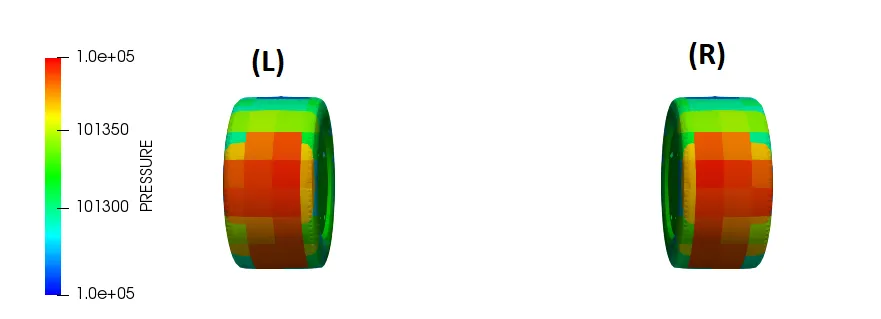
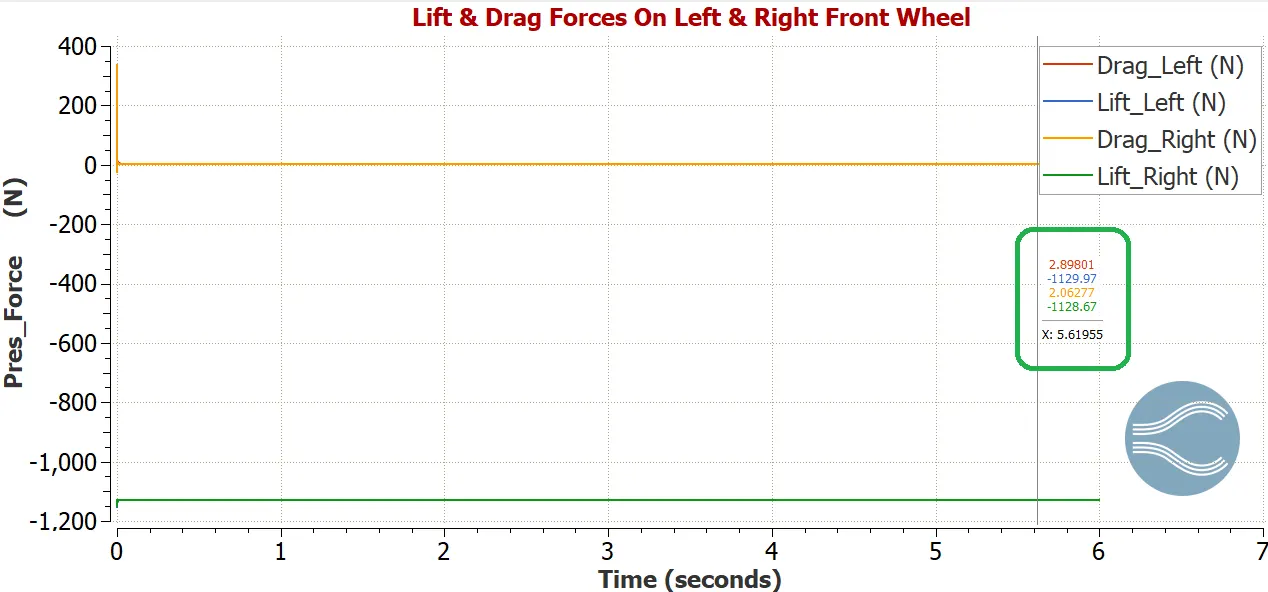
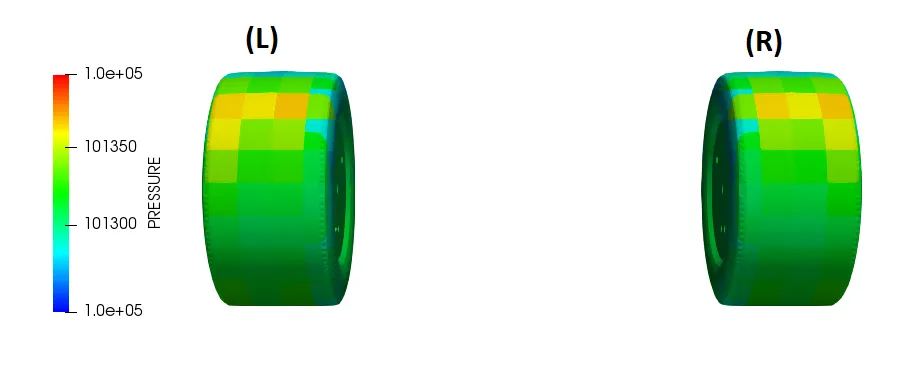
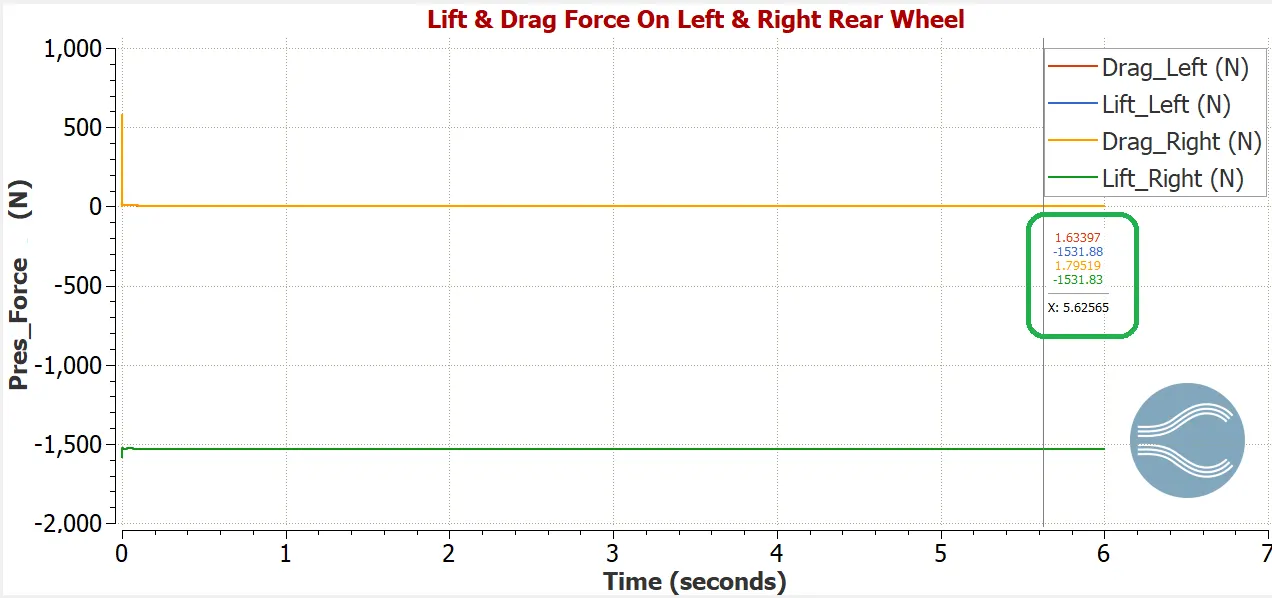
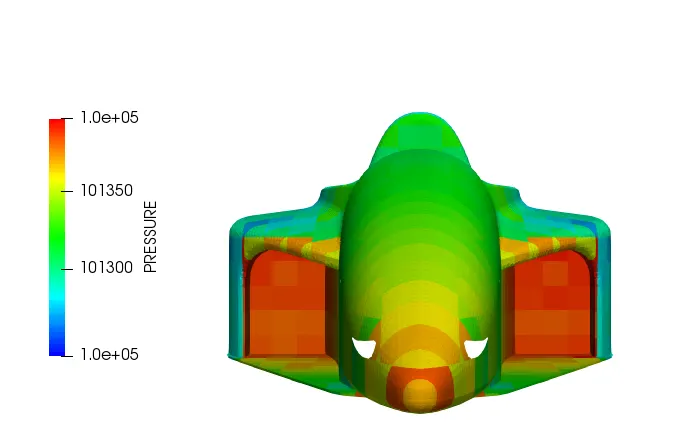
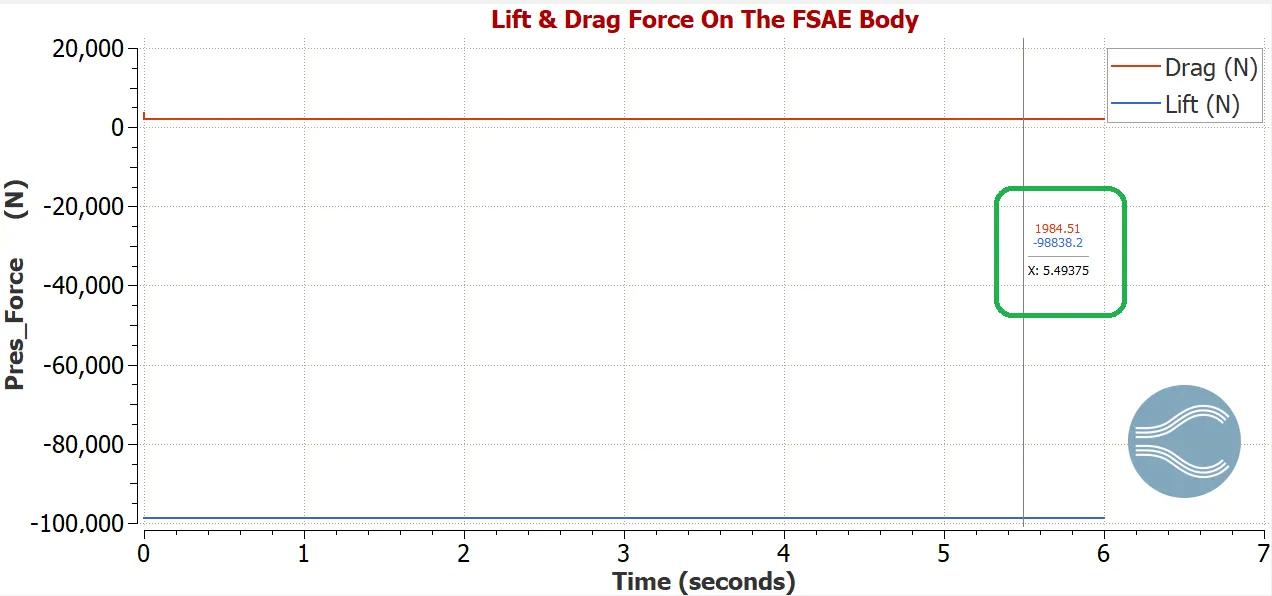
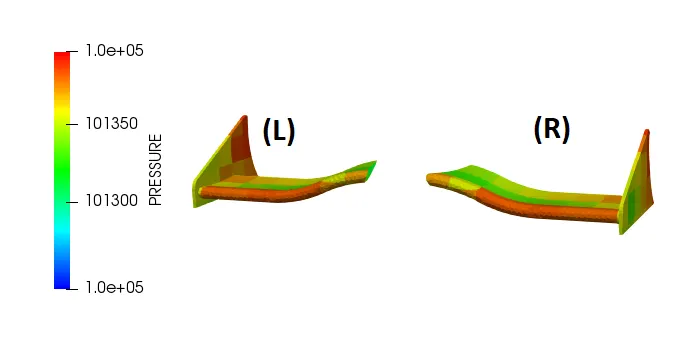
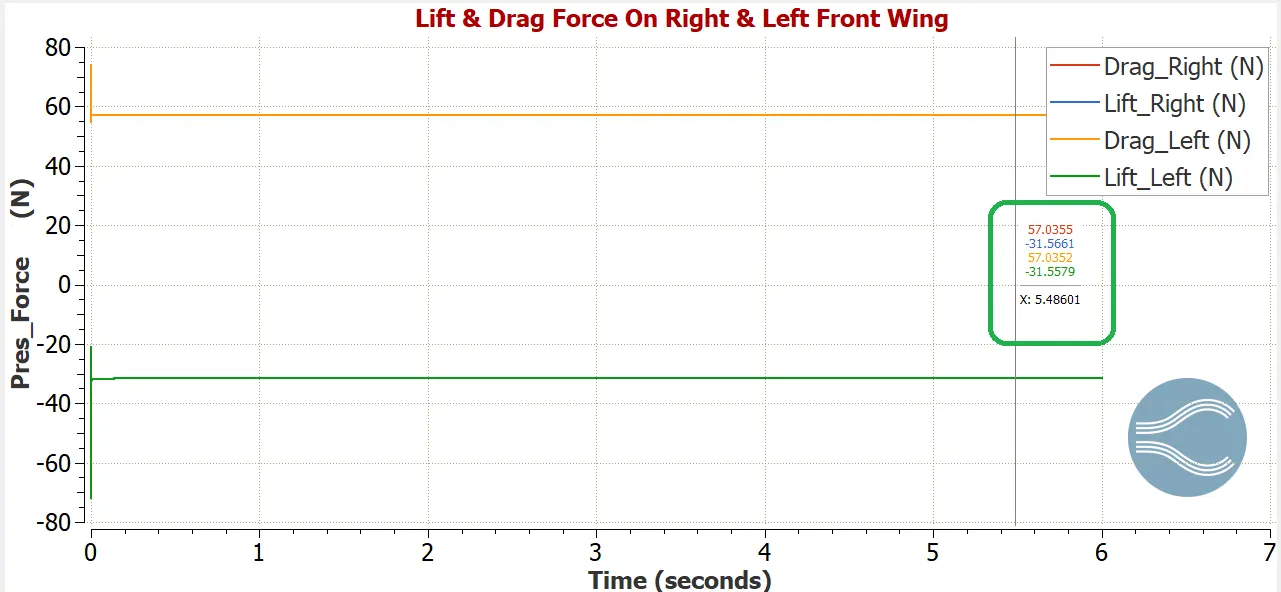
 ,
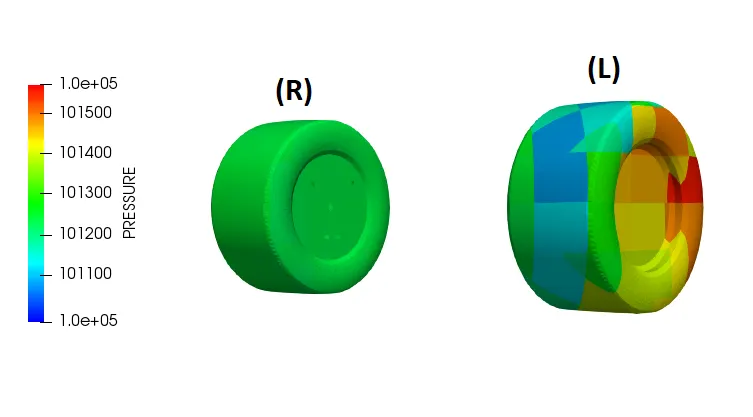
C. Pressure Contour Of The FSAE Car
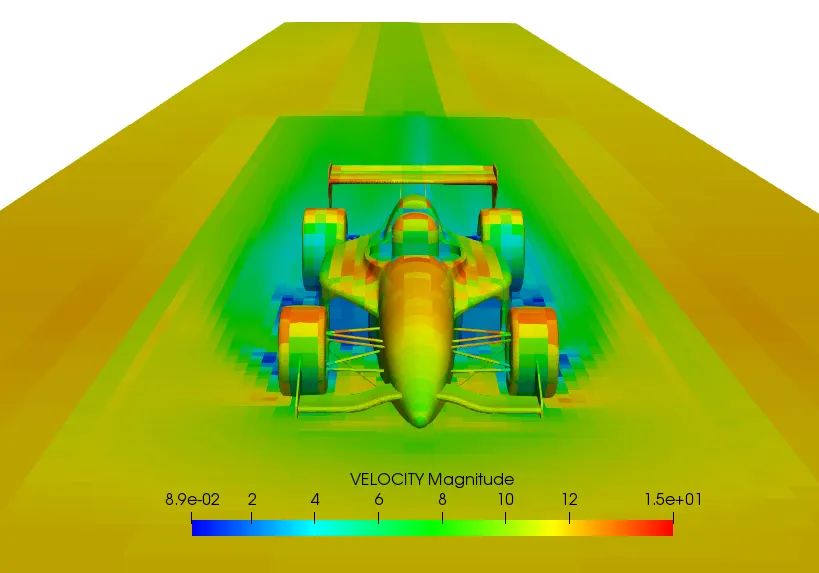
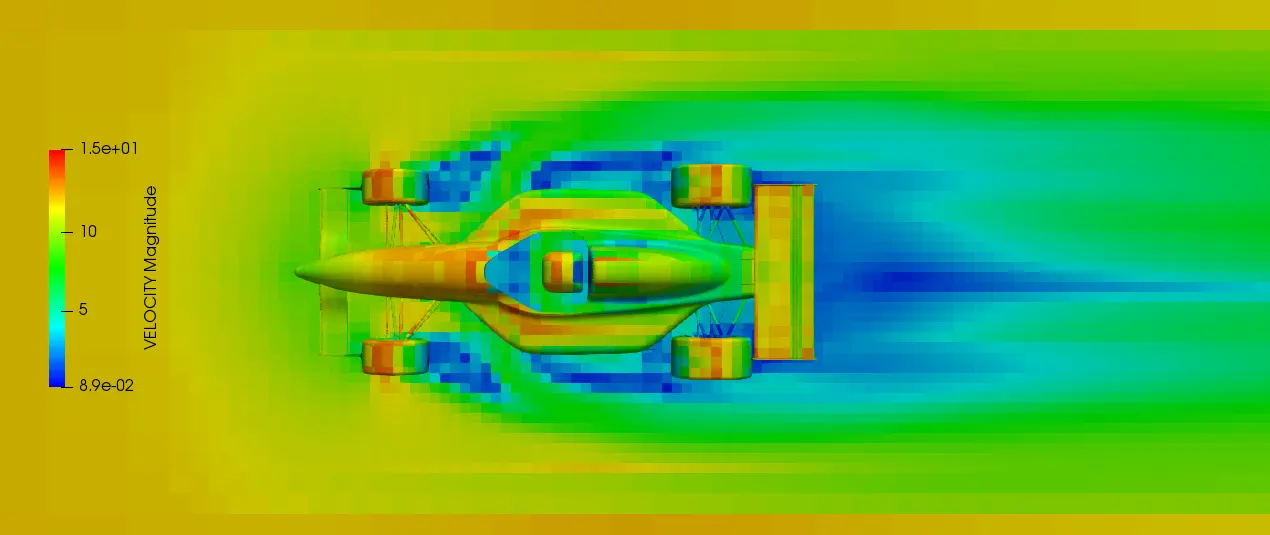
D. Velocity Contour Of The FSAE Car
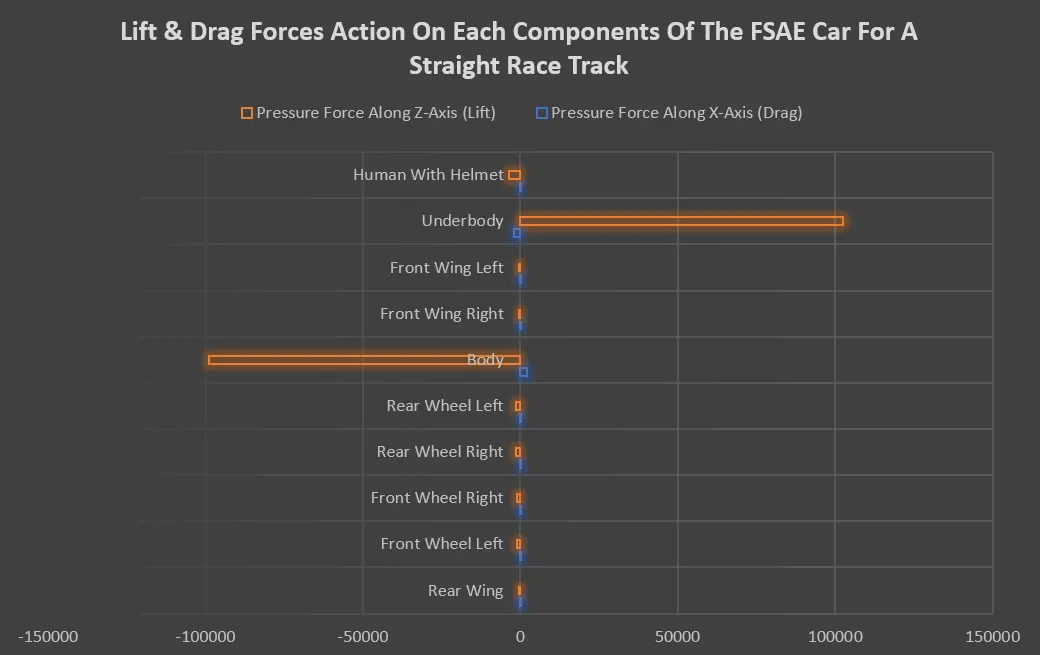
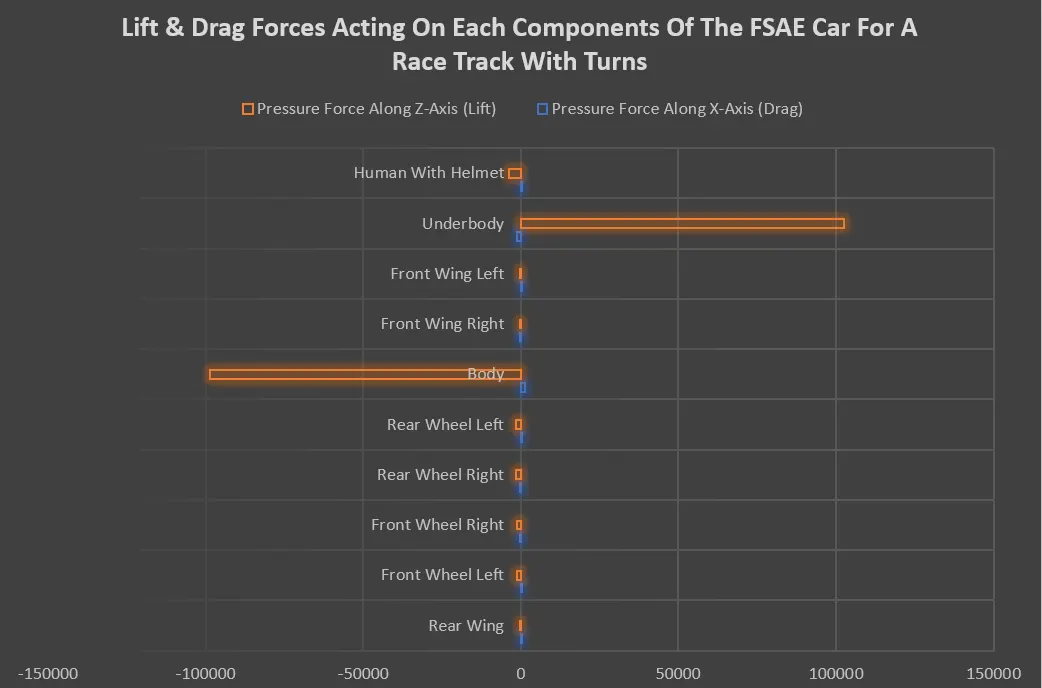
7. Comparing Simulation Results Using Charts
| Case 1 (With Turns) | Case 2 (Straight Track) | |||
| FSAE Components | Pressure Force Along X-axis (Drag) | Pressure Force Along Z-axis (Lift) | Pressure Force Along X-axis (Drag) | Pressure Force Along Z-axis (Lift) |
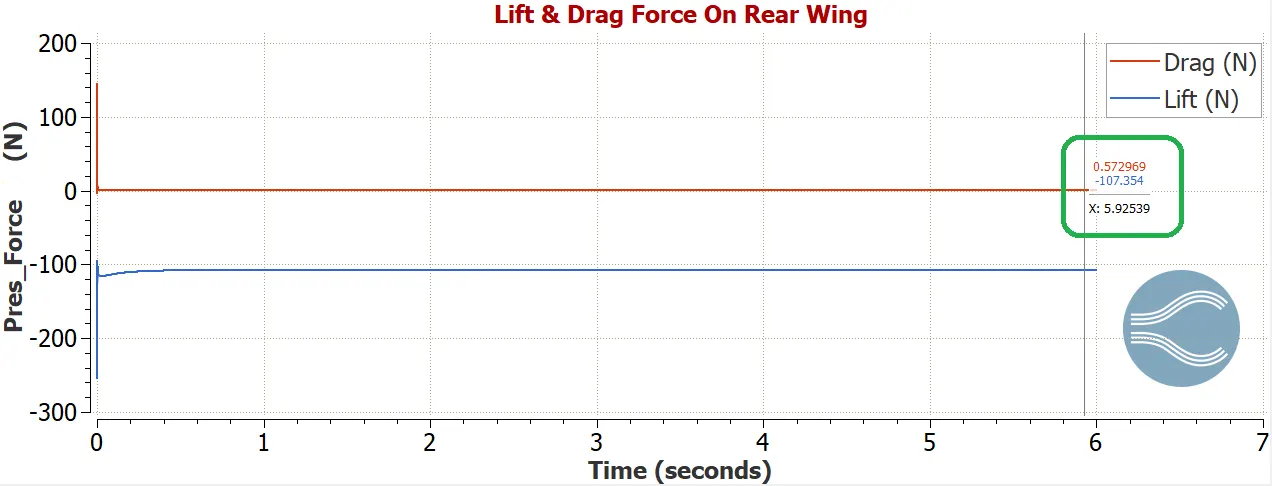
| Rear Wing | 4.338 | -90 | 0.557 | -107 |
| Front Wheel (Left) | 55.48 | -1129 | 2.883 | -1129.64 |
| Front Wheel (Right) | -32.311 | -1127.49 | 2.055 | -1128 |
| Rear Wheel (Right) | -59.342 | -1531.34 | 1.621 | -1531 |
| Rear Wheel (Left) | 92.275 | -1523.36 | 1.847 | -1531 |
| Body | 1374.58 | -98790 | 1984 | -98836 |
| Front Wing (Right) | -114.715 | -30.90 | 57.035 | -31.56 |
| Front Wing (Left) | 192 | -30.16 | 57.031 | -31.54 |
| Underbody | -1331 | 102538 | -2051 | 102618 |
| Human With Helmet | 5.574 | -3610.17 | 1.20 | -3614 |
8. Final Observations & Conclusions
This particular FSAE car produces a great downforce to drag ratio for the car body during turns, which translates to the fact that the car will have a good grip on the ground while going for turns. The car body generates the maximum amount of downforce 98836 N, which is natural. However, the front & rear wings fail to generate any significant downforce, one probable reason for that could be due to its poor design configuration. A possible change that could be made is to modify the angle of attack of the front wings or add more wings that can be introduced in such a way that it energizes the boundary layer even better. As for the drag force, the underbody of the FSAE car generates the maximum drag, which can be explained by the low pressure acting at the bottom whereas extremely high pressure acting on the top of the car, thus keeping the car planted on the road.