Study the different DC Motor Control Systems and Analysing optimum DC drive control system
AIM: -
Study the different DC Motor Control Systems and Analysing optimum DC drive control system
OBJECTIVE: -
- Overview on the Power semiconductor devices anf there conversion.
- Speed Control of DC Motor using BJT H-Bridge and its modelling and Analysing Simulation the results such that current didn't Shoot up while changing the direction of DC motor from forward to Reverse.
- Four Quadrant Chopper DC drive and its Simulation and analysing the results.
- Comparison of BJT H-Bridge and Four Quadrant DC drive control systems, to find optimum control system.
- Conversion of Optimum DC drive to Electric Vehcile model and Analysing its Simulation results.
SOFTWARE USED: - MATLAB and Simulink
POWER SEMICONDUCTOR DEVICES: -
A power electronic converter is an electronic device made of high power semiconductor switches that uses differentswitching states to change the magnitude and waveform of the voltage and current between the input and output.
Power semiconductor devices are widely used in automotive power electronic systems, and often dictate the efficiency, cost, and size of these systems. Active power semiconductor switches such as MOSFETs and IGBTs serve as load driversfor motors (ranging from 75 kW AC traction motors to 1W DC motors), solenoids, ignition coils, relays, heaters, lamps, and other automotive loads. Diodes are used in automotive systems to rectify AC current generated by the alternator, provide freewheeling current path for IGBTs or MOSFETs in DC/AC inverters and DC/DC converters, and suppress voltage transients. An average vehicle nowadays has over 50 actuators, which are often controlled by power MOSFETs or other power semiconductor devices.
Transistors-
A transistor is a semiconductor devices used to amplify or switch electronics signals and electrical power It is composed of semiconductor material usually with at least three terminals for connection to an external circuit. A voltage or current applied to one pair of the transistor's terminals controls the current through another pair of terminals.
Transistors are commonly used in digital circuits as electronic switches which can be either in an "on" or "off" state, both for high-power applications such as switched mode power switches and for low-power applications such as logic gates
The comman emitter-amplifier is designed so that a small change in voltage (Vin) changes the small current through the base of the transistor whose current amplification combined with the properties of the circuit means that small swings in Vin produce large changes in Vout.
Power MOSFET (Metal oxide semiconductor field effect transistors)-
The Power MOSFET is a type of MOSFET. The operating principle of power MOSFET is similar to the general MOSFET. The power MOSFETS are very special to handle the high level of powers. It shows the high switching speed and by comparing with the normal MOSFET, the power MOSFET will work better. The power MOSFETs is widely used in the n-channel enhancement mode, p-channel enhancement mode, and in the nature of n-channel depletion mode. Here we have explained about the N-channel power.
The power MOSFET’s are used in the power supplies
- DC to DC converters
- Low voltage motor controllers.
- These are widely used in the low voltage switches which are less than the 200V.

IGBT (Insulated Gate Bipolar Transistor)-
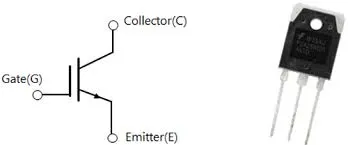
IGBT is the short form of Insulated Gate Bipolar Transistor. It is a three-terminal semiconductor switching device that can be used for fast switching with high efficiency in many types of electronic devices. These devices are mostly used in amplifiers for switching/processing complex wave patters with pulse width modulation (PWM).
The IGBT combines the simple gate-drive characteristics of power MOSFETs with the high-current and low-saturation-voltage capability of bipolar transistors. The IGBT combines an isolated-gate FET for the control input and a bipolar power transistor as a switch in a single device. The IGBT is used in medium- to high-power applications like traction motors control and induction heating. Large IGBT modules typically consist of many devices in parallel and can have very high current-handling capabilities in the order of hundreds of amperes with blocking voltages of 6500 V. These IGBTs can control loads of hundreds of kWh.
Power BJT (bipolar junction transistor)-
The power bipolar junction transistor (BJT) blocks a high voltage in the off state and high current carrying capacity in the on-state. The power handling capacity is very high. The construction of Power BJT is slightly different from the normal logic transistors as it has an extra highly doped (n-) region called as Collector drift region.
The power BJT has three terminals Collector (C), Emitter (E) and Base (B). It has a vertically oriented four-layers structure. The vertical structure uses to increase the cross-sectional area.
There are two types of BJT; n-p-n transistor and p-n-p transistor. Out of these two types, the n-p-n transistors widely use compare to the p-n-p transistor.
Applications-
- Switched Mode Power Supply (SMPS)
- Power Amplifier
- Relay and Drivers
- AC motor speed controller
- DC/AC inverter
- Power control circuit
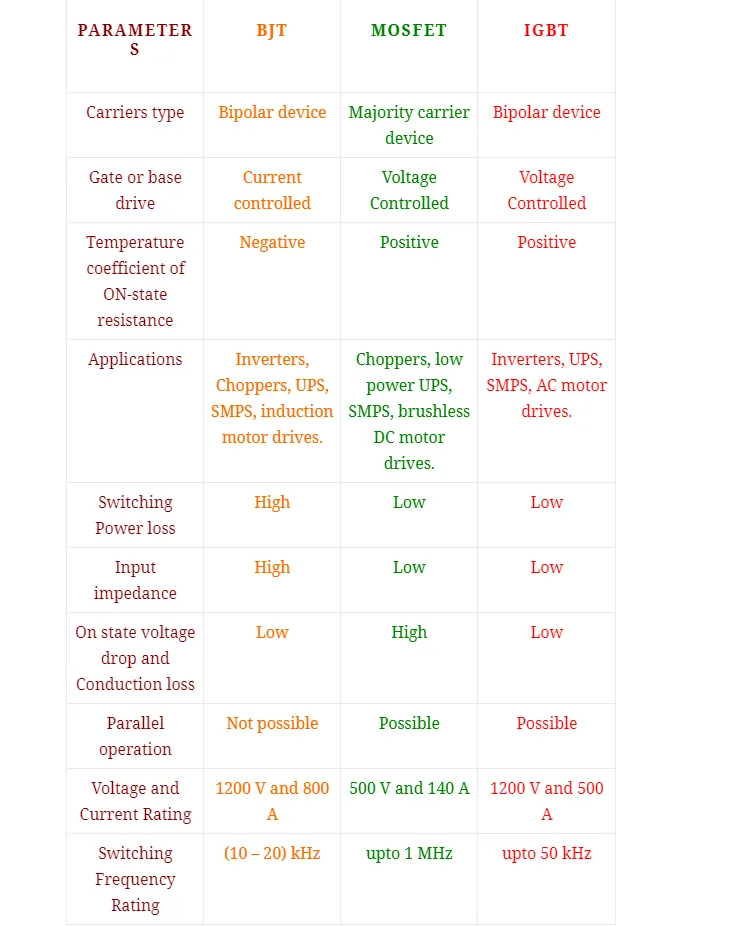
Comparison: -
SPEED CONTROL OF DC MOTOR USING BJT H-BRIDGE: -
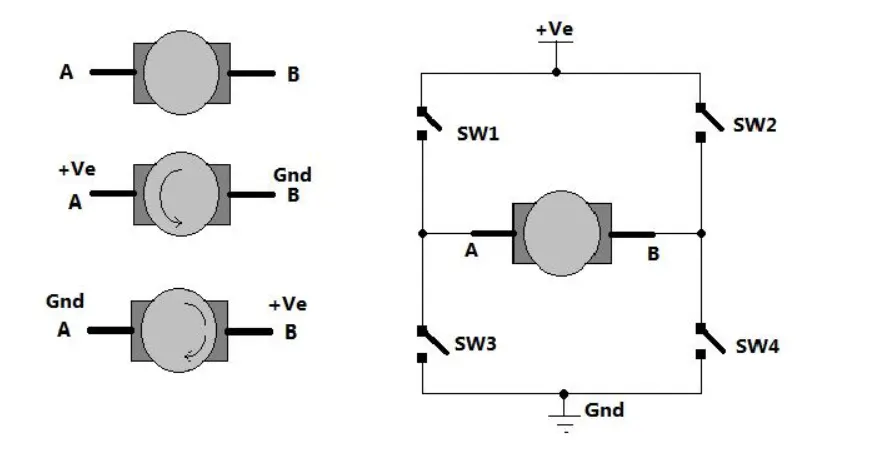
As shown in figure there are two terminals 'A' and 'B' of DC motor. Now if we connect terminal A with +ve supply and terminal B with -ve supply or ground the current will flow from motor A to B and motor will rotate in one direction- say clockwise or forward direction. Now as shown in second figure we change the supply terminals. Now B is connected with +ve terminal and a is connected to ground. The current will flow from motor from B to A and motor will rotate in other direction.
The arrangement in the right side of the figure shows that Four switches are connected in between +ve supply and ground and DC motor is connected in between two switches as shown. Such circuits is known as H-brigde becouse it look's like 'H' letter.
If SW1 and SW4 are pressed simultaneosly then current will flow from +ve -SW1-A-B-SW4-Gnd, so motor will rotate in one direction. Now, SW2 and SW3 is pressed then current will flow from +ve -SW2-A-B-SW3-Gnd, so motor will rotate in another (reverse) direction.
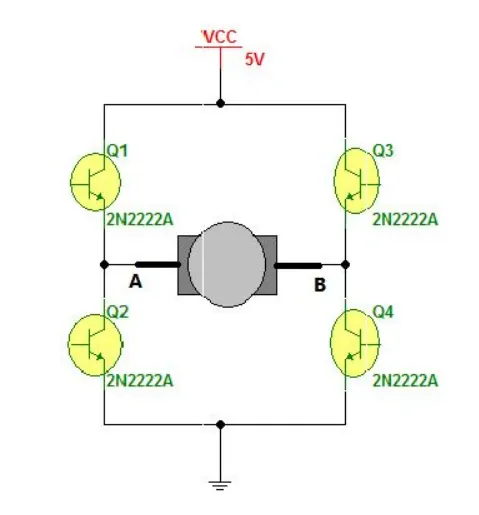
Now, in actual machine there are switches with NPN type transistors as transistors works as switch. For NPN transistor if we give +ve input to base it will turn ON and we we will give 0 input it will br turned OFF.
So in above circuit Q1 and Q4 are turned ON simulataneously the motor will rotate forward and if Q2 and Q3 are turned ON simulataneously the motor will rotate reverse.
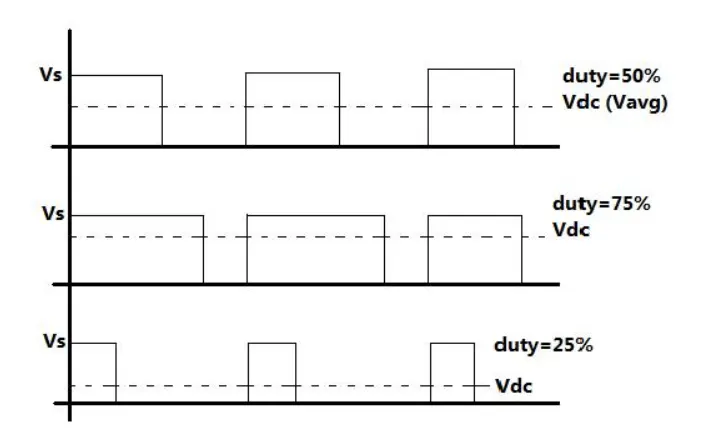
The DC motor speed varies as applied input voltage varies. As we increase applied input voltage, the speed will also increse and vice versa. Applying maximum rated voltage will rotate motor at full speed.
The varying DC voltage can be generated using Pulse width modulation (PMW).
PMW means varying the width (duty) of pulse. Width means ON time Ton of pulse. The average output voltage (Vdc or Vavg) is given by,
Vdc = [Ton/(Ton + Toff]*Vs
As we can see from above equation it is directly depends upon Ton, if duty is 50% the average output voltage Vdc is exactly half of Vs. If duty is incresed to 75%, Vdc also increases to 3/4th of Vs and if duty is decreased to 25% Vdc reduces to 1/4th of Vs. Thus as PWM varies the average output voltage varies. So we have to apply PWM to DC motor to vary its speed.
CHALLENGE- I
Speed control of DC Motor using BJT H-Bridge Model in MATLAB and Simulink such that armature current doen't shoot up when motor changes its direction from forward to reverse
MATLAB model of Speed Control of a DC Motor Using BJT H-Bridge: -
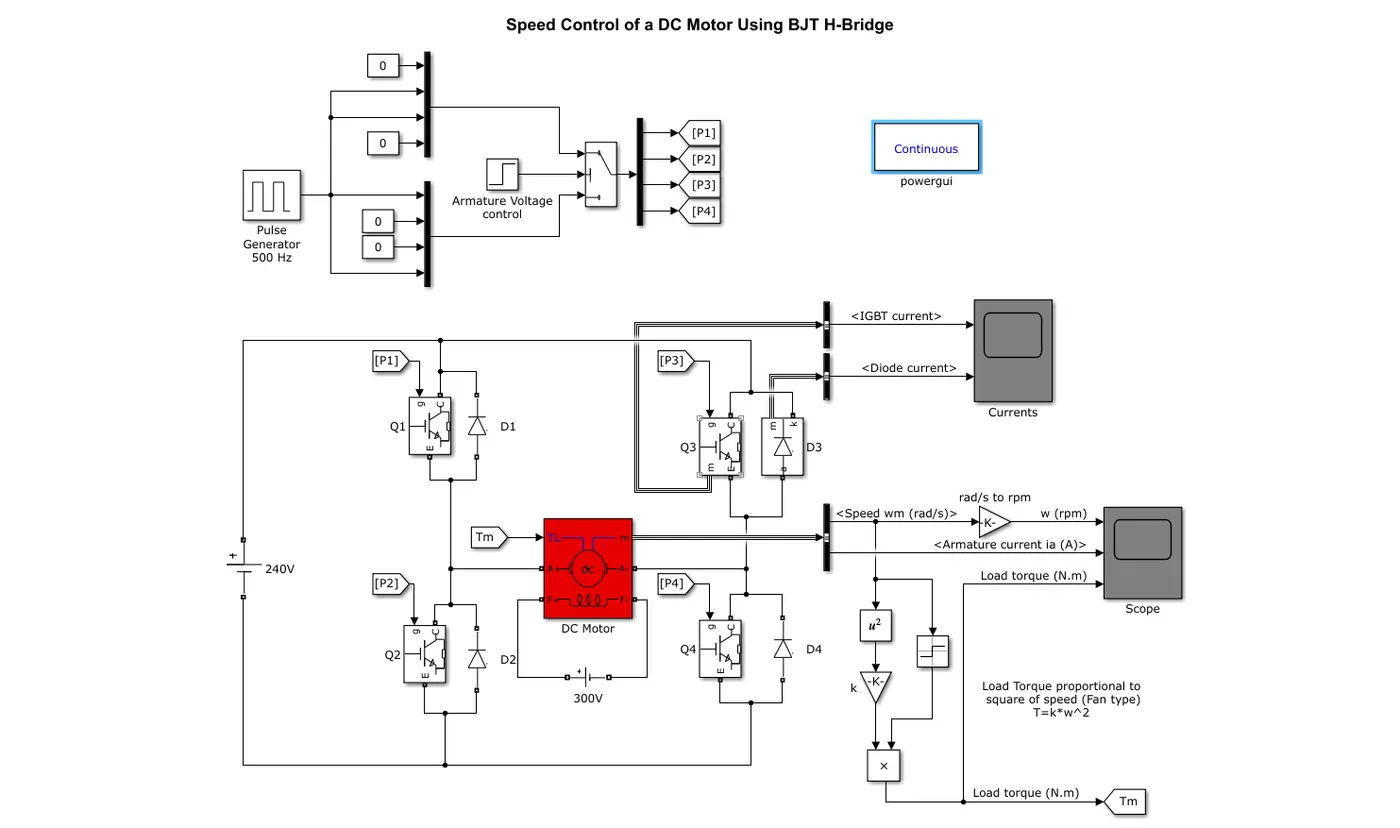
- The above Model is used to control the speed of DC motor used in electric vehicles using H-Bridge.
- The H-Bridge consist of 4 BJT and Diode pairs for the power switching applications, operates as an IGBT.
- There is pulse generator which uses 500 Hz frequency to control the armature voltage with the input in the duty ratio and it is stored as P1, P2, P3, P4 control blocks and sent as control signal to all the IGBT switches to control the DC Motor.
- Armature voltage varied from 0 to 240V when the duty cycle is varied from 0 to 100%.
- The DC Motor uses default model of 5 HP 24V 1750 rpm.
- The direction of motor are controlled with the change in the polarities of the current in the Two Transistors.
- As Q1 and Q4 are turned ON simulataneously the motor will rotate forward and if Q2 and Q3 are turned ON simulataneously the motor will rotate reverse.
SIMULATION-
CASE-I
- Total cycle time = 1 sec
- Duty cycle = 75%
- Forward motoring time = 0.5 sec
- Reverse motoring time = 0.5 sec
- Supply Voltage = 180 V
- Battery Voltage = 240 V
Results:-
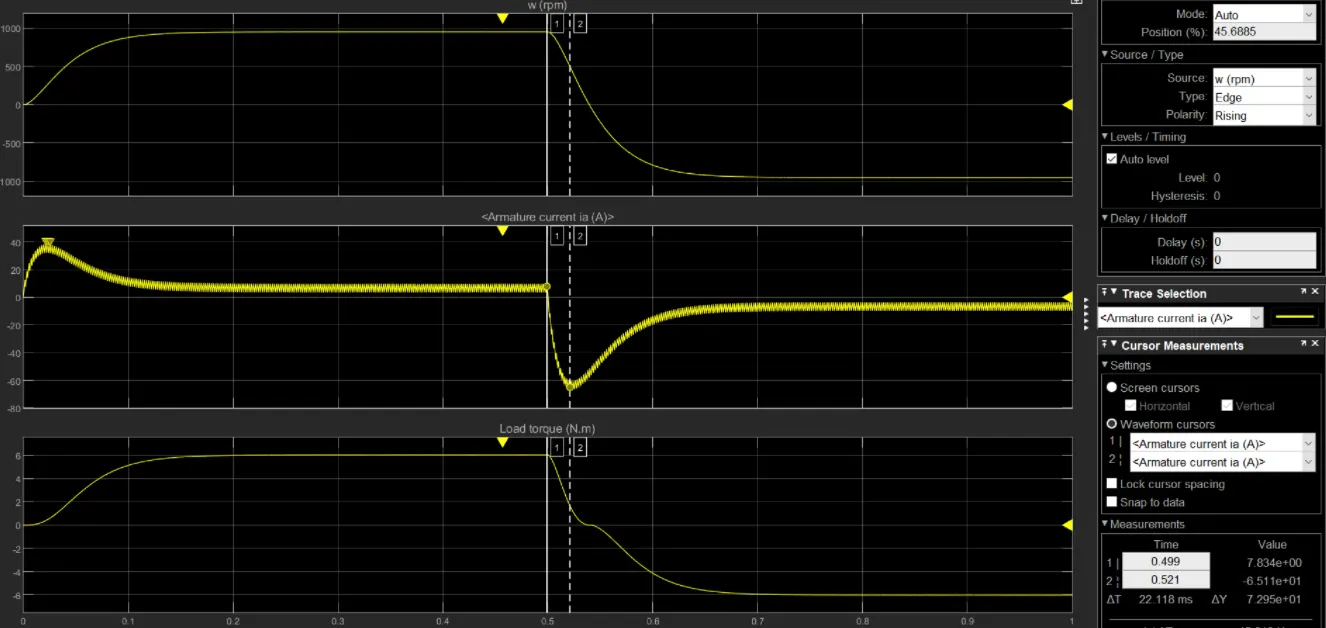
Plot 1:-
- The plot shows the angular velocity of DC motor w.r.t time cycle of the simulation.
- The maximum Forward speed of motor = 953 rpm (0-0.5 sec)
- The maximum Forward speed of motor = -953 rpm (0.5-1 sec)
Plot 2:-
- The plot shows the change in Armature Current in Ampere w.r.t time cycle of the simulation.
- The current in Forward rotation = 7.83 A (0-0.5 sec)
- The shoot up current in forward rotation = 37.5 A
- The current in Reverse rotation = -3.4 A (0.5-1 sec)
- The current dip in Reverse rotation = -65.1 A
Plot 3:-
- The plot shows the change in the Torque of the DC motor w.r.t change in the direction of rotation of motor.
- The maximum Forward Torque of motor = 6.013 Nm (0-0.5 sec)
- The maximum Forward Torque of motor = -6.011 Nm (0.5-1 sec)
From the above simulation resukt we can observe thatcurrent shoot up while the motor increasing in speed(w) and the negative current shoot up while the motor changes the direction of its motion.
When the motor start rotatation in forward motion these is a current shoot up because in DC motor starting current is High we can see this by usign motor equation that is
V = E(b) + I(a)R(a)
When we start the motor there is no back EMF to oppsoe the armature current because the conductors have not yet started rotating. Back EMF is produced when there is relative motion between conductors and magnetic field. When starting the motor, there is no relative motion so no back EMF. So E(b) = 0, I(a) = V/R(a) and there is huge shoot in current while starting.
Due to switching loss happening while changing the direction of rotation of the motor there is current dip. To control this happening the duty ratio can be altered slightly to reduce the disturbance in the current and compromiseof the motor's efficiency.
CASE-2
- Total cycle time = 1 sec
- Duty cycle = 45%
- Forward motoring time = 0.5 sec
- Reverse motoring time = 0.5 sec
- Supply Voltage = 108 V
- Battery Voltage = 240 V
Results:-
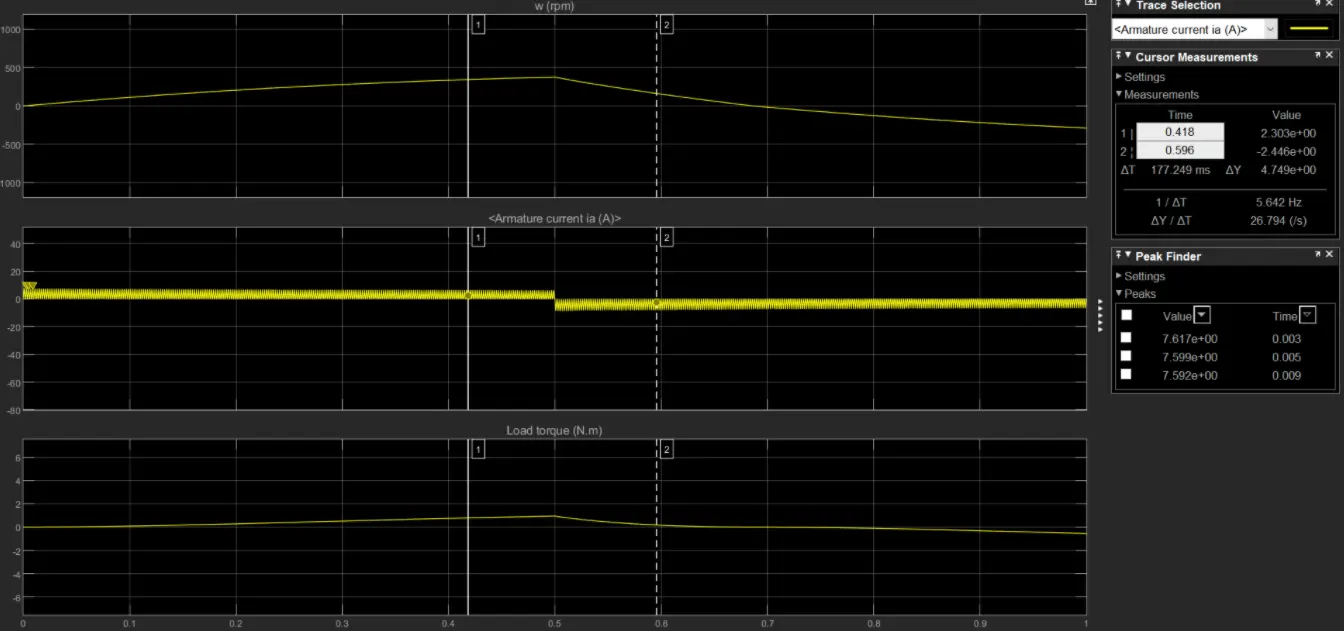
Plot 1:-
- The plot shows the angular velocity of DC motor w.r.t time cycle of the simulation.
- The maximum Forward speed of motor = 357 rpm (0-0.5 sec)
- The maximum Forward speed of motor = -287 rpm (0.5-1 sec)
Plot 2:-
- The plot shows the change in Armature Current in Ampere w.r.t time cycle of the simulation.
- The current in Forward rotation = 4.99 A (0-0.5 sec)
- The shoot up current in forward rotation = 7.32 A
- The current in Reverse rotation = -5.66 A (0.5-1 sec)
- The current dip in Reverse rotation = -8.69 A
Plot 3:-
- The plot shows the change in the Torque of the DC motor w.r.t change in the direction of rotation of motor.
- The maximum Forward Torque of motor = 0.94 Nm (0-0.5 sec)
- The maximum Forward Torque of motor = -0.54 Nm (0.5-1 sec)
From the above result we can observe that when duty ratio is get decreased to 45% there is fading of current dip starts from -65 A to -8.6 A. So there is slightly decriment in the motor's efficiency but motor is continously producing considerable Speed and Torque.
FOUR QUADRANTS OF A DC MOTOR: -
Four Quadrant operation of any drives or DC motor means that the machine operates in four quadrants, they are Forward braking, Forward motoring, Reverse motoring and Reverse braking. a motor operates in two modes- Monitoring and braking. A motor drive capable of operating in both directions of rotation and producing both monitoring and regeneration is called Four Quadrant variable speed drive.
In motoring mode, the machine works as a motor and converts electrical energy into mechanical energy, supporting its motion. In braking mode, the machine works as a generator, and converts mechanical energy into electrical energy and as a result, it opposes the motion. The Motor can work in both, Forward and Reverse Directions i.e.in motoring and braking operations.
The product of angular Speed and Torque is equal to power developed by a motor. For multi-quadrant operation of drives the following conventions about the signs of torque and speedare used. When the motor is rotated in the forward direction the speed of motor is considered positive. The drives whcih operates only in one direction, forward speed will be their normal speed.
In loads involving up and down motions, Speed of the motor which causes upward motion is considered to be in forward motion. For reversible drives, forward speed is chosen arbirately. The rotation in the opposite direction gives reverse speed which is denoted by negative sign.
The rate of change of speed positively in the forward direction or the Torque which provides acceleration is known as Positive motor Torque. In the case of retardation, the motor Torque is considered negative. Load torque is opposite to the positive motor torque in the direction.
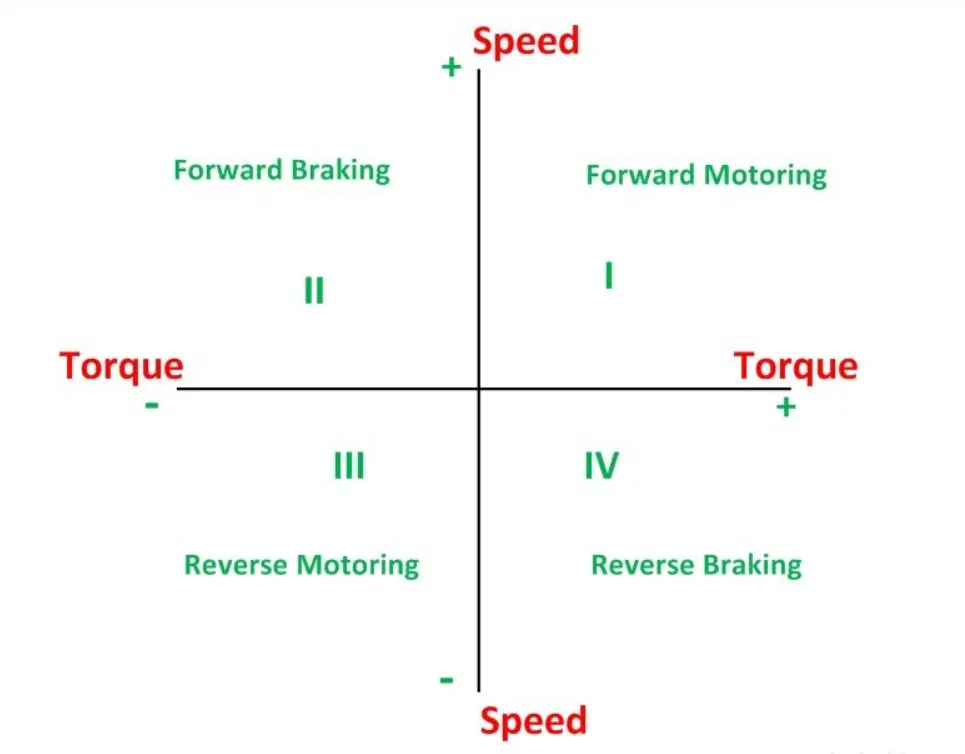
In I Quadrant power is developed is +ve and the machine is working as a motor supplying mechanical energy. The I Quadrant operation is called Forward motoring.
The II Quadrant operation is known as Forward Braking. In this quadrant the direction of rotation is +ve, and the Torque is -Ve and thus, the machine operates as generator developing a -ve torque, which opposes the motion.
The kinetic energy of the rotating parts is avialable as electrical energy whcih may be supplied back to the mains. In the dynamic braking dissapated the energy is dissapagnthted in the resistance. the III Quadrant operations is Known as Reverse Motoring. the motor works, in the reverse direction. Both the speed and the torque have -ve values while power is +ve.
In the IV Quadrant, the Torque is +ve, and the speed is -ve. This Quadrant corresponds to braking in the Reverse braking mode.
MATLAB model of Four Quadrant Chopper DC drive : -
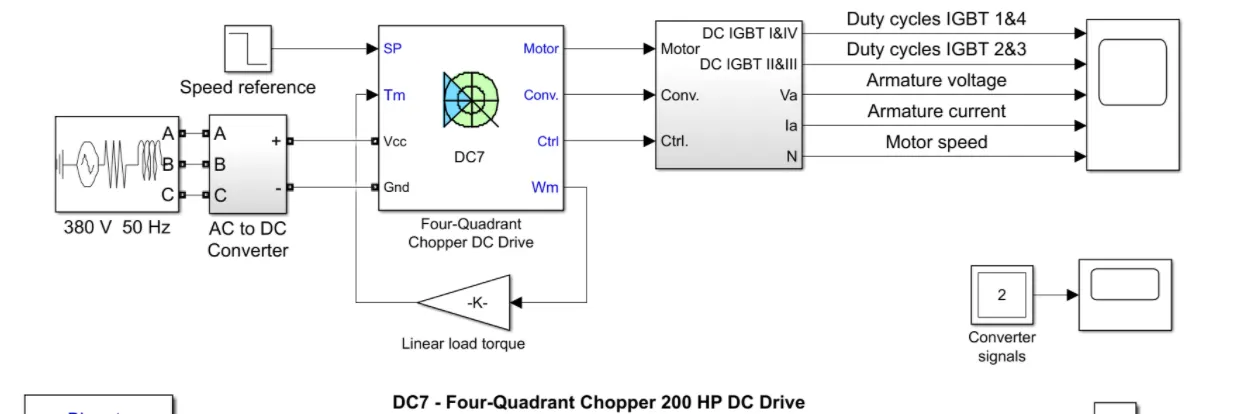
- The model consist of Four Quadrant 200 HP DC Motor which is excited with a constant 150 V DC voltage source.
- The armature voltage is provided by an IGBT convertercontrolled by two PI controller. In order to limit thr DC bus voltage during dynamic braking, a braking chopper has been added between the diode rectifier and DC7 block.
- In order to limit the amplitude of the current oscillations, an smoothing inductor is placed in series with the armature circuit.
SIMULATION-
- Total cycle time = 7 sec
- Initial bus Voltage = 515 V
- Frequency = 50 Hz
Results-
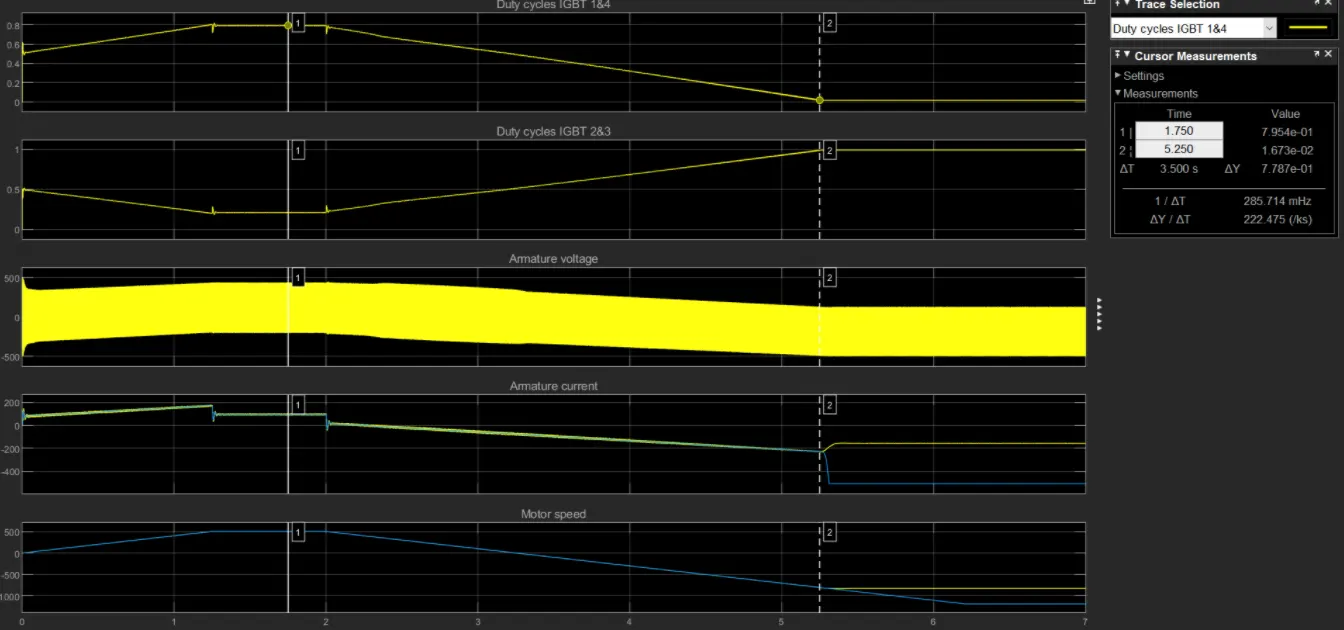
- The above result shows about the different plots that are armature voltage, armature current, motor Speed and IGBT pulse plots.
- The motor is couples with the linear load i.e. mechanical torque of the load is proportional to the Motor Speed.
- The Armature current follows the current reference very well and we find that the current ripple is 5 kHz.
- Now, at t = 2 sec, speed referance drops to -1180 rpm.
- At t = 2.1 sec, current reveses its polarity to produce braking electromagnetic torque.
- At t = 3,25 sec, the motor speed reaches 0 rpm and the load torque reverses and becomes -ve. T
- At t = 6.25 sec, the speed reaches -1184 rpm and stabilize the reference.
Comparison between H-Bridge and Four Quadrant DC Chopper:-
- In H-bridge we need to reverse the polarity to change the direction of motor while in Four Quadrant DC drive it uses speed reference to change the direction of its motion.
- PI controller is used for controlling the speed in Four Quadrant DC drive while H-bridge does not use it.
- Stabilty of current in Four quadrant DC drive is high as compare to H-bridge it has current shoot up due to switching losses.
- H-bride uses Forward and Reverse operations only and it do not operated for Regenerative breaking.
- While Four Quadrant DC drive operates in Four modes i.e. Forward motoring, Reverse motoring, Forward braking and Reverse braking. also it perform regenerative braking.
- Four Quadrant DC drive control is better than H-Bridge DC control.
ELECTRIC VEHICLE MODELLING USING DC7: -
- Now, as the Four Quadrant DC drive as compared above, so we will use it for the Modelling of an Electric vehicle.
- So,the above Four quadrant DC drive model is to be modified and analysed as the Elecric vehicle model and observe the results.
Modifications in the Model :-
Drive Cycle-
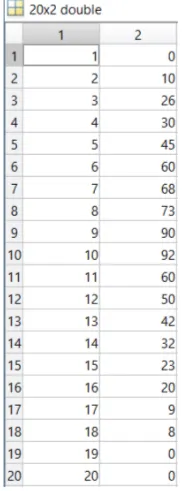
- Now to operate the Motor for desired speed we should Input an referance speed to which the motor operates.
- For this we will add an Drive cycle block which will be inputed by the workspace variable as shown below as an excel file.
Load Torque-
- Now for modelling the Electric vehicle we need a load characterisctics of a car consisting of all external forces acting on the vehicle to make DC motor model act as a EV model.
- This includes all types of external forces like Rolling resistance, Aerodynamics forces and air drag forces.
- The EV load torque equation is given by-
T = 24.7 + 0.0051*(w)^2
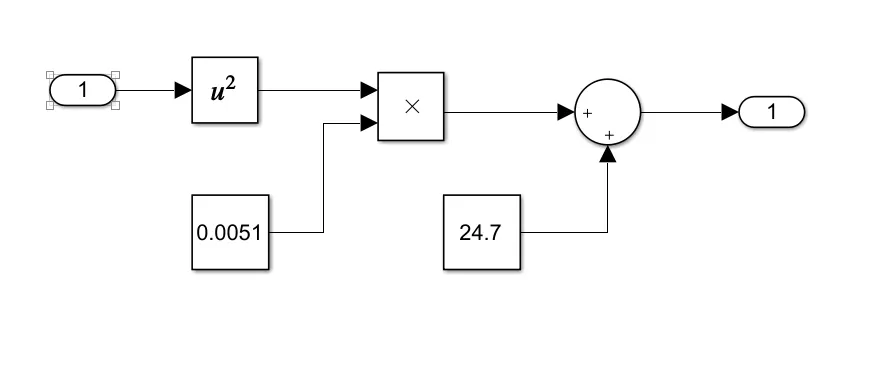
Subsystem of EV Load Characteristics
Power Source-
- Now for the AC Power source is replaced by a DC voltage source with similar voltage level as same as real EV battery voltage.
- Now from Simulink library the physical DC Voltage source is selected and we will assign a voltage level of 300 V and Power source is connected to the Vcc of DC motor.
- And an physical current measurement block is connected to the voltage source to measeure the current output from the power source to the motor.
Electric Vehicle Model-
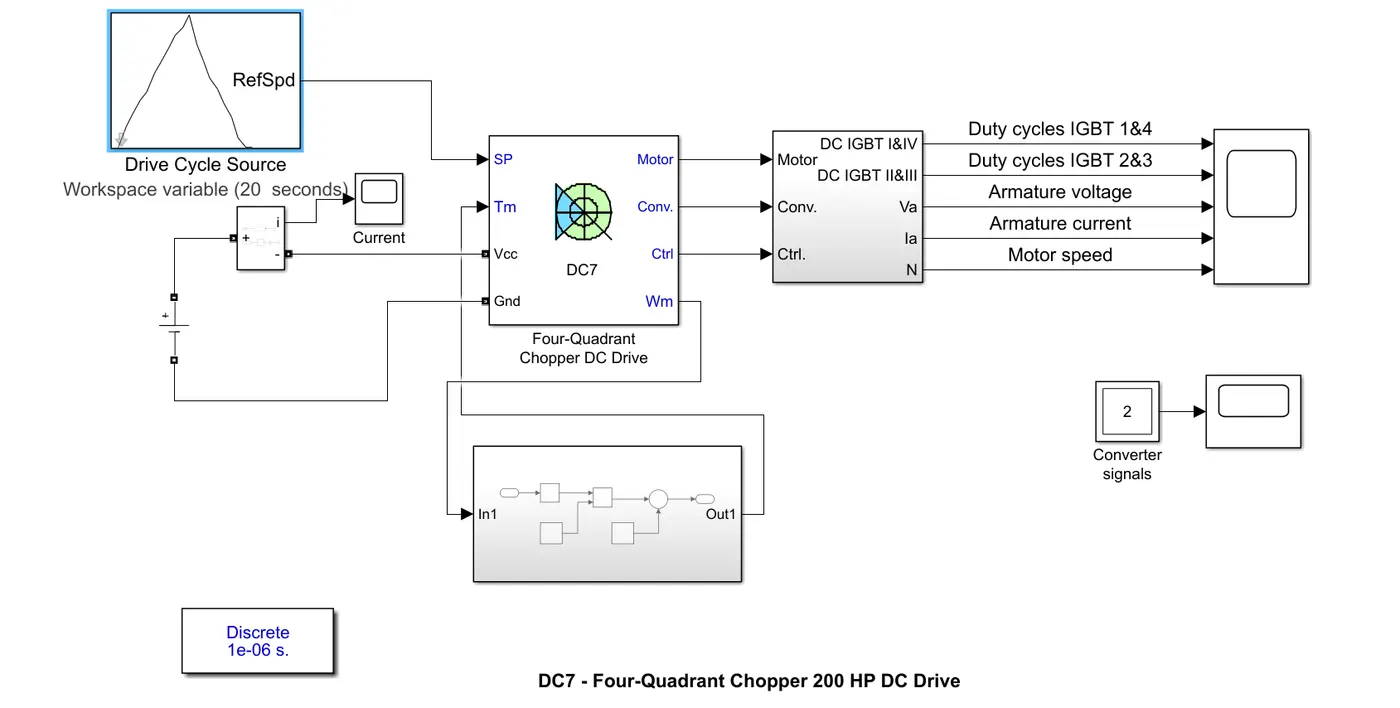
Now, we RUN the Simulation for 20 seconds.
SIMULATION-
- Total cycle time = 20 sec
- DC Voltage Source = 300 V
- Discrete Time = 1e - 06 sec
Results-
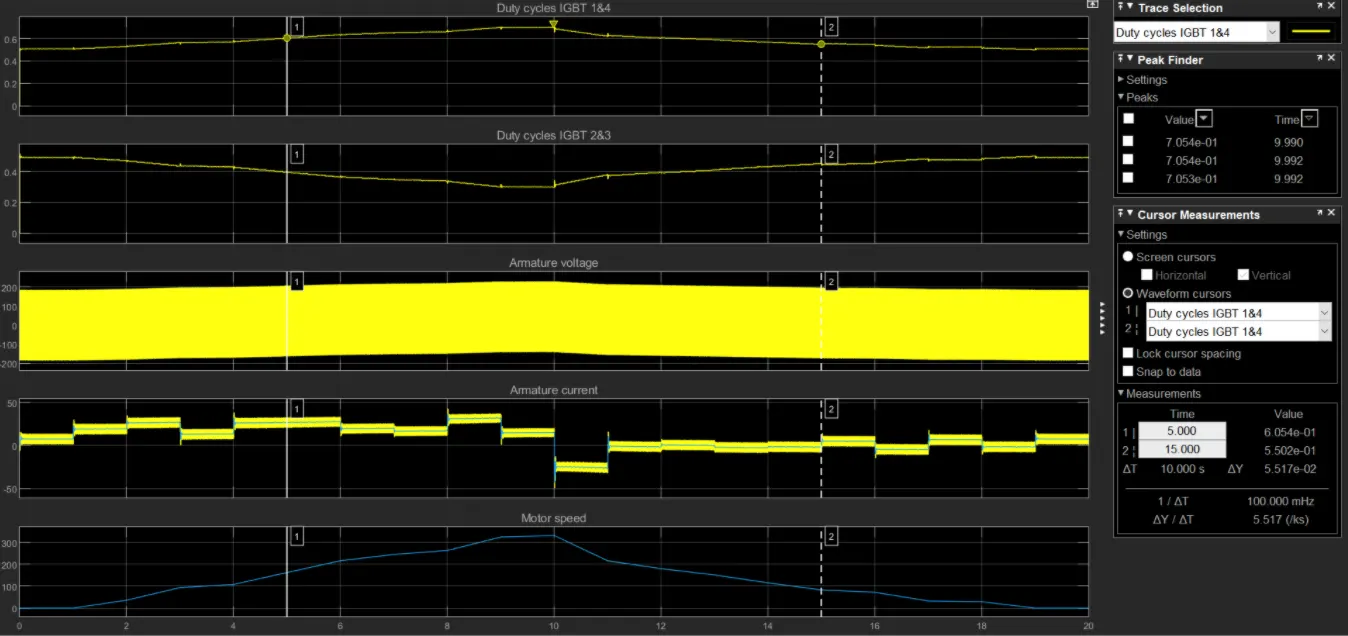
- The above result shows about the different plots that are armature voltage, armature current, motor Speed and IGBT pulse plots.
- Armature current follows the current reference very well and the current ripple frequency is 5 kHz and controller works very well.
- Motor Speed also following the reference speed very well.
- At t = 10 sec, current reverses in order to produce a braking electromagnetic torque. This causes DC bus voltageto increase.
- At t = 10 sec, there is highest value of Armature voltage and then decrement in the voltage.
SiC power devices have following benefits over silicon power devices:-
- The higher breakdown electric field strength of SiC allows a much thinner drift region and thus a much smaller specific on-resistance of SiC devices than their silicon counterparts.
- The low on-resistance of SiC devices for a voltage rating of 600–2000V allows the use of majority-carrier devices like MOSFET and Schottky diodes ratherthan minority-carrier devices such as IGBT and PiN diodes. This results in a much reduced switching losses and absence of charge storage effect. Lower switching losses will further allow higher switching frequency and subsequently smaller and less expensive passive components such as filter inductors and capacitors.
- The larger bandgap results in higher intrinsic carrier concentration and higher operating junction temperature. In principle, SiC devices could operate at a junction temperature as high as 300 C, as compared to 150 C maximum junction temperature of silicon devices. The increased operating temperature will reduce the weight, volume, cost, and complexity of thermal management systems.
- The very high thermal conductivity of SiC reduces the thermal resistance of the device die.
- The higher bandgap also results in much higher Schottky metalsemiconductor barrier height as compared to Si. This leads to extremely low leakage currents even at elevated junction temperatures due to reduced thermionic electron emission over the barrier.The magnetic field from the stator will induce a voltage and current in the windings of the rotor. That’s why it’s called the induction motor. This in turn leads to the rotor producing its own magnetic field, and this magnetic field will make the rotor turn so as to align itself with the magnetic field from the stator. The rotor will follow this rotating magnetic field in the stator, without the need for a commutator with brushes.
References:-
https://www.mathworks.com/help/physmod/sps/powersys/ref/fourquadrantchopperdcdrive.html
https://www.mathworks.com/help/physmod/sps/ug/dc7-four-quadrant-chopper-200-hp-dc-drive.html
https://www.switchcraft.org/learning/2016/12/9/si-vs-sic-devices