Go-kart Design and Fabrication
TEAM ROYALZ, MADRAS INSTITUTE OF TECHNOLOGY
FINAL REPORT
Abstract:
This work concentrates on explaining the design and engineering aspects of making a Go Kart as mentioned in the rulebook. This report explains objectives, assumptions and calculations made in designing a Go Kart. The team's primary objective is to design a quality kart applying our engineering skills. The design of the kart was built around the driver ensuring his comfort. To achieve this goal, the team has been divided into core groups responsible for the design and fabrication of the major sub systems which were later integrated into the final blue print.
Introduction:
The Go kart was built by TEAM ROYALZ – the students of MADRAS INSTITUTE OF TECHNOLOGY. We set up some parameters of our work and the team has been divided into core groups namely Design, Engine and Transmission, Steering Brakes and wheels, Business and Management. The model was modified and retested and a final design was fixed. We approached our design by considering all the possible alternatives for the system and modeling them in CATIA and SOLIDWORKS and analysing them in ANSYS.
TECHNICAL SPECIFICATIONS
Dimensions:-
|
Length |
1620mm |
|
Height |
600 mm |
|
Wheel base |
1054mm |
|
Track width– front |
945mm |
|
Track width – rear |
1054mm |
|
Total mass |
95 kg |
|
Ground clearance |
1.2” |
Materials:-
|
Material used |
Purpose |
|
AISI 1018 |
Chassis |
|
AluminiumA3105 |
Base plate |
|
Aluminium sheet |
Firewall of the vehicle |
|
Fibre reinforced polyester |
Side and front panels |
|
Rear Axle Material |
EN – 13 Steel |
Performance:-
|
Maximum speed |
62kmph |
|
Maximum acceleration |
3.87 m/s2 |
|
Turning radius |
2.3 m |
|
Braking distance at 45 kmph |
6 m |
3D Views of Kart
Fig 1. Isometric view
Fig 2. Isometric view 2
Fig 3. Front view
Fig 4. Rear View
Fig 5. Right Side View
Fig 6. Left Side View
ENGINE:
The engine used is Honda shine, 125 cc
|
Engine technology |
Air cooled, 4 stroke, SI engine |
|
Length*width*Height (approx.) |
300 mm* 200mm*250 mm |
|
Bore x stroke |
52.4 x 57.838 mm |
|
Displacement (cc) |
124.7 |
|
Net power output |
7.88 KW @ 7500 rpm |
|
Net torque |
10.30 Nm @ 5500 rpm |
|
Overall Reduction Ratios |
1st gear: 33.528 2nd gear: 19.624 3rd gear: 13.246 4th gear: 10.185 |
|
Fuel tank capacity |
3.5 liters |
|
Dry weight |
12.2 Kg |
|
Oil capacity |
0.5 L |
Design Methodology
ERGONOMICS CONSIDERATION:
The driver was made to sit in his comfortable position and the position of each component was fixed in the coordinates around him. The seat and steering design was selected to provide comfort to the driver. The pedal position and the gear shifter were positioned in the best suited points. Heat from the engine was prevented from the driver by designing a proper fire-wall. Ergonomics was also considered for safe and fast assembling and dismantling of the gokart.
FLOOR PLANNING:
The basic chassis design was done in the floor using insulation tape for an overview which was further developed as a pipe model. The drive was made to sit and the engine was placed in the respective positions. Necessary changes in the layout were made and the final design was validated.
Images of frame and prototype:
CHASSIS MATERIAL:
The material AISI1018 is used in the frame design because of its good weld ability
1. Relatively soft and, strengthens as well as good manufacturability. Analysis was conducted by use of finite element analysis on ANSYS software
Material used: AISI 1018
Ultimate strength: 440 MPa
Yield strength :370 MPa
Chemical composition:
|
ELEMENT |
% COMPOSITION |
|
Carbon |
0.14 - 0.20% |
|
Phosphorous and Sulphur |
< 0.050% |
|
Manganese |
0.6 - 0.9% |
DESIGN:
The design was done to satisfy three conditions
- Driver comfort
- Good performance
- Compactness
Hence a snug driver region, greater torque multiplication and least possible wheelbase was designed.
Finite Element Analysis:
The vehicle design is tested for accuracy and stability under the situation of extreme impacts and loads acting in case of any crash during the operation or racing. The Finite Element Analysis (FEA) is done using ANSYS Simulation Software. FEA was done taking the impact forces in three different directions. They are
1.Frontal impact
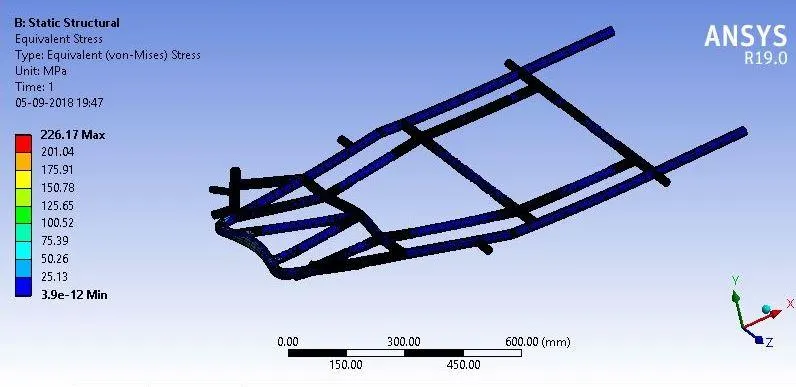
Fig 7. Frontal Impact – Stress
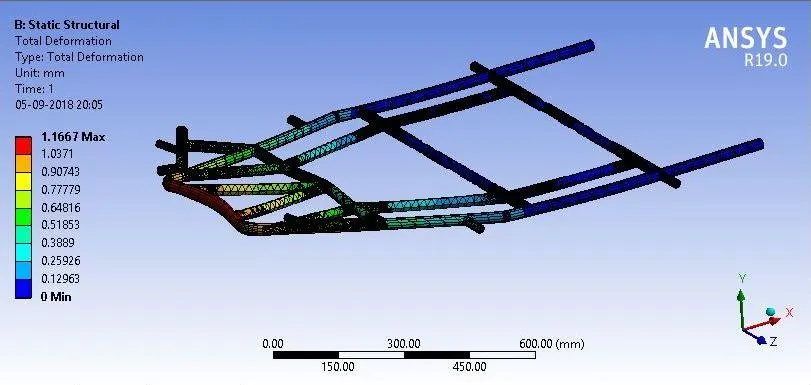
Fig 8. Frontal Impact - Deformation
2. Rear impact
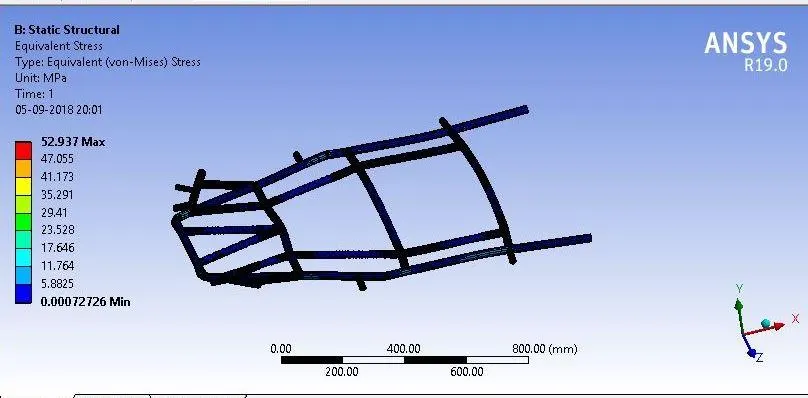
Fig 9. Rear Impact – Stress
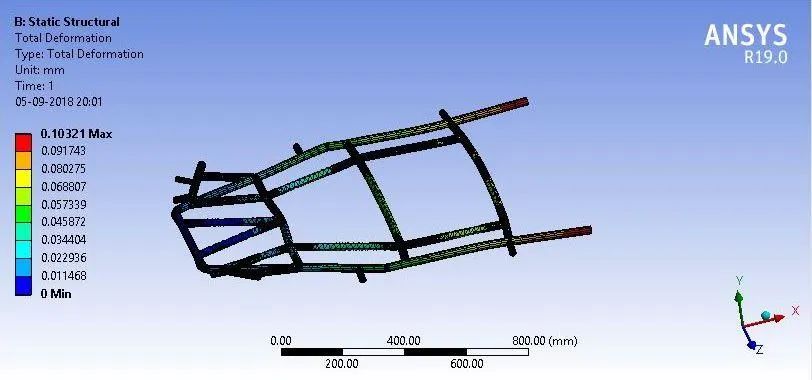
Fig 10. Rear Impact - Deformation
3.Side impact
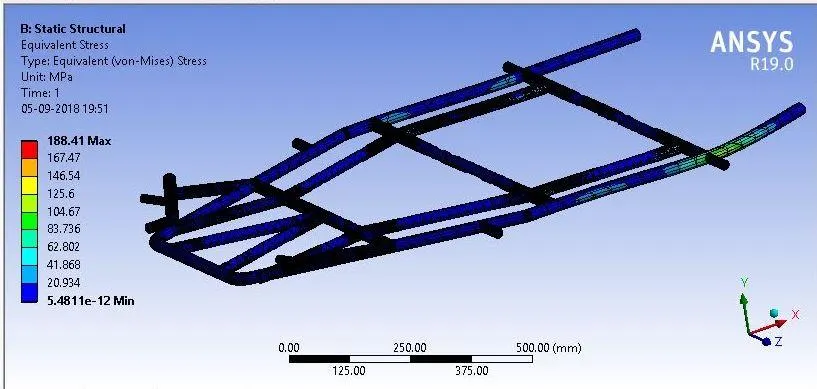
Fig 11. Side Impact – Stress
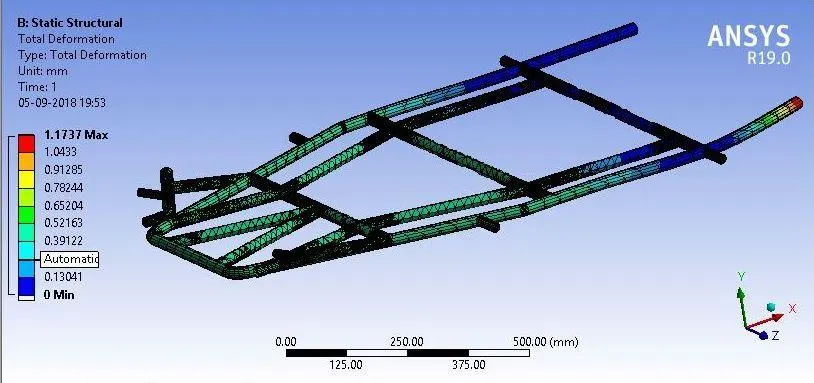
Fig 12. Side Impact - Deformation
IMPACT LOAD CALCULATIONS
FOR FRONTAL AND REAR IMPACTS:
Weight of the kart 175kg
Initial velocity= 12.5m/s
impact time= .1s
work done = change in kinetic energies
= .5*175*12.5*12.5
work done = 13671.875
s = impact time*vmax
= .1*12.5
= 1.25
force= W/s
= 10,937.5 N
Braking
|
Brake Type |
Single disc brake |
|
Recommended fluid |
Dot 3 |
|
Brake Disc |
Diameter-195mm |
|
Brake pad thickness |
4.5mm |
|
Master cylinder diameter |
19.05mm |
|
Caliper inside cylinder |
32mm |
As per norms the decceleration must be twice the acceleration.
We have a maximum acceleration of 3.87m/s2
required deccleration = 7.74m/s2
Under braking dynamic condition
MT=h.m.a/(l.g)
h=.02m
l=1.04m
m=200kg
Mt= 3.1kg
Wr=1145.62
Treq=160Nm
Treq=Wr x R
Assuming that we are applying a torque of 170Nm on the rotor
Frictional force on rotor = Tdisc/ Rdisc
Rdisc=100mm F_friction_rotor=1700N
Frotor= F_friction_rotor /µ
Mu=0.5 and Frotor =3400N
Force on Calliper =fdisc/2 Fcalliper=1700N
Brakeline pressure=Fcalliper/area
C =1700/.03175
=53.543E3 N/m2
Required Fmc= P.Amc
=53.543E3*.01905
=1020N
Force applicable by driver=400N
Pedal ratio req. to obtain Fmc is
PR=Fmc/Fdriver
= 2.55
We take PR as 3
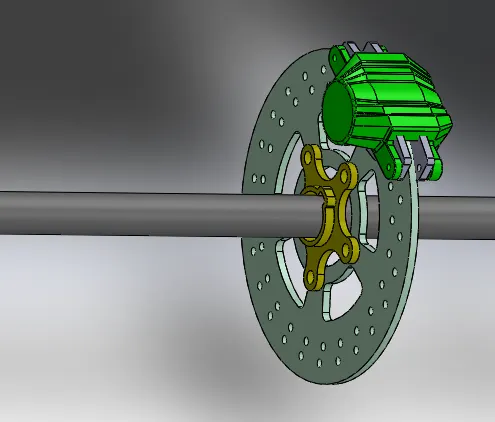
Fig 13. Disc Brake Assembly
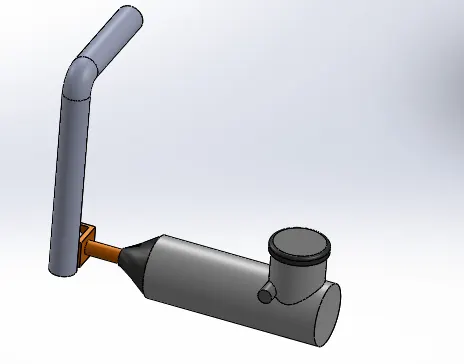
Fig14. Master Cylinder and Brake Pedal
POWER TRAIN AND TRANSMISSION SYSTEM:
Engine: Honda Shine 125 cc
Transmission:
Primary reduction = 3.35
Final reduction = 1.86
Secondary reduction:
|
First gear |
3.587: 1 |
|
Second gear |
2.100: 1 |
|
Third gear |
1.417: 1 |
|
Fourth gear |
1.090: 1 |
Chain: #40 or 08B chain (pitch, p = 12.7 mm)
CHAIN − SPROCKET SPECIFICATIONS:
Sprocket 1 :
No. of teeth (T1) = 14
Sprocket 2 :
No. of teeth (T2) = 26
Gear Ratio (r) = T2 / T1 =26/13=1.86
Centre to centre distance = 6.65 inches
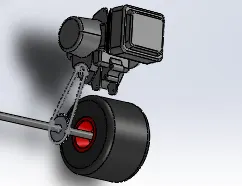
Transmission system
Engine
Calculation of No. of teeth in Final Drive Sprocket
total powertrain ratio iA.
ratio iS of the moving-off element,
ratio iG ofthe transmission
final ratio iE,
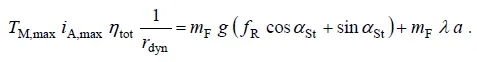
iAmax = .13315*175*9.8*(.01cos10 +sin10) + 175*3.87*1.5
vehicle is designed for an acceleration of 3.87m/s^2
iAmax = 21.77
iA = iS iG iE
12.016iE= 25.596
iE= 1.8
Best near match was Sprocket with 26 teeth resulting in iE of 1.86.
CALCULATION OF MAXIMUM SPEED AND ACCELERATION :
Maximum rpm at rear axle = maximum rpm at intermediate shaft / Sprocket reduction ratio
= 8500/(3.35*1.09*1.86)
Maximum rpm at rear axle = 1251.51
Maximum speed of the kart = Maximum rpm at rear axle * rear wheel radius * (2π/60)
= 1251.51 * 0.13335 * (2π/60)
= 17.47 m/s
Maximum speed of the kart = 63 km/h
Transmission:
Engine sprocket speed (N1) =
|
First gear |
458.47 RPM |
|
Second gear |
781.805 RPM |
|
Third gear |
1158.64 RPM |
|
Fourth gear |
1506.23 RPM |
Axle sprocket speed (N2)
|
First gear |
164.327 RPM |
|
Second gear |
280.217 RPM |
|
Third gear |
415.283 RPM |
|
Fourth gear |
539.867 RPM |
Max angular speed of the rear wheel (N):
|
Gear |
Reduction ratio |
Speed of the Rear wheel (RPM) |
|
First gear |
33.528 |
223.693 |
|
Second gear |
19.624 |
382.185 |
|
Third gear |
13.246 |
566.209 |
|
Fourth gear |
10.185 |
736.377 |
Performance Prediction:
Max Speed of the kart:
|
First gear |
3.28 m/s |
|
Second gear |
7.603 m/s |
|
Third gear |
12.45 m/s |
|
Fourth gear |
17.47 m/s |
Max Acceleration:
|
First gear |
3.87 m/s2 |
|
Second gear |
3.19m/s2 |
|
Third gear |
2.6m/s2 |
|
Fourth gear |
2.2m/s2 |
CHAIN SPROCKET CALCULATION :
For satisfactory performance of chain-sprocket drive, smaller pulley should be at least covered by 120 deg by the chain. So we can calculate approximate centre distance as
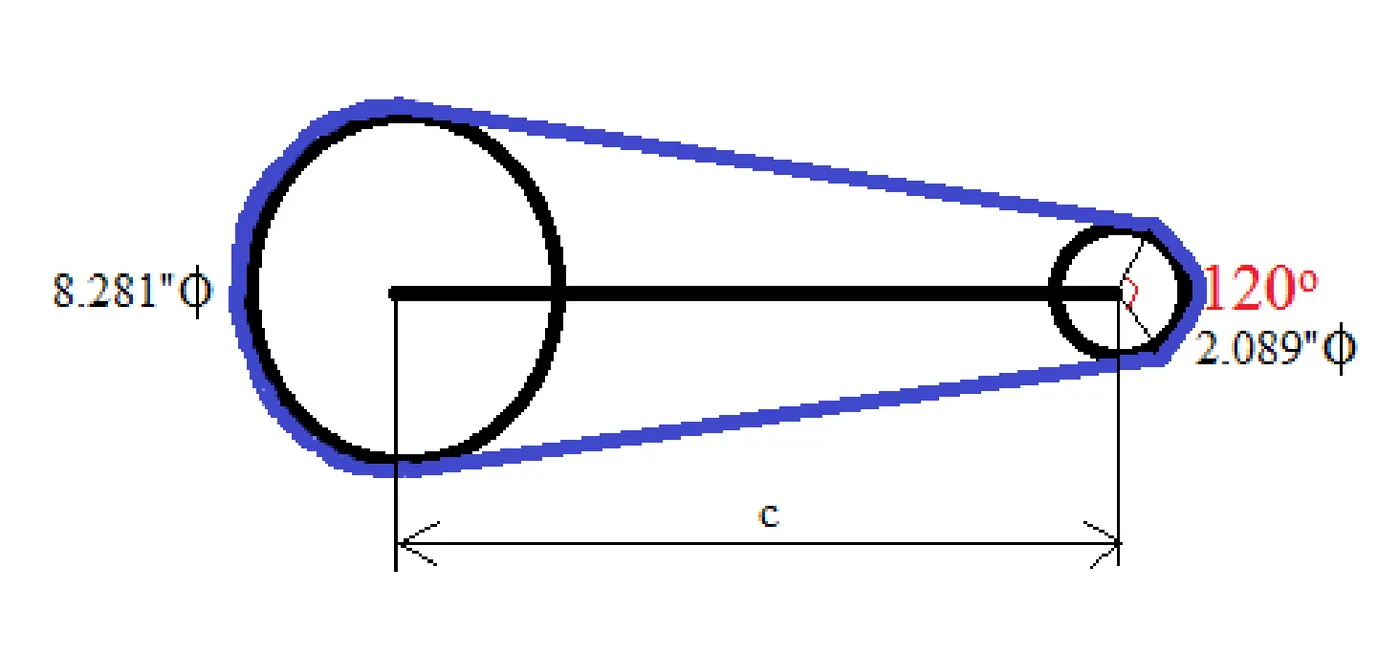
C = (d2-d1) / (2*cos600) = 6.238’’
Length of chain(L) = π(R+r) + {(R-r)^(2)}/C + 2*C
=3.14(4.283) +{(4.283-1.164)^(2)}/6.238 + 2*6.238
=31.14
No. of links = 31.14/0.5
= 62.28
Since we should use only even no. of links , so no. of links = 64
Final length of chain = 64*0.5
= 32”
Final center distance, C ={L - π(R+r) – (π-2φ)*(R-r)} / 2*sinφ
={ 32 – 3.14*(4.283 + 1.164 ) – (3.14 – 2.0944)*(4.283 – 1.164 ) } / (√ 3)
= 6.72
STEERING SYSTEM
|
NOTATIONS |
VALUES |
|
STEERING GEOMETRY |
Ackermann |
|
WHEEL BASE |
1054mm |
|
FRONT TRACK WIDTH |
945 |
|
REAR TRACK WIDTH |
1054mm |
|
TURN RADIUS |
2440.155mm |
|
CASTER |
3 degrees |
|
TOE IN |
2 degrees |
|
KING PIN INCLINATION |
8degrees |
|
TIE ROD |
Equal length of 340mm |
|
STEERING RATIO |
1:1 |
|
STEERING ARM LENGTH |
460mm |
|
STEERING ARM ANGLE |
74.22 degree |
Wheels: (in inches)
Front = 4.5 x 10 – 5
Rear = 7.1 x 11 – 5
Diameter of the rear wheel (D) = 280 mm [circumference = 398.98 mm]
Steering Model
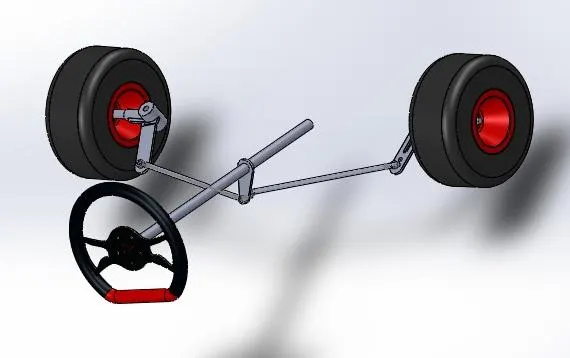
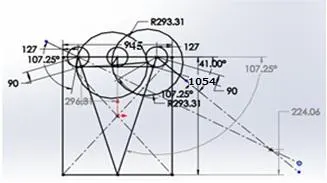
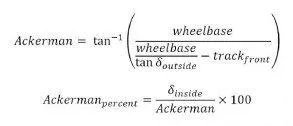
Ackerman Percentage = 90.45%
Rear Axle Diameter Calculation:
Bending Moment Calculation:
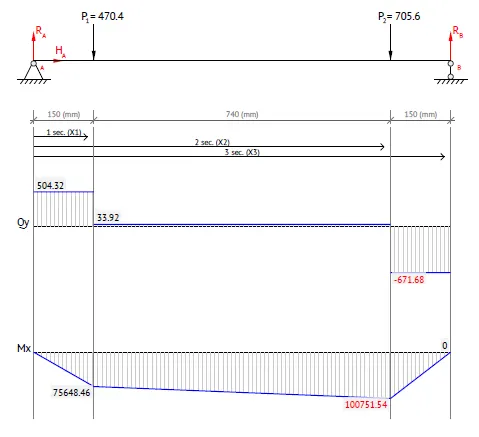
Vertical Loading:
RA=504.32 Rb=671.68
Maximum Bending Moment=100.75Nm
Torque Calculation:
Max Torque applied= Braking Torque
Max Torque applied, T= 120Nm
Minimum Diameter for Solid Shaft:
Total Torque due to applied Torque and Vertical Loading =M2+T2
Ttotal=1202+100.752 = 156.69Nm
Shaft Material Steel:
Considering fatigue loading FOS of 3 is taken Max Allowable Shear Strength= 121 MPa
Dmin=316Tt/max
Dmax=23.6mm is enough for the purpose
Considering availability and reliability a shaft of 30mm is used
Fabricated and pre-fabricated parts
|
Fabricated Parts |
Acquired |
|
Frame |
Engine |
|
Tie rod |
Clutch and Gear box |
|
Brake pedal |
Sprocket and chain |
|
Disc |
Master cylinder and caliper |
|
Fire wall |
Bumpers |
|
Steering column |
Tyre and wheel |
|
Hub |
Steering wheel |
|
Disc hub |
Fuel tank |
|
Sprocket hub |
Spindle |
|
All mounts |
Kill switch |
Since the engine used has a four gear speed variation system, some of the calculations below are done for each gear.
Validation Plan :-
|
Parameter |
Method Of Checking |
|
Minimum Turning Radius |
Negotiate a circle – Distance between two diametrically opposite points. |
|
Minimum Static Turning Effort |
Weight pan to the steering wheel Add weights till steering wheel start rotating. |
Frame Loading |
Slowly add weight to the assembled frame After each addition of weight visually inspect the frame to make sure it is holding Once the frame has proven to support drive system with no issues test its ability to hold the weight at different rpm Continue to increase the weight and the rpm while inspecting the rigidity of the frame. |
|
Travel |
Vehicle on a jack remove spring Distance between the extreme positions of after travel. |
|
Maximum Pulling Capacity |
Attach a trailer to the vehicle add weight subsequently Weight previous to the one where the vehicle fails to takes off. |
|
Stopping Distance and Time |
Drive the vehicle at preset speed Apply brakes at a marked position Vehicle to a complete halt Measure the stopping distance & time using stop watch. |
WEIGHT OPTIMIZATION:
The components of the kart were designed and subjected to Finite Element Analysis and unwanted material were removed in order to produce a light and dynamic kart.
CONCLUSION
This project gave us the opportunity to learn a variety of core knowledge, software and machine operation. It developed several soft skills in us. Our team made the best use of it and made a well engineered race spec 125cc four stroke gokart.
REFERENCES
[1]. http://www.bmikarts.com/Brakes-Accessories_c_198.html
[2]. http://gokartsusa.com/Gokart-Mini-Bike-Minibike-Parts-Brakes.aspx
[3]. http://en.m.wikipedia.org/wiki/Brake
[4]. http://auto.howstuffworks.com/auto-parts/brakes/brake-types/brake.htm
[5]. http://gokartguru.com/go_kart_steering_systems.php
[6]. http://gokartguru.com/go_kart_building_bundle.php
[7]. https://www.google.co.in/search?q=steering+system+in+go+karts&hl=en&noj=1&tbm=isch&tbo=u&souce=univ&sa=X&ei=_D20U5GnBpWjugS82IHACQ&ved=0CB8QsAQ&biw=1366&bih=657
[8]. http://books.google.co.in/books?id=jK93oR47zkwC&pg=PA224&source=gbs_toc_r&cad=3#v=onepage&q&f=false
Books
[9]. Don Knowels 2002 “Automobile suspension & steering system” page-224
Additional Sources
[10]. Seda Joseph B. “Drive Train Paper Report August”. Paper #1 UPRM Mini Baja 2006-2007. SAE. 2006.
[11]. Gillespie, Thomas D., Fundamentals of Vehicle Dynamics. Warren dale: SAE. 1992.
[12]. Lerner, Preston. “Going Nowhere Fast”. Popular Science. November 2006.
[13]. Thompson, Dale. “Ackerman? Anti-Ackerman? Or Parallel Steering?” Racing Car Technology, 2006.
[14]. Reimpell, Jornsen., et all. The Automotive Chassis: Engineering Principles. 2nd ed. Oxford: Butterworth-Heinemann. 2001.
[15]. Smith, Carroll. Racing Chassis and Suspension Design. Warrendale: SAE. 2004.
[16]. Smith, Carroll. Tune To Win.