Week-7 Challenge: DC Motor Control
1. A. Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’.
B. Comment on the armature current shoot-up from the scope results.
C. Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
1. A. Speed control of a DC motor using BJT H-bridge:
An H Bridge consists of Four switching elements and 4 diodes with load connected in center in an H-like configuration. The switching elements are bipoloar or FET Transistors and for high voltage applications IGBTs are used. The 4 diodes connected across Transistors acts as a freewheeling diode. When Switches Q1 and Q4 are closed and Q2 and Q3 are opened the positive side of voltage is applied to motor and current starts to flow from switches Q1 and Q4 and it energizes the dc motor and motor starts to rotate in forward direction. when Q2 & Q3 are turned on and Q1&Q4 are turned off then reverse voltage is applied and current starts to flow from switches Q3&Q2 and it energizes the motor but the flow of current is reversed so motor rotates in backward direction.
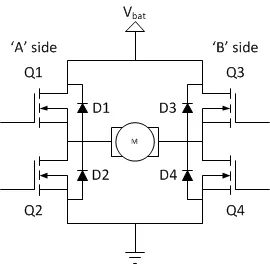
H-Bridge Circuit
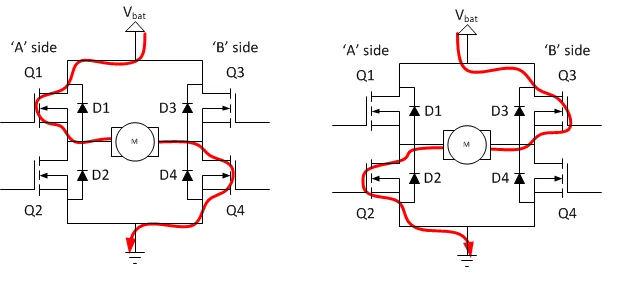
Switches Q1&Q4 are turned On Switches Q3&Q2 are turned On
At a time the switches of one leg shouldn't be turned on simultaneously since it can lead to formation of low resistance path for the current flow between Power and ground and will result in short circuit. This condition is called as 'shoot-through' and can damage the H-Bridge.
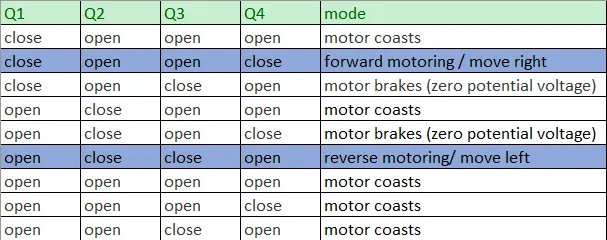
For the states in which the motor coasts, this occurs because the circuit is not connected completely (only one switch is turned on). This leaves the motor unaffected by the power supply from the source of the H-bridge. Therefore, the motor coasts.
For the states in which the motor brakes, this occurs because the voltage difference between both terminals of the motor is zero.
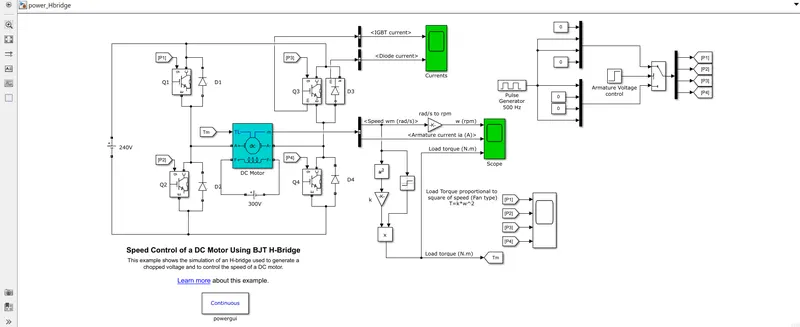
BJT H-Bridge Simulink Model
Model Description:
- The Model has 4 IGBTs as switching devices and diodes connected across ach IGBTs which acts as a freewheeling diode.
- The IGBTs has forward voltage of 1V and Resistance of 0.001Ohms.
- A DC Motor Model is used which has rating of 5Hp 240V 1750 RPM 300V. The field Winding is excited by 300V. The Armature winding is supplied by 240V.
- The motor mechanical input supplied is Torque.
- The output of DC Motor is connected to Fan type load wher load torque is proportional to square of speed (T=K*w^2).
- The Speed of dc motor is controlled by varying the armature voltage from (0 to 240V). This is scherived by using PWM method. A pulse Generator is used to generate the gate signals. By varying the duty cycle in % the Speed of the dc motor is controlled.
- A Pulse genearator is operaated at 500Hz. The time period is set as 2ms and Duty Cycle as 75%. A Armature Voltage control is used where it is stepped at 0.5seconds. At output four GOTO blocks are used and signals P1, P2,P3 and P4 are generated and FROM blocks are used with specified tags and are connected to respective Switches.
- According to the gate pulses the switches will be activated.
- Two transistors are switched simultaneously: Q1 and Q4 or Q2 and Q3. When Q1 and Q4 are fired, a positive voltage is applied to the motor and diodes D2-D3 operate as free-wheeling diodes when Q1 and Q4 are switched off.
- When Q2 and Q3 are fired, a negative voltage is applied to the motor and diodes D1-D4 operate as free-wheeling diodes when Q2 and Q3 are switched off.
- The Load Torque Tm is given as Mechanical input to dc motor.
- The Simulation is runned for 1s in which for 1st 0.5seconds the motor starts in the positive direction with a duty cycle of 75% (mean DC voltage of 180V). At t= 0.5 sec., the armature voltage is suddenly reversed and the motor runs in the negative direction.
- A bus Selector is used to select the output parameters of DC Motor.
- The DC Motor output consists of Motor Speed in RPM, Armature Current in A and Load Torque in Nm which is plotted using Scope Block.
- The IGBT current and Diode Current is also plotted by using Scope Block.
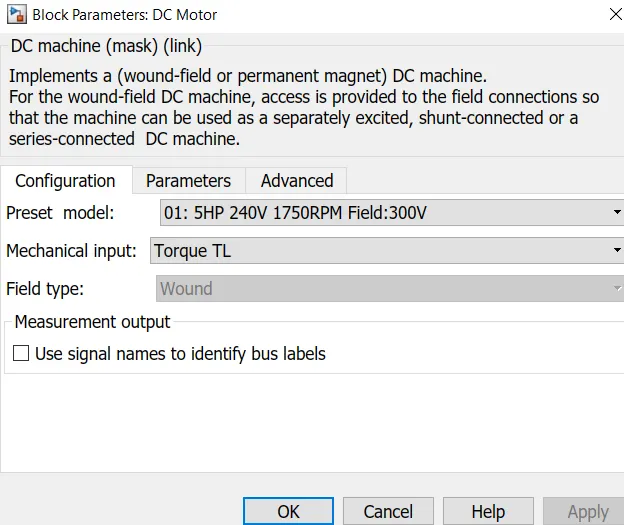
DC MOTOR PARAMETERS
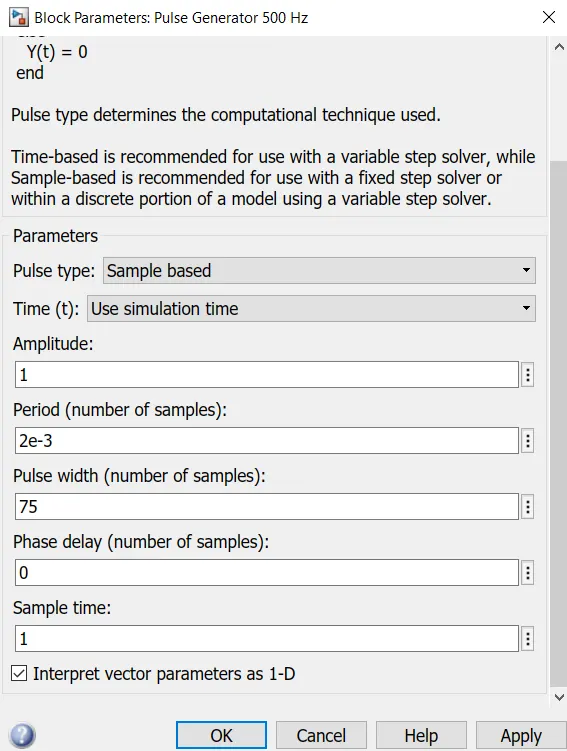
PULSE GENERATOR BLOCK
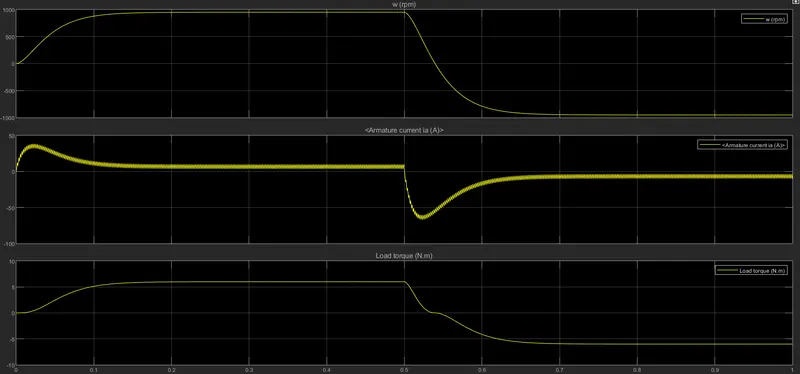
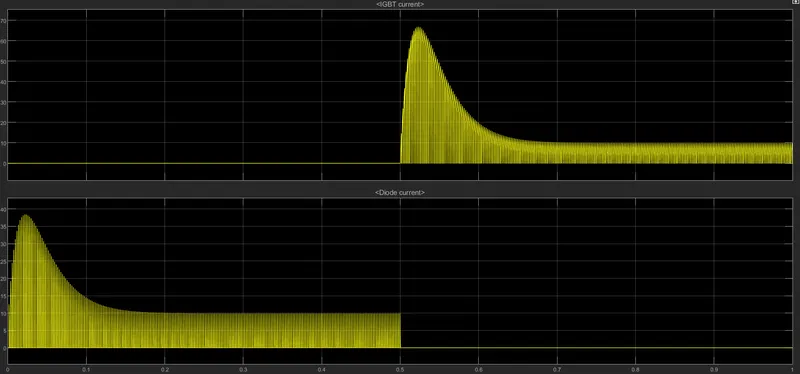
- Above graph shows the output of DC Motor ,Diode and IGBT Current.
- Since the duty cycle is applied as 75% so input voltage of 180V is applied to armature winding and Motor RPM is near to 950RPM which reaches its steady speed in 0.150Seconds.
- The Armature Current has Spike at starting since motor is connected to load, ths happens baecause of switching action.
- For 0 to 0.5 seconds the motor operates in forward motoring and after 0.5seconds the voltage direction is reversed so there is again spike in Armature Current because of switching action.
- Since Reverse current is flowing through Motor so Motor RPM Decreases from about 950RPM to -950 RPM.
- The motor torque has value of 6Nm during forward motoring and as the speed of motor reduces the torque developed also reduces and in reveerse motoring a reverse torque is generated.
- The Armature Current Spike can be reduced by changing the Duty Cycle.
B. Armature current shoot-up from the scope results:
- Whenever switching action occurs the armature current has a huge spike ie at 0sec forward motoring and 0.5sec reverse motoring.
- The Armature spike is high during reverse motoring action.
- The Speed of DC Motor can be controlled by varying the Supply Voltage and for this PWM method is used.
- By Reducing the pulse width the armature current shoot up can be controlled.
- In Pulse generator Block the pulse width is reduced to 50% so the gate pulse value and the diode and IGBT current value will also be varied.
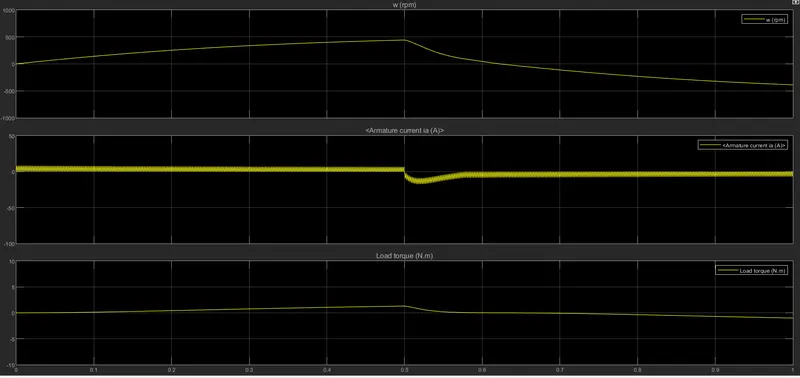
- The above graph shows the DC motor output when pulse width is reduced to 50%.
- When Duty Cycle is 50% the armature starting current has no spike but during the switching action at 0.5sec there is small overshoot but the Spike has reduced much as compared to the spike when duty cycle was 75%.
- Due to lower duty cycle the armature voltage applied has reduced to 50% ie 120V so motor Speed has also reduced and so the generated torque.
C. Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
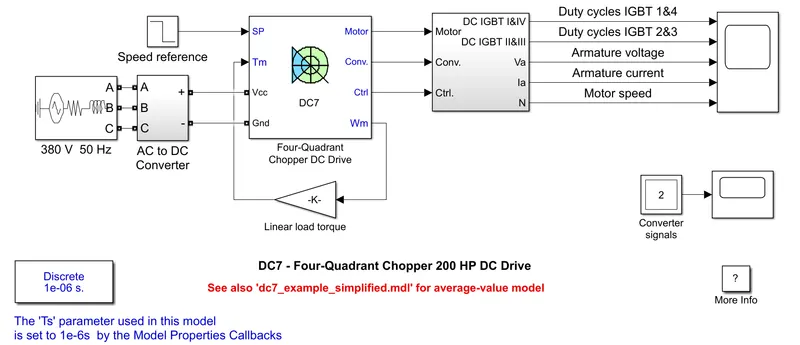
- The 200 HP DC motor is separately excited with a constant 150 V DC field voltage source. The armature voltage is provided by an IGBT converter controlled by two PI regulators.
- The converter is fed by a 515 V DC bus obtained by rectification of a 380 V AC 50 Hz voltage source. In order to limit the DC bus voltage during dynamic braking mode, a braking chopper has been added between the diode rectifier and the DC7 block.
- The first regulator is a speed regulator, followed by a current regulator. The speed regulator outputs the armature current reference (in p.u.) used by the current controller in order to obtain the electromagnetic torque needed to reach the desired speed.
- The speed reference change rate follows acceleration and deceleration ramps in order to avoid sudden reference changes that could cause armature over-current and destabilize the system.
- The current regulator controls the armature current by computing the appropriate duty ratios of the 5 kHz pulses of the four IGBT devices (Pulse Width Modulation).
- For proper system behaviour, the instantaneous pulse values of IGBT devices 1 and 4 are opposite to those of IGBT devices 2 and 3. This generates the average armature voltage needed to obtain the desired armature current. In order to limit the amplitude of the current oscillations, a smoothing inductance is placed in series with the armature circuit.
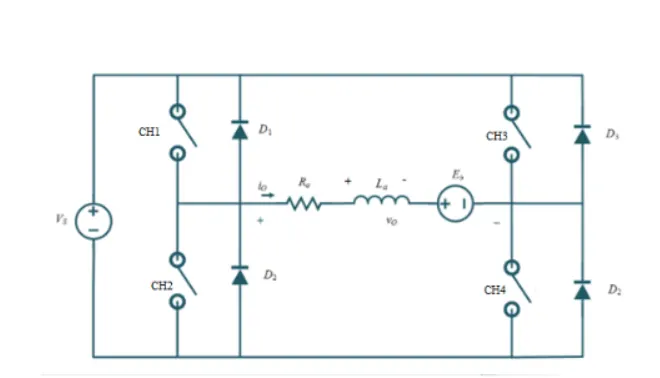
FOUR QUADRANT CHOPPER CIRCUIT
This Quadrant circuit operates in 4 modes.
Mode 1: Switch Ch1 and Ch4 Conducts:(Quadrant 1)
In 1st quadrant operation switch Ch1 is operated, and when Ch1 and Ch4 are On simultaneously then the source voltage flows through the load and output voltage becomes equal to source voltage. The load current Io flow from source to load. The Inductor charges and stores the charge. The Motor Rotates in forward direction and is called Forward Motoring.
When Ch1 is turned off, Ch4 and D2 conducts. The output voltage and current both are positive. The inductor now releases stored energy and the load current now flows through freewheeling diode and Ch4. This operation of the chopper is called first quadrant operation.
Mode 2: Switch Ch2 and D2Conducts:(Quadrant 2)
When Ch2 is operated then Ch2 and D2 conducts and switch Ch1,Ch3 and Ch4 are off. When CH2 is ON, the DC source in the load drives current through CH2, D4, E and L. Inductor L stores energy during the on period of CH2. The load current is now flowing in opposite direction.
When Ch2 is turned off, Diode D4 and D1 conducts and current is now fed back to the source, Output voltage is positive and Load current is negative. Inductor releases its stored energy during this operation. Since current is flowing back to the source this is called as Forward Braking since speed is positive.
Mode 3: Switch Ch3 Conducts:(Quadrant 3)
For Quadrant 3 operation both load current and load voltage must be negative. The polarity of back emf E in load must be reversed to have third quadrant operation. When Ch3 is operated, Ch2 and Ch3 conducts and source voltage flows through load, the load voltage and load current are negative, Inductor stores charge during this operation. Since current is flowing in reverse direction the motor also rotates in reverse direction and is called as Reverse Motoring.
When Ch3 is turned off Ch2 and D4 conducts, inductor releases stored energy through diode D4 and Ch2. The load current and load voltage both are negative.
Mode 4: Switch Ch4 Conducts:(Quadrant 4)
The Motor is rotating in reverse direction and when Ch4 is operated Ch4 and D2 Conducts.The polarity of load emf E needs to be reversed in this case too like third quadrant operation. When CH4 is turned ON, positive current flows through CH4, D2, L and E. Inductance L stores energy during the time CH4 is ON.
When CH4 is turned off, diode D2 and D3 conducts and output voltage Vo becomes negative and output current is positive, inductor release energy using free wheeling diodes D2 &D3, power starts to flow from load to source and this is called as Reverse braking.
COMPARISON:
- The H-Bridge can be operated in 2 modes only while Four Quadrant Chopper is Operated in four modes.
- H-Bridge is operated only in Forward Motoring and Reverse Motoring.
- Four Quadrant Chopper is Operated in Forward Motoring, Forward Braking, Reverse Motoring and Reverse Braking.
- The 4 Quadrant Chopper Circuit has high switching frequency and H Bridge has lower Switching frequency.
- Direction of the motor is changed by changing the polarity in a H-Bridge circuit whle the direction of the motor can be changed in a four quadrant chopper DC drive by changing the input signal to the DC7 block.
- In four Quadrant Chopper since forward braking and reverse braking can be done, the current starts to flow back to the source from load. So REGENERATIVE BRAKING is possible in four Quadrant Chopper.
2. Develop a 2-quadrant chopper using simulink & explain the working of the same with the relevant results. (Refer to article - Multiquadrant operation of motor )
A 2 Quadrant Chopper consists of 2 switches and 2 diodes. This Chopper can operate in either first quadrant or second quadrant. There are 2 types of chopper
Type A Chopper
Type B Chopper
In Type A Chopper the flow of power is from Source to load as the average voltage V0 is less than the dc input voltage Vs. In Type B Chopper the flow of power is from Load to source since the load must always contain a dc source E . When the chopper is on, v0 is zero but the load voltage E drives the current through the inductor L and the chopper, L stores the energy during the time Ton of the chopper . When the chopper is off , v0 =( E+ L . di/dt ) will be more than the source voltage Vs.
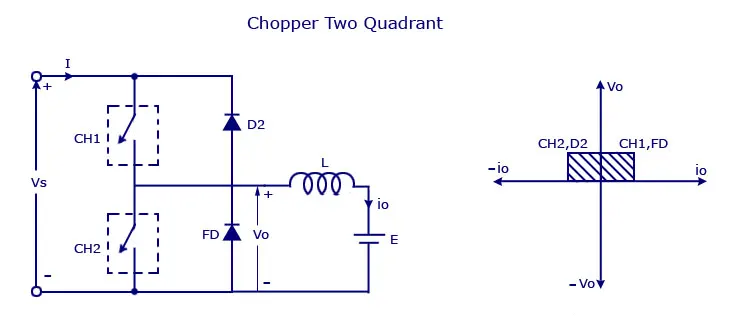
WORKING:
Mode-1: When CH1 is switched ON
When switch CH1 is switched ON, source Voltage gets connected to the load and hence load voltage Vo becomes equal to source voltage. The direction of current is from source to load. When CH1 is switched OFF, the free-wheeling diode FD conducts as it gets forward biased. Therefore, the output voltage becomes zero. However, the current Io continues to flow through the FD and L. Thus, the average output voltage Vo and current Io are positive and hence the operation of the chopper is in the first quadrant.
Case-2: When CH2 is switched ON / OFF
When the chopper is on,V0 is zero but the load voltage E drives the current through the inductor L and the chopper, L stores the energy during the time Ton of the chopper . When the chopper is off , v0 =( E+ L . di/dt ) will be more than the source voltage Vs . Because of this the diode D2 will be forward biased and begins conducting and hence the power starts flowing to the source. No matter the chopper is on or off the current I0 will be flowing out of the load and is treated negative . Since VO is positive and the current I0 is negative , the direction of power flow will be from load to source. The load voltage V0 = (E+L .di/dt ) will be more than the voltage Vs so the type B chopper is also known as a step up chopper.
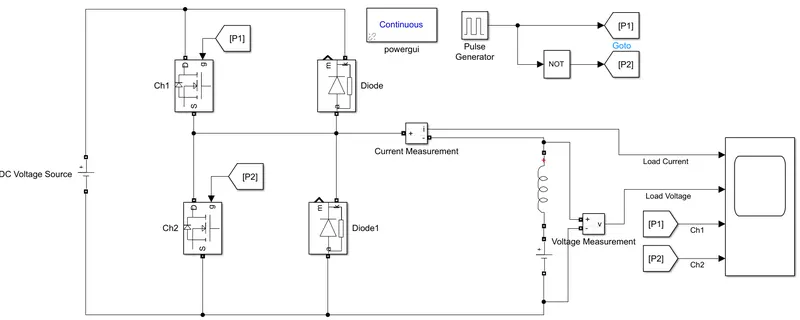
SIMULINK MODEL OF 2 QUADRANT CHOPPER
- The above Chopper circuit consists of 2 switches (MOSFET) and 2 diodes.
- A DC Voltage Source of 100V is supplying power to the circuit.
- A Inductor of 1e-3H and Back EMF Voltage Source is connected at the output of the circuit.
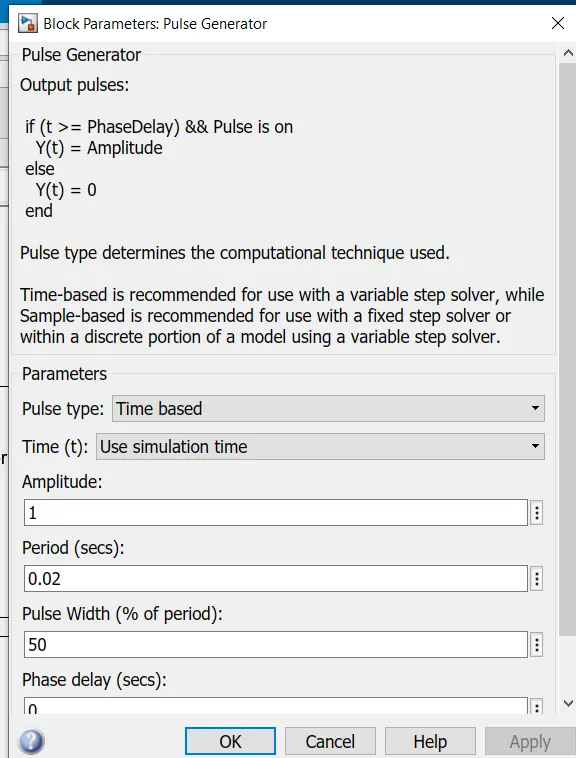
- A Pulse generator is used to generate the pulse for switches. The Duty Cycle is kept as 50%.
- A GOTO Block P1 and P2 are used to send the signals to switch Ch1 nad Ch2 by using FROMBlock.
- Gate Signal P2 is connected to NOT Block so that when P1 is turned ON at that P2 will be off. If P1 and P2 are turned On simultaneously then it will lead to formation of low resistance path and it will lead to short circuit.
- A current measurement and voltage measurement blocks are used to measure the Output Current and Output Voltage.
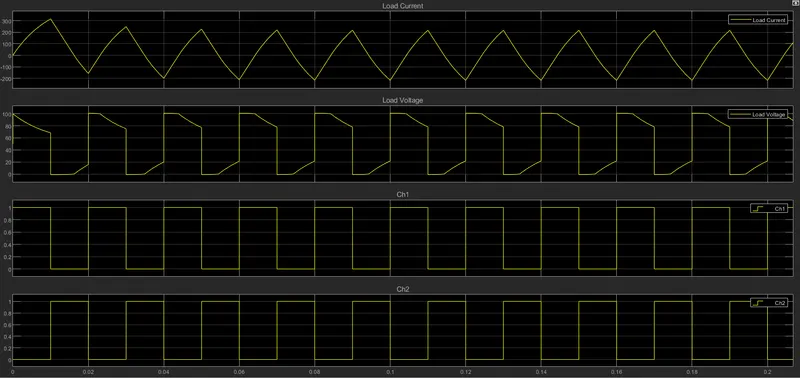
- From above graph when Ch1 is turned On the Load Current and load Voltage both are positive and Load voltage is equal to source voltage.
- When CH1 is switched OFF, the free-wheeling diode FD conducts as it gets forward biased and hence shorts the load. Therefore, the output voltage Vo becomes zero.This is First Quadrant Operation.
- When Ch2 is Turned On the load Current is reducing and value of load current is negative indicating that the direction of current is from Load to source. This is 2nd Quadrant Operation.
- The value of Current varies from +300A to - 200A ie Current will either be positive or negative but the Load Voltage is always positive, it is reducing to Zero when Ch2 is On but never goes below 0 Voltage.
3. Explain in a brief about operation of BLDC motor.
A brushless DC motor (known as BLDC) is a permanent magnet synchronous electric motor which is driven by direct current (DC) electricity and is electronically commutated(commutation is the process of producing rotational torque in the motor by changing phase currents through it at appropriate times) instead of a mechanically commutation system. BLDC motors are also referred as trapezoidal permanent magnet motors as the back EMF produced by BLDC Motor is of Trapezoidal Nature.
Unlike conventional brushed type DC motor, wherein the brushes make the mechanical contact with commutator on the rotor so as to form an electric path between a DC electric source and rotor armature windings, BLDC motor employs electrical commutation with permanent magnet rotor and a stator with a sequence of coils. In this motor, permanent magnet (or field poles) rotates and current carrying conductors are fixed.
The armature coils are switched electronically by transistors or silicon controlled rectifiers at the correct rotor position in such a way that armature field is in space quadrature with the rotor field poles. Hence the force acting on the rotor causes it to rotate. Hall sensors or rotary encoders are most commonly used to sense the position of the rotor and are positioned around the stator. The rotor position feedback from the sensor helps to determine when to switch the armature current.
This electronic commutation arrangement eliminates the commutator arrangement and brushes in a DC motor and hence more reliable and less noisy operation is achieved. Due to the absence of brushes BLDC motors are capable to run at high speeds. The efficiency of BLDC motors is typically 85 to 90 percent, whereas as brushed type DC motors are 75 to 80 percent efficient. There are wide varieties of BLDC motors available ranging from small power range to fractional horsepower, integral horsepower and large power ranges.
CONSTRUCTION AND TYPES:
The BLDC Motor are of types depending on their construction
1. Out Runner BLDC Motor
- The Rotor is outside and Stator is Inside the Motor.
- It is also called as Hub Motor as the wheels are directly connected to the exterior of Motor.
- Gear System is not required to transmit the power.
- It is mostly used in 2 Wheelers like Electric Scooters and Electric Bicycles.
- Out Runner Motors produce more torque as compared to In Runner Motor.
2. In Runner BLDC Motor
- In an outrunner motor the magnets are attached to a ring or sleeve on the outside of the stator coils. As a result, the motor has a rotating ring or sleeve, instead of a rotating shaft.
- The Torque produced is less as compared to Out Runner Motor so to compensate for lower torque In runner motors are often equipped with transmissions or gearboxes.
Construction:
IN RUNNER BLDC MOTOR
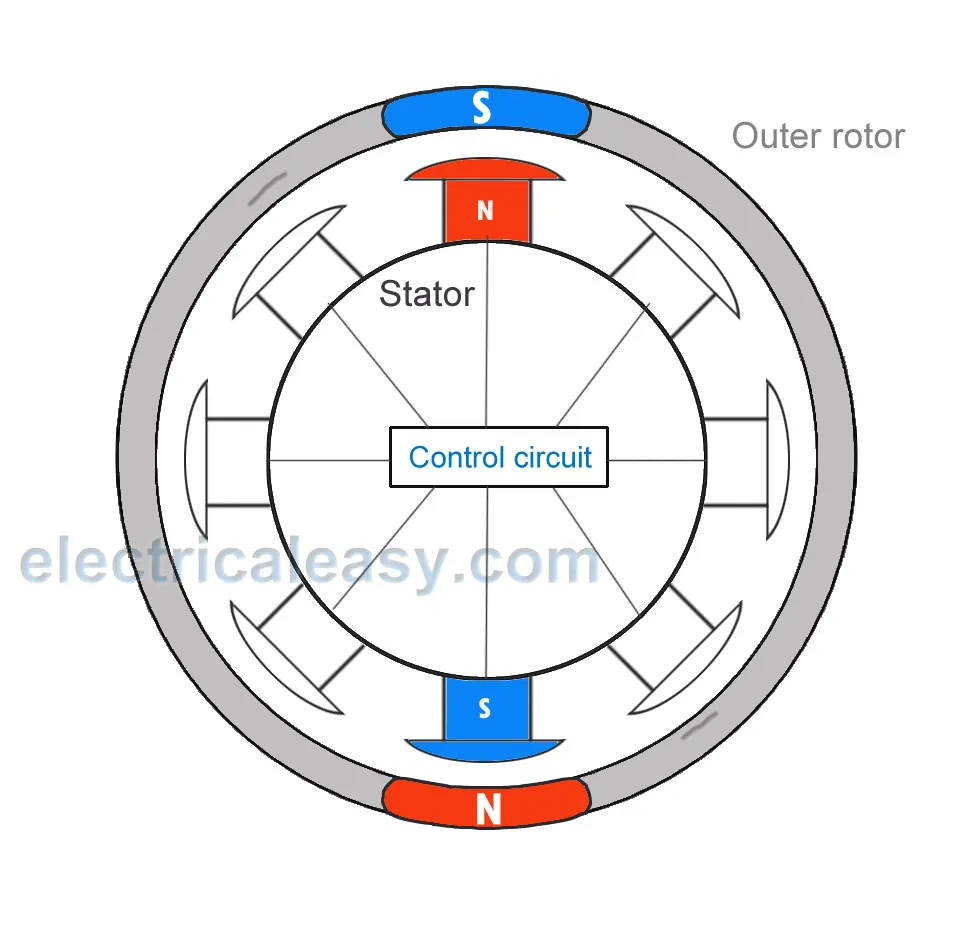
OUT RUNNER BLDC MOTOR
STATOR:
Stator of a BLDC motor made up of stacked steel laminations to carry the windings. These windings are placed in slots which are axially cut along the inner periphery of the stator. These windings can be arranged in either star or delta. However, most BLDC motors have three phase star connected stator.
Each winding is constructed with numerous interconnected coils, where one or more coils are placed in each slot. In order to form an even number of poles, each of these windings is distributed over the stator periphery.
The stator must be chosen with the correct rating of the voltage depending on the power supply capability. For robotics, automotive and small actuating applications, 48 V or less voltage BLDC motors are preferred. For industrial applications and automation systems, 100 V or higher rating motors are used.
Rotor
BLDC motor incorporates a permanent magnet in the rotor. The number of poles in the rotor can vary from 2 to 8 pole pairs with alternate south and north poles depending on the application requirement. In order to achieve maximum torque in the motor, the flux density of the material should be high. A proper magnetic material for the rotor is needed to produce required magnetic field density.
Ferrite magnets are inexpensive, however they have a low flux density for a given volume. Rare earth alloy magnets are commonly used for new designs. Some of these alloys are Samarium Cobalt (SmCo), Neodymium (Nd), and Ferrite and Boron (NdFeB). The rotor can be constructed with different core configurations such as the circular core with permanent magnet on the periphery, circular core with rectangular magnets, etc.
Hall Sensors
Hall sensor provides the information to synchronize stator armature excitation with rotor position. Since the commutation of BLDC motor is controlled electronically, the stator windings should be energized in sequence in order to rotate the motor. Before energizing a particular stator winding, acknowledgment of rotor position is necessary. So the Hall Effect sensor embedded in stator senses the rotor position.
Most BLDC motors incorporate three Hall sensors which are embedded into the stator. Each sensor generates Low and High signals whenever the rotor poles pass near to it. The exact commutation sequence to the stator winding can be determined based on the combination of these three sensor’s response.
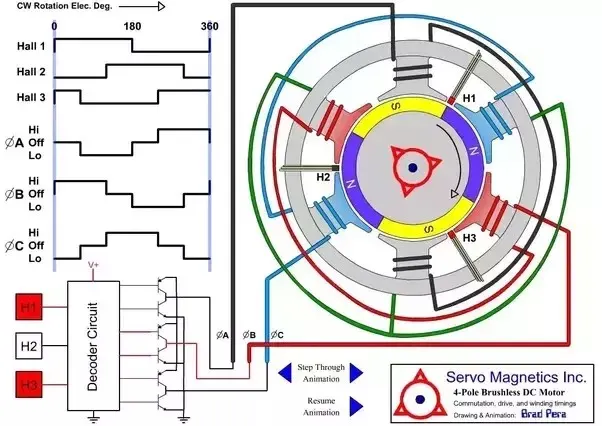
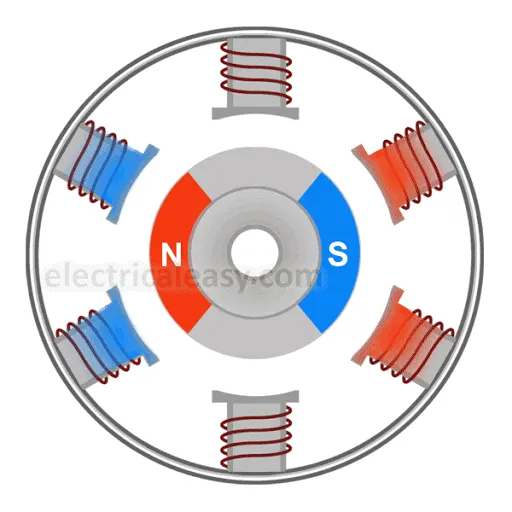
- A BLDC Motor has 3 input wires and 3 hall sensors wire. The Three inputs wires are connected to the motor controller.
- When input B is set to high at that time input C is low. Current will flow from B coil and exit from C Coil.
- Inner Rotor Motor has 4 permanent magnets.
- Alternate South and North Pole will be produced in the coil. The magnetic field created will push or drag the rotor in other direction.
- Red Coil ie S Pole will direct the N Pole of Rotor and push the S Pole of Rotor and Blue Coil ie N pole will do opposite.
- Due to this Rotor will rotate in Clockwise Direction.
- When the N Pole of magnet passes through the pole the input needs to be switched so that Rotor can rotate, If the switch is not changed the motor can stall.
- Now A switch is set to low, B is set to high and C is Off due to this South polarity of Coil will attract N Pole of Magnet and Repel the S Pole of magnet.
- Now C is set to high, A is set to low and B is Off, this switching is done for 6 times when 4 poles are used.
- By switching the the input in exact sequence the rotor will rotate and if the inputs are switched quickly then the motor will rotate faster.
- To obtain correct Switching sequence Hall Sensors are used to detect the position of Rotor and depending upon the Hall Sensor signal the stator Coils are energized.
- Another method is by Detecting the Back EMF of Motor and obtaining the switching operation.
- The windings of an electric motor act like a generator as they cut through magnetic field lines. A potential is generated in the windings, measured in Volts and called an electromotive force (EMF).
- According to Lenz’s law, this EMF gives rise to secondary magnetic field that opposes the original change in magnetic flux driving the motor’s rotation.
- In simpler terms, the EMF resists the motor’s natural movement and is referred to as a “back” EMF. For a given motor of fixed magnetic flux and number of windings, the magnitude of the EMF is proportional to the angular velocity of the rotor.
- Manufacturers of BLDC motors specify a parameter known as the back EMF constant that can be used to estimate back EMF for a given speed. The potential across a winding can be calculated by subtracting the back EMF value from the supply voltage.
- Motors are designed such that when they are running at rated speed, the potential difference between the back EMF and supply voltage will cause the motor to draw the rated current and deliver the rated torque.
- But Controlling the BLDC Motor by Back EMF is much diificult and costly as compared to Hall Sensors.
- There is one major disadvantage to sensorless BLDC motor control; when the motor is stationary, no back EMF is generated, depriving the MCU of information about the stator and rotor position.
- In each state one input is set to zero, so that input will have high impedance and according to Faradays Law o Electromagnetic Induction if the magnetic flux inside a coil is changed then inductive current will flow in coil. Higher the flux change higher amount of current will flow.
- The Rotor magnet will create the change of magnetic flux in coil, the more the center of magnet is near to the coil the higher magnetic field will pass through the coil.
Advantages of BLDC Motor
- High efficiency due to the use of permanent magnet rotor.
- High speed of operation even in loaded and unloaded conditions due to the absence of brushes that limits the speed.
- It is lighter in weight than both brushed type DC and induction AC motors.
- Long life as no inspection and maintenance is required for commutator system.
- Higher dynamic response due to low inertia and carrying windings in the stator.
- Less electromagnetic interference.
- Quite operation due to absence of brushes.
Disadvantages of Brushless Motor
- These motors are costly.
- Electronic controller required control this motor is expensive.
- Not much availability of many integrated electronic control solutions, especially for tiny BLDC motors.
- Requires complex drive circuitry.