Week-7 Challenge: DC Motor Control
AIM
To understand DC Machine Characteristics.
INTRODUCTION
1. BIPOLAR JUNCTION TRANSISTOR:
[1] A bipolar junction transistor (BJT) is a type of transistor that uses both electrons and electron holes as charge carriers. A bipolar transistor allows a small current injected at one of its terminals to control a much larger current flowing between two other terminals, making the device capable of amplification or switching. BJTs use two junctions between two semiconductor types, n-type, and p-type, which are regions in a single crystal of material. The junctions can be made in several different ways, such as changing the doping of the semiconductor material as it is grown, by depositing metal pellets to form alloy junctions, or by such methods as diffusion of n-type and p-type doping substances into the crystal.
[2] A Bipolar Junction Transistor (also known as a BJT or BJT Transistor) is a three-terminal semiconductor device consisting of two p-n junctions which are able to amplify or magnify a signal. It is a current controlled device. The three terminals of the BJT are the base, the collector, and the emitter. A BJT is a type of transistor that uses both electrons and holes as charge carriers. A signal of small amplitude if applied to the base is available in the amplified form at the collector of the transistor. This is the amplification provided by the BJT. Note that it does require an external source of DC power supply to carry out the amplification process. There are two types of bipolar junction transistors – NPN transistors and PNP transistors. A diagram of these two types of bipolar junction transistors as shown in the figure below.
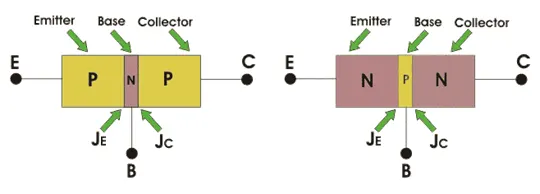
Figure 1. PNP and NPN transistors
Every BJT has three parts named emitter, base and collector. JE and JC represent the junction of emitter and junction of collector, respectively. The emitter-based junction is forward biased and collector-base junctions are reverse biased.
NPN TRANSISTOR: In an n-p-n bipolar transistor (or n-p-n transistor) one p-type semiconductor resides between two n-type semiconductors as shown in the diagram below.
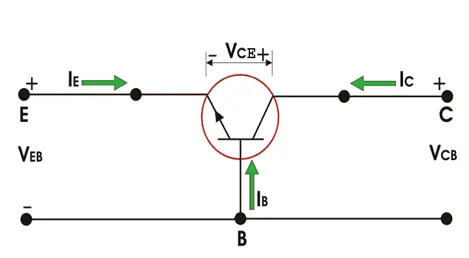
Figure 2. Layout of NPN bipolar transistor.
IE, IC is emitter current and collect current respectively and VEB and VCB are emitter-base voltage and collector-base voltage, respectively. According to the convention if for the emitter, base and collector current IE, IB and IC current goes into the transistor the sign of the current is taken as positive and if current goes out from the transistor, then the sign is taken as negative. When tabulated the different currents and voltages inside the n-p-n transistor, the following is observed:
|
Transistor Type |
IE |
IB |
IC |
VEB |
VCB |
VCE |
|
N-P-N |
- |
+ |
+ |
- |
+ |
+ |
Table 1. Nature of currents and voltages in NPN bipolar transistor.
PNP TRANSISTOR: Similarly for p-n-p bipolar junction transistor (or pnp transistor), an n-type semiconductor is sandwiched between two p-type semiconductors. The diagram of a p-n-p transistor is shown below in the Figure 3. For p-n-p transistors, current enters into the transistor through the emitter terminal. Like any bipolar junction transistor, the emitter-base junction is forward biased, and the collector-base junction is reverse biased.
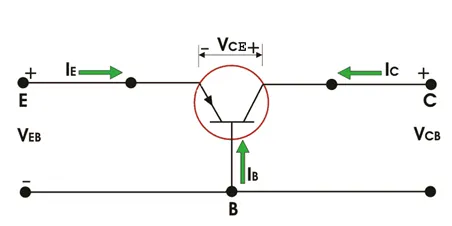
Figure 3. Layout of PNP bipolar transistor.
When tabulated the different currents and voltages inside the n-p-n transistor, the following is observed:
|
Transistor Type |
IE |
IB |
IC |
VEB |
VCB |
VCE |
|
N-P-N |
+ |
- |
- |
+ |
- |
- |
Table 2. Nature of currents and voltages in PNP bipolar transistor.
WORKING PRINCIPLE OF BJT: The Figure 4. shows an n-p-n transistor biased in the active region (See transistor biasing), the BE junction is forward biased whereas the CB junction is reversed biased. The width of the depletion region of the BE junction is small as compared to that of the CB junction.
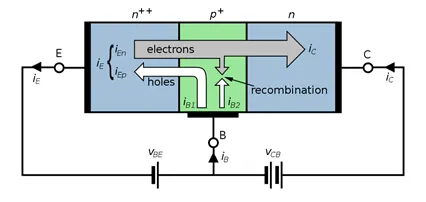
Figure 4. NPN BJT with forward-biased E–B junction and reverse-biased B–C junction.
The forward bias at the BE junction reduces the barrier potential and causes the electrons to flow from the emitter to the base. As the base is thin and lightly doped it consists of very few holes so some of the electrons from the emitter (about 2%) recombine with the holes present in the base region and flow out of the base terminal. This constitutes the base current, it flows due to recombination of electrons and holes (Note that the direction of conventional current flow is opposite to that of the flow of electrons). The remaining large number of electrons will cross the reverse-biased collector junction to constitute the collector current. Thus, by Kirchoff Law:
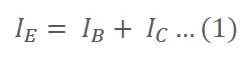
The base current is very small as compared to emitter and collector current. Therefore,
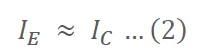
Here, the majority of charge carriers are electrons. The operation of a p-n-p transistor is same as of the n-p-n, the only difference is that the majority charge carriers are holes instead of electrons. Only a small part current flows due to majority carriers and most of the current flows due to minority charge carriers in a BJT. Hence, they are called as minority carrier devices.
BIPOLAR JUNCTION TRANSISTORS CHARACTERISTICS: The three parts of a BJT are collector, emitter, and base. Before knowing about the bipolar junction transistor characteristics, we have to know about the modes of operation for this type of transistors. The modes are:
- Common Base (CB) mode
- Common Emitter (CE) mode
- Common Collector (CC) mode
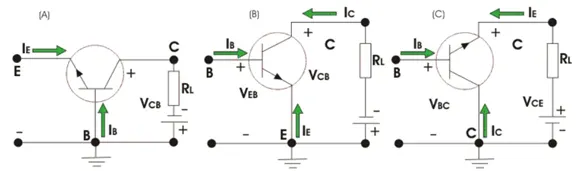
Figure 5. (A) Common Base Layout (B) Common Emitter Layout (C) Common Collector Layout.
The characteristics of BJT there are different characteristics for different modes of operation. Characteristics is nothing but the graphical forms of relationships among different current and voltage variables of the transistor. The characteristics for p-n-p transistors are given for different modes and different parameters.
COMMON BASE CHARACTERISTICS:
Input Characteristics: For p-n-p transistor, the input current is the emitter current (IE) and the input voltage is the collector base voltage (VCB). As the emitter-base junction is forward biased, therefore the graph of IE Vs VEB is similar to the forward characteristics of a p-n diode. IE increases for fixed VEB when VCB increases.
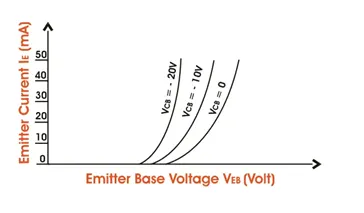
Figure 6. Input characteristics of Common Base mode.
Output Characteristics: The output characteristics show the relation between the output voltage and output current IC is the output current and collector-base voltage and the emitter current IE is the input current and works as the parameters. The Figure 7 below shows the output characteristics for a p-n-p transistor in CB mode.
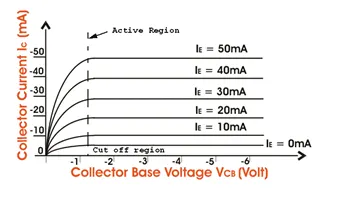
Figure 7. Output characteristics of Common Base mode.
For p-n-p transistors IE and VEB are positive and IC, IB, VCB are negative. These are three regions in the curve, active region saturation region and the cut off region. The active region is the region where the transistor operates normally. Here the emitter junction is reverse biased. Now the saturation region is the region where both the emitter-collector junctions are forward biased. And finally, the cut off region is the region where both emitter and the collector junctions are reverse biased.
COMMON EMITTER CHARACTERISTICS:
Input characteristics: IB (Base Current) is the input current, VBE (Base – Emitter Voltage) is the input voltage for CE (Common Emitter) mode. So, the input characteristics for CE mode will be the relation between IB and VBE with VCE as a parameter. The characteristics are shown in the Figure 8.
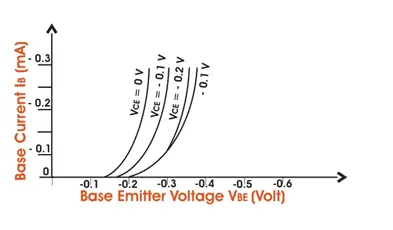
Figure 8. Input characteristics of Common Emitter mode.
The typical CE input characteristics are similar to that of a forward-biased of p-n diode. But as VCB increases the base width decreases.Output Characteristics: Output characteristics for CE mode is the curve or graph between collector current (IC) and collector-emitter voltage (VCE) when the base current IB is the parameter. The characteristics is shown below in the Figure 9.
Like the output characteristics of common – base transistor CE mode has also three regions named (i) Active region, (ii) cut-off regions, (iii) saturation region. The active region has collector region reverse biased and the emitter junction forward biased. For cut-off region, the emitter junction is slightly reverse biased, and the collector current is not totally cut-off. And finally for the saturation region both the collector and the emitter junction are forward biased.
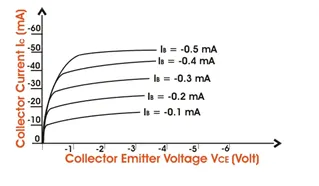
Figure 9. Output characteristics of Common Emitter mode.
COMMON COLLECTOR CHARACTERISTICS:
[3] The Common Collector Configuration is also called the grounded Collector configuration where the collector terminal is kept as the common terminal between the input signal applied across the base and the emitter, and the output signal obtained across the collector and the emitter. This configuration is commonly called as the Voltage follower or the emitter follower circuit. This configuration will be useful for impedance matching applications as it has very high input impedance, in the region of hundreds of thousands of ohms while having relatively low output impedance.
1. H-BRIDGE:
[4] An H-bridge is an electronic circuit that switches the polarity of a voltage applied to a load. These circuits are often used in robotics and other applications to allow DC motors to run forwards or backwards. Most DC-to-AC converters (power inverters), most AC/AC converters, the DC-to-DC push–pull converter, isolated DC-to-DC converter most motor controllers, and many other kinds of power electronics use H bridges. In particular, a bipolar stepper motor is almost always driven by a motor controller containing two H bridges.
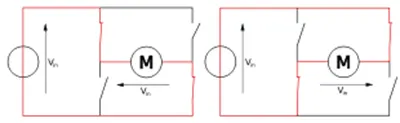
Figure 10(a). Two basic states of an H-Bridge.
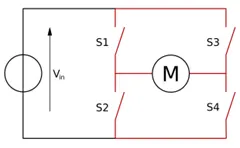
Figure 10(b). Structure of an H-Bridge (highlighted in red)
The H-bridge arrangement is generally used to reverse the polarity/direction of the motor but can also be used to 'brake' the motor, where the motor comes to a sudden stop, as the motor's terminals are shorted, or to let the motor 'free run' to a stop, as the motor is effectively disconnected from the circuit. The following table summarizes operation, with S1-S4 corresponding to the diagram above in Figure 10(b).
|
S1 |
S2 |
S3 |
S4 |
Result |
|
1 |
0 |
0 |
1 |
Motor moves right |
|
0 |
1 |
1 |
0 |
Motor moves left |
|
0 |
0 |
0 |
0 |
Motor coasts |
|
1 |
0 |
0 |
0 |
|
|
0 |
1 |
0 |
0 |
|
|
0 |
0 |
1 |
0 |
|
|
0 |
0 |
0 |
1 |
|
|
0 |
1 |
0 |
1 |
Motor brakes |
|
1 |
0 |
1 |
0 |
|
|
x |
x |
1 |
1 |
Short circuit |
|
1 |
1 |
x |
x |
Table 3. Operation of H-bridge.
2. INSULATED-GATE BIPOLAR TRANSISTOR (IGBT):
[5]An insulated-gate bipolar transistor (IGBT) is a three-terminal power semiconductor device primarily used as an electronic switch, which, as it was developed, came to combine high efficiency and fast switching. It consists of four alternating layers (P–N–P–N) that are controlled by a metal–oxide–semiconductor (MOS) gate structure.
Although the structure of the IGBT is topologically the same as a thyristor with a "MOS" gate (MOS-gate thyristor), the thyristor action is completely suppressed, and only the transistor action is permitted in the entire device operation range. It is used in switching power supplies in high-power applications: variable-frequency drives (VFDs), electric cars, trains, variable-speed refrigerators, lamp ballasts, arc-welding machines, and air conditioners. Since it is designed to turn on and off rapidly, the IGBT can synthesize complex waveforms with pulse-width modulation and low-pass filters, so it is also used in switching amplifiers in sound systems and industrial control systems. In switching applications modern devices feature pulse repetition rates well into the ultrasonic-range frequencies, which are at least ten times higher than audio frequencies handled by the device when used as an analog audio amplifier. As of 2010, the IGBT is the second most widely used power transistor, after the power MOSFET.
|
Device characteristic |
Power bipolar |
Power MOSFET |
IGBT |
|
Voltage rating |
High <1 kV |
High <1 kV |
Very high (>1Kv) |
|
Current rating |
High<500 A |
High >500 A |
High >500 A |
|
Input drive |
Current ratio hFE ~ 20–200 |
Voltage VGS ~ 3–10 V |
Voltage VGE ~ 4–8 V |
|
Input impedance |
Low |
High |
High |
|
Output Impedance |
Low |
Medium |
Low |
|
Switching speed |
Slow (µs) |
Fast (ns) |
Medium |
|
Cost |
Low |
Medium |
High |
Table 4. Comparison of Power Bipolar, Power MOSFET and IGBT characteristics.
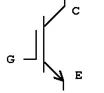
Figure 11. IGBT schematic symbol.
3. FOUR QUADRANT OPERATION OF DC MOTOR:
[6] Four Quadrant Operation of any drives or DC Motor means that the machine operates in four quadrants. They are Forward Braking, Forward motoring, Reverse motoring, and Reverse braking. A motor operates in two modes – Motoring and Braking. A motor drive capable of operating in both directions of rotation and of producing both motoring and regeneration is called a Four Quadrant variable speed drive.
In motoring mode, the machine works as a motor and converts the electrical energy into mechanical energy, supporting its motion. In braking mode, the machine works as a generator and converts mechanical energy into electrical energy and as a result, it opposes the motion. The Motor can work in both, forward and reverse directions, i.e., in motoring and braking operations. The product of angular speed and torque is equal to the power developed by a motor. For the multi-quadrant operation of drives, the following conventions about the signs of torque and speed are used. When the motor is rotated in the forward direction the speed of the motor is considered positive. The drives which operate only in one direction, forward speed will be their normal speed.
In loads involving up and down motions, the speed of the motor which causes upward motion is considered to be in forward motion. For reversible drives, forward speed is chosen arbitrarily. The rotation in the opposite direction gives reverse speed which is denoted by a negative sign. The rate of change of speed positively in the forward direction or the torque which provides acceleration is known as Positive motor torque. In the case of retardation, the motor torque is considered negative. Load torque is opposite to the positive motor torque in the direction.
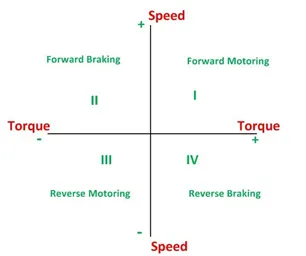
Figure 12. Four quadrant operation of DC Motor.
In the I quadrant power developed is positive and the machine is working as a motor supplying mechanical energy. The I (first) quadrant operation is called Forward Motoring. II (second) quadrant operation is known as Braking. In this quadrant, the direction of rotation is positive, and the torque is negative, and thus, the machine operates as a generator developing a negative torque, which opposes the motion.
The kinetic energy of the rotating parts is available as electrical energy which may be supplied back to the mains. In dynamic braking, the energy is dissipated in the resistance. The III (third) quadrant operation is known as the reverse motoring. The motor works, in the reverse direction. Both the speed and the torque have negative values while the power is positive.
In the IV (fourth) quadrant, the torque is positive, and the speed is negative. This quadrant corresponds to the braking in the reverse motoring mode.
4. CHOPPING CIRCUITS:
[7] The voltage from all sources of electrical power varies with time, temperature, and many other factors, especially current. Battery voltage is actually quite well regulated, but frequently there will be a requirement for a change in the voltage to a lower or higher value, usually to control the speed of a motor. Most electronic and electrical equipment requires a fairly constant voltage. This can be achieved by dropping the voltage down to a fixed value below the operating range of the fuel cell or battery or boosting it up to a fixed value. In other cases, it would be desirable to produce a variable voltage (e.g., for a motor) from the more-or-less fixed voltage of a battery. Therefore, a change is required, and it is done using ‘switching’ or ‘chopping’ circuits.
[8] Choppers are used for the control of DC motors because of a number of advantages such as high efficiency, flexibility in control, light weight, small size, quick response, and regeneration down to very low speeds. Presently, the separately excited DC motors are usually used in traction, due to the control flexibility of armature voltage and field. For a DC motor control in open-loop and closed-loop configurations, the chopper offers a number of advantages due to its high operation frequency. High operation frequency results in high-frequency output voltage ripple and, therefore, less ripples in the motor armature current and a smaller region of discontinuous conduction in the speed–torque plane. A reduction in the armature current ripple reduces the armature losses. A reduction or elimination of the discontinuous conduction region improves speed regulation and the transient response of the drive.
OBJECTIVES
- To create a MATLAB code to plot Torque-Speed characteristics of DC motor.
- To understand the difference between power cable and signal cable.
- To understand the battery limits of the battery source in EV.
PROBLEM SPECIFICATION AND SOLVING:
PROBLEM STATEMENT I:
To run MATLAB demo ‘Speed Control of a DC Motor using BJT H-Bridge’. Modify the model such that the armature current does not shoot up when the motor changes the direction from forward to reverse.
EXPLANATION AND OBSERVATION:
- The MATLAB demo ” Speed Control of a DC Motor Using BJT H-Bridge” is available in the following link:
https://in.mathworks.com/help/physmod/sps/ug/speed-control-of-a-dc-motor-using-bjt-h-bridge.html
- By running “power_Hbridge” in the command window of MATLAB, the model opens.
- The model is the simulation of an H-bridge used to generate a chopped voltage and to control the speed of a DC motor.
DESCRIPTION OF THE MATLAB MODEL:
- The Bipolar Junction Transistor (BJT) when used for power switching applications, operates as an IGBT.
- When it is conducting (BJT operating in the saturated region), a forward voltage Vf is developed between collector and emitter (in the range of 1 V).
- Therefore, the IGBT block can be used to model the BJT device.
- The IGBT block does not simulate the gate current controlling the BJT or IGBT. The switch is controlled by a Simulink® signal (1/0).
- The DC motor uses the preset model (5 HP 24V 1750 rpm).
- It simulates a fan type load (where Load torque is proportional to square of speed).
- The armature mean voltage can be varied from 0 to 240 V when the duty cycle (specified in the Pulse Generator block) is varied from 0 to 100%.
- The H-bridge consists of four BJT/Diode pairs (BJT simulated by IGBT models).
- Two transistors are switched simultaneously: Q1 and Q4 or Q2 and Q3.
- When Q1 and Q4 are fired, a positive voltage is applied to the motor and diodes D2-D3 operate as free-wheeling diodes when Q1 and Q4 are switched off.
- When Q2 and Q3 are fired, a negative voltage is applied to the motor and diodes D1-D4 operate as free-wheeling diodes when Q2 and Q3 are switched off.
- The motor starts in the positive direction with a duty cycle of 75% (mean DC voltage of 180V). At t= 0.5 sec., the armature voltage is suddenly reversed and the motor runs in the negative direction.
PROBLEM FORMATION AND SOLUTION:
- The layout of the DC motor using the BJT H-bridge is as follows:
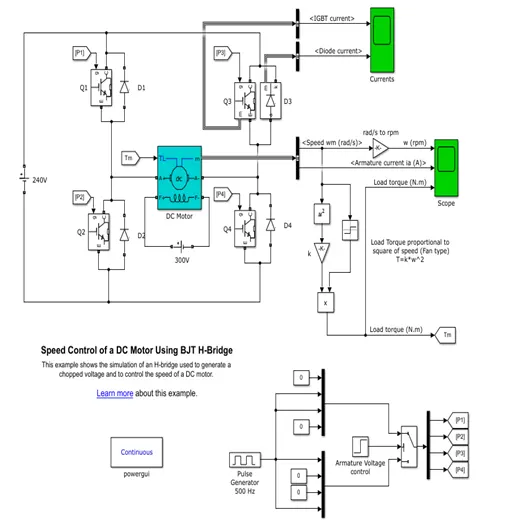
Figure 13. Layout of the “Speed Control of a DC Motor Using BJT H-Bridge”
- The blocks used in the layout are as follows:
- [9] DC MACHINE BLOCK: It implements a wound-field or permanent magnet DC machine. For the wound-field DC machine, access is provided to the field terminals (F+, F−) so that the machine model can be used as a shunt-connected or a series-connected DC machine. The torque applied to the shaft is provided at the Simulink® input TL.
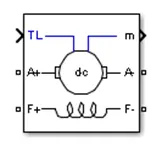
Figure 14. Layout of DC Machine block in MATLAB.
The inputs of as obtained from the block parameters is as follows:
|
Parameter |
Value/Specification |
|
Model |
01: 5HP 240V 1750RPM Field:300V |
|
Mechanical Input |
Torque TL |
|
Initial Speed |
0.001 rad/sec |
|
Sample time(-1 for inherited) |
-1 |
Table 5. Parameters that are predefined for the DC Machine.
- [10] IGBT BLOCK: The IGBT block implements a semiconductor device controllable by the gate signal. The IGBT is simulated as a series combination of a resistor Ron, inductor Lon, and a DC voltage source Vf in series with a switch controlled by a logical signal (g > 0 or g = 0).
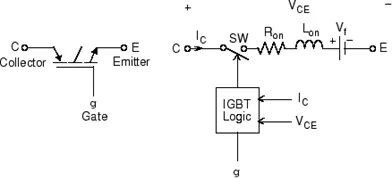
Figure 15. Layout of IGBT.
The IGBT turns on when the collector-emitter voltage is positive and greater than Vf and a positive signal is applied at the gate input (g > 0). It turns off when the collector-emitter voltage is positive, and a 0 signal is applied at the gate input (g = 0). The IGBT device is in the off state when the collector-emitter voltage is negative. Note that many commercial IGBTs do not have the reverse blocking capability.
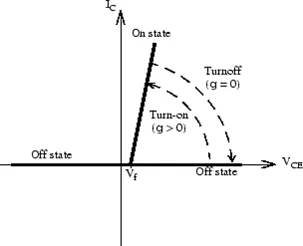
Figure 16. Turn ON-OFF Characteristics of IGBT.
Therefore, they are usually used with an antiparallel diode. The IGBT block contains a series Rs-Cs snubber circuit, which is connected in parallel with the IGBT device (between terminals C and E).The turnoff characteristic of the IGBT model is approximated by two segments. When the gate signal falls to 0, the collector current decreases from Imax to 0.1 Imax during the fall time (Tf), and then from 0.1 Imax to 0 during the tail time (Tt).
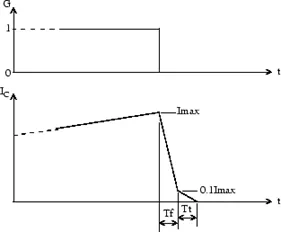
Figure 17. Turn ON-OFF Characteristics of IGBT
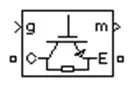
Figure 18. Layout of IGBT block in MATLAB.
The initial default parameters set to IGBT links is defined in the table given below:
|
Parameter |
Value/Specification |
|
Resistance Ron |
0.001 ohms |
|
Forward Voltage Vf |
1 V |
|
Snubber resistance Rs |
1e5 ohms |
|
Snubber capacitance Cs |
Inf F |
Table 6. Predefined parameters for IGBT.
- [11] DIODE BLOCK: The diode is a semiconductor device that is controlled by its own voltage Vak and current Iak.
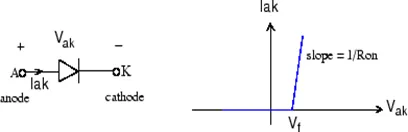
Figure 19. Layout and Characteristics of diode.
When a diode is forward biased (Vak > 0), it starts to conduct with a small forward voltage Vf across it. It turns off when the current flow into the device becomes 0. When the diode is reverse biased (Vak < 0), it stays in the off state.
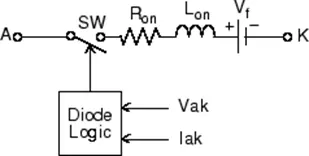
Figure 20. Layout of diode logic.
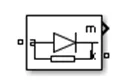
Figure 21. Layout of diode block in MATLAB.
The Diode block is simulated by a resistor, an inductor, and a DC voltage source connected in series with a switch. The switch operation is controlled by the voltage Vak and the current Iak. The Diode block also contains a series Rs-Cs snubber circuit that can be connected in parallel with the diode device (between nodes A and K).The initial default parameters set to Diode links is defined in the table given below:
|
Parameter |
Value/Specification |
|
Resistance Ron |
0.001 ohms |
|
Forward Voltage Vf |
0.8 V |
|
Snubber resistance Rs |
inf ohms |
|
Snubber capacitance Cs |
0 F |
Table 6. Predefined parameters for Diode.
- [12] PULSE GENERATOR BLOCK: The Pulse Generator block generates square wave pulses at regular intervals. The block waveform parameters, Amplitude, Pulse Width, Period, and Phase delay, determine the shape of the output waveform. The following diagram in the Figure 19 shows how each parameter affects the waveform.
In time-based mode, Simulink® computes the block output only at times when the output actually changes. This approach results in fewer computations for the block output over the simulation time period.
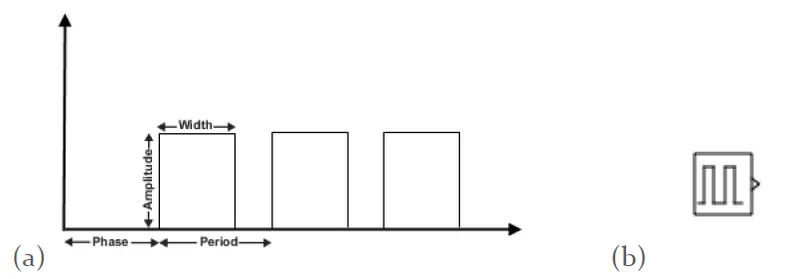
Figure 22. (a) Layout of waveform in pulse Generator depicting different parameters.(b) Layout of Pulse generator in MATLAB.
Activate this mode by setting the Pulse type parameter to Time based. The block does not support a time-based configuration that results in a constant output signal. Simulink returns an error if the parameters Pulse Width and Period satisfy either of these conditions:
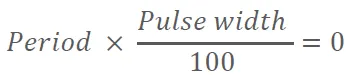
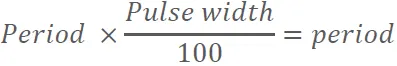
Depending on the pulse waveform characteristics, the intervals between changes in the block output can vary. For this reason, a time-based Pulse Generator block has a variable sample time.
- As per the problem statement, to minimize the surge in the armature current at the start and when motor runs in reverse, the duty cycle is to be modified.
- This can be achieved by modifying the pulse width of the pulse generator which is by default at 75%.
- This is the indicative that the motor receives voltage for 75% of the total time. The remaining 25% of the time, the motor does not receive any voltage.
- The pulsing ON and OFF voltage to the motor results in the spike of the armature current. i.e., it can also be considered as the reversal of armature voltage.
- In order to identify the sudden spike of armature current for different duty cycles, the values of the pulse width percentage is varied as follows:
|
Trial |
Duty cycle |
|
1 |
30 |
|
2 |
40 |
|
3 |
50 |
|
4 |
60 |
|
5 |
75 |
Table 7. Values of duty cycle under the evaluation.
- The pulse generator pulse width is varied as shown in the Figure 23 as mentioned below and the results are obtained accordingly.
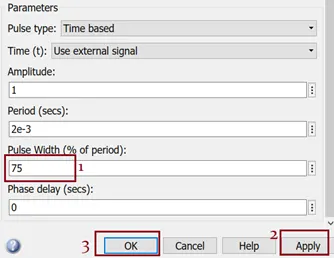
Figure 23. Stepwise variation of the Pulse width of the Pulse generator.
PROBLEM STATEMENT II:
Refer the help section of the ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with H-bridge model.
EXPLANATION AND OBSERVATION:
- The MATLAB demo ” DC7 - Four-Quadrant Chopper 200 HP DC Drive” is available in the following link:
https://in.mathworks.com/help/physmod/sps/ug/dc7-four-quadrant-chopper-200-hp-dc-drive.html?searchHighlight=dc7_example_simplified&s_tid=srchtitle
- By running “dc7_example” in the command window of MATLAB, the model opens.
DESCRIPTION OF THE MATLAB MODEL:
- The 200 HP DC motor is separately excited with a constant 150 V DC field voltage source.
- The armature voltage is provided by an IGBT converter controlled by two PI regulators.
- The converter is fed by a 515 V DC bus obtained by rectification of a 380 V AC 50 Hz voltage source.
- In order to limit the DC bus voltage during dynamic braking mode, a braking chopper has been added between the diode rectifier and the DC7 block.
- The first regulator is a speed regulator, followed by a current regulator. The speed regulator outputs the armature current reference (in p.u.) used by the current controller in order to obtain the electromagnetic torque needed to reach the desired speed.
- The speed reference change rate follows acceleration and deceleration ramps in order to avoid sudden reference changes that could cause armature over-current and destabilize the system.
- The current regulator controls the armature current by computing the appropriate duty ratios of the 5 kHz pulses of the four IGBT devices (Pulse Width Modulation).
- For proper system behavior, the instantaneous pulse values of IGBT devices 1 and 4 are opposite to those of IGBT devices 2 and 3.
- This generates the average armature voltage needed to obtain the desired armature current.
- In order to limit the amplitude of the current oscillations, a smoothing inductance is placed in series with the armature circuit.
PROBLEM FORMATION AND SOLUTION:
- The layout of DC7 - Four-Quadrant Chopper 200 HP DC Drive is as follows:
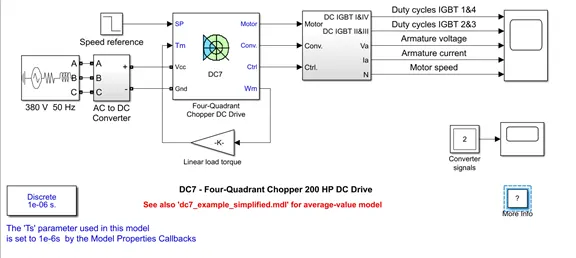
Figure 24. Layout of the DC7-Four Quadrant Chopper 200 HP DC Drive.
- The blocks used in the layout are as follows:
- [13] FOUR-QUADRANT CHOPPER DC DRIVE BLOCK: The Four-Quadrant Chopper DC Drive (DC7) block represents a four-quadrant, DC-supplied, chopper (or DC-DC PWM converter) drive for DC motors. This drive features closed-loop speed control with four-quadrant operation. The speed control loop outputs the reference armature current of the machine. Using a PI current controller, the chopper duty cycle corresponding to the commanded armature current is derived. This duty cycle is then compared with a sawtooth carrier signal to obtain the required PWM signals for the chopper.
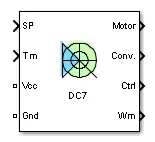
Figure 25. Layout of the Four Quadrant Chopper DC Drive block in MATLAB.
The main advantage of this drive, compared with other DC drives, is that it can operate in all four quadrants (forward motoring, reverse regeneration, reverse motoring, and forward regeneration). In addition, due to the use of high switching frequency DC-DC converters, a lower armature current ripple (compared with thyristor-based DC drives) is obtained. However, four switching devices are required, which increases the complexity of the drive system.
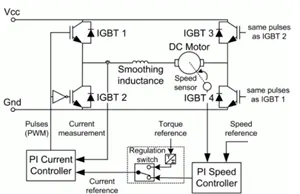
Figure 26. Layout of Four quadrant DC Chopper block.
The Four-Quadrant Chopper DC Drive block uses these blocks from the Electric Drives/Fundamental Drive Blocks library are Speed Controller (DC), Regulation Switch, Current Controller (DC)and Chopper. The input parameters of the Four Quadrant DC Chopper Block are as follows:
|
Parameter |
Value/Specification |
|
Mutual Inductance |
3.320 H |
|
Armature resistance |
0.076 ohm |
|
Armature Inductance |
0.00157 H |
|
Field Resistance |
310 ohm |
|
Field Inductance |
232.25 H |
|
Mechanical Input |
Torque Tm |
|
Smoothing Inductance |
1e-3 H |
|
Excitation circuit field DC source |
310 V |
|
Controller regulation type 1 |
Speed regulation |
|
Nominal speed |
1184 rpm |
|
Initial speed reference |
0 rpm |
|
Low-pass filter cutoff frequency |
40 Hz |
|
Sampling time 1 |
100e-6 seconds |
|
Controller Regulation type 2 |
Current regulation |
|
Low-pass filter cutoff frequency |
500 Hz |
|
Reference limit |
1.5 p.u. |
|
PWM switching frequency |
5e3 Hz |
|
Sampling time 2 |
20e-6 seconds |
|
Base sample time |
1e-06 seconds |
|
Output bus mode |
Multiple output busses |
Table 8. Predefined parameters of Four Quadrant DC Chopper Block.
- [14] THREE PHASE SOURCE BLOCK: The Three-Phase Source block implements a balanced three-phase voltage source with an internal R-L impedance. The three voltage sources are connected in Y with a neutral connection that can be internally grounded or made accessible. You can specify the source internal resistance and inductance either directly by entering R and L values or indirectly by specifying the source inductive short-circuit level and X/R ratio.
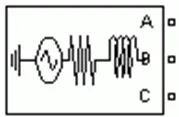
Figure 27. Layout of Three Phase Source block in MATLAB.
The input parameters of the Three Phase Source Block are as follows:
|
Parameter |
Value/Specification |
|
Configuration |
Yg |
|
Phase-to-Phase Voltage Vrms |
380 V |
|
Phase angle of Phase A |
0 degrees |
|
Frequency |
50 Hz |
|
Source resistance |
0.01 ohms |
|
Source inductance |
0.1e-3 H |
|
Base Voltage |
0 V |
|
Generator type |
Swing |
Table 9. Predefined parameters of Three Phase Source Block.
- AC TO DC CONVERTER: This is a subsystem in the given layout, and it comprises of Universal (rectifier in this case) Bridge and a braking Chopper as shown in the Figure below.
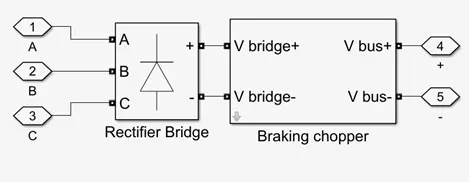
Figure 28. Layout of AC TO DC Converter.
- [15]UNIVERSAL BRIDGE: The Universal Bridge block implements a universal three-phase power converter that consists of up to six power switches connected in a bridge configuration. The type of power switch and converter configuration are selectable from the dialog box. The Universal Bridge block allows simulation of converters using both naturally commutated (or line-commutated) power electronic devices (diodes or thyristors) and forced-commutated devices (GTO, IGBT, MOSFET). The Universal Bridge block is the basic block for building two-level voltage-sourced converters (VSC). The device numbering is different if the power electronic devices are naturally commutated or forced-commutated.
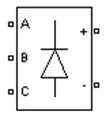
Figure 29. Layout of Universal Bridge block in MATLAB.
For a naturally commutated three-phase converter (diode and thyristor), numbering follows the natural order of commutation:
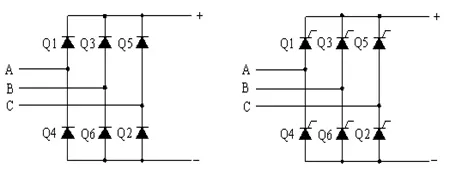
Figure 30. Layout of Naturally commutated three phase converter.
The input values of the universal Bridge block are tabulated below:
|
Parameters |
Value/Specification |
|
Number of Bridge arms |
3 |
|
Snubber Resistance Rs |
10e3 ohms |
|
Snubber capacitance Cs |
900e-9 H |
|
Power Electronic device |
Diodes |
|
Ron |
1e-3 ohms |
|
Lon |
0 H |
|
Forward Voltage Vf |
1.3 V |
Table 9. Predefined parameters of Universal bridge block.
- [16] BRAKING CHOPPER: This block limits the dc bus voltage during braking mode. This is made of a system as shown in the figure below:
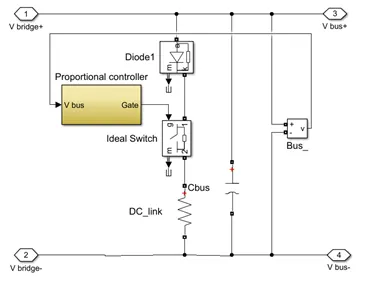
Figure 31. Layout of Braking chopper subsystem.
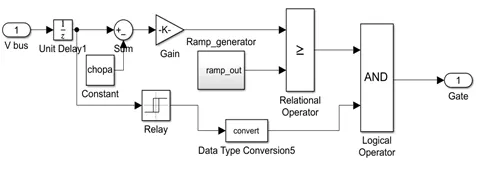
Figure 32. Layout of Proportional Controller subsystem.
The inputs given to the Braking Chopper subsystem are tabulated below:
|
Parameter |
Value/Specification |
|
Chopper Voltage activation |
560 V |
|
Chopper Voltage shutdown |
520 V |
|
Braking Chopper frequency |
4000 Hz |
|
Capacitance |
7500e-6 F |
|
Braking resistor |
8 ohm |
Table 10. Predefined parameters of Braking Chopper.
- The difference between the DC7-Four Quadrant Chopper 200 HP DC Drive and Speed Control of a DC Motor Using BJT H-Bridge are tabulated below:
|
DC7-Four Quadrant Chopper 200 HP DC Drive Model |
Speed Control of a DC Motor Using BJT H-Bridge Model |
|
Connected to an AC power source with an AC to DC converter. AC : 380 V, 50 Hz, 3 Phase. DC : 515 V |
Connected to a constant DC power supply. AC: 0 DC: 240 V |
|
Mechanical input is Motor Torque Tm. |
Mechanical input is the Load Torque TL. |
|
This DC motor is separately excited with a constant 150 V DC field voltage source. |
The DC motor is separately excited with a constant 300 V Field Voltage source. |
|
Power rating : 200 Hp. |
Power rating : 5 Hp. |
|
The speed of the motor is 1184 rpm. |
The speed of the motor is 1750 rpm. |
|
This displays four quadrant behavior i.e., Forward Braking, Forward motoring, Reverse motoring, and Reverse braking. |
This only displays two quadrant behavior i.e., Forward motoring and reverse motoring. |
|
A chopper is a device that is capable of producing variable voltage from a more or less, a fixed voltage source by chopping or switching the circuits. |
An H-bridge is an electronic circuit that switches the polarity of a voltage applied to a load. |
|
This model contains speed and current controllers in the power converter circuit. |
This model has no controllers in the power converter circuit. |
|
The speed and current controller modify accordingly and result in change in the rotation of the motor. |
The polarity of the current in this model (at every 0.5 seconds) the rotation of the motor is changed. |
|
In order to limit the amplitude of the current oscillations, a smoothing inductance is placed in series with the armature circuit. |
There is always a sharp changes/ oscillations in the current and there is no inductance to reduce these changes in this model. |
|
This model adapts active control. |
This relies on passive control. |
|
This model is more of conventional type and torque is linearly proportional to the speed. |
This model simulates a fan type load (where Load torque is proportional to square of speed |
|
This model computes the appropriate duty ratios for IGBT devices. (Pulse Width Modulation) |
This model allows the user to alter the duty cycle ratio for the IGBT devices. (Pulse Width Modulation) |
Table 10. Comparison of DC7-Four Quadrant Chopper 200 HP DC Drive and Speed Control of a DC Motor Using BJT H-Bridge.
PROBLEM STATEMENT III:
Develop a 2-quadrant chopper & explain the working of the same with the relevant results.
EXPLANATION AND OBSERVATION:
- [8] CLASS C TWO-QUADRANT CHOPPER: In some applications, a smooth transition from motoring to braking and vice versa is required. For such applications, the class C chopper is used as shown in Figure 31. The self-commutated semiconductor switch S1 and diode D1 constitute one chopper and the self-commutator switch S2 and diode D2 form another chopper. Both the choppers are controlled simultaneously, both for motoring and regenerative braking.
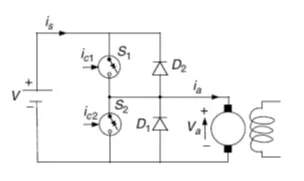
Figure 33. Forward motoring and regenerative braking control using class C two-quadrant chopper circuit.
The switches S1 and S2 are closed alternately. In the chopping period T, S1 is kept on for a duration δT, and S2 is kept on from δT to T. To avoid a direct, short-circuit across the source, care is taken to ensure that S1 and S2 do not conduct at the same time. This is generally achieved by providing some delay between the turn off of one switch and the turn on of another switch. The waveforms of the control signals va ia and is and the devices under conducting during different intervals of a chopping period are shown in Figure 33. In drawing these waveforms, the delay between the turn off of one switch and the turn on of another switch has been ignored because it is usually very small. The control signals for the switches S1 and S2 are denoted by ic1 and ic2, respectively. It is assumed that a switch conducts only when the control signal is present, and the switch is forward biased. The following points are helpful in understanding the operation of this two-quadrant circuit:
- In this circuit, discontinuous conduction does not occur, irrespective of its frequency of operation. Discontinuous conduction occurs when the armature current falls to zero and remains zero for a finite interval of time. The current may become zero either during the freewheeling interval or in the energy transfer interval. In this circuit, freewheeling will occur when S1 is off, and the current is flowing through D1. This will happen in interval δT ≤ t ≤ T, which is also the interval for which S2 receives the control signal. If ia falls to zero in the freewheeling interval, the back EMF will immediately drive a current through S2 in the reverse direction, thus preventing the armature current from remaining zero for a finite interval of time. Similarly, energy transfer will be present when S2 is off and D2 is conducting — that is, during the interval 0 ≤ t ≤ δT. If the current falls to zero during this interval, S1 will conduct immediately because ic is present and V > E. The armature current will flow, preventing discontinuous conduction.
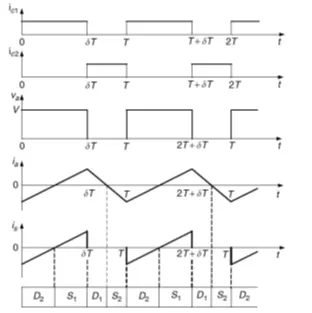
Figure 34. Forward motoring and regenerative braking control using class C two-quadrant chopper waveforms.
- Since discontinuous conditions are absent, the motor current will be flowing all the time. Thus, during the interval 0 ≤ t ≤ δT, the motor armature will be connected either through S1 or D2. Consequently, the motor terminal voltage will be V and the rate of change of ia will be positive because V > E. Similarly, during the interval δT ≤ t ≤ T, the motor armature will be shorted either through D1 or S2. Consequently, the motor voltage will be zero and the rate of change of ia will be negative.
- During the interval 0 ≤ t ≤ δT, the positive armature current is carried by S1 and the negative armature current is carried by D2. The source current flows only during this interval and it is equal to ia. During the interval δT ≤ t ≤ T, the positive current is carried by D1 and the negative current is carried by S2.
- From the motor terminal voltage waveform of Figure 34, Va = δV. Hence,
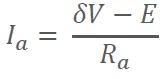 ...(3)
Equation (3) suggests that the motoring operation takes place when δ > E/V, and that regenerative braking occurs when δ < E/V. The no-load operation is obtained when δ = E/V.
- The layout of the two-quadrant chopper is as follows:
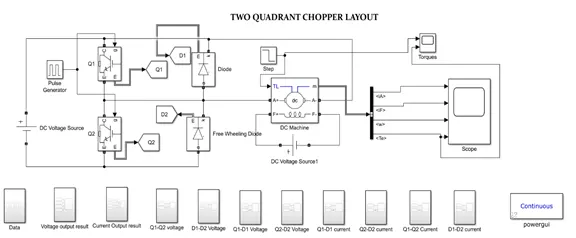
Figure 35. Layout of two-Quadrant chopper in Simulink.
- The layout of the Two-Quadrant chopper is taken from the Figure 33. In this, Two IGBT blocks and two diode blocks are considered. A DC machine is employed to impart the inductance required by the chopper circuit. An external DC voltage source of 240 V is supplied. A separate excited field voltage of 300V is given to the F terminal of the DC machine.
- The load torque (TL) input is given by using a step block. For simulation time (1 sec) greater than or equal to the Step time (1 sec), the output is the Final value parameter value.
- The initial value is set to 1000 and final value is set to 100 in the step function generator. The sample time is kept at 0.
- The initial default parameters set to IGBT links is defined in the table given below:
|
Parameter |
Value/Specification |
|
Resistance Ron |
0.001 ohms |
|
Forward Voltage Vf |
1 V |
|
Snubber resistance Rs |
1e5 ohms |
|
Snubber capacitance Cs |
Inf F |
Table 11. Predefined parameters for IGBT.
- The IGBT blocks are assumed to take the same values. The IGBTs are named as Q1 and Q2. The ‘m’ ports of the IGBTs i.e., Q1 and Q2 are connected to GoTo blocks named Q1 and Q2, respectively.
- Since both Q1 and Q2 are to be connected in series, the ‘E’ port of Q1 is connected to the ‘E’ port of Q2. The ‘C’ port of Q1 is connected to the positive terminal of the DC Voltage supply of 240 V and the ‘E’ port of the Q2 is connected to the negative terminal of the DC Voltage supply.
- The ‘g’ port of the IGBT takes the input as gate pulses. Therefore, pulse generator block is connected to both the ‘g’ ports of the IGBTs, and the following gives the details of the parameters given to the pulse generator:
|
Parameter |
Value/Specification |
|
Pulse type |
Time based |
|
Time (t) |
Simulation time |
|
Amplitude |
1 |
|
Period |
0.002 seconds |
|
Pulse width (% of period) |
75 |
|
Phase delay |
0 |
Table 12. Predefined parameters for Pulse generator block.
- The diodes are connected in parallel to the IGBTs. The diode parallel to Q2 is called Free Wheeling diode. The ‘m’ ports of the Diodes i.e., D1 and D2 are connected to GoTo blocks named D1 and D2, respectively.
- The ‘a’ port of the diode D1 is connected to the ‘k’ port of the Free-Wheeling Diode i.e., D2.
- The ‘k’ port of the diode D1 is connected to the positive terminal of the DC Voltage Supply of 240 V and the ‘a’ port of the Diode D2 is connected to the negative terminal of the DC Voltage supply.
- The initial default parameters set to Diode links is defined in the table 13 as given below.
|
Parameter |
Value/Specification |
|
Resistance Ron |
0.001 ohms |
|
Forward Voltage Vf |
0.8 V |
|
Snubber resistance Rs |
inf ohms |
|
Snubber capacitance Cs |
0 F |
Table 13. Predefined parameters for Diode.
- The left armature port ‘A’ of the DC machine is connected to the mid connections of Q1 and Q2 along with the mid connections of the diodes D1 and D2. The right side ‘A’ port of the DC Machine is connected to the negative terminal of the DC voltage source.
- The TL port of the DC machine is connected to the step block. The ‘m’ port of the DC Machine is connected to the scope to give the pictographic representation of the variation of armature current, field current, angular velocity and electromechanical torque in the scope through the bus selector.
- The input value to the TL port and the electromechanical torque is connected to the scope along with the electromechanical torque obtained from the ‘m’ port of the DC Machine.
- The inputs of as obtained from the DC Machine block parameters is as follows:
|
Parameter |
Value/Specification |
|
Model |
01: 5HP 240V 1750RPM Field:300V |
|
Mechanical Input |
Torque TL |
|
Initial Speed |
0.001 rad/sec |
|
Sample time(-1 for inherited) |
-1 |
Table 14. Parameters that are predefined for the DC Machine.
- The GoTo blocks from both IGBT and Diode blocks through their ‘m’ ports will each give two outputs namely Voltage and Current. As a result, there are four current values, and four voltage values as follows:
Q1 current, Q2 current, D1 current, D2 current; Q1 voltage, Q2 voltage, D1 voltage, D2 voltage.
- Each block’s (IGBT and Diode) value of voltage and current is available in the subsystem named as ‘Data’.
- Different subsystems are created to understand the variations of voltages and currents of different blocks with respect to one another.
- The total simulation time is set to 1 sec and the different voltages and currents are evaluated and the simulation is performed resulting in appropriate pictographic solutions in scope.
PROBLEM STATEMENT IV:
Explain in a brief about operation of BLDC motor.
[8] By using high-energy permanent magnets as the field excitation mechanism, a permanent magnet motor drive can be potentially designed with high power density, high speed, and high operation efficiency. These prominent advantages are quite attractive to the application on electric and hybrid electric vehicles. Of the family of permanent magnetic motors, the brush-less DC (BLDC) motor drive is the most promising candidate for EV and HEV application.
A BDLC motor drive consists mainly of the brush-less DC machine, a DSP based controller, and a power electronics-based power converter, as shown in Figure 35. Position sensors H1, H2, and H3 sense the position of the machine rotor. The rotor position information is fed to the DSP-based controller, which, in turn, supplies gating signals to the power converter by turning on and turning off the proper stator pole windings of the machine. In this way, the torque and speed of the machines are controlled.
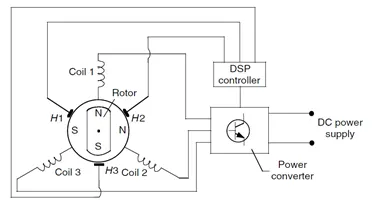
Figure 35. Layout of Brushless DC Motor.
BLDC machines can be categorized by the position of the rotor permanent magnet, the way in which the magnets are mounted on the rotor. The magnets can either be surface-mounted or interior-mounted. Figure 36(a) shows the surface-mounted permanent magnet rotor. Each permanent magnet is mounted on the surface of the rotor. It is easy to build, and specially skewed poles are easily magnetized on this surface-mounted type to minimize cogging torque. But there is a possibility that it will fly apart during high-speed operations. Figure 36(b) shows the interior-mounted permanent magnet rotor. Each permanent magnet is mounted inside the rotor. It is not as common as the surface-mounted type, but it is a good candidate for high-speed operations. Note that there is inductance variation for this type of rotor because the permanent magnet part is equivalent to air in the magnetic circuit calculation.
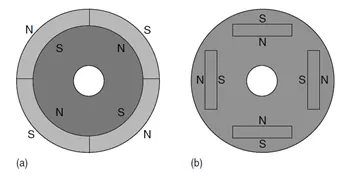
Figure 36 (a). Layout of surface-mounted permanent magnet rotor. (b) Layout of the interior-mounted permanent magnet rotor.
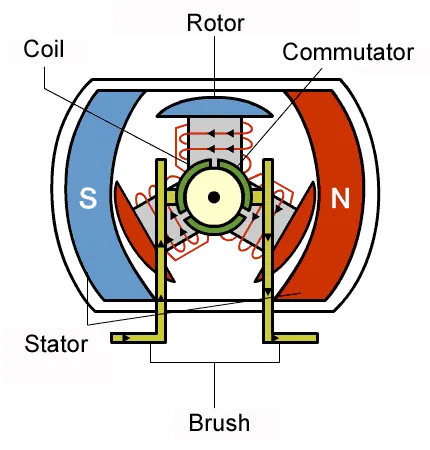
Figure 37. Working of BLDC motor.
In the case of the stator windings, there are two major classes of BLDC motor drives, both of which can be characterized by the shapes of their respective back EMF waveforms: trapezoidal and sinusoidal. The trapezoidal-shaped back EMF BLDC motor is designed to develop trapezoidal back EMF waveforms. It has the following ideal characteristics:
- Rectangular distribution of magnet flux in the air gap
- Rectangular current waveform
- Concentrated stator windings.
Excitation waveforms take the form of quasisquare current waveforms with two 60º electrical intervals of zero current excitation per cycle. The nature of the excitation waveforms for trapezoidal back EMF permits some important system simplifications compared to sinusoidal back EMF machines. In particular, the resolution requirements for the rotor position sensor are much lower since only six commutation instants are necessary per electrical cycle. Figure 38 shows the winding configuration of the trapezoidal-shaped back EMF BLDC machine.
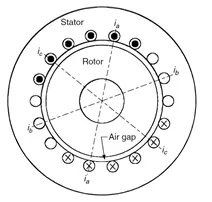
Figure 38. Layout of Winding configuration of the trapezoidal-shaped back EMF BLDC.
Figure 39(a) shows an equivalent circuit and 39 (b) shows trapezoidal back EMF, current profiles, and Hall sensor signals of the three-phase BLDC motor drive. The voltages seen in this figure, ea, eb, and ec, are the line-to-neutral back EMF voltages, the result of the permanent-magnet flux crossing the air gap in a radial direction and cutting the coils of the stator at a rate proportional to the rotor speed. The coils of the stator are positioned in the standard three-phase full-pitch, concentrated arrangement, and thus the phase trapezoidal back EMF waveforms are displaced by 120º electrical degrees. The current pulse generation is a “120º on and 60º off” type, meaning each phase current is flowing for two thirds of an electrical 360º period, 120º positively and 120º negatively. To drive the motor with maximum and constant torque/ampere, it is desired that the line current pulses be synchronized with the line-neutral back EMF voltages of the particular phase.
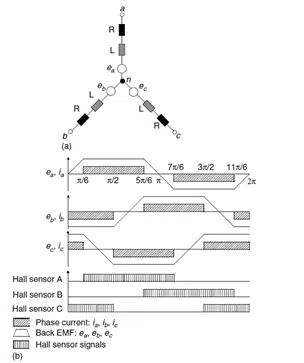
Figure 39. Layout of (a) Three-phase equivalent circuit and (b) back EMFs, currents, and Hall sensor signals of a BLDC motor.
A sinusoidal-shaped back EMF BLDC motor is designed to develop sinusoidal back EMF waveforms. It has the following ideal characteristics:
- Sinusoidal distribution of magnet flux in the air gap
- Sinusoidal current waveforms
- Sinusoidal distribution of stator conductors.
The most fundamental aspect of the sinusoidal-shaped back EMF motor is that the back EMF generated in each phase winding by the rotation of the magnet should be a sinusoidal wave function of rotor angle. The drive operation of the sinusoidal-shaped back EMF BLDC machine is similar to the AC synchronous motor. It has a rotating stator MMF wave like a synchronous motor and therefore can be analyzed with a phasor diagram. Figure 40 shows the winding configuration of the sinusoidal-shaped back EMF BLDC machine.
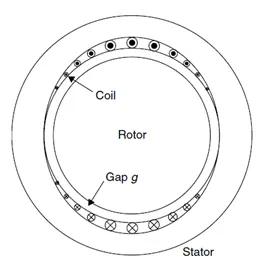
Figure 40. Layout of Winging configuration of sinusoidal-shaped back EMF BLDC.
ADVANTAGES:
|
Feature |
Explanation |
|
High Efficiency |
BLDC motors are the most efficient of all electric motors. This is due to the use of permanent magnets for the excitation, which consume no power. The absence of a mechanical commutator and brushes means low mechanical friction losses and therefore higher efficiency. |
|
Compactness |
The recent introduction of high-energy density magnets (rare-earth magnets) has allowed achieving very high flux densities in the BLDC motor. This makes it possible to achieve accordingly high torques, which in turns allows making the motor small and light. |
|
Ease of Control |
The BLDC motor can be controlled as easily as a DC motor because the control variables are easily accessible and constant throughout the operation of the motor. |
|
Ease of Cooling |
There is no current circulation in the rotor. Therefore, the rotor of a BLDC motor does not heat up. The only heat production is on the stator, which is easier to cool than the rotor because it is static and on the periphery of the motor. |
|
Low maintenance, great longevity, reliability |
The absence of brushes and mechanical commutators suppresses the need for associated regular maintenance and suppresses the risk of failure associated with these elements. The longevity is therefore only a function of the winding insulation, bearings, and magnet life-length. |
|
Low noise emissions |
There is no noise associated with the commutation because it is electronic and not mechanical. The driving converter switching frequency is high enough so that the harmonics are not audible. |
Table 15. Advantages of the Brushless DC Motor.
LIMITATIONS:
|
Feature |
Explanation |
|
Cost (expensive) |
Rare-earth magnets are much more expensive than other magnets and result in an increased motor cost. |
|
Limited constant power range |
A large constant power range is crucial to achieving high vehicle efficiencies. The permanent magnet BLDC motor is incapable of achieving a maximum speed greater than twice the base speed. |
|
Safety |
Large rare-earth permanent magnets are dangerous during the construction of the motor because they may attract flying metallic objects toward them. In case of vehicle wreck, if the wheel is spinning freely, the motor is still excited by its magnets and high voltage is present at the motor terminals that can possibly endanger the passengers or rescuers. |
|
Magnet Demagnetization |
Magnets can be demagnetized by large opposing mmfs and high temperatures. The critical demagnetization force is different for each magnet material. Great care must be exercised when cooling the motor, especially if it is built compact. |
|
High-speed capability |
The surface-mounted permanent magnet motors cannot reach high speeds because of the limited mechanical strength of the assembly between the rotor yoke and the permanent magnets. |
|
Inverter failures in BLDC motor drives |
Because of the permanent magnets on the rotor, BLDC motors present major risks in case of short circuit failures of the inverter. Indeed, the rotating rotor is always energized and constantly induces an EMF in the short-circuited windings. A very large current circulates in those windings and an accordingly large torque tends to block the rotor. The dangers of blocking one or several wheels of a vehicle are nonnegligible. If the rear wheels are blocked while the front wheels are spinning, the vehicle will spin uncontrollably. If the front wheels are blocked, the driver has no directional control over the vehicle. If only one wheel is blocked, it will induce a yaw torque that will tend to spin the vehicle, which will be difficult to control. In addition to the dangers to the vehicle, it should be noted that the large current resulting from an inverter short circuit poses a risk of demagnetizing and destroying the permanent magnets. |
Table 16. Limitations of the Brushless DC Motor.
RESULTS
- The following are the plots that are obtained by varying the duty cycles according to the data mentioned in the Table 5.
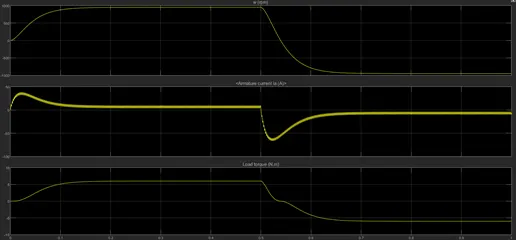
Figure 41. Results of DC motor under 75% duty cycle.
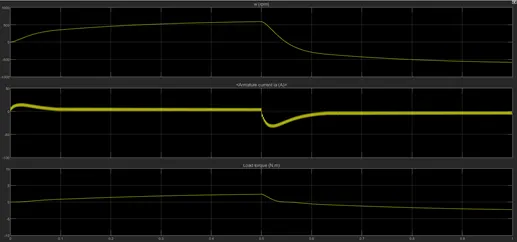
Figure 42. Results of DC motor under 60% duty cycle.
From the 75% duty cycle results, as it is the default state, it can be observed that the spike in the armature current after 0.5 seconds is quite sharp. This sudden change in the polarity of the armature current causes the motor to change the direction of rotation. The maximum armature current in this state is 38.4 A and -66.74A is the minimum value of the armature current. At 0.5 seconds, the angular velocity attains the maximum value of 950.9rpm and experiences a decrement in its value indicating the possibility of regenerative braking, for about 0.2 seconds and continues in almost linear path with a constant value of -950 rpm (approximately) until the end of the simulation. The torque load, since it is proportional to the square of the velocity, as mentioned, will represent similar trend to that of the velocity. It exhibits the maximum value of 6 Nm at 0.5 seconds and later by the end of 0.7 seconds, assumes a constant value of -5.9 Nm. This sudden spike may result in the damage of the DC motor and is not advisable.
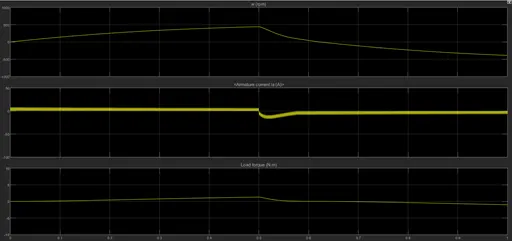
Figure 43. Results of DC motor under 50% duty cycle.
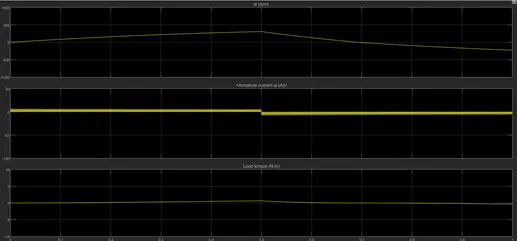
Figure 44. Results of DC motor under 40% duty cycle.
As the duty ratio is decreased i.e., by regulating the pulse width percentage from 75 (default) to 30, it can be observed that the spike in the armature current is being reduced. The angular velocity and torque profiles also align on the similar terms. This is due to the fact that out of the total current, smaller amount of it is being given to the motor and as a result, the spike in the armature current when the polarity changes is controlled and almost constant as observed in the results obtained when the duty cycle ratio is maintained at 30%.
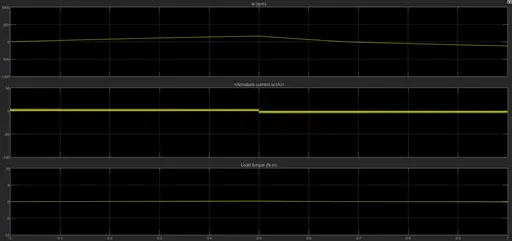
Figure 45. Results of DC motor under 30% duty cycle.
In the above case, at 30% duty cycle, the value of positive and negative armature currents is numerically same, and the value of the current remains constant in the positive and the negative cycle. The value of the current is less compared to that of the default cycle, and this is due to the fact that the voltage given to the motor is for a very short time period. This results in the changing of the armature current rapidly and the change is smooth.
- The result of simulation of the DC7-Four Quadrant Chopper 200 HP DC Drive:
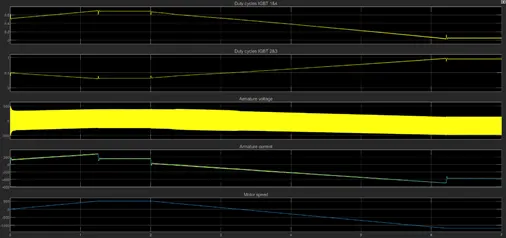
Figure 46. Results of DC7- Four Quadrant Chopper 200 HP DC Drive.
It can be observed that, unlike the case of DC Motor incorporated with H-bridge circuit, the armature current in the four-quadrant chopper DC drive has smooth transitions in the polarity of the current that impacts the rotation of the motor. This is due to the presence of the speed and current control regulators and smoothing inductance. This results in the balanced armature current spike as compared to that observed with the case involving a H-bridge. It can also be observed that this does not come with the compromise in the voltage supply time to the motor. The variations in the speed and torque are much refined and as a result, braking operation can be performed by this chopper unit is much smoother and therefore, find their application in automobiles. The H-bridge circuits are also capable of producing similar effect, but the operation is more suitable for robotics and electromechanical devices. Since chopper imitates switching, the loss of energy during the change of current flow is minimal as compared to H-bridge which involve polarity reversal under spiked conditions which is harder to control.
- A two-quadrant chopper is designed and is simulated. The results are displayed as follows:
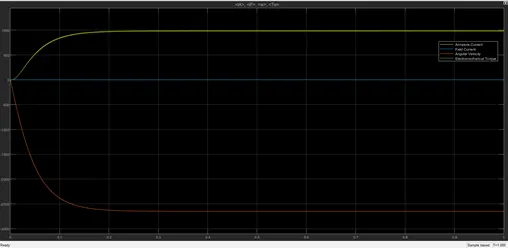
Figure 47. Results containing armature current, field current, angular velocity and electromechanical torque of the two-quadrant chopper system.
In this system, it can be observed that the Field current value (in blue) assumes a constant value of zero throughout the simulation time. It is safe to assume that the angular velocity of the motor ( in red) exponentially reduced up to 03 seconds and later assumes a constant value till the end of the simulation time. The point of inflexion of the angular velocity matches with the corresponding points of inflexion of armature current and torque. The angular velocity initially begins with 0 and continues to achieve a maximum of -2600 rpm (approximately) by the end of simulation.
The paths of armature current and the electromechanical torque are almost parallel which states as an indicative that the armature current effects the electromechanical torque. Initially, the armature current starts by assuming 0A and then for a very short time frame experiences a dip in its value which is negative about -0.04 A. Then it increases attains the highest value of 980 A. Similarly, the electromechanical torque exhibits its least value of -3.27 Nm exactly at the location where the armature current dips to its least value. Eventually, by the end of the simulation, the torque reaches its maximum value of 992 Nm by the end of simulation. By theory, the torque produced in the armature is directly proportional to the flux per pole and the armature current. If the armature current or the flux per pole is reversed, the electromechanical torque is also reversed. But in this case, they both seem to be in the same polarity for most of the simulation time except during the start where they assume negative values indicating the change in the polarity.
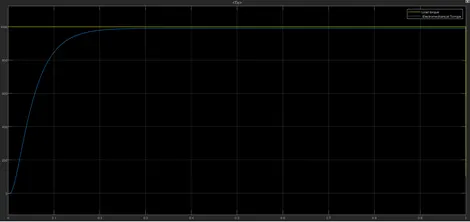
Figure 48. Variation of the input load torque and the output electromechanical torque.
It can be observed from the Figure 46, that the input load torque is constant while the electromechanical torque starts from 0Nm, reaches its minimum value, and then exponentially increases up to 0.3 sec and then almost linear attaining its highest value by the end of the simulation. By theory, when load torque equals the electromechanical torque, the motor runs steadily at constant speed. Therefore, almost after 0.3 sec, both the torque values are almost equal, and it is safe to assume that the motor in the time frame from 0.3 sec – 1 sec more stable than during the starting 0.3 sec.
From the figure 49, it can be observed that the voltages of both IGBT blocks and Diode blocks possess positive and negative values. It can also be observed that the graphical representation of the voltages is in the form of step function for all the blocks. The absolute numerical values of maximum and minimum voltages for both the blocks is the same.
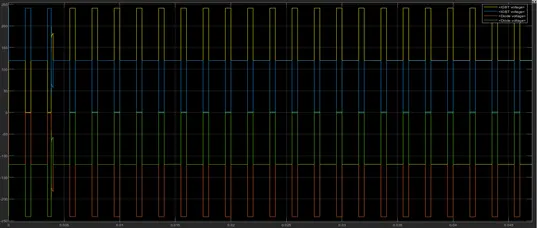
Figure 49. Variation of the Voltages of Q1 (yellow), Q2(blue), D1 (red) and D2 (green) in exaggerated view.
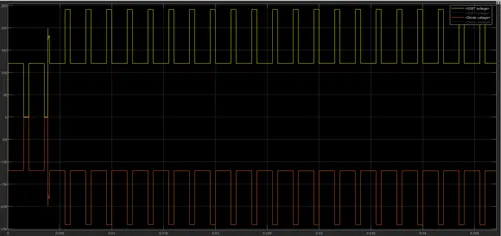
Figure 50. Variation of the Voltages of Q1 (yellow) and D1 (red) ,in exaggerated view.
The Q1 and D1 together form the chopper unit 1. The freewheeling will occur when Q1 is off, and the current is flowing through D1. During the same time interval, S2 receives the control signal as shown in the Figure 51. The freewheel diode is usually connected across the inductive coils to prevent voltage spikes in the case of the power getting turned off to the devices. There will be sharp voltage spike when power to inductive load, i.e., coils and other inductors is turned off. Then, according to Lenz law the direction of this voltage will be opposite to the applied voltage. The coil of the relay gets magnetically charged when current starts to flow and stores the energy in the magnetic field around the coil. Therefore, the voltage of the diode D1 will be negative since the applied voltage is positive. When the IGBT is ON, freewheeling diode will be in reverse biased and will not exist in a circuit. When the IGBT is OFF, Freewheeling diode will be forward biased. The freewheeling diode will make the inductor to draw current from itself in a form of loop until the whole energy is dissipated in wires and diode. In the absence of the freewheeling diode, the IGBT experiences severe damage due to voltage spikes.
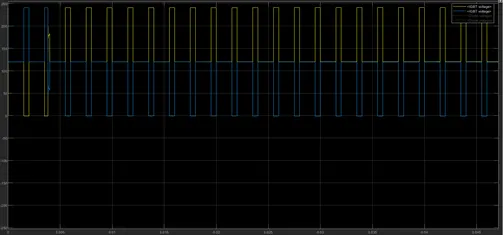
Figure 51. Variation of the Voltages of Q1(yellow) and Q2 (blue) in exaggerated view.
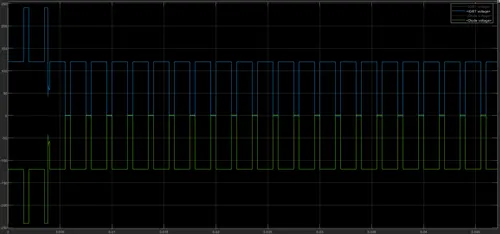
Figure 52. Variation of the Voltages of Q2 (blue) and D2 (green) ,in exaggerated view.
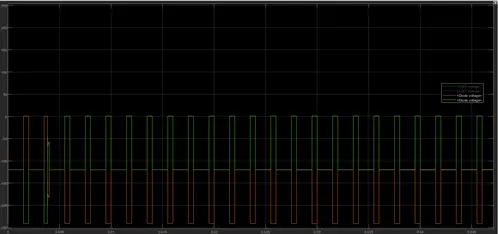
Figure 53. Variation of the Voltages of D1(red) and D2 (green) in exaggerated view.
The IGBT Q2 and the diode D2 form the chopper unit II. Similarly, just like the case of the chopper unit I, the energy transfer will be present when D2 is off and D2 is conducting and during the same time interval, the IGBT Q1 is on. This can be observed from the Figure 52. It can be observed that, there is no one condition where the supply is cut off. This is an indicative of a continuous system which is more advantageous as compared to incorporating H-bridge system.
The figure 54 displays the variation of the IGBT and diode currents. It can be observed that the value and the variation of the current in both the IGBTs i.e., Q1 and Q2 remain the same and hence an overlap is seen in the graph. Similarly, the diode current values are very small and are observed to take the constant value. The current in both the IGBTs take the form of a step function. It can be observed that even when the voltages were negative, the currents of both the choppers remain positive throughout the simulation.
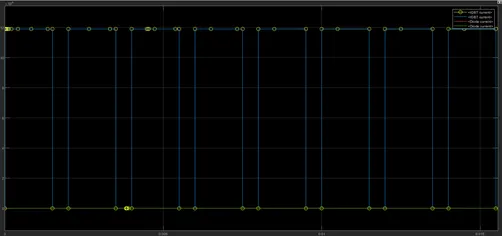
Figure 54. Variation of the Current of Q1 (yellow), Q2(blue), D1 (red) and D2 (green) in exaggerated view.
- The BDLC’s are very similar to the induction motor, in the terms of alternating current. Unlike the induction motors which require current at constant frequency obtained from AC source, the BDLC’s require the current with varied alternating frequency which is obtained by the DC source. Just like the ordinary DC motors, the torque reduces as the speed increases. The rotating magnet produces back EMF in the coil with is proportional to the speed of the rotation and decreases the current in the coil. As a result, the magnetic field is reduced and in turn reduces the torque. The maximum speed is obtained when the back EMF equals the supply voltage. These find applications as a generator of electricity, in regenerative or dynamic braking systems, in computer applications to drive the moving parts of disc storage and fans, and sophisticated electric vehicle drive motors. Although, these require strong permanent magnet, the current need not be induced in the rotor, which is the case for the induction motors. As a result, the BDLC’s have more specific power as compared to induction motors and hence display greater efficiency.
BIBLIOGRAPHY
- https://en.wikipedia.org/wiki/Bipolar_junction_transistor
- https://www.electrical4u.com/bipolar-junction-transistor-or-bjt-n-p-n-or-p-n-p-transistor/
- https://components101.com/articles/understanding-bjt-transistor-and-how-to-use-it-in-your-circuit-designs
- https://en.wikipedia.org/wiki/H-bridge
- https://en.wikipedia.org/wiki/Insulated-gate_bipolar_transistor
- https://circuitglobe.com/four-quadrant-operation-of-dc-motor.html
- “Electric Vehicle Technology Explained”, James Larminie, John Lowry, John Wiley & Sons Ltd, The Atrium, Southern Gate, Chichester, West Sussex PO19 8SQ, England. ISBN 0-470-85163-5.
- ‘Modern Electric, Hybrid Electric, and Fuel Cell Vehicles – Fundamentals, Theory, and Design”, Mehrdad Ehsani, Yimin Gao, Sebastian E.Gay, Ali Emadi, Power electronics and applications series, ISBN 0-8493-3154-4, CRC Press LLC, 2000 N.W. Corporate Blvd., Boca Raton, Florida.
- https://in.mathworks.com/help/physmod/sps/powersys/ref/dcmachine.html?searchHighlight=DC%20Machine&s_tid=srchtitle
- https://in.mathworks.com/help/physmod/sps/powersys/ref/igbt.html?searchHighlight=IGBT&s_tid=srchtitle
- https://in.mathworks.com/help/physmod/sps/powersys/ref/diode.html?searchHighlight=Diode&s_tid=srchtitle
- https://in.mathworks.com/help/simulink/slref/pulsegenerator.html?searchHighlight=Pulse%20Generator&s_tid=srchtitle
- https://in.mathworks.com/help/physmod/sps/powersys/ref/fourquadrantchopperdcdrive.html#:~:text=chopper%20DC%20drive-,Description,armature%20current%20of%20the%20machine.
- https://in.mathworks.com/help/physmod/sps/powersys/ref/threephasesource.html
- https://in.mathworks.com/help/physmod/sps/powersys/ref/universalbridge.html