Week-11 Challenge: Braking
AIM
To understand Braking in automobiles.
INTRODUCTION
1. BRAKE:
[1] Brake is a mechanical device that inhibits motion by absorbing energy from a moving system. It is used for slowing or stopping a moving vehicle, wheel, axle, or to prevent its motion, most often accomplished by means of friction.
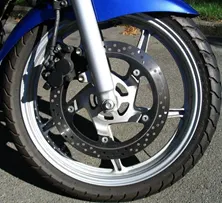
Figure 1. Disc brake on a motorcycle.
Most brakes commonly use friction between two surfaces pressed together to convert the kinetic energy of the moving object into heat, though other methods of energy conversion may be employed. For example, regenerative braking converts much of the energy to electrical energy, which may be stored for later use. Other methods convert kinetic energy into potential energy in such stored forms as pressurized air or pressurized oil. Eddy current brakes use magnetic fields to convert kinetic energy into electric current in the brake disc, fin, or rail, which is converted into heat. Still other braking methods even transform kinetic energy into different forms, for example by transferring the energy to a rotating flywheel.
Brakes are generally applied to rotating axles or wheels but may also take other forms such as the surface of a moving fluid (flaps deployed into water or air). Some vehicles use a combination of braking mechanisms, such as drag racing cars with both wheel brakes and a parachute, or airplanes with both wheel brakes and drag flaps raised into the air during landing.
Since kinetic energy increases quadratically with velocity (K = 0.5mv2), an object moving at 10 m/s has 100 times as much energy as one of the same mass moving at 1 m/s, and consequently the theoretical braking distance, when braking at the traction limit, is up to 100 times as long. In practice, fast vehicles usually have significant air drag, and energy lost to air drag rises quickly with speed.
NEED FOR BRAKING SYSTEM: [2] In an automobile vehicle braking system is needed:
- To stop the moving vehicle.
- To de-accelerate the moving vehicle.
- For stable parking of a vehicle either on a flat surface or on a slope.
- As a precaution for accidents.
- To prevent the vehicle from any damage due to road conditions.
CHARACTERISTICS OF BRAKES: [1] Brakes are often described according to several characteristics including:
|
Characteristic |
Description |
|
Peak force |
The peak force is the maximum decelerating effect that can be obtained. The peak force is often greater than the traction limit of the tires, in which case the brake can cause a wheel skid. |
|
Continuous Power dissipation |
Brakes typically get hot in use and fail when the temperature gets too high. The greatest amount of power (energy per unit time) that can be dissipated through the brake without failure is the continuous power dissipation. Continuous power dissipation often depends on e.g., the temperature and speed of ambient cooling air. |
|
Fade |
As a brake heats, it may become less effective, called brake fade. Some designs are inherently prone to fade, while other designs are relatively immune. Further, use considerations, such as cooling, often have a big effect on fade. |
|
Pedal Feel |
Brake pedal feel encompasses subjective perception of brake power output as a function of pedal travel. Pedal travel is influenced by the fluid displacement of the brake and other factors. |
|
Smoothness |
A brake that is grabby, pulses, has chatter, or otherwise exerts varying brake force may lead to skids. For example, railroad wheels have little traction, and friction brakes without an anti-skid mechanism often lead to skids, which increases maintenance costs and leads to a "thump" feeling for riders inside. |
|
Power |
Brakes are often described as "powerful" when a small human application force leads to a braking force that is higher than typical for other brakes in the same class. This notion of "powerful" does not relate to continuous power dissipation and may be confusing in that a brake may be "powerful" and brake strongly with a gentle brake application yet have lower (worse) peak force than a less "powerful" brake. |
|
Drag |
Brakes have varied amount of drag in the off-brake condition depending on design of the system to accommodate total system compliance and deformation that exists under braking with ability to retract friction material from the rubbing surface in the off-brake condition. |
|
Durability |
Friction brakes have wear surfaces that must be renewed periodically. Wear surfaces include the brake shoes or pads, and also the brake disc or drum. There may be tradeoffs, for example, a wear surface that generates high peak force may also wear quickly. |
|
Weight |
Brakes are often "added weight" in that they serve no other function. Further, brakes are often mounted on wheels, and un-sprung weight can significantly hurt traction in some circumstances. "Weight" may mean the brake itself or may include additional support structure. |
|
Noise |
Brakes usually create some minor noise when applied, but often create squeal or grinding noises that are quite loud. |
Table 1. Characteristics of Brake employed in an automobile.
2. CLASSIFICATION OF BRAKING SYSTEMS:
[2] In an automobile vehicle, a braking system is an arrangement of various linkages and components (brake lines or mechanical linkages, brake drum or brake disc , master cylinder or fulcrums etc.) that are arranged in such a fashion that it converts the vehicle’s kinetic energy into the heat energy which in turn stops or decelerates the vehicle. The conversion of kinetic energy into heat energy is a function of frictional force generated by the frictional contact between brake shoes and moving drum or disc of a braking system.
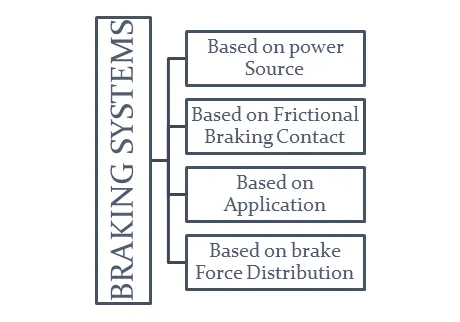
Figure 2. Classification of Braking Systems.
1. BASED ON POWER SOURCE: The power source which carries the pedal force applied by the driver on brake pedal to the final brake drum or brake disc in order to de accelerate or stop the vehicle the braking systems are of six types:
- Mechanical Brakes: It is the type of braking system in which the brake force applied by the driver on the brake pedal is transferred to the final brake drum or disc rotor through the various mechanical linkages like cylindrical rods, fulcrums, springs etc. In order to de accelerate or stop the vehicle. Mechanical brakes were used in various old automobile vehicles, but they are obsolete now days due to their less effectiveness.
- Hydraulic Brakes: It is the type of braking system in which the brake force applied by the driver on brake pedal is first converted into hydraulic pressure by master cylinder then this hydraulic pressure from master cylinder is transferred to the final brake drum or disc rotor through brake lines. Instead of mechanical linkages, brake fluid is used in hydraulic brakes for the transmission of brake pedal force in order to stop or decelerates the vehicle. Almost all the bikes and cars on the road today are equipped with the hydraulic braking system due to it high effectiveness and high brake force generating capability.
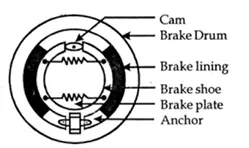
Figure 3. Depiction of Mechanical Brake.
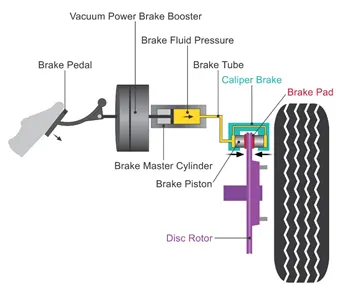
Figure 4. Depiction of Hydraulic Braking System.
- Air/Pneumatic Brakes: This is a braking system in which the atmospheric air through compressors and valves is used to transmit brake pedal force from brake pedal to the final drum or disc rotor. Air brakes are mainly used in heavy vehicles like busses and trucks because hydraulic brakes fails to transmit high brake force through greater distance and also pneumatic brakes generates higher brake force than hydraulic brake which is the need of the heavy vehicle. The chances of brake failure is less in case of pneumatic brakes as they are usually equipped with a reserve air tank which comes in action when there is a brake failure due to leakage in brake lines. High end cars these days are using air brakes system due to its effectiveness and fail proof ability.
- Vacuum Brakes: It is the conventional type of braking system in which vacuum inside the brake lines causes brake pads to move which in turn finally stops or de accelerate the vehicle. Exhauster , main cylinder , brake lines , valves along with disc rotor or drum are the main components that combines together to make a vacuum braking system. Vacuum brakes were used in old or conventional trains and are replaced with air brakes now days because of its less effectiveness and slow braking. Vacuum brakes are cheaper than air brakes but are less safe than air brakes.
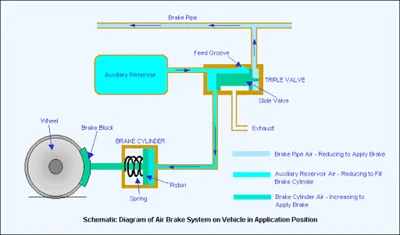
Figure 5. Depiction of Pneumatic Braking System.
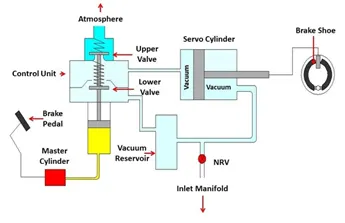
Figure 6. Depiction of Vacuum Braking System.
- Magnetic Brakes: In this types of braking system, the magnetic field generated by permanent magnets is used to cause the braking of the vehicle. It works on the principle that when a magnet is passed through a copper tube, eddy current is generated, and the magnetic field generated by this eddy current provides magnetic braking. This is the friction less braking system thus there is less or no wear and tear. This is the advanced technology in which no pressure is needed to cause braking. The response to the braking in this is quite quick as compared to other braking systems.
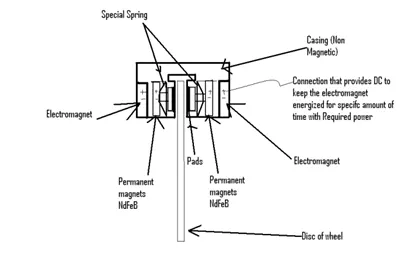
Figure 7. Depiction of Magnetic Braking System.
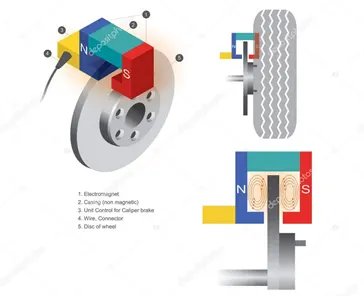
Figure 8. Depiction of Electric Braking System.
- Electric Brakes: It is type of braking used in electric vehicle in which braking is produced using the electrical motors which is the main source of power in electric vehicles, it is further divided into 3 types:
- Plugging Brakes: When the brake pedal is pressed in the electric vehicle equipped with plugging braking, the polarity of the motors changes which in turn reverses the direction of the motor and causes the braking.
- Regenerative Braking: It is the type of electrical braking in which at the time of braking the motor which is the main power source of the vehicle becomes the generator i.e. when brakes are applied, the power supply to the motor cuts off due to which the mechanical energy from the wheels becomes the rotating force for the motor which in turn converts this mechanical energy into the electric energy which is further stored in the battery. Regenerative braking saves the energy and are widely used in today’s electric vehicles. Tesla Model-S provides the most effective regenerative braking.
- Dynamic or Rheostat Braking; It is the type of electrical braking in which resistance provided by the rheostat causes the actual braking, in this type a rheostat is attached to the circuit that provides the resistance to the motor which is responsible for deceleration or stopping of the vehicle.
2. BASED ON FRICTIONAL BRAKING CONTACT: On the basis of the final friction contact made between the rotating brake components i.e., brake drum or disc rotor and the brake shoe the braking systems are of two types:
- Drum Brakes / Internally Expanding Brakes: It is the type of brake system in which a drum which is the housing of the brake shoes along with actuation mechanism is attached with the wheel hub in such a fashion that the outer part of the drum rotates with the wheel and inner part remains constant. When brakes are applied the actuating mechanism (wheel cylinder or mechanical linkage.) causes the brake shoes to expand due to which the outer frictional surface of the brake shoes makes frictional contact with the rotating drum part which in turn stops or de accelerate the vehicle.
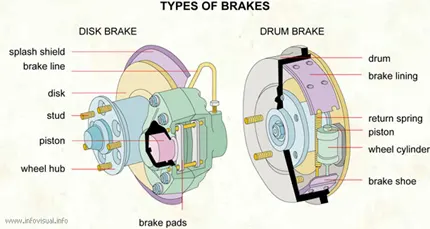
Figure 9. Depiction of Disc and Drum brakes.
- Disc Brakes/ Externally Contracting Brakes: I t is the types of braking system in which instead of a drum assembly a disc rotor attached to the hub of the wheel in such a fashion that it rotates with the wheel, this disc rotor is clamped in between the caliper which is rigidly fixed with the knuckle or upright of the vehicle. This caliper used is the housing of the brake shoes along with the actuation mechanism (mechanical linkages or caliper cylinder). When the brakes are applied the actuation mechanism contracts the attached brake shoes which in turn makes the frictional contact with the rotating disc rotor and causes the braking of the vehicle.
3. BASED ON APPLICATION: On the basis of method of applying brakes, braking systems are of two types:
- Service Brake/Foot brake: It is the type of brakes in which the brakes are applied when the driver presses the brake pedal mounted inside the cockpit or at the foot space of the vehicle with his foot, this pedal force applied by the driver is further multiplied and sent to the braking drum or disc either by mechanical linkages or by hydraulic pressure which in turn causes braking. In cars foot operated brakes are used and in bikes the combination of foot and hand operated brakes are used.
- Parking Brake/ Hand Brake: This type of brakes are also known as emergency brake as they are independent of the main service brake, hand brakes consists of a hand operated brake lever which is connected to the brake drum or disc rotor through the metallic cable. When hand brake lever is pulled, tension is created in the metallic rod which in turn actuates the brake drum or disc rotor mechanism and final braking occurs. Hand brakes are usually used for stable parking of the vehicle either on flat road or slope that is why it is also called parking brakes.
4. BASED ON BRAKE FORCE DISTRIBUTION: On the basis of the type of force application of the brake, there are two types:
- Single Acting Brakes: It is the type of braking in which brake force is transferred to either a pair of wheels(in cars) or to the single wheel(in bikes) through single actuation mechanism(mechanical linkages or master cylinder). These types of braking system is commonly used in bikes or in light purpose vehicles.
- Dual Acting Brakes: t is the type of braking in which the brake force is transferred to all the wheels of the vehicle through dual actuation mechanism (tandem master cylinder or mechanical linkages). This type of braking is used in cars as well as in heavy purpose vehicle.
3. CLASSIFICATION OF BRAKING SYSTEMS:
[3] Regenerative braking in EVs and HEVs adds some complexity to the braking system design. Two basic questions arise:
- one is how to distribute the total braking forces required between the regenerative brake and the mechanical friction brake so as to recover the kinetic energy of the vehicle as much as possible,
- the other is how to distribute the total braking forces on the front and rear axles so as to achieve a steady-state braking.
Usually, regenerative braking is effective only for the driven axle. The traction motor must be controlled to produce the proper amount of braking force for recovering the kinetic energy as much as possible and, at the same time, the mechanical brake must be controlled to meet the braking force command from the driver. Basically, there are three different brake control strategies: series braking with optimal braking feel; series braking with optimal energy recovery; and parallel braking.
a) SERIES BRAKING WITH OPTIMAL BRAKING FEEL: The series braking system with optimal feel consists of a braking controller that controls the braking forces on the front and rear wheels. The control objective is to minimize the stopping distance and optimize the driver’s feel. The shortest braking distance and good braking feel require the braking forces on the front and rear wheels to follow the ideal braking force distribution curve I. When the commanded deceleration (represented by the braking pedal position) is less than 0.2 g, only the regenerative braking on the front wheels is applied, which emulates the engine retarding function in conventional vehicles. When the commanded deceleration is greater than 0.2 g, the braking forces on the front and rear wheels follow the ideal braking forces distribution curve I, as shown in Figure 10. by the thick solid line.
The braking force on the front wheels (driven axle) is divided into two parts: regenerative braking force and mechanically frictional braking force. When the braking force demanded is less than the maximum braking force that the electric motor can produce, only electrically regenerative braking will apply. When the commanded braking force is greater than the available regenerative braking force, the electric motor will operate to produce its maximum braking torque, and the remaining braking force is met by the mechanical brake system.
It should be noted that the maximum regenerative braking force produced by an electric motor is closely related to the electric motor’s speed. At low speed (lower than its base speed), the maximum torque is constant. However, at high speed (higher than its base speed), the maximum torque decreases hyperbolically with its speed. Therefore, the mechanical brake torque at a given vehicle deceleration varies with vehicle speed.
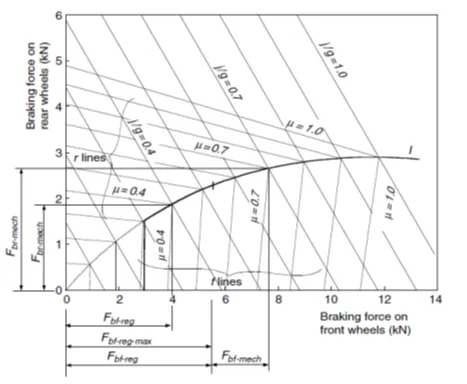
Figure 10. Illustration of braking forces on the front and rear axle for series braking — optimal feel.
b) SERIES BRAKING WITH OPTIMAL ENERGY RECOVERY: The principle of the series braking system with optimal energy recovery is to recover the braking energy as much as possible in the condition of meeting the total braking force demanded for the given deceleration. This principle is illustrated in Figure 11. When the vehicle is braked with an acceleration rate of j/g < μ, the braking forces on the front and rear wheels can be varied in a certain range, as long as the Fbf + Fbr = Mvj is satisfied. This variation range of the front and rear axles is shown in Figure 11 by the thick solid line ab, where μ = 0.9 and j/g = 0.7.
In this case, regenerative braking should be used in priority. If the available regenerative braking force (maximum braking force produced by the electric motor) is in this range (point c in Figure 11, for example), the braking force on the front wheels should be developed only by regenerative braking without mechanical braking. The braking force on the rear wheels, represented by point e, should be developed in order to meet the total braking force requirement. If, on the same road, the available regenerative braking force is less than the value corresponding to point a (e.g., point i in Figure 11), the electric motor should be controlled to produce its maximum regenerative braking force. The front and rear braking forces should be controlled at point f so as to optimize the driver feel and reduce braking distance. In this case, additional braking force on the front wheels must be developed by mechanical braking by the amount represented by Fbf-mech, and the braking force on the rear axle is represented by point h.
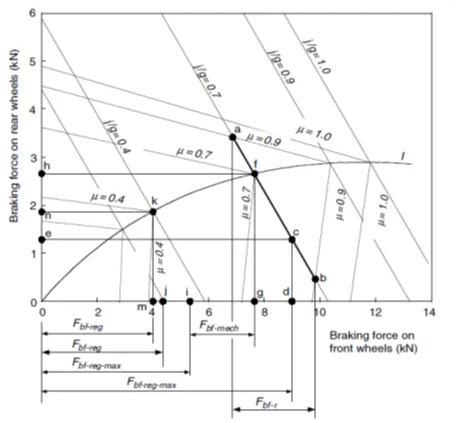
Figure 11. Demonstration of series braking — optimal energy recovery.
When the commanded deceleration rate, j/g, is much smaller than the road adhesive coefficient (j/g = 0.3 in Figure 11 for example), and the regenerative braking force can meet the total braking force demand, only regenerative braking is used without mechanical braking on the front and rear wheels (point j in Figure 11). When the commanded deceleration rate, j/g, is equal to the road adhesive coefficient μ, the operating point of the front and rear braking forces must be on the curve I. On a road with a high adhesive coefficient (μ = 0.7, operating point f, in Figure 11, for example), the maximum regenerative braking force is applied, and the remaining is supplied by the mechanical brake. On a road with a low adhesive coefficient (μ = 0.4, operating point k, in Figure 11, for example), regenerative braking alone is used to develop the front braking force. When the commanded deceleration rate, j/g, is greater than the road adhesive coefficient μ, this commanded deceleration rate will never be reached due to the limitation of the road adhesion. The maximum deceleration that the vehicle can obtain is (a/g)max = μ. The operating point of the front and rear braking forces is on the curve I, corresponding to μ (μ = 0.4 and j/g > 0.4 in Figure 11, for example); the operating point is point k and the maximum deceleration rate is j/g = 0.4.
It should be noted that the series brake with both optimal feel and energy recovery needed active control of both electric regenerative braking and mechanical braking forces on the front and rear wheels. At present, such a braking system is under research and development.
4. LOSSES IN AN INDUCTION MOTOR:
[4] There are two types of losses occur in three phase induction motor. These losses are:
- Constant or fixed losses: Constant losses are those losses which are considered to remain constant over normal working range of induction motor. The fixed losses can be easily obtained by performing no-load test on the three-phase induction motor. These losses are further classified as-
- Iron loss: Iron or core losses are further divided into hysteresis and eddy current losses. Eddy current losses are minimized by using lamination on core. Since by laminating the core, area decreases and hence resistance increases, which results in decrease in eddy currents. Hysteresis losses are minimized by using high grade silicon steel. The core losses depend upon frequency of the supply voltage. The frequency of stator is always supply frequency, f and the frequency of rotor is slip times the supply frequency, (sf) which is always less than the stator frequency. For stator frequency of 50 Hz, rotor frequency is about 1.5 Hz because under normal running condition slip is of the order of 3 %. Hence the rotor core loss is very small as compared to stator core loss and is usually neglected in running conditions.
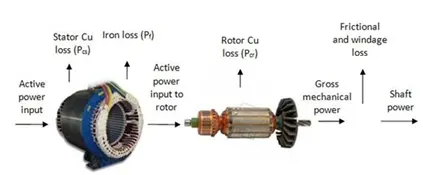
Figure 12. Demonstration of losses in an induction motor.
- Mechanical and Brush Friction losses: Mechanical losses occur at the bearing and brush friction loss occurs in wound rotor induction motor. These losses are zero at start and with increase in speed these losses increases. In three phase induction motor the speed usually remains constant. Hence these losses almost remains constant.
- Variable losses: These losses are also called copper losses. These losses occur due to current flowing in stator and rotor windings. As the load changes, the current flowing in rotor and stator winding also changes and hence these losses also changes. Therefore these losses are called variable losses. The copper losses are obtained by performing blocked rotor test on three phase induction motor. The main function of induction motor is to convert an electrical power into mechanical power. During this conversion of electrical energy into mechanical energy the power flows through different stages.
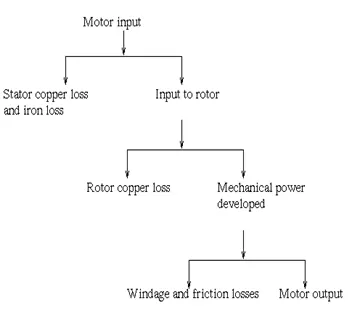
Figure 13. Distribution of the power in an induction motor.
A part of this power input is used to supply stator losses which are stator iron loss and stator copper loss. The remaining power i.e., (input electrical power – stator losses) are supplied to rotor as rotor input. Now, the rotor has to convert this rotor input into mechanical energy, but this complete input cannot be converted into mechanical output as it has to supply rotor losses. As explained earlier the rotor losses are of two types of rotor iron loss and rotor copper loss. Since the iron loss depends upon the rotor frequency, which is very small when the rotor rotates, so it is usually neglected. So, the rotor has only rotor copper loss. Therefore the rotor input has to supply these rotor copper losses. After supplying the rotor copper losses, the remaining part of Rotor input, is converted into mechanical power. Therefore, this mechanical power developed is given to the load by the shaft but there occur some mechanical losses like friction and windage losses. So, the gross mechanical power developed has to be supplied to these losses. Therefore the net output power developed at the shaft is finally given to the load.
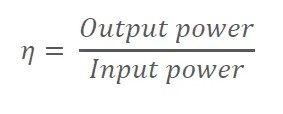
The three-phase induction motor efficiency is given as:
OBJECTIVES
- To calculate braking energy for an assumed drive cycle.
- To understand the braking torque at high speed and the coordination of the electrical and mechanical brakes in EV and HEVs.
- To plot the characteristics of an induction motor.
PROBLEM SPECIFICATION AND SOLVING:
PROBLEM STATEMENT I:
For a defined driving cycle, calculate the energy required for braking.
EXPLANATION AND OBSERVATION:
- An excel sheet with appropriate values of time and velocity are fed and thereby creating a drive cycle.
- The minimum value of the time and velocity in the drive cycle are maintained at 0 and the maximum value of time and velocity are maintained at 30 sec and 29 m/s respectively.
- The hence created drive cycle portrays the rise and fall of the velocity replicating the driving of the vehicles.
- The braking is usually applied to reduce the velocity with which the vehicle is moving and therefore, by using the following formula, the braking energy is calculated:
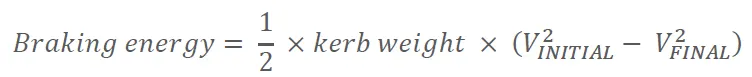
- The kerb-weight of the automobile is taken as 1000 kg.
- The formula for braking energy for all those incidents when the velocity decrease and the amount of braking energy required is tabulated.
- The layout of the drive cycle is as shown in the figure below:
|
Time(sec) |
Velocity(m/s) |
Braking Energy |
|
0 |
0 |
… |
|
1 |
2 |
… |
|
2 |
3 |
… |
|
3 |
5 |
… |
|
4 |
7 |
… |
|
5 |
10 |
… |
|
6 |
14 |
… |
|
7 |
16 |
… |
|
8 |
22 |
… |
|
9 |
20 |
42000 |
|
10 |
17 |
55500 |
|
11 |
12 |
72500 |
|
12 |
6 |
54000 |
|
13 |
3 |
13500 |
|
14 |
0 |
4500 |
|
15 |
7 |
… |
|
16 |
15 |
… |
|
17 |
25 |
… |
|
18 |
19 |
132000 |
|
19 |
17 |
36000 |
|
20 |
20 |
… |
|
21 |
13 |
115500 |
|
22 |
8 |
52500 |
|
23 |
11 |
… |
|
24 |
2 |
58500 |
|
25 |
5 |
… |
|
26 |
19 |
… |
|
27 |
29 |
… |
|
28 |
18 |
258500 |
|
29 |
7 |
137500 |
|
30 |
0 |
24500 |
Table 2. The drive cycle depicting the values of time and velocity along with braking energy column.
PROBLEM STATEMENT II:
Why electric motor cannot develop braking torque at high speed similar to starting? How electric and mechanical brakes are coordinated?
EXPLANATION AND OBSERVATION:
[5] In the case of steady state operation (the angular acceleration α is zero) the motor torque has to make friction torque correspond proportionally to the angular speed and load torque at that specific angular speed. The braking torque and power need in respect to time varies greatly in these two different load types.
The motor torque is given as:
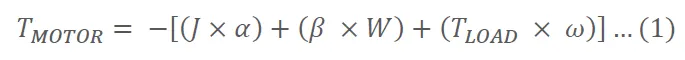
For, constant load torque conditions, i.e., TLOAD = Constant then the power is defined as:
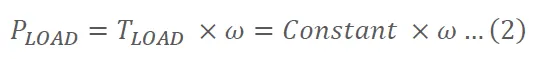
EVALUATING BRAKE TORQUE AND POWER:
In the case of steady state operation (the angular acceleration α = 0) the motor torque has to make friction torque correspond proportionally to the angular speed and load torque at that specific angular speed. The braking torque and power need in respect to time varies greatly in these two different load types.
Let us first consider the case where the load is constant torque type and the drive system is not able to generate braking torque, i.e., the drive itself is single quadrant type. In order to calculate the braking time needed one can apply the following equation. Please note that formula (1) underlines that the torque needed for inertia accelerating (or decelerating), friction and load torque is in the opposite direction to the motor torque.
In practice, it is difficult to define the effect of friction exactly. By assuming friction to be zero the time calculated is on the safe side. (β = 0)
On rewriting the motor torque equation:
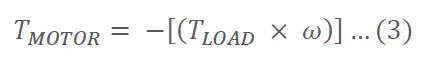
This applies for those applications where the load torque remains constant when the braking starts. In the case where load torque disappears the kinetic energy of the mechanics remains unchanged but the load torque that would decelerate the mechanics is now not in effect. In that case if the motor is not braking the speed will only decrease as a result of mechanical friction. Therefore, in the case of constant torque condition, the braking torque cannot be developed as high as the starting torque. The natural braking effect is at its maximum at the beginning of the braking. This clearly indicates that it is not necessary to start braking the motor till it reaches a certain threshold value.
COORDINATION OF ELECTRIC AND MECHANCIAL BRAKES: Basically, there are three different brake control strategies: series braking with optimal braking feel; series braking with optimal energy recovery; and parallel braking.
- PARALLEL BRAKING: The parallel brake system includes both an electrical (regenerative) brake and a mechanical brake, which produce braking forces in parallel and simultaneously. The operating principle is illustrated in Figure 14, in which regenerative braking is applied only to the front wheels.
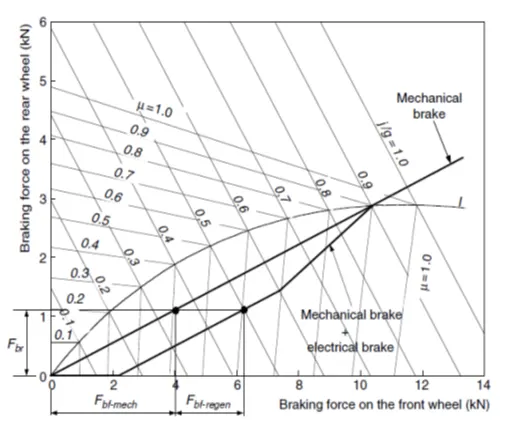
Figure 14. Illustration of parallel braking strategy.
The parallel brake system has a conventional mechanical brake which has a fixed ratio of braking force distribution on the front and rear wheels. Regenerative braking adds additional braking force to the front wheels, resulting in the total braking force distribution curve. The mechanical braking forces on the front and rear axles are proportional to the hydraulic pressure in the master cylinder. The regenerative braking force developed by the electric motor is a function of the hydraulic pressure of the master cylinder, and therefore a function of vehicle deceleration. Because the regenerative braking force available is a function of motor speed and because almost no kinetic energy can be recovered at low motor speed, the regenerative braking force at high vehicle deceleration (e.g., a/g = 0.9) is designed to be zero so as to maintain braking balance. When the demanded deceleration is less than this deceleration, regenerative braking is effective.
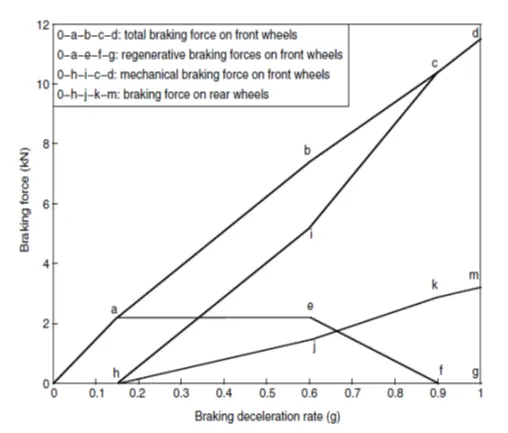
Figure 15. Braking forces varying with deceleration rate.
When the braking deceleration commanded is less than a given value, say 0.15 g, only regenerative braking is applied. This emulates the engine retarding in a conventional vehicle. In Figure 14, the regenerative braking force, Fbf-regen, and mechanical braking forces on the front and rear wheels, Fbf-mech and Fbr, are illustrated. Figure 15 shows the total braking force, regenerative braking force, and mechanical braking force on the front wheels as well as the braking force on the rear wheels in the parallel braking system of a passenger car.
The parallel braking system does not need an electronically controlled mechanical brake system. A pressure sensor senses the hydraulic pressure in the master cylinder, which represents the deceleration demand. The pressure signal is regulated and sent to the electric motor controller to control the electric motor to produce the demanded braking torque. Compared with the series braking of both optimal feel and energy recovery, the parallel braking system has a much simpler construction and control system. However, the driver’s feeling, and amount of energy recovered are compromised.
PROBLEM STATEMENT III:
Make a MATLAB program which plots contour of given motor speed, torque, and efficiency values. Attach the code as a .m file attach a screenshot of all the plots.
EXPLANATION AND OBSERVATION:
- The code begins with the introduction of the values of angular velocity and the values of torque in the form of a numerical array using linspace command.
- The minimum values of angular velocity and torque are maintained at 0 and the maximum values of angular velocity and the torque are 1800 rad/sec and 450Nm.
- The motor constants required are defined as variables as follows:
|
Constant |
Value |
|
Copper loss coefficient (k_c) |
0.3 |
|
Iron loss coefficient (k_i) |
0.008 |
|
Winding loss coefficient (k_w) |
0.00001 |
|
Coefficient accounting for constant motor loss (c ) |
25 |
Table 3. Description of the values of constants.
- The output power of the induction motor is the product of the torque and the angular velocity and therefore, the two numerical arrays are multiplied.
- These numerical arrays are remodeled using meshgrid to form 2D arrays and then are multiplied to yield output power.
- The values of corresponding losses are computed using the formulae mentioned in the table below:
|
Constant |
Value |
|
Copper loss |
(Torque)2 (k_c) |
|
Iron loss |
(Angular velocity * k_i) |
|
Winding loss |
(angular velocity)3 (k_w) |
Table 4. Calculation of various losses incurred by an induction motor.
- The input power, using the principle of energy balance, the sum of the output power and the other losses along with the coefficient accounting for the constant motor loss sum up to the input power.
- We know that y standard definition, the efficiency is defined as the ratio of the output power to the input power.
- Two plots are created to evaluate the characteristics of the induction motor. One being the surface plot. The variation of the values of the angular velocity, torque and the efficiency are studied using the command ‘surf’.
- An array of efficiencies is created to be imparted to the contour, the other plot, which is created using the values of angular velocities, torques, efficiencies, by using the command ‘contourf’.
- The command ‘contour’ can also be used but the command ‘contourf’ is used to fill the contours created.
- An array is assigned to the contour created and this array is used to impart labels using the command ‘clabel’.
- The color palette of the contour is altered using the command ‘colormap’ and theme of ‘winter’ is chosen.
- Both the plots are labelled and given appropriate titles.
- The MATLAB code is as follows:
%% PLOTTING CONTOURS OF MOTOR SPEED, TORQUE AND EFFICIENCY

clear

close all

clc


w = linspace(0,1800,100); %angular velocity in rad/sec

tor = linspace(0,100,100); %torque in Nm


%Defining the motor constants

k_c = 0.3; %Copper loss coefficient

k_i = 0.008; %Iron loss coefficient

k_w = 0.00001; %Windage loss coefficient

c = 25; %constant motor loss coefficient


%Creating a mesh  i.e. 2D array of angular velocity and torque

[W,T] = meshgrid(w,tor);


Power_output = [W.*T]; % product of torque and angular velocity


Copper_Loss = (T.^2) * k_c;

Iron_Loss = (W * k_i);

Windage_Loss = (W.^3)*k_w;


Power_input = Copper_Loss + Iron_Loss + Windage_Loss + Power_output + c;


efficiency = Power_output./Power_input;


%PLOTTING

figure(1);

surf(W,T,efficiency);

colorbar

xlabel('Angular velocity (rad/sec)');

ylabel('Torque (Nm)');

zlabel('Efficiency');

title('Efficiency Curve for an Induction Motor');

grid off;


E = [0.70,0.75,0.80,0.85,0.90,0.91,0.92,0.93,0.94,0.95]; %selecting the efficiencies to appear on the plot

figure(2);

box off;

grid off;

[C,h] = contourf(W,T,efficiency,E);

clabel(C,h);

colormap(winter);

colorbar;

xlabel('Angular speed (rad/sec)');

ylabel('Torque (Nm)');

zlabel('Efficiency');

title('Torque-Speed characteristic curve for an induction motor');
RESULTS
- The layout of the drive cycle is as shown in the figure below:
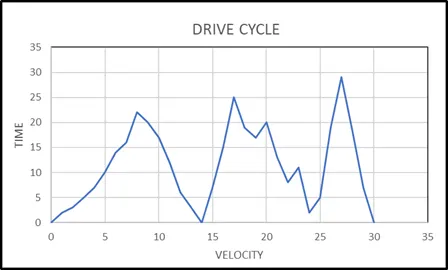
Figure 16. Layout of the drive cycle.
It can be observed from the above figure of the drive cycle that the braking energy is needed from the time period as shown below:
|
Time (sec) |
Velocity (m/s) |
Braking Energy (J) |
|
9 |
20 |
42000 |
|
10 |
17 |
55500 |
|
11 |
12 |
72500 |
|
12 |
6 |
54000 |
|
13 |
3 |
13500 |
|
14 |
0 |
4500 |
|
18 |
19 |
132000 |
|
19 |
17 |
36000 |
|
21 |
13 |
115500 |
|
22 |
8 |
52500 |
|
24 |
2 |
58500 |
|
28 |
18 |
258500 |
|
29 |
7 |
137500 |
|
30 |
0 |
24500 |
Table 5. Depiction of the braking energy produced in the drive cycle.
The maximum value of the braking energy occurs when the difference in the velocities is the maximum and that occurs when the drive cycle moves from 27th to the 28th second. The velocity changes from 29m/s to 18 m/s. The braking energy produced during this time is the maximum braking energy and it amounts to 2,58,500 J. Whereas the least braking energy occurs when the velocity decreases from 3 m/s to 0 m/s as the drive cycle moves from 13th second to 14th second. The least braking energy obtained is 4,500 J.
- Under single quadrant application and in the case of constant torque condition, the braking torque cannot be developed as high as the starting torque. The natural braking effect is at its maximum at the beginning of the braking. This clearly indicates that it is not necessary to start braking the motor till it reaches a certain threshold value. Basically, there are three different brake control strategies: series braking with optimal braking feel; series braking with optimal energy recovery; and parallel braking. The parallel brake system includes both an electrical (regenerative) brake and a mechanical brake, which produce braking forces in parallel and simultaneously. Compared with the series braking of both optimal feel and energy recovery, the parallel braking system has a much simpler construction and control system. However, the driver’s feeling, and amount of energy recovered are compromised.
- The layout of the surface plot and the contour plots of the induction motor are shown below:
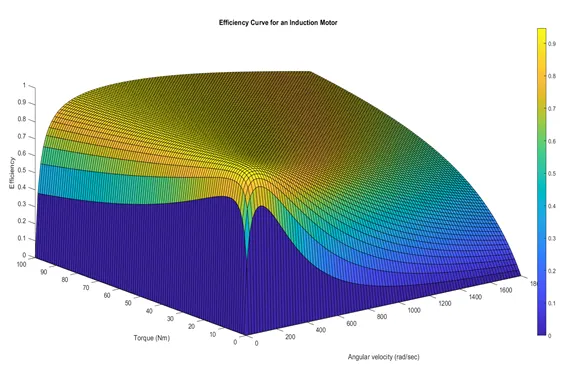
Figure 17. Efficiency curve of an induction motor.
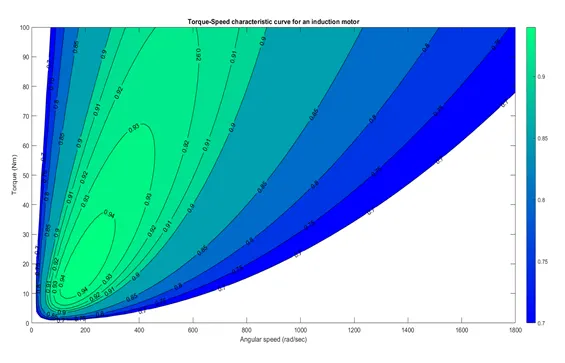
Figure 18. Torque-Speed characteristics of an induction motor..
BIBLIOGRAPHY
- https://en.wikipedia.org/wiki/Brake
- https://www.mechanicalbooster.com/2018/06/types-of-braking-system.html#:~:text=In%20an%20automobile%20vehicle%2C%20a,which%20in%20turn%20stops%20or
- ‘Modern Electric, Hybrid Electric, and Fuel Cell Vehicles – Fundamentals, Theory, and Design”, Mehrdad Ehsani, Yimin Gao, Sebastian E.Gay, Ali Emadi, Power electronics and applications series, ISBN 0-8493-3154-4, CRC Press LLC, 2000 N.W. Corporate Blvd., Boca Raton, Florida.
- https://www.electrical4u.com/losses-and-efficiency-of-induction-motor/
- https://library.e.abb.com/public/20be376000f34dd6b9c513580cf56423/Technical_guide_No_8_3AFE64362534_RevC.pdf