Week 5 Battery characteristics using drive cycle
Aim
The aim of the project is create a generic battery model of charge discharge using UDDS data.
Matlab model
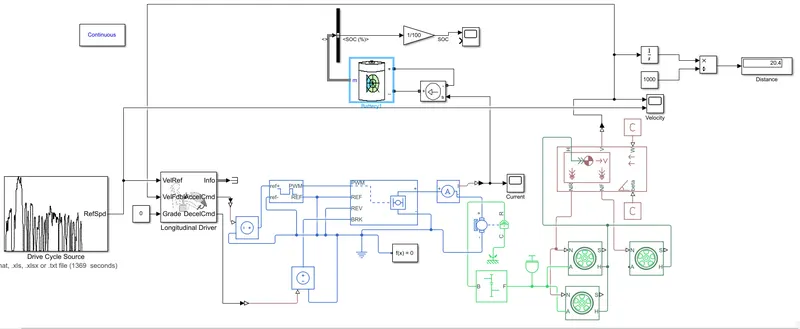
Simulink block
Drive cycle source - 1.
Longitudinal driver - 1.
Constant HDL coder - 1.
Constant Simulink - 2.
Constant voltage source - 2.
Constant PWM source - 1.
Solver configuration - 1.
Electrical reference - 1.
Terminator - 1.
H-bridge - 1.
Current sensor -1.
DC motor -1.
Controlled current source - 1.
Battery -1.
Scope -3.
PS-Simulink converter - 2.
Simulink-PS converter - 2.
Mechanical rotational reference - 1.
Ideal rotational motion sensor - 1.
Simple gear - 1.
Inertia - 1.
Tire - 3.
Vehicle body - 1.
Calculation table
Rolling resistance force
| Kerb weight (kg) | 362 | |
| Payload (kg) | 410 | |
| Coeff of Rolling Resistance | 0.01 | |
| Rolling resistance force (N) | 75.73 |
Air drag force
| Air density | 1.225 | |
| Width (m) | 0.13 | |
| Height (m) | 0.17 | |
| Frontal area (m^2) | 0.0221 | |
| Drag Coeff | 0.45 | |
| Speed(km/hr) | 50 | |
| Speed(m/s) | 13.89 | |
| Drag force (N) | 0.08 |
Gradient force
| Gradient(deg) | 12 | |
| Gradient(rad) | 0.21 | |
| Gradient force | 1574.58 |
Total power
| Total Force (N) | 1650.40 | |
| Total Force with Redn gear (N) | 412.60 | |
| Total Power (kW) | 12.0 | |
| Total Power with Redn gear (kW) | 3.4 |
Vehicle body
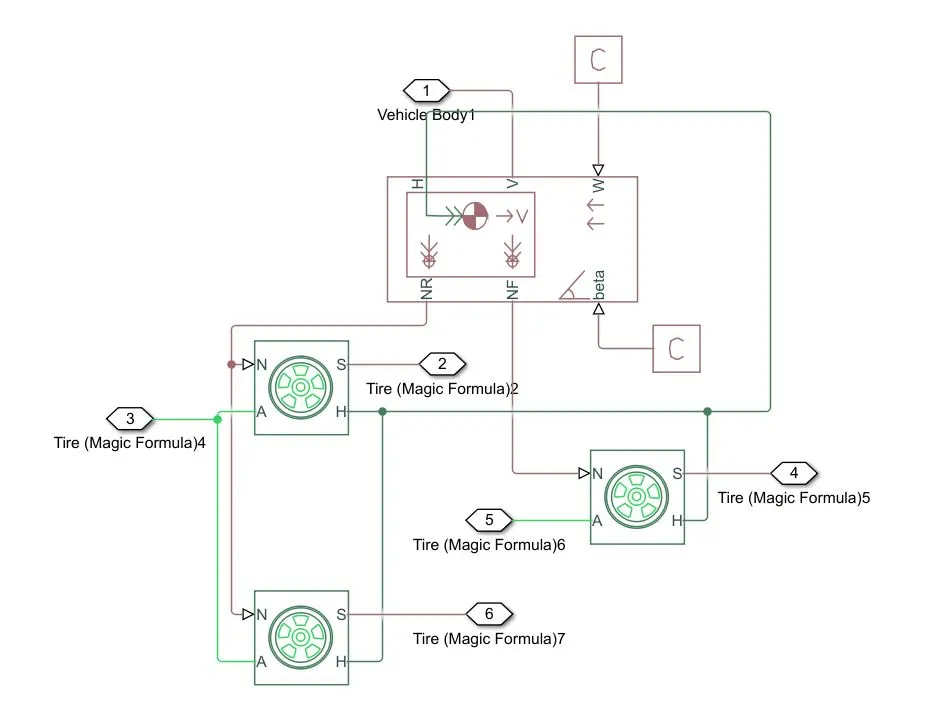
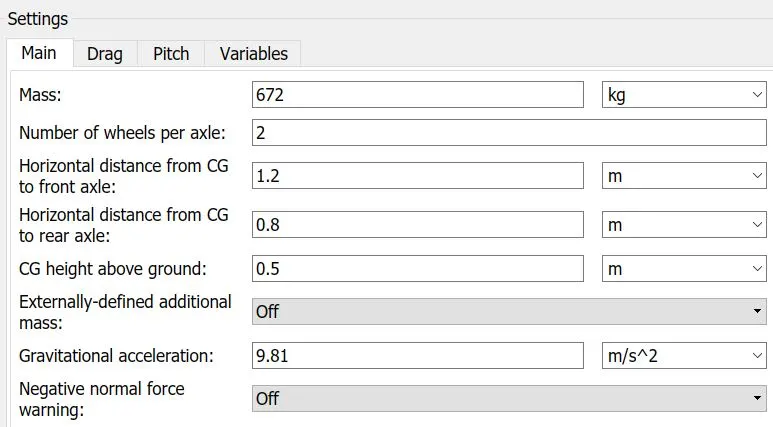
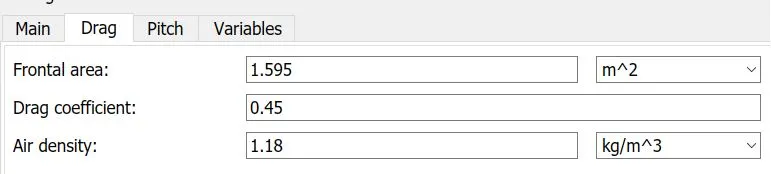
Represents a two-axle vehicle body in longitudinal motion. The block accounts for body mass, aerodynamic drag, road incline, and weight distribution between axles due to acceleration and road profile. The vehicle can have the same or a different number of wheels on each axle. Optionally include pitch and suspension dynamics or additional variable mass and inertia. The vehicle does not move vertically relative to the ground.
- NR: It is a physical signal output which is connected to the rear wheel axle, it is connected with a normal force of the rear tire.
- NF: It is a physical signal output which is connected to the front wheel axle, it is connected with a normal force of the front tire.
- Beta: Beta provides a road incline angle. The constant gradient value of the ground is defined.
- H: The horizontal motion of the vehicle body. This is connected to all the hubs of the wheel for finding the thrust generated by the tire.
- V: The vehicle's longitudinal velocity.
- W: It defines a particular wind speed by adding a constant block.
Pitch Settings
Pitch dynamics - off.
Variable settings
Beginning value of velocity - 0m/s.
Wind velocity - 5 m/s.
Road Incline - 0.
Tire - It represents the longitudinal behavior of a highway tire characterized by the tire magic formula. The block is built from tire-road interaction and Simscape foundation library wheel and axle blocks. The effects of tire inertia, stiffness, and damping can be included.
N: Normal force acting on the tire and connected with NR of the vehicle body.
S: Slip between the tire and road.
H: Hub and it is used to find the thrust created by the tire and it is connected with H input of the vehicle body.
A: Axle and rear axle are connected with the simple gear to final drive system.
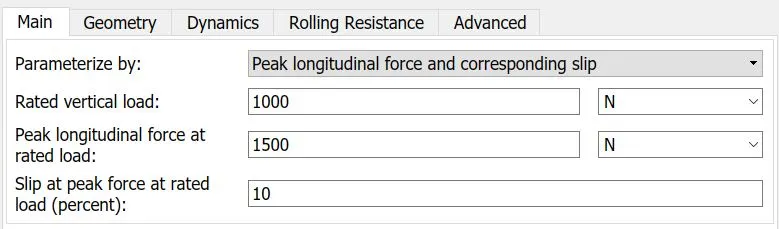
Geometry setting
Rolling radius - 0.2m.
Dynamic setting
Inertia: Specify inertia and initial velocity.
Tire inertia - 0.5.
Initial velocity - 0.
Rolling resistance
Resistance model - Constant coefficient.
Constant coefficient - 0.015.
Velocity threshold - 0.001 m/s.
Inertia
The block represents an ideal mechanical rotational inertia and the value is set to 0.01 kg*m^2.
Simple gear
Represents a fixed-ratio gear or gearbox. No inertia or compliance is modeled in this block. You can optionally include gear meshing and viscous bearing losses.
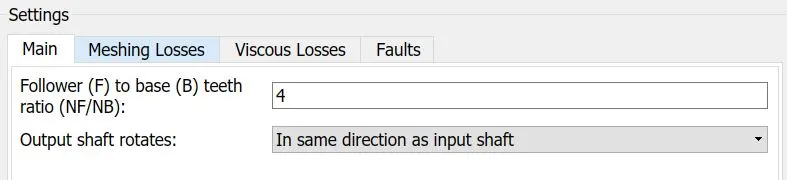
Meshing losses
Friction model - Constant efficiency.
Efficiency - 0.95.
Power threshold - 0.001W.
The viscous losses and faults are not considered for this model.
DC Motor
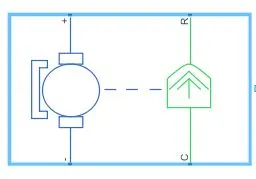
This block represents the electrical and torque characteristics of a DC motor. The block assumes that no electromagnetic energy is lost, and hence the back-emf and torque constants have the same numerical value when in SI units. When a positive current flows from the electrical + to - ports, a positive torque acts from the mechanical C to R ports. Motor torque direction can be changed by altering the sign of the back-emf or torque constants.
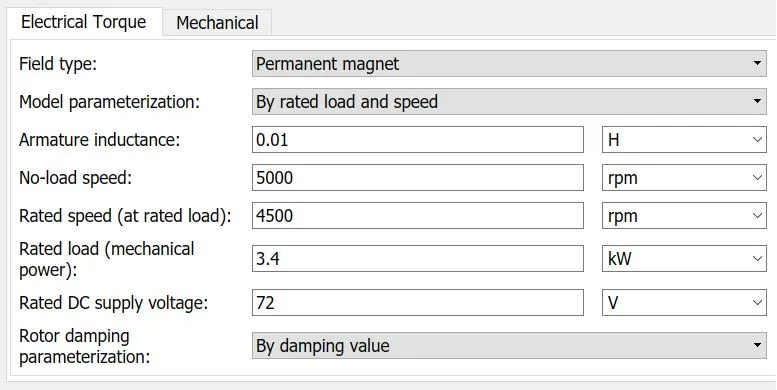
Mechanical
Rotor inertia - 0.01 g*cm^2.
Rotor damping - 0.
Initial rotor speed - 0.
Battery
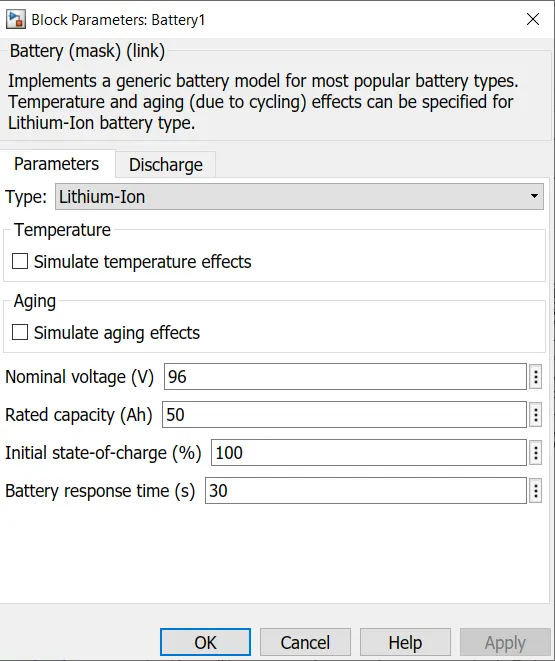
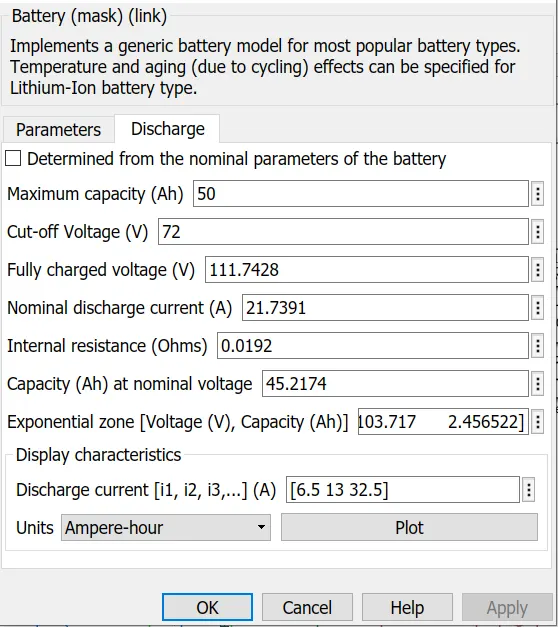
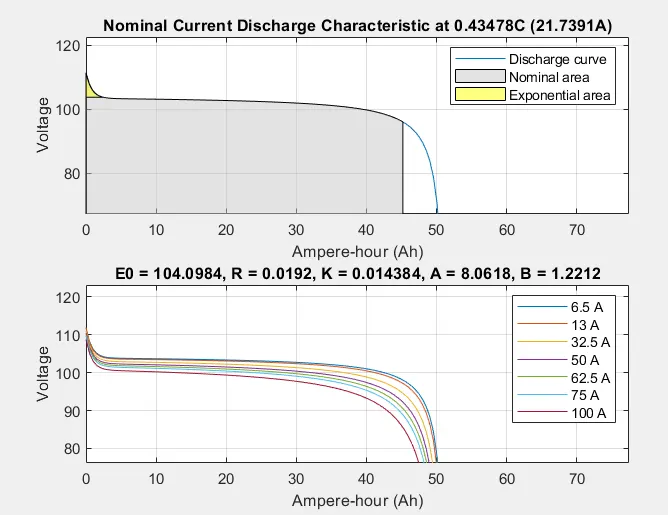
Implements a generic battery model for most popular battery types. Temperature and aging (due to cycling) effects can be specified for Lithium-Ion battery type.
SOC plot
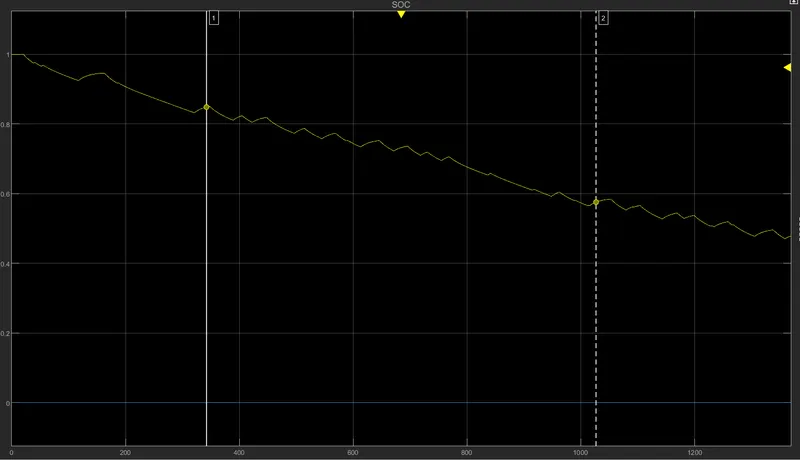
The initial state of charge is 100% & the state of charge left after 1369 seconds for UDDS cycle is 0.45, SOC increases during the braking of the drive cycle.
Discharge & charge plot
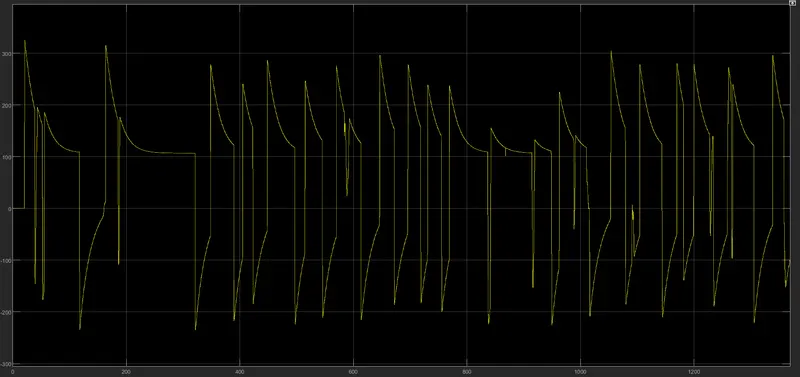
The maximum discharge current is 300 A & maximum charge current is 200A the discharge rate is constant when the speed of the vehcle is constant.
Velocity plot
The velocity plot to compare the reference plot & actual drive cycle.
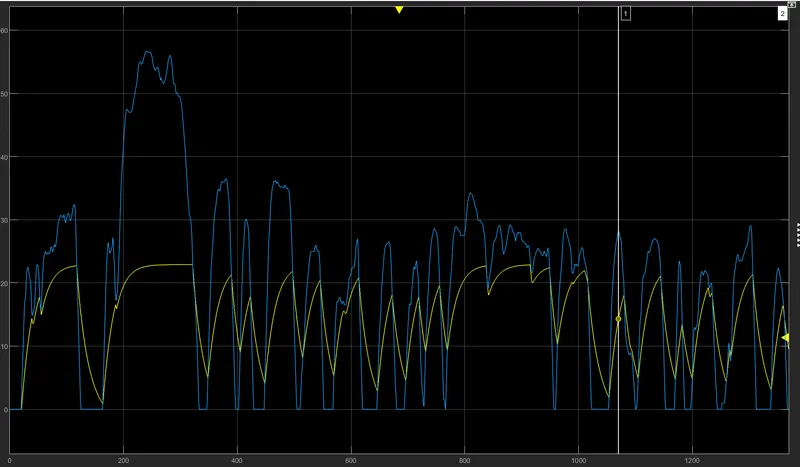
The actual curve doesnt follow the reference UDDS drive cycle the integral & proportional gain value are altered to follow the UDDS cycle.