Week-4 Challenge WOT Condition Part-2
AIM
To understand and use the Powertrain Blockset tool in MATLAB.
INTRODUCTION
1. VEHICLE MODEL:
[1] Electric motorcycles and scooters are plug-in electric vehicles with two or three wheels. The electricity is stored on board in a rechargeable battery, which drives one or more electric motors. Electric scooters (as distinct from motorcycles) have a step-through frame. Most electric motorcycles and scooters as of May 2019 are powered by rechargeable lithium-ion batteries, though some early models used nickel-metal hydride batteries. Alternative types of batteries are available. Z Electric Vehicle has pioneered use of a lead/sodium silicate battery (a variation on the classic lead acid battery invented in 1859, still prevalent in automobiles) that compares favorably with lithium batteries in size, weight, and energy capacity, at considerably less cost.
2. POWERTRAIN BLOCKSET:
[2] Powertrain Blockset™ provides fully assembled reference application models of automotive powertrains, including gasoline, diesel, hybrid, and electric systems. It includes a component library for simulating engine subsystems, transmission assemblies, traction motors, battery packs, and controller models. Powertrain Blockset also includes a dynamometer model for virtual testing. MDF file support provides a standards-based interface to calibration tools for data import. Powertrain Blockset provides a standard model architecture that can be reused throughout the development process. One can use it for design tradeoff analysis and component sizing, control parameter optimization, and hardware-in-the-loop testing. One can customize models by parameterizing components in a reference application with their own data or by replacing a subsystem with their own model.
Reference applications serve as a starting point for the user’s system model. To tailor a reference application to one’s powertrain project, parameterize the components in the reference application using data from a domain-specific tool, a test bench, or a vehicle. Depending on one’s application and powertrain configuration, one might need to select the type of component models and further customize the system model. The component library in Powertrain Blockset provides blocks of physical systems and controllers for:
- Propulsion
- Transmission
- Drivetrain
- Energy storage
- Longitudinal vehicle dynamics
- Drive cycle data and longitudinal driver
All the models in Powertrain Blockset, including the reference applications and components in the library, are fully open for customization. One can use Simulink Projects to manage model variants including variant selection, version management, and comparison.
3. WIDE OPEN THROTTLE (W.O.T):
[3] Wide open throttle or wide-open throttle (WOT), also called full throttle, is the fully opened state of a throttle on an engine (internal combustion engine or steam engine). The term also, by extension, usually refers to the maximum-speed state of running the engine, as the normal result of a fully opened throttle plate/butterfly valve. In an internal combustion engine, this state entails the maximum intake of air and fuel that occurs when the throttle plates inside the carburetor or throttle body are "wide open" (fully opened up), providing the least resistance to the incoming air.[1] In the case of an automobile, WOT is when the accelerator is depressed fully, sometimes referred to as "flooring it" (because automotive throttle controls are usually a pedal, so full throttle is selected by pressing the pedal to the floor, or as near as it will go).
In the case of a diesel engine, which does not have a throttle valve, WOT is the point at which the maximum amount of fuel is being injected relative to the amount of air pumped by the engine, generally in order to bring the fuel-air mixture up to the stoichiometric point. If any more fuel were to be injected, then black smoke would result. (Regardless of the non-literal nature of the term when applied to diesel contexts, it is nonetheless figuratively common and well understood.)
In both control theory (involving humans and machines) and control logic (as a machine-based application thereof), the concept of wide-open throttle can be divided logically into operator intent, throttle position itself, the resultant/net effect on the state of engine running at each moment, and the feedback loops among those factors. This is true even in a system without electronic control, as, for example, when the operator holds the throttle open (pedal floored) to overcome flooding in a carbureted engine. The intent of WOT in that case is not to rev up the engine (which is not even running yet) but simply to lean out the air–fuel ratio enough to get the engine started. In electronic control, the feedback between the factors can be finessed and exploited in countless ways, even to the extent that in drive by wire systems the operator's input (which is pedal position) is a completely separate concern from throttle position itself, and the computer constantly makes new decisions about how the two should be correlated when the state of engine running changes from second to second. In the carburetion era, carbs had jets and fuel circuits arranged with a certain logic to overcome the transient differences between throttle position changes and their resultant effects on the engine's running (for example, jets to prevent hesitation).
OBJECTIVES
- To understand the difference between mapped model and a dynamic model.
- To understand the factors which are considered to model fuel flow.
- To run the HEV Reference Application with WOT drive cycle with varying parameters.
- To understand the variation in the results for hybrid vehicles and pure electrical vehicles.
PROBLEM SPECIFICATION AND SOLVING:
PROBLEM STATEMENT I:
What is the difference between mapped and dynamic model of engine, motor, and generator? How can you change model type?
EXPLANATION AND OBSERVATION:
- Powertrain Blockset provides two types of combustion engine models: mapped and dynamic.
- The mapped and dynamic models can be understood in the following way: [4]
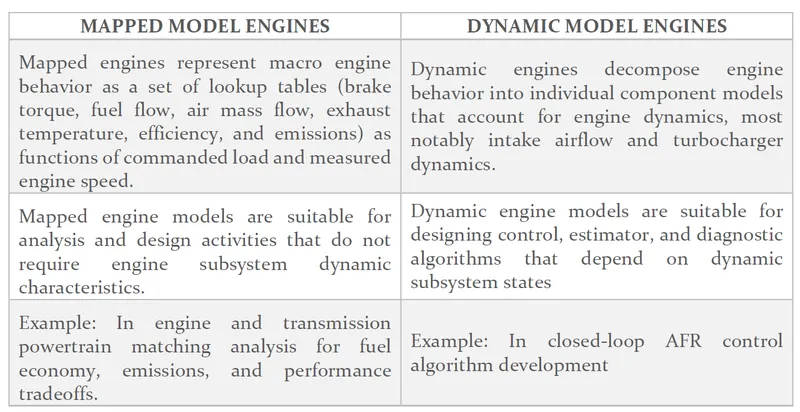
Table 1. Differentiating mapped model and dynamic model
- MAPPED MOTOR: It is a block in Powertrain Blockset which implements a mapped motor and drive electronics operating in torque-control mode. Specify electrical torque range with a torque-speed envelope or maximum motor power and torque. Output torque tracks a torque reference demand and includes a motor and drive response time constant. Specify electrical losses as a single operating point that estimates loss across the operating range, measured loss, or measured efficiency.
This block is used for fast system-level simulations when the user does not know detailed motor parameters, for example, for motor power and torque tradeoff studies. The block assumes that the speed fluctuations due to mechanical load that do not affect the motor torque tracking. [5]
- DYNAMIC MOTOR: It is a complex combination of the three-phase voltage source inverter block [Implements a three-phase voltage source inverter that generates line-to-neutral voltage commands for a balanced three-phase load. Configure the voltage switching function for continuous voltage or inverter switch input signals. To enable electrical loss calculations suitable for memory optimized code generation, select Enable memory optimized 2D LUT] connected to interior PM controller SS torque block [Implements a torque-based, field-oriented controller for an internal permanent magnet synchronous machine (PMSM) with an optional outer-loop speed controller. The torque control implements strategies for maximizing the torque per amp (MTPA) and weakening the magnetic flux] and interior PMSM SS speed block. This gives the user to choose the input data carefully and meticulously. This model motor displays more accuracy.
- MAPPED GENERATOR: It is a block in Powertrain Blockset which implements a mapped motor and drive electronics operating in torque-control mode. Specify electrical torque range with a torque-speed envelope or maximum motor power and torque. Output torque tracks a torque reference demand and includes a motor and drive response time constant. Specify electrical losses as a single operating point that estimates loss across the operating range, measured loss, or measured efficiency.
- DYNAMIC GENERATOR: The layout of the generator is exactly as the dynamic motor with three-phase voltage source connecting interior PM controller SS torque block and interior PMSM SS speed block. This gives the user to choose the input data carefully and meticulously. This model motor displays more accuracy.
- TO CHANGE FROM MAPPED MODEL TO THE DYNAMIC MODEL, THE FOLLOWING STEPS ARE PERFORMED:
- Condition: using the generator system to change mapped generator to dynamic generator.
- Tool bar >> Modelling >> Model Explorer. Then select ‘Model Explorer’.
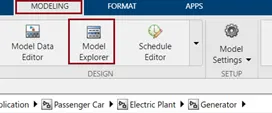
Figure 1. Selecting Model Explorer.
3.In Model Explorer, select the following:
Model hierarchy : Electric Plant
Contents of HevMmreferenceApplication/Passenger Car/Electric Plant (only): Generator (subsystem)
Block parameters Generator : label mode active choice : ‘GenDynamic (GenDynamic)
4. Apply.
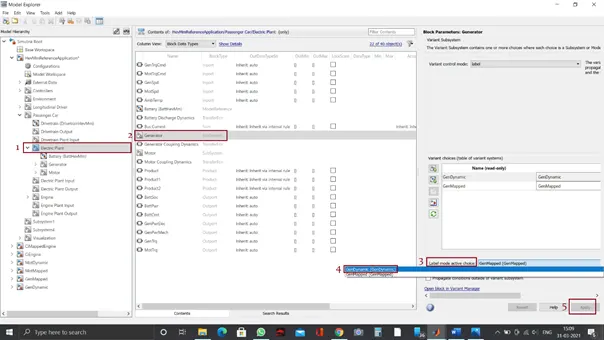
Figure 2. Step-wise process of changing from mapped to dynamic model in Model Explorer.
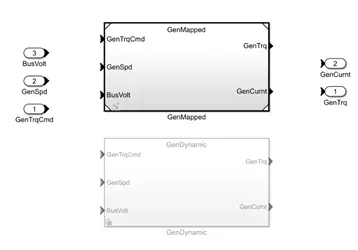
Figure 3. Initial layout of the Generator system.
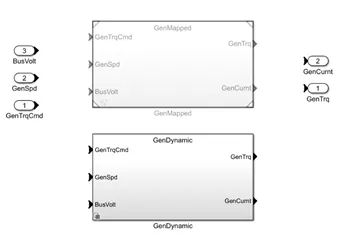
Figure 4. Final layout of the Generator system.
PROBLEM STATEMENT II:
How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
EXPLANATION AND OBSERVATION:
- MILES PER GALLON: Miles per gallon (mpg) is commonly used in the United States, the United Kingdom, and Canada (alongside L/100 km). When the mpg unit is used, it is necessary to identify the type of gallon used: the imperial gallon is 4.54609 liters, and the U.S. gallon is 3.785 liters. When using a measure expressed as distance per fuel unit, a higher number means more efficient, while a lower number means less efficient. [6]
- CALCULATION OF MILES PER GALLON BY THE MODEL:
- On selecting the following the user can understand the layout of the performance calculations: HevMmreferenceApplication >> Visualization >> Performance Calculations
- The distance in ‘meters’ from the vehicle speed block, is converted to miles by using a constant value of gain i.e., 0.000621371.
- The volume from the fuel flowrate block is converted into gallons by using a constant value of gain i.e., 264.172.
- A saturation block is set up in connection with the volume in gallons to limit input signal to the upper and lower saturation values.
- The output from the Saturation block is operated on ‘/’ while the output from distance is operated on ‘*’ and the output obtained is in mile per gallon.
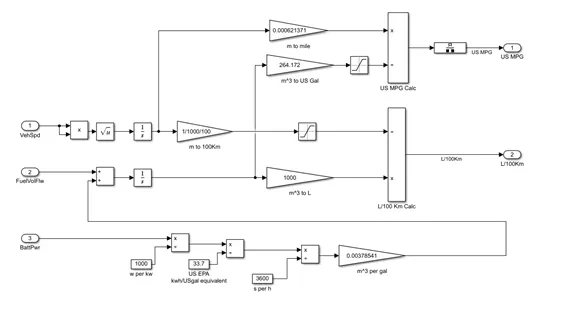
Figure 5. Layout of the Performance Calculations
- Fuel requirement and consumption vary as per the real-time conditions. Therefore, to model the fuel flow to a vehicle, the following aspects must be considered.
- Driving behavior,
- Road conditions,
- Aerodynamics of the vehicle,
- Design of the vehicle,
- Load carrying capacity of the vehicle,
- Fuel injection system,
- Effect of turbo charging,
- Valve timing,
- and other miscellaneous factors.
PROBLEM STATEMENT III:
Run the HEV Reference Application with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
EXPLANATION AND OBSERVATION:
- [7] The hybrid electric vehicle reference application represents a full multimode hybrid electric vehicle (HEV) model with an internal combustion engine, transmission, battery, motor, generator, and associated powertrain control algorithms. Use the reference application for powertrain matching analysis and component selection, control and diagnostic algorithm design, and hardware-in-the-loop (HIL) testing.
- [7] By default, the HEV multimode reference application is configured with Mapped motor and generator; 1.5–L spark-ignition (SI) dynamic engine. This diagram shows the powertrain configuration.
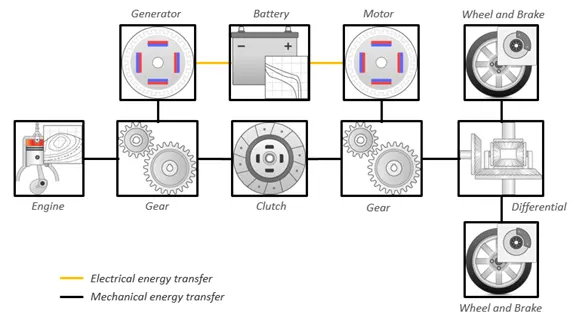
Figure 6. Layout of the Powertrain configuration of HEV.
- The model under consideration is Hybrid Electric Vehicle Multimode Reference Application and is obtained from the following link:
- After opening the model in MATLAB, a window in Simulink named ‘HevMmreferenceApplication’ opens.
- A layout of the hybrid electric vehicle layout in the form of connected subsystems appears as follows:
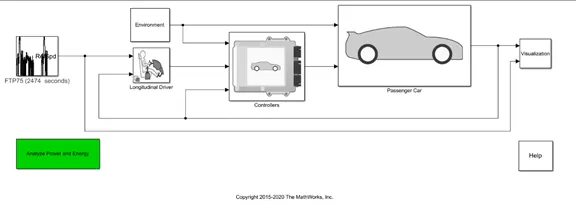
Figure 7. Layout of the Hybrid Electric Vehicle Multimode Reference Application
- The drive cycle, as per the problem statement III must be changed to WOT as follows:
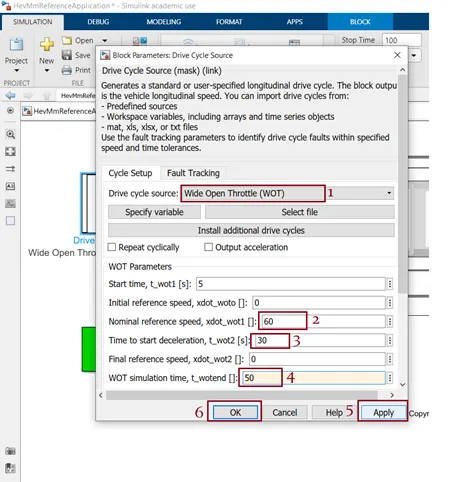
Figure 8. Step-wise process to change the drive cycle to WOT.
- The values set of CASE I are as follows:
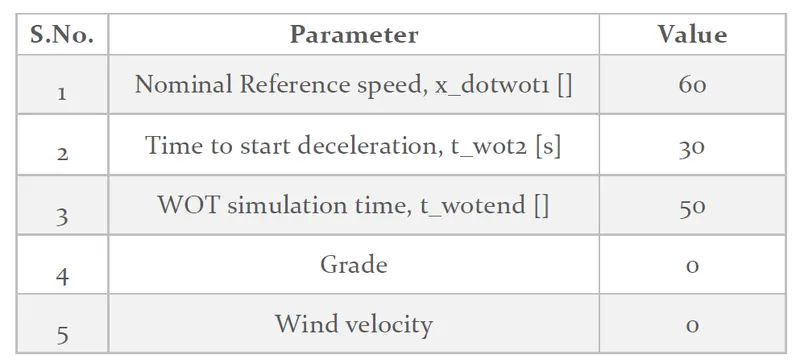
Table 2. Parameter specification.
- The new layout of the entire system is as follows:
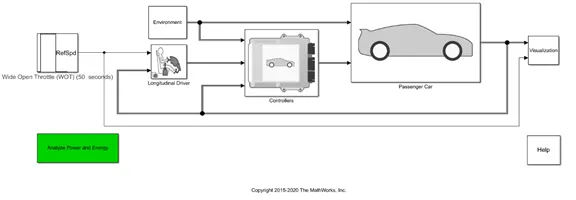
Figure 9. New layout of the Hybrid Electric Vehicle Multimode Reference Application
- Keeping all other parameters same, the total computational time is set to 100 seconds and the model is run.
- The values set of CASE II are as follows:
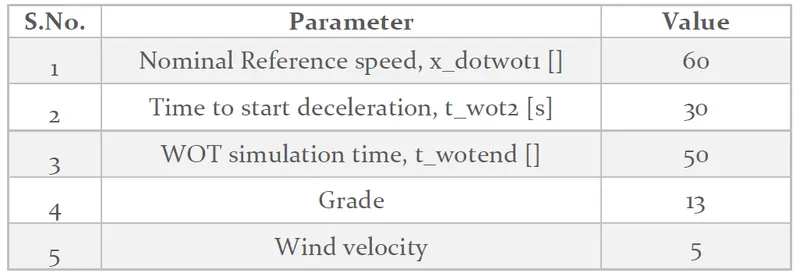
Table 3. Parameter specification.
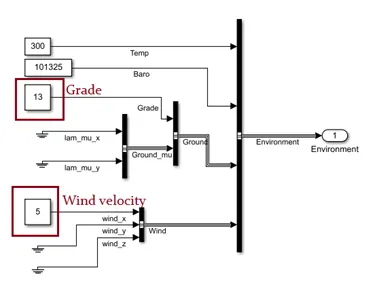
Figure 10. Depicting the change of grade and wind velocity.
- Keeping all other parameters same, the total computational time is set to 100 seconds and the model is run.
- The results of the above-mentioned cases are detailed in the RESULTS section of the report.
PROBLEM STATEMENT IV:
In the above case as mentioned in Problem Statement III, keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
EXPLANATION AND OBSERVATION:
- [8] The electric vehicle reference application represents a full electric vehicle model with a motor-generator, battery, direct-drive transmission, and associated powertrain control algorithms. Use the electric vehicle reference application for powertrain matching analysis and component selection, control and diagnostic algorithm design, and hardware-in-the-loop (HIL) testing.
[8] The electric vehicle reference application is configured with a mapped motor and battery. This diagram shows the powertrain configuration.
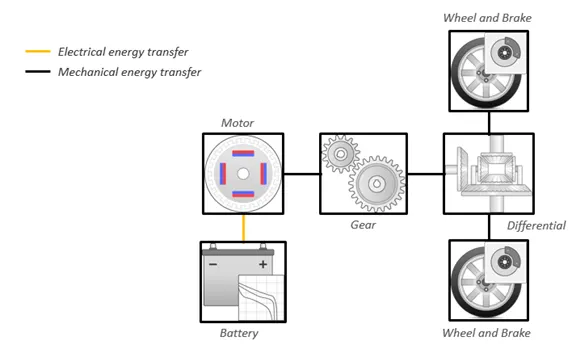
Figure 11. Layout of the Powertrain configuration of EV.
- The model under consideration is Electric Vehicle Reference Application and is obtained from the following link:
https://in.mathworks.com/help/autoblks/ug/explore-the-electric-vehicle-reference-application.html
- After opening the model in MATLAB, a window in Simulink named ‘EvReferenceApplication’ opens.
- A layout of the hybrid electric vehicle layout in the form of connected subsystems appears as follows:
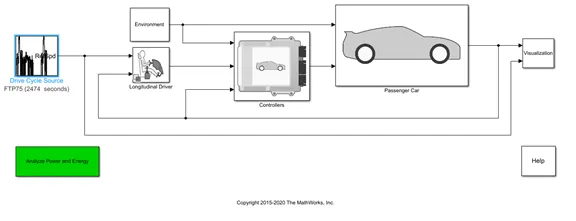
Figure 12. Layout of the Electric Vehicle Reference Application
- The drive cycle, as per the problem statement III must be changed to WOT as follows:
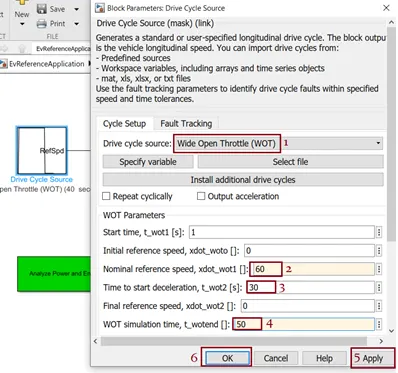
Figure 13. Step-wise process to change the drive cycle to WOT.
- The values set of CASE II are as follows:
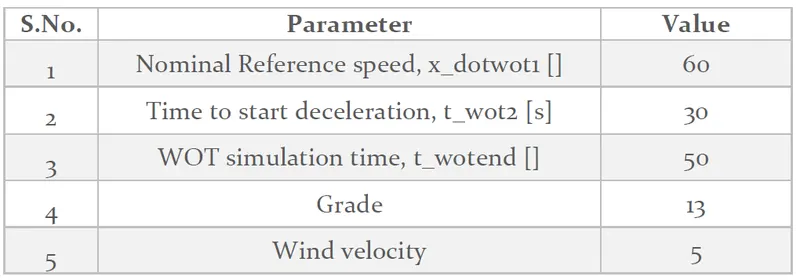
Table 4. Parameter specification.
Figure 14. Depicting the change of grade and wind velocity.
- Keeping all other parameters same, the total computational time is set to 100 seconds and the model is run.
- The results of the above-mentioned cases are detailed in the RESULTS section of the report.
RESULTS
- The difference between mapped and dynamic models is clearly detailed under problem statement I.
- The calculation of the miles per gallon by the model is clearly explained under the problem statement II.
- The results of HEV Reference Application with WOT drive cycle evaluation without changing the grade and wind velocity:
The following table depicts the limiting values of the evaluation:
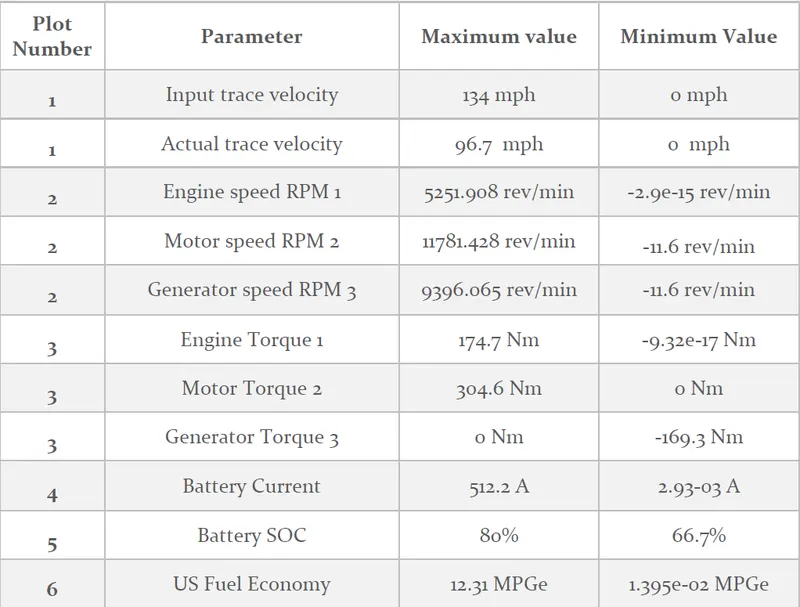
Table 5. Results of HEV without grade and wind velocity in WOT drive cycle.
PLOT I – Graph between Velocity and simulation time:
- X axis data is time in seconds and Y axis data is velocity in miles per hour (mph).
- Two velocities input velocity as per WOT condition and actual velocity considering the availability of power.
- From the graph, it is certain that the acceleration time for ideal input velocity is 5.347 mph/s.
- The acceleration time for the actual velocity input considering the availability of power and other losses is about 3.848 mph/s.
PLOT II – Graph between Engine, Motor and Generator speeds and simulation time:
- X axis data is time in seconds and Y axis data is velocity in rpm.
- Three values of speed namely engine speed, motor speed and generator speed are plotted with values corresponding to rpm 1 , rpm 2 and rpm 3 respectively.
- Time taken to reach maximum value of engine speed is 30.483 sec.
- Time taken to reach maximum value of motor speed is 28.966 sec.
- Time taken to reach maximum value of generator speed is 30.207 sec.
- The value of engine speed at maximum velocity is 5295.923 rpm.
- The value of motor speed at maximum velocity is 11764.016 rpm.
- The value of generator speed at maximum velocity is 5295.923 rpm.
PLOT III – Graph between Engine, Motor and Generator torques and simulation time:
- X axis data is time in seconds and Y axis data is torque in Nm.
- Three values of speed namely engine speed, motor speed and generator speed are plotted with values corresponding to Nm 1 , Nm 2 and Nm 3 respectively.
- Time taken to reach maximum value of engine torque is 23.586 sec.
- Time taken to reach maximum value of motor torque is 4.414 sec.
- Time taken to reach minimum value of generator torque is 19.172 sec.
- The value of engine torque at maximum velocity is 162.7 Nm.
- The value of motor torque at maximum velocity is 100.7 Nm.
- The value of generator torque at maximum velocity is -163.4 Nm.
PLOT IV – Graph between Battery Current and simulation time:
- X axis data is time in seconds and Y axis data is Battery current in amperes.
- Time taken to reach maximum battery current is 5.391 sec.
- The value of battery current at maximum velocity is 187.9 A.
PLOT V – Graph between Battery SOC and simulation time:
- X axis data is time in seconds and Y axis data is Battery SOC.
- The time taken to reach minimum battery SOC is 25.691 sec.
- The value of battery SOC at maximum velocity is 66.9%
PLOT V – Graph between US Fuel Economy MPGe and simulation time:
- X axis data is time in seconds and Y axis data is Battery SOC.
- The time taken to reach maximum value is 17.517 sec.
- The value of US Fuel economy MPGe at maximum velocity is 108.9 MPGe.
- The results of HEV Reference Application with WOT drive cycle evaluation by changing the grade and wind velocity:
The following table depicts the limiting values of the evaluation:
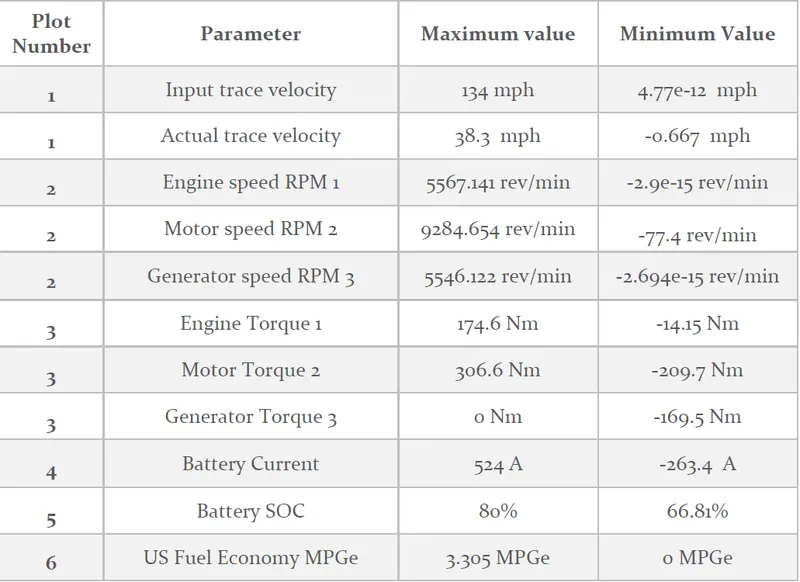
Table 6. Results of HEV without grade and wind velocity in WOT drive cycle.
PLOT I – Graph between Velocity and simulation time:
- X axis data is time in seconds and Y axis data is velocity in miles per hour (mph).
- Two velocities input velocity as per WOT condition and actual velocity considering the availability of power.
- From the graph, it is certain that the acceleration time for ideal input velocity is 5.376 mph/s.
- The acceleration time for the actual velocity input considering the availability of power and other losses is about 1.562 mph/s.
PLOT II – Graph between Engine, Motor and Generator speeds and simulation time:
- X axis data is time in seconds and Y axis data is velocity in rpm.
- Three values of speed namely engine speed, motor speed and generator speed are plotted with values corresponding to rpm 1 , rpm 2 and rpm 3 respectively.
- Time taken to reach maximum value of engine speed is 31.103 sec.
- Time taken to reach maximum value of motor speed is 6.414 sec.
- Time taken to reach maximum value of generator speed is 30.828 sec.
- The value of engine speed at maximum velocity is 5251.908 rpm.
- The value of motor speed at maximum velocity is 5034.317 rpm.
- The value of generator speed at maximum velocity is 5251.908 rpm.
PLOT III – Graph between Engine, Motor and Generator torques and simulation time:
- X axis data is time in seconds and Y axis data is torque in Nm.
- Three values of speed namely engine speed, motor speed and generator speed are plotted with values corresponding to Nm 1 , Nm 2 and Nm 3 respectively.
- Time taken to reach maximum value of engine torque is 24.483 sec.
- Time taken to reach maximum value of motor torque is 5.586 sec.
- Time taken to reach minimum value of generator torque is 29.862 sec.
- The value of engine torque at maximum velocity is 167.5 Nm.
- The value of motor torque at maximum velocity is 227.9 Nm.
- The value of generator torque at maximum velocity is -168.8 Nm.
PLOT IV – Graph between Battery Current and simulation time:
- X axis data is time in seconds and Y axis data is Battery current in amperes.
- Time taken to reach maximum battery current is 22.275 sec.
- The value of battery current at maximum velocity is 179.5 A.
PLOT V – Graph between Battery SOC and simulation time:
- X axis data is time in seconds and Y axis data is Battery SOC.
- The time taken to reach minimum battery SOC is 29.905 sec.
- The value of battery SOC at maximum velocity is 13.23%.
PLOT V – Graph between US Fuel Economy MPGe and simulation time:
- X axis data is time in seconds and Y axis data is Battery SOC.
- The time taken to reach maximum value is 31.54 sec.
- The value of US Fuel economy MPGe at maximum velocity is 3.215 MPGe.
- The comparison of the results of the HEV Reference Application with WOT drive cycle under zero grade and zero wind velocity conditions and with grade and wind velocity conditions are as follows:
It is evident that actual velocity in figure 15 is more than actual velocity in figure 16.It is evident that the actual velocity is largely affected with the presence of grade and wind velocity. Large fluctuations in motor speed and subsequently in the motor torque is observed due to the presence of road elevation and opposing wind velocity in the X direction. In the figure 15, it can be noticed that the battery charge fluctuations have smaller magnitude but are concentrated in certain areas. But with the inclusion of grade and opposing wind velocity, the fluctuations in battery charge is very small and evenly distributed as compared to the earlier case.
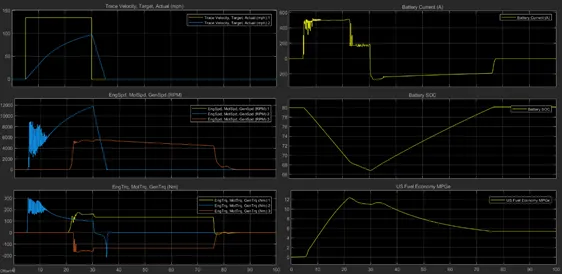
Figure 15. Results of HEV reference application with WOT drive cycle without grade and wind velocity.
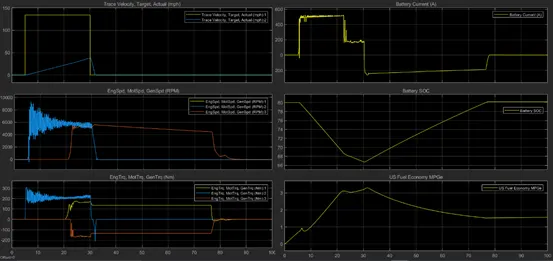
Figure 16. Results of HEV reference application with WOT drive cycle with modified grade and wind velocity.
The generator speed and torque, engine speed and torque almost remain analogous to each other in both the cases. Although, there is a change in the values in both the cases, the change is not that significant. The values of minimum SOC in both the cases is insignificantly small. But the fuel economy in the first case is more than that in the latter case. In both the cases, the motor initially achieves the maximum velocity and later on, the engine supports it in adding more energy based on the drive cycle condition. The negative value of the generator can indicate the regeneration of charge. The negative charge value is the indicative of regenerative braking and/or perhaps charging.
- The results of EV Reference Application with WOT drive cycle evaluation by changing the grade and wind velocity:
The following table depicts the limiting values of the evaluation:
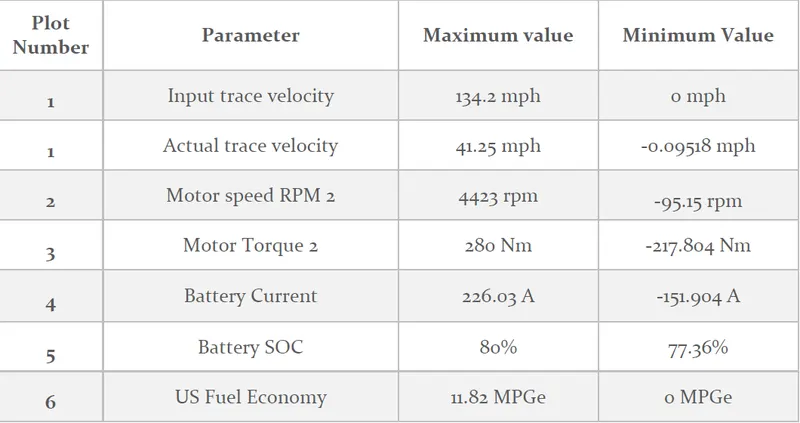
Table 7. Results of EV with grade and wind velocity in WOT drive cycle.
PLOT I – Graph between Velocity and simulation time:
- X axis data is time in seconds and Y axis data is velocity in miles per hour (mph).
- Two velocities input velocity as per WOT condition and actual velocity considering the availability of power.
- From the graph, it is certain that the acceleration time for ideal input velocity is 0 mph/s.
- The acceleration time for the actual velocity input considering the availability of power and other losses is about 1.472 mph/s.
PLOT II – Graph between Motor speed and simulation time:
- X axis data is time in seconds and Y axis data is velocity in rpm.
- The motor speed is plotted with value corresponding to rpm 1.
- Time taken to reach maximum value of motor speed is 29.809 sec.
- The value of motor speed at maximum velocity is 442.6 rpm.
PLOT III – Graph between Motor torque and simulation time:
- X axis data is time in seconds and Y axis data is torque in Nm.
- The motor torque is plotted with value corresponding to Nm 1.
- Time taken to reach maximum value of motor torque is 1.432 sec.
- The value of motor torque at maximum velocity is 163.018 Nm.
PLOT IV – Graph between Battery Current and simulation time:
- X axis data is time in seconds and Y axis data is Battery current in amperes.
- Time taken to reach maximum battery current is 1.567 sec.
- The value of battery current at maximum velocity is 215.991 A.
PLOT V – Graph between Battery SOC and simulation time:
- X axis data is time in seconds and Y axis data is Battery SOC.
- The time taken to reach minimum battery SOC is 30.313 sec.
- The value of battery SOC at maximum velocity is 77.37%.
PLOT V – Graph between US Fuel Economy and simulation time:
- X axis data is time in seconds and Y axis data is US Fuel Economy.
- The time taken to reach maximum value is 100 sec.
- The value of US Fuel economy at maximum velocity is 9.386 MPGe.
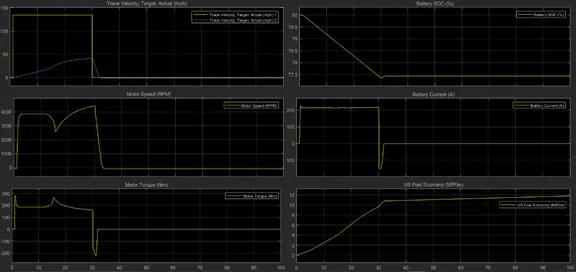
Figure 17. Results of EV reference application with WOT drive cycle with modified grade and wind velocity.
- The comparison of the results of the HEV Reference Application with WOT drive cycle and with grade and wind velocity conditions and EV Reference Application with WOT drive cycle and with grade and wind velocity conditions are as follows:
The major difference that catches the eye of the programmer is that the absence of engine and generator in EV which is a part of its nature.The following data elucidates the differences in simulation of EV and HEV subjected to same conditions as drive cycle, grade and opposing wind velocity.
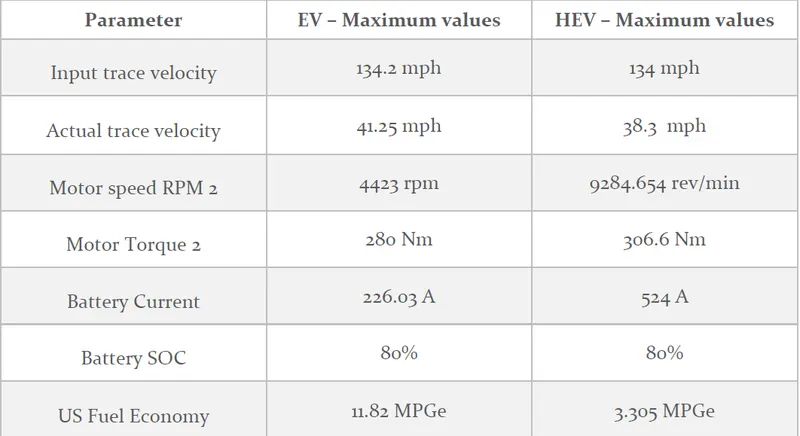
Table 8. Comparison of results of EV and HEV with grade and wind velocity in WOT drive cycle depicting maximum values.
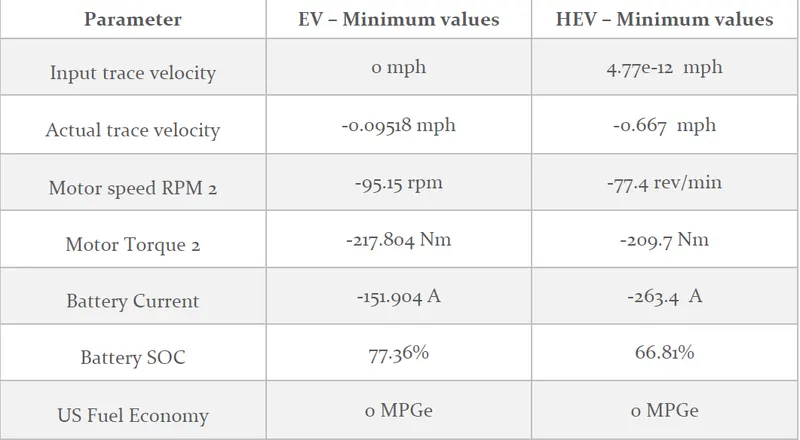
Table 9. Comparison of results of EV and HEV with grade and wind velocity in WOT drive cycle depicting minimum values.
The battery SOC from the table 9 shows that the EV can produce instant torque compared to HEV. The charging of battery is more in the case of HEV due the presence of the generator. From the table 8, it is evident that the EV give more fuel economy as compared to the HEV. The velocities attained by the EV is higher than that of the HEV due to its weight, composition and working.
CONCLUSION
The required problems have been solved and justified with appropriate results. Dynamic model gives more accurate results compared to mapped models as it uses realistic data inputs from time to time and therefore takes longer to evaluate. The US miles per gallon is the measurement of fuel economy based on distance travelled per gallon of fuel. From the evaluations, it is safe to consider that the pure EV produce highest fuel economy along with zero emissions while HEV has moderate economy with comparatively less emissions as compared to conventional vehicles that use fossil fuels. The HEV produces better results when it is not subjected to a road inclination and opposing wind. Under similar conditions of grade and opposing wind, the EV shows better results compared to HEV in terms of SOC and Fuel economy along with maximum speed. But, the power developed by the HEV is more useful when the vehicle is subjected to difficult terrains and large initial acceleration requirement.
BIBLIOGRAPHY
- https://en.wikipedia.org/wiki/Electric_motorcycles_and_scooters
- https://in.mathworks.com/products/powertrain.html
- https://en.wikipedia.org/wiki/Wide_open_throttle#:~:text=Wide%20open%20throttle%20or%20wide,combustion%20engine%20or%20steam%20engine).
- https://in.mathworks.com/products/powertrain.html
- https://in.mathworks.com/help/autoblks/ref/mappedmotor.html?s_tid=srchtitle
- https://en.wikipedia.org/wiki/Fuel_economy_in_automobiles
- https://in.mathworks.com/help/autoblks/ug/explore-the-hybrid-electric-vehicle-multimode-reference-application.html
- https://in.mathworks.com/help/autoblks/ug/explore-the-electric-vehicle-reference-application.html