Joint creation between Rigid and Deformable bodies
OBJECTIVE:
Create the following set of joints between two rigid bodies and two deformable bodies.
- Spherical joint
- Revolute joint
- Cylindrical joint
- Translational joint
DELIVERABLES:
Animation of joints to show the mechanism of joints
Demonstrations of joints to determine the dof associated with joint.3
Keyword files for each joint.
DESIGN OF REPORT:
1. Joints for Rigid bodies.
2. Joints for Deformable bodies.
JOINTS FOR RIGID BODIES:
Material for Rigid Body
- Material card: MAT_020
- MID, E, `rho`, `v`
- COM. CON1 or CON2 be entered if required.
Material is defined for Steel
i.e E = 210GPa, `rho` = 7.8`times``10^-6` Kg/`mm^3`, `v` = 0.3
Boundary conditions:
A LCID is defined for the motion using *DEFINE_CURVE
Motion could be linear or constant.
*PRESCRIBED_MOTION_RIGID
PID = Part in motion
DOF = translational or rotational in x,y or z.
VAD = 0 (velocity for rigid body/nodes)
LCID = ID for described load curve for motion.
SF = Scale factor
VID = A defined vector using *DEFINE_VECTOR in case of DOF = 4 or 8.
Control cards:
*CONTROL_TIMESTEP is defined using a curve. A constant interval for entire duration of experiment.
Here,
*CONTROL_TERMINATION = 10ms
LCID_timestep curve is as follows:
| Time (ms) | Time step (ms) |
| 0.0 | 0.1 |
| 10 | 0.1 |
| 10.5 | 0.1 |
Output Files:
*Database_Binary_D3plot
*Database_ASCII (GLSTAT, JNTFORC, RBDOUT)
GLSTAT - Store global energy data.
JNTFORC - Joint forces.
RBDOUT - Rigid body data.
1. Spherical Joint:
Reason for constrained rigid motion: A coincident node remains coincident through out the motion.
The spherical joints is a spherical member which share a mutual point of coincidence about which the assembly rotates.
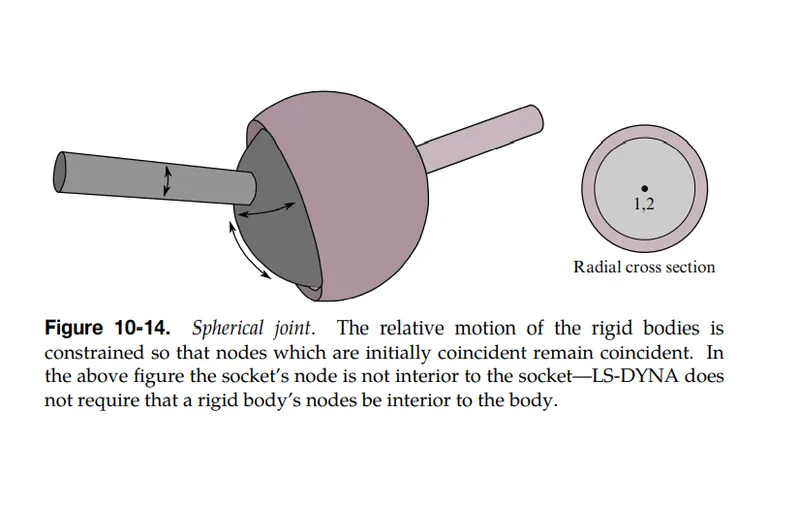
Fig 1: Description and figure for spherical joint.
Number of fixed nodes = 2
Type of motion = Rotational degree of freedom about axis passing through point of coincidence.
Modelling of Spherical joint in LS DYNA
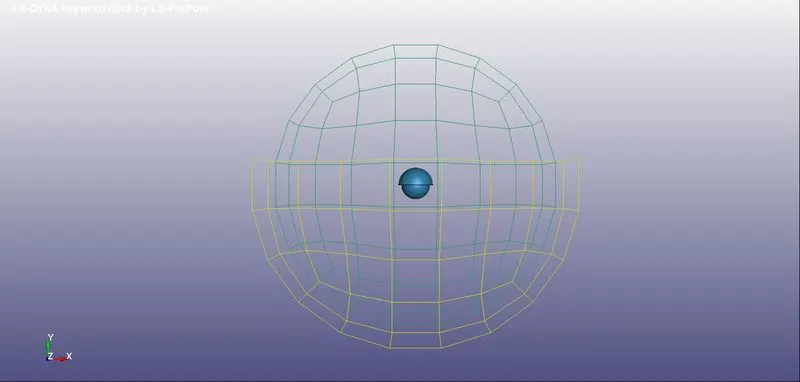
Fig2: Spherical joint for sphere shells.
1. Creating shell sphere: Elements and Mesh > Shape Mesher > Sphere shell > Enter position and radius, Enter mesh size or density, Part ID and Part name > Create >Accept > Done.
2. Creating temp nodes (point of coincidence) one for each part: Element and MEsh > Node editing > Create > Enter coordinates (along COM), Node ID > Accept>Done
3. *CONSTRAINT_EXTRA_NODE_NODE is defined to link the temp node for each part.
PATRT_ID, NID is defined to gether.
4. *CONSTRAINED_JOINT_SPHERICAL is defined to specify the nodes coinciding eachother and about which relative motion has to take place.
5. BCs, LCs, Output files and Material are assigned as discussed above.
Simulation:
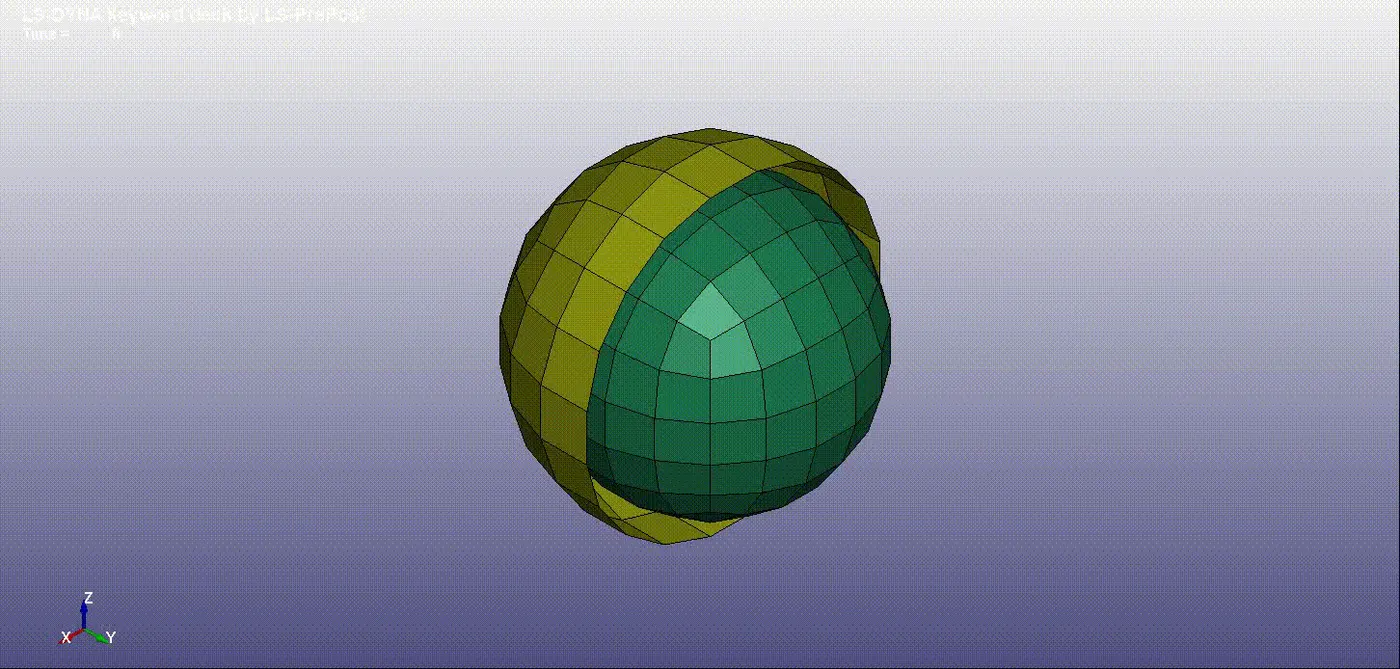
Simulation1: Rotation of Ball in socket around y axis. However it can rotate at cosines of x and z as well.
2. Revolute Joint:
Reason for relative motion is the constraint using a mutual axis.
joined members are joined about an axis of rotation.
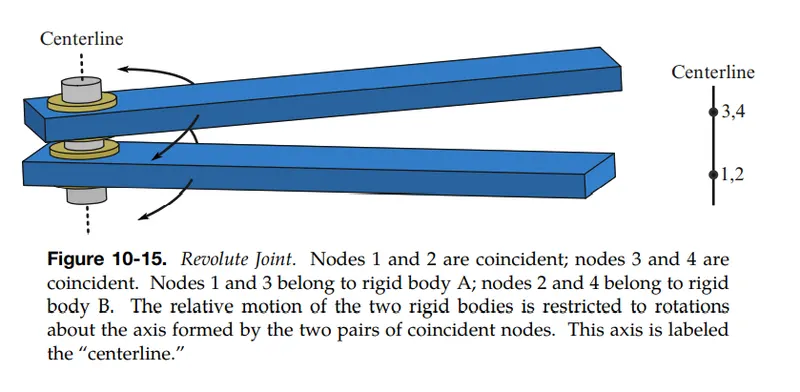
Fig3: Description and figure for revolute joint.
Number of fixed nodes = 4
Type of motion = Rotational degree of freedom about axis passing through two point of coincidence.
Modelling of Revolute joint in LS DYNA
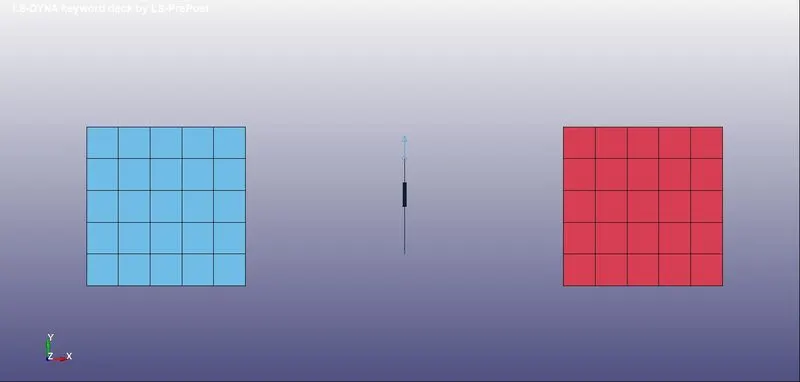
Fig4: Revolute joint for square shell plates.
1. Creating planar shell paltes: Elements and Mesh > Shape Mesher > 4N shell > Enter position, Enter mesh size or density, Part ID and Part name > Create >Accept > Done.
2. Creating temp nodes (point of coincidence) two for each part: Element and Mesh > Node editing > Create > Enter coordinates between two shell memebers), Node ID > Accept>Done
3. *CONSTRAINT_EXTRA_NODE_NODE is defined to link the temp nodes for each part.
PATRT_ID, NID is defined to gether.
4. *CONSTRAINED_JOINT_REVOLUTE is defined to specify the nodes coinciding eachother and about which relative motion has to take place.
5. BCs, LCs, Output files and Material are assigned as discussed above.
Simulation:
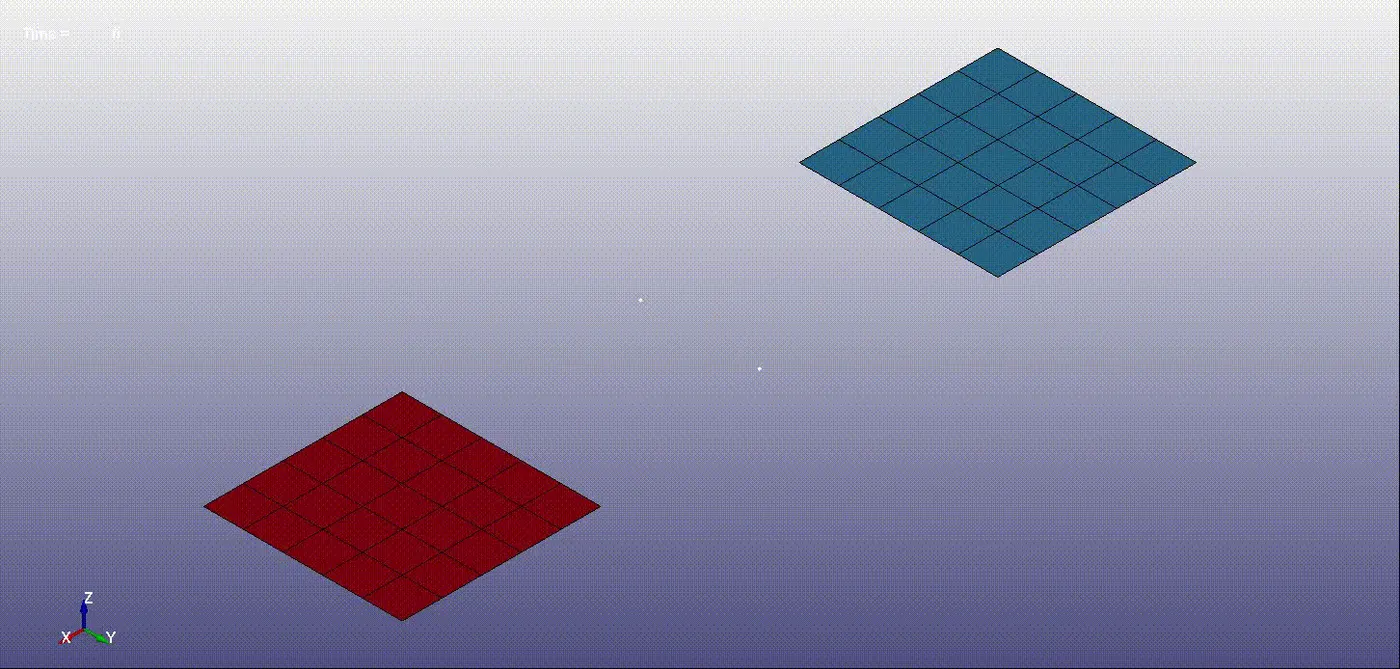
Simulation2: Revolution of square shell around y axis.
3. Cylindrical Joint:
Reason for relative motion is the constraint using a mutual axis.
joined members are joined about an axis of rotation.
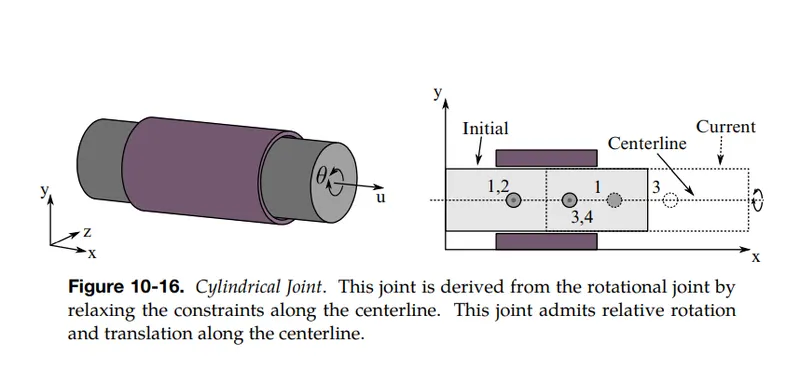
Fig5: Description and figure for Cylindrical joint.
Number of fixed nodes = 4
Type of motion = Rotational degree of freedom about axis passing through two point of coincidence. translational degree of freedom along axis passing through two points of coincidence.
Modelling of Cylindrical joint in LS DYNA
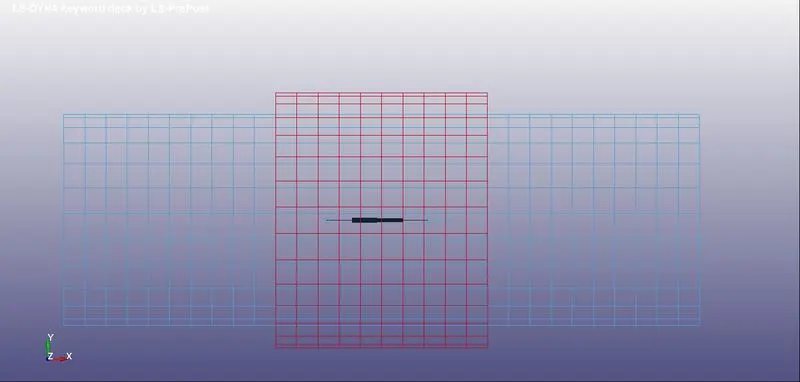
Fig6: Cylindrical joint for Cylindrical shell plates.
1. Creating cylinder shell: Elements and Mesh > Shape Mesher > Cylinder shell > Enter position, radius, Enter mesh size or density, Part ID and Part name > Create >Accept > Done.
2. Creating temp nodes (point of coincidence) two for each part: Element and Mesh > Node editing > Create > Enter coordinates along mutual axis of rotation, Node IDs > Accept>Done
3. *CONSTRAINT_EXTRA_NODE_NODE is defined to link the temp nodes for each part.
PATRT_ID, NID is defined together.
4. *CONSTRAINED_JOINT_CYLINDRICAL is defined to specify the nodes coinciding eachother and about which relative motion has to take place.
5. BCs, LCs, Output files and Material are assigned as discussed above.
Simulation:
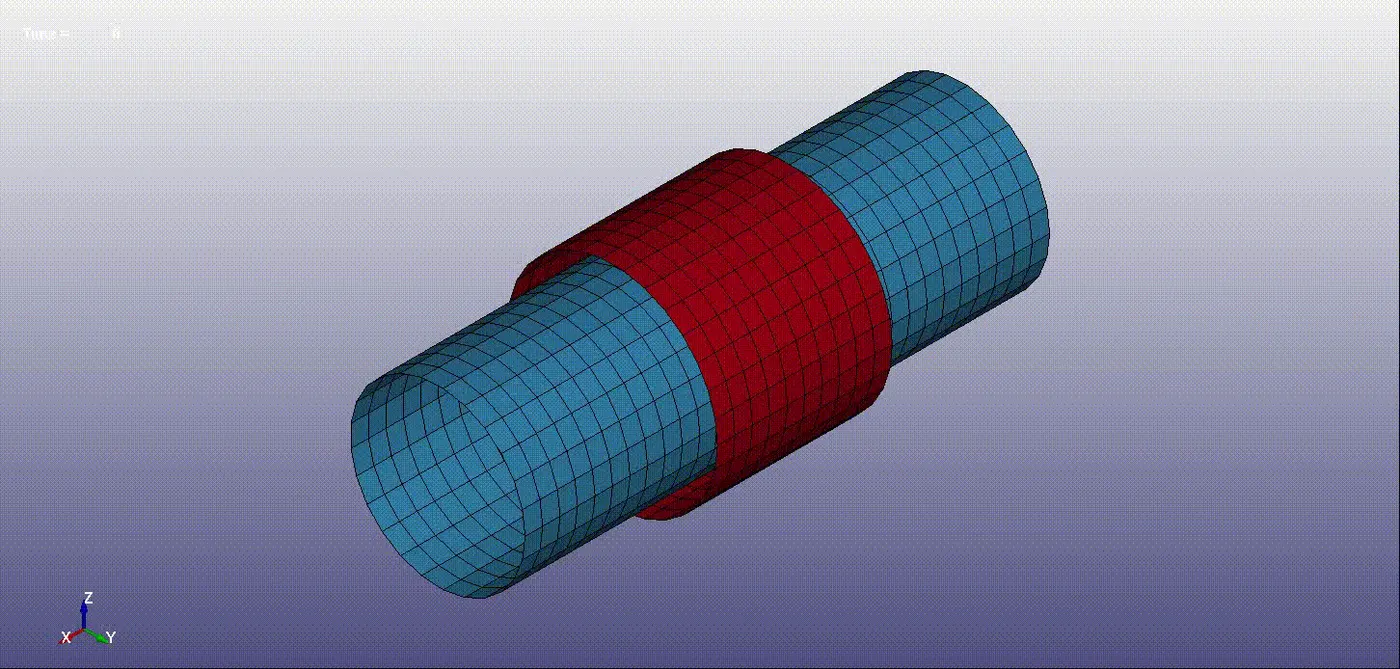
Simulation3: Rotation and translation of cylinder shell along x axis.
4. Translation Joint:
Reason for relative motion is the constraint using a mutual axis and a constraint to avoid revolution along that mutual axis.
joined members are joined about an axis of slide.
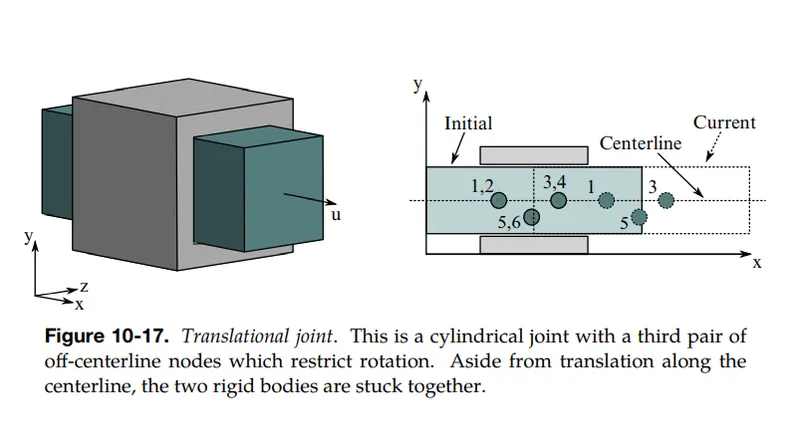
Fig7: Description and figure for Translation joint.
Number of fixed nodes = 6
Type of motion = Translational degree of freedom along axis passing through two points of coincidence.
Modelling of Cylindrical joint in LS DYNA
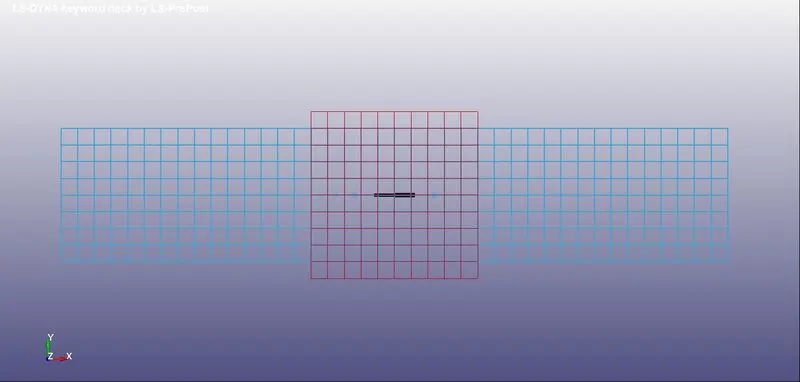
Fig8:Translation joint for Sauare shell columns.
1. Creating square column shell: Elements and Mesh > Shape Mesher > Box shell > Enter position, Enter mesh size or density, Part ID and Part name > Create >Accept > Done.
2. Creating temp nodes (point of coincidence) two for each part: Element and Mesh > Node editing > Create > Enter coordinates along mutual axis of rotation, Node IDs > Accept>Done
3. *CONSTRAINT_EXTRA_NODE_NODE is defined to link the temp nodes for each part.
PATRT_ID, NID is defined together.
4. *CONSTRAINED_JOINT_TRANSLATIONAL is defined to specify the nodes coinciding eachother and about which relative motion has to take place.
5. BCs, LCs, Output files and Material are assigned as discussed above.
Simulation:
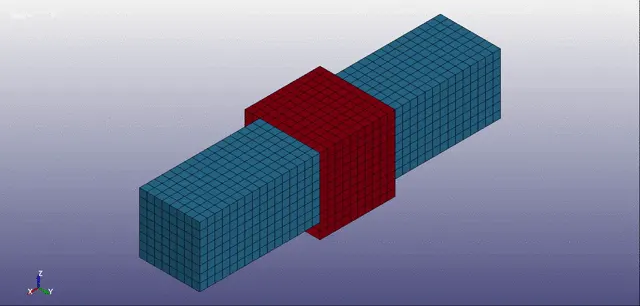
Simulation4: Translation of square column shell along x axis.
JOINTS FOR DEFORMABLE BODIES:
Material for Rigid Body
- Material card: MAT_001
- MID, E, `rho`, `v`
Material is defined for Steel
i.e E = 210GPa, `rho` = 7.8`times``10^-6` Kg/`mm^3`, `v` = 0.3
Boundary conditions:
*CONSTRAINED_NODAL_RIGID_BODY
PID = Part in motion
NSID = Chosen slave nodes and centre master node (MNID = 305)
Output files:
*Database_Binary_D3plot
*Database_ASCII (GLSTAT)
GLSTAT - Store global energy data.
1. Spherical Joint:
Number of central master nodes = 2
Type of motion = Fixed as connected by rigid elements.
Modelling of Spherical joint in LS DYNA
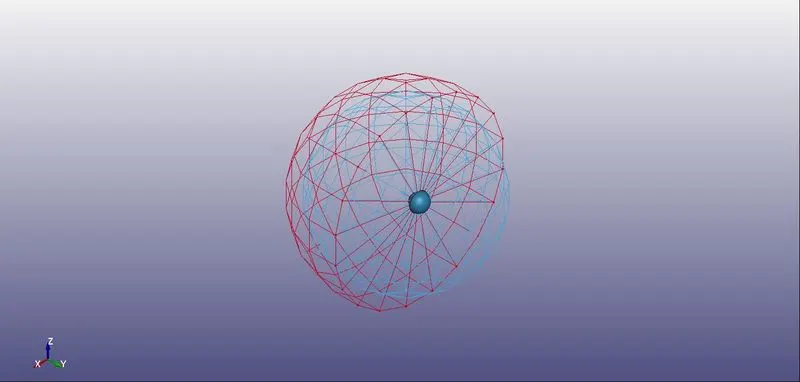
Fig9: Spherical joint for sphere shells using rigid elements.
1. Creating shell sphere: Elements and Mesh > Shape Mesher > Sphere shell > Enter position and radius, Enter mesh size or density, Part ID and Part name > Create >Accept > Done.
2. Creating temp nodes (point of coincidence) one for each part: Element and MEsh > Node editing > Create > Enter coordinates (along COM), Node ID > Accept>Done
3. *CONSTRAINT_Nodal_Rigid_Body is defined to link the temp node for each part.
PATRT_ID, NID is defined together.
4. *CONSTRAINED_JOINT_SPHERICAL is defined to specify the master nodes connecting CNRBs for bot spheres.
2. Revolute Joint:
Reason for relative motion is the constraint using a rigid nodes.
joined members are joined about an axis of rotation.
Number of fixed nodes = 4
Type of motion = Fixed as connected by rigid elements
Modelling of Revolute joint in LS DYNA
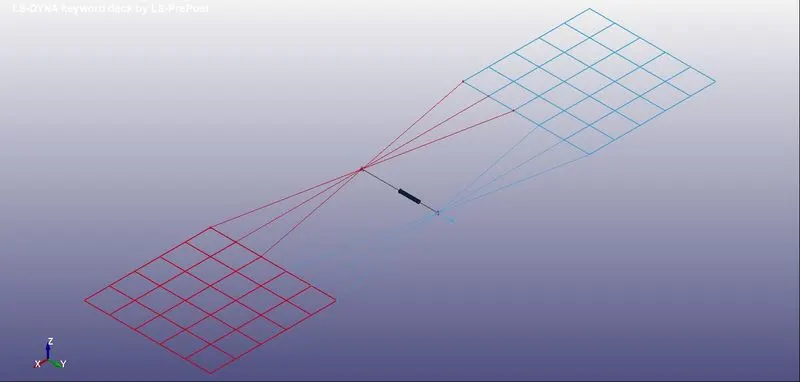
Fig10: Revolute joint for square shell plates using rigid elements.
1. Creating planar shell paltes: Elements and Mesh > Shape Mesher > 4N shell > Enter position, Enter mesh size or density, Part ID and Part name > Create >Accept > Done.
2. Creating temp nodes (point of coincidence) two for each part: Element and Mesh > Node editing > Create > Enter coordinates between two shell memebers), Node ID > Accept>Done
3. *CONSTRAINT_NODAL_RIGID_BODY is defined to link the temp nodes for each part.
PATRT_ID, NID is defined to gether.
4. *CONSTRAINED_JOINT_REVOLUTE is defined to specify the master nodes formed by CNRBs for each shell.
3. CylindricalJoint:
Reason for relative motion is the constraint using a mutual axis and a constraint to avoid revolution along that mutual axis.
joined members are joined about an axis of slide.
Number of fixed nodes = 4
Modelling of Cylindrical joint in LS DYNA
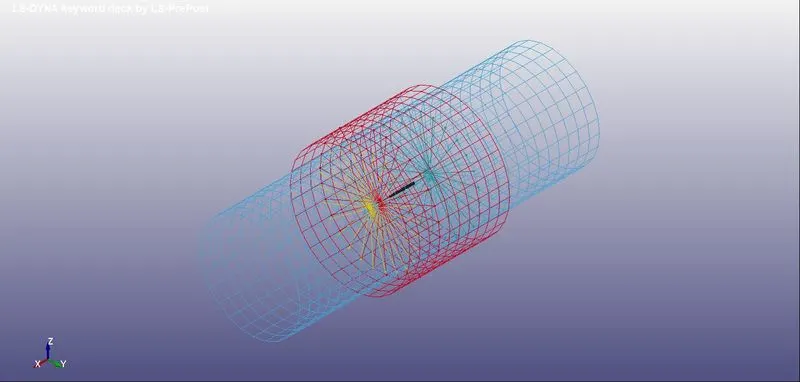
Fig11:Translation joint for cylindrical shell columns with rigid elements.
1. Creating square column shell: Elements and Mesh > Shape Mesher > Box shell > Enter position, Enter mesh size or density, Part ID and Part name > Create >Accept > Done.
2. Creating temp nodes (point of coincidence) two for each part: Element and Mesh > Node editing > Create > Enter coordinates along mutual axis of rotation, Node IDs > Accept>Done
3. *CONSTRAINT_NODAL_RIGID_BODY is defined to link the temp nodes for each part.
PATRT_ID, NID is defined together.
4. *CONSTRAINED_JOINT_CYLINDRICAL is defined to sjoin the master nodes with slave nodes.
4. Translation Joint:
Reason for relative motion is the constraint using a mutual axis and a constraint to avoid revolution along that mutual axis.
joined members are joined about an axis of slide.
Number of fixed nodes = 6
Modelling of Cylindrical joint in LS DYNA
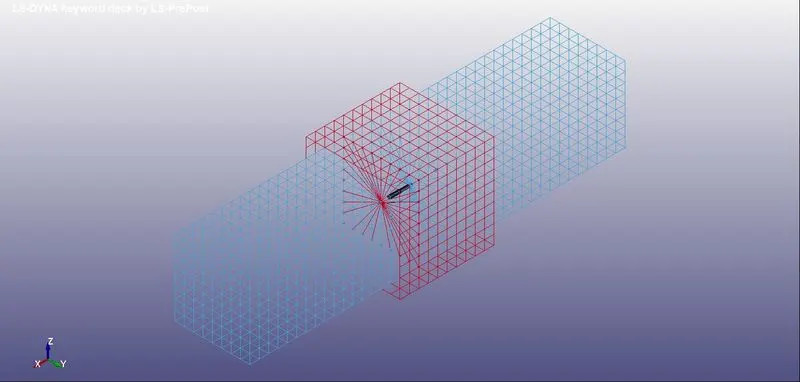
Fig12:Translation joint for Square shell columns.
1. Creating square column shell: Elements and Mesh > Shape Mesher > Box shell > Enter position, Enter mesh size or density, Part ID and Part name > Create >Accept > Done.
2. Creating temp nodes (point of coincidence) two for each part: Element and Mesh > Node editing > Create > Enter coordinates along mutual axis of rotation, Node IDs > Accept>Done
3. *CONSTRAINT_NODAL_RIGID_BODY is defined to link the temp nodes for each part.
PATRT_ID, NID is defined together.
4. *CONSTRAINED_JOINT_TRANSLATIONAL is defined to specify the nodes coinciding eachother and about which relative motion is rigidised.
CONCLUSION:
Nodes need to be coincident for a joint to form.
In rigid bodies, joints created via nodes, nodes are assigned to part ids using *Constrained_Extra_node_node.
In deformable bodies, joints are created by CNRBs (*Constrained_Nodal_Rigid_Bodies)
There are various card to create various kinds of joints, Ex:
- Spherical joint - *Constrained_Spherical
- Cylindrical joint - *Constrained_Cylindrical
- Revolute joint - *Constrained_Revolute
- Translational joint - *Constrained_Translational
Each joint has certain dofs, basically relative motion between two bodies can be constrained about coinciding nodes (spherical) or mutual axis of rotation (revolute) of slide (translational) or rotation or both (cylindrical).