Vehicle frontal crash for various cases - Simplified | FMVSS 208 Rigid Barrier, perpendicular, 100% Overlap at 56kmph. | ECE-R 94, Car to car frontal crash, 50% overlap at 50Kmph.
OBJECTIVE:
- To study the vehicle front crash.
- To understand the solver deck for this exercise.
- To understand the contacts, motion, and physics behind the vehicle crash.
- Output files associated with the practise.
- Correlation for Car crash with NCAP-36 load cell wall.
DESIGN OF EXPERIMENT
- CASE 1: To understand the crash, we start with a very simple case in which a simple chassis is collided with a rigid wall.
- CASE 2: Frontal Impact FMVSS 208 Full frontal, perpendicular at 56 kmph (Car 1)
- CASE 3: Frontal Impact FMVSS 208 Full frontal, perpendicular at 56 kmph (Car 2)
- CASE 4: Frontal Impact ECE-R 94 Car to car crash with a collision speed of each 50kmph and 50% overlap.
Lesson learnt in each case:
- CASE 1: To understand the basic solver deck, and output files created for frontal crash.
- CASE 2 & 3: To understand the solver deck, output files, correlations created for frontal crash in detail.
- CASE 4: To understand the solver deck, output files, correlations created for frontal crash in detail.
NOTE:
Seatbelts, Crash dummies and Airbag related studies are absent in the report. Here, basic goal is to understand the test setup and correlations.
Passive safety and rating calculations arenot part of this report.
It strictly demonstrates the experimental set up for FMVSS 208 Frontal impact with Rigid Barrier.
It strictly demonstrates the experiment setup for ECE-R 94 Car to car crash with a collision speed of 50kmph each and 50% overlap.
However, crash dummies for FMVSS 208 and ECE-R 94 are discussed in detail.
THEORY RELATED TO PASSIVE SAFETY, DUMMIES, FMVSS 208 REGULATION AND RATING CALCULATION AS PER USNCAP
This theory is to understand the dummies, and rating calculations and to understand the FMVSS 208 regulation.
Frontal Impact
MORE ABOUT DUMMIES
1. What is a dummy?
Dummies are mechanical surrogates of the human body. Thus, they are also called: ANTHROPOMORPHIC TEST DEVICES
2. Applications of dummy in automotive crash and safety?
To measure the impact loading of different body parts (by using a suit of instrumenetation built into dummy). To correctly load a vehicle to assess type and severity of injury by mimicking human dynamic impact responses.
3. Dummy Terminology:
- Percentile
- Anthropometry
- Biofidelity
- Measuring capability
- Repeatability
- Reproducibility
- Durability
- Sensitivity
- Simplicity and ease of use.
1. Percentile:
Size of adult dummies are expressed as 'Percentiles'
Percentile masses are:
- 5th Percentile
- 50th Percentile
- 95th Percentile
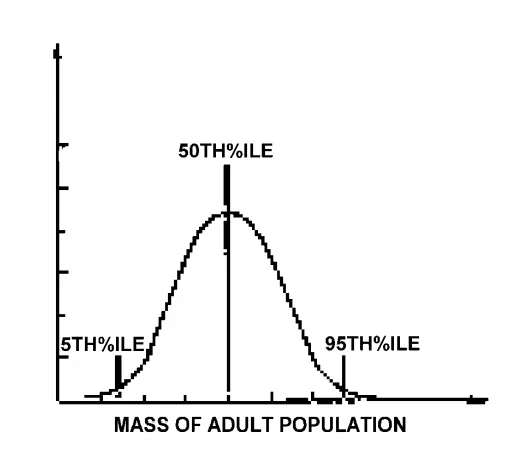 Ex 5th percentile indicates that 5% of adult population is smaller than the dummy.
2. Anthropometry:
Dummies are supposed to mimic human body behaviour in terms of impact dynamics effects in following ways:
• Have similar mass distribution to that of a living human
• Have similar shape to that of a living human
3. Biofidelity:
Dummies should duplicate the biomechanical response behaviour of a living human exposed to the same impact conditions.
4. Measuring capability:
The dummy should be instrumented to provide the following measurements:
- Appropriate forces
- Deflections
- Accelerations
5 & 6. Repeatability and reproducibility:
Different Dummies of same design should:
- Receive the same response (output) to the same impact conditions (input)
- Repeatability is assessed from responses to tests with the same dummy
- Reproducibility from responses to tests with different dummies of the same design
7. Durability:
Durability implies that the dummy should be:
- Structurally sound (intact) following an impact.
- Have responses that remain repeatable
- Replacement parts are available easily
8. Environmental sensitivity:
The dummy should not be sensitive to temperature and humidity. These factors may affect its biofidelity and repeatability.
Examples for calibration
- Hybrid II and US SID temperature limits between 18.9°C and 25.6°C
- Hybrid III, BIOSID temperature limits between 20.6°C and 22.2°C
- The relative Humidity limits between 10% RH and 70%RH
9. Simplicity and ease of use:
- The dummy should be easy to caliberate
- Require minimal extension support equipment
- Be readily repairable
- Have parts that are easy to change and replace.
DUMMIES USED IN FRONTAL IMPACT
ADULT:
- Hybrid III
5th, 50th, 95th ,Pregnant 5th percentile female
- THOR
50th percentile male, 5th percentile female
CHILD:
- CRABI
3,6,12,18 month
- Hybrid III
3,6,10 years old
- EUROPE
P series (P0, P3/4, P3, P10)
Q series (Q0, Q1, Q1.5, Q3, Q6, Q10)
DUMMIES IN LEGISLATION: Legend: 1) planned
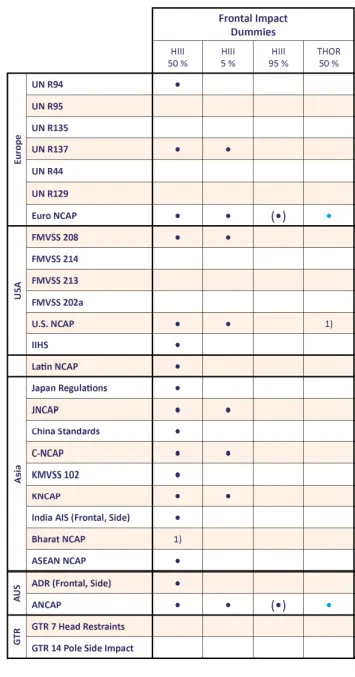
Source: Herald Zellmer: Motor Vehicle Safety Standard & NCAP
Legend: 1) = planned
FMVSS 208
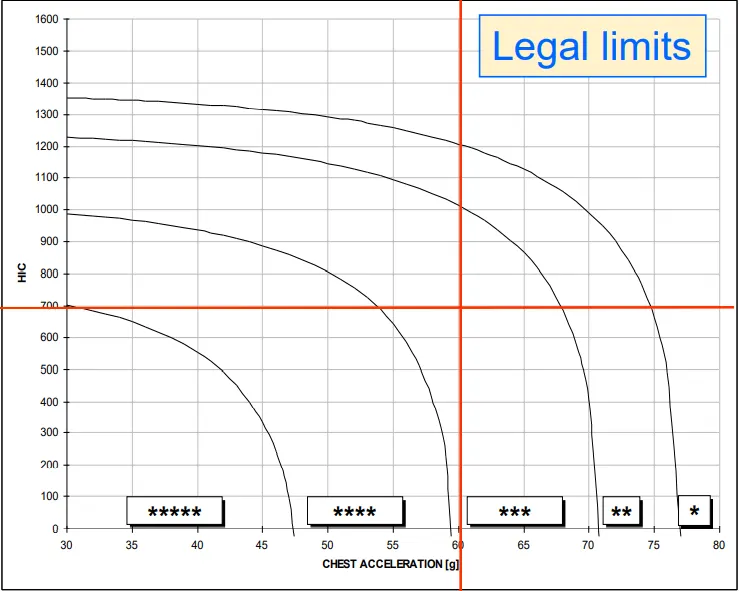
Rating on the basis of HIC calculations Vs Chest acceleration(g)
FMVSS 208 Frontal impact test setup:
- Impact velocity = 56kmph
- Driver dummy = H III - 50%
- Passenger dummy = H III - 50%
- Seatbelt = Belted
- Collision partner = Rigid Barrier
- Overlap = 100%
Legal limits:
- For Head, HIC15 < 700
- For Neck, Nij < 1.0
- Chest, a 3ms < 60g, deflection < 63mm
- Femur axial<10.2 kN
- No submaring
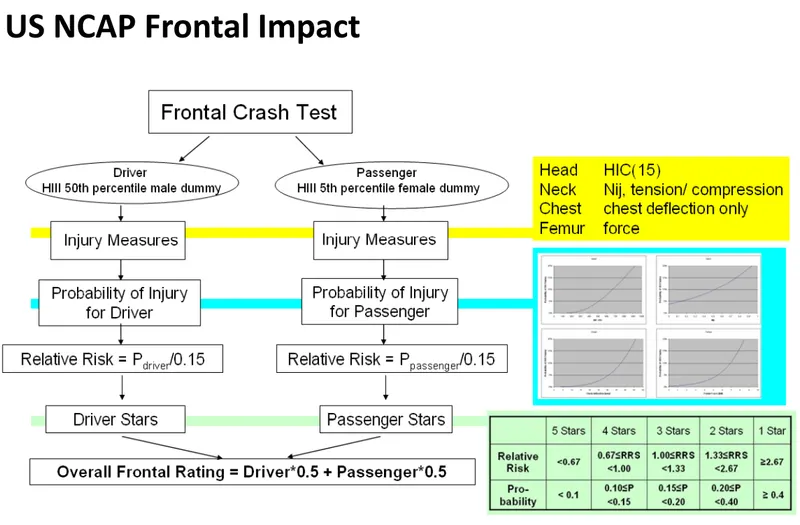
US NCAP RATING CALCULATION:
VEHICLES USED IN CASE 2, CASE 3 and CASE 4
CAR1
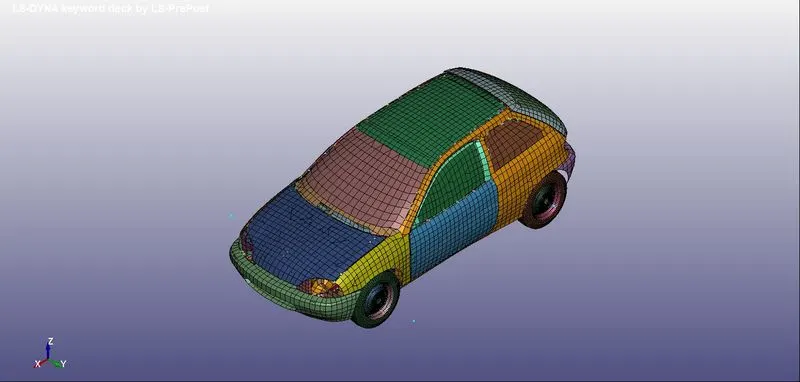
Name: Geo Metro car Model (Ver. GM_R3)
Wieght of car: 900 Kgs
Total parts: 265
No of nodes: 28656
No of shells: 24061
No of beams: 2
No of solids: 820
No of elements: 25037
CAR2
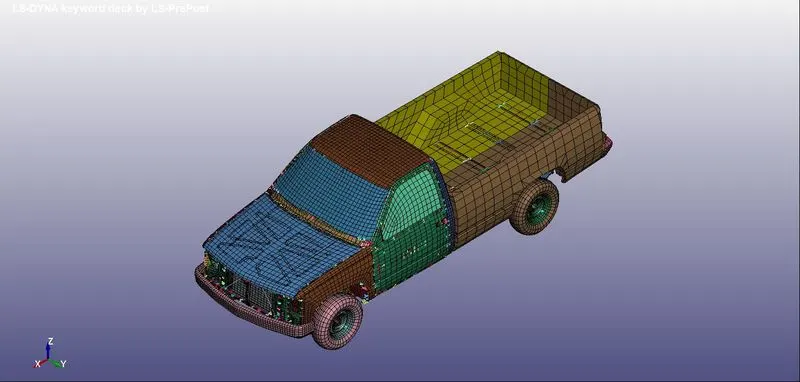
NAME:
Wieght of car: 2013 Kgs
Total parts: 251
No of nodes: 66586
No of shells: 54565
No of beams: 163
No of solids: 3561
No of elements: 58313
BARRIER USED IN FMVSS 208, PERPENDICULAR 100% OVERLAP FRONTAL CRASH
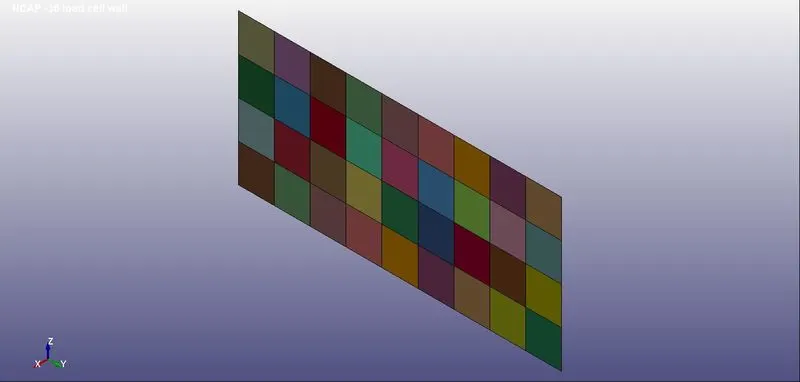
No of parts: 36
No of elements: 36
No of nodes: 50
LIST OF MATERIALS.
Barrier:
| Material card | Name | Description |
| MAT_024 | *MAT_PIECEWISE_LINEAR_PLASTICITY |
|
CAR1:
| Material Card | NAME | MATERIAL MODELLING DESCRIPTION | No. of Material IDs |
| MAT_020 | *MAT_RIGID |
|
37 |
| MAT_024 | *MAT_PIECEWISE_LINEAR_PLASTICITY |
|
159 |
| MAT_026 | *MAT_HONEYCOMB |
|
1 |
| MAT_S01 | *MAT_SPRING_ELASTIC |
|
3 |
| MAT_S02 | *MAT_DAMPER_VISCOUS |
|
5 |
| MAT_S04 | *MAT_SPRING_NON-LINEAR_ELASTIC |
|
1 |
| MAT_S06 | *MAT_SPRING_GENERAL_NON-LINEAR |
|
2 |
CAR2:
| Material Card | NAME | MATERIAL MODELLING DESCRIPTION | No. of Material IDs |
| MAT_020 | *MAT_RIGID |
|
52 |
| MAT_001 | *MAT_ELASTIC |
|
22 |
| MAT_024 | *MAT_PIECEWISE_LINEAR_PLASTICITY |
|
160 |
| MAT_026 | *MAT_HONEYCOMB |
|
1 |
| MAT_S01 | *MAT_SPRING_ELASTIC |
|
1 |
| MAT_S02 | *MAT_DAMPER_VISCOUS |
|
3 |
| MAT_S04 | *MAT_SPRING_NON-LINEAR_ELASTIC |
|
3 |
| MAT_007 | *MAT_BLASTZ_KO_RUBBER |
|
7 |
| MAT_009 | *MAT_NULL |
|
1 |
LIST OF CONSTRAINTS/ JOINTS WITHIN VEHICLE.
CAR1:
| Name of Joint | Card Name | IDs |
| Cylindrical joint | *CONSTRAINED_JOINT_CYLINDRICAL | 4 |
| Revolute joint | *CONSTRAINED_JOINT_REVOLUTE | 12 |
| Spherical joint | *CONSTRAINED_JOINT_SPHERICAL | 16 |
| Constrained Nodal Rigid Bodies | *CONSTRAINED_NODAL_RIGID_BODY | 387 |
| Constrained Rigid Bodies | *CONSTRAINED_RIGID_BODIES | 10 |
| SPOTWELDS | *CONSTRAINED_SPOTWELDS | 787 |
CAR2:
| Name of Joint | Card Name | IDs |
| Revolute joint | *CONSTRAINED_JOINT_REVOLUTE | 16 |
| Spherical joint | *CONSTRAINED_JOINT_SPHERICAL | 14 |
| Constrained Nodal Rigid Bodies | *CONSTRAINED_NODAL_RIGID_BODY | 945 |
| Constrained Rigid Bodies | *CONSTRAINED_RIGID_BODIES | 7 |
| SPOTWELDS | *CONSTRAINED_SPOTWELDS | 78 |
LIST OF CONTACTS WITHIN VEHICLE.
CAR1:
| Contact Type | Contact card | Description |
| Self contact | *CONTACT_AUTOMATIC_SINGLE_SURFACE | To avoid the self penetration of part within itself |
CAR2:
| Contact Type | Contact card | Description |
| Self contact | *CONTACT_AUTOMATIC_SINGLE_SURFACE | To avoid the self penetration of part within itself |
| Null elems contact | *CONTACT_AUTOMATIC_GENERAL | To provide contact between shell exterior edges using null beams |
| Tied contacts for geomteric discontinuity in mesh | *CONTACT_TIED_NODE_TO_SURFACE | Beam or end node contact with shell. |
CASE1: Simplified frontal crash test
It is a very simple case, in which a simplified chassis is collided with a rigid wall.
Here, we will try to understand the basic physics and solver deck in LS DYNA.
Emphasis on to understand the keywords and cards used to conduct the experiment.
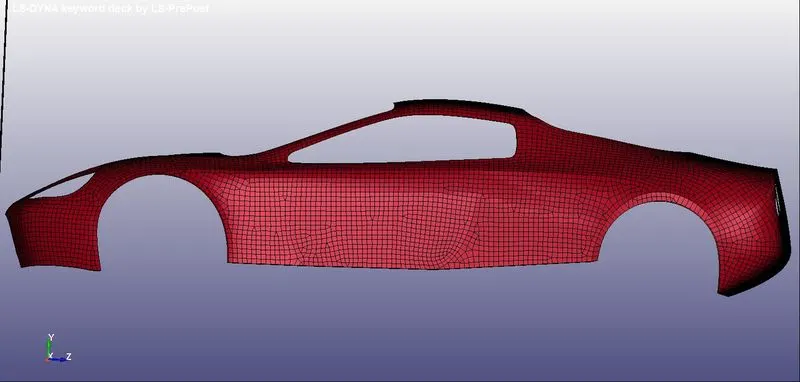
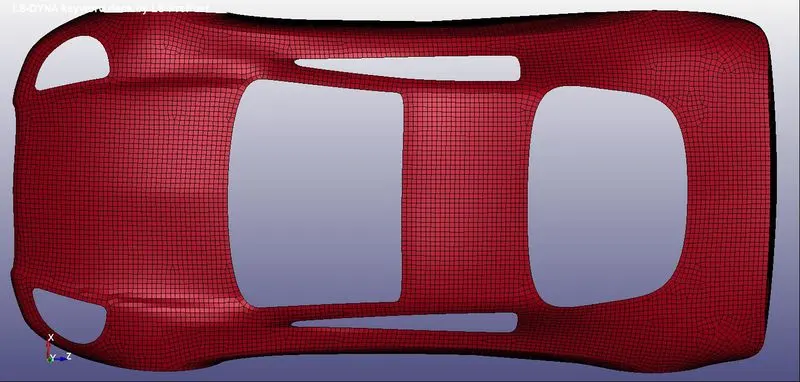
Chassis mesh:
This is a basic scenerio where, we could understand the basics of Frontal crash:
- Basic solver deck
- Output files
- Interpreting results.
- Basic hand calculations equations
- Experimental data for correlation
CHASSIS: Basic chassis of automotive vehicle.
1) Solver deck
Boundary conditions:
For frontal crash, basic boundary condition is between the barrier and the chassis
*CONTACT_AUTOMATIC_SURFACE_TO_SURFACE
MSID, SSID are defined by parts.
Dynamic and static friction is defined.
Here, Chassis is considered as relatively less stiff and thus deformable when compared to Rigid Barrier.
*CONTACT_AUTOMATIC_SINGLE_SURFACE
To prevent self penetration when contact happens. (Ex Buckling scenerio)
Loading condition:
Inital velocity is given to chassis in the direction perpendicular to Barrier.
Velocity is assigned with PartID.
*INITIAL_VELOCITY_GENERATION card assigns the initial velocity to Part set ID, Part ID or Nodal set ID.
This card is used to assign translational velocities as well as the angular velocity about an axis.
Axis coordinates are defined and axis in global direxction is raised to 1.
In a scenerio of real car, transaltional velocity is paired with angular velocity of wheel.
Angular velocity is to adjust as per translational velocity.
Material
Here, Material is powerlaw plasticity for chassis.
Rigid mat with COM1 and CON1 and CON2 for barrier.
Control cards
*Control_Energy - every parameter is raised to 2 so that each and every energy can be computed.
*Control_Termination - To set up run time constrain.
Output files:
Since, Dummies, wheels, airbag are missing so few of the output files such as ABSTAT, SBTOUT, RWFORC on lateral walls etc arenot written, but these stats are necessary for an industrial simulation.
GLSTAT: Global energy data
MATSUM: Material energy data
RWFORC: to deduce the forces induced in the rigid wall.
SLEOUT: Sliding interfaces (contact surfaces energies) It helps im deducing the initial penetrations.
HISTORY_ELEMENT/NODE for accelerometers data. Because accelerometers deduce the forces on dummies, vehicle_CG.
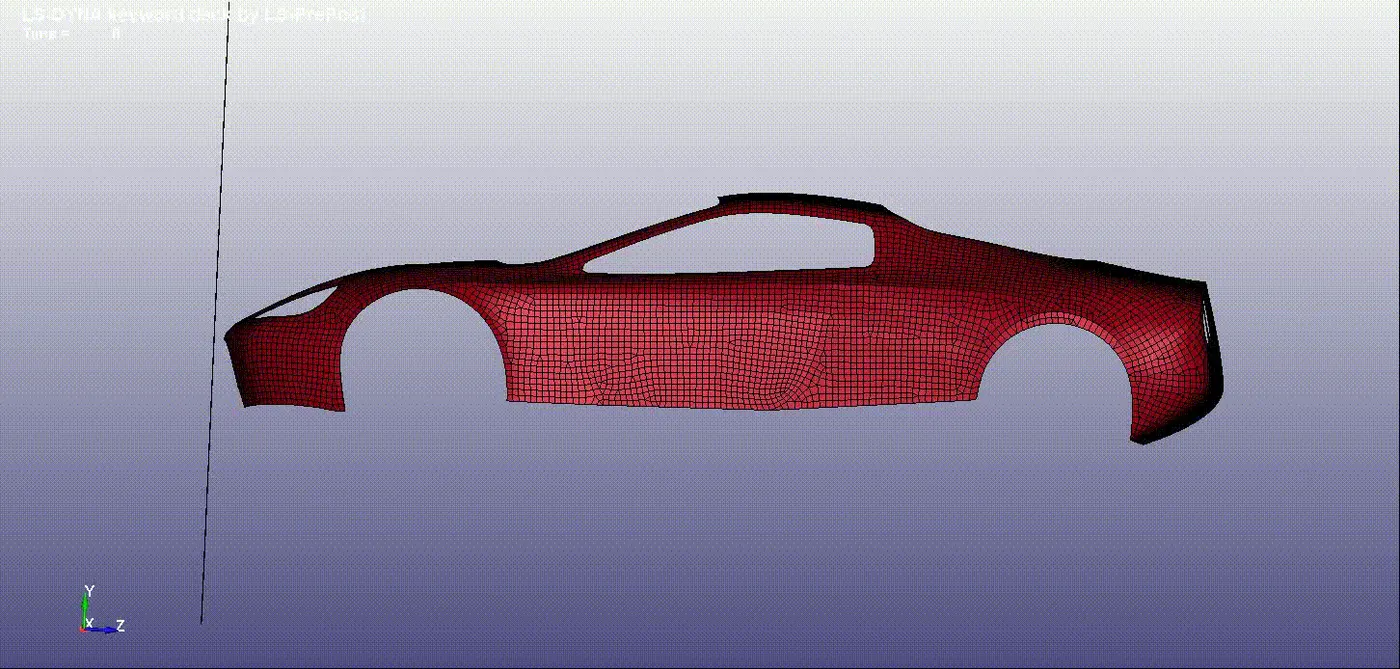
SIMULATION:
POST-PROCESSING DATA:
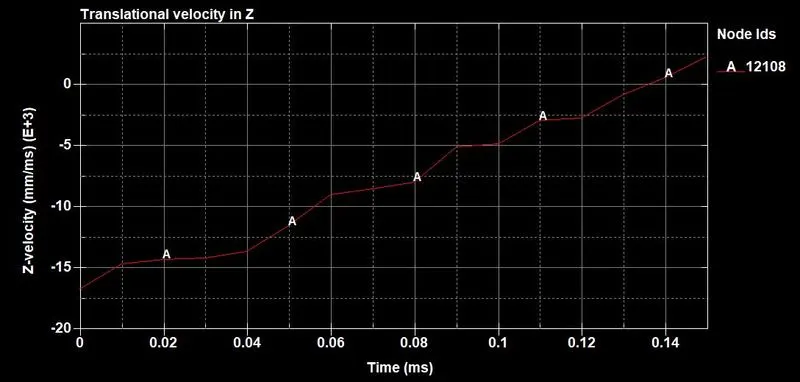
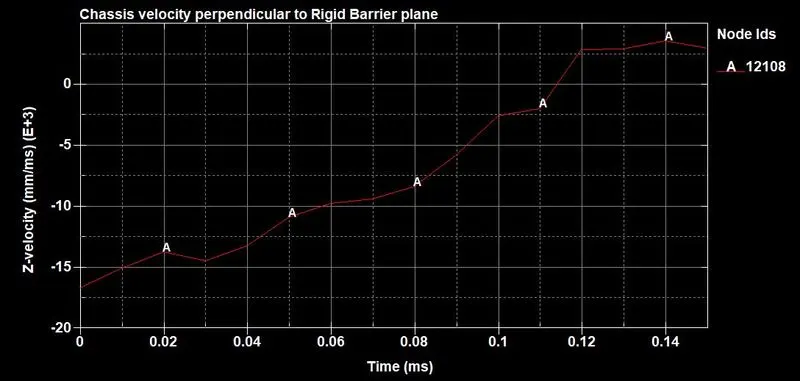
VELOCITY DATA (In direction perpendicular to Rigid Barrier plane)
All velocities are plotted for CG nodal set or element set.
Averages are taken and plotted.
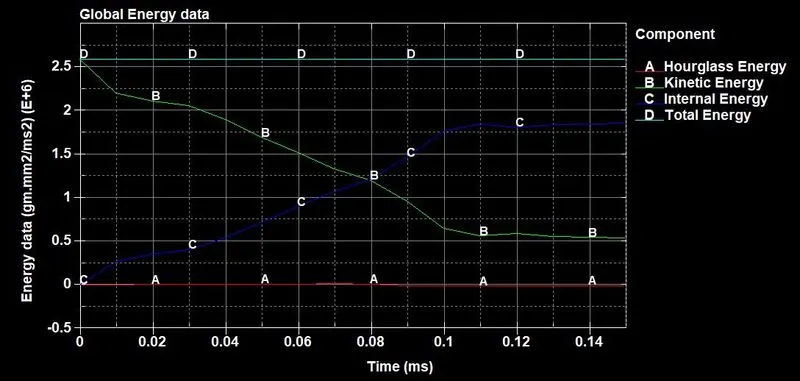
ENERGY DATA (Global energy data)
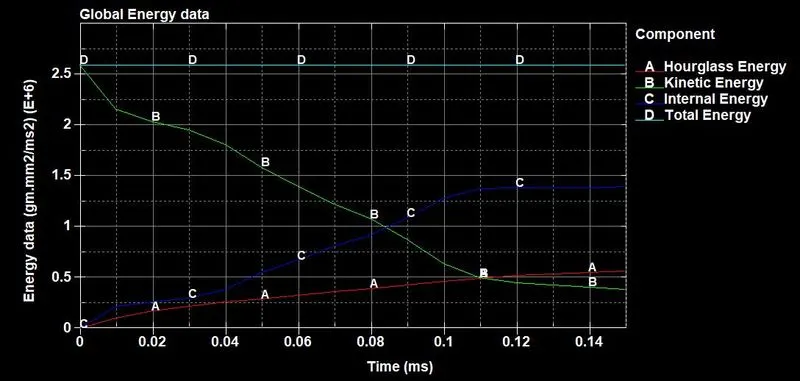
Total Energy = 2.6`times``10^6` units
Maximum Hourglass Energy = 5.66`times``10^5` units
%age hourglass = 5.66/2.6`times`10 = 21.76%
Hourglass effect: Zero domain energy deformation.
Due to poor element formulation or lack of integration points, deformations may arise or may not be accurate.
Forces which are function of material properties are assigned to counter those deformations, energy due to these forces is called hourglass energy.
Since the enrgy is pseudo energy and is not due to physical or real loads, hence there is a certain tolerance for hourglass energy.
Lets say 10% of total energy.
Generally, hourglass need to be within certain tolerance, lets say 10%
In such cases, we need to introduce *Control_Hourglass for shell elems.
*HOURGLASS
IHQ = 6
QM = QB = QW = 0.1
*CONTROL_HOURGLASS
IHQ = 6
QH = 0.10
Energy plot with Hourglass control.
Z Velocity is also changed:
Crashworthiness calculations for frontal impact:
1 denotes before impact
2 denotes after impact
Upper case is for Car1
Lower case for Car2
- Using Impulse relations, Force is obtained = `int`Fdt = I for t =t1 to t =t2
- Momentum equations for both vehicles are considered
M`underset( 1)(V)` - I = MV
m`underset( 1)(v)` - I = mv
- Relative velocity during impact, `underset( r)(V)` = V+v
- Coefficient of restitution, e =`underset( r2) (V)` / `underset( r1)(V)`
If e=0, bodies remain in contact after collision
If e =1, bodies deviates with same speed as speed of approach.
For real cases, 0<e<1
Using above relations, we can calculate the final velocities for colliding bodies `underset( 2)(V)`, `underset( 2)(v)` and coefficient of restitution (e)
From simulated plots,
`underset( 2)(v)` = `underset( 1)(v)` - M(1+e)(`underset( 1)(v)` + `underset( 1)(V)`)/(m + M)
`underset( 2)(V)` = `underset( 1)(V)` - m(1+e)(`underset( 1)(v)` + `underset( 2)(V)`)/(m + M)
We can correlate hand calculation and simulated calculation.