Project 2 - Modeling of 3 phase Induction Motor Drive
This project is focused towards electric vehicle application using an Induction Motor. Student will have to take following steps for a successful model:
AIM :
To designe the matlab simulink model of 3 Phase Inverter and 3 phase induction motor with a 3 phase inverter using Direct Torque control.
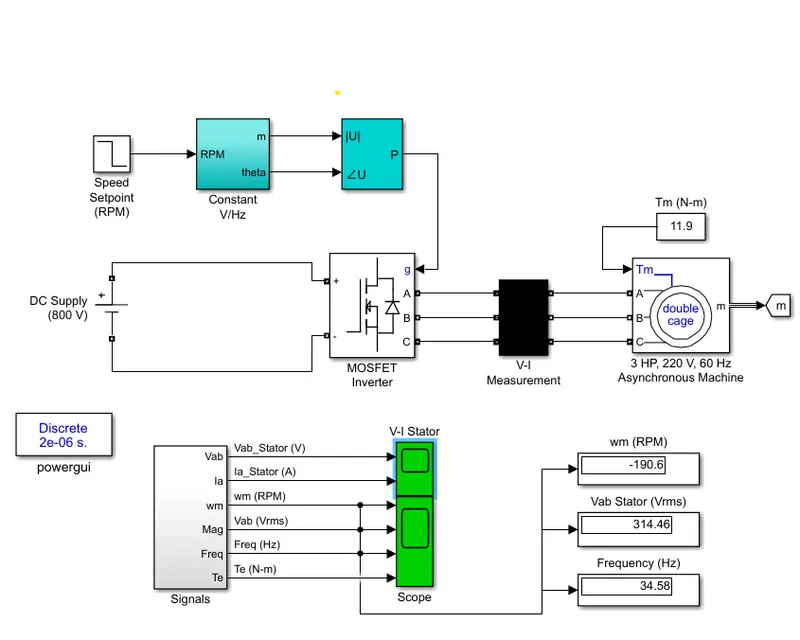
- Model 3 Phase Inverter using Simulink (model the parasitic as well) with a switching frequency of 10Khz using 3 phase Squirrel Cage Induction motor, using V/F method, open loop
Design Parameters:
- Power = 100 HP
- DC Voltage = 800 V
- Output Voltage = 460 VRMS – line to line
- Initial Speed = 1500 RPM
- Final Speed = 1000 RPM
- Initial Load Torque = 10 Nm
- Final Torque=20 Nm
- Torque Step Time = 0.1 secs
For Induction Motor model – use Asynchronous Machine from Simulink with Squirrel Cage Preset Model – 05 , for 100HP Motor
For back emf to speed relation, assume a linear rate from 0.25 to 1, with speed changing from 500 RPM to 2000 RPM
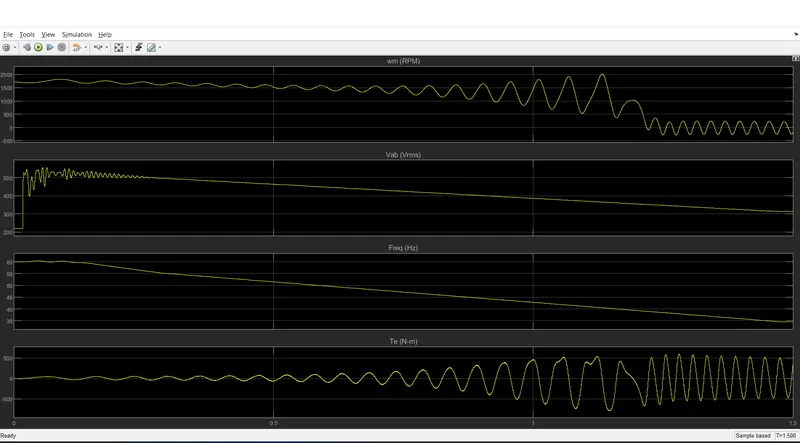
Plot speed, stator voltage (line to line) and frequency.
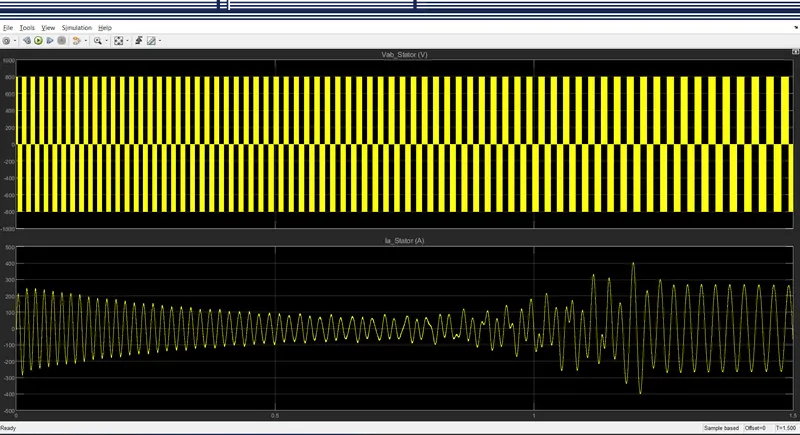
Plot stator line voltage, phase current
THEROY OF THREE PHASE INVERTER :
The Three-Phase Voltage Source Inverter block implements a three-phase voltage source inverter that generates neutral voltage commands for a balanced three-phase load. Configure the voltage switching function for continuous vector modulation or inverter switch input signals. You can incorporate the block into a closed-loop model to simulate a power inverter. The block controls the ideal switch states. he Three-Phase Series RLC Load block implements a three-phase balanced load as a series combination of RLC elements. At the specified frequency, the load exhibits a constant impedance. The active and reactive powers absorbed by the load are proportional to the square of the applied voltage.
He Three-Phase Series RLC Load block implements a three-phase balanced load as a series combination of RLC elements. At the specified frequency, the load exhibits a constant impedance. The active and reactive powers absorbed by the load are proportional to the square of the applied voltage. The formula is volts times the square root of 3, which happens to be rounded off to 0.2 sec. For 2 lines each carrying 120 volts, the calculation for this is 800 volts times 0.2 sec , and the result is rounded up to 208 volts. That's why we call it a 800 volt three-phase circuit, or a 100 HP 800 volt 3 phase line.
- Voltage measurement.
- Use a label.
- Signal label (use a From block to collect this signal)
- Voltages in pu, based on peak value of nominal phase-to-ground voltage.
- Voltages in pu, based on peak value of nominal phase-to-phase voltage.
- Current measurement.
- Use a label.
- Signal label (use a From block to collect this signal)
MATLAB SIMULNK MODEL :
2. Use the 3 phase inductor motor theory to derive the transfer function of 3 phase Induction Motor
The stator has three sets of windings that are aligned at 120 degrees to each other and are driven by balanced currents that are 120 degrees out of phase. Call the coils A, B, C and we will work in cylindrical coordinates. (See figure below.) The coils are wound in such a way as to generate a field that is a rough stepwise approximation to a cos( ) θ distribution. The windings overlap and each winding slot has two windings in it usually from different phases. (See 4 and 6 pole distributions on the handout from class).
V_phase = R_phase * I_phase + jX_phaseI_phase
T = (3/2)P(synchronous speed - rotor speed)*R2/S
I_phase = (1/(jwL_phase))(V_phase - jwM_phaseI_r)
I_r = (1/(jwM_phase))[(V_phase/jw*L_
T = (3/2)PR2S[(V_phase/jwL_phase)/
T/V_phase = (3/2)PR2S/((jwL_phase)((jwM_
Simplifying this expression, we get:
T/V_phase = K/(1 + jwTau)
where K is a constant, w is the angular frequency of the AC voltage, and Tau is a time constant given by:
Tau = (L_phase*(jwM_phase + R2))/(jwL_phase*(synchronous speed - (V_phase/jwL_phase)/((jwM_
The power factor of the rotor circuit is the ratio of rotor resistance to rotor impedance. The power factor of the rotor circuit is;
Winding EMFs in a 3-Phase Induction Motor; Stator EMF and Rotor EMF. Now, let, 𝑘𝑐𝑠 𝑘𝑑𝑠 = 𝑘𝑤 = Winding factor of stator. 𝑘𝑐𝑟 𝑘𝑑𝑟 = 𝑘𝑤𝑟 = Winding factor of rotor.
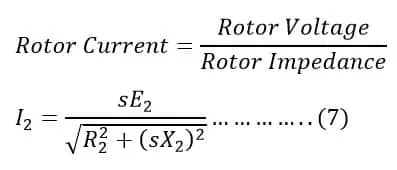
rotor emf is directly proportional to flux per stator pole, i.e. E2 ∝ ɸ. therefore, T ∝ E2 I2 cosɸ2 OR T =k1 E2 I2 cosɸ2.
An emf induced by motion relative to a magnetic field is called a motional emf. This is represented by the equation emf = LvB, where L is length of the object moving at speed v relative to the strength of the magnetic field B.
A 3-phase induction motor is an electromechanical energy conversion device which converts 3-phase input electrical power into output mechanical power. A 3-phase induction motor consists of a stator and a rotor.
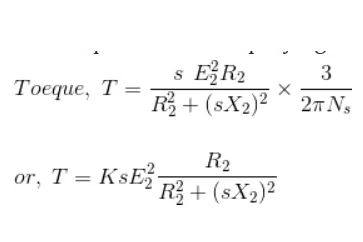
3. Model 3 phase induction motor with a 3 phase inverter using Direct Torque control using an Average Model, Implement both torque and flux control to achieve desired power.
Design Parameters:
- Initial Speed = 0 RPM
- Flux Target = 2.5 webers
- DC Voltage = 500 V;
- Fundamental Frequency = 60 Hz
- Speed Step Time = 0.01 secs
- Determine fundamental speed based upon fundamental frequency
- Determine the switching sequence for direct torque control
- Moment of Inertia = 0.1 Kgm^2
- Load Torque Initial = 0 Nm
- Final Load Torque = 50 Nm
- Torque Step Time = 0.03 secs
Motor Parameters: (Create an Average Model)
- Stator Resistance = 0.5 Ohms
- Rotor Resistance = 0.2 Ohms
- Stator Leakage Inductance = 20 mH
- Rotor Leakage Inductance = 10 mH
- Magnetizing Inductance = 200 mH
- Number of Poles = 4
- Torque to Speed
Direct Torque Control of an Induction Motor Drive :
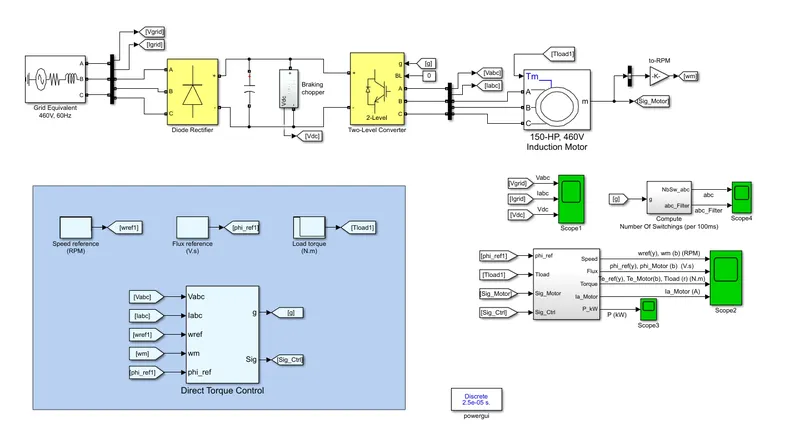
This example demonstrates the speed regulation of a variable-frequency AC drive using a hysteresis-based direct torque control (DTC) technique. The electrical energy is supplied by a three-phase AC/DC diode rectifier connected to a 460 V, 60 Hz grid equivalent. The DC bus is connected to a three-phase, two-level converter. This converter generates the variable voltage and frequency required for variable-speed operation of the 150 HP induction motor. In addition, a braking chopper is connected to the DC bus in order to dissipate the kinetic energy of the motor during deceleration. An inverter-fed induction motor drive can be controlled through various techniques depending on application, desired performance, and controller design complexity. Commonly used schemes are scalar control (V/Hz control or open loop flux control) or vector control (field-oriented control or direct torque control). This example uses a hysteresis-based direct torque control (DTC) technique.
Direct torque control (DTC) is a technique that allows you to instantaneously control the motor magnetic flux and its electromagnetic torque in a decoupled way. Controlling the torque directly permits accurate static and dynamic speed regulation. The main components of the DTC subsystem are:
-
Flux and Torque Calculation — The stator flux linkage is estimated by integrating the stator voltages, and torque is calculated based on the estimated flux and the motor currents.
-
Speed Regulator — The regulator compares the actual motor speed with the speed reference and generates the torque reference.
-
Hysteresis Control — The calculated flux magnitude and torque are compared with the reference values. When the resulting flux or torque error crosses either the positive or negative hysteresis band value, a control signal is activated in order to correct the error.
-
Optimal Switching — Pulses to the motor inverter are produced based on the control signals generated by the hysteresis control and the stator flux linkage position.
The figure below illustrates the strategy used to determine the best voltage vector when the flux linkage is located in sector 0.
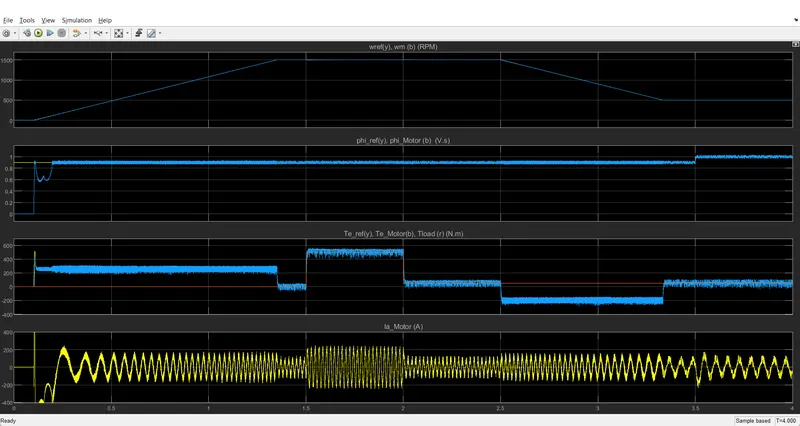
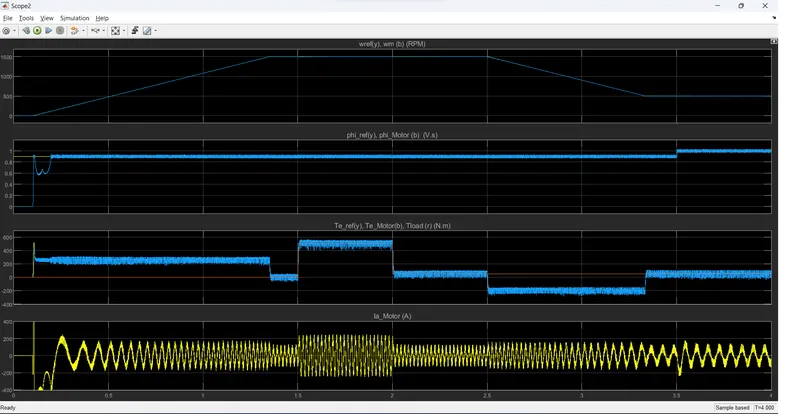
Run the simulation and observe the waveforms on Scope2. Initially, the flux reference is set to 0.9 V.s.
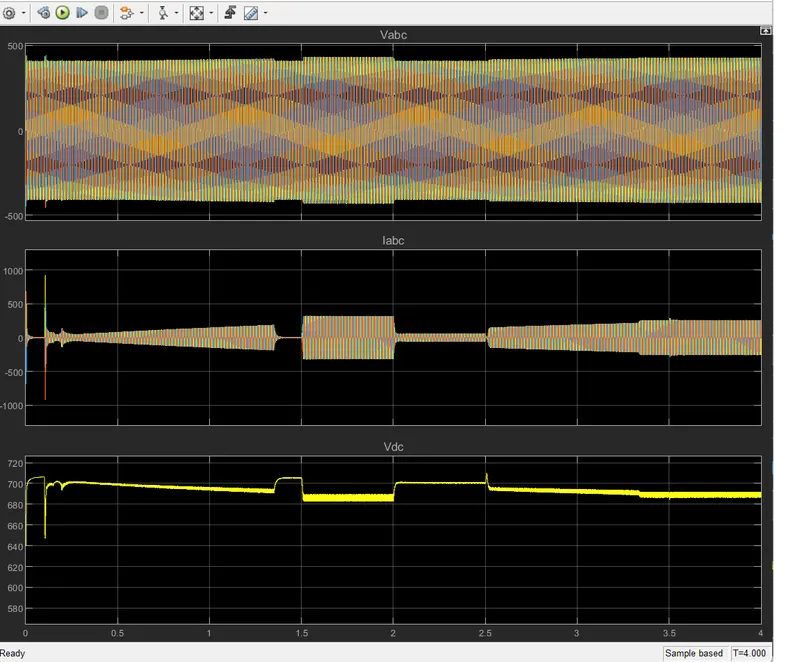
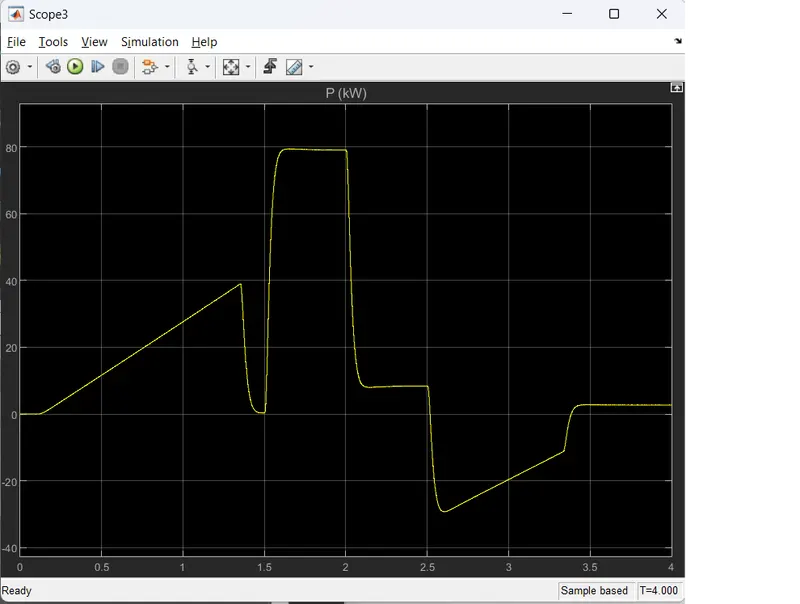
At 0.1 s, the speed reference is set to 1500 RPM and the motor starts to accelerate. The motor speed precisely follows the speed reference, whose maximum rate of change is limited to 1200 rpm/s. The 1500 RPM set point is reached at 1.35 s.
At 1.5 s, a load torque of 500 N.m is applied to the motor. The DTC control operates to maintain the motor speed at 1500 RPM.
At 2 s, the load torque is reduced to 50 N.m and at 2.5 s, the speed reference is reduced to 500 RPM. Observe on Scope 1 that the braking chopper operation dissipates the kinetic energy produced by the motor in order to avoid overvoltage on the DC bus. Finally, at 3.5 s, the flux reference is increased from 0.9 to 1.0 V.s.
RESULTS :
CONCLUSION :
To conclusion of the matlab simulink model of 3 Phase Inverter and 3 phase induction motor with a 3 phase inverter using Direct Torque control and output results.