Setting Up the Simulation in SolidWorks: Motion Analysis for the Machine Vice
Learn how to set up a motion analysis in SolidWorks for the machine vice assembly. This step-by-step guide covers adding motors, defining contacts, and analyzing multibody dynamics using SolidWorks.
Welcome back to the Multibody Dynamics using SolidWorks blog series! In this final phase of our Multibody Dynamics using SolidWorks series, we focus on bringing the entire machine vice assembly to life by setting up a motion simulation. You’ve built each component, but now it’s time to simulate how the machine vice works, with the rotation of the handle, the interaction between the screw and nut, and the gradual movement of the sliding jaw.
This blog will guide you through the key steps in enabling SolidWorks Motion, setting up a motor to rotate the handle, defining essential contacts, and simulating gravity. By the end, you'll also learn how to analyze the simulation with displacement plots and trace paths. These simulation tools are crucial for understanding the multibody dynamics of your machine vice and optimizing its performance.
Motion simulation is a powerful tool that enables engineers to visualize real-world mechanical behavior and predict how designs will function before production. Through this process, we gain valuable insights into how each component interacts under various forces, saving time and resources in the design phase.
Let’s dive into setting up this SolidWorks simulation and extracting useful data, ensuring our machine vice operates smoothly and efficiently.
Step 1: Enable SolidWorks Motion Add-In
Before setting up the simulation, ensure that SolidWorks Motion is enabled:
- In the top toolbar, check that SolidWorks Add-ins is visible.
- Enable SolidWorks Motion to unlock motion analysis tools.
Once enabled, click on Motion Study 1 at the bottom of the interface, and click the arrow next to it. Change Animation to Motion Analysis to allow for a more detailed simulation of multibody dynamics.
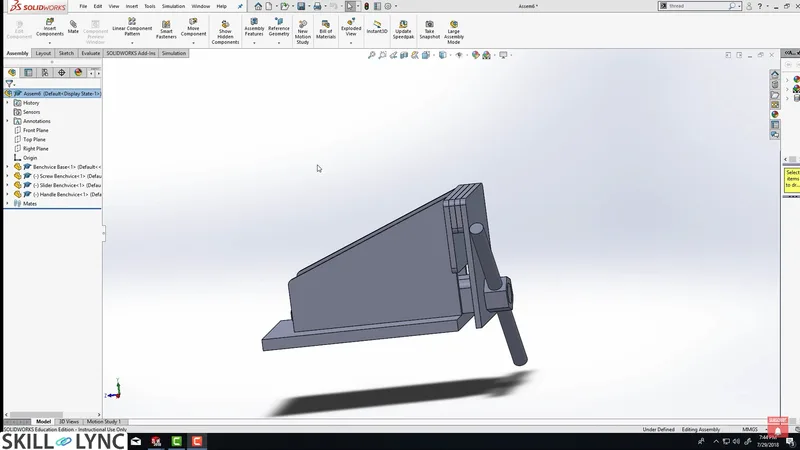
Step 2: Adding the Rotary Motor
To simulate the machine vice’s motion, we’ll need to add a motor to rotate the handle:
- Click Motor from the motion toolbar and choose Rotary Motor.
- Select the rotational axis of the handle as the motor’s axis of rotation.
- Set the motor speed to 10 RPM in a clockwise direction and confirm by clicking OK. The motor will now be added to drive the screw.
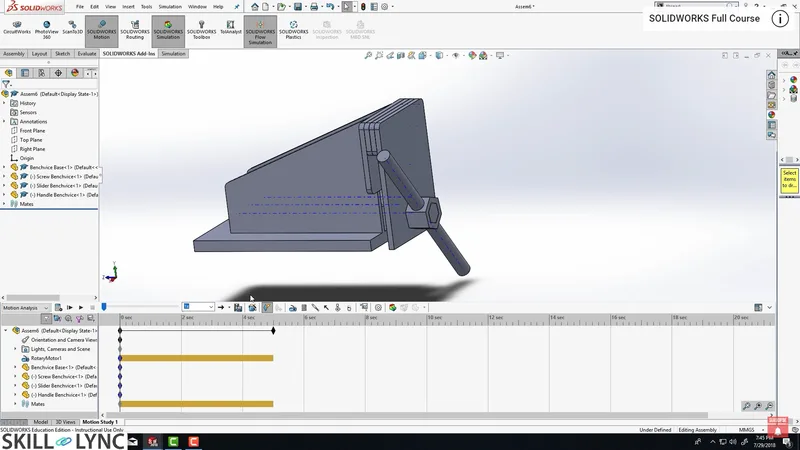
Step 3: Defining Contact and Gravity
After adding the motor, it’s important to set the contacts between parts and gravity:
- Select Contacts: Define the contact between the screw and nut by choosing their respective faces and applying a material. For this simulation, we’ll use Steel.
- Add Gravity: View the geometry from the front view and apply gravity along the Y-axis.
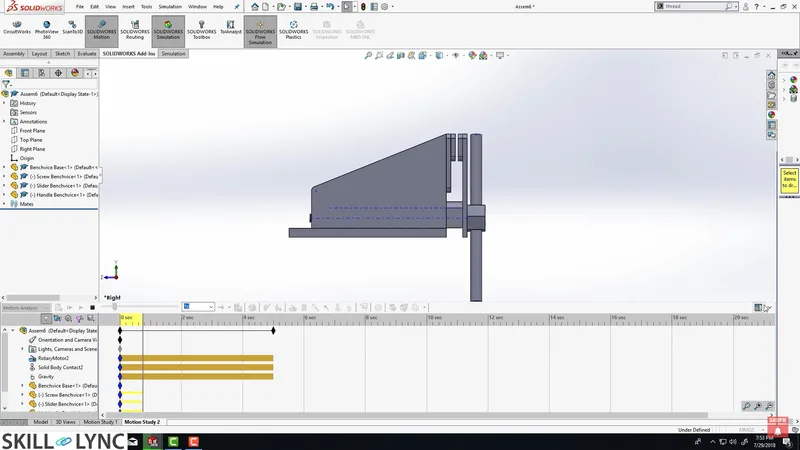
This step ensures realistic interactions between the parts during the simulation.
Step 4: Running the Simulation
Now that everything is in place, click Calculate to run the simulation. As the handle rotates, the screw will turn, and you will see the moving jaw gradually shift to the right. This might appear slow initially, as SolidWorks is calculating and rendering the motion simultaneously.
Once the calculation completes, replay the animation by selecting Play from Start to observe a smoother version of the simulation.
Step 5: Plotting and Analyzing Data
With the simulation complete, it’s time to extract useful data:
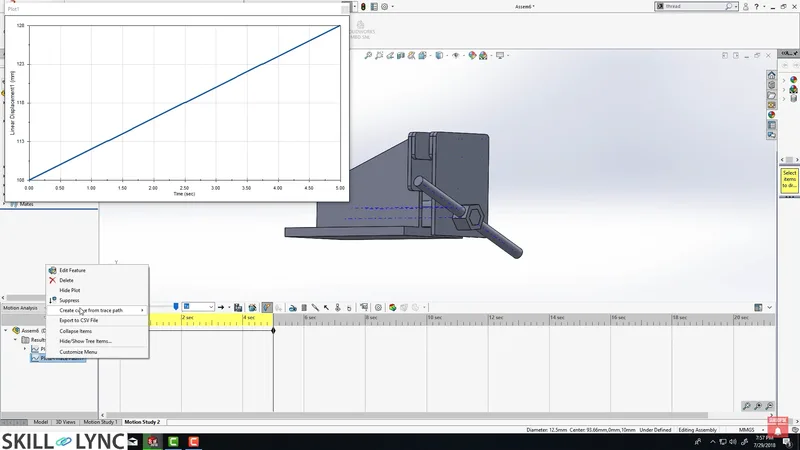
- Create a Displacement Plot: Go to Graphs, select Linear Displacement, and choose Magnitude. Select the moving jaw as the component to measure. The resulting plot will show linear displacement over time, which is expected since the motor rotates at a constant RPM and the screw has a fixed pitch.
- Trace Path for Components: To further analyze motion, use the Trace Path feature under Results. Select a point on the moving jaw (such as the outer edge), and you will be able to visualize the exact path taken by that point during the simulation.
You can view both plots simultaneously by clicking the upward-pointing arrow on the right and using Filter Results. This allows you to compare the displacement and trace path data for a comprehensive understanding of the system’s dynamics.
Conclusion
In this blog, we have successfully set up the multibody dynamics simulation for the machine vice in SolidWorks. By adding a rotary motor, defining contacts, and analyzing displacement through plots, we’ve gained valuable insights into the behavior of the system. These steps provide a detailed foundation for motion analysis in SolidWorks.
To learn more about complex simulations and how to master SolidWorks, consider exploring Skill-Lync’s Full Course on Multibody Dynamics and SolidWorks training.
Stay tuned for the next installment, where we’ll dive deeper into advanced simulation features!
This blog is part of our ongoing series on Multibody Dynamics.
If you missed the previous posts, check them out here.
Would you like to have a more interactive experience going through the SolidWorks user interface?
Skill-Lync has released a FREE comprehensive course covering Multibody Dynamics in detail! Check it out here.
If you’re looking to go deeper into SolidWorks training and multibody dynamics skills, check out Skill-Lync’s SolidWorks certification course.
Check out our hands-on course today and add Multibody Dynamics and SolidWorks to your list of skills!
Let’s get #IndustryReady together, one skill at a time!