Week-7 Challenge: DC Motor Control
- 1. Aim:
- To understand the Speed control of a DC motor BJT H bridge circuit.
- To study the Four-Quadrant Chopper DC Drive (DC7) block and compare it with the H bridge circuit.
- To do modifications in DC7 in order to get the EV cycle.
- 2. Objective:
- Understanding the H bridge circuit and how to do speed control.
- Comparison of DC7 with H bridge circuit.
- Changing the input of DC7 in order to get input for an EV vehicle.
- 3. Method:
3.1 Run MATLAB demo ‘Speed control of a DC motor using BJT H-bridge’. Modify the model such that armature current doesn’t shoot up when motor changes direction from forward to reverse.
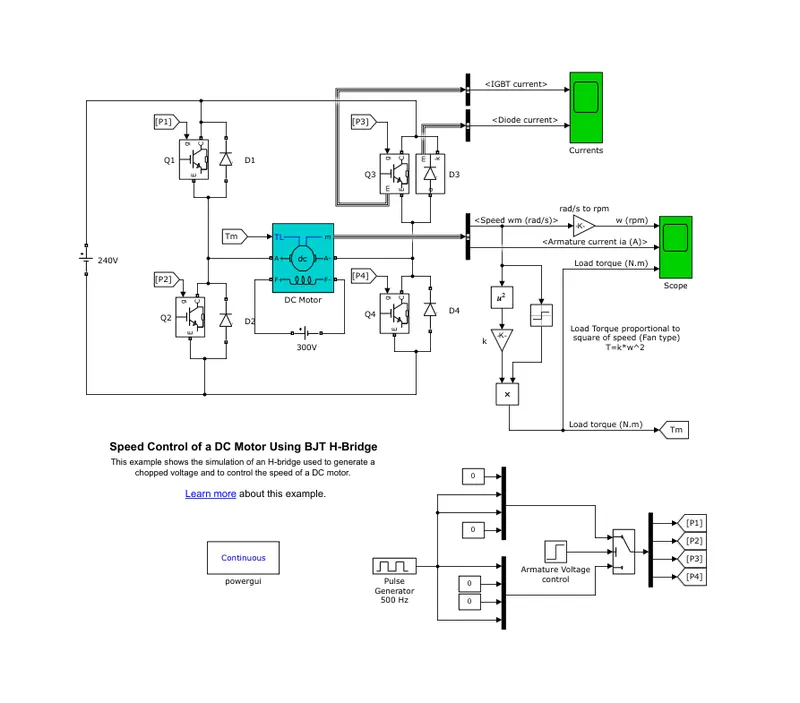
- The simulation shown above is for a DC motor using BJT h Bridge. The system is working on the principle of the H bridge circuit. The circuit consists of 4 BJT transistors and 4 diodes.
|
Q1 & Q4 active |
Q3 & Q2 active. |
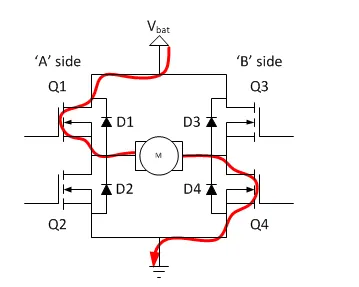
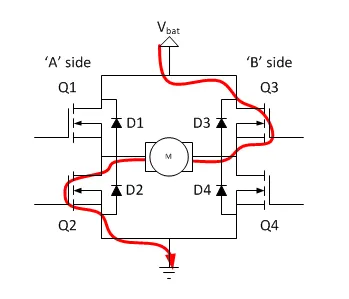
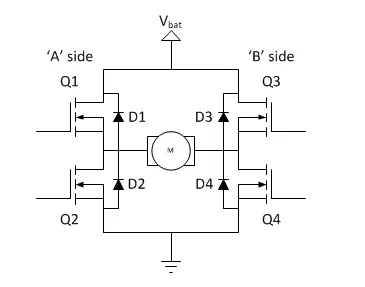
- H bridge is rather a simple circuit, containing four switching elements, with load at the centre in an H configuration. The switching elements are generally bi-polar or FET transistors, in some high voltage applications IGBTs. The top end is connected to the power supply and the bottom is generally grounded.
- These BJT are run as either Q1 & Q4 or Q2 & Q3. The Q1 & Q2 are not run simultaneously as this will result in short-circuiting.
- This configuration is used in order to rotate the motor in one direction for some time and in other direction for the next half-cycle. The basic principle consists of 2 PNP and 2 NPN connected along with a diode.
- The input is given by the user in the control signal to control the motor. According to the input the power converter will turn ON/OFF the motor.
- The cycle is run for 1sec and in this, the current is provided for 0.5 sec, i.e for 0.5 to 1 sec, the simulation will run.
- Goto and from blocks are used in order to give the required input.
- From the second plot it can be seen that there is some shoot up is occurring when the polarities are changed. This change in the reverse direction is more as there is some back emf occurring. In real-world this back emf is reduced by giving some delay time, this time will reduce the current to 0 and this results in no back emf and this shoot up gets to 0.
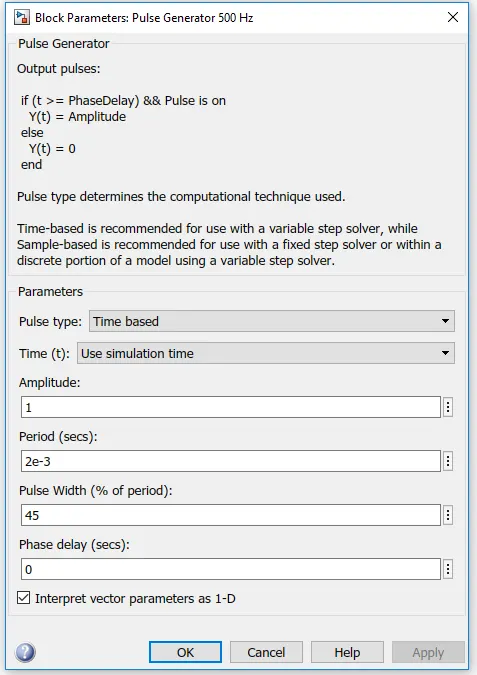
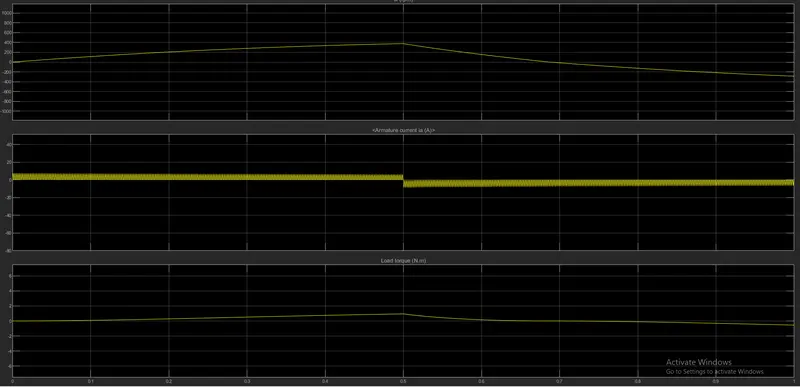
- However in this case the pulse width is changed to 50 and then to 45 in order to reduce the shoot. However, it is not a standard practice to do, as it can be seen from the plot when the pulse width is changed to 45 the torque and speed also reducing to coming close to 0 which is not a suitable case.
- Here just for study purpose the pulse width is taken as 45.
|
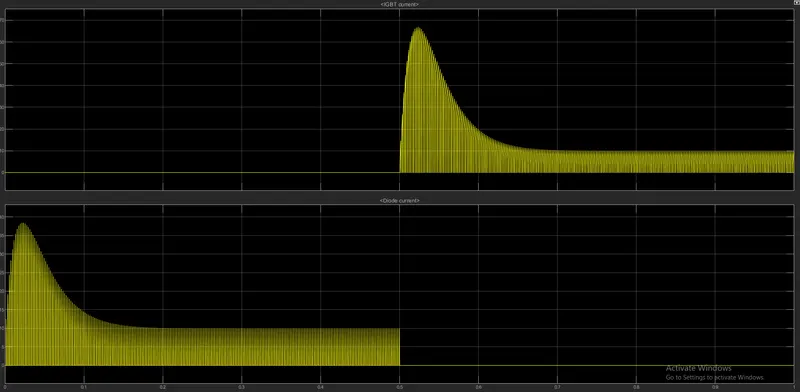
- From the plot, it can be seen that the cycle is working after 0.5 sec. In this case, the input is given for 0.5 to 1sec and that is why the plot is appearing like this. Initially, the pulse width was 75%. - This means the cycle is on for 75% of the time and off for the remaining 25% of the time. - In the 2nd plot, it can be seen that the current passes for 0.5 sec through the diode and for next 0.5 sec there is no current that means no current passed through the circuit. |
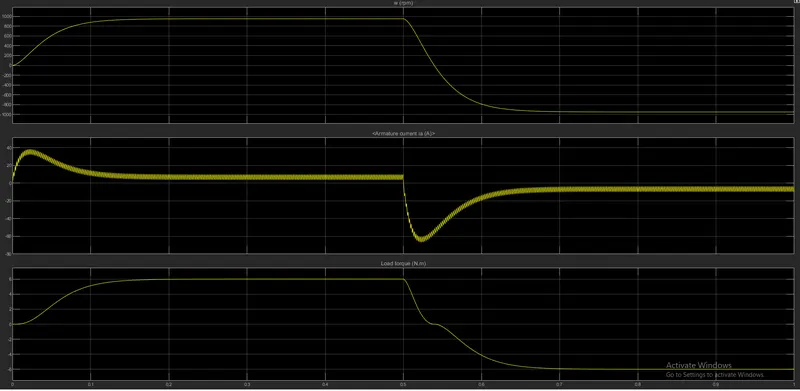
- From the 1st plot, it can be observed that the motor takes some time to reach the maximum speed. This is due to the load. - Also it can be seen that the armature current is having a shoot while shifting from 1 direction to others. This is resulting in more compared with the initial half-cycle and that is due to back emf. - This back emf and shoot is needed to be removed. This can be done by changing the pulse width that means the cycle will run to less number of time. But this also means that there will be less speed and torque. |
|
- In order to satisfy the problem thought the pulse width is taken 50, there was some shoot still remaining and in order to remove it, the pulse width is further reduced to 45 and after run this result is obtained. - It can be seen that the speed and load torque also reduces. |
 |
- 2.Refer to help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
- In case of H bridge, the Bipolar Junction Transistor (BJT) when used for power switching applications, operates as an IGBT. The Four-Quadrant Chopper DC Drive (DC7) block represents a four-quadrant, DC-supplied, chopper drive for DC motors. This drive features closed-loop speed control with the four-quadrant operation.
- Using a PI current controller, the chopper duty cycle corresponding to the commanded armature current is derived. The IGBT block does not simulate the gate current controlling the BJT or IGBT. The switch is controlled by a Simulink signal (1/0).
- In case of H bridge, two transistors are switched simultaneously: Q1 and Q4 or Q2 and Q3. When Q1 and Q4 are fired, a positive voltage is applied to the motor and diodes D2-D3 operate as free-wheeling diodes when Q1 and Q4 are switched off. When Q2 and Q3 are fired, a negative voltage is applied to the motor and diodes D1-D4 operate as free-wheeling diodes when Q2 and Q3 are switched off.
- The main advantage of the H bridge drive, compared with other DC drives, is that it can operate in all four quadrants forward motoring, reverse regeneration, reverse motoring, and forward regeneration.
3. Make a suitable EV model using DC7 block and make result report.
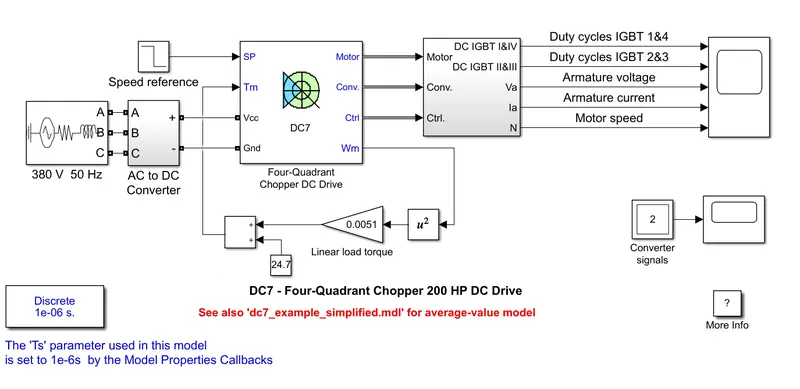
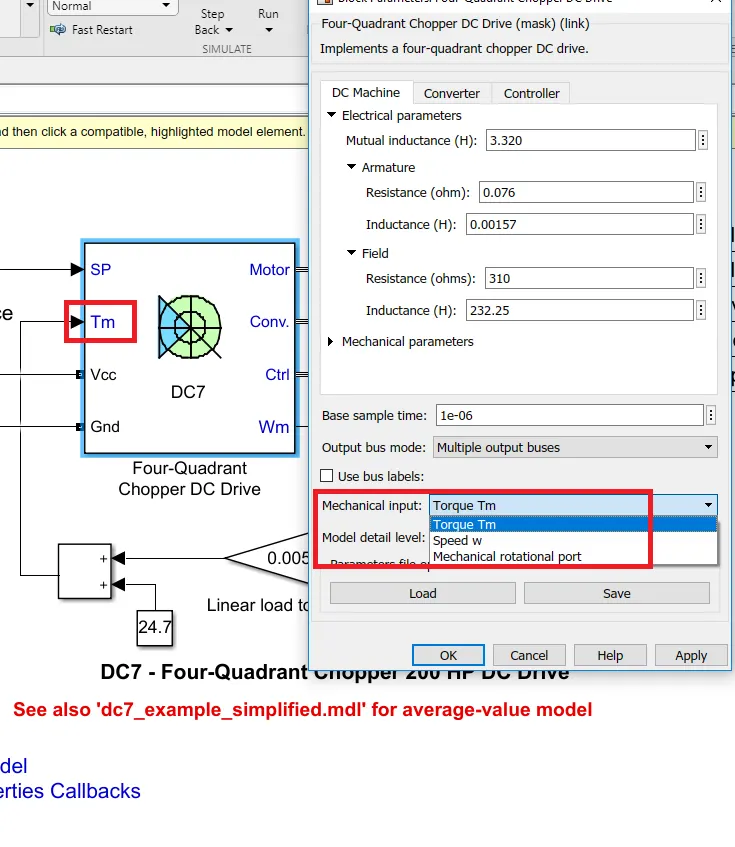
- In order to make a suitable EV model using DC7 block we need to give the torque feedback input as per the equation.
- As we are familiar with the Torque and speed equation: T = 24.7 + 0.0051*w^2, we can use this equation and find the torque which can be fed as an input. According to this torque, the output values will change.
- Here a constant, a square, a gain, a sum/add blocks are used in order to get the required torque.
|
- Modifications has been done in the model. |
- In order to give Torque as input from this mechanical block it can be given. |
|
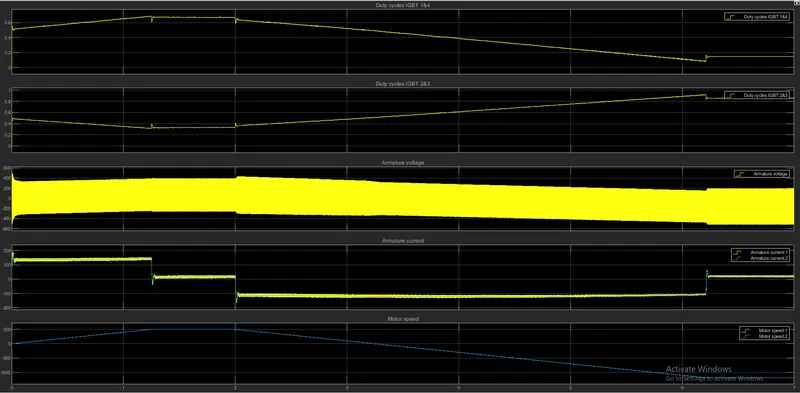
- After running the simulation this plot is obtained. It can be seen that in the 4th plot motor speed 1 and motor speed 2 are close to each other and that means the results are almost the same and as per the requirement. |
- 4. Learning outcome:
- Understanding the working of the H-bridge circuit.
- Comparison of H bridge and DC7 circuit.
- Forming a block diagram as an input to EV vehicle using Torque-speed relation.