Week 3 - Solving second order ODEs
YOUTUBE LINK :-
GOOGLE DRIVE LINK :-
https://drive.google.com/drive/folders/1JybKWW_MgbcbZldZRV-TBqvLK7COi6iY?usp=sharing
AIM:-
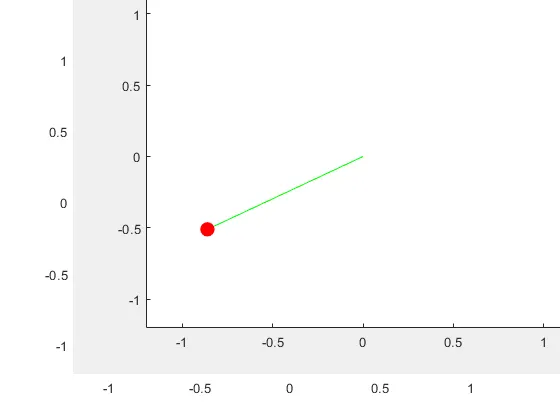
To solve the second order differential equation using MATLAB which mathematical of the motion of the pendulum and to create an animation for that equation.
OBJECTIVE:-
To write a program that solves the following second order differential equation.This second order differential equation represents the equation of motion of a simple pendulum with damping.
GOVERNING EQUATIONS:-
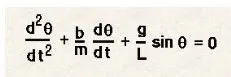
In the above equation.
g = gravity in m/s2
L = length of the pendulum in m.
m = mass of the ball in kg.
b = damping coefficient
FIXED PARAMETERS:-
Length(L) = 1 meter
Mass(m) = 1kg
Damping coefficient(b) = 0.05
Acceleration due to gravity(g) = 9.81 m/s2
Time period = 0-20 sec
MAIN CODE:-
% input
% b = damping coefficient
 b = .05;

 % l = length of the pendulam in m
 l = 1;

 % g = gravity in m/s2
 g = 9.81;

 % m = mass of the ball in kg
 m = 1;

 % intial condition
 theta_0 = [0 5];

 % time point
 t_span = linspace(0,20,100);

 % solve ode
 [t, result] = ode45(@(t,theta) ODE_func(t,theta,b,g,l,m),t_span,theta_0);
 figure(1);
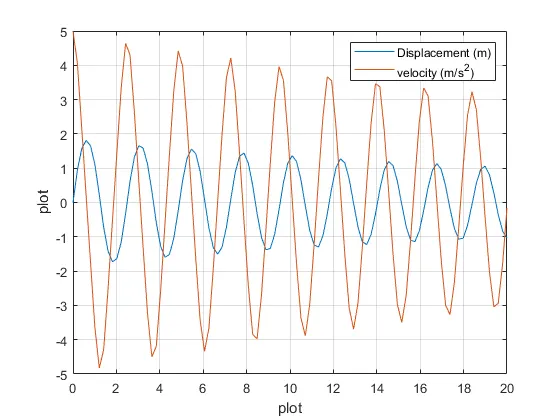
 plot(t,[result(:,1) result(:,2)]);
 grid on
 ylabel('plot')
 xlabel('plot')
 legend('Displacement (m)','velocity (m/s^2)');
 saveas(figure(1),'SHM.jpg');
 theta = result(:,1);
 i = 1;

 for j = 1:length(theta)
     Theta = theta(j);

     % intial points
     x0 = 0;
     y0 = 0;

     % movement of the pendulum

     x1 = l*sin(Theta);
     y1 = -l*cos(Theta);

     figure (2);

     % ploting string

     plot([x0 x1],[y0 y1],'color','g');
     hold on

     % ploting the pendulum bob

     plot(x1,y1,'o','markersize',10,'color','r','markerfacecolor','r');
     hold off

     axis([-1.2 1.2 -1.2 1.2]);
     pause(0.001);
     M(i) = getframe(gcf);
     i = i+1;
 end

 movie(M);
 videofile = VideoWriter('pendulum1.avi','Uncompressed avi');
 open(videofile)
 writeVideo(videofile,M)
 close(videofile);
- In the above program,the fixed parameters are length, mass,damping coefficient and acceleration due to gravity.
- Tine and angle are given as the initial condition.
- In the t_span command, 100 values are taken in between 0 to 20 time period.
- Using the ode 45 command ODE function is introduced.
- Using the plot commond velocity and displacement are plotted in the y-axis against time on the x-axis.
- Using the for loop commamd the mass at various points and various times are marked in the graph and are poltted.
- Using the movie command the plot is saved as an uncompressed .avi file.
FUNCTIONCODE :- ODE_FUNC
function [dtheta_dt] = ODE_func(t,theta,b,g,l,m)
theta1 = theta(1);
theta2 = theta(2);
dtheta1_dt = theta2;
dtheta2_dt = -(b/m)*theta2 - (g/l)*sin(theta1);
dtheta_dt = [dtheta1_dt;dtheta2_dt];
end- In this function program the second-order ODE is simplified to the first-order ODE by introducing the term theta1 & theta2
- Then theta1 & theta@ are differentiated and the dtheta_dt gives a column matrix.
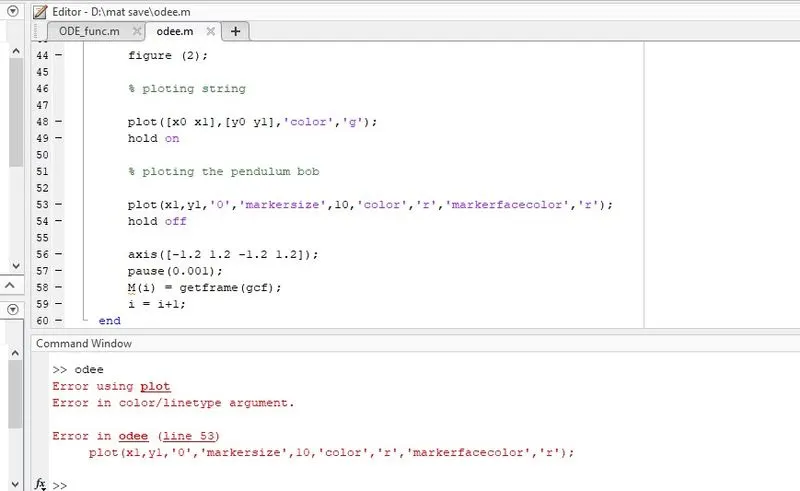
ERRORS:-
RESULTS:-
The program executed and animation generated successfully.
ANIMATION:-
PLOT:-