Week-11 Challenge: Braking
Aim :
1.To calculate the energy required for braking.
2.Make a MATLAB program which plots contour of given motor speed, torque and efficiency values. Attach the code as a .m file attach a screenshot of all the plots
Solution:
Regenerative Braking :
Moving vehicles have a lot of kinetic energy, and when brakes are applied to slow a vehicle, all of that kinetic energy has to go somewhere. Back in the Neanderthal days of internal combustion engine cars, brakes were solely friction based and converted the kinetic energy of the vehicle into wasted heat in order to decelerate a car. All of that energy was simply lost to the environment.
Fortunately, we have evolved as a species and developed a better way. Regenerative braking uses an electric vehicle’s motor as a generator to convert much of the kinetic energy lost when decelerating back into stored energy in the vehicle’s battery. Then, the next time the car accelerates, it uses much of the energy previously stored from regenerative braking instead of tapping in further to its own energy reserves.
An object in motion possesses kinetic energy and to bring the object to a stop this kinetic energy must be removed. Removing the kinetic energy can be accomplished by dissipating the energy to the atmosphere through friction or by converting it into another form of energy. The most common type of braking is a mechanical brake which inhibits motion through friction brake pads.A mechanical brake applies a friction force to convert the kinetic energy of the vehicle into thermal energy which then dissipates into the atmosphere.
As with any system, the process of braking must follow the principal of conservation of energy. Energy cannot be created or destroyed but only converted from one form to another.
The energy present in an object in motion is given by the following equation:
Ekinetic=1/2*m*v^2
• mm is the mass of the object in (kg).
• vv is the velocity of the object in (m/s).
• Ekinetic is the kinetic energy in J
Now all the kinetic energy of the vehicle is converted into heat energy or regenerative energy which is fed back into the battery or it is the combination of both .
Kinetic Energy of Vehicle = Braking Energy
The following drive cycle is considered :
UDDSCOL CYCLE
The following code describes the braking energy required for this drive cycle :
clear all
clc
load uddscol.txt
time=uddscol(:,1)
velocity=uddscol(:,2)
M= 1000 %Weight of vehicle(kgs)
B.E = 0.5*M*velocity


plot(time,B.E)
title('Braking Energy vs Time')
xlabel('Time')
ylabel('Braking Energy')
legend('UDDSCOL DRIVE CYCLE')
Results :
2.Breaking Torque :
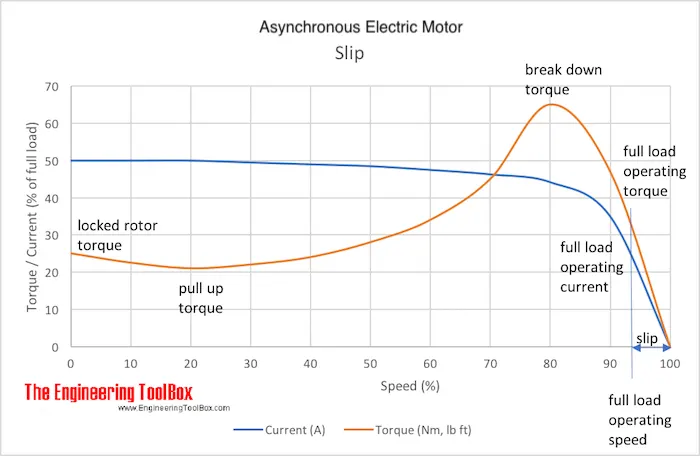
Starting Torque :
The Locked Rotor Torque or Starting Torque is the torque an electrical motor develops when starting at zero speed.
A high Starting Torque is more important for application or machines hard to start - like positive displacement pumps, cranes etc. A lower Starting Torque can be accepted for centrifugal fans or pumps where the start load is low or close to zero.
Break-down Torque
The Break-down Torque is the highest torque available before the torque decreases when the machine continues to accelerate to working conditions.
Electric motor can’t develop braking torque at high speed similar to starting because :
Sometimes after accelerating you can't reach the maximum torque. The reason is that no matter how much the current loop wants to increase current (proportional to torque) by increasing the PWM duty cycle of the power stage, the Vmotor is too close to Vbemf and therefore current can't increase more.
In another words when the motor is at high speed ,the difference between the rotor speed and speed of the magnetic field is lesser compared to the beginning ,meaning that the the difference between the two magnetic field magnitudes is less ,therefore the force created because of the two is less hence the torque generated is less at high speeds .
3. Contours of given motor speed, torque and efficiency values.
A contour plot is a graphical technique for representing a 3-dimensional surface by plotting constant z slices, called contours, on a 2-dimensional format. That is, given a value for z, lines are drawn for connecting the (x,y) coordinates where that z value occurs.
clc
clear all
omega=linspace(0,1000) %rpm
T=linspace(0,300) % Torque (N.m

kc=0.2 % copper losses coefficient
ki=0.008 % iron losses coefficient
kw=0.0001 % kw windage losses coefficient


[X,Y]=meshgrid(omega,T)
copper_loss=(Y.^2)*kc
iron_losses=X.*ki
Windage_losses=(X.^3)*kw
con=20

o_p = X.*Y

input_power = (copper_loss) +(iron_losses) + (Windage_losses) + (o_p) + (con)
Eff= (o_p)./(input_power)
n=linspace(0.7,0.95,10)
grid off
box off
contourf(X,Y,Eff,n)
xlabel('rpm')
ylabel('Torque')
zlabel('Efficiency')