The difference between static and dynamic analysis
When I was doing my first civil engineering design I hardly thought about dynamics. Static analysis was “all there was” for me. And to some degree, it might have been even justified back then. Now, when I understand a bit more, I would like to take you on a trip! We will learn about the differences between statics and dynamics!
The main difference between static and dynamic analysis is TIME! If the load is applied so slowly, that inertia effects won’t play a role, all you need is static analysis. Dynamic analysis handles impacts and other “fast” happening situations, but also vibrations (which happen in time).
But of course, there is implicit and explicit, and all the exciting stuff! So let’s get rolling!
Starting slow (deeeespaaaacito!)
This part will be short (and slow!) because it’s about static analysis.
The basic idea is, that the load you have applied to your structure just is there. Furthermore, it could have already been there those precious seconds after the Big Bang! In short, it doesn’t matter how this load “got there”, but it’s there now and it won’t change later. If you want a slightly more scientific description, this more or less means that the load is applied extremely slowly! So slow in fact, that the speed of the load application can be omitted!
Static analysis in a nutshell:
It doesn’t matter how you apply the load. Solver assumes that this is happening extremely slowly. This means that the way you apply the load has no impact on structural behavior.
The load is not changing in time – it is just there… and that’s that!
Structural response to the static load CAN differ in time (you know, things like creep, relaxation, etc.). Engineers usually view such analysis as more specialistic, and not “simple static”. Still, structural response changing in time is an option in static design.
The fact the load is not changing doesn’t mean that the structural response is linear! All sorts of fun things can happen! If the load is high enough it can cause buckling, yield and all sort of other cool things. This, however, doesn’t change the fact that the analysis is “static” in nature!
Without a doubt, the static design is really popular. In fact, in Poland when someone will do calculations of a structure they would say that they are going to do “static design” or simply “statics”. I know the same is true in several other countries as well.
This is mostly because static is much easier to calculate than dynamic, and requires less sophisticated software to do so! This also means that people will prefer doing statics. Which in turn leads to something pretty interesting and that is…
Static load equivalent
You see, “back in the day” it was almost impossible to calculate impact, etc. Simply put software was to “weak” to do so. I assume you could do such things at Universities, etc. But in a typical structural office, it was out of reach – at least in civil engineering.
But of course, this doesn’t mean that impacts didn’t happen! There were stone crushers, things were thrown out of trucks on structures (in gravel plants and similar facilities) and myriads of other things (including even a car hitting the building you are designing).
But how people handled those if they couldn’t perform the dynamic analysis?
… well, they increased the static load!
Static load equivalent
In essence if something will impact our structure you may not have to calculate the actual impact. I know it would be super cool to do such things! But often you don’t have the software, and more importantly, the time to do such analysis.
This is where static equivalent of dynamic load comes in play.
The idea is simple: just increade the load with the “dynamic factor”! Then you can treat it as static load in your analysis.
I saw various “dynamic factors” in my career, starting from a humble 1.5 and going up to around 10. If I would have to give the most popular value it would definitely be 4.0. However, 2,0 would be close behind it.
Of course, the value of “dynamic factors” depends on the industry and what you are trying to do. Often times, those were estimated and then “passed along” for decades. The origins of many of the values are long forgotten. But it doesn’t mean that this approach doesn’t work! Far from it! I think that most civil engineering structures with impact loads were designed this way!
This approach is so popular, that many manufacturers of various technical equipment supply this information in their datasheet! For instance, you get the machine drawing (to know how to connect it to the structure, etc). Usually, this drawing contains machine weight (the real one) and the “static weight” you should use in design. If the machine can cause horizontal loads, the manufacturer should provide those as “static equivalent” as well. Cool huh!
You will also get the frequency of the machine, along with all of the above. And this nicely leads us to another part of this article!
Dynamic or not dynamic – vibrations!
This is where things start to be a bit more interesting. I think it’s obvious that “vibrations” are a dynamic thing. But, you most likely won’t need all the fancy stuff to analyze vibrations! This is the realm of “linear dynamics”.
In essence, you can use modal analysis to predict vibration modes of your structure (as long as the structure itself behaves in a linear way). And what is interesting is, that loads in this analysis don’t change in time. In fact, the solver will “change” the loads you select into the mass of your model. It will simply ignore the rest of the loads! So there is no “load changing in time” component yet!
You may think about modal analysis as about Linear Buckling Analysis (LBA) of dynamics! It’s there, it does help, but it’s not the pinnacle of human achievement in the field!
Modal analysis
Modal analysis allows you to predict natural frequencies of your linear model. This way, you can check if you may have vibration problems. Of course, you don’t want the applied load frequency to be close to the one you’ve got for your structure in modal analysis. If that is the case, it’s better to be careful, since your structure can enter resonance, and this hurts!
Resonance is of course dangerous. It’s the situation where the amplitude of vibrations increases A LOT! I don’t want to say that it increases to “infinity” because of the damping. But still, it increases enough to destroy your structure if the source of vibrations isn’t shut off quickly enough!
Storytime!
When I was a student I was in a building during resonance once. And nothing really bad happened, so I live to tell the tale. In Wrocław, the civil engineering department is a 10 story building, and they were making a parking space behind it. Since they needed to compact sand they used those small “hoppers”. You know the small machines that basically “jump” up and down to compact the ground below them. It so happened that the frequency of the hopper “jumps” they used matched almost perfectly to the natural frequency of our building. So naturally, after some time the building started to shake!
I was in the lecture on the 1st floor so it wasn’t so bad. But people from the 10th run down in panic on the stairs (they were afraid to use elevators). Luckily someone realized what was going on! They run to the guys doing the parking space and ask them to take a break… and things stabilized!
But I also helped in the design of repairs of the steel structure that entered resonance! This time the source was some technology thing, and before they shut it down, many of the welds and bolts cracked. Luckily the crew was wise enough to run off and shut down the machine by killing the electricity from afar!
So yea… you may want to pay attention to natural vibrations, and modal analysis will help you here. Sadly, it’s pretty costly to change the natural frequencies of the structure once it is built! So it’s better to pay attention!
2)
Elastic Behavior of Solids
Elasticity is defined as an attribute of rigid bodies to restore their original shape. Consider a spring hanging at one end through a rod at the top and the other end of it is left free. If I stretch this free end, the spring starts vibrating back and forth. It means the potential energy stored inside it transforms into kinetic energy; the spring is in solid form, so there is a tiny space between the successive atoms. Due to the force of attraction between them, they try to come back to their lattice points. This is how an interatomic force of attraction comes into play. So soon the stage comes when restoring force acting in the opposite direction to the applied force brings the spring into its natural state. Hence, the condition in which the body rolls back to its initial form. Such a condition is elasticity.
Explain Elastic Behaviour of Solids
Solid is one of the three states of matter composed of many molecules or atoms arranged in a particular form. Here, each molecule is acted upon by the forces because of neighbouring molecules. The solids take such a shape that each molecule finds itself in a position of stable equilibrium. The rigid bodies when stretched with an external force restore their original shape after the removal of this force. It means they are in an elastic limit. So, until the elastic limit, the body resists the changes. Therefore, we can say that the body is perfectly elastic. Thus, the elastic behaviour of solids can be explained very well by observing the microscopic nature of the solids.
Elastic Behavior of Solids
When a solid body is deformed, the atoms or molecules inside it are displaced from their fixed points or lattice points (equilibrium positions) causing a change in interatomic and intermolecular distances. When this force is removed, the interatomic force tries to bring back the body into its original position. Thus, the body comes to its original shape.
Mechanical Properties of Solids
The restoring mechanism can be visualized through a model of a spring ball system. Here, the ball represents atoms and spring represents the interatomic force of attraction between the balls or atoms.
(Image will be added soon)
Initially, these atoms are in their respective lattice points as shown in Fig.2. When they are displaced from their points, the interatomic force of attraction brings the system to its original shape.
Deformation: The phenomenon of change in the shape of a body under the effect of applied force.
Deforming Force: The external force that is responsible for deformation in the shape of the system is called the deforming force.
Restoring Force: The opposite force that works in the way the frictional force does in a moving body. This force acts in the opposite direction, and it is a property of a body to come back to its original position after an external force is removed.
Physical and Chemical Properties of Solids
Solids are incompressible, which means that the constituent particles are placed close to each other, resulting in little space between the constituent particles.
Solids have a fixed mass, volume, and form, resulting in a compact arrangement of component particles.
Solids are inflexible. This is because there isn't enough space between the constituent particles, which causes it to be hard or fixed.
Molecules have a small intermolecular distance. As a result, the force between component particles (atoms, molecules, or ions) is extremely strong.
Particles in the system can only fluctuate about their mean locations.
The melting point of a solid is determined by the strength of the interactions between its constituents: stronger interactions result in a higher melting point.
Important Points on Elastic Behaviour of Solids
The attribute of a matter or a body under which a body regains its original configuration is called elasticity. Let us understand this through an experiment:
On stretching a rubber band, we observe that there is a change in its shape and size. On releasing the band, the rubber regains its original length.
(Image will be added soon)
The force applied to the rubber band is the deforming force. Therefore, the force that restores the elongated body to its original shape, and size is called the restoring force.
What Causes this to Happen?
Depending on their atomic elasticity, solids are formed up of atoms (or molecules). They are surrounded by other atoms of the same type, which are kept in balance by interatomic forces. When a force is applied to the solid, these particles are displaced, causing it to distort. When the deforming force is eliminated, the atoms revert to their previous state of equilibrium due to interatomic interactions. Because no substance is fully elastic, elasticity is an idealization.
Applications of Elastic Behavior of Materials
Elastic materials are those materials that can be used in places where the long-term usage of such material is required. The applications of elastic materials are outlined below:
Used in the construction of bridges, beams, columns, pillars: while constructing these materials, in-depth knowledge of the strength of the materials used in the construction is of prime importance.
Construction of cranes: Cranes are used to lift the loads. Therefore, great care is taken into consideration that the extension of the rope does not exceed the elastic limit of the rope.
In engineering, it is of utmost importance to know the elastic behaviour of materials being used.
The bridges are designed in such a way that they don’t get deformed or break under a load of heavy traffic, or due to the force of strongly blowing wind, and its weight.
Let’s consider a bar of length L and breadth d. Let Y be the young's modulus of the material of the bar. When a load ‘W’ is attached at its middle point, the depression δ produced at its middle point is given by,
δ = Wl3/4Ybd3
The metallic parts of the machinery are designed in such a way that when they are subjected to stress beyond the elastic limit, they will get permanently deformed.
Factors Affecting Elasticity
Effect of Stress: Even within the elastic limit, we know that when a solid is exposed to a high number of cycles of stresses, it loses its elastic characteristic. As a result, the material's operating stress should be kept lower than the ultimate tensile strength and the safety factor.
Effects of Temperature: Temperature affects the elastic properties of materials. Elasticity rises with lower temperatures and decreases with higher temperatures.
Effect Nature of Crystals: The flexibility of the crystals also relies on whether they are single crystals or polycrystals. The elasticity of a single crystal is higher, whereas the elasticity of a polycrystal is lower.
Effect of Annealing: Annealing is a procedure that involves heating a material to a very high temperature and then cooling it slowly. Typically, this technique is used to improve the material's softness and ductility. However, annealing a material causes the production of big crystal grains, which lowers the material's elastic properties.
Effect of Impurities: The presence of impurities causes variations in the materials' elastic properties. The type of impurity introduced to it determines how much elasticity it gains or loses.
Differences Between Elasticity and Plasticity
Elasticity is the quality of a solid material that allows it to restore its form once external stress is removed. Plasticity is the characteristic of a solid substance that allows it to keep its distorted shape even when the external load is removed.
The amount of elastic deformation is minimal. The amount of plastic distortion is substantial.
The amount of external force necessary to bend a solid elastically is relatively tiny. Plastic deformation needs a greater amount of force.
Within this elastic zone, Hooke's Law of Elasticity applies. If the material is plastically distorted, Hooke's Law does not apply.
Within this elastic area, most solid materials exhibit linear stress-strain behaviour. In the plastic zone, the stress-strain curve is non-linear.
Although atoms of the material are displaced from their original lattice location during elastic deformation, they return to their original position once external stress is eliminated. As a result, atoms are momentarily displaced. Plastic deformation causes solid atoms to be permanently displaced from their original lattice location. They maintain their new location even when the external stress is removed.
Elastic deformation takes place before plastic deformation. Only after it has been elastically deformed does it undergo plastic deformation.
The Similarity Between Elasticity and Plasticity
Both are the qualities of Solid.
Both forms of deformations can occur as a result of any sort of loading (normal, shear, or mixed).
Depending on the application, both elastic and plastic deformations might be advantageous.
Only when the material has been elastically deformed can plastic deformation begin. As a result, plastic deformation is impossible without elastic deformation.Elasticity is defined as an attribute of rigid bodies to restore their original shape. Consider a spring hanging at one end through a rod at the top and the other end of it is left free. If I stretch this free end, the spring starts vibrating back and forth. It means the potential energy stored inside it transforms into kinetic energy; the spring is in solid form, so there is a tiny space between the successive atoms. Due to the force of attraction between them, they try to come back to their lattice points. This is how an interatomic force of attraction comes into play. So soon the stage comes when restoring force acting in the opposite direction to the applied force brings the spring into its natural state. Hence, the condition in which the body rolls back to its initial form. Such a condition is elasticity.3)
3)
When no mass is attached to the spring, the spring is at rest (we assume that the spring has no mass). We choose the origin of a one-dimensional vertical coordinate system
This is the same equation as that for the simple harmonic motion of a horizontal spring-mass system (Equation 13.1.2), but with the origin located at the equilibrium position instead of at the rest length of the spring. In other words, a vertical spring-mass system will undergo simple harmonic motion in the vertical direction about the equilibrium position. In general, a spring-mass system will undergo simple harmonic motion if a constant force that is co-linear with the spring force is exerted on the mass (in this case, gravity). That motion will be centered about a point of equilibrium where the net force on the mass is zero rather than where the spring is at its rest position.
Exercise 13.2.113.2.1
How does the period of motion of a vertical spring-mass system compare to the period of a horizontal system (assuming the mass and spring constant are the same)?
The period of the vertical system will be larger.
The period of the vertical system will be smaller.
The period will be the same.
Answer
Two-spring-mass system
Consider a horizontal spring-mass system composed of a single mass, m�, attached to two different springs with spring constants k1�1 and k2�2, as shown in Figure 13.2.213.2.2.
Figure 13.2.213.2.2: A mass attached to two different springs.
When the motion of an oscillator reduces due to an external force, the oscillator and its motion are damped. These periodic motions of gradually decreasing amplitude are damped simple harmonic motion. An example of a damped simple harmonic motion is a simple pendulum.
In the damped simple harmonic motion, the energy of the oscillator dissipates continuously. But for a small damping, the oscillations remain approximately periodic. The forces which dissipate the energy are generally frictional forces.
Browse more Topics Under Oscillations
Expression of damped simple harmonic motion
Let’s take an example to understand what a damped simple harmonic motion is. Consider a block of mass m connected to an elastic string of spring constant k. In an ideal situation, if we push the block down a little and then release it, its angular frequency of oscillation is ω = √k/ m.
However, in practice, an external force (air in this case) will exert a damping force on the motion of the block and the mechanical energy of the block-string system will decrease. This energy that is lost will appear as the heat of the surrounding medium.
The damping force depends on the nature of the surrounding medium. When we immerse the block in a liquid, the magnitude of damping will be much greater and the dissipation energy is much faster. Thus, the damping force is proportional to the velocity of the bob and acts opposite to the direction of the velocity. If the damping force is Fd, we have,
Fd = -bυ (I)
where the constant b depends on the properties of the medium(viscosity, for example) and size and shape of the block. Let’s say O is the equilibrium position where the block settles after releasing it. Now, if we pull down or push the block a little, the restoring force on the block due to spring is Fs = -kx, where x is the displacement of the mass from its equilibrium position. Therefore, the total force acting on the mass at any time t is, F = -kx -bυ.
Now, if a(t) is the acceleration of mass m at time t, then by Newton’s Law of Motion along the direction of motion, we have
ma(t) = -kx(t) – bυ(t) (II)
Here, we are not considering vector notation because we are only considering the one-dimensional motion. Therefore, using first and second derivatives of s(t), v(t) and a(t), we have,
m(d2x/dt2) + b(dx/dt) + kx =0 (III)
This equation describes the motion of the block under the influence of a damping force which is proportional to velocity. Therefore, this is the expression of damped simple harmonic motion. The solution of this expression is of the form
x(t) = Ae-bt/2m cos(ω′t + ø) (IV)
where A is the amplitude and ω′ is the angular frequency of damped simple harmonic motion given by,
ω′ = √(k/m – b2/4m2 ) (V)
The function x(t) is not strictly periodic because of the factor e-bt/2m which decreases continuously with time. However, if the decrease is small in one-time period T, the motion is then approximately periodic. In a damped oscillator, the amplitude is not constant but depends on time. But for small damping, we may use the same expression but take amplitude as Ae-bt/2m
∴ E(t) =1/2 kAe-bt/2m (VI)
This expression shows that the damping decreases exponentially with time. For a small damping, the dimensionless ratio (b/√km) is much less than 1. Obviously, if we put b = 0, all equations of damped simple harmonic motion will turn into the corresponding equations of undamped motion.
Damped Harmonic Motion: Have you ever come up with a pendulum clock? When the clock strikes an hour, the pendulum begins to ring. The pendulum swings back and forth about its mean position as it rings. The swinging of this pendulum slows and ultimately comes to rest. Why is that? Due to friction between air and bob, the pendulum slows and ultimately comes to rest but what it is called?
Have you ever tried swinging? The ones that move back and forth as you exert force on them with your limbs. But what happens when you stop pushing forward? The swing swings back and forth for a while before coming to a halt. Why is that? When we swing a pendulum, we know that it will ultimately come to rest due to air pressure and friction at the support. This motion is described as damped harmonic motion. The amplitude of a damped simple harmonic oscillator gradually decreases. Read this article to know the definition, examples, and expressions of damped simple harmonic motion
A simple harmonic motion is the oscillatory motion of the simplest type. The motion of an oscillating system is said to be a simple harmonic when the force acting on it is directly proportional to the displacement of the oscillating object from its mean position. At any point during the simple harmonic motion, the force acting on an object will act towards its mean position.
The oscillating systems eventually come to a halt due to the damping and dissipative forces. The systems can be forced to remain oscillating with the help of some external periodic agency.
Damping can be defined as energy dissipation by restraining the vibratory motion like mechanical oscillations, alternating electric current, and noise. Damping can be understood as the resistance offered to the oscillation of a body. In automobiles, shock absorbers and carpet pads act like damping devices. Damping can be of two types:
Natural Damping
Artificial Damping
Damped Simple Harmonic Motion
A simple harmonic motion whose amplitude goes on decreasing with time is known as damped harmonic motion. These oscillations fade with time as the energy of the system is dissipated continuously. If the damping applied to the system is relatively small, then its motion remains almost periodic. Frictional forces generally act as dissipative forces.
Expression for Damped Simple Harmonic Motion
Let us understand the effect of a damping force on the motion of a harmonic oscillator. Suppose we have a block of mass mm connected to an elastic spring having a spring constant k that is oscillating vertically. Now, this block is pushed down slightly and released immediately. The spring block system will start oscillating. Let the angular frequency of the oscillation be ω.
Although in reality, a damping force will be exerted by the surrounding medium, i.e. air on the block’s motion. Due to this, the mechanical energy of the spring-block system will decrease. The loss in the system’s energy will appear in the form of heat energy in the surroundings. The magnitude and the type of damping forces acting on the system will depend on the nature of the surrounding medium. When the spring block system is immersed in fluid instead of air, due to the larger magnitude of the damping thus, the dissipation of energy will be much faster.
4)
Since wave frequency is the number of waves per second, and the period is essentially the number of seconds per wave, the relationship between frequency and period is f = 1 T 13.1 or T = 1 f, 13.2 just as in the case of harmonic motion of an object. We can see from this relationship that a higher frequency means a shorter period.
Wave Variables
In the chapter on motion in two dimensions, we defined the following variables to describe harmonic motion:
Amplitude—maximum displacement from the equilibrium position of an object oscillating around such equilibrium position
Frequency—number of events per unit of time
Period—time it takes to complete one oscillation
For waves, these variables have the same basic meaning. However, it is helpful to word the definitions in a more specific way that applies directly to waves:
Amplitude—distance between the resting position and the maximum displacement of the wave
Frequency—number of waves passing by a specific point per second
Period—time it takes for one wave cycle to complete
In addition to amplitude, frequency, and period, their wavelength and wave velocity also characterize waves. The wavelength � is the distance between adjacent identical parts of a wave, parallel to the direction of propagation. The wave velocity �� is the speed at which the disturbance moves.
Its wavelength is the distance from crest to crest or from trough to trough. The wavelength can also be thought of as the distance a wave has traveled after one complete cycle—or one period. The time for one complete up-and-down motion is the simple water wave’s period T. In the figure, the wave itself moves to the right with a wave velocity vw. Its amplitude X is the distance between the resting position and the maximum displacement—either the crest or the trough—of the wave. It is important to note that this movement of the wave is actually the disturbance moving to the right, not the water itself; otherwise, the bird would move to the right. Instead, the seagull bobs up and down in place as waves pass underneath, traveling a total distance of 2X in one cycle. However, as mentioned in the text feature on surfing, actual ocean waves are more complex than this simplified example.
Figure 13.7 The wave has a wavelength λ, which is the distance between adjacent identical parts of the wave. The up-and-down disturbance of the surface propagates parallel to the surface at a speed vw.
WATCH PHYSICS
Amplitude, Period, Frequency, and Wavelength of Periodic Waves
This video is a continuation of the video “Introduction to Waves” from the "Types of Waves" section. It discusses the properties of a periodic wave: amplitude, period, frequency, wavelength, and wave velocity.
A building’s natural frequency (n) is simply the inverse of the fundamental period (T), and, for flexible and dynamically sensitive buildings and other structures, this natural frequency is used in the calculation of the Gust Factor. The ASCE 7 standard specifies that buildings are considered “flexible” if they have a fundamental period greater than 1 second. Tall building or moment-frame buildings tend to be more flexible than others, so these code criteria can have a significant impact on their design and their construction costs. And engineering judgement is required when the natural frequency/fundamental period of the structure is near 1.0 and note that the nonbuilding structure or components with the fundamental period less than 0.06 s shall be considered a rigid element.
Fundamental Frequency vs Natural Frequency
Natural frequency and fundamental frequency are two wave related phenomena that are very important. These phenomena are of great significance in fields such as music, construction technologies, disaster prevention, acoustics and most of the natural system analysis. It is vital to have a clear understanding in these concepts in order to excel in such fields. In this article, we are going to discuss what fundamental frequency and natural frequency are, their definitions, applications, the phenomena connected to natural frequency and fundamental frequency, their similarities and finally the differences between natural frequency and fundamental frequency.
Every system has a property called the natural frequency. The system will follow this frequency, if the system is to be provided with a small oscillation. The natural frequency of a system is very important. Events such as earthquakes and winds can do destruction on objects with the same natural frequency as the event itself. It is very important to understand and measure the natural frequency of a system in order to protect it from such natural disasters. Natural frequency is directly related with resonance. When a system (e.g. a pendulum) is given a small oscillation, it will start to swing. The frequency with which it swings is the natural frequency of the system. Now imagine a periodical external force applied to the system. The frequency of this external force does not necessarily be similar to the natural frequency of the system. This force will try to oscillate the system to the frequency of the force. This creates an uneven pattern. Some energy from the external force is absorbed by the system. Now let us consider the case where the frequencies are the same. In this case, the pendulum will freely swing with maximum energy absorbed from the external force. This is called resonance. Systems such as buildings, electronic and electrical circuits, optical systems, sound systems and even biological systems have natural frequencies. They can be in the form of impedance, oscillation, or superposition, depending on the system.
Fundamental frequency is a concept discussed in standing waves. Imagine two identical waves, which are travelling in opposite directions. When these two waves meet, the result is called a standing wave. The equation of a wave travelling in +x direction is y = A sin (ωt – kx), and the equation for a similar wave traveling in the -x direction is y = A sin (ωt + kx). By the principle of superposition, the resultant waveform from the overlapping of these two is y = 2A sin (kx) cos (ωt). This is the equation of a standing wave. ‘x’ being the distance from the origin; for a given x value, the 2A sin (kx) becomes a constant. Sin (kx) varies between -1 and +1. Therefore, the maximum amplitude of the system is 2A. The fundamental frequency is a property of the system. At the fundamental frequency, the two ends of the systems are not oscillating, and they are known as nodes. The center of the system is oscillating with the maximum amplitude, and it is known as the antinode.
An object's natural frequency is the frequency or rate that it vibrates naturally when disturbed. Objects can possess more than one natural frequency and we typically use harmonic oscillators as a tool for modeling the natural frequency of a particular object.
We can apply an unnatural or forced frequency to an object that equals the natural frequency of an object. In cases such as this, we are in effect creating resonance, i.e., oscillations at the object’s natural frequency. If this occurs in certain structures, the oscillations will continue to increase in magnitude, thus resulting in structural failure.
Once we move the ball away from its position of equilibrium, there are two possible outcomes:
It adds more tension to the spring, i.e., it is stretched downwards.
It provides gravity the opportunity to pull the ball downward devoid of the tension from the counteracting spring, i.e., you push the ball upward.
Regardless of which action you take, the ball will begin to oscillate about the equilibrium position.
This oscillating frequency is the natural frequency, and we measure it in Hz (hertz). In summary, this will provide the oscillations per second depending on the spring's properties and the ball's mass.
Now, we will use the above example to calculate the natural frequency of a simple harmonic oscillator. When calculating the natural frequency, we use the following formula:
f = ω ÷ 2π
Here, the ω is the angular frequency of the oscillation that we measure in radians or seconds. We define the angular frequency using the following formula:
ω = √(k ÷ m)
This, in turn, adjusts our formula to the following:
f = √(k ÷ m) ÷ 2π
f is the natural frequency
k is the spring constant for the spring
m is the mass of the ball
We measure the spring constant in Newtons per meter. A spring with a higher constant is stiffer and requires additional force to extend.
As we calculate the natural frequency utilizing the above formula, we must initially determine the spring constant for the system. Typically, we obtain this value by conducting tests. However, for this example, we will use 150 N/m to represent k and 2 kg to describe our mass m.
Now, we will utilize these values by performing the steps of the calculation:
f = √(150 N/m ÷ 2 kg) ÷ 2π
f = √(75 Hz) ÷ 2π
f = 8.66 Hz ÷ 2π
f = 8.66 Hz ÷ 2(3.14)
f = 8.66 Hz ÷ 6.28
f = 1.3789 Hz
per
f = 1.38 Hz
The natural frequency is 1.38 Hz, which translates into the system oscillating nearly one and a half times per second.
The Importance of Calculating Natural Frequencies
We typically consider the natural frequencies and mode shapes to be the single most critical property of virtually any system. As you might imagine, excessive vibrations in any system lead to structural and functional issues.
The reason for this is the natural frequencies can match . For example, if you employ a time-varying force to a system and select a frequency equivalent to one of the natural frequencies, this will result in immense amplitude vibrations that risk putting your system in jeopardy.
This is why when designing a mechanical system it’s important to calculate and ensure the natural frequencies of vibration are far greater than any possible excitation frequency that your system is likely to encounter.
Methods for Shifting Natural Frequencies
In general, the following are rules that allow natural frequency shifting and minimizing the vibrational response of a system:
To increase the natural frequency, add stiffness.
To decrease the natural frequency, add mass.
An increase in the damping diminishes the peak response, however, it broadens the response range.
A decrease in the damping raises the peak response, however, it narrows the response range.
5)
A response spectrum is a graphical plot of the frequency of an oscillator and its damping. The response spectrum plot represents the peak or steady-state response (velocity, displacement, or acceleration) of a series of oscillators of varying natural frequenci
In the vibration analysis of any system, the response spectrum is very useful as the resulting plot can provide the response of any linear system with respect to its natural frequency.
Earthquakes are random ground motion that produces inertial loads in structures built on them. The ground motion of the earthquake can be attenuated by the building’s resonant response producing much larger motions at higher levels. That leads to major damage to the structure. Hence, structures need to be designed to withstand the earthquake’s ground motion.
Static equivalent analysis, for most non-critical piping systems, the earthquake is treated as a static load, which is proportional to the weight of the piping and components. The magnitude of the load is generally determined by the ‘g’ factor according to respective codes, for example, UBC, IBC, ASCE, IS, etc. This load is applied statically in the vertical and two horizontal directions.
For seismic analysis of piping and structures, the earthquake response spectrum is the most popular tool. For predicting forces and displacements of pipes and structures, the response spectrum method provides various computational advantages. The main benefit of the seismic response spectrum method is the calculation of only the maximum displacement and force values in each mode of vibration using smooth design spectra that are the average of several earthquake motions.
If the natural frequency of the structure coincides with the frequency of earthquake ground motion, it leads to a resonance condition, which creates substantial damage to the system. That’s the main reason, not all buildings collapse during an earthquake. The natural frequency of building/structure is a property of height, stiffness, material, etc. Buildings whose natural frequency matches with earthquake frequency collapse during an earthquake while remaining are not experiencing major damage.
The response spectrum is using the same principles as time history. Only instead of using time history, it is using maximum values of the response. When the time history profile is not available for a particular dynamic event, then the response spectrum is used. Response spectrum analysis provides more conservative results than time history.
Parameters affecting Response Spectra
The response spectral values are dependent on various factors like,
Soil condition
Energy release mechanism
Damping in the system
Epicentral distance
Focal depth
Richter magnitude
The time period of the system
Construction of Response Spectrum Plot
The construction of a Response Spectrum requires the solution of a single degree of freedom system, for a sequence of natural frequency values and damping ratio in the range of interest. Every solution provides only one point (with the maximum value) of the response spectrum. All of these maximum response values are plotted against natural frequency to construct a single response spectrum.
Since a large number of systems must be analyzed in order to fully plot each response spectrum, the task is lengthy and time-consuming. But once these curves are constructed and available for the excitation of interest, the analysis for the design of structure subjected to dynamic loading is reduced to a very simple calculation of the natural frequency of the system and the use of response spectrum to calculate the maximum response.
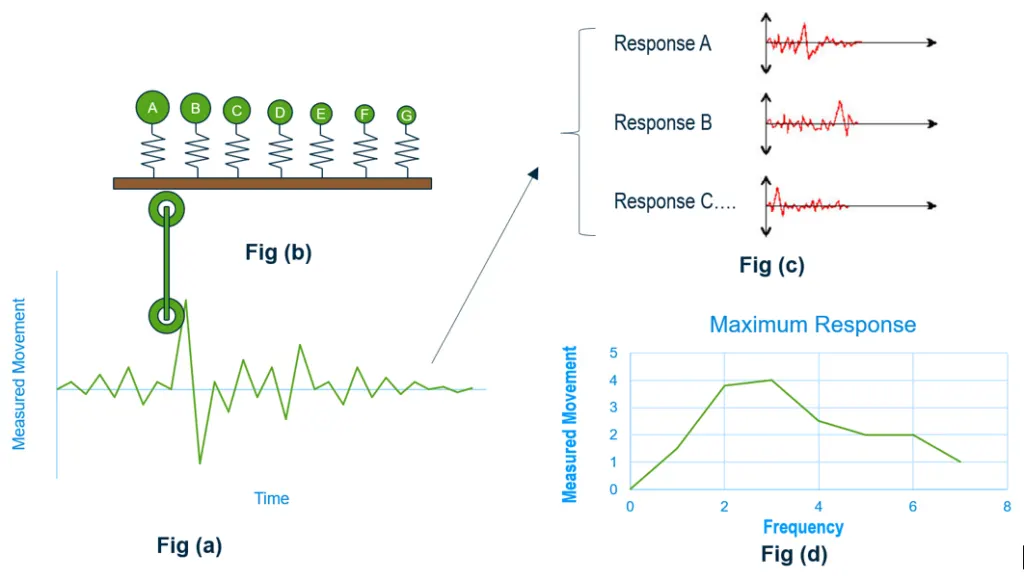
Step 1: First, take the randomly measured ground motion from previous earthquake records in that area. (Fig a)
Step 2: Then sequence of tuned SDOF oscillators with some fixed damping values attached to a shaker table and measured motion used to shake the table. (Fig b)
Step 3: The response of all the SDOF oscillators is recorded and plotted for an individual oscillator. (Fig c)
Step 4: Maximum response for all individual oscillators is extracted to plot the combined response. (Fig d)
Calculating the maximum response for a range of values of frequency and damping and then plotting results graphically to get a spectrum chart that shows the maximum response for all possible single-degree-of-freedom systems to that component of the earthquake.
This combined response is made up of many peaks and troughs. The envelope of the broadened peaks is shown in fig (d), which is a conservative approach. The idea is that even though all earthquakes are different, the maximum response of similar earthquakes should be the same even though the time the maximum response occurs may differ i.e. timing of the event is not considered.
Seismic engineers and government planning departments use these values from the spectrum chart to determine the appropriate earthquake loading for buildings in the respective zone. Earthquake load impact calculations for any structure in that area of the region are simplified into a few steps to (a) calculate the natural frequency of the system, (b) and then the maximum response found from the respective spectrum chart for calculated natural frequency.
Pseudo-acceleration and Pseudo-velocity
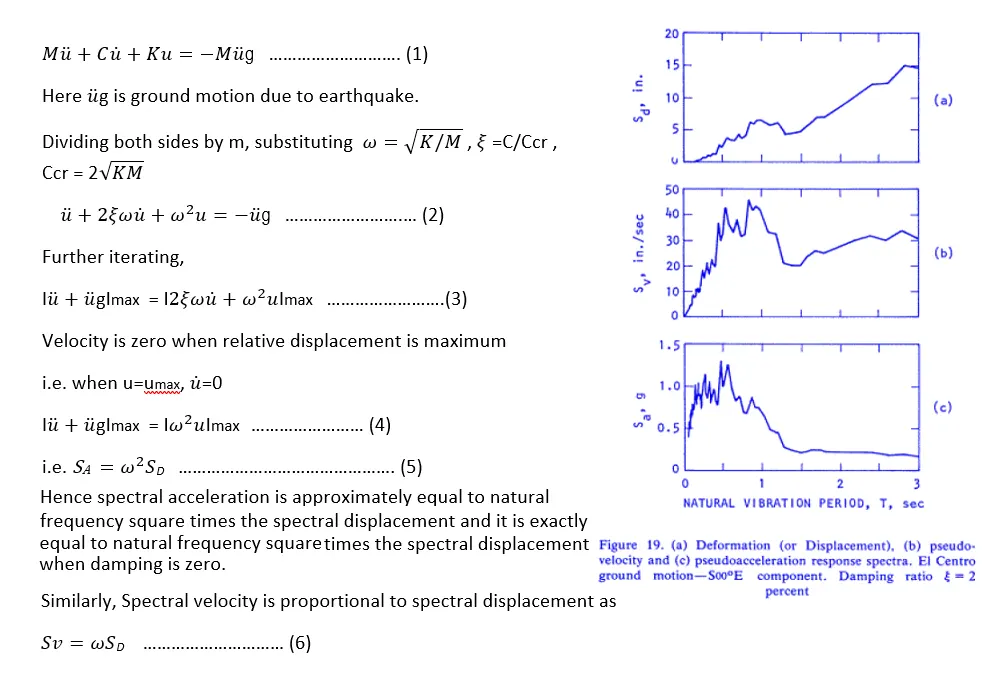
Response spectrum plots can be plotted as maximum relative displacement, maximum velocity, or maximum acceleration. These three quantities are also known as spectral displacement (SD), Spectral velocity (SV), and Spectral acceleration (SA) and are also proportional to each other.
The spectral displacement i.e. maximum relative displacement is proportional to spectral acceleration i.e. maximum absolute acceleration. This can be demonstrated with simple numerical iterations on the dynamic equation of motion.
And this can be demonstrated by equating the equation for potential energy and kinetic energy.
The acceleration and velocity so defined are called pseudo-acceleration and pseudo-velocity, respectively. Pseudo-acceleration is very close to absolute acceleration and is the same as absolute acceleration when there is no damping. Pseudo-velocity is the fictitious velocity associated with the apparent harmonic motion for convenience.
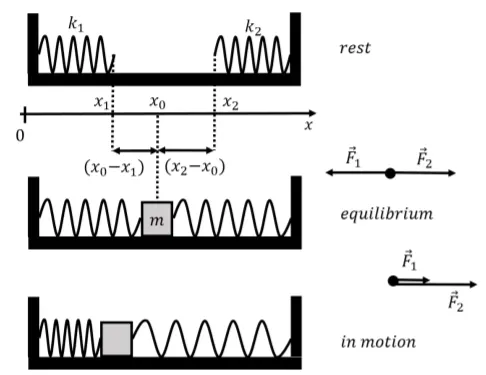
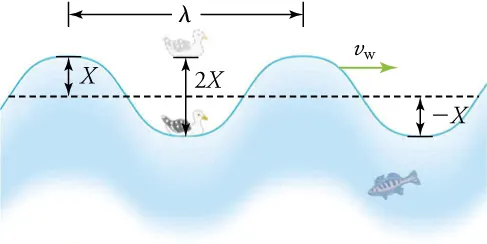 Figure 13.7 The wave has a wavelength λ, which is the distance between adjacent identical parts of the wave. The up-and-down disturbance of the surface propagates parallel to the surface at a speed vw.