Project
Carry out a system-level simulation of an all-terrain vehicle.
Download the model from the given link:
https://www.mathworks.com/matlabcentral/fileexchange/70576-baja-all-terrain-vehicle-atv-model
Prepare a technical report explaining the model properties & comments on the results
Aim :
To simulate system level of BAJA all-terrain vehicle (ATV) and technical report explaining the model.
working principle
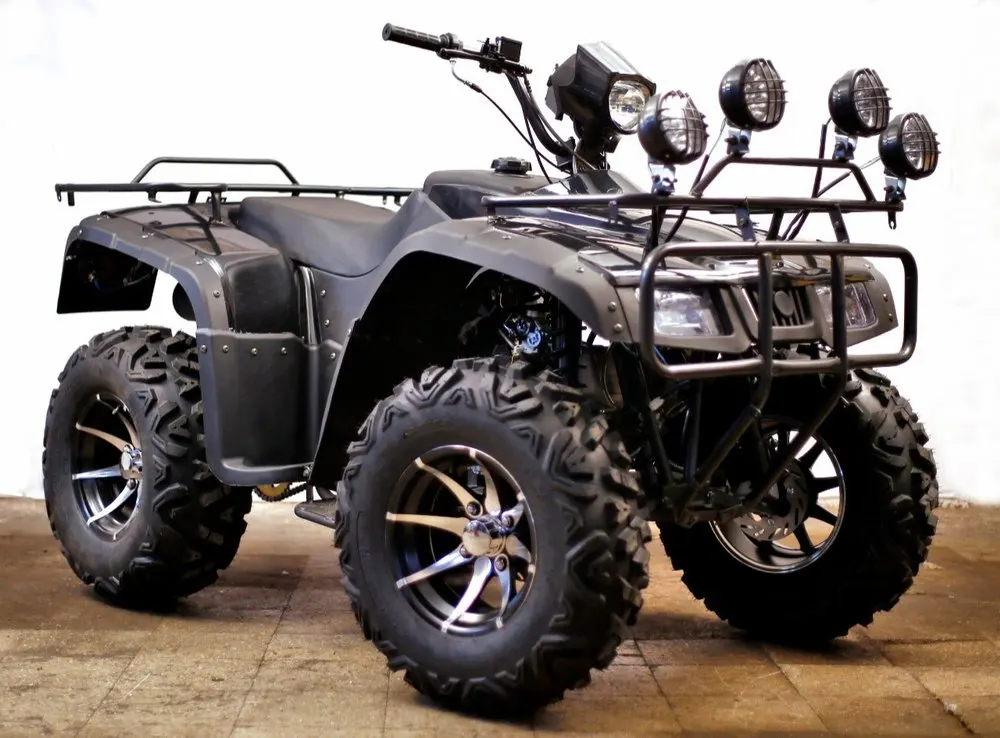
The AVT model of sum examples and image of AVT. this used in An all-terrain vehicle (ATV), also known as a light utility vehicle (LUV). is a vehicle that travels on low-pressure tires, with a seat that is straddled by the operator, along with handlebars for steering control
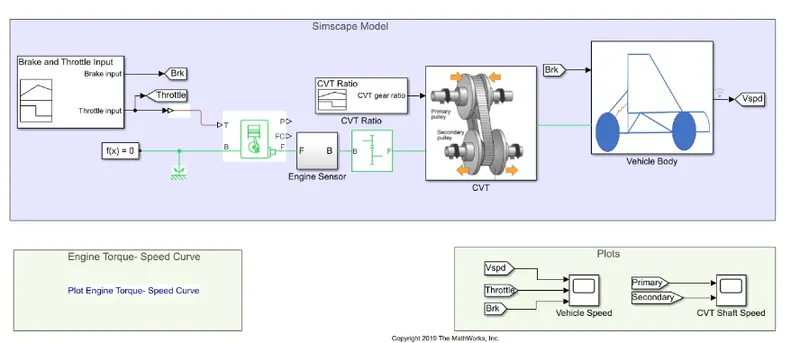
Simulink module of BAJA AVT :
study case 1 :
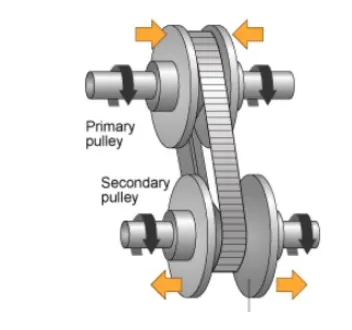
The CVT is an automatic transmission that uses two pulleys with a steel belt running between them. To continuously vary its gear ratios, the CVT simultaneously adjusts the diameter of the "drive pulley" that transmits torque from the engine and the "driven pulley" that transfers torque to the wheels.
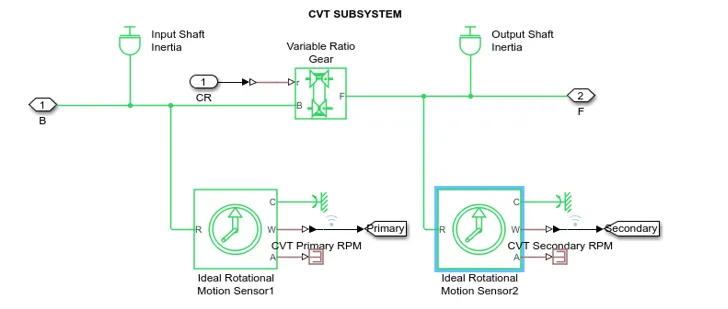
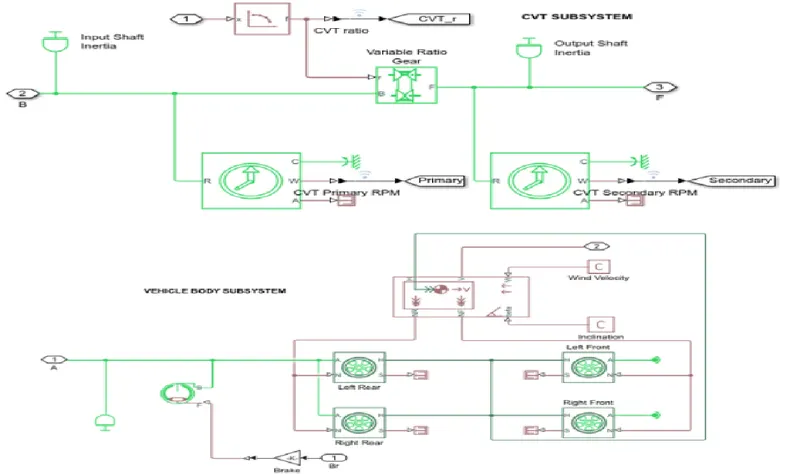
CVT subsystem block is used variable ratio gear is used in the cvt system CVT primary RPM and secondry rpm is used ideal rotational motion senspor block output. input shaft inertia and output shaft inertia is used to the CVT system main blocks. this all blocks of general engine function of ATV
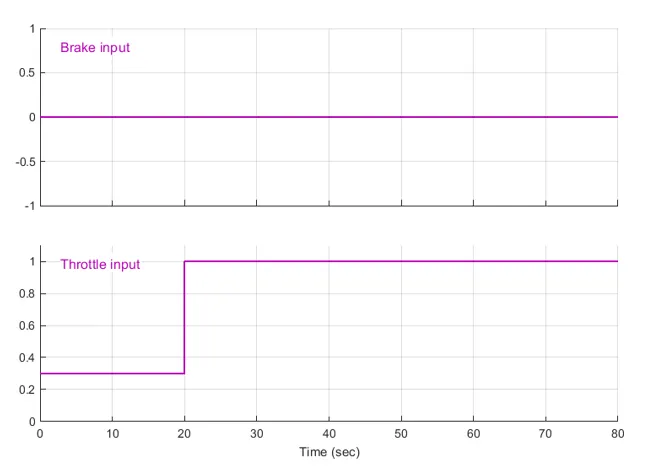
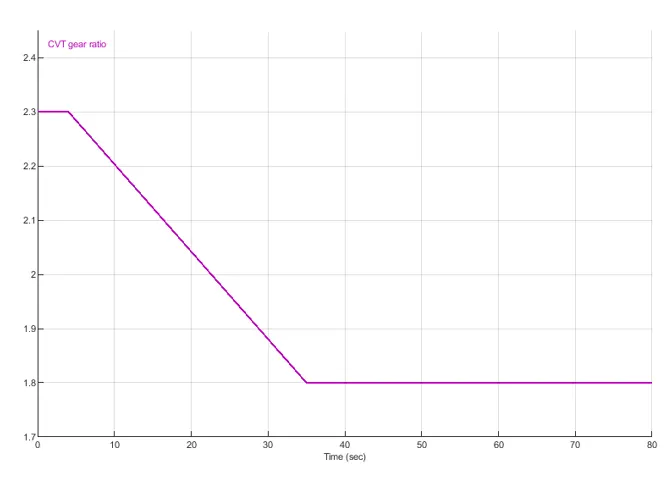
the inpute of the cvt model signal bilder of break and throttle input value of the inpu is brake 0 positio, throttle input is 0.3 to 1 value of signal. and model ration value of cvt gear ratio function.
vechile body system of AVT :
STUDY CASE 2 :
BAJA ATV usin block modul :
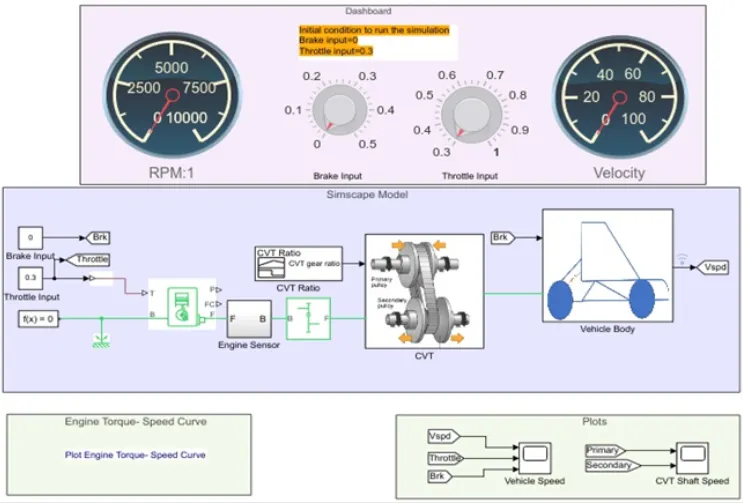
ATV module is usde in RPM and velocity of vechile body system speedmetter of conneting the CVT and generic engine sensor block. cvt ratio is connect to primary pully of system. the signal builder of input value is used. break and throttle founction is used inpute 0.1 to 1.0 value plote engine torque speed and vechile speed and cvt shiaft speed.
engine torque and speed variation is modified function plote. maximum speed and throttle inpute cvt block of primary and secondry pully controle and the vechile bodyfunction
STUDEY CASE 3 :
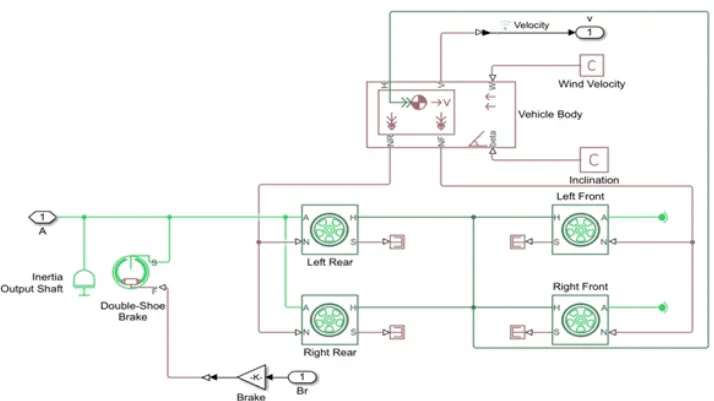
same case is used study 3 allso this function input shaft variable ratio gear is cvt subsystem of vechile body function right front and left front and right rear left rear working the cvt primary and secondry rpm change momement signal waching.
lookup table plote function :
STUDY CASE 4 :
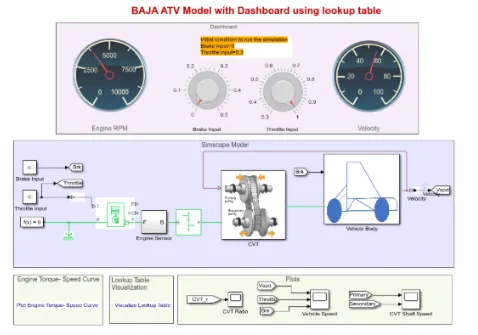
The dashboard module ATV block using look up table plote the function of dasboard variation of the output.
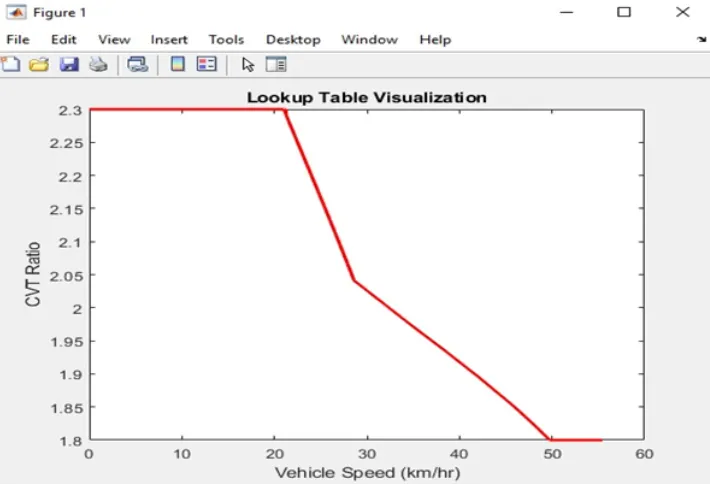
the simuling module of look up table is a CVT and gear ratio inputted of the function dashboard without module
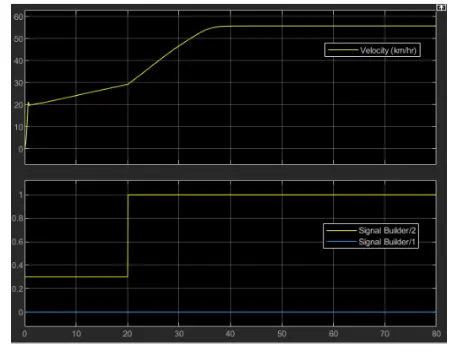
the value of the inpute is break and throttle value consider of break is zero and but throttle inpute is 0.3 to 1.0 the time range 20 sce time velocity inchresing throttle value is incrising
the output of the function is simulik wave is wthout dash board function
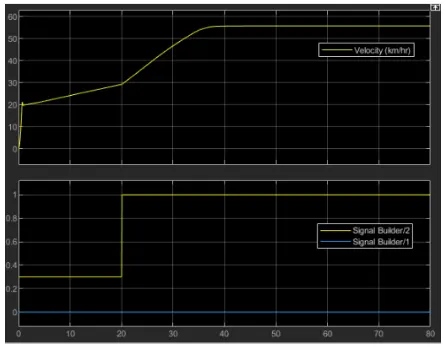
case of dashboard module is
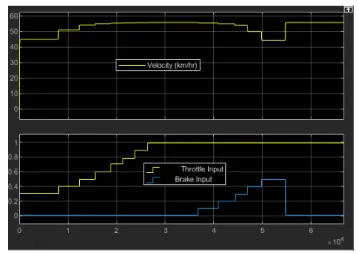
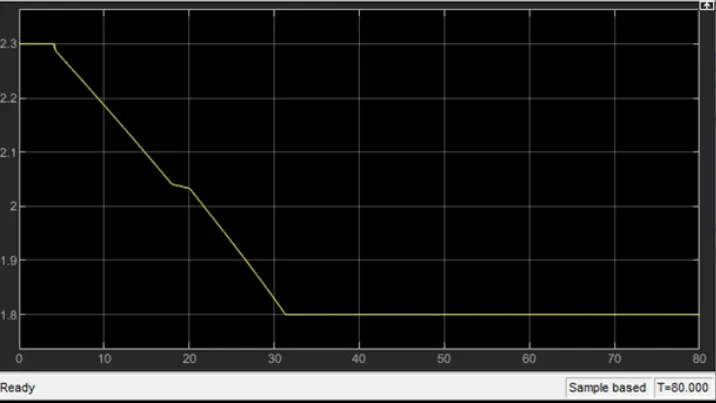
velocity incrising sum speed also incrising this function of sum km of speed rising gear ratio conatant of dash board module outpu
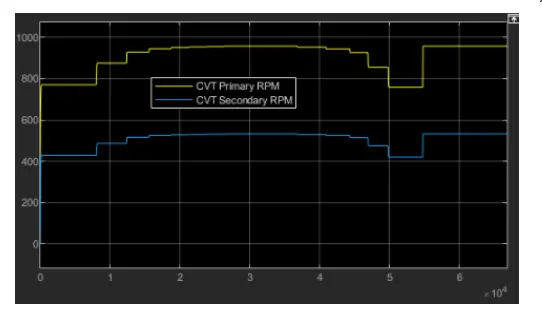
CVT is primary rpm and secondry rpm plote function of simulink range of baja ATV ratio of gear of velocity throttle x10^4 value.
CONCULATION :
System level simulation of simulnk of BAJA ATV module of without dashboard and look up table all the an all-terrain vehicle completed.