Exhaust Port Challenge
Aim:
- Give a brief description of why and where a CHT analysis is used.
- Maintain the y+ value according to the turbulence model and justify the results.
- Calculate the wall/surface heat transfer coefficient on the internal solid surface & show the velocity & temperature contours in appropriate areas
- Verify if the HTC predictions from the simulations are right and find on what factors does the accuracy of the prediction depend on.
Solution:
First we will be defining what a Conjugate heat transfer is :
The term conjugate heat transfer (CHT) is used to describe processes which involve variations of temperature within solids and fluids, due to thermal interaction between the solids and fluids. The exchange of thermal energy between the two physical bodies is called study of Heat Transfer, the rate of transferred heat is directly proportional to the temperature difference between the bodies. A typical example is the heating or cooling of a solid object by the flow of air in which it is immersed and some other example includes conduction through solids, free and forced convection in the gases/fluids and thermal radiation.
Conjugate heat transfer corresponds with the combination of heat transfer in solids and heat transfer in fluids. In solids, conduction often dominates whereas in fluids, convection usually dominates. Efficiently combining heat transfer in fluids and solids is the key to designing effective coolers, heaters, or heat exchangers. Forced convection is the most common way to achieve high heat transfer rate. In some applications, the performances are further improved by combining convection with phase change (for example liquid water to vapor phase change).
Modes of heat transfer
- Conduction: diffusion of heat due to temperature gradients. A measure of the amount of conduction for a given gradient is the heat conductivity.
- Convection: when heat is carried away by moving fluid. The flow can either be caused by external influences, forced convection; or by buoyancy forces, natural convection. Convective heat transfer is tightly coupled to the fluid flow solution.
- Radiation: transfer of energy by electromagnetic waves between surfaces with different temperatures, separated by a medium that is at least partially transparent to the (infrared) radiation. Radiation is especially important at high temperatures, e.g. during combustion processes, but can also have a measurable effect at room temperatures.
An accurate description of heat transfer modes, material properties, flow regimes, and geometrical configurations enables the analysis of temperature fields and heat transfer.
Typical design problems involve the determination of:
- Overall heat transfer coefficient, e.g. for a car radiator.
- Highest (or lowest) temperature in a system, e.g. in a gas turbine, chemical reaction vessels, food ovens.
- Temperature distribution (related to thermal stress), e.g. in the walls of a spacecraft.
- Temperature response in time dependent heating/cooling problems, e.g. engine cooling, or how fast does a car heat up in the sun and how is it affected by the shape of the windshield?
The fluid flow and heat transfer problems can be tightly coupled through the convection term in the energy equation and when physical properties are temperature dependent. While analytical solutions exist for some simple problems, we must rely on computational methods to solve most industrially relevant applications.
CHT can be performed to improve cooling performance of the water jacket and increase engine life. Advancements in cooling for applications such as gas turbines components require improved understanding of the complex heat transfer mechanisms and the interactions between those mechanisms, which our engineers can perform without hassle. Critical cooling applications often rely on multiple thermal protection techniques, including internal cooling, external film cooling, etc. which are efficiently used by our analysis to cool components and limit the use of coolant. We do extensive support for Motor and Battery CHT Analysis to get optimized design for High voltage systems. Conjugate Heat Transfer analysis provides the temperature distribution in solid and coolant of the engine and clear insight on velocity distribution and mechanism of heat transfer of coolant. Results of CHT analysis become input to structural simulations as thermal loads.
We have a wide experience in Engine CHT Analysis for various type of engines like Bikes, Passenger Cars, Racing cars, Commercial Vehicles, Marine, Agricultural equipment and Earth-moving equipment etc.
Where is CHT analysis done ?
It is done on the following applications :
Efficiently combining heat transfer in fluids and solids is the key to designing effective coolers, heaters, or heat exchangers.
The fluid usually plays the role of energy carrier on large distances. Forced convection is the most common way to achieve high heat transfer rate. In some applications, the performances are further improved by combining convection with phase change (for example liquid water to vapor phase change).
Even so, solids are also needed, in particular to separate fluids in a heat exchanger so that fluids exchange energy without being mixed.
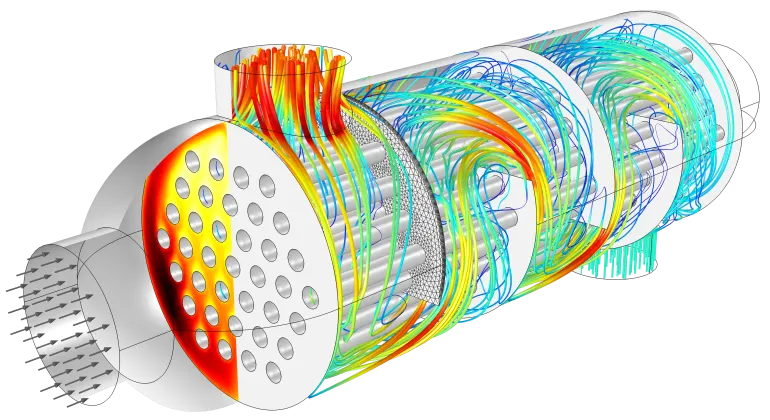
Heat sinks are usually made of metal with high thermal conductivity (e.g. copper or aluminum). They dissipate heat by increasing the exchange area between the solid part and the surrounding fluid.
The temperature field and the heat flux are continuous at the fluid/solid interface. However, the temperature field can rapidly vary in a fluid in motion: close to the solid, the fluid temperature is close to the solid temperature, and far from the interface, the fluid temperature is close to the inlet or ambient fluid temperature. The distance where the fluid temperature varies from the solid temperature to the fluid bulk temperature is called the thermal boundary layer. The thermal boundary layer size and the momentum boundary layer relative size is reflected by the Prandtl number 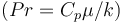 : for the Prandtl number to equal 1, thermal and momentum boundary layer thicknesses need to be the same. A thicker momentum layer would result in a Prandtl number larger than 1. Conversely, a Prandtl number smaller than 1 would indicate that the momentum boundary layer is thinner than the thermal boundary layer. The Prandtl number for air at atmospheric pressure and at 20°C is 0.7. That is because for air, the momentum and thermal boundary layer have similar size, while the momentum boundary layer is slightly thinner than the thermal boundary layer. For water at 20°C, the Prandtl number is about 7. So, in water, the temperature changes close to a wall are sharper than the velocity change.
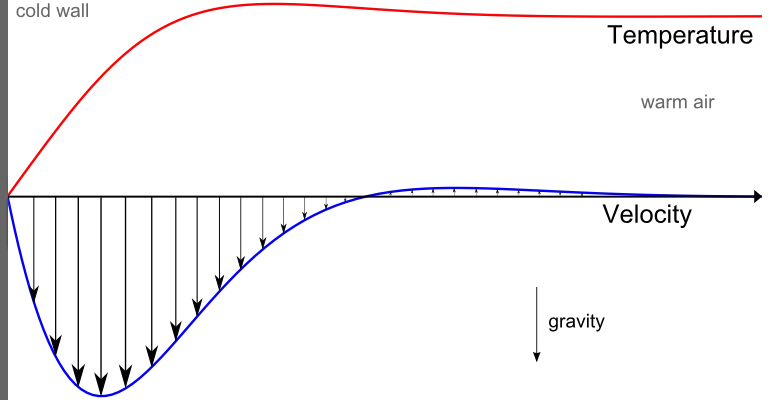
The natural convection regime corresponds to configurations where the flow is driven by buoyancy effects. Depending on the expected thermal performance, the natural convection can be beneficial (e.g. cooling application) or negative (e.g. natural convection in insulation layer).
The Rayleigh number, noted as  , is used to characterized the flow regime induced by the natural convection and the resulting heat transfer. The Rayleigh number is defined from fluid material properties, a typical cavity size,
 , and the temperature difference,
 , usually set by the solids surrounding the fluid:
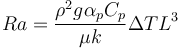
The Grashof number is another flow regime indicator giving the ratio of buoyant to viscous forces:
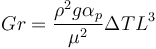
The Rayleigh number can be expressed in terms of the Prandtl and the Grashof numbers through the relation 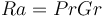 .
When the Rayleigh number is small (typically <103), the convection is negligible and most of the heat transfer occurs by conduction in the fluid.
Now we will be discussing about Y+
The behaviour of the flow near the wall is a complicated phenomenon and to distinguish the different regions near the wall the concept of wall  has been formulated. Thus is a dimensionless quantity, and is distance from the wall measured in terms of viscous lengths.
One of the reasons for the need of is to distinguish different regions near the wall or in the viscous region, however how exactly it helps in turbulence modelling or in general CFD modelling need to be well understood. Let us try to understand this with an example. A fisherman uses fishing net, a grid kind of structure to trap the fishes. If he is trying to catch medium to big sized fishes the grids in the net he uses is somewhat big, but if he is trying to trap even small sized fishes then the grid size of the net should be small enough to capture them. In this case even the large fishes are also captured. Similarly coming back to our case if we intend to resolve the effects near the wall i.e., in the viscous sub layer then the size of the mesh size should be small and dense enough near the wall so that almost all the effects are captured. But in some cases if the wall effects are negligible then there is option of including semi-empirical formulae to bridge between the viscosity affected region and fully turbulent region and in this case the mesh need not to be dense or small near the wall i.e., coarse mesh would work.
Some mature turbulence models such as k−ϵ are only valid in the area of turbulence fully developed, and do not perform well in the area close to the wall. In order to deal with the near wall region, two ways are usually proposed.
One way is to integrate the turbulence to the wall. Turbulence models are modified to enable the viscosity-affected region to be resolved with all the mesh down to the wall, including the viscous sublayer. When using a modified low Reynolds turbulence model to solve the near-wall region, the first cell center must be placed in the viscous sublayer (preferably y+ = 1) leading to the requirement of abundant mesh cells. Thus, substantial computational resources are required.
- Use low-Re model like k−ω
- Good when you are interested in the forces on the wall (aerodynamics analyses for F1 cars, blade optimization in turbomachinery, etc.) 3
Another way is to use the so-called wall functions, which can model the near wall region. Wall functions are equations empirically derived and used to satisfy the physics in the near wall region. The first cell center needs to be placed in the log-law region to ensure the accuracy of the results. Wall functions are used to bridge the inner region between the wall and the turbulence fully developed region. When using the wall functions approach, there is no need to resolve the boundary layer causing a significant reduction of the mesh size and the computational domain!
- First grid cell needs to be 30 < y+ < 300 (If this is too low, the model is invalid. If this is too high, the wall is not properly resolved.
- Use high-Re model (Standard k−ϵ, RNG k−ϵ)
- Use when you are more interested in the mixing rather than the forces on the wall 3
Now we will be doing conjugate heat analysis of an exhaust port as shown below :
Before meshing we will discuss about different turbulent models and accordingly decide the sizing of the mesh :
Turbulence is a type of fluid flow which is unsteady, enormously irregular in space and time, three-dimensional, rotational, dissipative (in terms of energy), and diffusive (transport phenomenon) at high Reynolds numbers. Due to those divergences in turbulent flow, extremely small-scale fluctuations emerge in velocity, pressure, and temperature. Despite the fact that direct implementation of fluctuated values into the Navier-Stokes equation is possible, called a Direct Numerical Solution (DNS), it requires an extreme amount of resources in terms of hardware, software, and human effort. Therefore, an appropriate numerical model should be implemented when modeling turbulent flow.
Implementation of the turbulence model into the numerical scheme is substantial and makes a big difference to the simulation results. At the first step, a quick examination must be carried out—which pertains to the Reynolds number—to detect the type of fluid flow. For instance, as you keep on with the laminar model (no turbulence) for a fluid flow over a cylinder which is turbulent in the reality, the effect of the driven forces, eddies, vorticities and so forth are destructively negated.
Although there is a number of miscellaneous turbulence models that investigate the motion of the fluid, these rely on turbulent viscosity, and no universal turbulence model exists yet. Generally, turbulence models are classified regarding governing equation and numerical method used to calculate turbulent viscosity, for which a solution is sought for turbulence. Reynolds-averaged Navier-Stokes equations (RANS) and large eddy simulation equations (LES) are the common ones that require a compatible amount of resources during examination against DNS. Beyond that, Unsteady Reynolds-averaged Navier-Stokes (URANS), in which motion of the solid body or flow separation causes unsteady flow, has been broadly implemented.
The main purpose of turbulence modeling is to prompt equations to anticipate the time-averaged velocity, pressure, and temperature fields, without calculating the complete turbulent flow pattern as a function of time as in RANS and LES. It is unnecessary to solve the Navier-Stokes equations for every value of fluctuation since most engineering problems do not require such a comprehensive solution. The turbulence models can be summarized as follows:
DNS: Direct implementation of fluctuated values into the Navier-Stokes equation without any turbulence model.
LES: An average turbulence model between DNS and RANS in which filtered Navier-Stokes equations are used for large-scale eddies. An appropriate model is preferred to solve small-scale eddies.
RANS: A mathematical model based on average values of variables for both steady-state and dynamic flows (unsteady for URANS). The numerical simulation is driven by a turbulence model which is arbitrarily selected to find out the effect of turbulence fluctuation on the mean fluid flow.
Requiring a modest amount of hardware, computational time, and human effort, RANS/URANS methods, and sub-models are highly applied for various computational fluid dynamics problems. The implementation of LES is rare but possible in some cases which specifically need much more computational facilities against URANS/RANS.
Spalart-Allmaras
- One-equation model
- No wall functions
- Stable with good convergence
- Convenient: Aerodynamics flows, transonic flows over airfoils
- Limitations: Solving shear flows, separated flow, decaying turbulence
k-epsilon
- Two-equation model (turbulent kinetic energy and dissipation)
- Uses wall functions
- Good convergence and low memory requirements
- Convenient: Compressible/incompressible, external flow interactions with complex geometry
- Limitations: Not accurate for no-slip walls, adverse pressure gradients, strong curvature into flow, and jet flows
k-omega
- Two-equation model (turbulent kinetic energy and dissipation)
- Omega used as it is easier to solve than epsilon
- Uses wall functions
- Good convergence and low memory requirements
- Convenient: Similar to k-epsilon improved accuracy for internal flows, curvatures, separated flows and jets
- Limitations: Hard to converge and sensitive to initial conditions
k-omega SST
- Two-equation model (turbulent kinetic energy and dissipation)
- Wall functions
- Combination of k-epsilon (in the outer region of and outside of the boundary layer) and k-omega (in the inner boundary layer)
- Convenient: Separated flows and jets
- Limitations: Difficult to converge
Hence we have concluded that we should use SST K omega turbulence model as it gives more accuarte results around the wall .The y+ value should be ideally 2 which gives element length of 0.000054038895761013426 with 15 layers and growth rate of 1.2 as shown below :
Now for the sold fluid volume we have used the following mesh settings :
Element size = 8 mm
For solid Volume surrounding the flow we get :
Element size = 20 mm
The mesh is shown below :
Results :
We can see from the results , accurate temperature ,heat transfer coefficients have been achieved with the y+ and k omega sst turbulence model .
We can predict accurate results from the following :
The number of elements in the mesh:- Finer mesh offers more accurate performance
2. Inflation layers around the boundary:-Inflation layers providing a body-fitting mesh guarantee precise geometry analysis
3.Accurate fitting of mesh around the geometry:-Mesh must be precisely geometrical around the curvatures
4. Setting share topology:-Mesh should be spherically symmetric to smooth mesh transition in various areas