Side Pole Crash Simulation
Objective:
To perform a side pole crash simulation of a car using RADIOSS solver.
Softwares used: Hypermesh, Hypercrash, RADIOSS, Hyperview, Hypergraph 2D
Introduction:
A crash simulation is a virtual recreation of a destructive crash test of a car or a highway guard rail system using a computer simulation in order to examine the level of safety of the car and its occupants. Crash simulations are used by automakers during computer-aided engineering (CAE) analysis for crashworthiness in the computer-aided design (CAD) process of modeling new cars. During a crash simulation, the kinetic energy, or energy of motion, that a vehicle has before the impact is transformed into deformation energy, mostly by plastic deformation (plasticity) of the car body material (Body in White), at the end of the impact.
Data obtained from a crash simulation indicate the capability of the car body or guard rail structure to protect the vehicle occupants during a collision (and also pedestrians hit by a car) against injury. Important results are the deformations (for example, steering wheel intrusions) of the occupant space (driver, passengers) and the decelerations (for example, head acceleration) felt by them, which must fall below threshold values fixed in legal car safety regulations.
Side crashes are the second most common type of accident. They cause the highest number of critical injuries relative to the accident rate. One reason for this is the spatial proximity of the occupant to the deformation zone.
In a side pole crash test, a car is propelled sideways at 32 km/h against a rigid, narrow pole. The car is placed at right angles to the direction of motion, or as is done from 2015 onwards, at a small angle away from the perpendicular.
Case setup:
Because of the student license limitations, it is not possible to perform simulation for a complete car model. Therefore, for this simulation, a reduced model of the Dodge Neon car is used, shown in the image below.
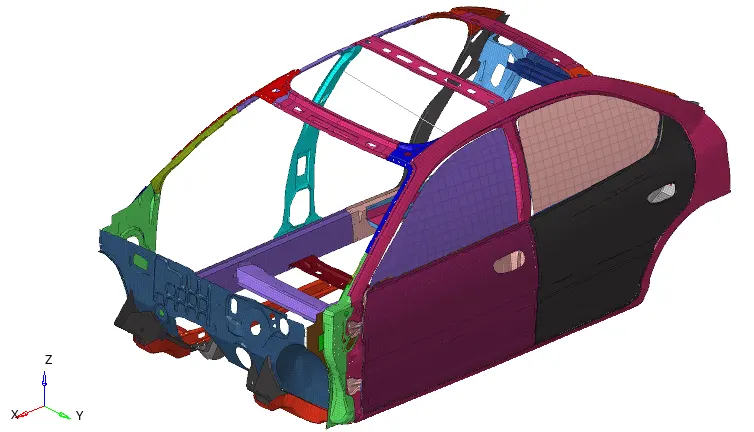
All the connections, materials, and properties are already deployed for this model as per the recommendations for the crash analysis.
The unit system used throughout the system is [kN Kg mm ms].
Interfaces:
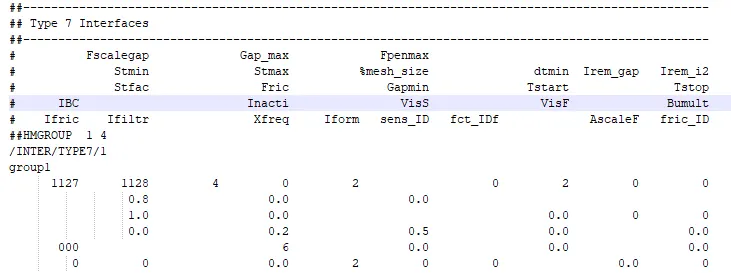
All the previous interfaces are deleted from the model. And, a new TYPE 7 interface is created. All the components are selected as both master and slave components. Recommended parameters used for TYPE 7 contact are as follows,
| Parameter | Comment |
| Istf | = 4, Interface stiffness is the minimum of the master and slave stiffness. |
| Igap | = 2, Variable gap + gap scale correction of the computed gap. |
| Idel | = 2, When an element is deleted, the corresponding segment is removed from the master side of the interface. |
| Fscale_gap | = 0.8, Gap scale factor. |
| Stmin | = 1, Minimum stiffness in the contact to avoid too soft contact. |
| Fric | = 0.2, Coulumb friction. |
| Gapmin | = 0.5, Minimum gap for impact activation. |
| Inacti | = 6, Gap is variable with time, but the initial gap is adjusted (the node is slightly depenetrated). |
| Iform | = 2, Stiffness (incremental) formulation. |
The TYPE 7 contact card created is shown in the image below,
Mass balancing and COG:
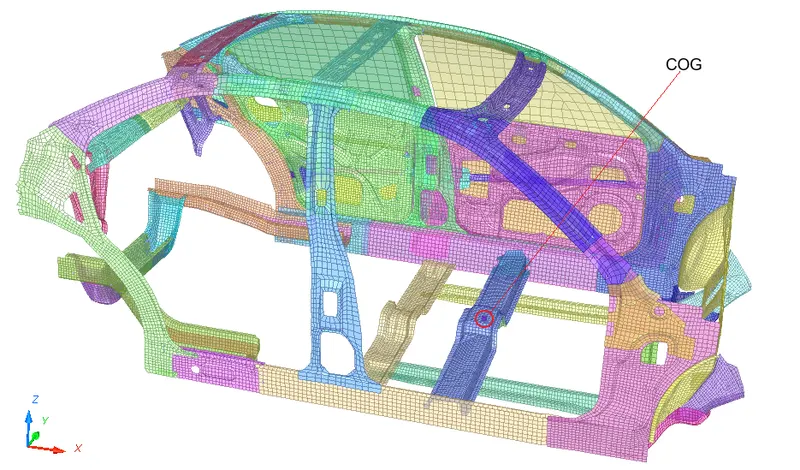
As the given model is a reduced model derived from a full car model, the current COG doesn't lie in its actual position. Also, a lot of other components are removed from the model, therefore the mass is also low. Therefore, to capture the crash behavior properly, we need to match the COG of the car model to its actual position using mass balancing and increase the overall weight of the car model to 700Kg. This is done by adding mass to the nodes of the floor panel using 'ADMAS'.
The new COG is aligned near the driver, as shown in the image below,
Sectional forces:
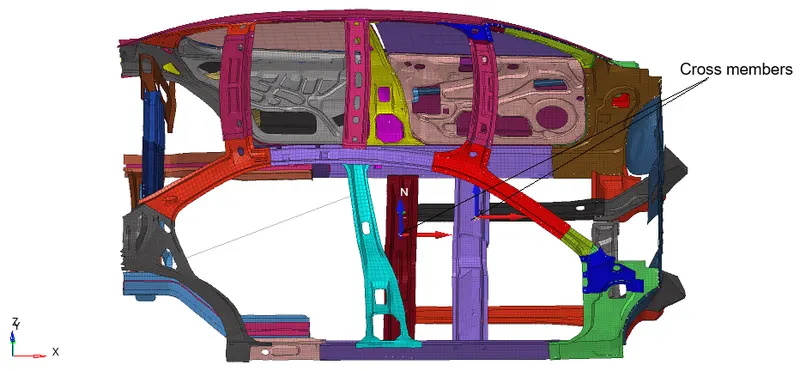
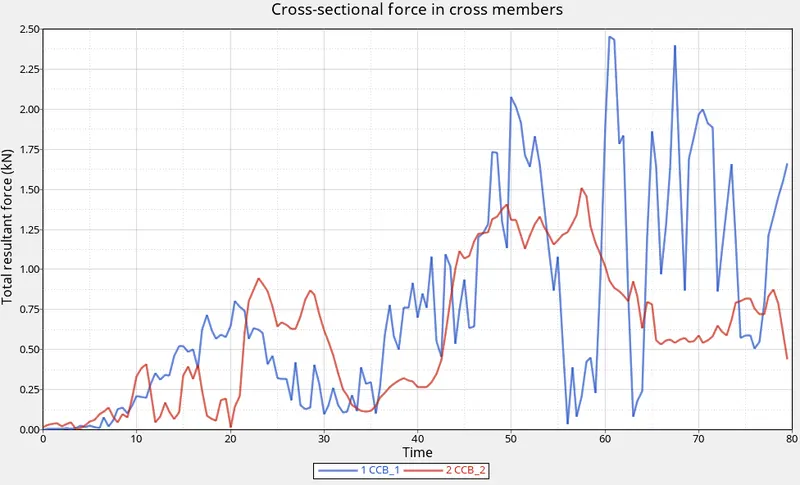
Next, sections are created with local moving frames to measure the forces passing through these sections in the two cross members, as shown in the image below.
Node time history:
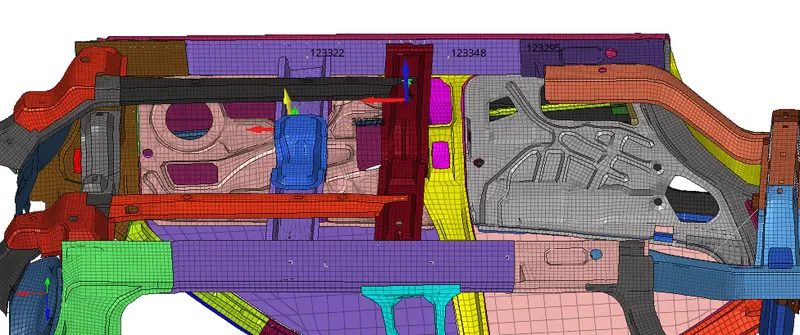
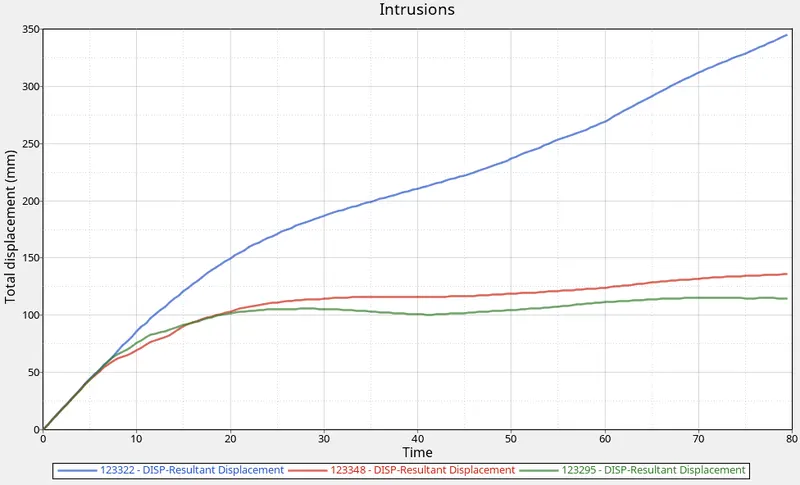
Next, we need to measure the intrusions at the B pillar, hinge pillar, and fuel tank region. For that, three nodes (one from each region) are added to time history with reference to a moving skew system.
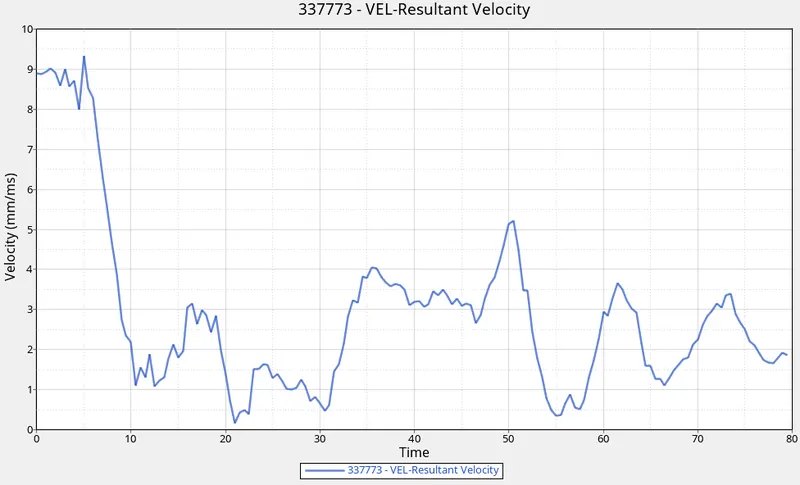
Also, we need are required to measure the peak velocity of the inner node of the door due to impact. Therefore, a node is added to the time history with reference to a moving skew on the car model. Therefore, the following nodes are added to the output block to request their time history,
- Node id: 123322 for intrusion in driver compartment
- Node id: 123348 for B-pillar intrusion
- Node id: 123295 for fuel tank intrusion
- Node id: 337773 for peak velocity of inner node of the door
Boundary condition: INIVEL:
Next, an INIVEL card is configured to give an initial velocity of 32kmph (8.89 mm/ms) in +y direction to the complete car model.
Rigid wall:
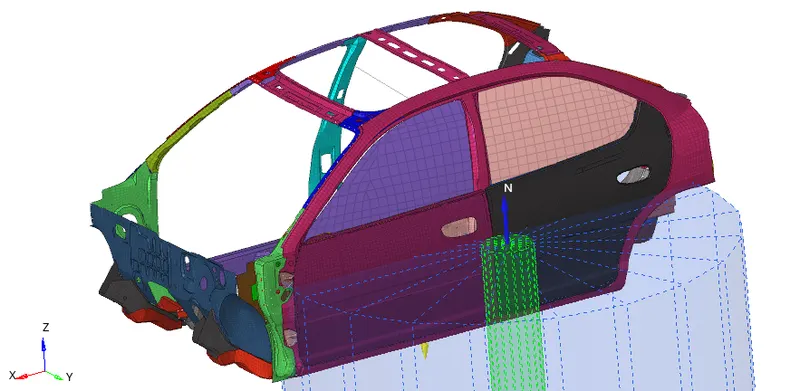
Next, an infinite rigid pole is created beside the B-pillar as shown in the image below. Search distance is set to 1000mm and the friction coefficient is 0.1. The diameter of the pole is 254mm.
Checks:
- Penetration check: Next, the complete model is checked for penetration and intersections using Tools>Penetration Check tool in Hypermesh. All the penetration and intersections need to be removed. There were no penetration and intersections found in this model.
- Connectivity check: The model is checked for connectivity issues in Hypercrash. As this model is derived from a full car model, there is the possibility of components that are not required in this model and are not connected. There were some components that were not connected. Those components were important for the analysis and therefore were connected using rigid body elements.
- Model check: Next, the complete model is checked for any errors in Hypercrash before running the simulation. There were some empty sets and those were removed from the model.
Output request:
The time history is requested for the following:
- Parts
- RWALL (rigid pole)
- Intrusions
- Sections
Time step:
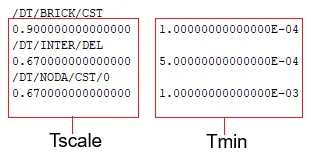
The time step is requested to be 0.5 to 0.1 microseconds. The image below shows the time step parameters configured in the engine file,
Simulation time: 80ms
Results:
- Solving time: 4267.42s (01:11:07)
- Energy error: -1.1%
- Mass error: 0.03
Both energy error and mass error are very low and within acceptable limits. Therefore, the simulation results are acceptable.
Crash Animation:
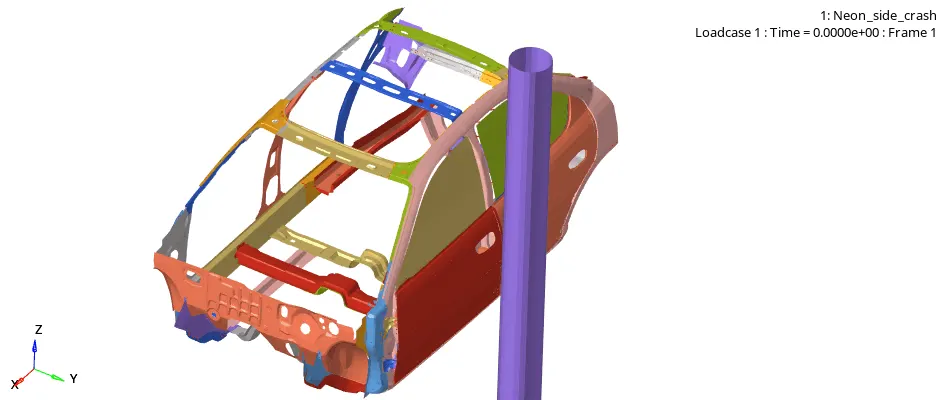
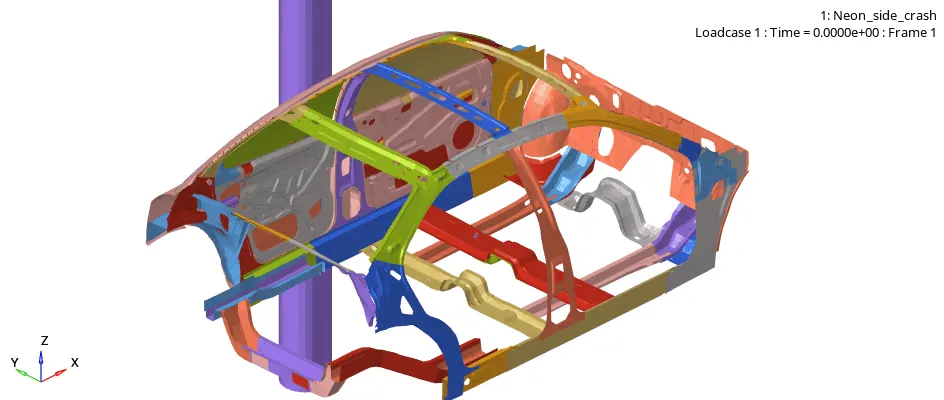
Global energies:
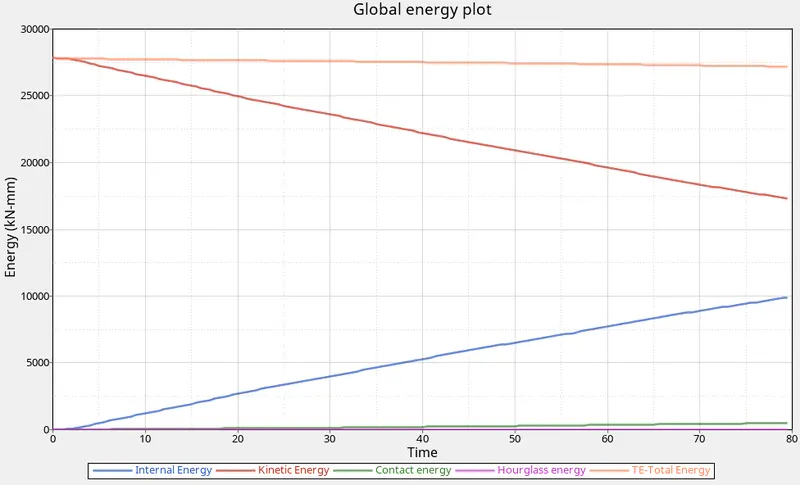
Rigid pole forces:
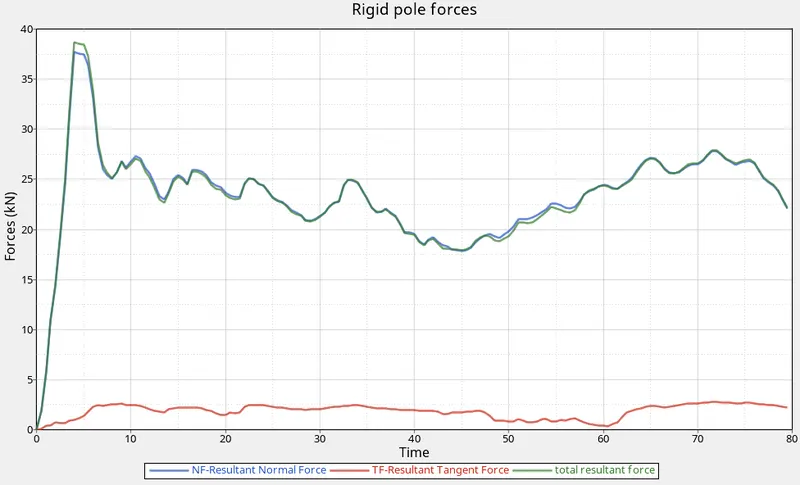
Intrusions:
Peak velocity of inner node of the door:
Sectional forces:
| Variable | Peak Value |
| Global Total energy | 27853 kN-mm @0ms |
| Global Kinetic energy | 27853 kN-mm @0ms |
| Global Internal energy | 9899 kN-mm @79.5ms |
| Global contact energy | 494 kN-mm @79.5ms |
| Global Hourglass energy | 23.5 kN-mm @79.5ms |
| Net Rigid wall forces | 38.65 kN @04ms |
| Intrusion in driver compartment (node: 123322) | 345 mm |
| B-pillar intrusion (node: 123348) | 135.8 mm |
| Fuel tank intrusion (node: 123295) | 114.8 mm |
| Peak velocity of inner node of the door (node: 337773) | 9.3 mm/ms @5ms |
| Sectional force in Cross member 1 | 2.45 kN @60.5ms |
| Sectional force in Cross member 2 | 1.5 kN @57.5ms |
Conclusion:
- Global energy plots showed expected behavior. Most of the kinetic energy is converted to internal energy and the total energy remains almost constant during the simulation. Hourglass energy and contact energy are both very low.
- Intrusions are very high and therefore not safe for the driver.
- Overall, simulation results are not accurate as we are using a reduced car model and can be improved with a complete and detailed car model.
The intrusion in the fuel tank region can be minimized by adding a cross beam member in that region.
This is a very severe test of a car’s ability to protect the driver’s head. As the loading on the car is so localized, deformation is very high and the pole can penetrate deeply into the passenger compartment. Without effective protection, the pole would strike the head resulting in serious injuries. Head protection airbags – often curtain airbags mounted above the side windows but sometimes seat-mounted thorax/head airbags are the common solutions to make the passenger compartment safe.
Note: Because of the big file size, I have attached only .rad, .out and T01 files.