Week-7 Challenge: DC Motor Control
DC Motor Control
Aim:
1. A. Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’.
B. Comment on the armature current shoot-up from the scope results.
C. Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
2. Develop a 2-quadrant chopper using simulink & explain the working of the same with the relevant results. (Refer to article - Multiquadrant operation of motor )
3. Explain in a brief about operation of BLDC motor.
Abstract:
If the semiconductor devices in power converter circuits are arranged appropriately, it can be used to control a variable DC drive. The speed and torque control of a DC motor can be forced by making it operative with the help of an H Bridge circuit in its different mode of operation. Here a Two quadrant chopper circuit is studied for the different modes of operation of a motor. and Brief explain about BLDC motor. This project emphasis on simulation of Speed control of a DC motor using BJT H-bridge and Two-quadrant operation of chopper using MATLAB Simulink.
Objective 1:
A. Explain Speed control of DC motor using BJT H-Bridge
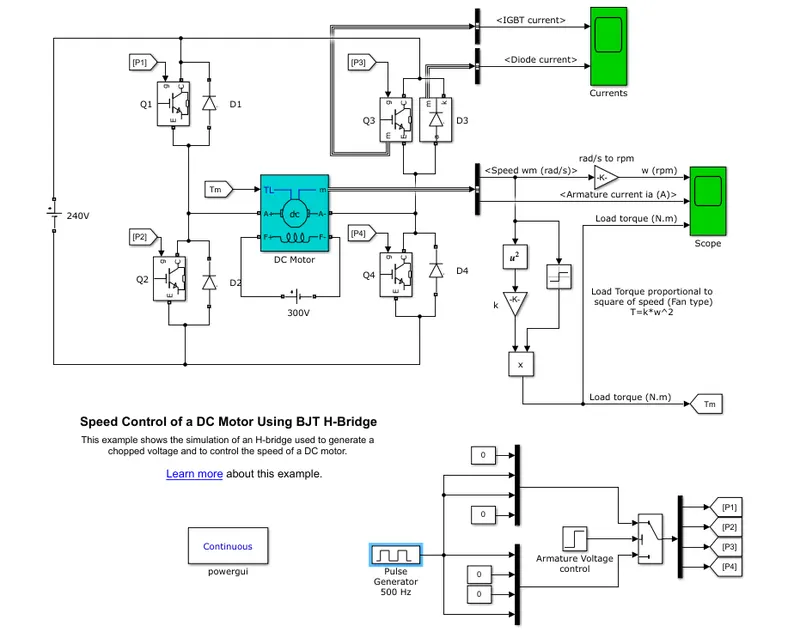
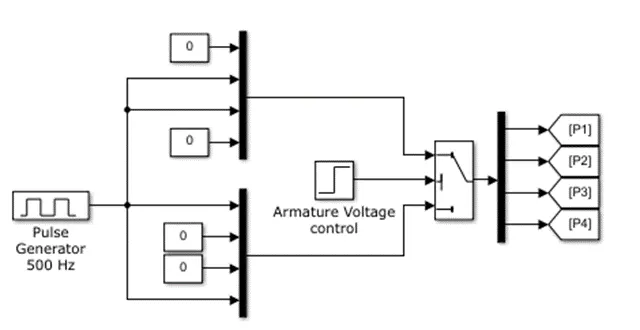
In general H brige is rather is a simple cicuit, Conntaining four switching elements, with load at the centre, in an H-like configuration. Any power switch it has three terminals with Diode in parallel arranged shown above fig with a DC motor connected between the switch pairs. The diodes (D1..D4) are called catch diodes and are usually of a Schottky type. The top-end of the bridge is connected to a power supply of 240V DC Supply and the bottom-end is grounded. Gate used to control Armature voltage with given 500Hz Pulse generator with 75% Duty cycle in each IGBT's. Implements an IGBT device in parallel with a series RC snubber circuit. In on-state the IGBT model has internal resistance (Ron) and inductance (Lon). For most applications, Lon should be set to zero. In off-state the IGBT model has infinite impedance.
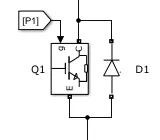
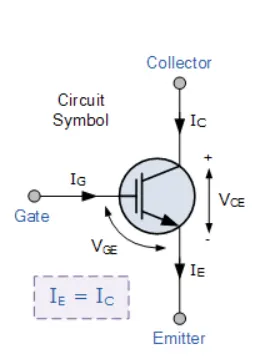
IGBT is a voltage-controlled device, it only requires a small voltage on the Gate to maintain conduction through the device unlike BJT’s which require that the Base current is continuously supplied in a sufficient enough quantity to maintain saturation. Also the IGBT is a unidirectional device, meaning it can only switch current in the “forward direction”, that is from Collector to Emitter unlike MOSFET’s which have bi-directional current switching capabilities (controlled in the forward direction and uncontrolled in the reverse direction).
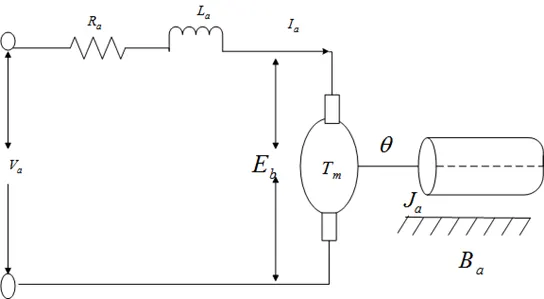
A DC motor is an energy conversion device: it takes electrical energy and turns it into mechanical energy. When operated as a generator, it does the opposite: converts mechanical energy into electrical. On the electrical side, the motor basically contains a number of inductors, that move in a magnetic field. The inductors themselves of course have an inductance, and some internal resistance. Their movement in the field will generate a voltage – called generator voltage and denoted by Vg – across the inductors. Here were using 5HP, 240V, 1750 RPM, field voltage of 300V Model.
 0
DC MOTOR
Static Operation:
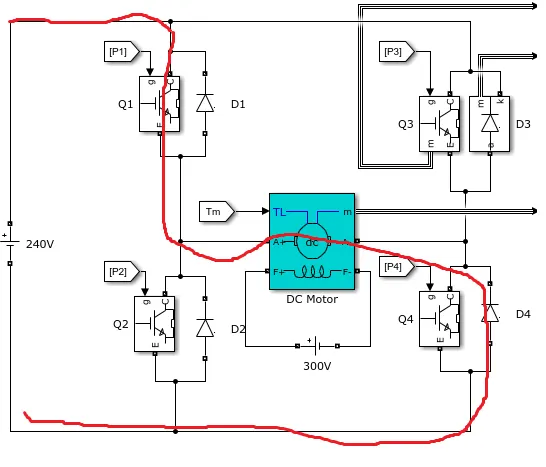
The basic operating mode of an H-bridge is fairly simple: if Q1 and Q4 are turned on, the left lead of the motor will be connected to the power supply, while the right lead is connected to ground. Current starts flowing through the motor which energizes the motor in (let’s say) the forward direction and the motor shaft starts spinning.
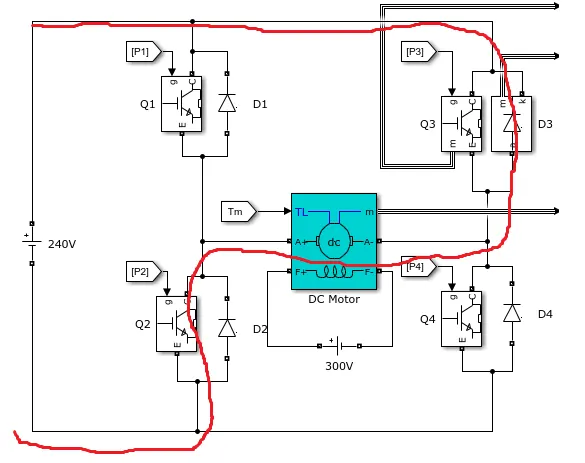
If Q2 and Q3 are turned on, the reverse will happen, the motor gets energized in the reverse direction, and the shaft will start spinning backwards.
Simulation Result.
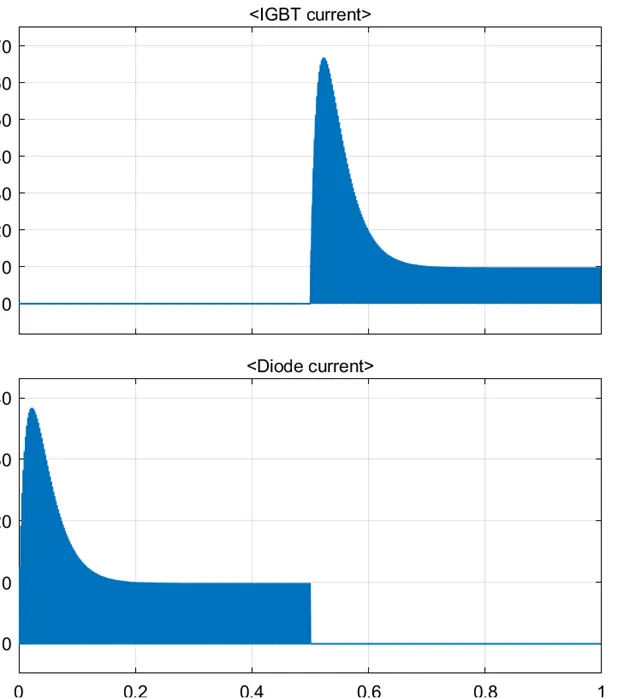
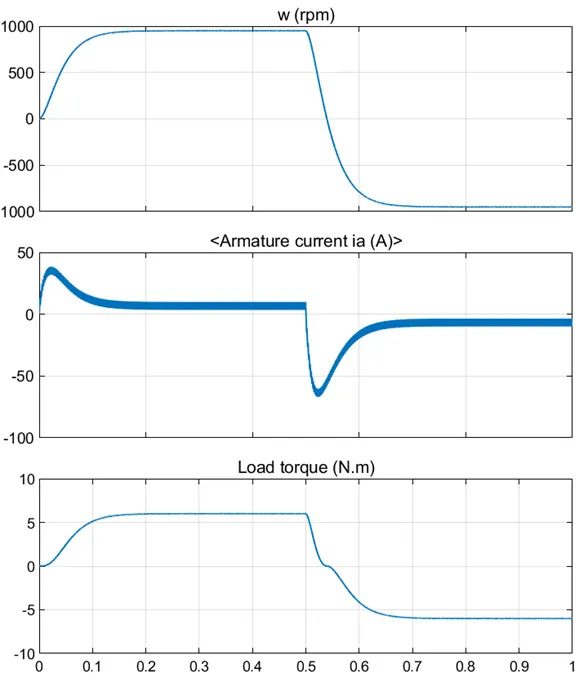
The motor starts in the positive direction with a duty cycle of 75% (mean DC voltage of 180V). At t= 0.5 sec., the armature voltage is suddenly reversed and the motor runs in the negative direction. Scope shows motor speed, armature current and load torque and 'Currents' shows currents flowing in BJT Q3 and diode D3.
B. Comment on the armature current shoot-up from the scope results.
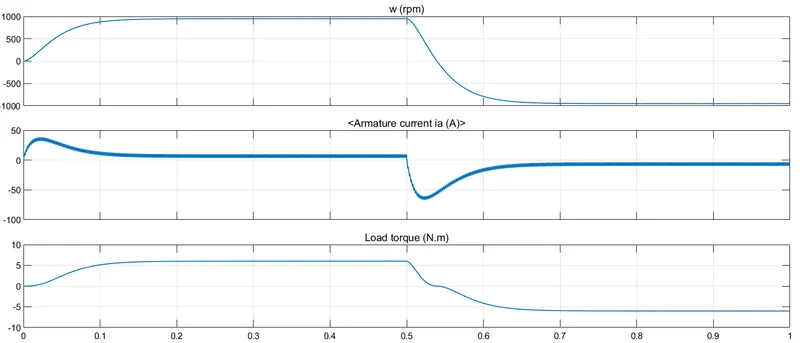
'Scope' shows motor speed, armature current and load torque and 'Currents' shows currents flowing in BJT Q3 and diode D3. Motor draws peak current 40A at starting due to require High starting torque, during running time current drops to 15A, motor draws less current during running. At time 0.5 Armature current decreased from 15A to -30A due to regenerative braking, Here Motor act as Generator which supplies power back to battery up to when motor rpm comes to 0. During second half cycle motor runs with reverse direction which draws negative peak current during starting and negative current while running
C. Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
The Four-Quadrant Chopper DC Drive (DC7)
The Four-Quadrant Chopper DC Drive (DC7) block represents a four-quadrant, DC-supplied, chopper (or DC-DC PWM converter) drive for DC motors. This drive features closed-loop speed control with four-quadrant operation. The speed control loop outputs the reference armature current of the machine. Using a PI current controller, the chopper duty cycle corresponding to the commanded armature current is derived. This duty cycle is then compared with a sawtooth carrier signal to obtain the required PWM signals for the chopper.
The main advantage of this drive, compared with other DC drives, is that it can operate in all four quadrants (forward motoring, reverse regeneration, reverse motoring, and forward regeneration). In addition, due to the use of high switching frequency DC-DC converters, a lower armature current ripple (compared with thyristor-based DC drives) is obtained. However, four switching devices are required, which increases the complexity of the drive system.
The Four-Quadrant Chopper DC Drive block uses these blocks from the Electric Drives/Fundamental Drive Blocks library:
-
Speed Controller (DC)
-
Regulation Switch
-
Current Controller (DC)
-
Chopper
The 200 HP DC motor is separately excited with a constant 150 V DC field voltage source. The armature voltage is provided by an IGBT converter controlled by two PI regulators. The converter is fed by a 515 V DC bus obtained by rectification of a 380 V AC 50 Hz voltage source. In order to limit the DC bus voltage during dynamic braking mode, a braking chopper has been added between the diode rectifier and the DC7 block.
The first regulator is a speed regulator, followed by a current regulator. The speed regulator outputs the armature current reference (in p.u.) used by the current controller in order to obtain the electromagnetic torque needed to reach the desired speed. The speed reference change rate follows acceleration and deceleration ramps in order to avoid sudden reference changes that could cause armature over-current and destabilize the system. The current regulator controls the armature current by computing the appropriate duty ratios of the 5 kHz pulses of the four IGBT devices (Pulse Width Modulation). For proper system behaviour, the instantaneous pulse values of IGBT devices 1 and 4 are opposite to those of IGBT devices 2 and 3. This generates the average armature voltage needed to obtain the desired armature current. In order to limit the amplitude of the current oscillations, a smoothing inductance is placed in series with the armature circuit.
| H Bridge | Four quadrant Chopper Dc Drive |
| Operate only Two quadrants of operation are possible | It can operate on all four quadrants |
| Forward monitoring and Reverse monitoring | Forward Monitoring, Reverse regeneration, Reverese monitoring and Forward regeneration |
| Highier Armature current ripple due to Lower switching frequency of DC-DC Converters | Lower Armature current ripple due to High switching frequency of DC-DC converters |
| Less complex | More Complex |
| Simulation is continuous and simuoation time is more | Descrete and simulation time is less |
| Widely used in robotics | Used in Automobiles, Home appliances |
Objective 2:
Simulation of all four-quadrant operation of chopper using MATLAB Simulink.
Abstract:
If the semiconductor devices in power converter circuits are arranged appropriately, it can be used to control a variable DC drive. The speed and torque control of a DC motor can be forced by making it operative with the help of an H Bridge circuit in its different mode of operation. Here a chopper circuit is studied for the different modes of operation of a motor. We can classify chopper circuits according to their working in any of these four quadrants as type A, type B, type C, type D and type E. This project emphasis on simulation of all four-quadrant operation of chopper using MATLAB Simulink.
To begin with, a chopper-based DC motor drive model is developed in Simulink and the multi quadrant operation is explained
Introduction
The DC motor is used in many industrial applications requiring variable speed and load characteristics due to its ease of control. A chopper drive-based speed control is widely preferred as far as speed control is concerned. Choppers are mostly applied in electric cars, conversion of wind and solar energy, and DC motor regulators. A chopper uses the high speed to connect and disconnect from a source load. A fixed DC voltage is applied intermittently to the source load by continuously triggering the power switch ON/OFF. The period for which the power switch stays ON or OFF is referred to as the chopper’s ON and OFF state times, respectively.
The four-quadrant chopper is a chopper which can operate in all the four quadrants. The power can flow either from source to load or load to source in this chopper. In the first quadrant, a Class-E chopper acts as a Step-down chopper whereas in the second quadrant it behaves as a Step-up chopper. This type of chopper is also known as a Class-E or Type-E chopper. This article describes the working principle and operation of a Class-E chopper with the help of a circuit diagram.
What is a chopper?
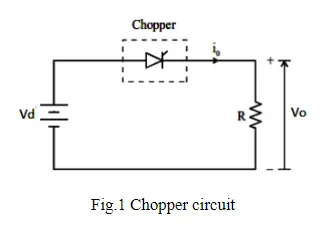
A dc‐to‐dc converter, also known as dc chopper, is a static device which is used to obtain a variable dc voltage from a constant dc voltage source. Choppers are widely used in trolley cars, battery-operated vehicles, traction motor control, control of large numbers of dc motors, etc. They are also used as dc voltage regulators. Choppers are of two types: (1) Step‐down choppers, and (2) Step‐up choppers. In step‐down choppers, the output voltage will be less than the input voltage, whereas in step‐up choppers output voltage will be more than the input voltage
Chopper-Fed DC Motor Drive
D.C motor is considered a SISO (Single Input and Single Output) system having torque/speed characteristics compatible with most mechanical loads. This makes a DC motor controllable over a wide range of speeds by proper adjustment of the terminal voltage
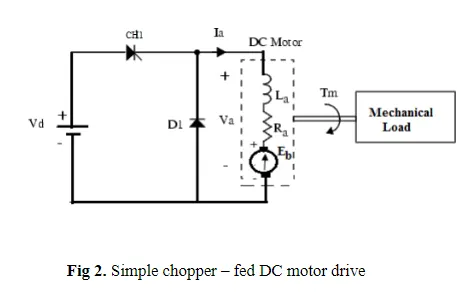
A simple chopper – fed DC motor drive is shown in Fig.2. The basic principle behind DC motor speed control is that the output speed of a DC motor can be varied by controlling armature voltage for speed below and up to rated speed keeping field voltage constant. The armature voltage can be controlled by controlling the duty cycle of the converter (here the converter used is a DC chopper)
Two Quadrant Chopper
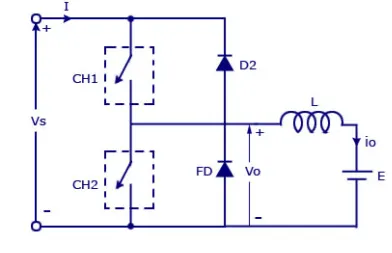
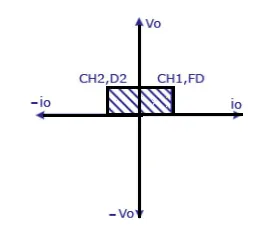
In this type of Chopper, the average voltage will be always positive but the average load current might be positive or negative. The two Switches CH1 and CH2 should not be turned on simultaneously as the combined action may cause a short circuit in supply lines. For regenerative braking and motoring these type of chopper configuration is used.
We will always get a positive output voltage V0 as the freewheeling diode FD is present across the load. When the chopper CH1 is on the current flows from source to load. The inductor stores energy. When Ch1 turn OFF the freewheeling diode starts conducting and the output voltage v0 will be equal to Vs. The direction of the load current i0 will be reversed. The current i0 will be flowing towards the source. The load current will be negative when the CH2 is on. The current completes its path through diode D2.
Two Quadrant operation of Dc motor explained with Matlab model
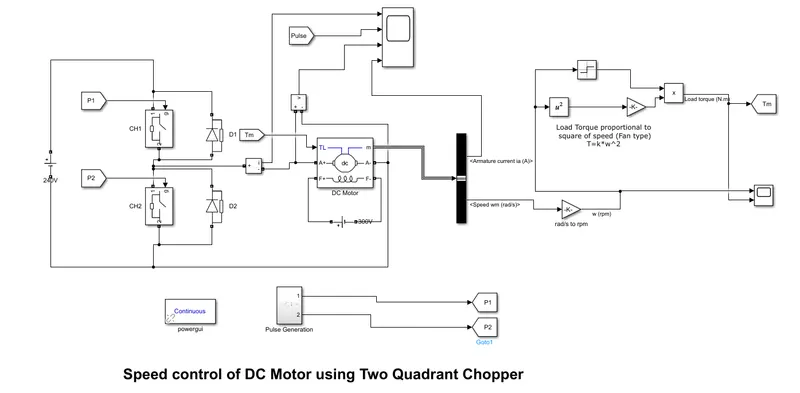
The Two-quadrant chopper model was developed in Simulink with ideal switches and diodes. A DC machine was connected as the load. The torque of the motor was measured as in closed-loop control. The pulse generation subsystem has the pulse generator giving switching pulses to the four switching elements as in order. The armature voltage provided is 240V and the field voltage is given to be 300VDC as per the Standard specification of the present model (5HP 240V,1750RPM 300V) The switches are triggered with 60 %duty cycles. At the output side, the speed output in rad/s is converted to its equivalent speed in RPM. Closed-loop control of torque of the motor is implemented.
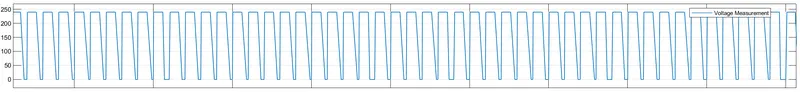
Load Voltage during operation
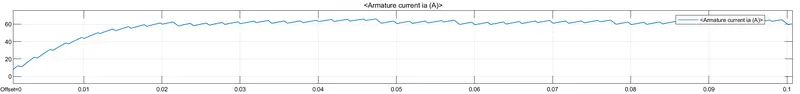
Armature Current during Operation
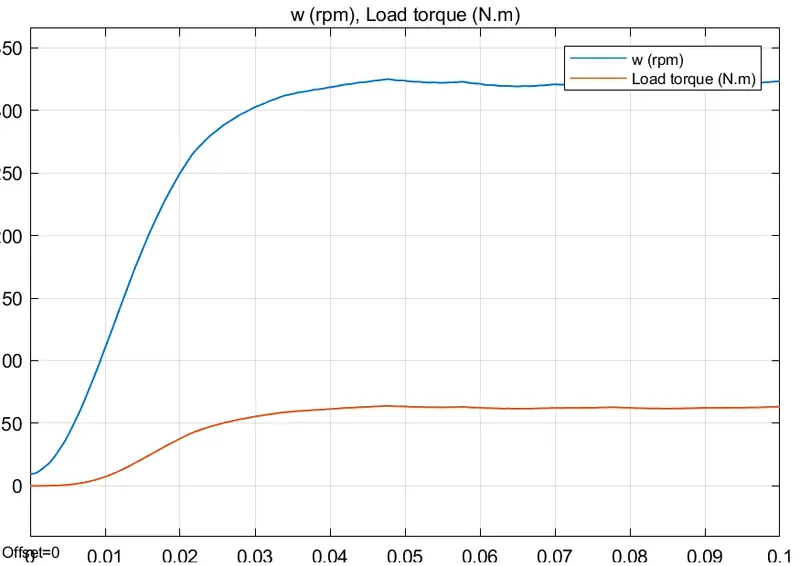
Speed Torque Charactaristics of the motor
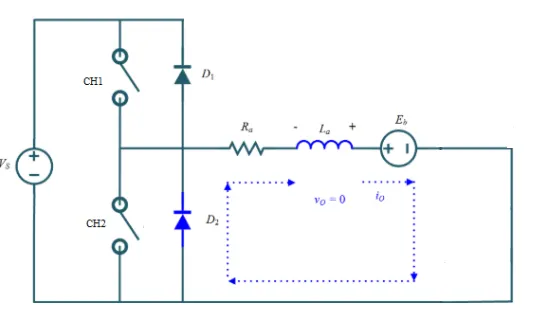
First Quadrant Operation:
For first quadrant operation, CH1 is kept ON and CH1 is operated. The load gets directly connected to the source and hence the output voltage becomes equal to the source voltage. This essentially means that vo = vs. It may be noted that the load current flows from source to load as shown by the direction of io.
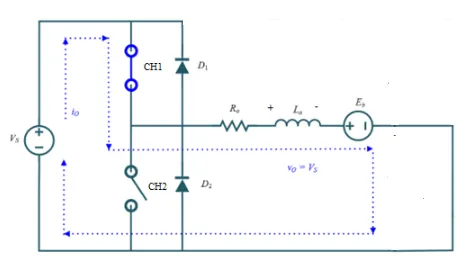
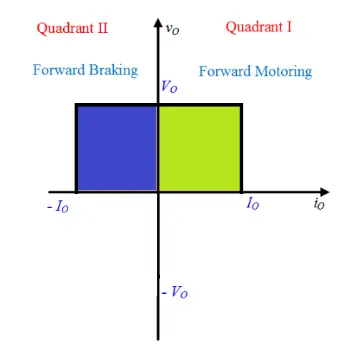
When CH1 is switched OFF, the load current freewheels through motor and D2. During this period, the load voltage and current remain positive. Thus, both the output voltage vs and load current io are positive and hence, the operation of the chopper is in the first quadrant.
Second Quadrant Operation:
To obtain second quadrant operation, CH2 is operated while keeping the CH1 OFF. When CH2 is ON, the DC source in the load drives current through CH2, E and L. Inductor L stores energy during the on period of CH2.
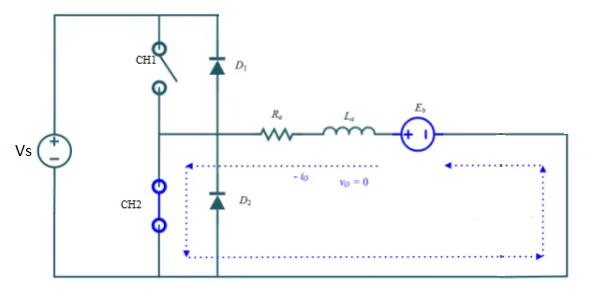
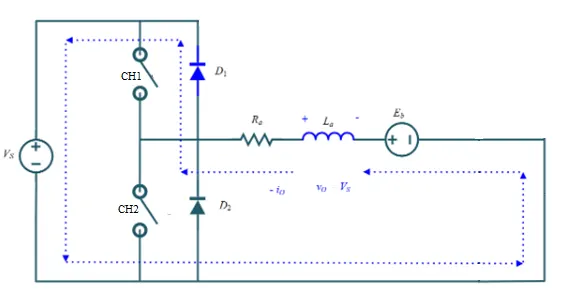
When CH2 is turned OFF, the current is fed back to the source through D1. It should be noted at this point that (E+Ldi/dt) is more than the source voltage Vs. As load voltage Vo is positive and Io is negative, it is the second quadrant operation of the chopper. Since the current is fed back to the source, this simply means that load is transferring power to the source.
Conclusion
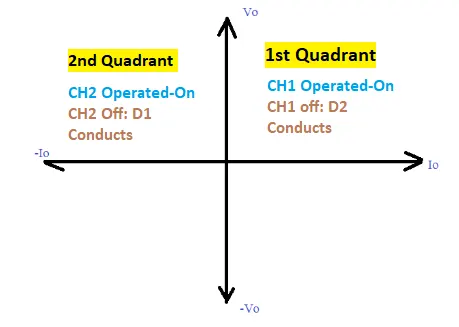
The operation of a Two-quadrant chopper is summarized in the figure below
Objective 3:
BLDC Motor
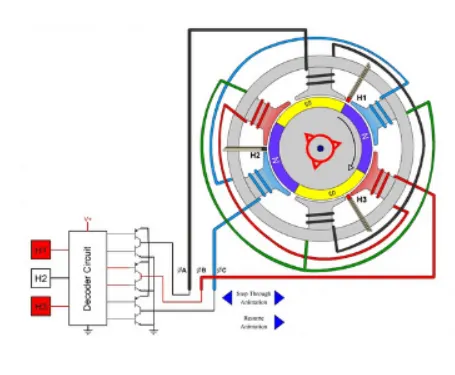
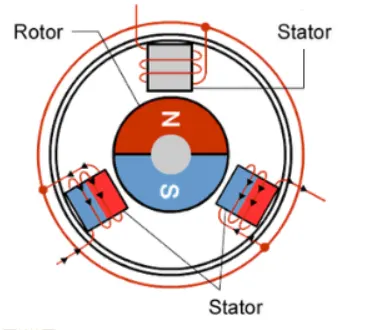
A brushless DC motor (also known as a BLDC motor or BL motor) is an electronically commuted DC Motor which does not have brushes. The controller provides pulses of Current to the motor windings which Control the speed and torque of the synchronous motor.
These types of motors are highly efficient in producing a large amount of torque over a vast speed range. In brushless motors, permanent magnets rotate around a fixed armature and overcome the problem of connecting current to the armature. Commutation with electronics has a large scope of capabilities and flexibility. They are known for smooth operation and holding torque when stationary.
Working of BLDC motor
Before explaining the working of a brushless DC motor, it is better to understand the function of a brushed motor. In brushes motors, there are permanent magnets on the outside and a spinning armature which contains electromagnet is inside. These electromagnets create a magnetic field in the armature when the power is switched on and help to rotate the armature.
The brushes change the polarity of the pole to keep the rotation on of the armature. The basic working principle for the brushed DC motor and for brushless DC motor are same i.e. internal shaft position feedback.
Brushless DC motor has only two basic parts: rotor and the stator. The rotor is the rotating part and has rotor magnets whereas stator is the stationary part and contains stator windings. In BLDC permanent magnets are attached in the rotor and move the electromagnets to the stator. The high power transistors are used to activate electromagnets for the shaft turns. The controller performs power distribution by using a solid-state circuit.
Types of BLDC motors
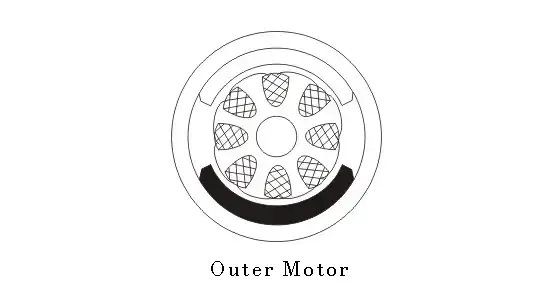
Basically, BLDC are of two types, one is outer rotor motor and other is inner rotor motor. The basic difference between the two is only in designing, their working principles are same.
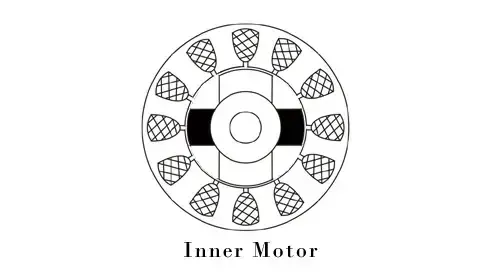
In an inner rotor design, the rotor is located in the centre of the motor and the stator winding surround the rotor. As the rotor is located in the core, rotor magnets do not insulate heat inside and heat get dissipated easily. Due to this reason, inner rotor designed motor produces a large amount of torque and validly used.
Outer Rotor Design
In outer rotor design, the rotor surrounds the winding which is located in the core of the motor. The magnets in the rotor trap the heat of the motor inside and do not allow to dissipate from the motor. Such type of designed motor operates at lower rated current and has low cogging torque.
Advantages of Brushless DC Motor
The advantages of a BLDC motor are:
- Brushless motors are more efficient as its velocity is determined by the frequency at which current is supplied, not the voltage.
- As brushes are absent, the mechanical energy loss due to friction is less which enhanced efficiency.
- BLDC motor can operate at high-speed under any condition.
- There is no sparking and much less noise during operation.
- More electromagnets could be used on the stator for more precise control.
- BLDC motors accelerate and decelerate easily as they are having low rotor inertia.
- It is high performance motor that provides large torque per cubic inch over a vast sped rang.
- BLDC motors do not have brushes which make it more reliable, high life expectancies, and maintenance free operation.
- There is no ionizing sparks from the commutator, and electromagnetic interference is also get reduced.
- Such motors cooled by conduction and no air flow are required for inside cooling.
Disadvantages of Brushless DC Motors
The disadvantages of a BLDC motor are:
- BLDC motor cost more than a brushed DC motor.
- The limited high power could be supplied to BLDC motor, otherwise, too much heat weakens the magnets and the insulation of winding may get damaged.