Week-7 Challenge: DC Motor Control
AIM:
DC MOTOR CONTROLLER
Objective:
1. Run MATLAB demo ‘Speed control of a DC motor using BJT H-bridge’. Modify the model such that armature current doesn’t shoot up when motor changes
direction from forward to reverse.
2. Refer to help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with H-bridge model.
3. Make a suitable EV model using DC7 block and make result report.
4. Explain in a brief about operation of BLDC motor.
Introduction:
IGBT(Insulated Gate Bipolar Transistor): IGBT is the short form of Insulated Gate Bipolar Transistor. It is a three-terminal semiconductor switching device
that can be used for fast switching with high efficiency in many types of electronic devices. These devices are mostly used in amplifiers for switching/processing
complex wave patters with pulse width modulation (PWM).
As mentioned earlier an IGBT is a fusion between a BJT and MOSFET. The symbol of the IGBT also represents the same, as you can see the input side represents
a MOSFET with a Gate terminal and the output side represents a BJT with Collector and Emitter. The Collector and the Emitter are the conduction terminals and
the gate is the control terminal with which the switching operation is controlled.
Internal structure of IGBT:
IGBT can be constructed with the equivalent circuit that consists of two transistors and MOSFET, as the IGBT posses the output of the below combination of the PNP transistor,
NPN transistor, and MOSFET. IGBT combines the low saturation voltage of a transistor with the high input impedance and switching speed of a MOSFET.
The outcome obtained from this combination delivers the output switching and conduction characteristics of a bipolar transistor, but the voltage is controlled like a MOSFET.
Since IGBT is the combination of MOSFET and BJT they are also called by different names. The different names of IGBT are Insulated Gate Transistor( IGT),
Metal Oxide Insulated Gate Transistor (MOSIGT), Gain Modulated Field Effect Transistor (GEMFET), Conductively Modulated Field Effect Transistor (COMFET).
BJT(BIPOLAR JUNCTION TRANSITIOR):A bipolar junction transistor is a three-terminal semiconductor device that consists of two p-n junctions which are able to
amplify or magnify a signal. It is a current controlled device. The three terminals of the BJT are the base, the collector, and the emitter. A signal of a small amplitude
applied to the base is available in the amplified form at the collector of the transistor. This is the amplification provided by the BJT. Note that it does require
an external source of DC power supply to carry out the amplification process.
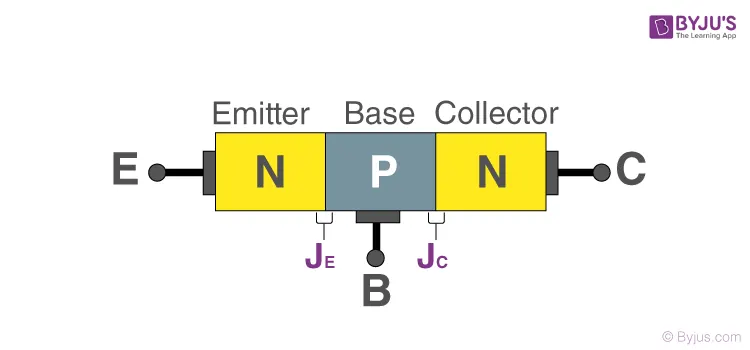
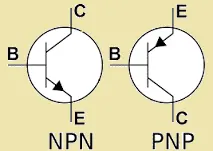
Function of BJT: BJTs are of two types namely NPN and PNP based on doping types of the three main terminals. An NPN transistor consists of two semiconductor
junctions that have a thin p-doped anode region and PNP transistor also consists of two semiconductor junctions that have a thin n- doped cathode region.
MAIN THEORY:
1. Run MATLAB demo ‘Speed control of a DC motor using BJT H-bridge’. Modify the model such that armature current doesn’t shoot up when motor changes direction
from forward to reverse.
An H-bridge is a simple circuit that lets you control a DC motor to go backward or forward. You normally use it with a microcontroller, such as an Arduino, to control motors.
When you can control two motors to go either forward or backward.
Description:
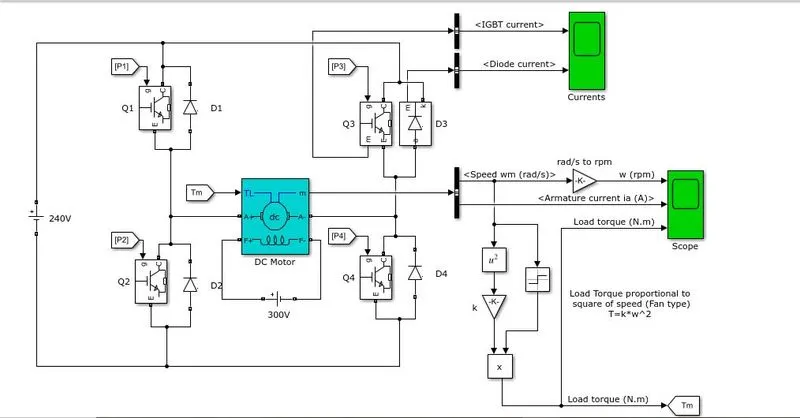
The Bipolar Junction Transistor (BJT) when used for power switching applications, operates as an IGBT. When it is conducting (BJT operating in the saturated region),
a forward voltage Vf is developed between collector and emitter (in the range of 1 V). Therefore, the IGBT block can be used to model the BJT device.
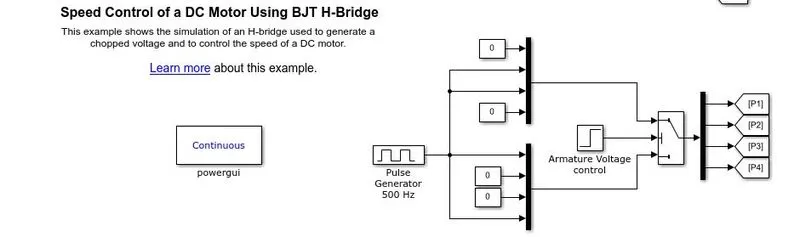
The IGBT block does not simulate the gate current controlling BJT or IGBT. The switch is controlled by a Simulink signal (1/0). The DC motor uses the preset model
(5 HP 24V 1750 rpm). It simulates a fan type load (where Load torque is proportional to square of speed). The armature mean voltage can be varied from 0 to 240 V
when the duty cycle (specified in the Pulse Generator block) is varied from 0 to 100%.
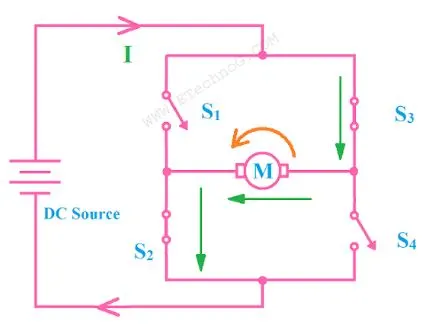
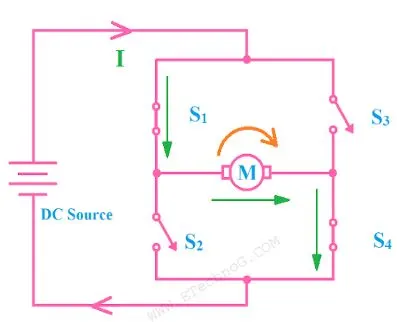
The H-bridge consists of four BJT/Diode pairs (BJT simulated by IGBT models). Two transistors are switched simultaneously: Q1 and Q4 or Q2 and Q3.
When Q1 and Q4 are fired, a positive voltage is applied to the motor and diodes D2-D3 operate as free-wheeling diodes when Q1 and Q4 are switched off.
When Q2 and Q3 are fired, a negative voltage is applied to the motor and diodes D1-D4 operate as free-wheeling diodes when Q2 and Q3 are switched off.
SIMULATION:
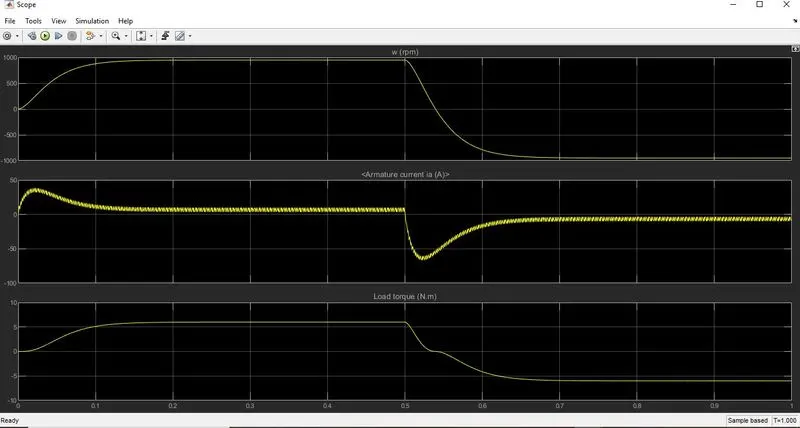
The motor starts in the positive direction with a duty cycle of 75% (mean DC voltage of 180V). At t= 0.5 sec.,the armature voltage is suddenly reversed
and the motor runs in the negative direction.
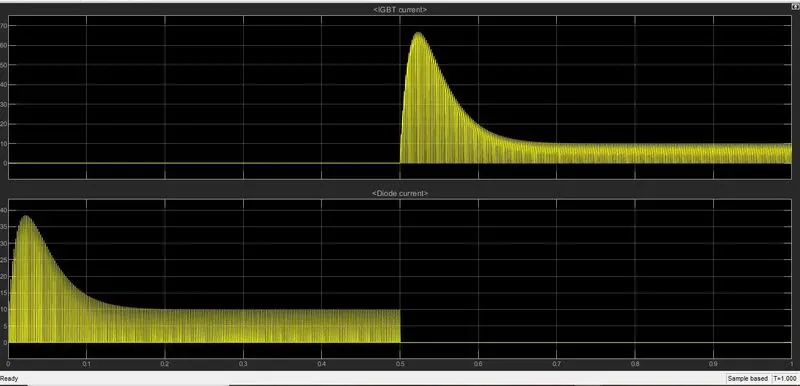
'Scope' shows motor speed, armature current and load torque and 'Currents' shows currents flowing in BJT Q3 and diode D3.
The block has two values as a display of the output. One is the current output for the IGBTand the diode current and the other is the scope for the values
of the DC motor. The values of the DC motor include-
1. Speed (in RPM)
2. Armature Current (in AMPS)
3. Load Torque (in N-m)
The output values are as follows:-
1. IGBT Current
2. Diode Current
The values of the SCOPE:
2. Refer to help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with H-bridge model.
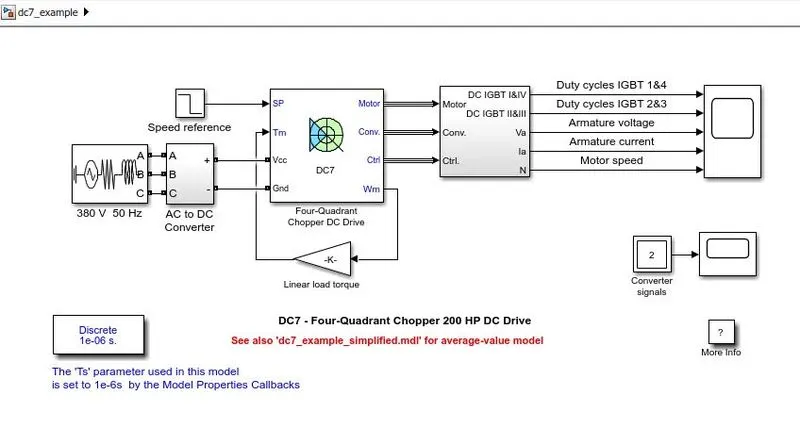
Description:
The 200 HP DC motor is separately excited with a constant 150 V DC field voltage source. The armature voltage is provided by an IGBT converter controlled
by two PI regulators. The converter is fed by a 515 V DC bus obtained by rectification of a 380 V AC 50 Hz voltage source. In order to limit the DC bus voltage during
dynamic braking mode, a braking chopper has been added between the diode rectifier and the DC7 block.
The first regulator is a speed regulator, followed by a current regulator. The speed regulator outputs the armature current reference (in p.u.) used by the current controller
in order to obtain the electromagnetic torque needed to reach the desired speed. The speed reference change rate follows acceleration and deceleration ramps in order to
avoid sudden reference changes that could cause armature over-current and destabilize the system. The current regulator controls the armature current by computing the
appropriate duty ratios of the 5 kHz pulses of the four IGBT devices (Pulse Width Modulation). For proper system behaviour, the instantaneous pulse values of IGBT devices
1 and 4 are opposite to those of IGBT devices 2 and 3. This generates the average armature voltage needed to obtain the desired armature current. In order to limit the
amplitude of the current oscillations, a smoothing inductance is placed in series with the armature circuit.
Simulation:
Before starting the simulation, set the initial bus voltage to 515 V via the GUI block ('Initial States Setting' button and 'Cbus' variable).
Start the simulation. You can observe the motor armature voltage and current, the four IGBT pulses and the motor speed on the scope. The current and speed references are also shown.
The motor is coupled to a linear load, which means that the mechanical torque of the load is proportional to the speed.
The speed reference is set at 500 rpm at t = 0 s. Observe that the motor speed follows the reference ramp accurately (+400 rpm/s) and reaches steady state around t = 1.3 s.
The armature current follows the current reference very well, with fast response time and small ripples. Notice that the current ripple frequency is 5 kHz.
At t = 2 s, speed reference drops to -1184 rpm. The current reference decreases to reduce the electromagnetic torque and causes the motor to decelerate with the help of the
load torque.
At t = 2.2 s, the current reverses in order to produce a braking electromagnetic torque (dynamic braking mode). This causes the DC bus voltage to increase.
At t = 3.25 s, the motor reaches 0 rpm and the load torque reverses and becomes negative. The negative current now produces an accelerating electromagnetic torque to
allow the motor to follow the negative speed ramp (-400 rpm/s). At t = 6.3 s, the speed reaches -1184 rpm and stabilizes around its reference.
OUTPUT SCOPE:
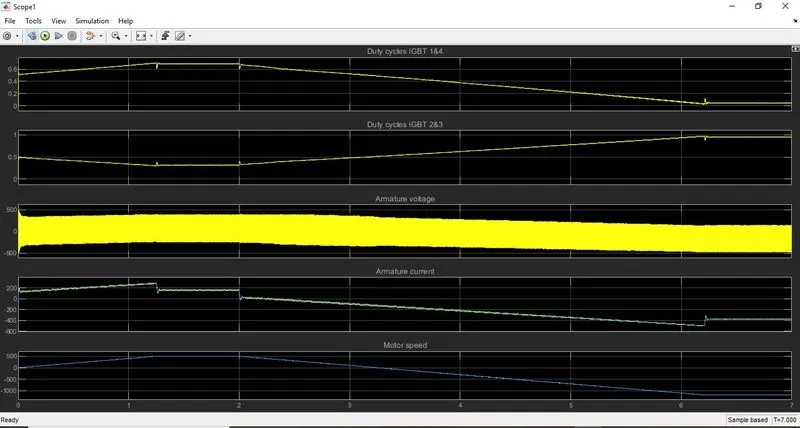
The main advantage of this drive, compared with other DC drives, is that it can operate in all four quadrants (forward motoring, reverse regeneration,
reverse motoring, and forward regeneration). In addition, due to the use of high switching frequency DC-DC converters, a lower armature current ripple (compared with
thyristor-based DC drives) is obtained. However, four switching devices are required, which increases the complexity of the drive system.
3. Make a suitable EV model using DC7 block and make result report.
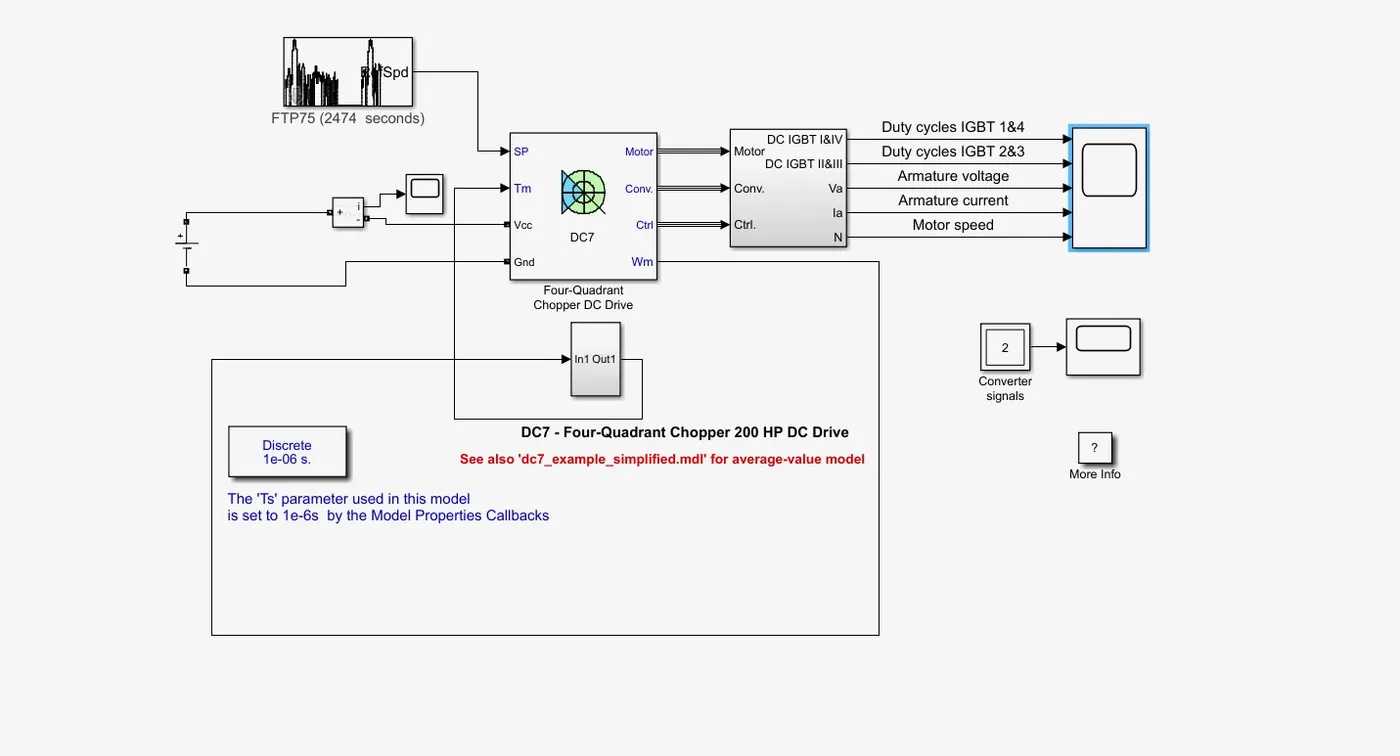
The DC7 Block is modified with addition of blocks to make a suitable EV model
The Speed reference is replaced with the drive cycle.
Ac Source is replaced by the DC voltage source and a current sensor ias added in series to measure the flow of current and to view that measure of the current a scope is connected.
Linear Torque characteristic block is removed and a new subsystem is created by using the torque equation .
The input of the subsystem is the output speed of the dc chopper block, the output of the subsystem block is given to the Torque input port of the dc chopper block.
The resultant graphs obtained are as follows:
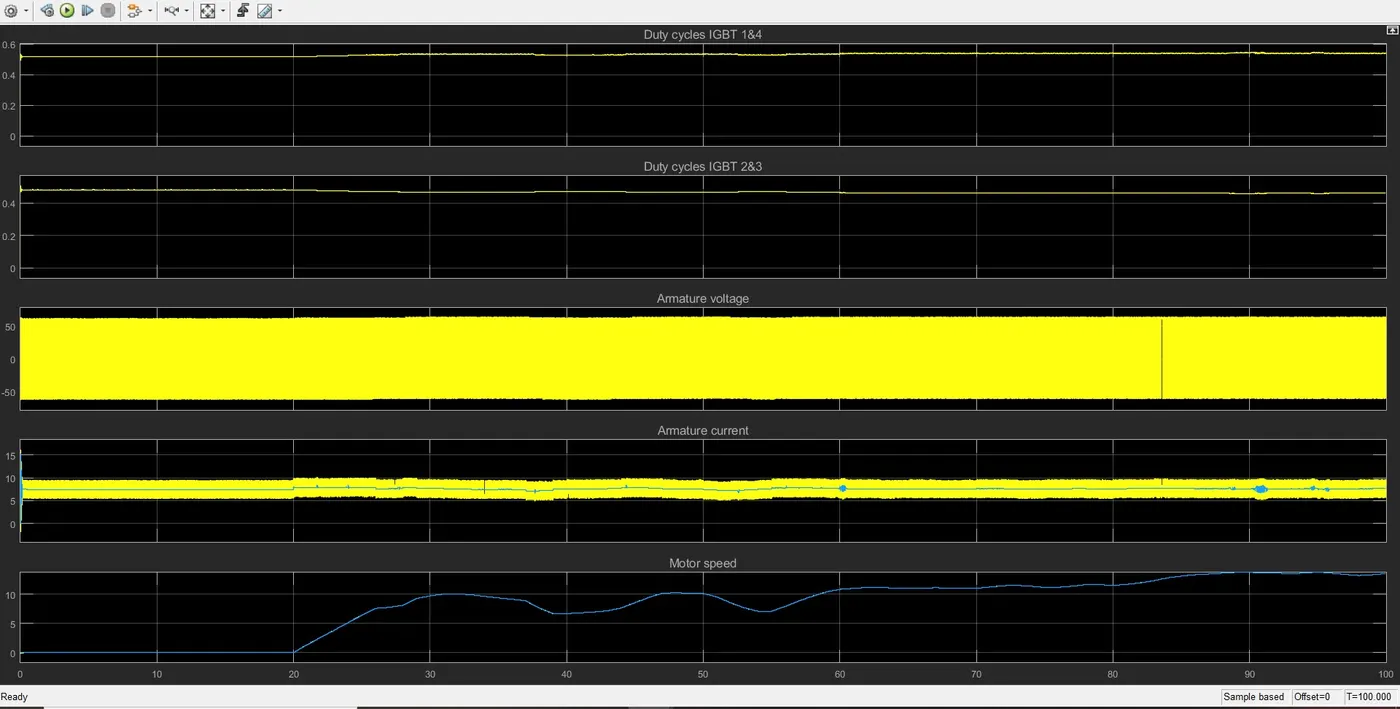
The duty cycles of the IGBT’s are kept constant through out as 50% for a better armature current flow.
The armature voltage flow through is smoother and its pulse is around +50 to -50.
Without the torque characteristic equation the armature voltage goes from 0 to 500 to -500. As there will be linear load torque. When the equation is provided the
voltage supplied will be as per the torque demanded hence the smoother graph and as observed the losses are also less.
Here we have used FTP75 drivecycle whose first 20seconds are at rest and the acceleration starts after 20 seconds as we can observe that the motor speed increases
and the armature current also rises slightly to meet the demanded acceleration.
4. Explain in a brief about operation of BLDC motor.
A brushless DC motor (known as BLDC) is a permanent magnet synchronous electric motor which is driven by direct current (DC) electricity and
it accomplishes electronically controlled commutation system (commutation is the process of producing rotational torque in the motor by changing phase currents through
it at appropriate times) instead of a mechanically commutation system. BLDC motors are also referred as trapezoidal permanent magnet motors.
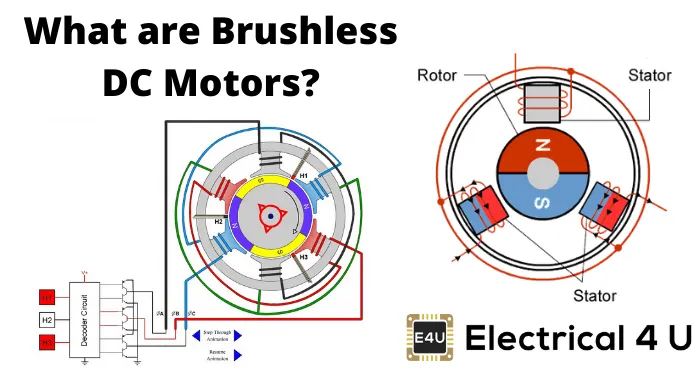
Unlike conventional brushed type DC motor, wherein the brushes make the mechanical contact with commutator on the rotor so as to form an electric path
between a DC electric source and rotor armature windings, BLDC motor employs electrical commutation with permanent magnet rotor and a stator with a sequence of coils.
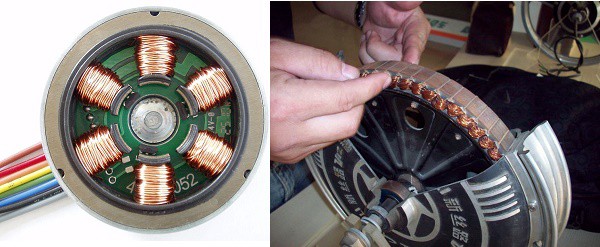
In this motor, permanent magnet (or field poles) rotates and current carrying conductors are fixed
.
The armature coils are switched electronically by transistors or silicon controlled rectifiers at the correct rotor position in such a way that armature field
is in space quadrature with the rotor field poles. Hence the force acting on the rotor causes it to rotate. Hall sensors or rotary encoders are most commonly used
to sense the position of the rotor and are positioned around the stator. The rotor position feedback from the sensor helps to determine when to switch the armature current.
This electronic commutation arrangement eliminates the commutator arrangement and brushes in a DC motor and hence more reliable and less noisy operation
is achieved. Due to the absence of brushes BLDC motors are capable to run at high speeds. The efficiency of BLDC motors is typically 85 to 90 percent, whereas as brushed
type DC motors are 75 to 80 percent efficient. There are wide varieties of BLDC motors available ranging from small power range to fractional horsepower, integral horsepower
and large power ranges.
Construction of BLDC Motor:
BLDC motors can be constructed in different physical configurations. Depending on the stator windings, these can be configured as single-phase, two-phase, or three-phase motors.
However, three-phase BLDC motors with permanent magnet rotor are most commonly used.
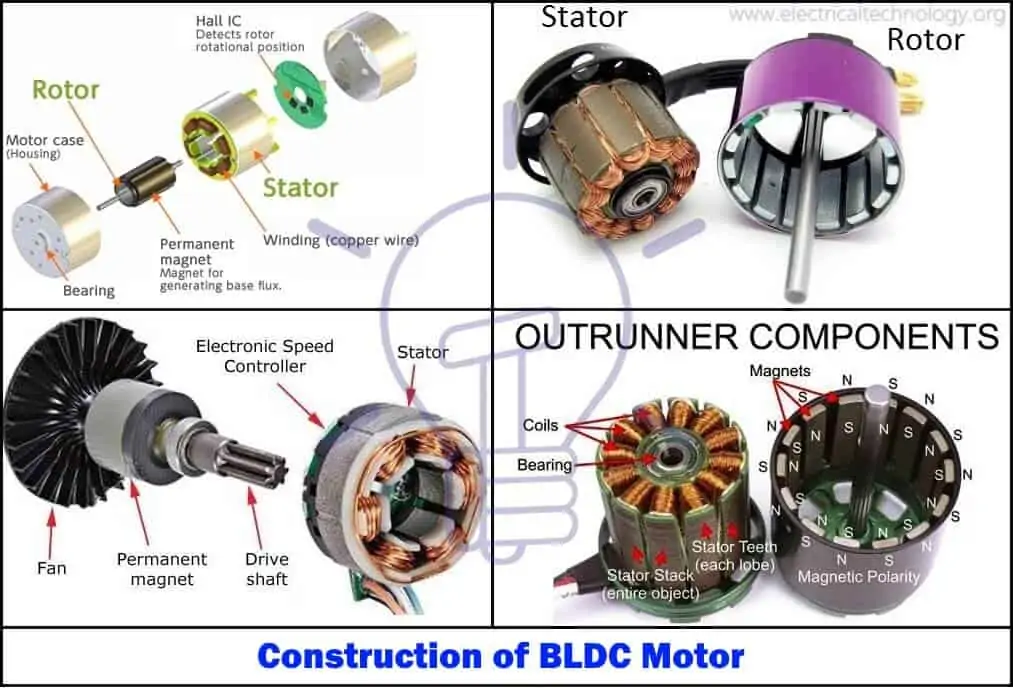
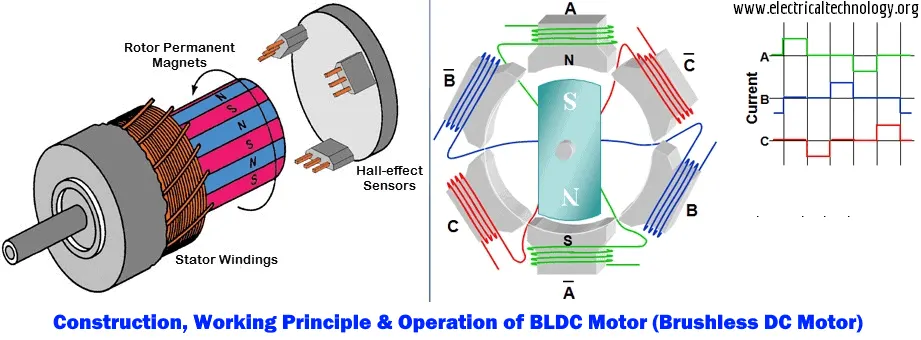
The construction of this motor has many similarities of three phase induction motor as well as conventional DC motor. This motor has stator and rotor parts as like all other motors.

Related Post Cable Size Calculation for LT & HT Motors
Stator of a BLDC motor made up of stacked steel laminations to carry the windings. These windings are placed in slots which are axially cut along the inner periphery
of the stator. These windings can be arranged in either star or delta. However, most BLDC motors have three phase star connected stator.
Each winding is constructed with numerous interconnected coils, where one or more coils are placed in each slot. In order to form an even number of poles, each of these windings is
distributed over the stator periphery.
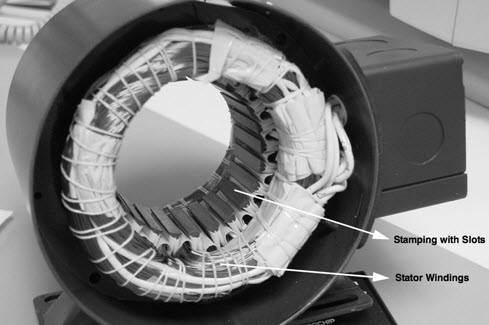
The stator must be chosen with the correct rating of the voltage depending on the power supply capability. For robotics, automotive and small actuating
applications, 48 V or less voltage BLDC motors are preferred. For industrial applications and automation systems, 100 V or higher rating motors are used.