Week-11 Challenge: Braking
AIM:
Learn about BRAKING SYSTEM in the EVs using Matlab.
Objective:
1. For a defined driving cycle, calculate the energy required for braking.
2. Why electric motor can’t develop braking torque at high speed similar to starting? How electric and mechanical brakes are coordinated?
3. Make a MATLAB program which plots contour of given motor speed, torque and efficiency values. Attach the code as a .m file attach a screenshot of all the plots.
Theory:
1. For a defined driving cycle, calculate the energy required for braking.
REGENERATIVE BRAKING:
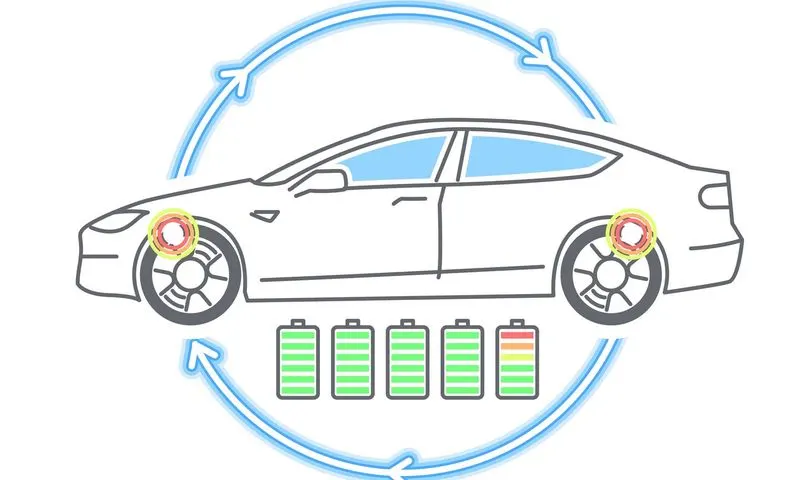
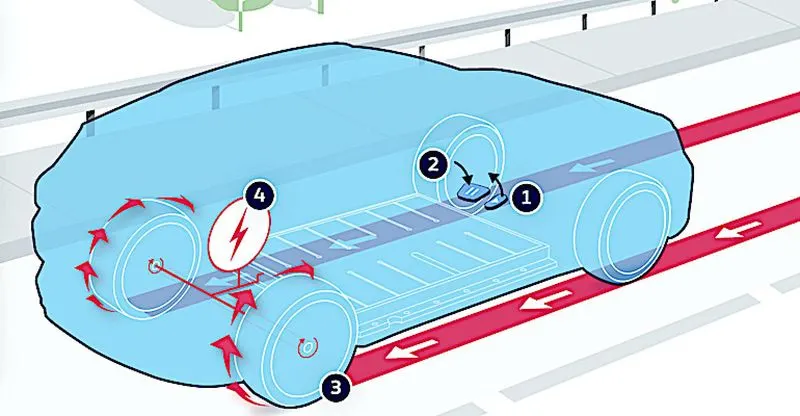
Regenerative braking is an energy recovery mechanism that slows down a moving vehicle or object by converting its kinetic energy into a form that can be either
used immediately or stored until needed. In this mechanism, the electric traction motor uses the vehicle's momentum to recover energy that would otherwise be lost to
the brake discs as heat. This contrasts with conventional braking systems, where the excess kinetic energy is converted to unwanted and wasted heat due to friction in the
brakes, or with dynamic brakes, where the energy is recovered by using electric motors as generators but is immediately dissipated as heat in resistors. In addition to improving
the overall efficiency of the vehicle, regeneration can significantly extend the life of the braking system as the mechanical parts will not wear out very quickly.
GOVERNING EQUATIONS:
For Brakiing Energy,
`E=1/2⋅m⋅(Vf−Vi)^2`
where,
E= Braking Energy
m= Mass of the vehicle
Vf= Final Velocity
Vi= Intial Velocity
For Motor Efficiency
`η = Pout / P i n`
`P out = T⋅ω`
`P i n = P o u t + Cu loss + F e loss + Wi n loss + Cond loss`
`Cu loss = K c u ⋅ ω 2`
`Fe loss = K F e ⋅ T 2`
`Wi n loss = k w ⋅ T 3`
where,
`P i n =Input power to motor
`P out =output power to motor
`Cu loss = Copper of loss
`Wi n loss = Winding of loss
`Feloss = Iron of loss
`Cond loss = Condition of loss
`T = Torque of motor
`w = Speed
Matlab code:
clear all
close all
clc

%Loading data file
load('matlab.mat');

% Defining Time and Speed
time=nyc(:,1);
speed=nyc(:,2);
m=1000;

% Braking Energy
for i=1:598
    if speed(i+1)< speed(i);
        BE(i)= 0.5*m*(speed(i+1)-speed(i))^2 ;
    end
end
E=BE';

%Total Braking energy
TE=sum(E)/1000
fprintf("The Total Braking Energy Required is %f",TE)

% Plotting
figure(1)
subplot(2,1,1)
plot(time,speed)
xlabel('Time')
ylabel('Velocity')
title('Drivecycle')
subplot(2,1,2)
plot(E)
xlabel('Time')
ylabel('Braking Energy')
1.To calculate the braking energy, we have used Matlab program.
2.Here first we have imported a New York City Cycle (NYCC) excel sheet into our program.
3.Then using the load command, we have loaded it into the code.
4.Then we have defined that 1st column of excel sheet is Time of the drive cycle and 2nd column of excel sheet is Speed of the drive cycle.
5.Then we have defined the mass of the vehicle and we have applied a logic that when the speed in the drive cycle is less than the previous data point speed, this means there
is a brake applied and we calculate brake energy at this point using the above mentioned kinetic energy formula and then after calculated all such braking energies we will add all
of them and get total brake energy.
6.To implement the about logic we have used for loop and if condition, then since we will get a row matrix, we have change it into column matrix using transpose operation.
7.Now we have used plot command to plot the graphs. Once we run the code we get the following result.
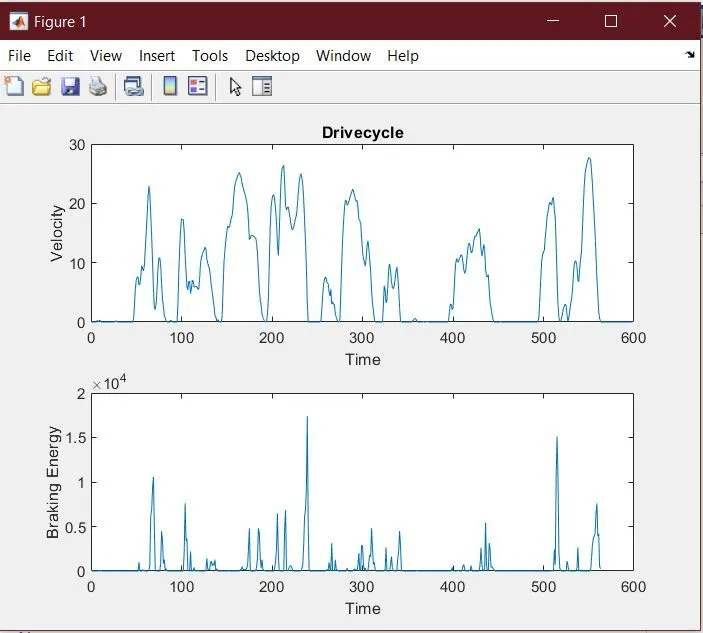
FIGURE.1
8. We can see that where ever the speed is being reduced the brake energy is more.
2. Why electric motor can’t develop braking torque at high speed similar to starting? How electric and mechanical brakes are coordinated ?
Electric Motor Braking:
1.The electric motor braking is also known as Regenerative Braking, which is an energy recovery mechanism that slows down a moving vehicle or object by converting its
kinetic energy into a form that can be either used immediately or stored until needed.
2.When we press the brake pedal, we cut off the power supply to the motor and now the motor will be in rotation due to its inertia.
3.As this rotation is happening inside the magnetic field a Back Emf is generated which produces a negative Torque and that is used as the brakes to reduce the vehicle speed.
4.Also the current flows in reverse direction, Using a Bi-directional Inverter we can store the current back into the battery.
5.This process of Braking by the effect of negative Torque produced and where the motor acts as a generator in producing the current out of the motor's rotation and storing
it back into the battery is called Regenerative braking.
Speed and Torque Characteristics of a DC Motor:
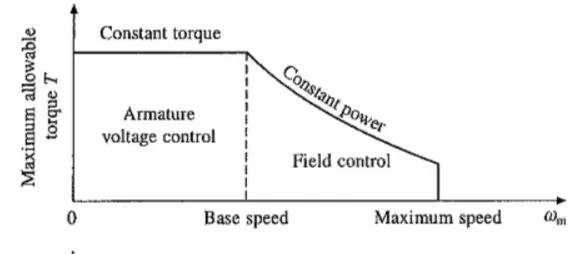
From the above figure we can see the speed and torque behaviour of a electric motor.
During the initial low speed the Torque is high which is the constant Torque region. As speed builds up, after the Critical speed point the torque gradually decreases
which is known as constant Power region.
So during high speeds the motor will be at constant power region and while braking, due to high speed of the motor the negative Torque produced will be less.
But while starting the motor, the speed will be very less and at this stage the motor will be operating in constant Torque region and this is the reason for High accelerating
torque during the start of motor.
From this we can say that the Braking torque produced at High speed motor operations will be lesser than the starting Torque of an Electric motor.
Also there are other reasons like Battery Limitations due to which we cannot get High braking torque.
The rate of discharge is always higher than the rate of charging due to the battery's chemical compositions.
Combination of Electric and Mechanical brakes:
Motor of electric vehicle is able to be used to brake regeneratively, so braking energy can be recycled.
Braking stability of electric vehicles with electro-hydraulic hybrid braking system can be influenced by braking force distribution between hydraulic braking force and
regenerative braking force
Yes electric cars have regenerative braking and this does substantially reduce the need for hydraulic braking.
But there are some limitations like, the maximum deceleration with the engine alone is far smaller than with brake assistance. So you still need an ordinary Frictional brake
system to make the car stop instantly if required.
When the regenative capacity is less than the actual braking required, mechanical brakes are applied at those times.
Brake control Strategy:
When the brake pedal is pressed the control signal is sent to both the Hydraulic cylinder and power converters for producing both Frictional Braking and Regenerative braking.
There are two ways of applying the combination of brakes and they are classified as,
1. Series - The Regenerative braking and Frictional braking are applied one after another.
2. Parallel - The Regenerative braking and Frictional braking are applied at the same time
The series braking and parallel braking is chosen based on two parameters, one is Driver's comfort and other one is based on the Efficiency.
This parallel combined braking Technology is further developed as EDIB, which is Electric Driven Intelligent Braking.
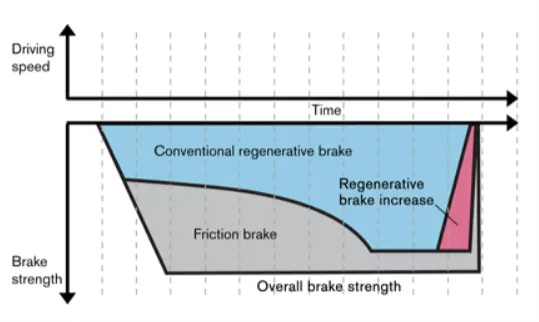
EDIB Braking Technology
The above figure shows the Electric driven intelligent braking system, where we see that both the Regenerative Brakes and the Frictional brakes are applied at the same time.
After braking the speed reduces from higher speed values and at this moment the % of composition of the combined braking changes.
So after brake application the speed is reduced to low speeds. Here Torque will be high and the motor will be operating at constant Torque region.
Now at this point the % of Frictional brake application is reduced and Regenative Braking is Increased because at this point more Negative Torque can be generated and
thus higher electric power generated out of this braking can also be fed back to the battery.
Thus using this technology in Braking an electric driven vehicle certainly increases the stopping power and also contributes to higher efficiency figures.
3.Make a MATLAB program which plots contour of given motor speed, torque and efficiency values. Attach the code as a .m file attach a screenshot of all the plots.
clear all
close all
clc


w = linspace(0,1000);
T = linspace(0,250);

% motor constants
kc = 0.2; % for copper loss
ki = 0.008; % for iron loss
kw = 0.00001; % for windage loss
conL = 20; % for constant motor losses

% making mesh
[X,Y] = meshgrid(w,T);
Outputpower = (X.*Y) ; % Torque * Speed = Power
B = (Y.^2)*kc; % copper loss
C = (X.^3)*kw; % winding loss
D = X*ki; % Iron loss
InputPower = Outputpower + B + C + D + conL;
Z = Outputpower./InputPower;

% Set the efficiencies for which the control will be plotted
V = [0.70,0.75,0.80,0.82,0.87,0.89,0.90,0.92];
box off
grid off
contour(X,Y,Z,V)
xlabel('Speed(rad/s)')
ylabel('Torque(N.m)')
hold on
V = [8000,10000];
contour(X,Y,Outputpower,V)
Output:
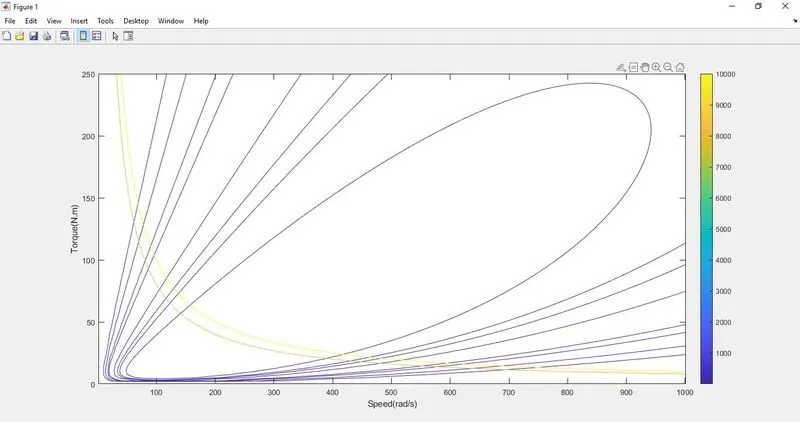
The above figure shows the contour plot and the X axis is speed in RPM, Y axis is Torque in Nm and the height (i.e) Z axis is Efficiency.
The color bar is used to know the efficiency based on the color of shading in the plot ranging from 0.75 to 0.93.
The contour plot represents the operational condition of the Permanent Magnet DC Motor.
The efficiency of the Motor is High at Lower values of speed & Torque at 0.93 . As Speed and Torque Increases the efficiency of the motor goes down upto 0.75 value of efficiency.
Thus the contour plot is made using a Matlab program for an electric motor with given speed, Torque and efficiency values.