Transient Simulation of flow over a throttle body in CONVERGE
In this project, a trasient simulation of flow over a throttle body at different angles will be performed in CONVERGE.
Geometry Creation
The geometry can either be created manually using converge or it can also be imported from another CAD software, in my case I imported the simple geometry.
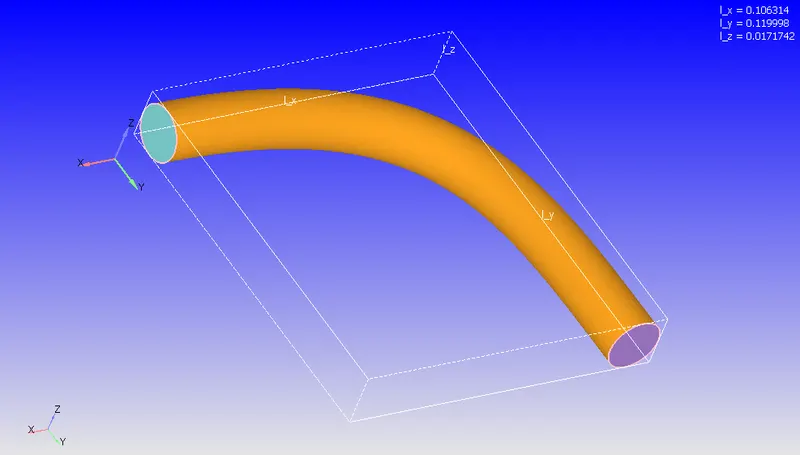
Do note that converge requires all geometry to be in metres, hence transformation may be required if the geometry was exported as millimetres (mm). This is the final geometry seen in converge.
Boundary
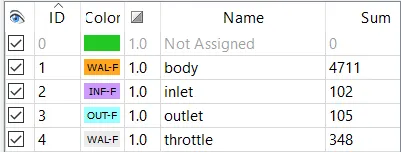
The inlet, outlet and body were given their separate boundaries as usual, and the throttle was given a separate boundary as well.
Case Setup
Now, on to the case setup tab:
Application Type
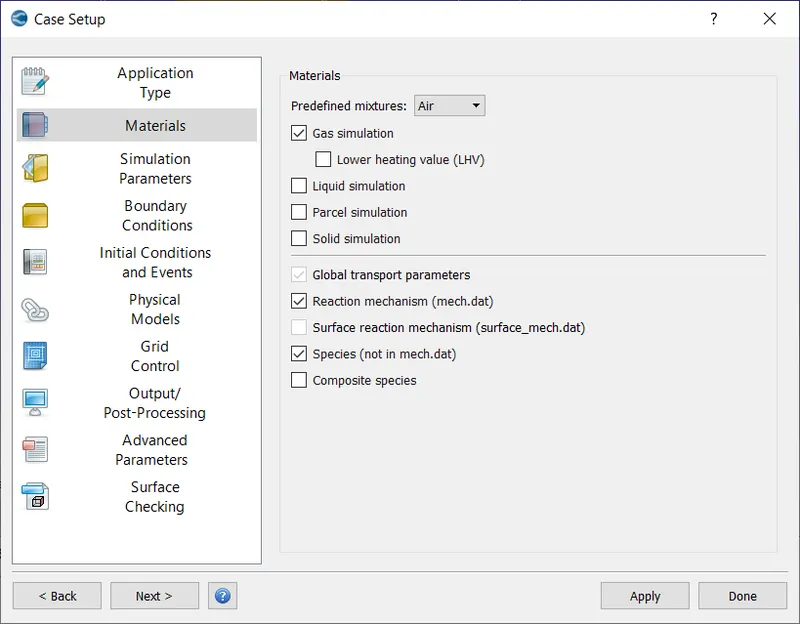
Materials: Gas Simulation, Global Transport Parameters and Reaction Mechanisms were set to default. In species, O2 and N2 were added.
Simulation Parameters
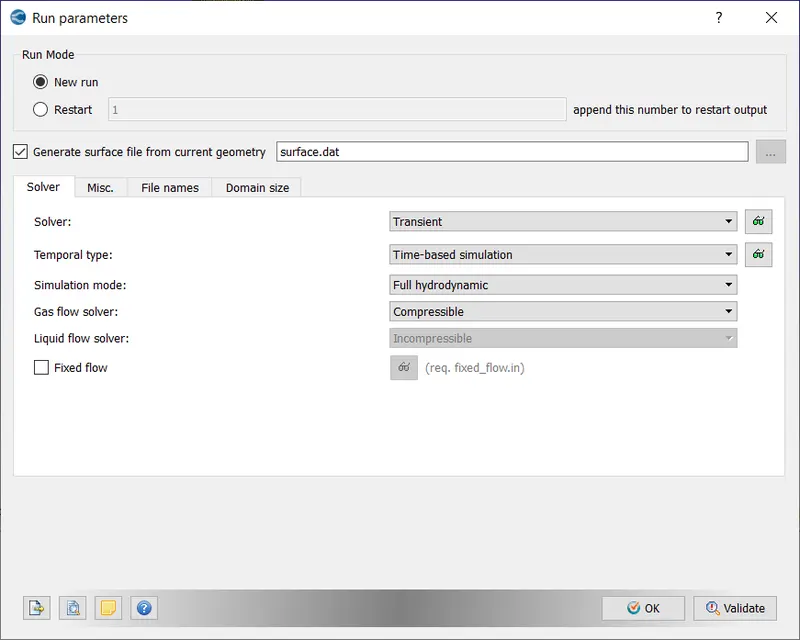
Calculation of Simulation End Time
The geometry is about 0.01m wide and 0.01m long, hence the furthest distance flow would have to travel in the domain once would be 0.02m. From the steady state analysis performed earlier, the inlet velocity is about 100m/s.
`Speed = (Distance)/(Time) or Time = (Distance)/(Speed)`
Plugging in the values, we get time ~= 0.002s for the fluid to traverse the domain once. To ensure all and any changes in flow must be recorded when the throttle moves, the time was multiplied by 5 to get the end time (0.01s) for the simulation.
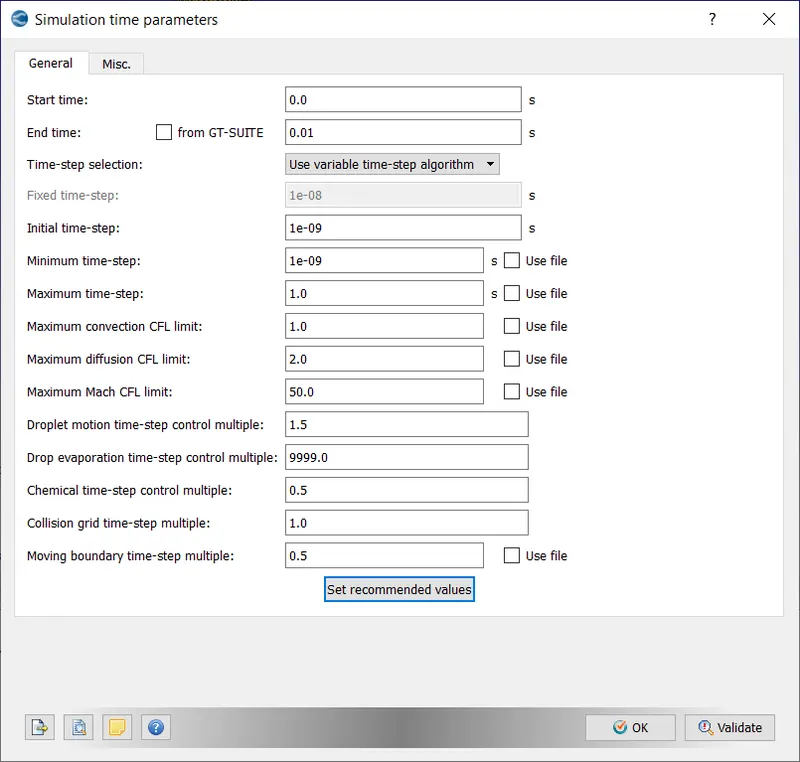
Note: a maximum convection CFL limit is required else the solution will never converge.
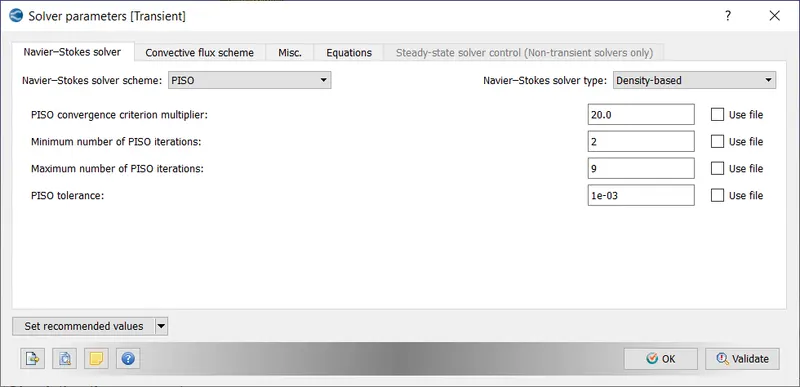
Boundary Conditions
Inlet: 150000 Pa (1.5 bar)
Outlet: 100000 Pa (1 bar)
Body: No-Slip
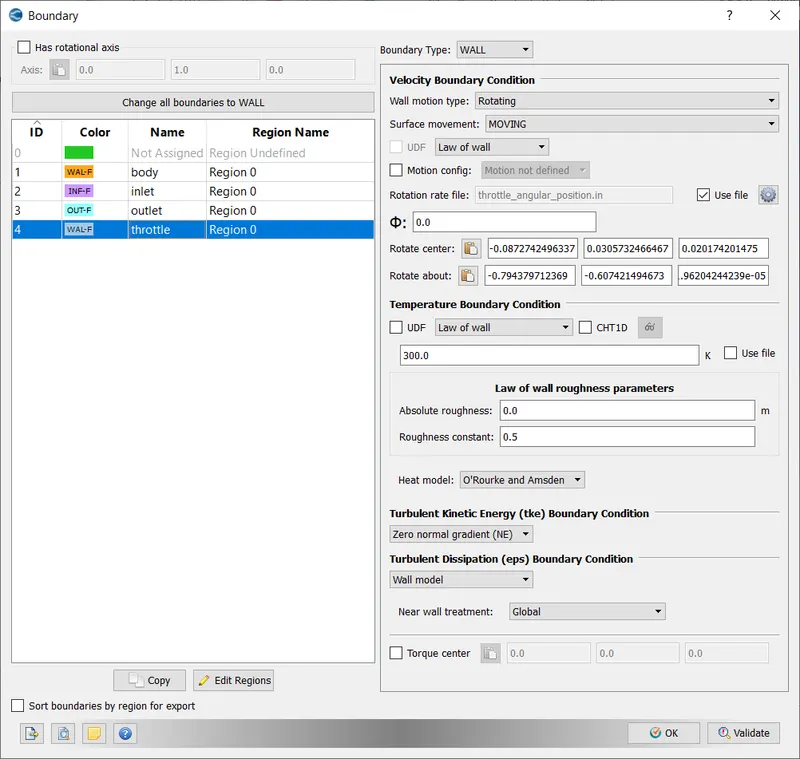
Throttle:
The throttle is poised to rotate about the shaft in the geometry as follows:
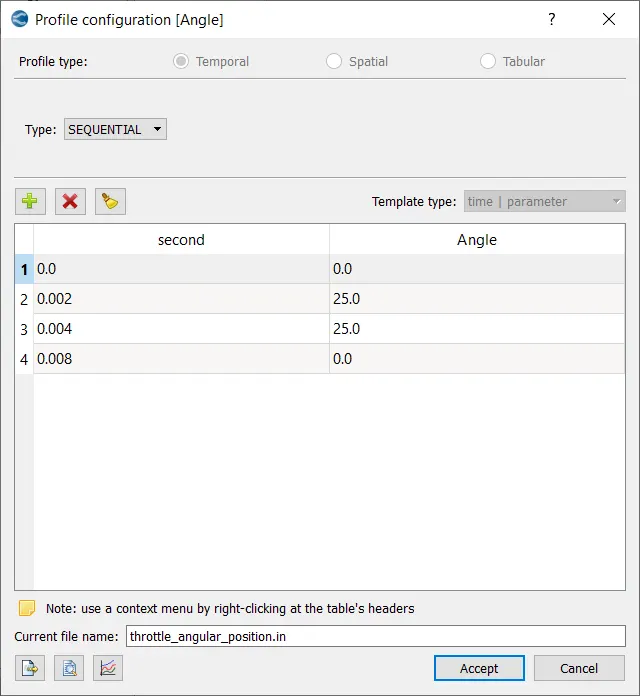
- From 0 to 2 ms, the valve rotates by 25 degrees.
- From 2 to 4ms, the valve should stay at 25 degrees.
- By 8ms, the valve should get back to its original position.
This movement of the valve is acheived by setting the wall motion type as rotating and manually creating a file throttle_angular_position.in for the rotation rate.
The rotation center and axis is also determined from converge's Geometry -> Measure -> Direction
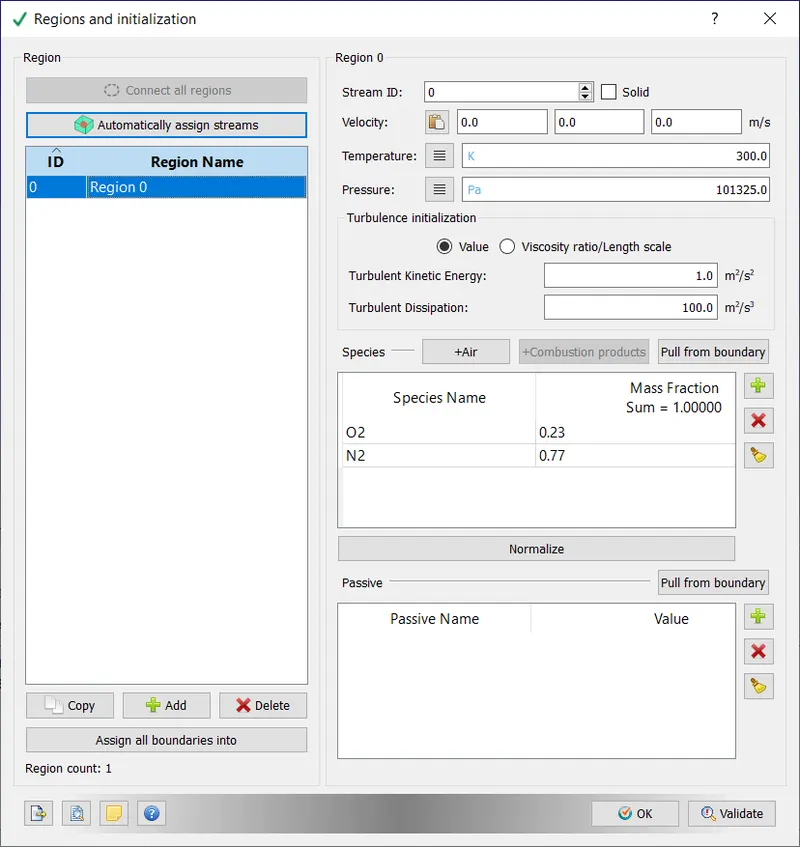
Initial Conditions
Physical Models
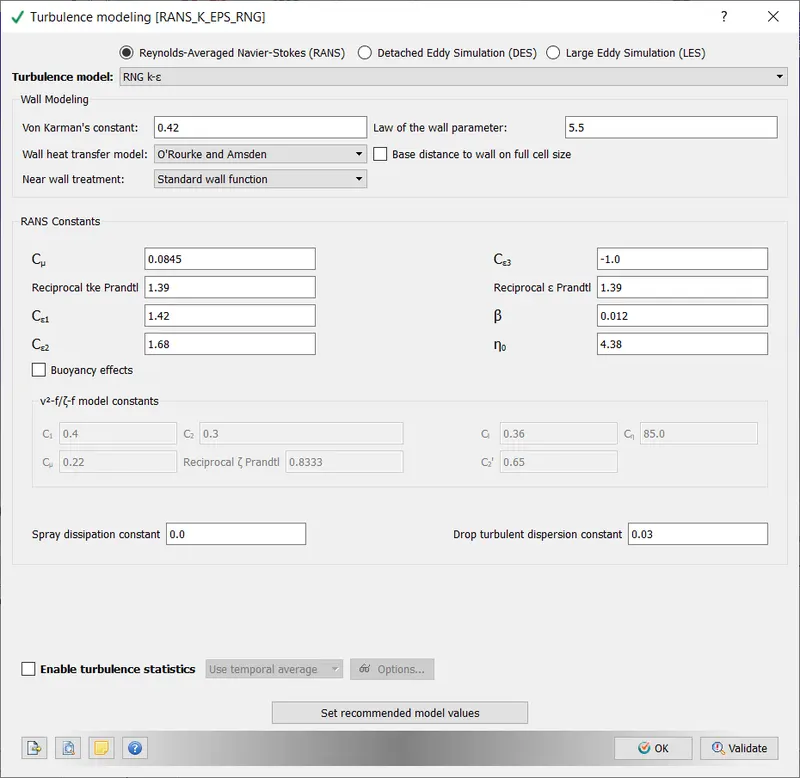
Turbulence was checked as vortices near the throttle are formed due to turbulence, also RNG k-epsilon was chosen as the model since this is a simple simulation.
Grid Control
This is the step were sizes of each element is provided.
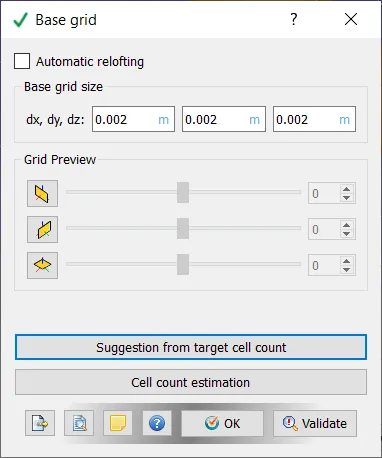
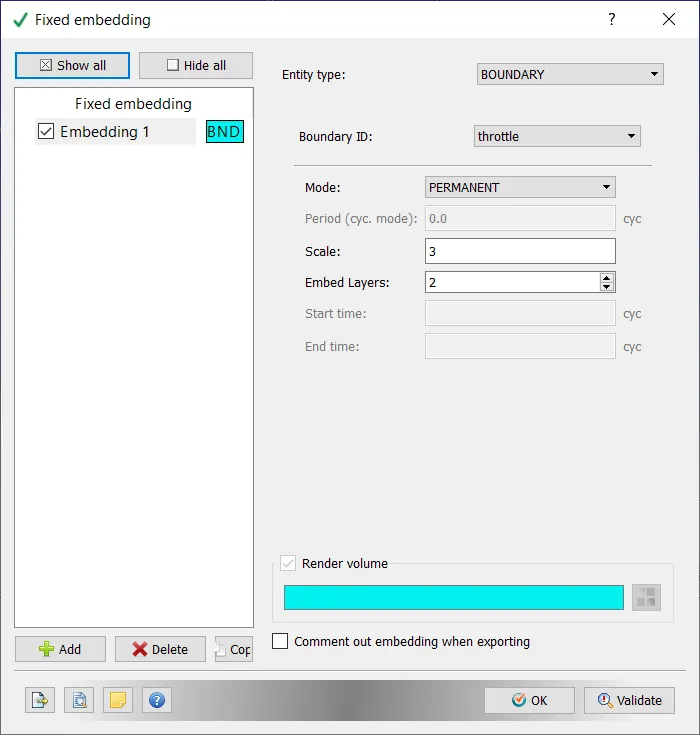
Another option, fixed embedding was enabled for this simulation to ensure more cells are used for processing near the throttle.
Output/Post Processing
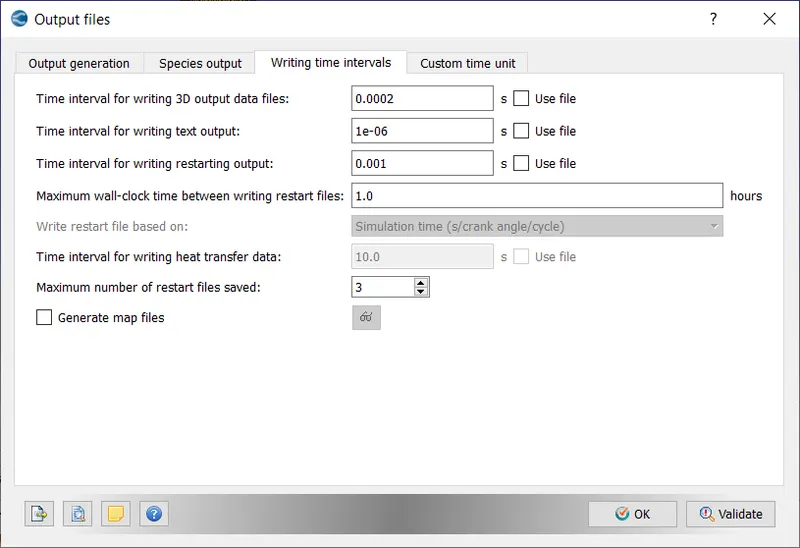
Because the runtime of the simulation is 0.01s and anywhere between 50 and 100 files are optimal, I chose the minimal file count (50), so interval between each 3D output will be: `0.01//50 = 0.0002`
Now, our case setup is complete. The files will be exported into a folder using the Files Export tool (File -> Export->Export input files)
In total 12 files were exported, these are:
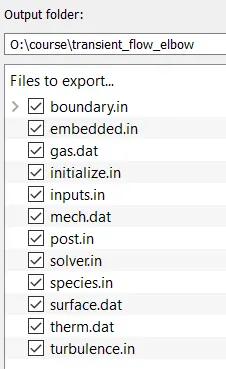
These files contain all the necessary information for the simulation.
Running the Simulation
1. Open cygwin
2. Navigate to directory where case files were exported
3. Run the following command
mpiexec.exe -n 4 "C:Program FilesConvergent_ScienceCONVERGE3.0.16binintelmpiconverge.exe" restricted </dev/null> logfile.txt &This will take a while, you can view the progress in task manager. CPU usage is usually maxed out.
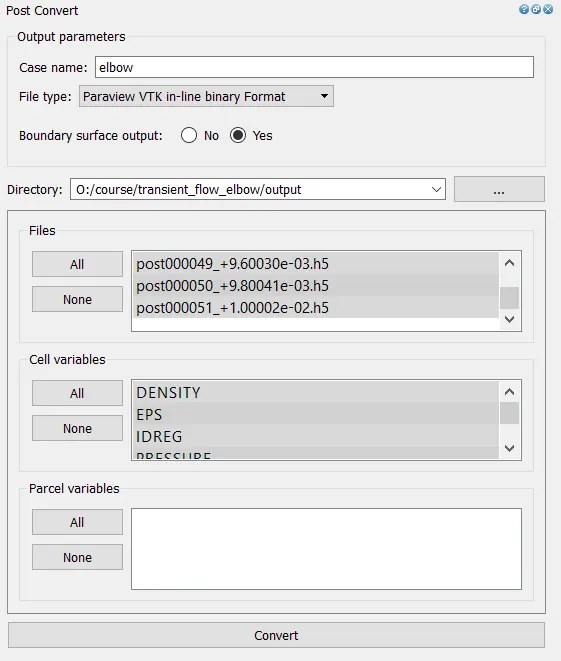
Once CPU usage drops from 100%, the output files are generated. To view them in paraview, we must export them to a format which is supported by paraview.
Go to 3D-post processing in converge,
Post-Processing
In Paraview
Import these files into paraview
The required plots/animation are generated
In converge
Go to Line plotting, select the case folder and plots can be viewed
Outputs and Plots with explanations
1. Velocity and Pressure Contours
These were taken in paraview.
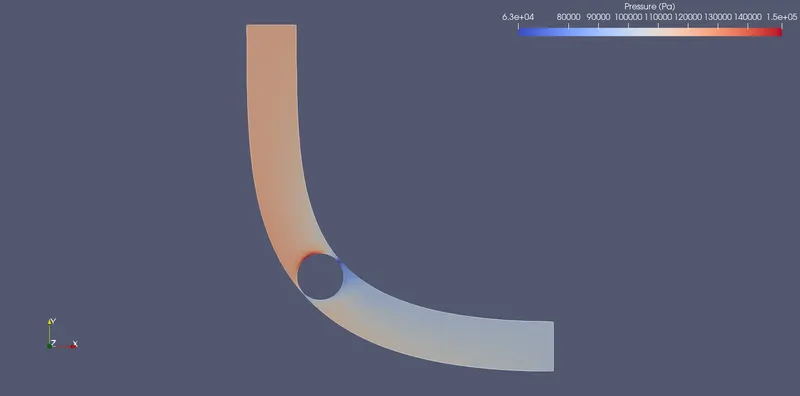
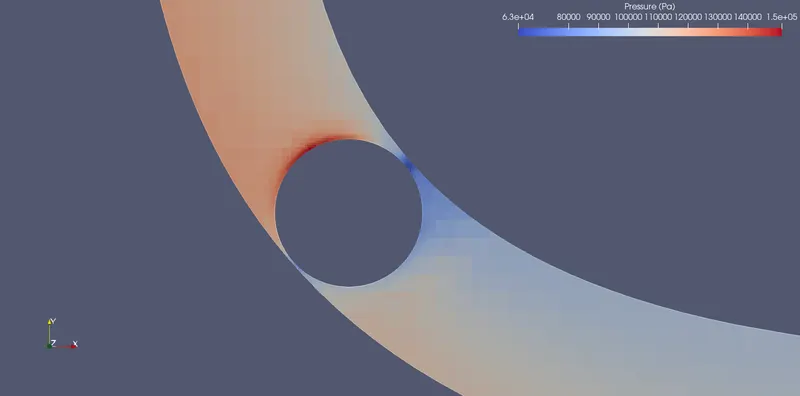
Inlet Pressure is higher at the enterance of the channel, as expected due to the boundary condition. It drops gradually untill the throttle where the pressure is high around the throttle face towards the inlet. After the flow crosses the throttle, the pressure drops to low levels and continues to drop to its lowest level at the outlet of the domain.
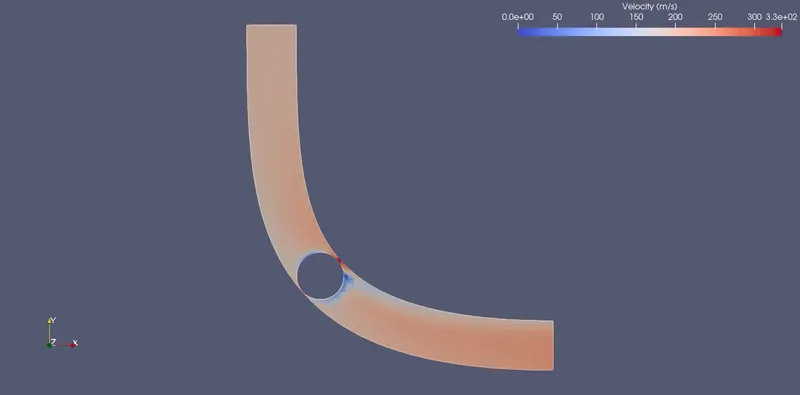
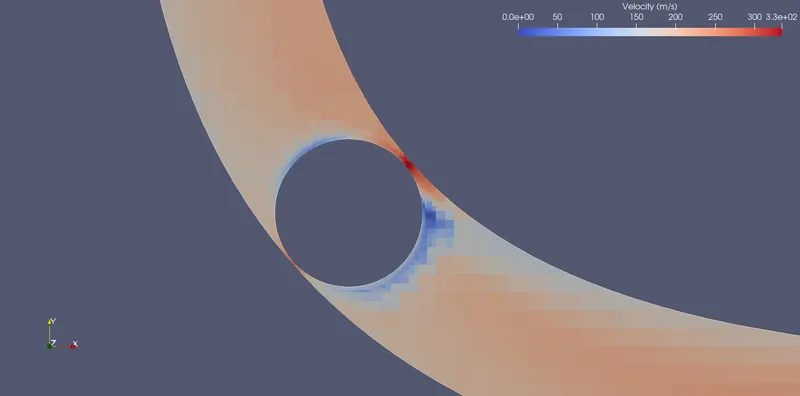
Velocity slowly increases towards the centre of the domain, while the velocity near the walls are low (due to boundary layer effect). On the side of the throttle that faces the inlet, the velocity is low while the velocity is high around the gaps between the throttle and elbow walls. On the side of the throttle that faces the outlet, there is a small region of very low velocity due to flow combining from 2 sides.
We can also notice that how the flow slows down and picks up speed again after the obstruction (throttle)
2. Mesh
This was taken in paraview.
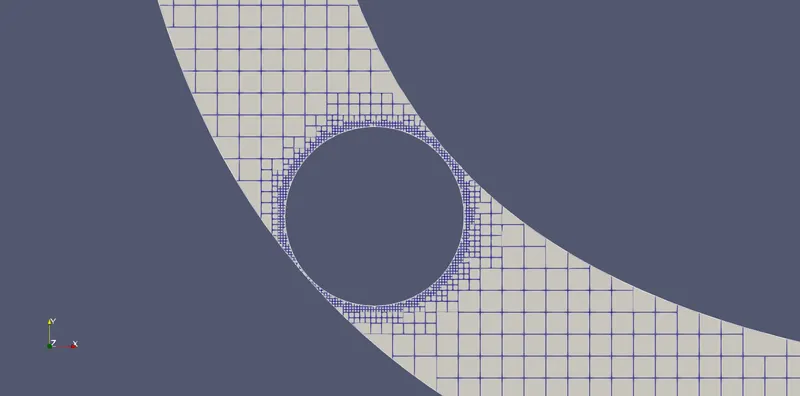
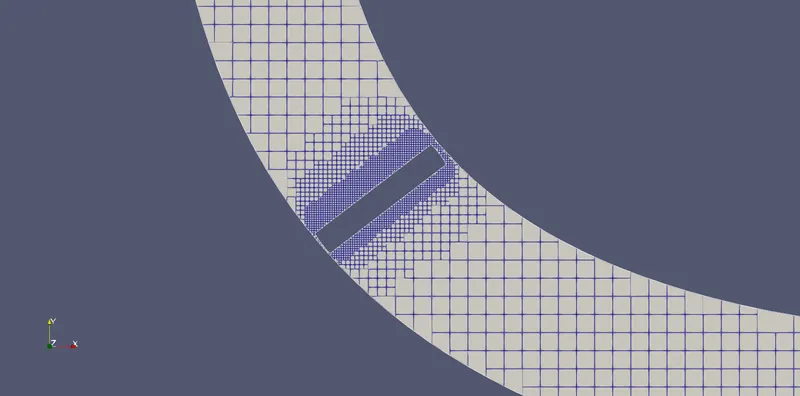
The mesh is finer around the throttle because of the fixed embedding option around the throttle's boundary. We can also observe that as the throttle rotates, the mesh adapts to the new domain and also embedding is done near the new throttle walls.
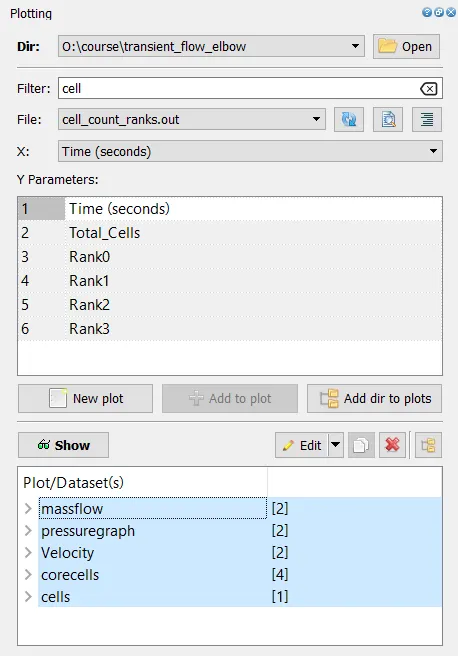
3. Velocity, Pressure, MassFlowRate and Cell Count Plots
This was taken in converge -> Line plotting
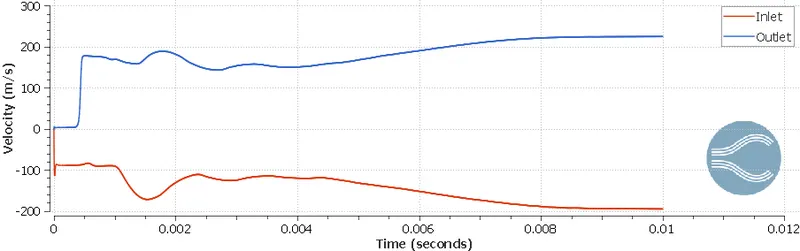
Velocity at the inlet is negative since flow enters the domain is considered negative, while velocity at the outlet is positive. The abosolute values of the velocities differ so much because, there is a change in density at the inlet vs outlet. The velocities initially start from 0 and wildly change due to the turbulent flow changes induced by the movement of the throttle.
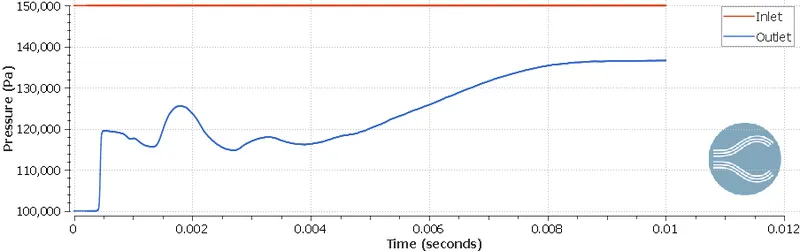
Pressure at the inlet stays constant because of the boundary condition, and outlet pressure increases slightly to compensate for mass conservation. Outlet pressure also changes suddenly due to the turbulent conditions induced to the throttle's movement.
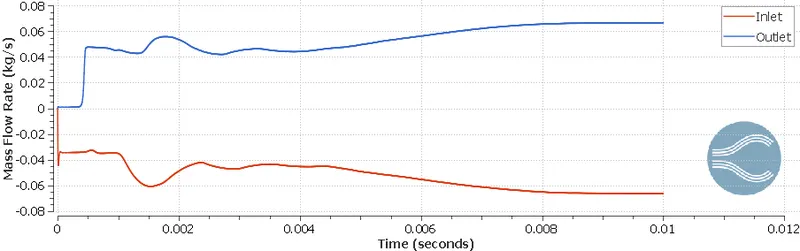
Mass flow rate at the inlet is negative since flow enters the domain is considered negative, while mass flow rate at the outlet is positive. Both masses' abosolute values are roughly the same throughout the simulation showing that mass conservation is followed. The masses initially start from 0 and wildly change as the throttle is rotated.
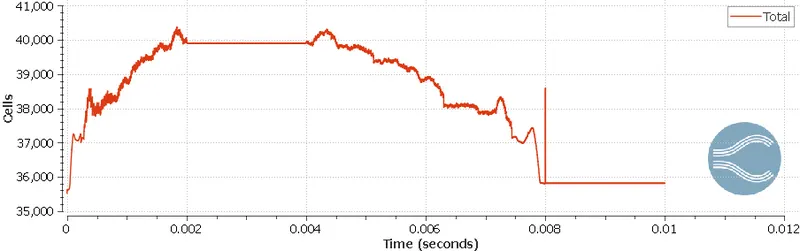
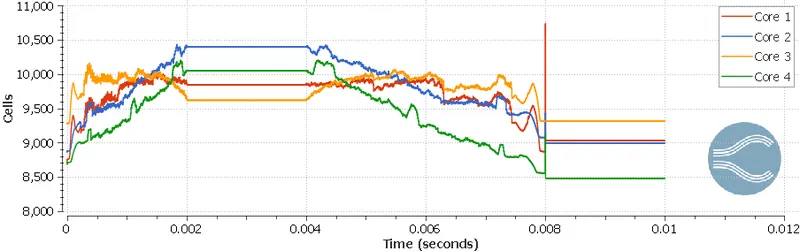
Cellcount, do not remain constant in this case, as the mesh is generated individually for each timestep. The mesh becomes more fine when the throttle is rotated to compensate for extra regions which need more meshing. The reverse happens when the throttle moves back to its original position. There is no mesh change during times when the throttle is static (2ms to 4ms and 8ms to 10ms). Total Cell count is always roughly 4 times the value for each Core.
5. Animation
We can notice wild changes in the flow whenever the throttle is not at its initial position. There is a lot of turbulence when the throttle is not at its initial position.