Week 3 - Solving second order ODEs
ODE MAIN CODE:
clear all
close all
clc

b = 0.05
g = 9.81
l = 1
m = 1

%Intial condition
theta_0 =[0;3];

% time points
t_span = linspace(0,20,500);

% solve ODE
[t, results] = ode45(@(t,theta) ode_func(t, theta, b,g,l,m),t_span,theta_0);

figure(1)
plot(t,results(:,1))
hold on
plot(t,results(:,2))
xlabel('time')
ylabel('plot')
grid on;

%Animation
theta1 = results(:,1);
ct = 1; % counter actually represents each and every frame

 for i=1:length(theta1)
     r = theta1(i);
     x0=1;
     y0=1;
     x1=1 -l*sin(r);
     y1=1 -l*cos(r);

     figure(2)
     plot([0 2],[1 1], 'linewidth',4,'color','g');
     axis([-2 5 -2 2]);
     hold on
     plot([x0 x1],[y0 y1],[x1 x1],[y1 y1],'o','MarkerSize',20,'color', 'r')
     title('Damping of Pendulum');
     legend('Support rod','length of pendulum','Bob of pendulum');
     grid on;
     hold off;
     pause(0.02)
     M(ct) = getframe(gcf);
     ct=ct+1;
 end

movie(M);
videofile = VideoWriter('pendulum.avi','Uncompressed AVI');
open(videofile);
writeVideo(videofile,M);
close(videofile);
ODE_FUNC Program:
function [dtheta_dt]= ode_func(t,theta,b,g,l,m)


theta1 = theta(1)
theta2 = theta(2)
dtheta1_dt = theta2;
dtheta2_dt = -(b/m)*theta2 - (g/l)*sin(theta1);
dtheta_dt = [dtheta1_dt; dtheta2_dt];

end
EXPLANATION:
By providing the initial inputs that includes the value of b, g, l & m.
Following with initial inputs, While solving the ODE system, two first order ODE, first describes the initial displacement and
second describes the initial velocity in 3 m/s
Here inbuilt solver in MATLAB ode45 used to solve the second order ODE.
Since ode45 can only solve a first order ode, the pendulum equation has to be converted into two first order ODE as defined
in the separate generated function program named “ode_func”
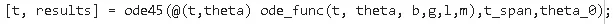
Here, t & theta are the function. Where as "ode_func(t, theta, b, g, l, m" says how your ode function is defined by calling the
sepearte ode function (attached).
After defining everything now plot command is used to generate figure as usual
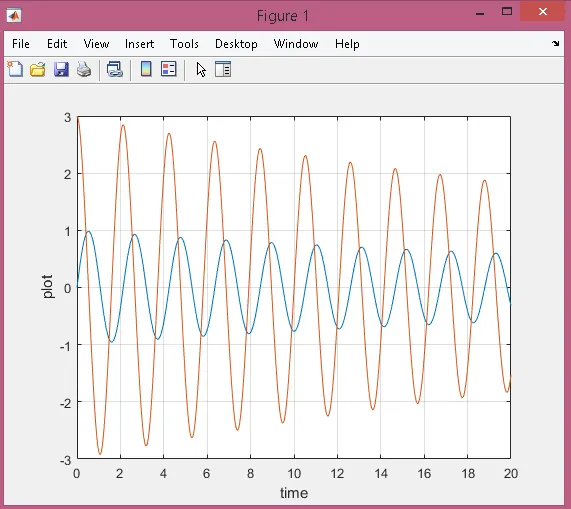
Here blue line represents the displacement & red line represent the velocity.
After doing this, now creating animation we need to use for loop command. But before that Ct comand will be used.
For loop command with using I to length theta1 and.
However, “theta” is an array.
Adding all mathematical expressions mentioning the values of x0,x1, y0,y1
After that using Plotting command where plots are being used instead of giving line command. As plots will give clear
animation.
Mentioning axis with [-2 5 -2 2] will give the clear animation within the mentioned axis boundary which will look elegant
also.
Here,counter actually represents each and every frame. we create an array called “M” while making movie/animation. At the
last te video dmesify the position of pendulum.