Week - 2 - Explicit and Implicit Analysis
Aim:
As demonstrated in the PDF, F(u) = u3+9u2+4u use this equation and solve using both Explicit and Implicit Methods ( have a tolerence of 10-2.
Deliverables :
1. Write a detailed report about Implicit and explicit methods.
2. Do the calculations in a spreadsheet, try to plot the graph and compare them (optional).
3. Calculations that are done in a piece of paper and uploaded as an image will not be taken into consideration for grading.
4. Equations can be typed using the insert equation option present in the toolbar. Equations are supposed to be typed and not copy-pasted as images.
5. plots can be uploaded as images, Don't use the google drive to upload the plots you can upload images directly and post it in the answer section.
Solution:
Implicit and Explicit Analysis:
The finite element method (FEM) is a numerical problem-solving methodology commonly used across multiple engineering disciplines for numerous applications such as structural analysis, fluid flow, heat transfer, mass transport, and anything existing as a real-world force. This practice systematically yields equations and attempts to approximate the values of the unknowns. This method subdivides the overall problem into simpler sub-issues that are easier to solve. In turn, these sub-issues called finite elements require implicit vs explicit analysis.
For all nonlinear and non-static analyses, incremental load (also known as displacement steps) are needed. In more simplistic terminology, this means we need to break down the physics/time relationship to solve a mathematical problem. To do this, we form two groups: either time-dependent or time-independent problems. To solve these problems, we commonly use ‘implicit’ and/or ‘explicit’ methods.
We refer to problems as ‘time-dependent’ when the effects of acceleration are pronounced and cannot be neglected. For example, in a drop test, the highest force occurs within the first few milliseconds as the item decelerates to a halt. In this case, the effect of such a deceleration must be accounted for.
In contrast, when loads are slowly applied onto a structure or surface (i.e., when a monitor is placed onto a table) the loading can be considered ‘quasi-static’ or ‘time-independent’. This is because the loading time is slow enough that the acceleration effects are negligible.
All of these implicit vs explicit problems are expressed through mathematical partial differential equations (PDE’s). While today’s computers can’t single-handedly solve PDE’s, they are equipped to solve matrix equations. These matrix equations can be linear or nonlinear. In most structural problems, the nonlinear equations fall into 3 categories:
- Material Nonlinearity: Where deformations and strains are large (i.e., polymer materials)
- Geometric Nonlinearity: Where strains are small, but rotations are large (i.e., thin structures)
- Boundary Nonlinearity: Due to non-linearity of boundary conditions, (i.e., contact problems)
In linear problems, the PDE’s reduce to a matrix equation as:
[K]{x} = {f}
and for non-linear static problems as:
[K(x)]{x} = {f}
For dynamic problems, the matrix equations come down to:
[M]{x´´} + [C]{x´} + [K]{x} = {f}
where (.‘) represents the derivative.
One method of solving for the unknowns {x} is through matrix inversion (or equivalent processes). This is known as an implicit analysis. When the problem is nonlinear, the solution is obtained in a number of steps and the solution for the current step is based on the solution from the previous step. For large models, inverting the matrix is highly expensive and will require advanced iterative solvers (over standard direct solvers).
Explicit analyses aim to solve for acceleration (or otherwise {x´´}). In most cases, the mass matrix is considered as “lumped” and thus a diagonal matrix. Inversion of a diagonal matrix is straightforward and includes inversion of the terms on the diagonal only. Once the accelerations are calculated at the nth step, the velocity at n+1/2 step and displacement at n+1 step are calculated accordingly. In these calculations, the scheme is not unconditionally stable and thus smaller time steps are required.
To be more precise, the time step in an explicit finite element analysis must be less than the courant time step (i.e., the time taken by a sound wave to travel across an element) while implicit analyses have no such limitations.
Explicit FEM is used to calculate the state of a given system at a different time from the current time. In contrast, an implicit analysis finds a solution by solving an equation that includes both the current and later states of the given system. This method requires additional computation and can be harder to implement. However, it will be used in lieu of explicit methodologies when problems are still and using alternative analysis methods is impractical.
Implicit and Explicit analysis differ in the approach to time incrementation. In Implicit analysis each time increment has to converge, but you can set pretty long time increments. Explicit on the other hand doesn’t have to converge each increment, but for the solution to be accurate time increments must be super small.
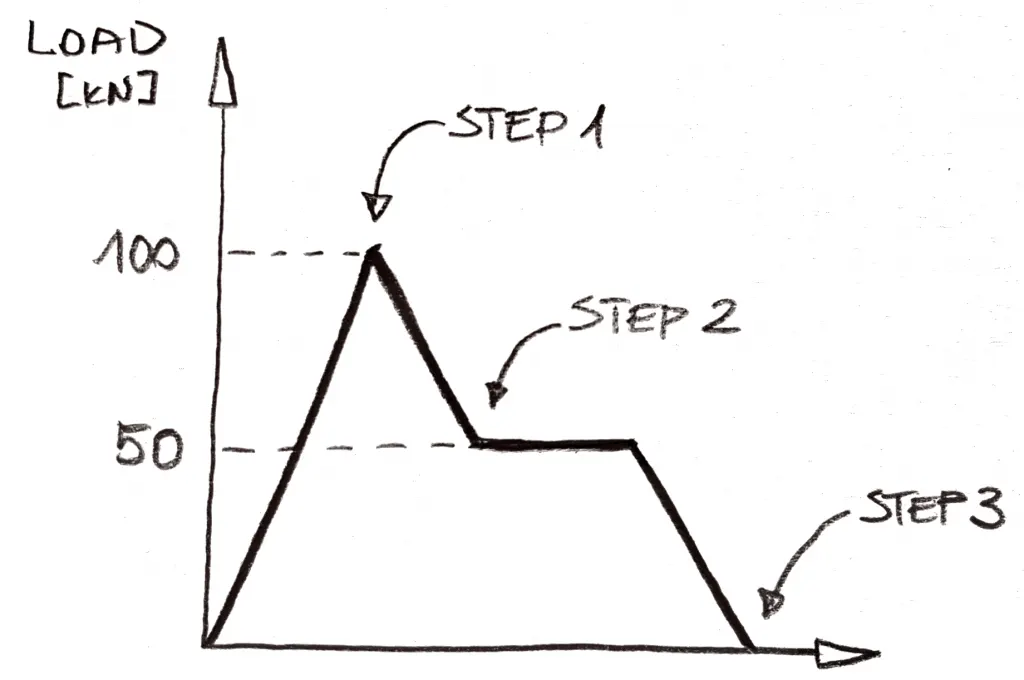
In static this would be a 3 “steps” analysis (those are called subcases in NX Nastran, but I think Abaqus actually used “step” as a name, can’t recall this for sure though!). The idea would be simple, you have to apply the 100kN of load in step 1, then remove 50kN of the load in step 2, and remove 50kN in step 3. There is no way to include the “plateau” of load after step 2 into the analysis, and it will be omitted. Logic is simple: no changes in load = nothing changes in static!
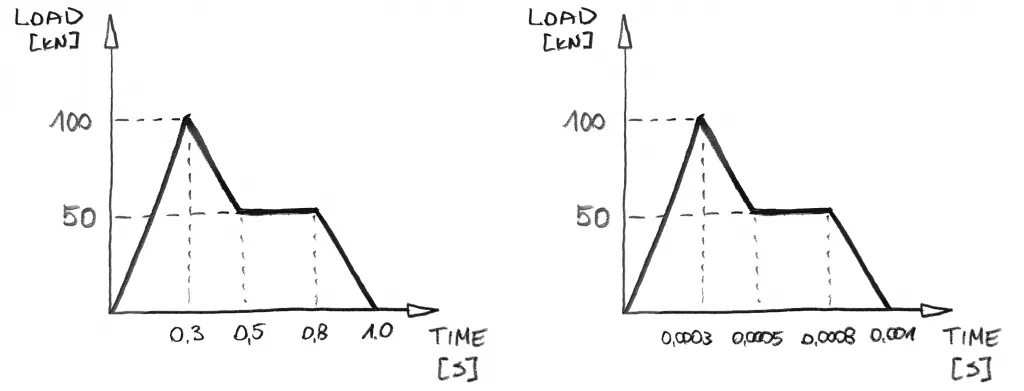
- There are no steps! This is because in dynamic analysis you won’t increment load. You will increment the time! And since time goes “constantly” from zero to the prescribed value, you can increment it in “one step”.
- Time is of the essence! When it comes to the values of the load, the above charts are the same. But this is not the same dynamic case! The chart on the right applies the load 1000x quicker! This isn’t something you can just ignore in dynamic analysis!
In general, when you want to solve a dynamic problem, you are asking your solver to do one thing. You ask it to calculate the series of time increments, to see what is going on in the model. In each of those increments, time slightly increases. This of course also changes the load in the model. This is why you need to have a time-dependent chart for load. So the solver “knows” what load should be applied at which time increment. To this extent, it works the same as load incrementation in static analysis. The bonus is, that since you are incrementing time, inertia effects can be taken into account when things are happening fast enough.
To this extent, both implicit and explicit analysis does more or less the same thing. They divide the “analysis time” into small increments, and then analyze what is going on in your model one increment of time after another. But here is where the similarities end! You see, there are distinct approaches to time incrementation you may have!
How Implicit Analysis Works:
First of all, implicit seems to be a more “basic” solution. In essence it works just as you would think it should!
- Firstly, in each time increment the “global equilibrium” in the model is established. This means that each increment has to converge (this is happening in iterations).
- After global equilibrium is ok, solver calculates all the local finite element variables (stresses etc.) for this increment.
- Benefits: Since global equilibrium is verified at each time increments, those increments can be BIG!
- Drawbacks: Each time increment computes slowly, since iterations are needed to get to the global equilibrium.
If you are familiar with the nonlinear static analysis you will feel “at home” with the implicit solver. As a user, you usually get to say how big the time increments you want to have. This is a huge advantage… that is easy to miss. Because Explicit solver does not offer such a possibility!
Now we will be solving a function using expilicit and impilicit analysis :
Consider the following equation :
F(u) = u3+9u2+4u
We will first use explicit analysis method for this function :
We will consider the above equation as force (f) as function of displacement (u) and will be using excel to make calulation as shown below :
The variables used are u for displacement, f for
internal force in the bar, F for external force applied to the bar and k for stiffness. Incremental displacements or incremental externally applied forces are represented as ∆u or ∆F,
respectively. Use is made of the relationship ∆F = k∆u
Now we know that :
F(u) = u3+9u2+4u
The stiffness will be the derivative of this function
k(u) = u^2 +18*u + 4
Now we use increment based on load and will give increment of 1 load per step and calculate the displacement for the next step as shown below :
We will assume that the intial condition at u= 0 at t =0 we get the following :
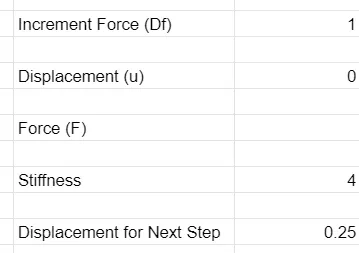
2. At u=0.25 we get :
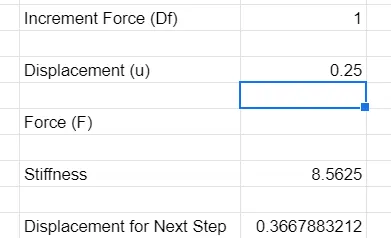
3. At u =0.36
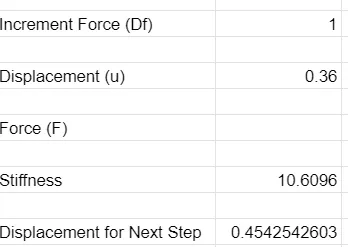
Now we will examine the total external force and internal force as shown below :
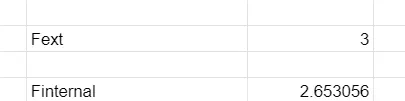
As you can see the external and internal force are not equal and hence the system is not in equilibrium.
Now we will be doing the implicit analysis for the same function :
An implicit analysis is the same as the explicit analysis, except that at the end of each step
Newton-Raphson iterations are used to enforce equilibrium before moving to the next step.
Basically, an incremental force is applied to advance the solution forward at the beginning
of a step. However, internal forces and external forces will not be in equilibrium unless the
stiffness is linear for the given step. Hence, in order to achieve equilibrium, corrections must
be made to the displacement. This is accomplished by using Newton-Raphson iterations to
minimize the residual, R(u) = fint − Fext.
Now we will apply the same boundary condition as shown below :
1. We will assume that the intial condition at u= 0 at t =0 we get the following :
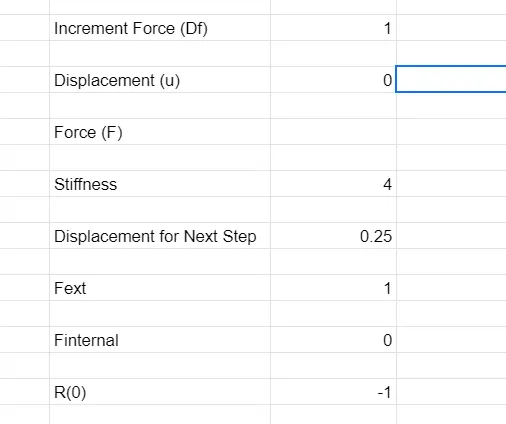
As you can see R(0)<10^-2 , we can proceed to step 2 .
2.2. At u=0.25 we get :
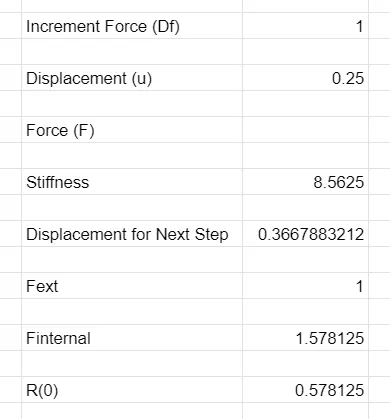
Hence we will use newton raphson method and do iteration until we get the covergence less than 10^-2