Project
REPORT
Aim:-
A report carry out a system level simulation of an all- terrain vehicles used in BAJA.
Objective:-
To prepare the full detail technical report on the BAJA (ATV) model with continous variable transmission (CVT).
Information about all-terrain vehicle:-
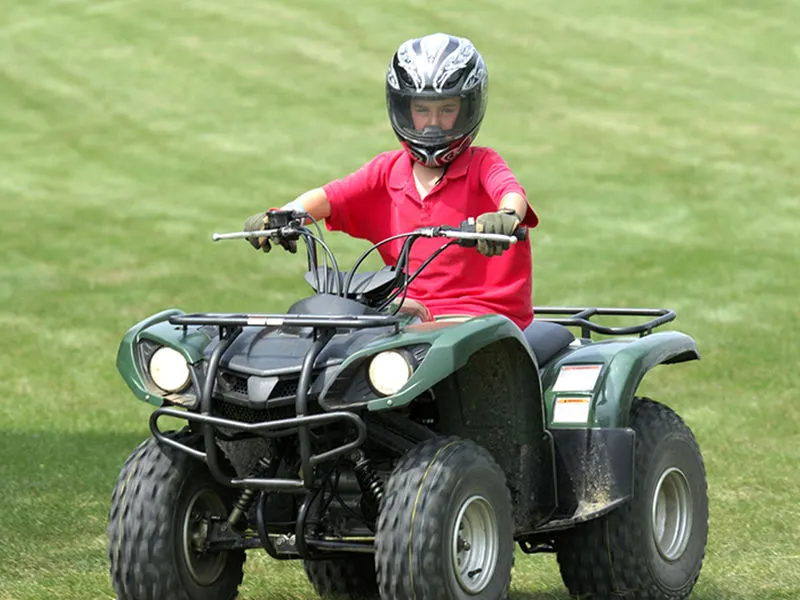
An all-terrain vehicle (ATV), also known as a light utility vehicle (LUV), a quad bike, or simply a quad, as defined by the American national standard institute (ANSI) is a vehicle that travels on low-pressure tires, with a seat that is straddled by the operator, along with handlebars for steering control. As the name implies, it is designed to handle a wider variety of terrain than most other vehicles. Although it is a street legal vehicle in some countries, it is not street-legal within most states, territories, and provinces of Australia the United state and Canada.
By the current ANSI definition, ATVs are intended for use by a single operator, although some companies have developed ATVs intended for use by the operator and one passenger. These ATVs are referred to as tandem ATVs.
The rider sits on and operates these vehicles like a motorcycle, but the extra wheels give more stability at slower speeds. Although most are equipped with three or four wheels, six-wheel models exist for specialized applications. Multiple-user analogues with side-by-side seating are called Utiliy terrain vehicle (UTV)or side by side to distinguish the classes of vehicle. The ATV is commonly called a four-wheeler in Australia, New Zealand, South Africa, parts of Canada, India and the United States. They are used extensively in agriculture, because of their speed and light footprint.
What is ATV?
Defination of ATV:-
An all-terrain vehicle (ATV) is defined as a motorized off-highway vehicle designed to travel on four low-pressure or non-pneumatic tires, having a seat designed to be straddled by the operator and handlebars for steering control. ATVs are subdivided into two types as designated by the manufacturer.
Type I :- ATVs are intended by the manufacturer for use by a single operator and no passenger.
Type II :- ATVs are intended by the manufacturer for use by an operator and a passenger, and are equipped with a designated seating position behind the operator. Similarly, riders must also consider the various ATV sizes.
Continuous variable transmission (CVT):-
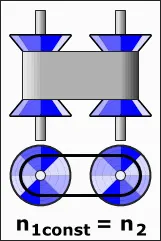
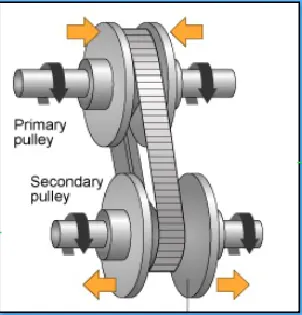
A continuously variable transmission (CVT) is an automatic transmission that can change seamlessly through a continuous range of gear ratio. This contrasts with other transmissions that provide a limited number of gear ratios in fixed steps. The flexibility of a CVT with suitable control may allow the engine to operate at a constant RPM while the vehicle moves at varying speeds.
CVTs are used in automobile , tractor,motor scooter, snowmobile and earth moving equipment.The most common type of CVT uses two pulleys connected by a belt or chain and aother types such as torodial,Ratcheting. In these cvt there are two primary and secondary cvt.
Working of CVT system in BAJA (SAE):-
The type of CVT considered here is V-Belt rubber type. The input (Engine) is to the primary sheave while the output is from the secondary sheave. When the speed increases, the flyweights pull the movable sheave in the primary sheave closer. The force provided by the flyweight should be enough to overcome the spring force and the frictional force between belt and the pulley. The secondary pulley consists of a similar arrangement with the movable sheaves actuated by a shift in the primary pulley.
BAJA SAE model:-
Explanation of model :-
1) ATV model without a dashboard :- Following simulink model show the BAJA ATV using the CTV for power transmission.
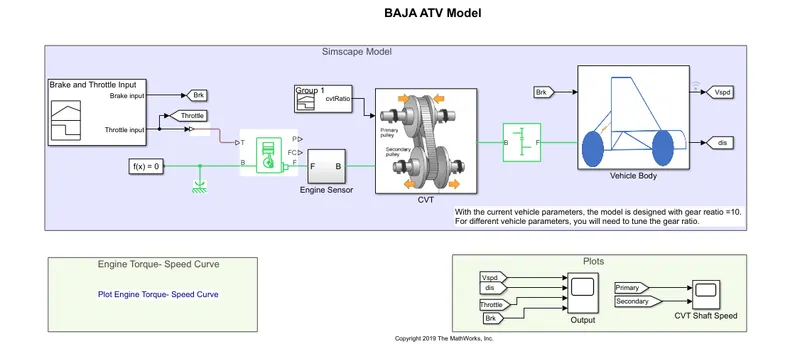
The block used in simulink model are as follows:-
A) Signal builder block:- The signal builder blockis used to crate ,edit and input signal source for model. In these model we have used two signal builder block one for the throttle and brake input signal. Another for theinput for CVT ratio.
1) Throttle and brake input signal:-
2) CVT ratio input signal:-
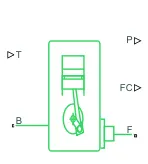
B) Generic Engine :- This block represent a general internal combustion engine. The types of engine include spark ignition and diesel.Speed torque and speed power parameterization are provide. The optional idle speed and red line controller are include which prevent engine stall and enable control. There are 5 port of these block are as follows:-
| Port | Function |
| F & B | Connection F and B are the mechanical rotational converting port representing the engine block and cranshaft |
| T | Physical input signal port specifying the normalised Engine throttle level |
| P | Physical output signal port reporting the engine power |
| FC | Physical output signal port reporting the fuel consumption rate. |
The throttle input signal T lies between zero and one and specifies the torque demanded from the engine as a fraction of the maximum possible torque. If the engine speed falls below the Stall speed, the engine torque is blended to zero. If the engine speed exceeds the Maximum speed, the simulation stops and issues an error message.
Connections F and B are mechanical rotational conserving ports associated with the engine crankshaft and engine block, respectively. Connections P and FC are physical signal output ports through which engine power and fuel consumption rate are reported.
Connections F and B are mechanical rotational conserving ports associated with the engine crankshaft and engine block, respectively. Connections P and FC are physical signal output ports through which engine power and fuel consumption rate are reported.
B) CVT block:- CVT block represent the actual continous variable transmission system. These system having a sub system are as follows:-
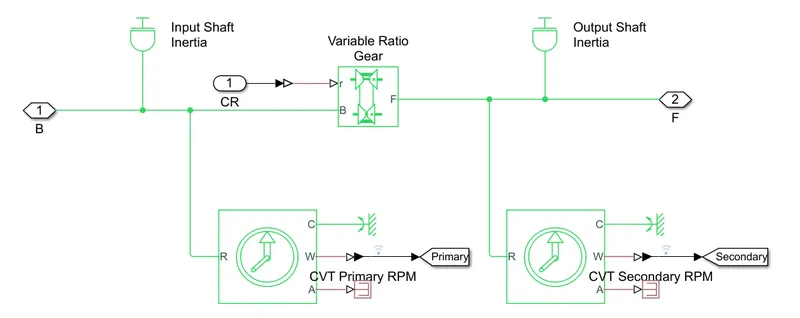
Sub system of CVT :-
Inertia block:- It represent the ideal machanical rotational inertia and it hs one or two mechanical rotational conversing port. The difference is purely graphical, as the ports are rigidly linked. The block positive direction is from its port to the reference point. This means that the inertia torque is positive if the inertia is accelerated in the positive direction. In this two inertia block is used one is input and other is output.
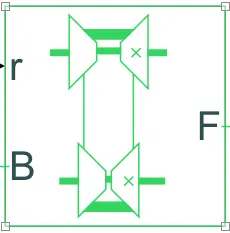
Variable ratio gear:- It represents a variable ratio gearbox such as implemented by mechanical belt CVT, electric, or hydraulic transmissions. The physical signal input r defines the ratio of input to output angular shaft velocities. Connections B (base) and F (follower) are mechanical rotational conserving ports. Specify the relation between base and follower rotation directions with the Output shaft rotates parameter.
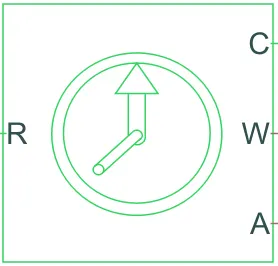
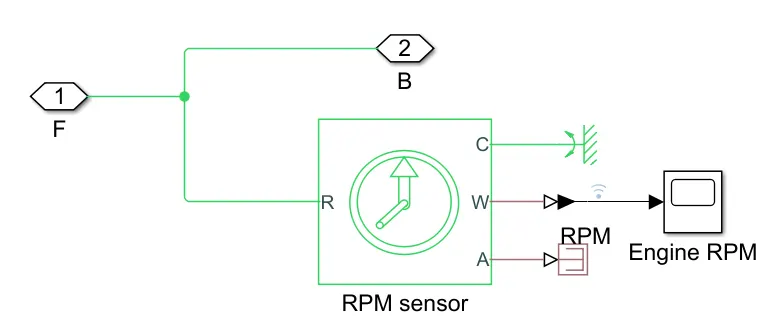
Ideal rotaionalmotion sensor:- This block measures angular velocity or angle in a mechanical rotational network. The sensor is ideal since it does not account for inertia, friction, delays, energy consumption, and so on.
The physical signal ports W and A report the angular velocity and angle, respectively, of port R relative to port C. The measured angular velocity is positive when the angular velocity at port R is greater than the angular velocity at port C.
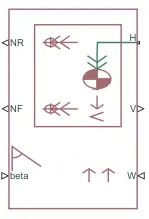
C) Vehicle body:- The vehicle body block represent the complete vehicle aseembly with all the input required to oprate the engine with varying parameter. subsystem of vehicle is explained below:-
Subsystem of vehicle body:-
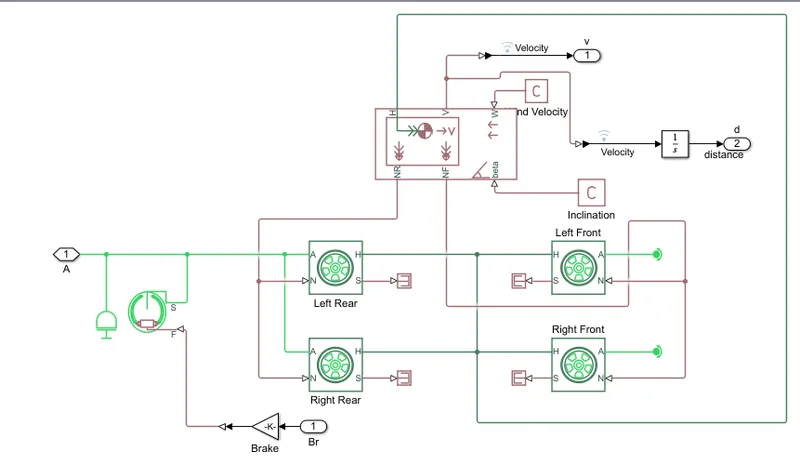
These block represents a two-axle vehicle body in longitudinal motion. The block accounts for body mass, aerodynamic drag, road incline, and weight distribution between axles due to acceleration and road profile. The vehicle can have the same or a different number of wheels on each axle. Optionally include pitch and suspension dynamics or additional variable mass and inertia. The vehicle does not move vertically relative to the ground.
Connection H is the mechanical translational conserving port associated with the horizontal motion of the vehicle body. The resulting traction motion developed by tires should be connected to this port. Connections V, NF, and NR are physical signal output ports for vehicle velocity and front and rear normal wheel forces, respectively. Wheel forces are considered positive if acting downwards. Connections W and beta are physical signal input ports corresponding to headwind speed and road inclination angle, respectively. If variable mass is modeled, the physical signal input ports CG and M are exposed. CG accepts a two- element vector representing the x and y distance offsets from vehicle CG to additional load mass CG. M represents the additional mass. If both variable mass and pitch dynamics are included, the physical signal port J accepts the inertia of the additional mass about its own CG.
Wheel:-
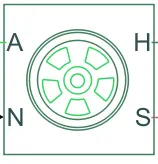
The block represents the longitudinal behavior of a highway tire characterized by the tire Magic Formula. The block is built from Tire-Road Interaction (Magic Formula) and Simscape Foundation Library Wheel and Axle blocks. Optionally, the effects of tire inertia, stiffness, and damping can be included.
Connection A is the mechanical rotational conserving port for the wheel axle. Connection H is the mechanical translational conserving port for the wheel hub through which the thrust developed by the tire is applied to the vehicle. Connection N is a physical signal input port that applies the normal force acting on the tire. The force is considered positive if it acts downwards. Connection S is a physical signal output port that reports the tire slip. Optionally expose physical signal port M by setting Parameterize by to Physical signal Magic Formula coefficients. Physical signal port M accepts a four element vector corresponding to the B, C, D, and E Magic Formula coefficients.
Double-shoe brake:-
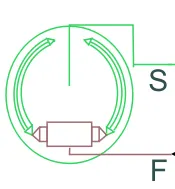
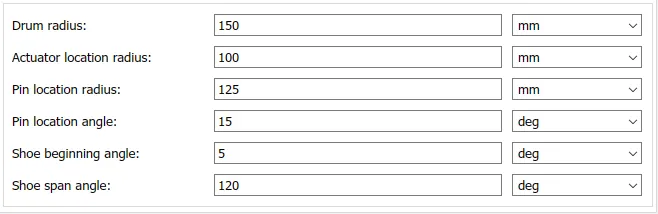
This block represents a brake arranged as two pivoted rigid shoes symmetrically installed inside or outside a drum and operated by one actuator. The actuator force causes the shoes to exert a friction torque on a shaft connected to the drum.
Connection S is a conserving rotational terminal associated with the drum shaft. Connection F is a physical signal port representing the force input to the actuator. Positive force creates friction torque that resists shaft rotation. Optionally include thermal effects and expose thermal conserving port H by setting Thermal port to Model.
Parameter :-
D) Engine sensor:- This sensor is used to sense the output value of generic engine to the CVT. The subsytem of block consist of two PMC port onefor rotational sensor and scopeb to display the change in value of speed due to increasing and decrasing throttle. The terminator and mechanical reference is connect to C and A port of sensor.
E) Simple gear:-
This block represents a fixed-ratio gear or gear box. No inertia or compliance is modeled in this block. You can optionally include gear meshing and viscous bearing losses.
Connections B (base) and F (follower) are mechanical rotational conserving ports. Specify the relation between base and follower rotation directions with the Output shaft rotates parameter. Optionally include thermal effects and expose thermal conserving port H by setting Friction model to a temperature-dependent setting.
Working step:- 1) A signal builder block is used to provide the brake and throttle input and CVT ratio to the system. The output of throttle is connected to the engine block and cvt ratio is connected to the cvt block.
2) The output of engine is sense by the sensor which connect to the engine block. the output of Engine sensor block is connect to cvt block.
3) The CVT block takes the input CVT ratio and engine sensor and both input recongnised as per the parameter of engine and provide output to the wheel through the simple gear block attached between them.
4) The power output from simple gear is connect to the vehicle body block where we can check the value of throttling and braking effect and display on the scope for particular effect.
5)Goto and from block and scope attatched to vehicle body to display the performance of vehicle such as throttling and braking speed and velocity.
ATV model with dashboard:- following model represent the simulink model of BAJA ATV using the CTV for power transmission using a dashboard.
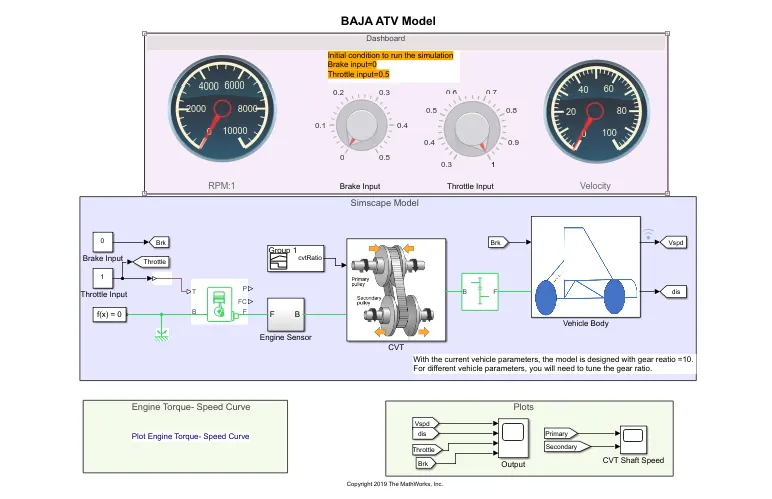
The process is same as above model,the only difference is that the input signal provide by circular gauge instead of signal builder block. The circular guage is act as speedometer where value can be display from the input knob . The knob can be used to set the value of brake and throttle input as per requirement.
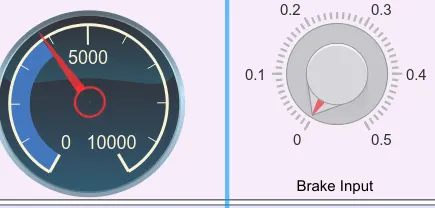
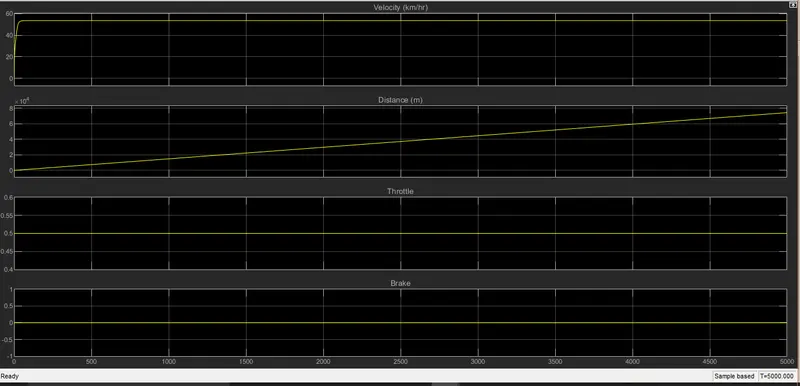
Output result:-The output result of model are as follows:- the value of brake=0 , throttle =0.5
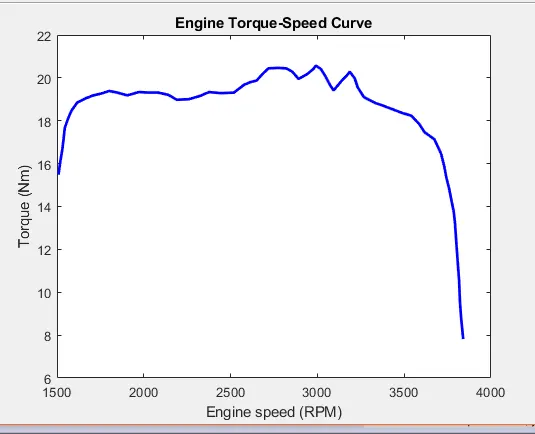
Speed-Torque curve:-
Vehicle-speed curve:-
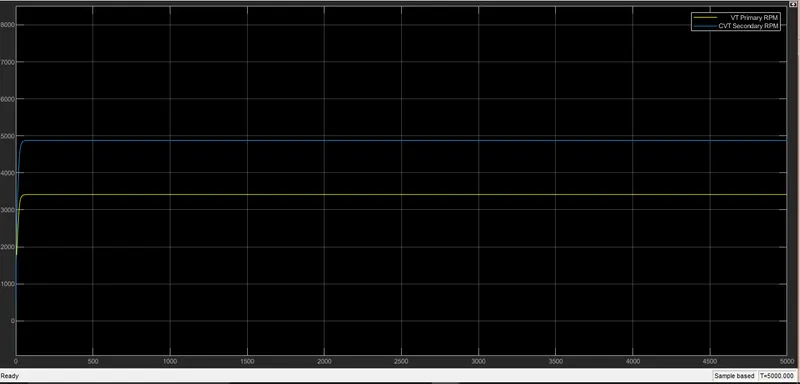
 CVT shaft speed graph:-
Observation:- 1) The torque is high at start because it require for pick up .but as speed incrase then torque reduces.
2) As we see the velocity graph the vehicle speed increase gradually and become constant at certain level.
Simulink model of Atv with a lookup table:-
1) ATV model without dashboard:- Following figure shows the simlink model of BAJA ATV using cvt for power transmission using the look up table.
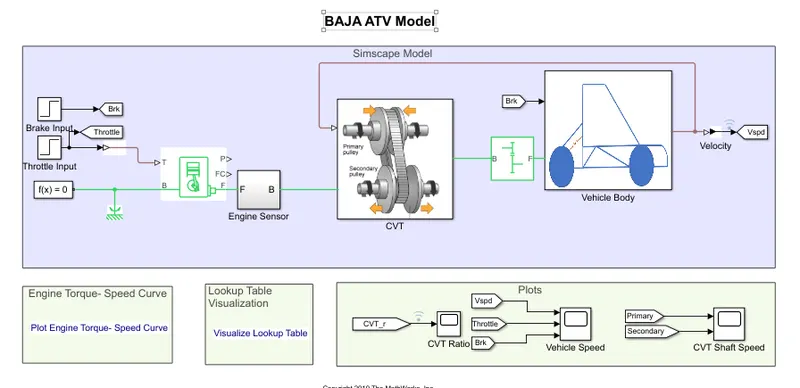
Lookup table:- Look up table is an array of data which provide for input and output value. The lookup table generate the output based on input value using one of the method selected from look up method parameter list. In this model we are using the output signal from the vehicle body as input to CVT.
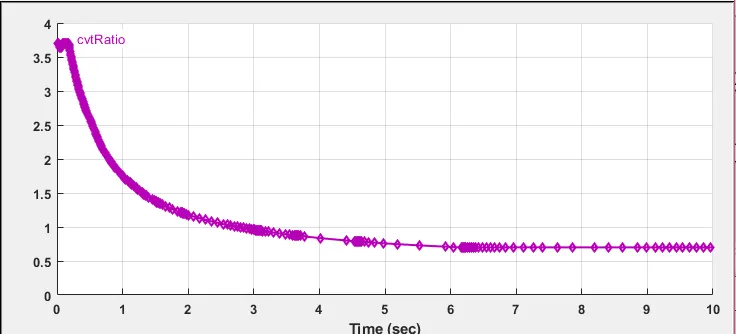
CVT ratio VS vehicle speed:-
0 to 40 the cvt ratio is 3.5 , 40 to 80 the cvt ratio is drop down to 2.45
80 to 100 the cvt ratio is dropdown to 0.74 , Above 100 cvt ratio is again constant 0.5
The procedure of ATV simulinkmodel is same only difference is that here the look up table is used.
2) ATV model with dashboard:- Following fig shows the simulink modelfor BAJA ATV using the CTV for power transmission using a dashboard along with look up table
The process is same as above model,the only difference is that the input signal provide by circular gauge instead of signal builder block. The circular guage is act as speedometer where value can be display from the input knob . The knob can be used to set the value of brake and throttle input as per requirement.
Output result:-The output result of model with look up table are as follows:-
1) Output vehicle velocity, brake and throttle.
CVT shaft speed graph:- 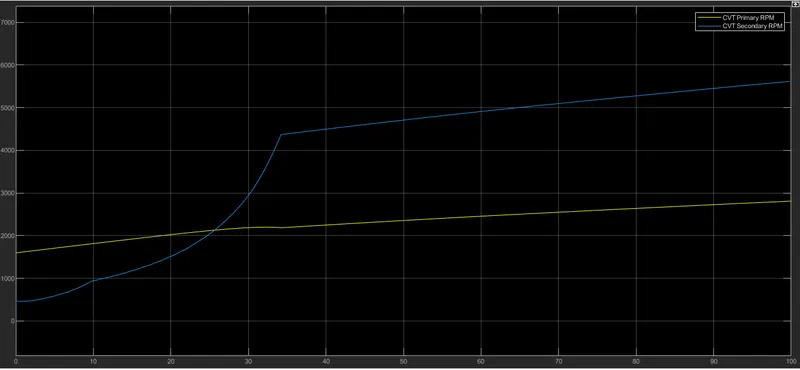 Look up table visualization:-
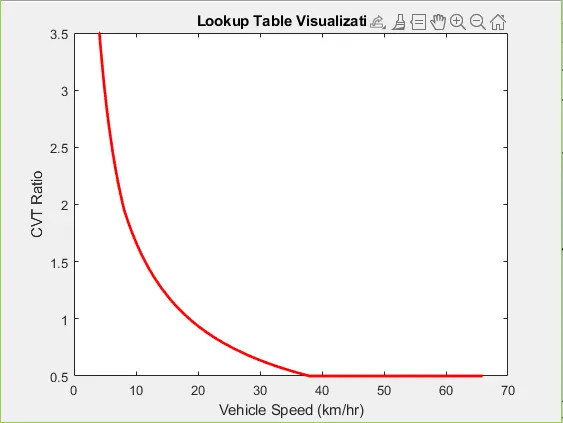
Observation:-
1) Using the look up table, the vehicle speed (velocity) increases gradually and take somtime going for constant at certain level as we see vehicle speed compared with model without lookup table.
2) There is gradual increase in speed at the secondary gear of the CVT as initial speed is picked by driving gear
3) The look up table graph shows the CVT ratio with respect to output power at the wheel.