Week-11 Challenge: Braking
1) Drive cycle :-
A driving cycle is a series of data points representing the speed of a vehicle versus time. Driving cycles are produced by different countries and organizations to assess the performance of vehicles in various ways, as for instance fuel consumption, electric vehicle autonomy and polluting emissions.
From drive cycle, calculating the energy required for braking :-
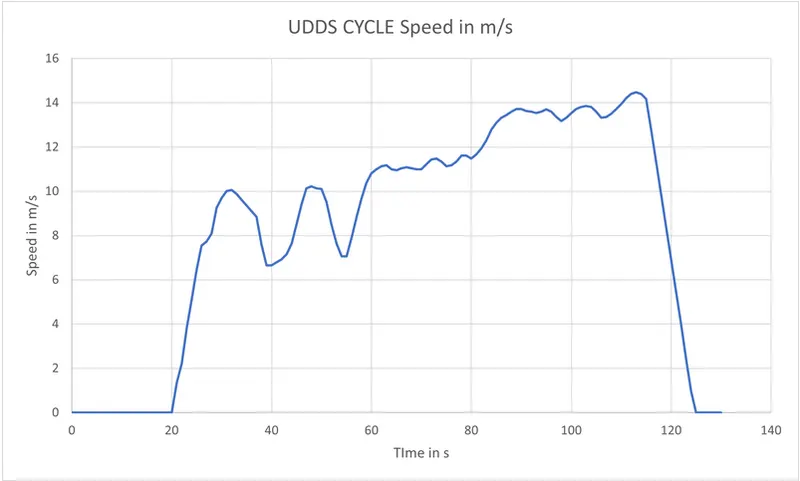
Drive cycle is UDDS cycle which is urban dynamometer drive schedule. The data is taken for 1370s time for our simplicity of calculation we take 150 sec drive cycle time is consider. Speed which is in miles per hour has been converted into meter per second.
Drive cycle is given below :-
The equation for calculating braking energy :- The energy calculate by equation is given as follows ,
E = (1/2) * M * (Vi - Vf) ^2
Where ,
M = Mass of vehicle in Kg
Vi = Initial speed of the vehicle in m/s.
Vf = Final speed of the vehicle
From above drive cycle, we get 10 braking point. The mass of vehicle is constant is about 1500 Kg then the energy required for braking is calculate as follows:-
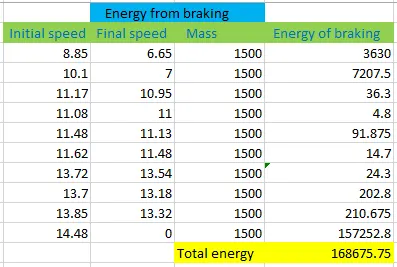
From above calculation the energy required for thr braking is about 16.8 KW.
2) Why electric motor cannot developed the braking torque at high speed ?
Torque speed characteristic of induction motor:-
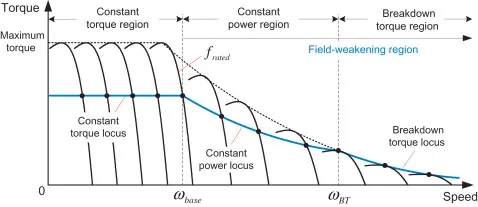
From above curve , we see the three region first one is constant torque region , constant second is power region , third is breakdown torque region. So at start of motor, the motor ahieved the peak torque till the moment at it reaches the certain speed and after that it start rapidly drop. The reason of dropping the torque of motor because the motor shaft reaching the critical speed.The area motor achieve the peak torque and constant is called constant torque region.
The region where the torque reduce is known as constant power regionas the power generated by motor will be its peak.so the torque produced at constant power region is low this is reason where the motor does not produced braking torque in this region.
How electric brake and mechanical brake co-ordianate:-
There are two types of braking is used electric and mechanical braking system are as follows:-
Electric braking :- In electric braking, the winding of the motor is used to produce the braking torque these braking torque developed during braking operation.these opeation opposes the rotation of shaft and it doing by changing the connection of motor.
Mechanical braking :- In mechanical braking , the frictional force produce between rotating part of wheel and brake drum produce require braking. to achieve these braking various mechanical part are use such as brake lining and brake drum.
Both these method co-ordinate in EV application as follows:-
In an Electric vehicle, at start of the vehicle the friction braking gives the 60 % contribution and regenrative braking give 40 % contribution and speed of vehicle start reduce. After some of the braking time the regenrative braking in role and provide the some of power supply back to the source . As we know the raking torque is very low at high speed at start so friction braking apply brake and slow the speed of vehicle and after that the regenrative braking in which motor act as generator and supply toward the source by producing negative torque.
3) Matlab program to plot the contour of motor speed, torque and efficiency :-
The efficiency map of electric motor is contour plot of torque and speed. In order to model efficiency contour we must consider loss occur in motor. The losses occur in motor are as follows :-
There are two types of losses occur in Motor These losses are,
1) Constant loss
2) Variable loss
Constant loss :-
- Iron or core losses,
- Mechanical losses,
- Brush friction losses
Iron or core losses are further divided into hysteresis and Eddy current loss. Eddy current losses are minimized by using lamination on core. Since by laminating the core, area decreases and hence resistance increases, which results in decrease in eddy current. Hysteresis losses are minimized by using high grade silicon steel. The core losses depend upon frequency of the supply voltage.Mechanical losses occur at the bearing and brush friction loss occurs in motor. These losses are zero at start and with increase in speed these losses increases.
Variable loss :-
These losses are also called copper losses. These losses occur due to current flowing in stator and rotor windings. As the load changes, the current flowing in rotor and stator winding also changes and hence these losses also changes. Therefore these losses are called variable losses.
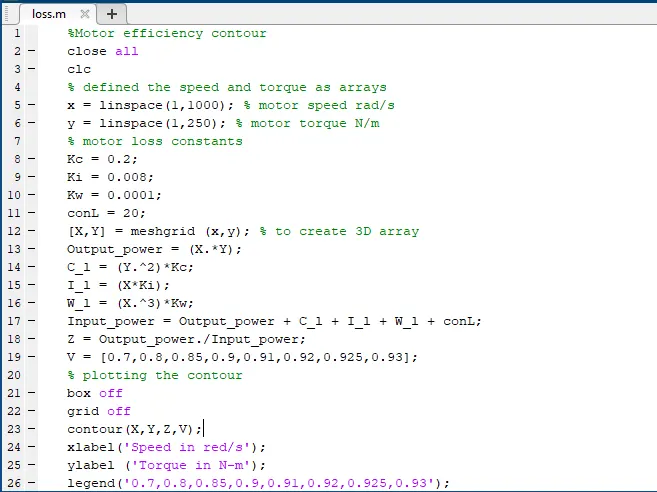
Matlab program to plot efficiency contour:-
The arranging step of program :-
- First the start of every program to close all and clc to clear all the data in workspace.
- The speed and torque are define as Linearly space array using linspace command.
- The constant of motor lossare defined
- The 2D array of speed and torque represent in 3D array using meshgrid command.
- The output power equationis define asproduct of speed and torque.
- The equation motor losses are define based on speed and torque.
- The input power define as addition of output power plus losses.
- Efficiecy define as output power to the input power.
- In order to ploy contour different range of efficiency are givenfrom 0.7 to 0.93.
- Plot the contour graph by contour command.
Result :-
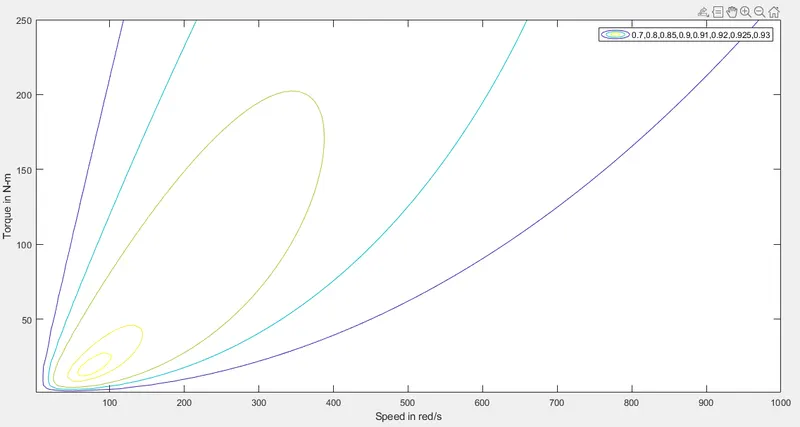
From the graph we observe when speed torque varies the as efficiency increases. at 70% efficiency , the torque at reaches it's peak value 250 N-m at dark blue line and vehicle speed is very low but when speed increase the torque decrease.