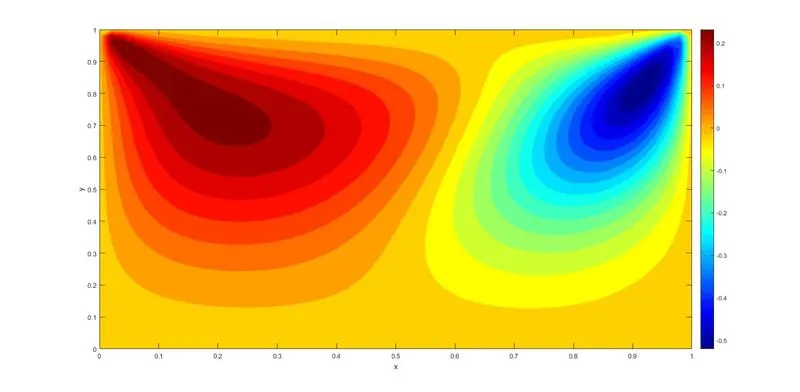
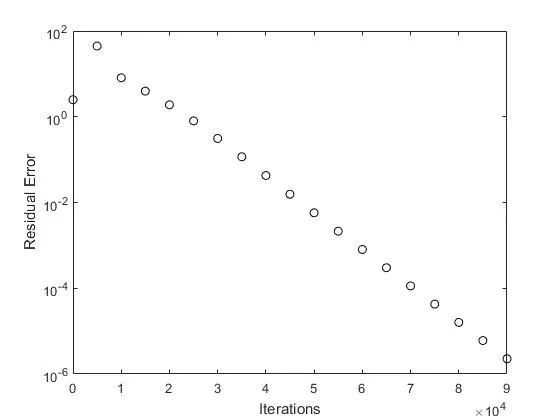
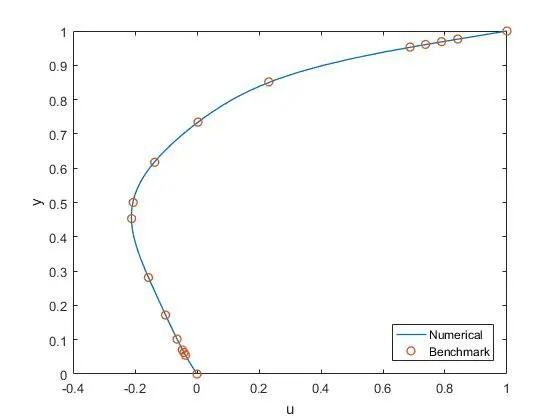
Artificial Compressibility Method in MATLAB
Computational Fluid Dynamics :
The term computational refers to one of the pathways to solve the fluid flow equations. the other possible pathways are experimental fluid dynamics and theoretical fluid dynamics. In experimental fluid dynamics, various experimental techniques are employed to determine the fluid flow phenomena. Theoretical fluid dynamics also refers to analytical fluid dynamics where we mathematically solve the governing equations to achieve fluid flow solution. In computational fluid dynamics, various numerical techniques are employed to simulate the flow of fluid using computers.
Fluid: Any material that cannot resist the flow of shear stress is called fluid. All Liquids and Gases are referred to as Fluids.
Dynamics: to determine both the kinematics parameters such as velocity, acceleration and the effect these parameters causes such as Force (Lift, Drag, Pressure forces, etc)
Computational fluid dynamics allows estimation of all flow-related phenomena using computers. This helps solve complex fluid flow phenomena and results can be obtained in no time with less cost than experimental technique.
Governing Equations :
2D incompressible flow:
Conservation of Mass :
`(delu)/(delx) + (delv)/(dely) = 0`
Conservation of Momentum :
`(delu)/(delt) + u(delu)/(delx) + v(delu)/(dely) = -1/rho(delp)/(delx)+vartheta((del^2u)/(delx^2)+(del^2u)/(dely^2))+F_x`
`(delv)/(delt) + u(delv)/(delx) + v(delv)/(dely) = -1/rho(delp)/(dely)+vartheta((del^2v)/(delx^2)+(del^2v)/(dely^2))+F_y`
In CFD, these differential equations are converted into Algebraic equations so that they can easily be manipulated. Finite differencing methods are one of the ways to convert them.
The fluid flow is governed using
1. Continuity Equation :
`(delu)/(delx)+ (delv)/(dely) = 0`
2. Momentum Equation:
x - momentum = `u(delu)/(delx) + v(delu)/(dely) = -(delp)/(delx) + (1/(Re))((del^2u)/(delx^2)+(del^2u)/(dely^2))`
y - momentum = `u(delv)/(delx) + v(delv)/(dely) = -(delp)/(dely) + (1/(Re))((del^2v)/(delx^2)+(del^2v)/(dely^2))`
To solve the problem in Artificial compressibility method, artificial compressibility is introduced in to the continuity equation. Using that pressure field can be solved.
Steady-state incompressible Navier stokes equations
`1/delta((delp)/(delt))+``(delu)/(delx)+ (delv)/(dely) = 0`
x - momentum = `(delu)/(delt)` + `u(delu)/(delx) + v(delu)/(dely) = -(delp)/(delx) + (1/(Re))((del^2u)/(delx^2)+(del^2u)/(dely^2))`
SIMPLE Algorithm :
clear all
close all
clc

%% Defining the problem domain
n_points = 51; % no_of_points
dom_length = 1;
h = dom_length/(n_points-1);
x = 0:h:dom_length; %X domain span
y = 0:h:dom_length; %Y domain span
Re = 1000; %Reynolds number
nu = 1/Re;
% Under-relaxation factors
alpha = 0.01;
alpha_p = 0.8;
%% Initializing the variables
%Final collocated variables
u_final(n_points,n_points)=0;
v_final(n_points,n_points)=0;
p_final(n_points,n_points)=1;
u_final(1,:) = 1;

%Staggered variables
u(n_points+1,n_points)=0;
u_star(n_points+1,n_points)=0;
d_e(n_points+1,n_points)=0;
v(n_points,n_points+1)=0;
v_star(n_points,n_points+1)=0;
d_n(n_points,n_points+1)=0;
p(n_points+1,n_points+1)=1;
p_star(n_points+1,n_points+1)=1;
pc(n_points+1,n_points+1)=0;
b(n_points+1,n_points+1)=0;
u(1,:)=2;

u_new(n_points+1,n_points)=0;
v_new(n_points,n_points+1)=0;
p_new(n_points+1,n_points+1)=1;
u_new(1,:)=2;

%% Solving the governing equations
error = 1;
iterations = 0;
error_req = 1e-7; %final required error residual
figure(1); %for error monitoring

while error > error_req
    % x-momentum eq. - Interior
    for i = 2:n_points
        for j = 2:n_points - 1
            u_E = 0.5*(u(i,j) + u(i,j+1));
            u_W = 0.5*(u(i,j) + u(i,j-1));
            v_N = 0.5*(v(i-1,j) + v(i-1,j+1));
            v_S = 0.5*(v(i,j) + v(i,j+1));

            a_E = -0.5*u_E*h + nu;
            a_W = 0.5*u_W*h + nu;
            a_N = -0.5*v_N*h + nu;
            a_S = 0.5*v_S*h + nu;

            a_e = 0.5*u_E*h - 0.5*u_W*h + 0.5*v_N*h - 0.5*v_S*h + 4*nu;

            A_e = -h;
            d_e(i,j) = A_e/a_e;

            u_star_mid = (a_E*u(i,j+1) + a_W*u(i,j-1) + a_N*u(i-1,j) + a_S*u(i+1,j))/a_e + d_e(i,j)*(p(i,j+1) - p(i,j));
            u_star(i,j) = (1-alpha)*u(i,j) + alpha*u_star_mid;
        end
    end

    % x-momentum eq. - Boundary
    u_star(1,:) = 2 - u_star(2,:);
    u_star(n_points + 1,:) = -u_star(n_points,:);
    u_star(2:n_points,1) = 0;
    u_star(2:n_points,n_points) = 0;

    % y-momentum eq. - Interior
    for i = 2:n_points - 1
        for j = 2:n_points
            u_E = 0.5*(u(i,j) + u(i+1,j));
            u_W = 0.5*(u(i,j-1) + u(i+1,j-1));
            v_N = 0.5*(v(i-1,j) + v(i,j));
            v_S = 0.5*(v(i,j) + v(i+1,j));

            a_E = -0.5*u_E*h + nu;
            a_W = 0.5*u_W*h + nu;
            a_N = -0.5*v_N*h + nu;
            a_S = 0.5*v_S*h + nu;

            a_n = 0.5*u_E*h - 0.5*u_W*h + 0.5*v_N*h - 0.5*v_S*h + 4*nu;

            A_n = -h;
            d_n(i,j) = A_n/a_n;

            v_star_mid = (a_E*v(i,j+1) + a_W*v(i,j-1) + a_N*v(i-1,j) + a_S*v(i+1,j))/a_n + d_n(i,j)*(p(i,j) - p(i+1,j));
            v_star(i,j) = (1-alpha)*v(i,j) + alpha*v_star_mid;
        end
    end

    % y-momentum eq. - Boundary
    v_star(:,1) = -v_star(:,2);
    v_star(:,n_points + 1) = -v_star(:,n_points);
    v_star(1,2:n_points) = 0;
    v_star(n_points,2:n_points) = 0;

    % Zeroing the corrections to begin with
    pc(1:n_points+1,1:n_points+1)=0;

    % Continuity equation a.k.a. pressure correction - Interior
    for i = 2:n_points
        for j = 2:n_points
            a_E = -d_e(i,j)*h;
            a_W = -d_e(i,j-1)*h;
            a_N = -d_n(i-1,j)*h;
            a_S = -d_n(i,j)*h;
            a_P = a_E + a_W + a_N + a_S;
            b(i,j) = -(u_star(i,j) - u_star(i,j-1))*h + (v_star(i,j) - v_star(i-1,j))*h;

            pc(i,j) = (a_E*pc(i,j+1) + a_W*pc(i,j-1) + a_N*pc(i-1,j) + a_S*pc(i+1,j) + b(i,j))/a_P;
        end
    end

    % Correcting the pressure field
    for i = 2:n_points
        for j = 2:n_points
            p_new(i,j) = p(i,j) + alpha_p*pc(i,j);
        end
    end

    % Continuity eq. - Boundary
    p_new(1,:) = p_new(2,:);
    p_new(n_points + 1,:) = p_new(n_points,:);
    p_new(:,1) = p_new(:,2);
    p_new(:,n_points + 1) = p_new(:,n_points);

    % Correcting the velocities
    for i = 2:n_points
        for j = 2:n_points - 1
            u_new(i,j) = u_star(i,j) + d_e(i,j)*(pc(i,j+1) - pc(i,j));
        end
    end

    % x-momentum eq. - Boundary
    u_new(1,:) = 2 - u_new(2,:);
    u_new(n_points + 1,:) = -u_new(n_points,:);
    u_new(2:n_points,1) = 0;
    u_new(2:n_points,n_points) = 0;

    for i = 2:n_points - 1
        for j = 2:n_points
            v_new(i,j) = v_star(i,j) + d_n(i,j)*(pc(i,j) - pc(i+1,j));
        end
    end

    % y-momentum eq. - Boundary
    v_new(:,1) = -v_new(:,2);
    v_new(:,n_points + 1) = -v_new(:,n_points);
    v_new(1,2:n_points) = 0;
    v_new(n_points,2:n_points) = 0;


    % Continuity residual as error measure
    error = 0;
    for i = 2:n_points
        for j = 2:n_points
            error = error + abs(b(i,j));
        end
    end

    % Error monitoring after every few timesteps
    if(rem(iterations, 1000)) == 0
       figure(1);
       semilogy(iterations, error, '-ko')
       hold on
       xlabel('Iterations')
       ylabel('Residual Error')
    end

    % Finishing the iteration
    u = u_new;
    v = v_new;
    p = p_new;
    iterations = iterations + 1;

end

% After the converged solution, we map the staggered variables to
% collocated variables
for i = 1:n_points
    for j = 1:n_points
        u_final(i,j) = 0.5*(u(i,j) + u(i+1,j));
        v_final(i,j) = 0.5*(v(i,j) + v(i,j+1));
        p_final(i,j) = 0.25*(p(i,j) + p(i,j+1) + p(i+1,j) + p(i+1,j+1));
    end
end

%% Centreline u validation - Comparison with benchmark
% figure(11);
% plot(u_final(:,(n_points+1)/2),1-y, 'LineWidth', 1)
%
% tab_data = xlsread('plot_u_y_Ghia100.csv', 'A2:B18');
% y_ghia = tab_data(:,1);
% u_ghia = tab_data(:,2);
%
% figure(11); hold on
% plot(u_ghia, y_ghia, 'o', 'LineWidth', 1)
% xlabel('u')
% ylabel('y')
% legend('Numerical', 'Benchmark', 'location', 'southeast')

%% Contour and vector visuals.
x_dom = ((1:n_points)-1).*h;
y_dom = 1-((1:n_points)-1).*h;
[X,Y] = meshgrid(x_dom,y_dom);
figure(21);
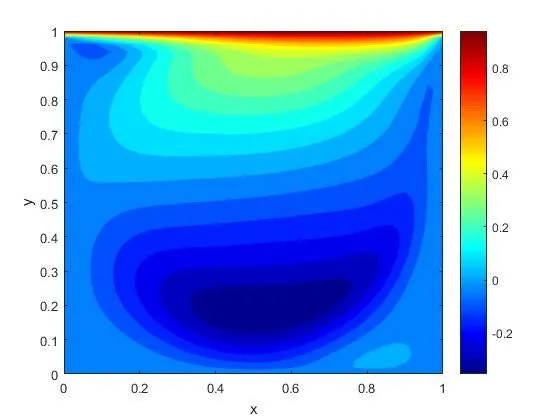
contourf(X,Y,u_final, 21, 'LineStyle', 'none')
colorbar
colormap('jet')
xlabel('x')
ylabel('y')

figure(22);
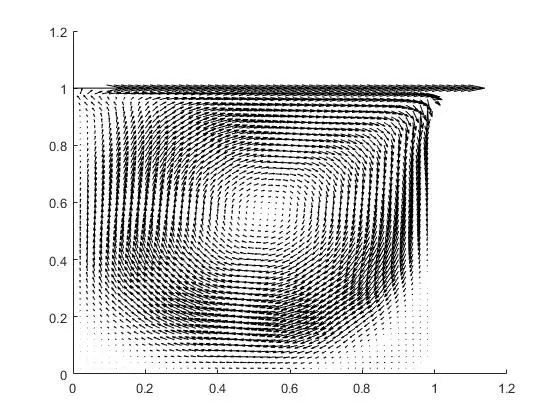
hold on
quiver(X, Y, u_final, v_final, 5, 'k')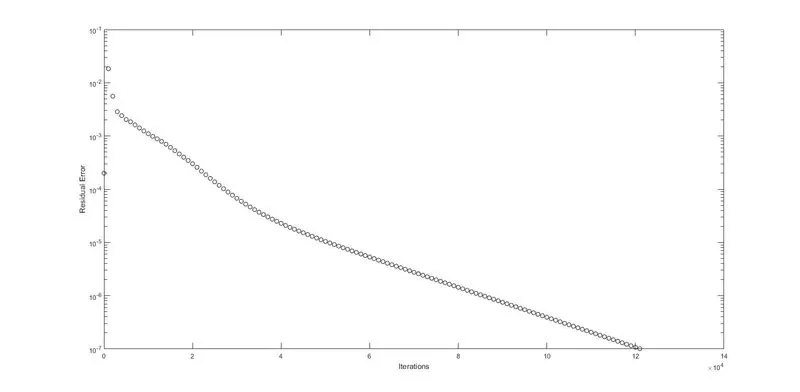
Artificial Compressibility Method :
clear all
close all
clc

%% Defining the Domain Problem

n_points = 51 ; % Number of points
dom_length = 1; % Domain length
h = dom_length/(n_points - 1); % Grid spacing
x = 0:h:dom_length; % X - coordinates
y = 0:h:dom_length; % Y - coordinates
dt = 0.001; % Time advancement
Re = 100; % Reynolds number
delta = 1.5; % Artificial compressibility


%% Initializing the variables

% Final collocated variables

u_final(n_points,n_points) = 0;
v_final(n_points,n_points) = 0;
p_final(n_points,n_points) = 0;
u_final(1,:) = 1;

% Staggered variables
u(n_points+1, n_points) = 0;
v(n_points, n_points+1) = 0;
p(n_points+1 , n_points+1) = 1;
u(1,:) = 2;


u_new(n_points+1, n_points) = 0;
v_new(n_points, n_points+1) = 0;
p_new(n_points+1 , n_points+1) = 1;
u_new(1,:) = 2;

%% Solving the Governing Equations
error = 1;
iterations = 0;
error_req = 1e-6; % final required error residual
figure(1); % for error monitoring

while error > error_req
    % x-momentum eq. - Interior
    for i = 2:n_points
        for j = 2:n_points - 1
            pressure = -(p(i,j+1) - p(i,j))/h;
            diffusion = (1/Re)*((u(i+1,j) - 2*u(i,j) + u(i-1,j))/(h*h) + (u(i,j+1) - 2*u(i,j) + u(i,j-1))/(h*h));
            advection_x = ((0.5*(u(i,j)+u(i,j+1)))^2 - (0.5*(u(i,j)+u(i,j-1)))^2)/h;
            advection_y = ((0.25*(u(i,j)+u(i-1,j))*(v(i-1,j)+v(i-1,j+1))) - (0.25*(u(i,j)+u(i+1,j))*(v(i,j)+v(i,j+1))))/h;
            u_new(i,j) = u(i,j) + dt*(diffusion - advection_x - advection_y + pressure);
        end
    end

    % x-momentum eq. - Boundary
    u_new(1,:) = 2 - u_new(2,:);
    u_new(n_points + 1,:) = -u_new(n_points,:);
    u_new(2:n_points,1) = 0;
    u_new(2:n_points,n_points) = 0;

    % y-momentum eq. - Interior
    for i = 2:n_points - 1
        for j = 2:n_points
            pressure = -(p(i,j) - p(i+1,j))/h;
            diffusion = (1/Re)*((v(i+1,j) - 2*v(i,j) + v(i-1,j))/(h*h) + (v(i,j+1) - 2*v(i,j) + v(i,j-1))/(h*h));
            advection_y = ((0.5*(v(i,j)+v(i-1,j)))^2 - (0.5*(v(i,j)+v(i+1,j)))^2)/h;
            advection_x = ((0.25*(u(i,j)+u(i+1,j))*(v(i,j)+v(i,j+1))) - (0.25*(u(i,j-1)+u(i+1,j-1))*(v(i,j)+v(i,j-1))))/h;
            v_new(i,j) = v(i,j) + dt*(diffusion - advection_x - advection_y + pressure);
        end
    end

    % y-momentum eq. - Boundary
    v_new(:,1) = -v_new(:,2);
    v_new(:,n_points + 1) = -v_new(:,n_points);
    v_new(1,2:n_points) = 0;
    v_new(n_points,2:n_points) = 0;

    % Continuity eq. - Interior
    for i = 2:n_points
        for j = 2:n_points
            p_new(i,j) = p(i,j) - delta*dt*(u(i,j) - u(i,j-1) + v(i-1,j) - v(i,j))/h;
        end
    end

    % Continuity eq. - Boundary
    p_new(1,:) = p_new(2,:);
    p_new(n_points + 1,:) = p_new(n_points,:);
    p_new(:,1) = p_new(:,2);
    p_new(:,n_points + 1) = p_new(:,n_points);

    % Continuity residual as error measure
    error = 0;
    for i = 2:n_points - 1
        for j = 2:n_points - 1
            error = error + abs((u_new(i,j) - u_new(i,j-1) + v_new(i-1,j) - v_new(i,j))/h);
        end
    end

    % Error monitoring after every few timesteps
    if(rem(iterations, 5000)) == 0
       figure(1);
       semilogy(iterations, error, '-ko')
       hold on
       xlabel('Iterations')
       ylabel('Residual Error')
    end

    % Finishing the iteration
    u = u_new;
    v = v_new;
    p = p_new;
    iterations = iterations + 1;
end

% After the converged solution, we map the staggered variables to
% collocated variables
for i = 1:n_points
    for j = 1:n_points
        u_final(i,j) = 0.5*(u(i,j) + u(i+1,j));
        v_final(i,j) = 0.5*(v(i,j) + v(i,j+1));
        p_final(i,j) = 0.25*(p(i,j) + p(i,j+1) + p(i+1,j) + p(i+1,j+1));
    end
end

%% Centreline u validation - Comparison with benchmark
figure(11);
plot(u_final(:,(n_points+1)/2),1-y, 'LineWidth', 1)

tab_data = xlsread('plot_u_y_Ghia100.csv', 'A2:B18');
y_ghia = tab_data(:,1);
u_ghia = tab_data(:,2);

figure(11); hold on
plot(u_ghia, y_ghia, 'o', 'LineWidth', 1)
xlabel('u')
ylabel('y')
legend('Numerical', 'Benchmark', 'location', 'southeast')

%% Contour and vector visuals.
x_dom = ((1:n_points)-1).*h;
y_dom = 1-((1:n_points)-1).*h;
[X,Y] = meshgrid(x_dom,y_dom);
figure(21);
contourf(X,Y,v_final, 21, 'LineStyle', 'none')
colorbar
colormap('jet')
xlabel('x')
ylabel('y')

figure(22);
hold on
quiver(X, Y, u_final, v_final, 5, 'k')