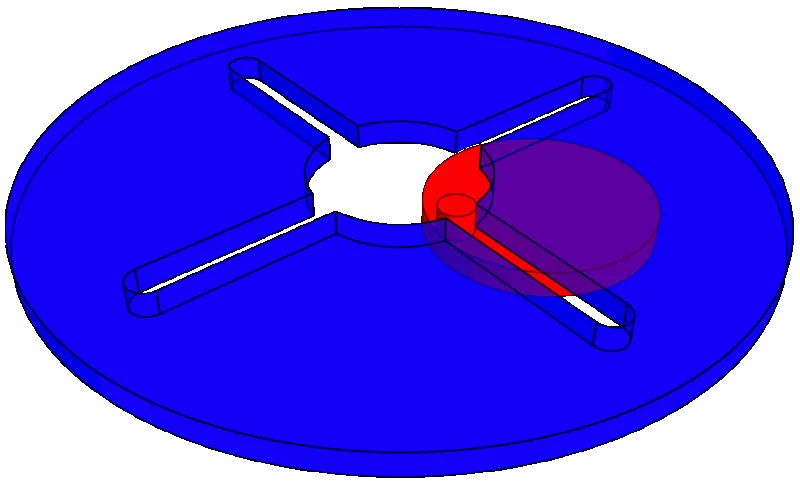
Internal Geneva Mechanism
AIM:- Internal Geneva Mechanism
OBJECTIVE:-
In this Project, Creating a 3D part of Driver and Driven from scratch and will be setting up the motion analysis for an Internal Geneva Mechanism at 10rpm and 20rpm with 60 frames and 120 frames respectively.
Then obtaining the plots of Contact force (between driving and the driven wheel) as a function of time, Angular Displacement of the driven wheel, and plot of the driver wheel's angular velocity.
INTRODUCTION:-
Multibody dynamics is an advanced set of tools for designing and optimizing multibody structural mechanics systems using Kinematics of Mechanisms.
You will be using a software called Motionsolve/ Motionview from Altair HyperWorks, to simulate the kinematic analysis of various mechanisms.
Geneva Mechanism:-
Geneva mechanism, also called Geneva Stop, one of the most commonly used devices for producing intermittent rotary motion, characterized by alternate periods of motion and rest with no reversal in direction.
CONTACT FORCE:-
contact force is a force that is applied by objects in contact with each other.
The contact force acts on a point of direct contact between the two objects.
This force can either be continuous as a continuous force or can be momentary in the form of an impulse.
ANGULAR DISPLACEMENT:-
Angular displacement is defined as the angle in radians (degrees, revolutions) through which a point or line has been rotated in a specified sense about a specified axis.
It is the angle of the movement of a body in a circular path.
A body is generally considered rigid when the separations between all the particles remain constant throughout the body's motion, so for example parts of its mass are not flying off.
In a realistic sense, all things can be deformable, however, this impact is minimal and negligible.
Thus the rotation of a rigid body over a fixed axis is referred to as rotational motion.
The Present study is to analyze the motion study of an internal geneva mechanism and plot various graphs and compare the plots and explain the results.
Geometry and Modelling:-
Geometry of Driver wheel:-
Driven Wheel:-
.The parts are assembled determined using the drawings:-
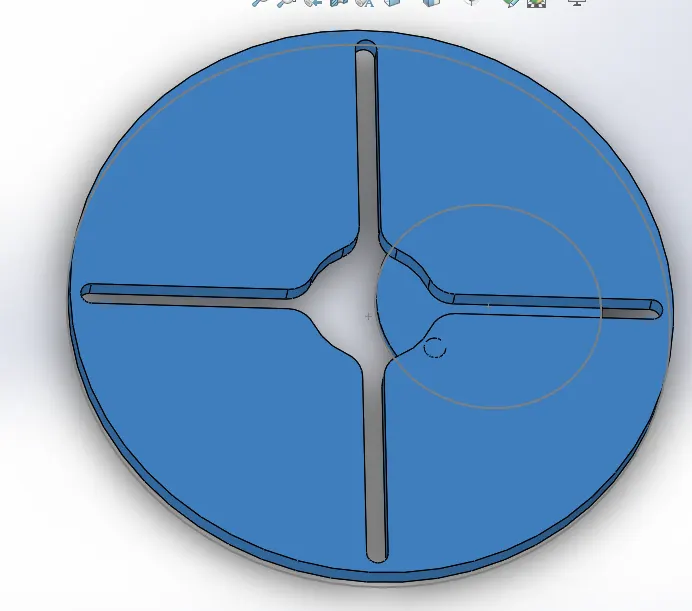
.3D model is developed based on given drawings
The motion of the wheels is to be constrained to rotation about their axes.
A motor is to be defined at the axis of driving wheel at required rpm.
Contact has to be established between the wheels and the simulation is ready to be run.
After running the simulation required plots are to be extracted.
Precision contact available in the settings can be used to determine the contact forces more accurately.
Precise Contact For 20 Rpm
Precise Contact For 10 Rpm
Driver Wheel Output
Angular Displacement Driver wheel
Angular velocity at 10 rpm
- Angular velocity at 20 rpm
Animation Video of Internal Geneva Mechanism